


Servo Reversers
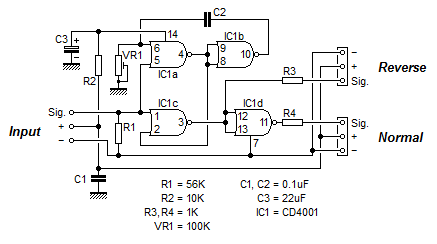
Description: This project describes a simple servo reverser that can be inexpensively constructed using a CD4001 NOR gate, four resistors, three capacitors, and one variable potentiometer (see schematic below).
The proposed circuit utilizes the CD4001 NOR gate as the primary component for reversing the servo direction. The NOR gate is a versatile digital logic gate that outputs a low signal when any of its inputs are high. By configuring the NOR gate in a specific arrangement, it can effectively control the polarity of the signal sent to the servo motor, thus reversing its direction of rotation.
The four resistors in the circuit serve multiple purposes, including biasing the inputs of the NOR gate and setting the voltage levels for proper operation. The values of these resistors can be selected based on the desired response time and sensitivity of the servo control. Typically, resistor values in the range of 1kΩ to 10kΩ are suitable for this application.
The three capacitors are employed to filter noise and stabilize the voltage levels in the circuit. They can also be used to create timing delays, influencing how quickly the servo responds to input changes. Capacitor values may vary, but common choices include 10µF for bulk capacitance and smaller values such as 0.1µF for high-frequency noise filtering.
The variable potentiometer is a crucial component that allows for manual adjustment of the input signal. By varying the resistance, the user can control the threshold at which the servo reverses direction. This feature adds versatility to the circuit, enabling it to be tailored to specific applications.
The overall design emphasizes simplicity and cost-effectiveness, making it accessible for hobbyists and those looking to experiment with servo control systems. The schematic diagram, which should be referenced for precise connections and component placement, illustrates how these components are interconnected to achieve the desired functionality. Proper assembly and testing of the circuit will ensure reliable operation of the servo reverser.This projects will describe a simple Servo Reverser that can be cheaply built using a CD4001 NOR gate, 4 resistors, 3 capacitors and one variable potentiometer (see schematic below).
The proposed circuit utilizes the CD4001 NOR gate as the primary component for reversing the servo direction. The NOR gate is a versatile digital logic gate that outputs a low signal when any of its inputs are high. By configuring the NOR gate in a specific arrangement, it can effectively control the polarity of the signal sent to the servo motor, thus reversing its direction of rotation.
The four resistors in the circuit serve multiple purposes, including biasing the inputs of the NOR gate and setting the voltage levels for proper operation. The values of these resistors can be selected based on the desired response time and sensitivity of the servo control. Typically, resistor values in the range of 1kΩ to 10kΩ are suitable for this application.
The three capacitors are employed to filter noise and stabilize the voltage levels in the circuit. They can also be used to create timing delays, influencing how quickly the servo responds to input changes. Capacitor values may vary, but common choices include 10µF for bulk capacitance and smaller values such as 0.1µF for high-frequency noise filtering.
The variable potentiometer is a crucial component that allows for manual adjustment of the input signal. By varying the resistance, the user can control the threshold at which the servo reverses direction. This feature adds versatility to the circuit, enabling it to be tailored to specific applications.
The overall design emphasizes simplicity and cost-effectiveness, making it accessible for hobbyists and those looking to experiment with servo control systems. The schematic diagram, which should be referenced for precise connections and component placement, illustrates how these components are interconnected to achieve the desired functionality. Proper assembly and testing of the circuit will ensure reliable operation of the servo reverser.This projects will describe a simple Servo Reverser that can be cheaply built using a CD4001 NOR gate, 4 resistors, 3 capacitors and one variable potentiometer (see schematic below).
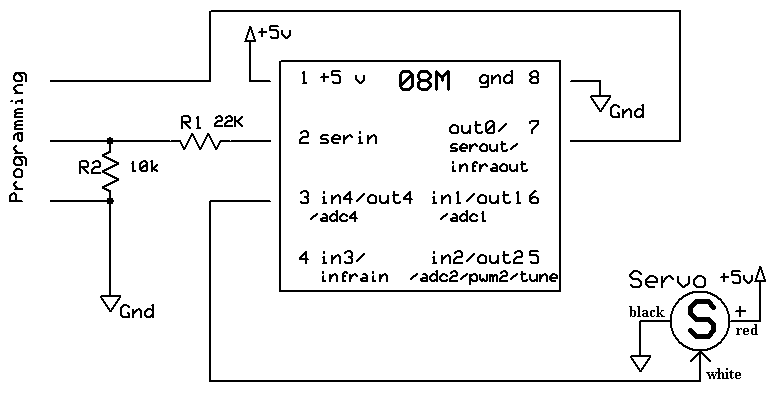
Animation with Servos
A servo consists of a small motor and gear mechanism that rotates a shaft to a precise location and maintains that position. The image displays a typical servo with its cover removed. The shaft's position is controlled by a digital...
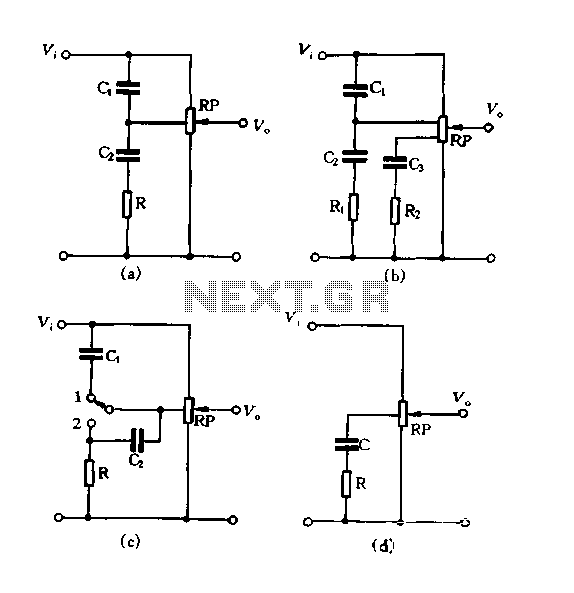
Using tap potentiometer loudness circuit
Figure 1.88 illustrates the loudness control circuit utilizing multiple taps on a potentiometer. In Figure (A), the connection is made between the tap and the potentiometer's input, along with the ground. An RC compensation network is employed, where the slide...
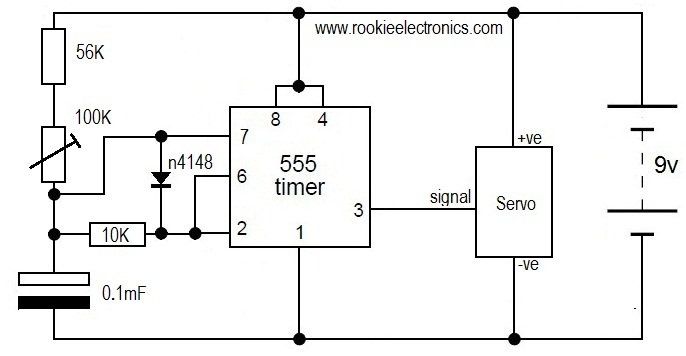
servo speed tester
This is likely the simplest circuit to test a servo. It tests the speed of the servo using a potentiometer to control the speed. By applying a low voltage, such as 4.5V, and adjusting the potentiometer value, the position of...
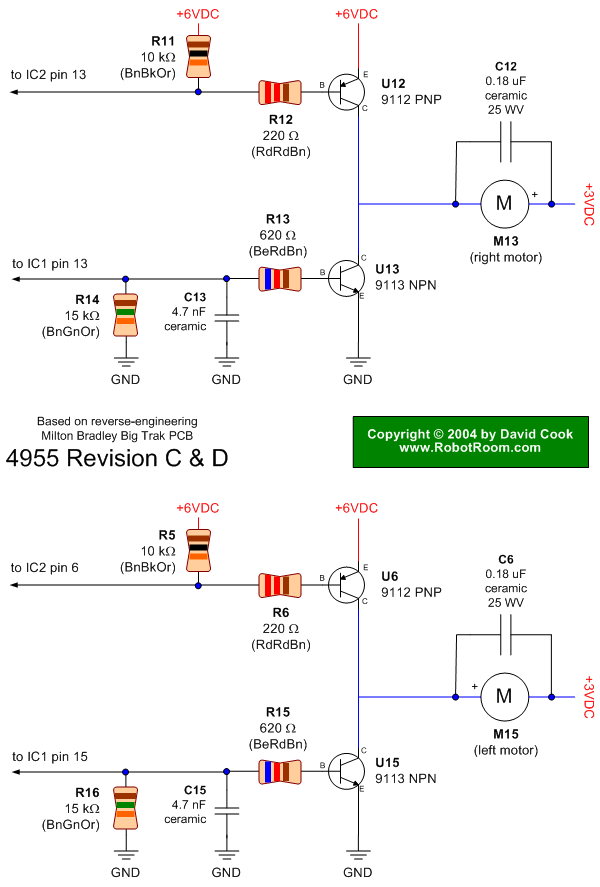
Big Trak Motor Driver Schematic
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...
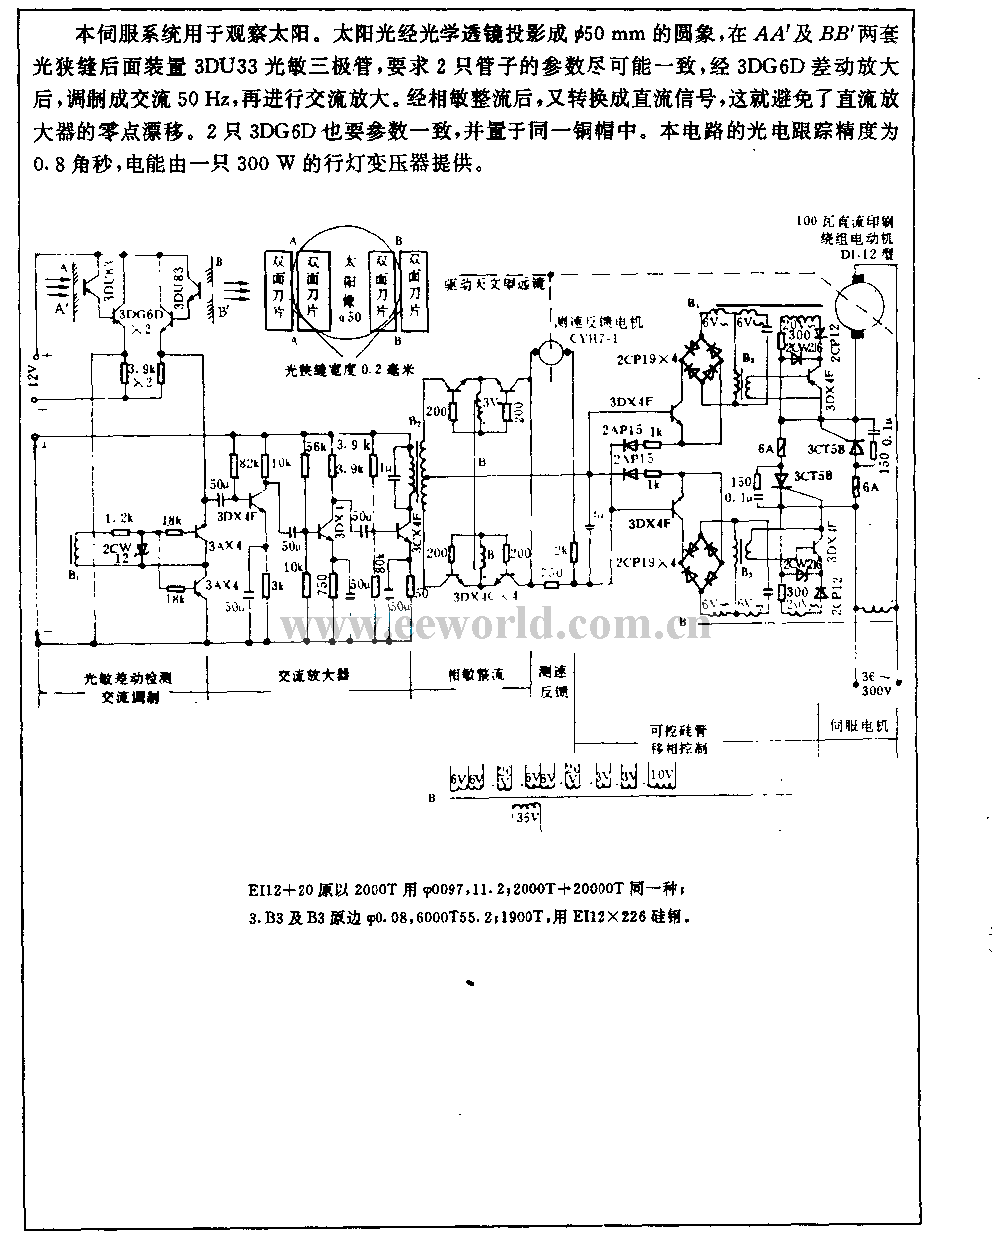
Tracking sun photoelectric servo circuit used in chromospheric telescope
This servo system is designed to track the sun. Sunshine is focused onto a 50mm round image using an optical lens, and a 3DU33 photosensitive transistor is positioned at the light slit of AA' and BB'. It is essential that...
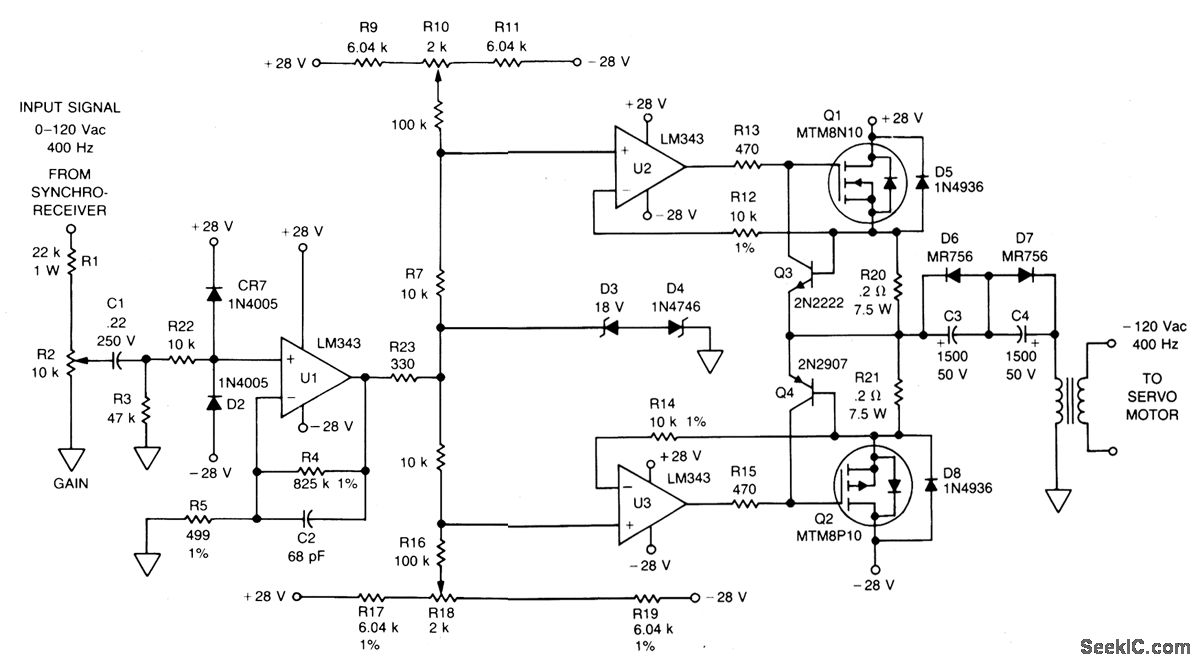
400 Hz SERVO AMPLIFIER
The signal from a synchro receiver or a variable resistive cam follower (potentiometer) is amplified by operational amplifier U1, with its output swing restricted by back-to-back zener diodes D3 and D4. This amplified signal is then fed into operational amplifiers...
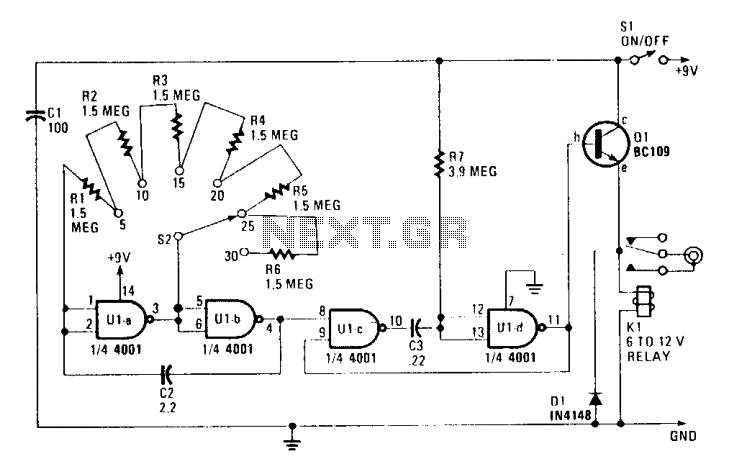
Auto-advance projector
The circuit is constructed using a 4001 quad two-input NOR gate, allowing for switch-selectable auto-advance times of 5, 10, 15, 20, 25, or 30 seconds through the remote control socket of a projector. Ula and Ulb create an astable multivibrator,...
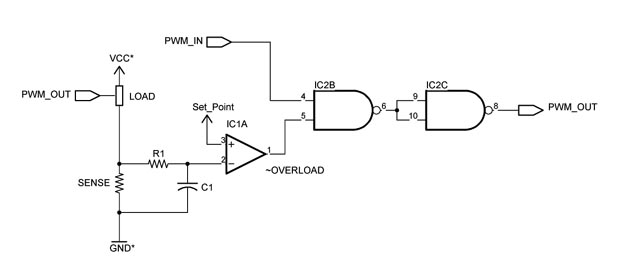
Custom Motor Driver
This chapter was removed from Applied Robotics 2 due to space constraints. It addresses general motor control issues and details the construction of a 5-amp motor driver. The principles discussed can be applied to larger motor controllers. Although commercially available...
Circuits
To prevent soldering errors, students were instructed to place all their resistors on the board first. Once their placements were verified, they could proceed with soldering. Capacitors were next, followed by LEDs and other components. The middle school class demonstrated...