


Motor-tachometer speed control
#dc motor
#tachometer
#speed control
#summing amplifier
#servo loop
#phase lag
#op-amp
#voltage proportional
#response time
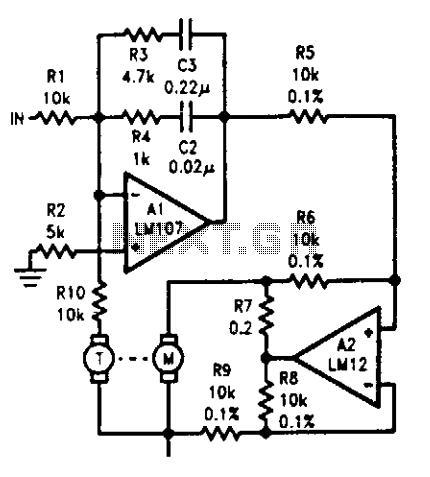
Description: The tachometer, mounted on the same shaft as the DC motor, functions as a generator, producing a DC output voltage that is proportional to the motor's speed. A summing amplifier, labeled as Al, manages its output to ensure that the tachometer voltage is equal to the input voltage but with an opposite polarity. When current is supplied to the motor, the tachometer experiences a 90° phase lag before secondary effects are taken into account. The compensation for Al is engineered to maintain a phase shift of less than 90° across the frequency range where the servo loop reaches unity gain. If the response time is not a critical factor, a power operational amplifier could replace Al to drive the motor directly. Additionally, reducing the break frequencies of the compensation would be necessary. This circuit can also function as a position servo; it requires a voltage that indicates both the direction and magnitude of the motor shaft's displacement from a target position. This error signal is connected to the input, prompting the servo to adjust the output to zero. The tachometer remains essential for generating a phase-correcting rate signal, as the error signal lags the motor drive by 180°.
The described circuit integrates a tachometer with a DC motor to provide feedback on the motor's speed, enabling precise control over its operation. The tachometer generates a DC voltage that reflects the motor's speed, which is essential for closed-loop control in servo systems. The summing amplifier Al plays a crucial role in this feedback mechanism by ensuring that the output voltage from the tachometer is effectively inverted, allowing for proper error correction.
The design of the summing amplifier includes compensation techniques that are vital in maintaining stability within the control loop. By ensuring that the phase shift remains below 90° within the operational frequency range, the system can avoid instability and oscillations that could arise from excessive phase lag. The ability to substitute a power operational amplifier for Al provides flexibility in the design, allowing for direct motor drive when rapid response is less critical.
In the context of position control, the circuit can be adapted to function as a position servo by incorporating a method to measure the displacement of the motor shaft from a predetermined setpoint. This involves generating an error signal that indicates the difference between the actual position and the desired position. The servo system then works to minimize this error, effectively driving the motor to the correct position.
It is important to note that the tachometer's feedback is necessary not only for speed control but also for compensating the phase lag introduced by the error signal. The inherent 180° lag must be countered to ensure that the control system remains responsive and accurate. Therefore, the integration of the tachometer and the summing amplifier is essential for achieving both speed regulation and positional accuracy in servo applications.The tachometer, on the same shaft as the dc motor, is simply a generator. It gives a dc output voltage proportional to the speed of the motor. A summing amplifier, Al, controls its output so that the tachometer voltage equals the input voltage, but of opposite sign. With current drive to the motor, phase lag to the tachometer is 90°, before the second order effects come in.
Compensation on Al is designed to give less than 90° phase shift over the range of frequencies where the servo loop goes through unity gain. Should response time be of less concern, a power op amp could be substituted for Al to drive the motor directly.
Lowering break frequencies of the compensation would, of course, be necessary. The circuit could also be used as a position servo. All that is needed is a voltage indicating the sense and magnitude of the motor shaft displacement from a desired position. This error signal is connected to the input, and the servo works to make it zero. The tachometer is still required to develop a phase-correcting rate signal because the error signal lags the motor drive by 180°.
The described circuit integrates a tachometer with a DC motor to provide feedback on the motor's speed, enabling precise control over its operation. The tachometer generates a DC voltage that reflects the motor's speed, which is essential for closed-loop control in servo systems. The summing amplifier Al plays a crucial role in this feedback mechanism by ensuring that the output voltage from the tachometer is effectively inverted, allowing for proper error correction.
The design of the summing amplifier includes compensation techniques that are vital in maintaining stability within the control loop. By ensuring that the phase shift remains below 90° within the operational frequency range, the system can avoid instability and oscillations that could arise from excessive phase lag. The ability to substitute a power operational amplifier for Al provides flexibility in the design, allowing for direct motor drive when rapid response is less critical.
In the context of position control, the circuit can be adapted to function as a position servo by incorporating a method to measure the displacement of the motor shaft from a predetermined setpoint. This involves generating an error signal that indicates the difference between the actual position and the desired position. The servo system then works to minimize this error, effectively driving the motor to the correct position.
It is important to note that the tachometer's feedback is necessary not only for speed control but also for compensating the phase lag introduced by the error signal. The inherent 180° lag must be countered to ensure that the control system remains responsive and accurate. Therefore, the integration of the tachometer and the summing amplifier is essential for achieving both speed regulation and positional accuracy in servo applications.The tachometer, on the same shaft as the dc motor, is simply a generator. It gives a dc output voltage proportional to the speed of the motor. A summing amplifier, Al, controls its output so that the tachometer voltage equals the input voltage, but of opposite sign. With current drive to the motor, phase lag to the tachometer is 90°, before the second order effects come in.
Compensation on Al is designed to give less than 90° phase shift over the range of frequencies where the servo loop goes through unity gain. Should response time be of less concern, a power op amp could be substituted for Al to drive the motor directly.
Lowering break frequencies of the compensation would, of course, be necessary. The circuit could also be used as a position servo. All that is needed is a voltage indicating the sense and magnitude of the motor shaft displacement from a desired position. This error signal is connected to the input, and the servo works to make it zero. The tachometer is still required to develop a phase-correcting rate signal because the error signal lags the motor drive by 180°.
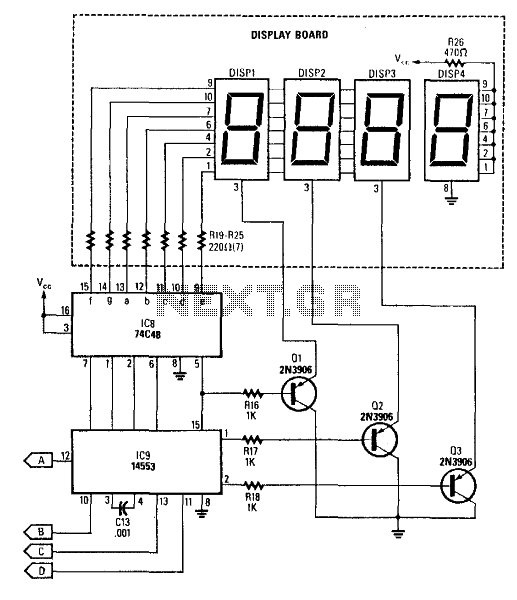
Digital Tachometer Counter
This circuit produces a readout for the digital tachometer circuit. IC9 is a 3-digit LED display driver, counter, and latch. IC8 drives the common-cathode LEDs, which are enabled by Q1, Q2, and Q3. See page 268, Fig. 46-5 for the...
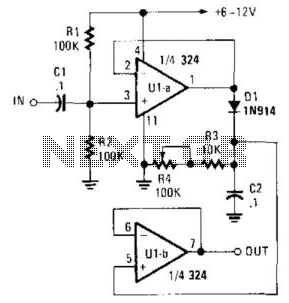
Positive Pulse Pulse Stretcher
A simple pulse stretcher built with two sections of an operational amplifier uses a voltage follower U1A to drive D1 and C2. C2 charges to the peak value of the pulse voltage. Resistors R3 and R4 determine the discharge time...
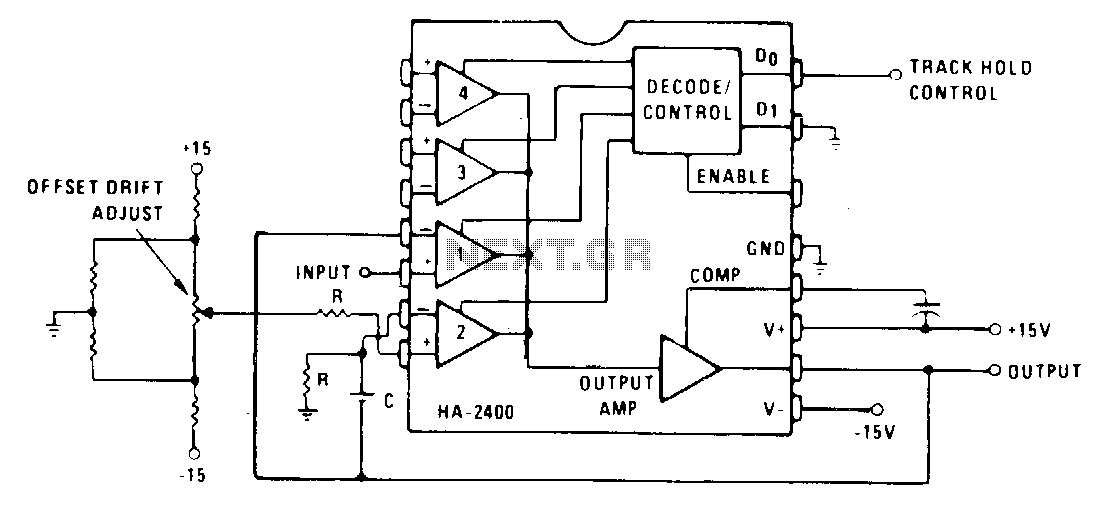
Track-and-hold-sample-and-hold
Channel 1 is configured as a voltage follower and is activated during the track/sample time. If the product of R and C is sufficiently short compared to the period of maximum output frequency or sample time, then C will charge...
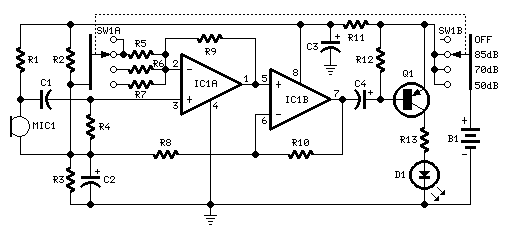
Room Noise Detector Schematic Circuit
This circuit is designed to signal the exceeding of a fixed threshold in room noise through a flashing LED. Three fixed levels are selectable: 50, 70, and 85 dB. Two operational amplifiers provide the necessary gain for sounds captured by...
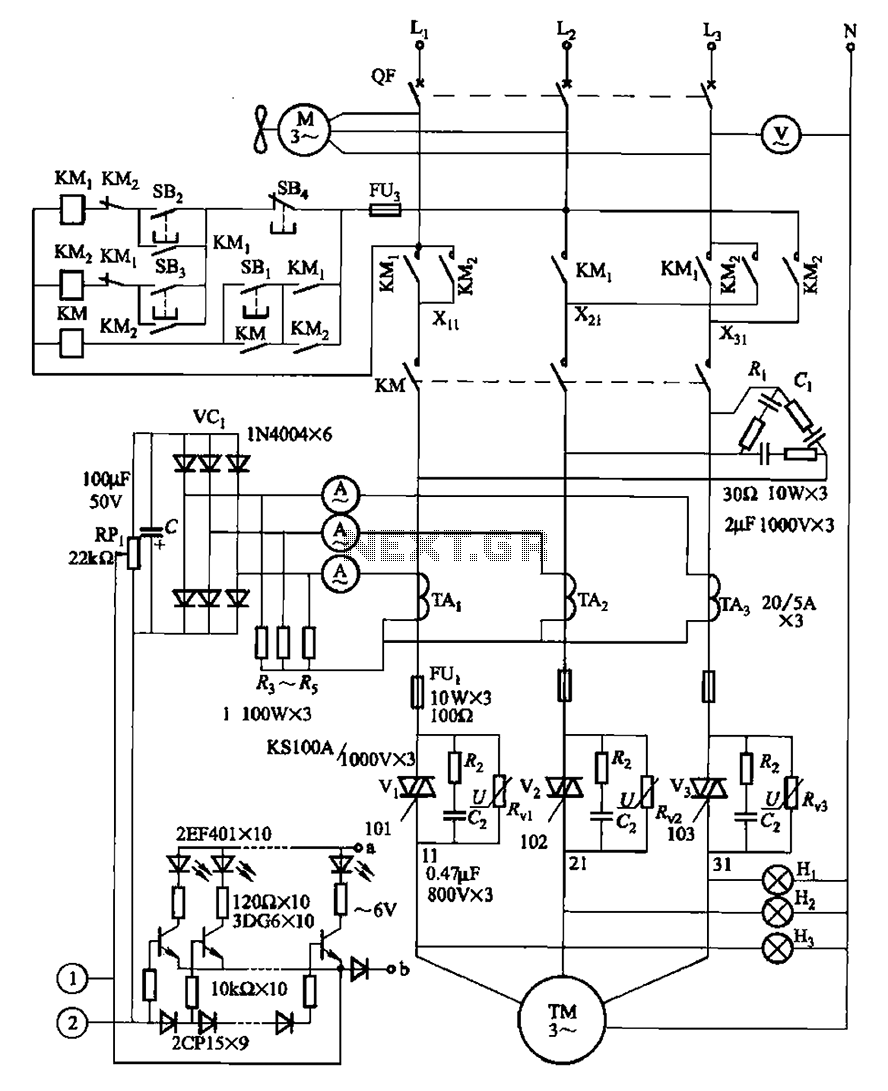
Two motor speed control circuit and the main level indicating circuit
The circuit illustrated in Figure 3-178 is designed for controlling the speed and torque of a motor used in a continuous casting machine. It consists of the main circuit, a trigger circuit, and both manual and automatic control signal circuits,...
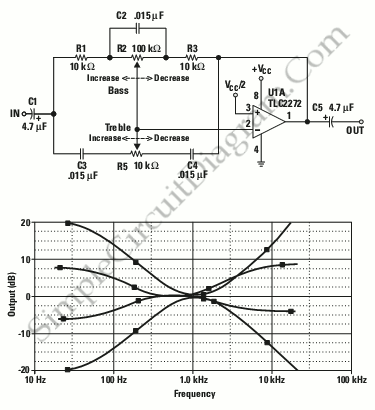
Single Op-Amp Tone Control
This is a single operational amplifier tone control circuit. The circuit functions as a hybrid low-pass, high-pass, and one-pole filter with both attenuation and gain.
The single op-amp tone control circuit utilizes an operational amplifier (op-amp) to manipulate audio signals by...
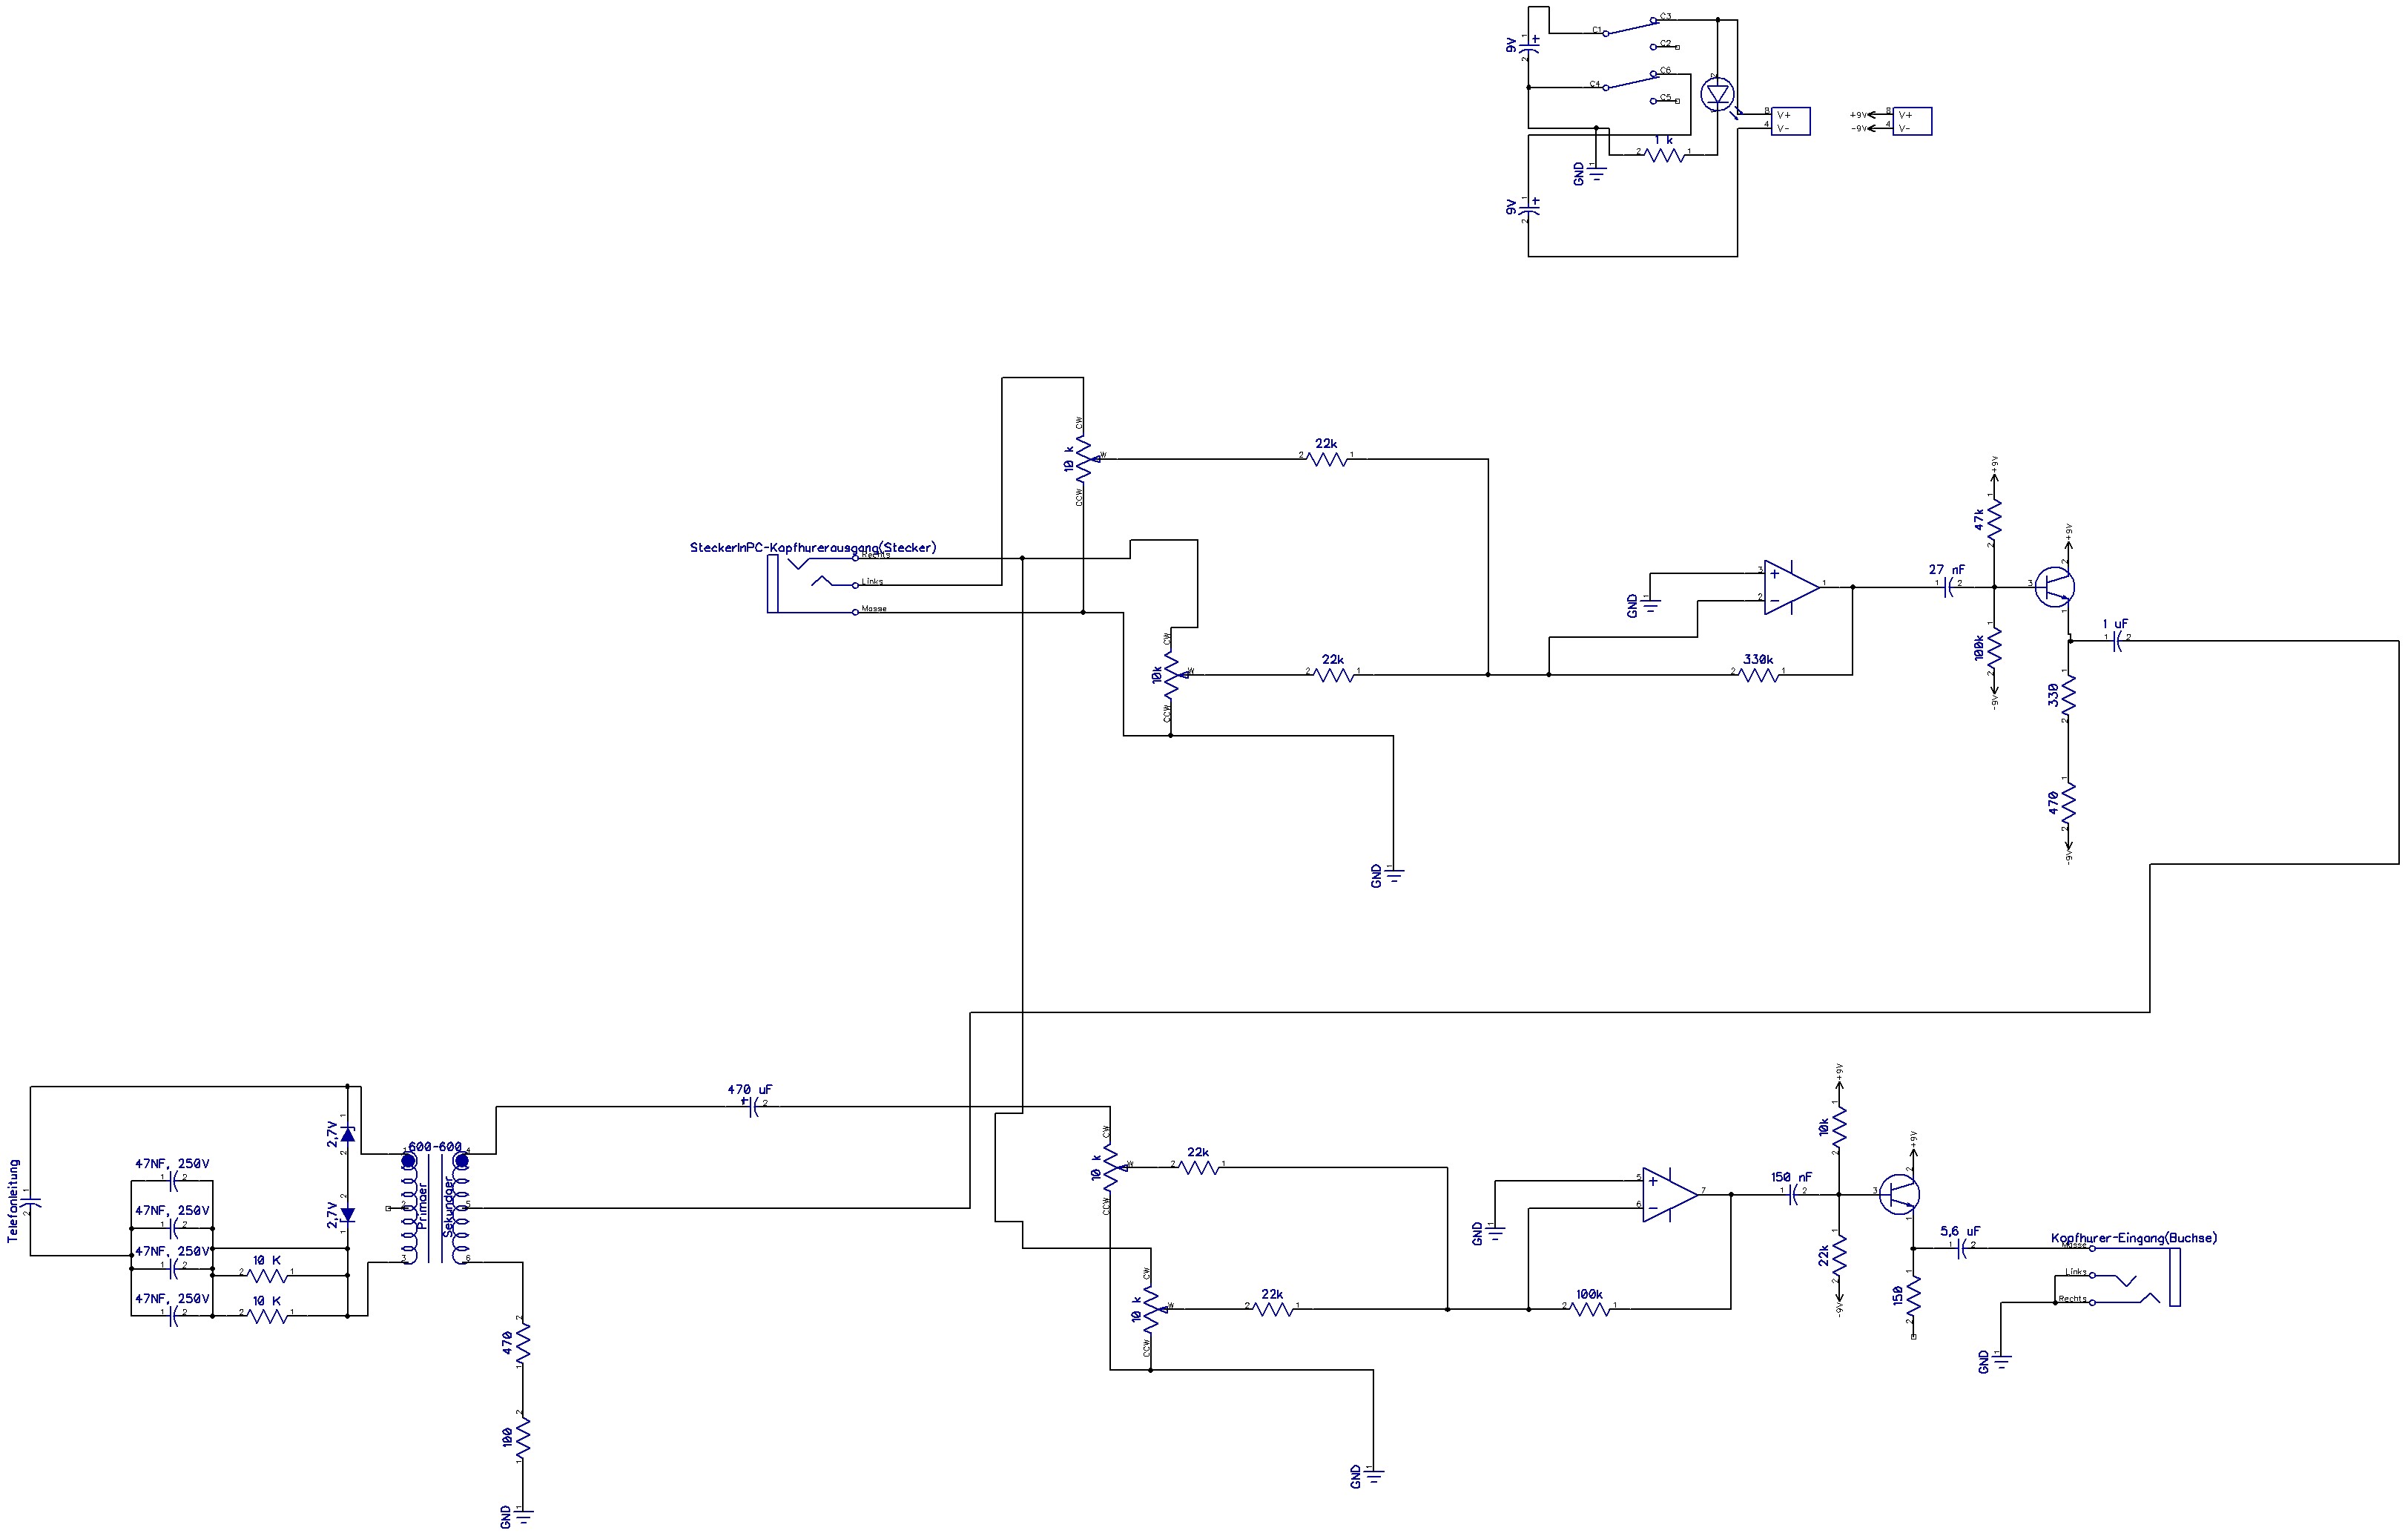
op amp Humming and Transmission issues
When the connection to the PC speaker is plugged in alongside the telephone connection (located at the bottom-left), a humming sound is heard in the headphones. However, when only one of the connections is used, the sound is clear without...
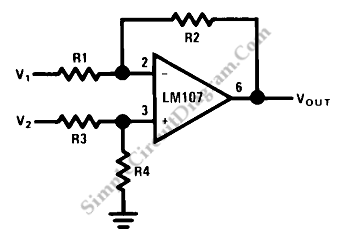
Op-Amp Circuit: Difference Amplifier
This circuit is a difference amplifier. It functions as an inverting amplifier that enables the subtraction of two voltages, effectively performing a summation.
The difference amplifier is a fundamental circuit configuration in analog electronics, primarily used for amplifying the difference between...
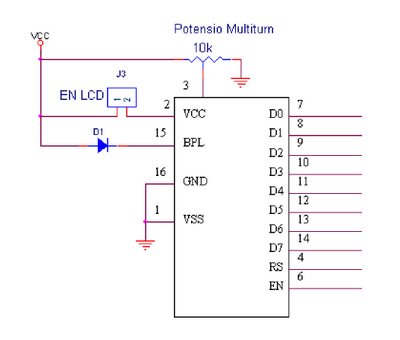
Contactless Tachometer
The tachometer, also known as a revolution counter, is an instrument that measures the speed of rotating machinery, typically expressed in revolutions per minute (RPM). This project involves creating a custom sensor using a light-emitting diode (LED) as a light...