


Model Train Throttle Control
#model train
#throttle control
#momentum feature
#realism
#motor control
#speed regulation
#hobby electronics
#analog control
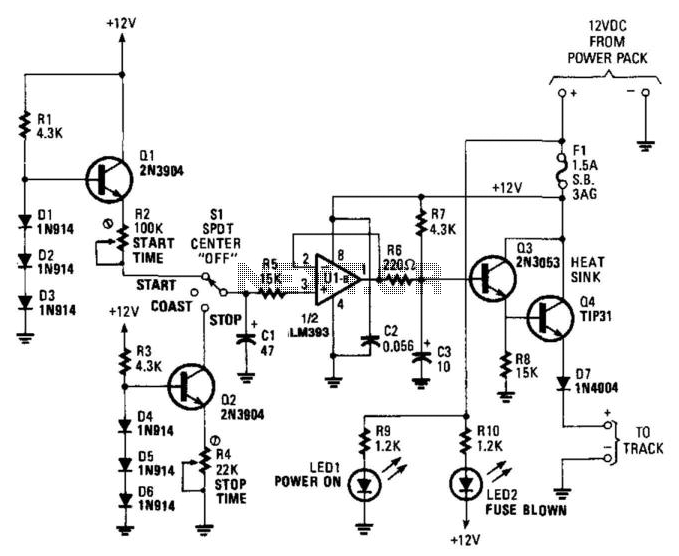
Description: The unique aspect of this control is its momentum feature, which enhances realism. The circuit is designed to operate efficiently for trains that draw up to 1 A at 15 V. None of the components are critical. In the start mode, current source Q1 charges capacitor C1. The charging current and startup time are adjusted using resistor R2. In the stop mode, current sink Q2 discharges capacitor C1. The discharge current and stop time are determined by resistor R4. During the coast mode, operational amplifier U1 draws minimal current from C1, allowing the speed to remain nearly constant for a period before gradually decreasing. Transistors Q3 and Q4 form a Darlington emitter-follower configuration to amplify the output of U1. Diode D7 reduces the output voltage by approximately 0.8 V. An additional diode can be added in series to bring the output to 0 V in the stop mode.
The circuit described operates with a momentum feature that simulates realistic train behavior by controlling the acceleration and deceleration profiles. The system is capable of handling a maximum load of 1 A at 15 V, making it suitable for small model train applications.
In the start mode, the operation begins with current source Q1, which charges capacitor C1. The resistor R2 plays a crucial role in determining the rate at which C1 charges, thereby influencing the startup time. This allows for customization of the acceleration curve to enhance the realism of the train's movement.
Once the train reaches the desired speed, the stop mode is activated. Current sink Q2 takes over to discharge capacitor C1, with resistor R4 setting the rate of discharge. This configuration allows for a gradual decrease in speed, simulating the natural deceleration of a train.
During the coast mode, operational amplifier U1 is employed to maintain a near-constant output from capacitor C1. The low current draw from U1 ensures that the train does not come to an immediate stop but rather coasts for a while, contributing to the overall realistic behavior of the system.
Transistors Q3 and Q4 are configured as a Darlington pair, which provides high current gain and effectively amplifies the output signal from U1. This amplification is critical for driving the load, ensuring that the train operates smoothly without any sudden interruptions in power.
Diode D7 serves to slightly reduce the output voltage, providing a necessary adjustment to the circuit's performance. The option to add another diode in series allows for further control over the output voltage, enabling the system to reach a complete stop when required.
Overall, this circuit design effectively integrates various components to create a control system that mimics the realistic operation of model trains, enhancing the user experience through its momentum feature and adjustable parameters. What makes this control unique is its momentum feature, which adds a degree of realism. The circuit will opera te well for trains that draw up to 1 A at 15 V. None of the components are critical. In the start mode, current source Ql charges capacitor CI. The charge current and start-up time are adjusted by resistor R2. In the stop mode, current-sink Q2 discharges capacitor CI. The discharge current and stop time are set by resistor R4. In the coast mode, op amp Ul draws very little current from CI, so the speed will remain nearly constant for some time, and then gradually decrease. Transistors Q3 and Q4 form a Darlington emitter-follower to amplify the output of Ul. Diode D7 reduces the output by about 0.8 V. Another diode could be added in series to decrease the output to 0 in the stop mode.
The circuit described operates with a momentum feature that simulates realistic train behavior by controlling the acceleration and deceleration profiles. The system is capable of handling a maximum load of 1 A at 15 V, making it suitable for small model train applications.
In the start mode, the operation begins with current source Q1, which charges capacitor C1. The resistor R2 plays a crucial role in determining the rate at which C1 charges, thereby influencing the startup time. This allows for customization of the acceleration curve to enhance the realism of the train's movement.
Once the train reaches the desired speed, the stop mode is activated. Current sink Q2 takes over to discharge capacitor C1, with resistor R4 setting the rate of discharge. This configuration allows for a gradual decrease in speed, simulating the natural deceleration of a train.
During the coast mode, operational amplifier U1 is employed to maintain a near-constant output from capacitor C1. The low current draw from U1 ensures that the train does not come to an immediate stop but rather coasts for a while, contributing to the overall realistic behavior of the system.
Transistors Q3 and Q4 are configured as a Darlington pair, which provides high current gain and effectively amplifies the output signal from U1. This amplification is critical for driving the load, ensuring that the train operates smoothly without any sudden interruptions in power.
Diode D7 serves to slightly reduce the output voltage, providing a necessary adjustment to the circuit's performance. The option to add another diode in series allows for further control over the output voltage, enabling the system to reach a complete stop when required.
Overall, this circuit design effectively integrates various components to create a control system that mimics the realistic operation of model trains, enhancing the user experience through its momentum feature and adjustable parameters. What makes this control unique is its momentum feature, which adds a degree of realism. The circuit will opera te well for trains that draw up to 1 A at 15 V. None of the components are critical. In the start mode, current source Ql charges capacitor CI. The charge current and start-up time are adjusted by resistor R2. In the stop mode, current-sink Q2 discharges capacitor CI. The discharge current and stop time are set by resistor R4. In the coast mode, op amp Ul draws very little current from CI, so the speed will remain nearly constant for some time, and then gradually decrease. Transistors Q3 and Q4 form a Darlington emitter-follower to amplify the output of Ul. Diode D7 reduces the output by about 0.8 V. Another diode could be added in series to decrease the output to 0 in the stop mode.
Motorized Video Camera Mount
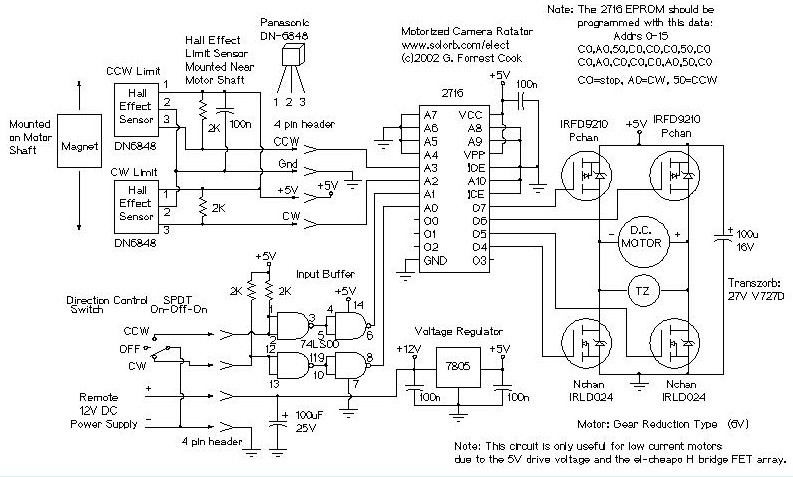
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
My Motors got me to Tap into Radiant Energy
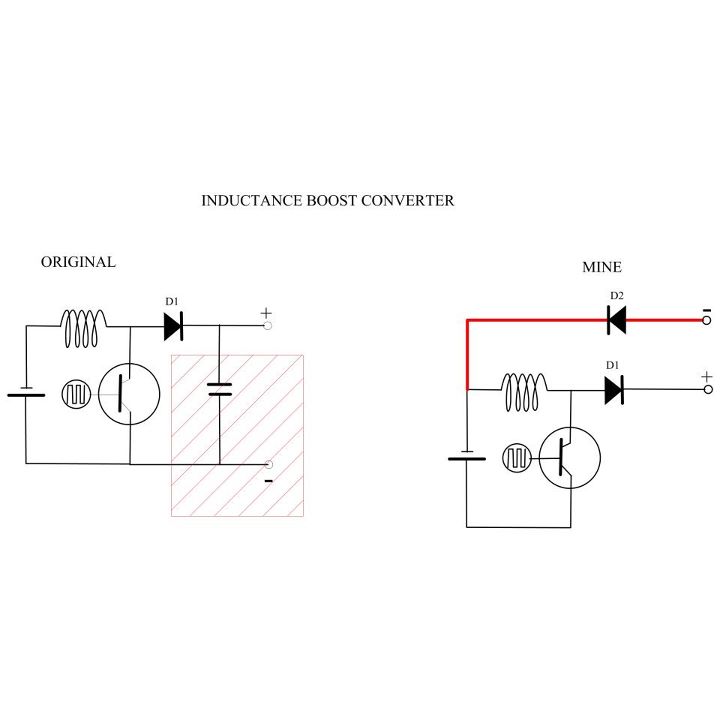
A new user is seeking to share information about their experiences on this platform.
The user expresses a desire to communicate and engage with the community regarding their experiences. This indicates an interest in exchanging knowledge and possibly seeking assistance or...
To Automate Rolling Shutter Motor
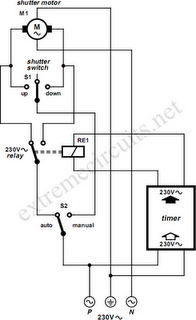
To automate the opening and closing of a rolling shutter using a time-controlled switch, additional wiring will be necessary.
To implement an automated system for a rolling shutter, a time-controlled switch can be utilized to manage the operation of the shutter....
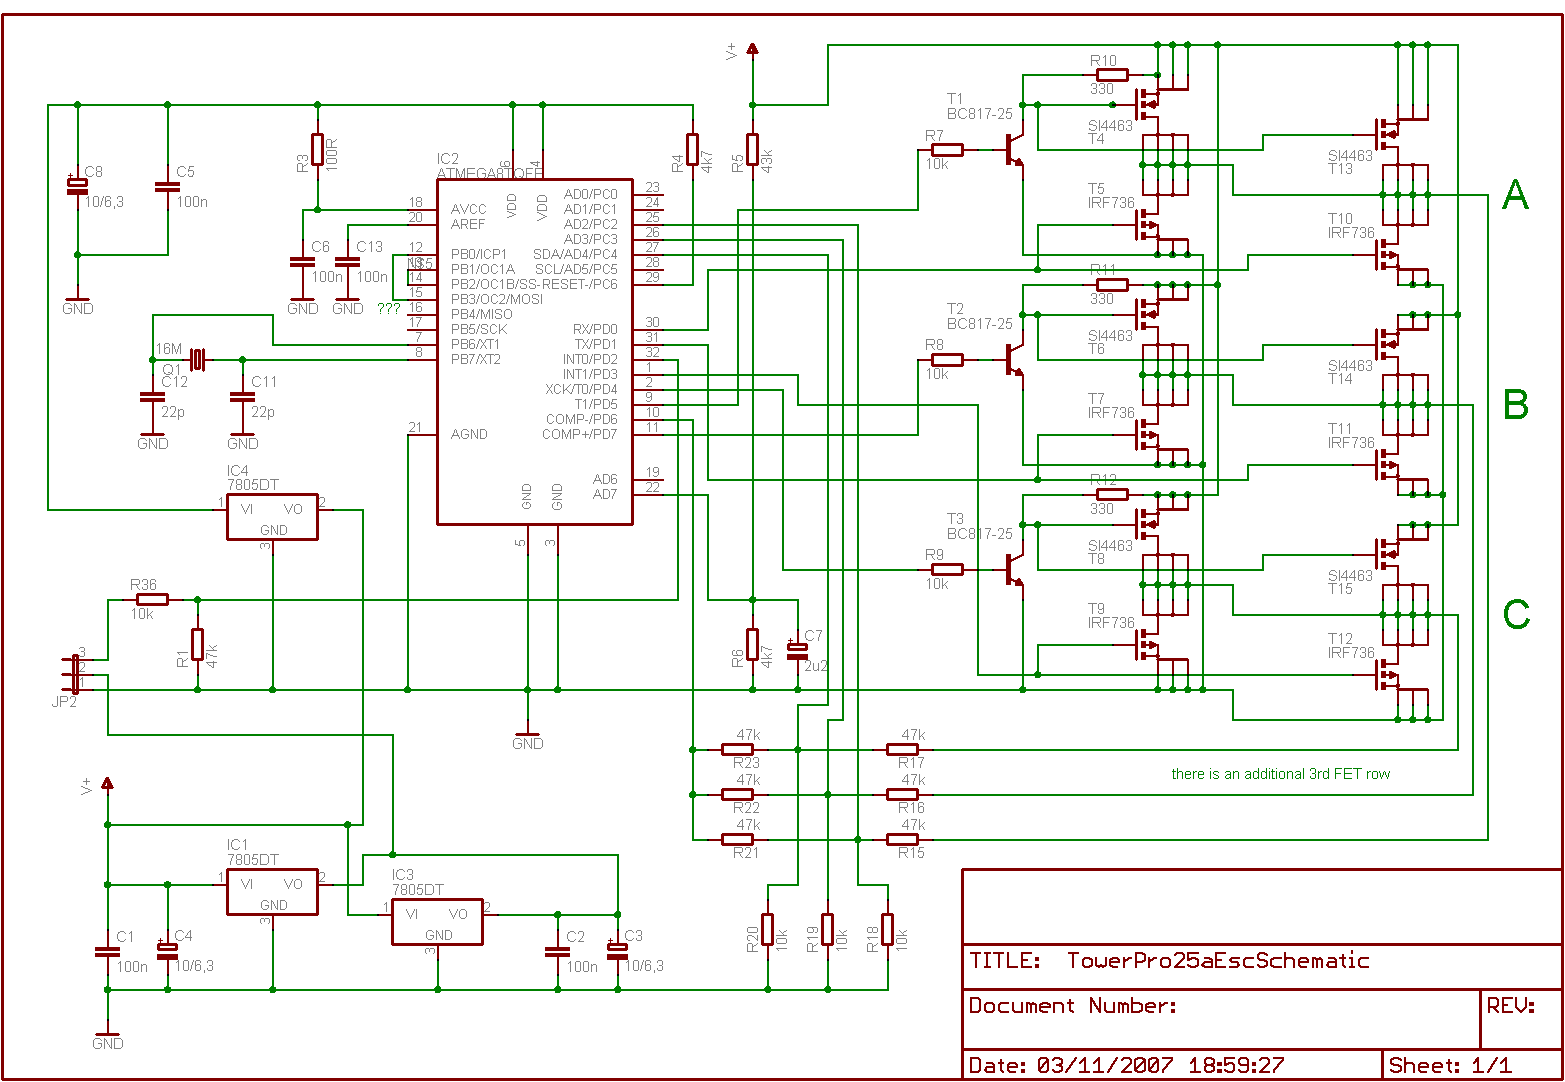
circuit board for throttle control
Is it feasible to eliminate the Electronic Speed Controllers (ESCs) from a multicopter configuration and substitute them with a single circuit board to control all the motors? The current setup consists of eight motors, each requiring an individual ESC, which...
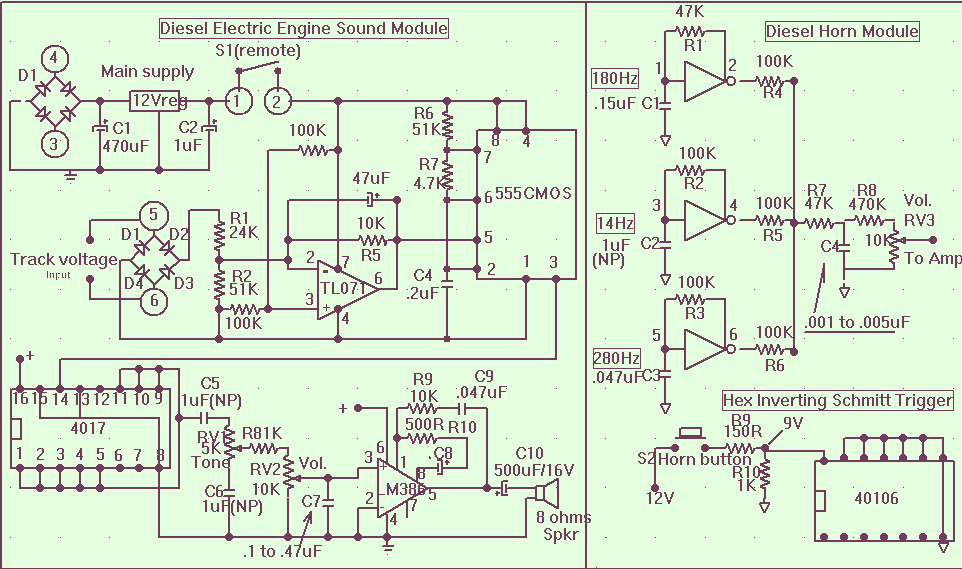
Model Train Diesel and Horn Circuit
The main power supply to the system must be a regulated 12 volts DC with a minimum input from the train control AC or DC power supply of 13.5 VAC connected to pos 3 and 4 of the rectifier bridge....
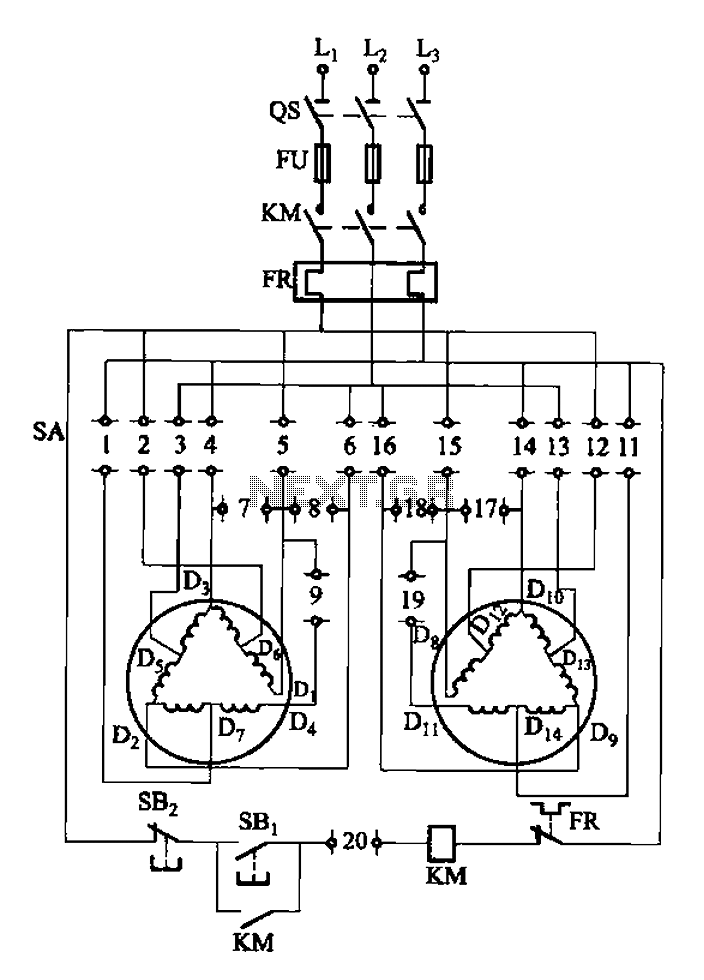
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
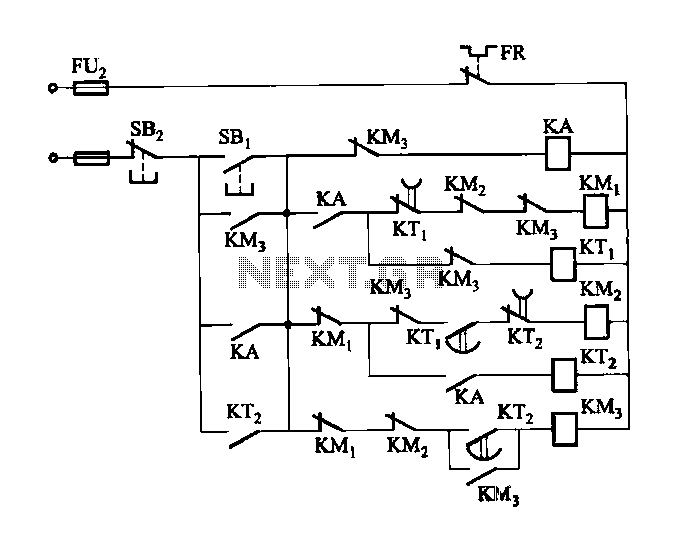
2 -Y- connection automatic three-speed motor acceleration control circuit
Figure 3-118 illustrates an automatic acceleration control circuit. This circuit employs a male contactor time relay, enabling the motor to start automatically at a low speed before transitioning to high-speed operation.
The automatic acceleration control circuit depicted in Figure 3-118 is...
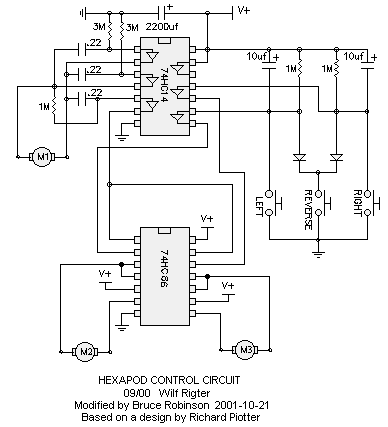
5-motor hexapod circuit
This circuit has a long history, originating from an idea by Rich Piotter and later refined by Wilf Rigter and Bruce Robinson. The final result does not include the necessary motor drivers, which are typically H-bridge based, but presents a...
motor timer
The primary concept is to rotate the motor slightly every 15 seconds. A monofilament line conveys the motion to the ornament, which is wound by the motor and gradually unwinds as the ornament turns. The charging circuit includes a 1...