


H-bridge circuit using NPN transistors
#H-bridge
#NPN transistors
#motor control
#power transistors
#forward direction
#current flow
#transistor driver
#bridge circuit
#DC motor
#switching
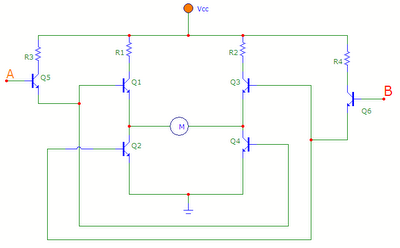
Description: The transistors Q1, Q2, Q3, and Q4 form a bridge circuit. These are typically power transistors designed to handle high current. Transistors Q5 and Q6 drive the bridge. When input A is set high and input B is set low, transistor Q5 activates, turning on transistors Q1 and Q4. Consequently, current flows from Vcc to ground through Q1, the motor, and Q4, causing the motor to rotate in the forward direction. Conversely, when input A is set low and input B is set high, transistor Q6 activates, turning on transistors Q3 and Q2. In this scenario, current flows from Vcc to ground through Q3, the motor, and Q2, resulting in the motor rotating in the reverse direction.
The described circuit utilizes a H-bridge configuration, which is commonly employed in motor control applications. The four transistors (Q1, Q2, Q3, Q4) are arranged in a manner that allows for bidirectional control of the motor. Power transistors are selected for their ability to handle significant current loads, ensuring reliable operation under various conditions.
Transistors Q5 and Q6 act as control switches for the H-bridge. By manipulating the states of inputs A and B, the circuit can effectively control the direction of the motor. When A is high and B is low, Q5 conducts, enabling Q1 and Q4, which completes the circuit path, allowing current to flow through the motor in one direction. This configuration is essential for applications requiring forward motion.
In contrast, when A is low and B is high, Q6 turns on, enabling Q3 and Q2. This configuration reverses the current flow through the motor, allowing it to rotate in the opposite direction. This dual control mechanism provides an efficient means of motor direction control, which is crucial for robotics, automation, and various electromechanical systems.
To ensure safe and efficient operation, it is important to consider the specifications of the transistors, including their voltage and current ratings, as well as the thermal management of the circuit. Proper heat sinks may be required to dissipate heat generated during operation, especially under high load conditions. Additionally, incorporating flyback diodes across the motor terminals can protect the transistors from voltage spikes caused by inductive loads, further enhancing the reliability of the circuit.The transistors Q1, Q2, Q3 and Q4 form the bridge circuit. Generally these are power transistors capable of handling high current. Q5 and Q6 drive the bridge. when the `A` is made high and `B` low, transistor Q5 is on and it makes Q1 and Q4 on. The current flows from vcc to ground through Q1, motor and Q4. hence the motor rotates in forward direction. When `A` is made low and `B` high the transistor Q6 is on and it makes the Q3 and Q2 on. The current flow from vcc to ground through Q3, motor and Q2. hence the motor rotates in reverse direction.
The described circuit utilizes a H-bridge configuration, which is commonly employed in motor control applications. The four transistors (Q1, Q2, Q3, Q4) are arranged in a manner that allows for bidirectional control of the motor. Power transistors are selected for their ability to handle significant current loads, ensuring reliable operation under various conditions.
Transistors Q5 and Q6 act as control switches for the H-bridge. By manipulating the states of inputs A and B, the circuit can effectively control the direction of the motor. When A is high and B is low, Q5 conducts, enabling Q1 and Q4, which completes the circuit path, allowing current to flow through the motor in one direction. This configuration is essential for applications requiring forward motion.
In contrast, when A is low and B is high, Q6 turns on, enabling Q3 and Q2. This configuration reverses the current flow through the motor, allowing it to rotate in the opposite direction. This dual control mechanism provides an efficient means of motor direction control, which is crucial for robotics, automation, and various electromechanical systems.
To ensure safe and efficient operation, it is important to consider the specifications of the transistors, including their voltage and current ratings, as well as the thermal management of the circuit. Proper heat sinks may be required to dissipate heat generated during operation, especially under high load conditions. Additionally, incorporating flyback diodes across the motor terminals can protect the transistors from voltage spikes caused by inductive loads, further enhancing the reliability of the circuit.The transistors Q1, Q2, Q3 and Q4 form the bridge circuit. Generally these are power transistors capable of handling high current. Q5 and Q6 drive the bridge. when the `A` is made high and `B` low, transistor Q5 is on and it makes Q1 and Q4 on. The current flows from vcc to ground through Q1, motor and Q4. hence the motor rotates in forward direction. When `A` is made low and `B` high the transistor Q6 is on and it makes the Q3 and Q2 on. The current flow from vcc to ground through Q3, motor and Q2. hence the motor rotates in reverse direction.
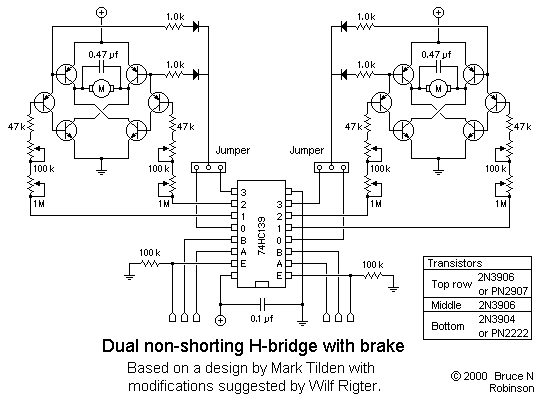
Full-featured Dual H-bridge
This is a slightly revised version of the 6-transistor H-bridge designed by Mark Tilden and found on the BEAM Tek website (now only available via archive). I encourage anyone interested in H-bridges to read Mark's article, as it gives an...
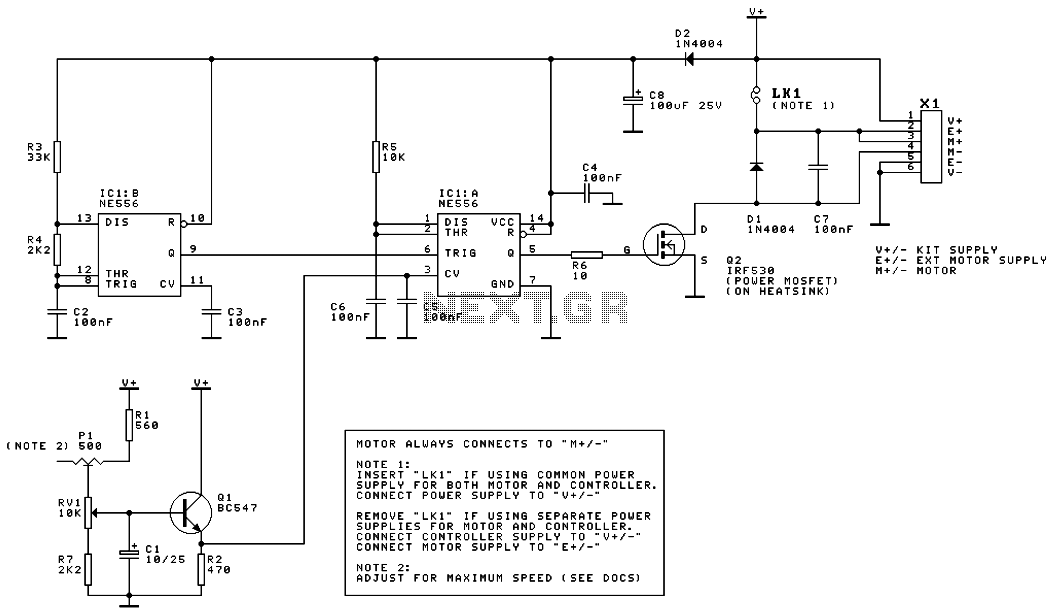
DC Motor Speed Controller
This is the schematic diagram of a DC motor speed controller circuit. The circuit utilizes two oscillators/timers that are configured as a Pulse Width Modulator (PWM). The timer chip used in this circuit is a dual NMOS timer/oscillator.
The DC motor...
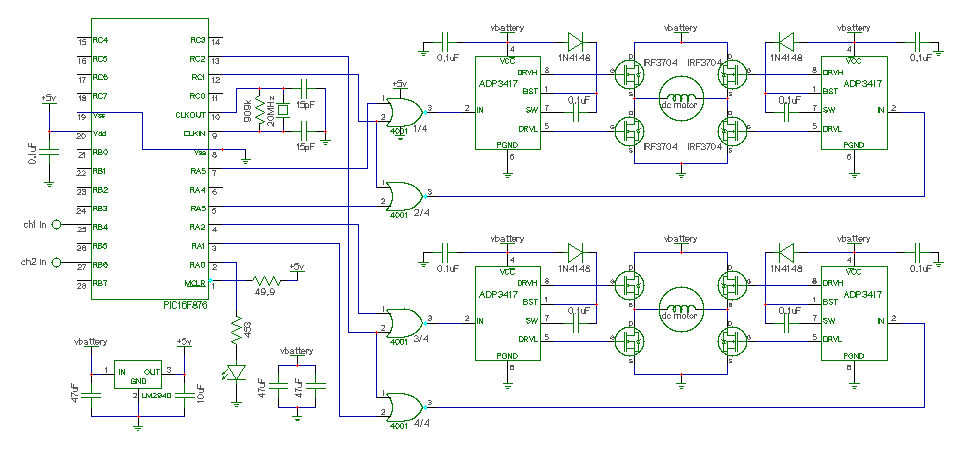
Dual DC motor speed control
Here is a design for a DC motor speed control featuring: Efficient PWM H-bridge MOSFET architecture. Supply (battery) voltage range from 4.2 to 13 volts. High current capacity for driving large motors (65 amps max). Input compatible with standard RC...
H Bridge Direct Current Motor Control Circuits
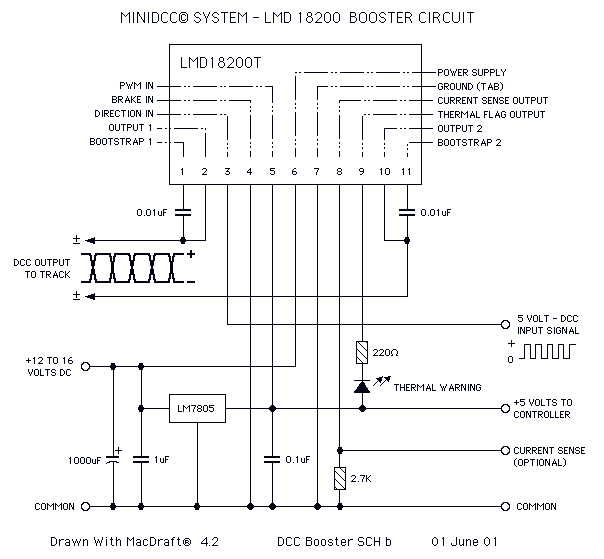
This page features H-Bridge circuits used for controlling direct current motors. Several designs are shown using both CMOS and Bi-Polar power devices. These circuits could be used as the basis for Model Railroad DCC Boosters or PWM motor controllers. The...
Dual-Motor SIP&PUFF Controlled Kayak System
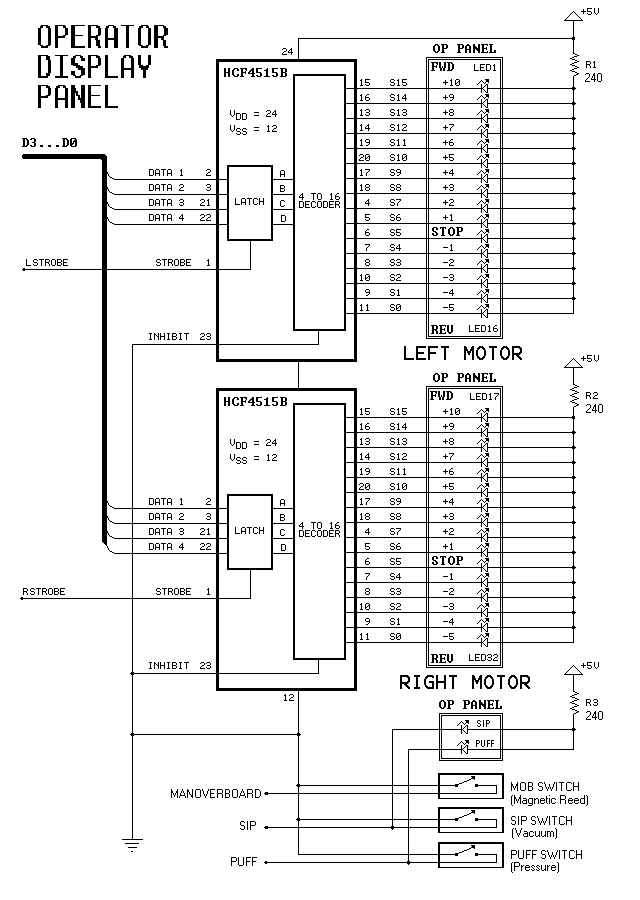
The YouTube video below demonstrates the quick and easy setup of the system at the launch site.
The provided description indicates a focus on the efficiency of system installation at a launch site, as showcased in a YouTube video. In an...
Two Basic Motor Speed Controllers
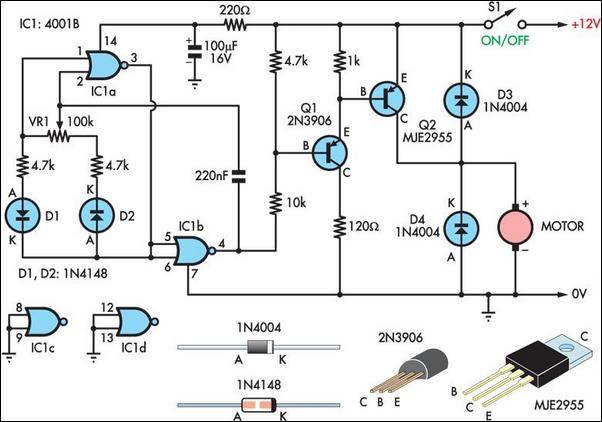
Two simple 12V DC motor speed controllers can be constructed for a minimal cost. These controllers take advantage of the principle that the rotational speed of a DC motor is directly proportional to the average value of its supply voltage....
Speed-controlled-reversible-dc-motor-drive
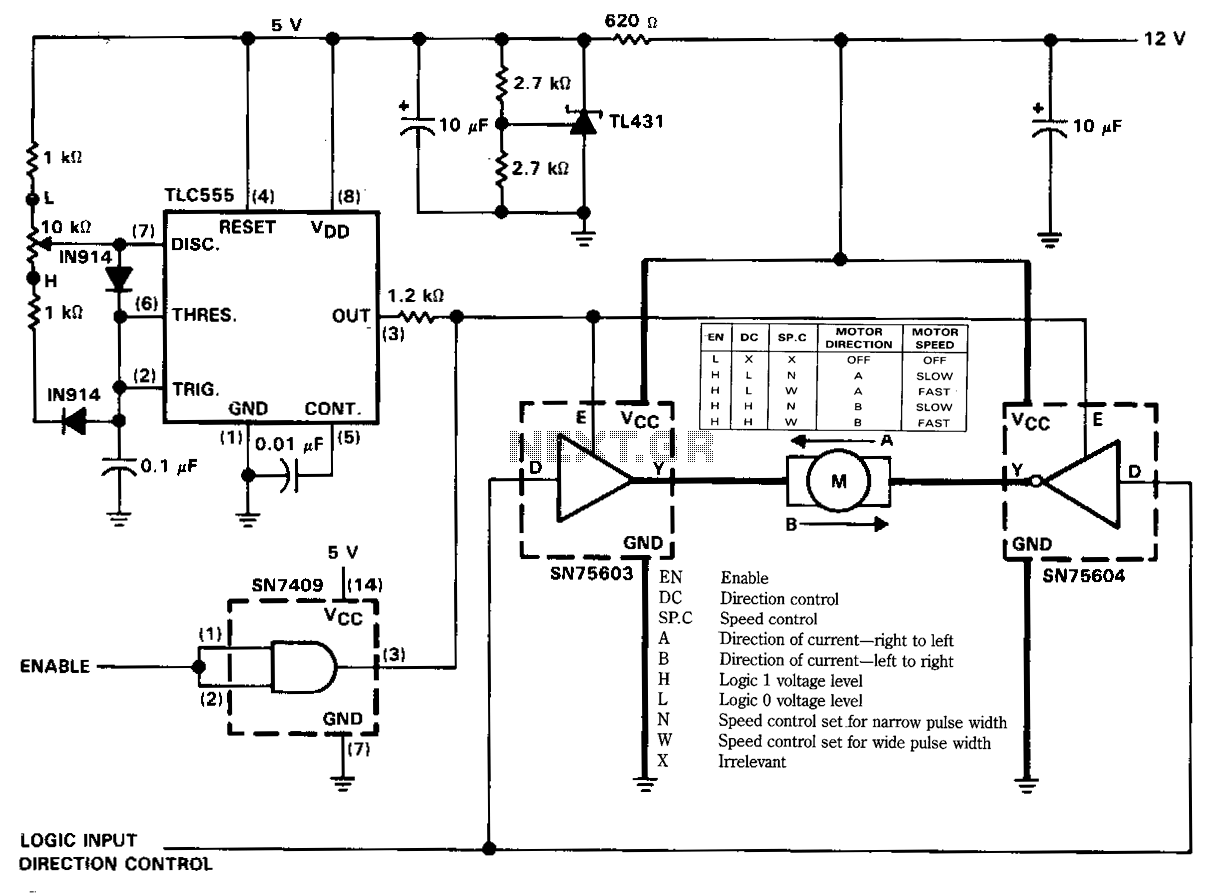
The figure illustrates a reversible DC motor drive application with adjustable speed control. The D inputs for these drivers are complementary and can be tied together and driven from the same logic control for bidirectional motor drive. The enables are...
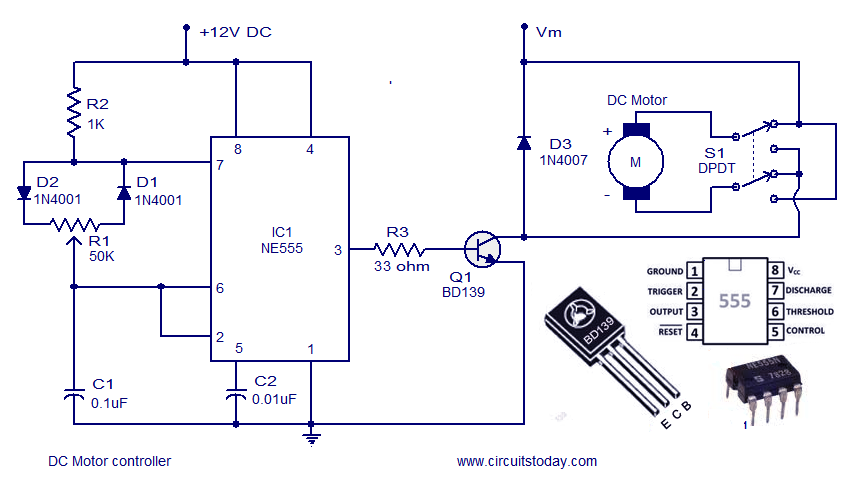
Dc motor speed controller circuit using NE555
A DC motor controller based on an NE555 timer is presented here. The direction of rotation of the DC motor can also be changed using this DC motor speed control circuit.
The described circuit utilizes the NE555 timer IC in astable...
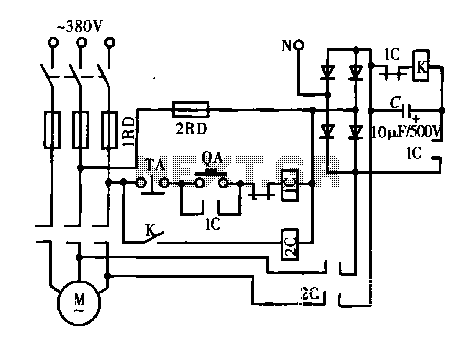
DC motor dynamic braking circuit
A DC motor is depicted in a dynamic braking circuit. When the stop button (SB2) is pressed, the contactor (KM1) is deactivated, causing its movable contact to disconnect, which interrupts the electrical voltage. Additionally, relay (KV) is activated, closing its...