


DC motor reverse brake circuit
#DC motor
#reverse brake
#braking
#contactor
#stop button
#motor control
#circuit
#power release
#KM2
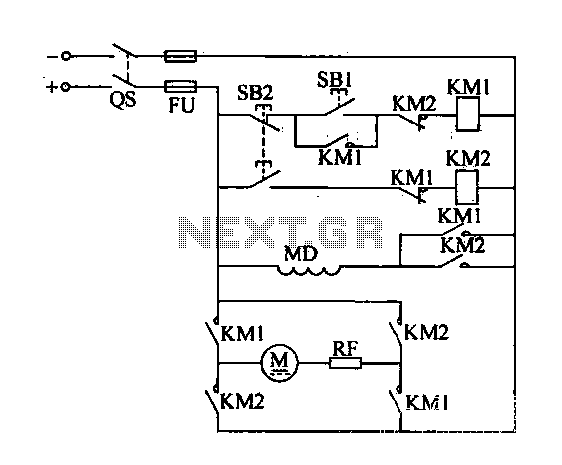
Description: A DC motor reverse brake circuit is presented. To initiate braking, the stop button (SB2) is pressed, which disconnects the move-off contact, causing KM1 to lose power and release. Subsequently, the brake contactor (KM2) is activated. KM2 is designed for electric operation, reversing the armature power. As a result, the motor's electromagnetic torque transitions into braking torque, leading to a rapid decrease in motor speed until it approaches zero. Releasing the stop button (SB2) concludes the braking process.
The DC motor reverse brake circuit is an essential configuration used in applications requiring rapid deceleration of the motor. The operation of this circuit begins with the pressing of the stop button (SB2), which interrupts the power supply to the move-off contact. This action results in the deactivation of contactor KM1, effectively disconnecting the motor from its power source.
Once KM1 is released, the brake contactor KM2 is energized. This contactor is specifically designed to reverse the armature voltage applied to the motor. When KM2 is activated, it causes the motor's electromagnetic torque to switch from its normal operational mode to a braking mode. This transition is crucial as it generates a braking torque that opposes the motor's rotation, leading to a swift reduction in the motor's speed.
The braking process continues until the motor speed drops to a near-zero value. This rapid deceleration is vital in applications where precise control over motor speed is necessary, such as in conveyor systems or robotic actuators. Once the desired speed is achieved, releasing the stop button (SB2) completes the braking sequence, allowing the motor to remain in a stationary state until further commands are issued.
Key components of this circuit include the DC motor, the move-off contact, contactor KM1, and the brake contactor KM2. The design ensures that the transition from normal operation to braking is smooth and efficient, minimizing wear on the motor and associated mechanical components. Proper implementation of this circuit can enhance the overall safety and reliability of motor-driven systems.DC motor reverse brake circuit is shown. Braking, press the stop button SB2, disconnect move off contact so KM1 loss of power release, then turned on the brake contactor KM2 ci rcuit. KM2 eligible for electric operation, the armature power reverse, the motor electromagnetic torque becomes braking torque, the motor speed rapidly drops to near zero, release the stop button SB2, the end of the braking process.
The DC motor reverse brake circuit is an essential configuration used in applications requiring rapid deceleration of the motor. The operation of this circuit begins with the pressing of the stop button (SB2), which interrupts the power supply to the move-off contact. This action results in the deactivation of contactor KM1, effectively disconnecting the motor from its power source.
Once KM1 is released, the brake contactor KM2 is energized. This contactor is specifically designed to reverse the armature voltage applied to the motor. When KM2 is activated, it causes the motor's electromagnetic torque to switch from its normal operational mode to a braking mode. This transition is crucial as it generates a braking torque that opposes the motor's rotation, leading to a swift reduction in the motor's speed.
The braking process continues until the motor speed drops to a near-zero value. This rapid deceleration is vital in applications where precise control over motor speed is necessary, such as in conveyor systems or robotic actuators. Once the desired speed is achieved, releasing the stop button (SB2) completes the braking sequence, allowing the motor to remain in a stationary state until further commands are issued.
Key components of this circuit include the DC motor, the move-off contact, contactor KM1, and the brake contactor KM2. The design ensures that the transition from normal operation to braking is smooth and efficient, minimizing wear on the motor and associated mechanical components. Proper implementation of this circuit can enhance the overall safety and reliability of motor-driven systems.DC motor reverse brake circuit is shown. Braking, press the stop button SB2, disconnect move off contact so KM1 loss of power release, then turned on the brake contactor KM2 ci rcuit. KM2 eligible for electric operation, the armature power reverse, the motor electromagnetic torque becomes braking torque, the motor speed rapidly drops to near zero, release the stop button SB2, the end of the braking process.
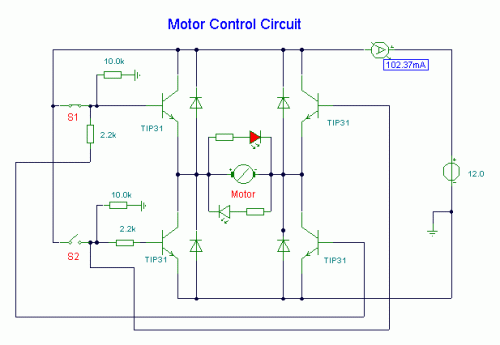
DC Motor Control Circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes can be either red or green and are used solely for indicating direction. The TIP31 transistors may need to be adjusted based on the motor specifications. It is important...
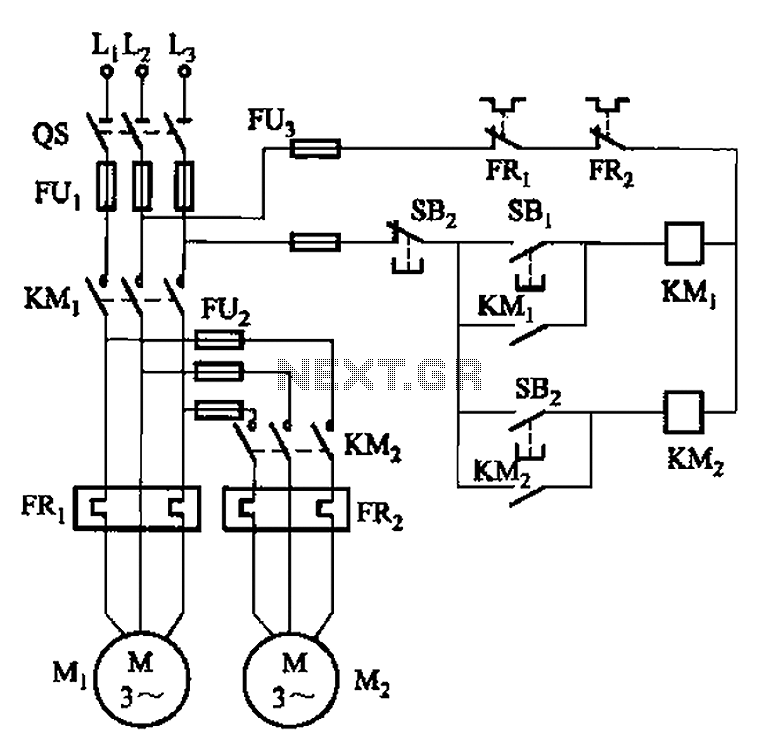
The main circuit in order to start the control circuit
The circuit illustrated in Figure 3-83 demonstrates that the contactor KMi is activated only after it is pulled, which indicates that the motor Mi has started for the first time. Following this, the contactor KM2 is then activated, indicating that...
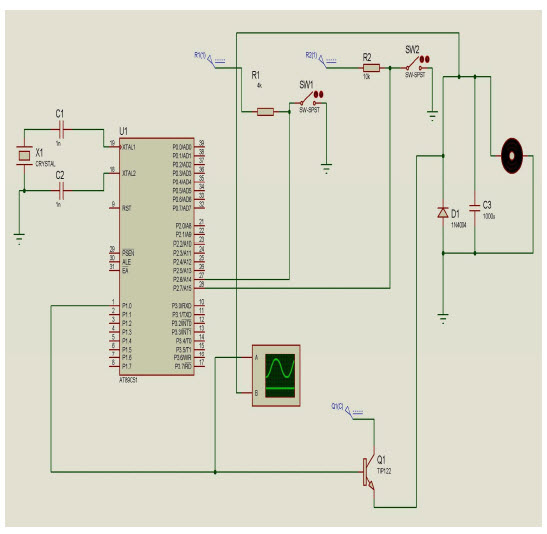
Speed Control of DC Motor using Microcontroller 8051 withCircuit
The objective of this project is to control the speed of a DC motor. The primary benefit of utilizing a DC motor is the ability to modify the Speed-Torque relationship to nearly any desired form. To facilitate speed control, an...
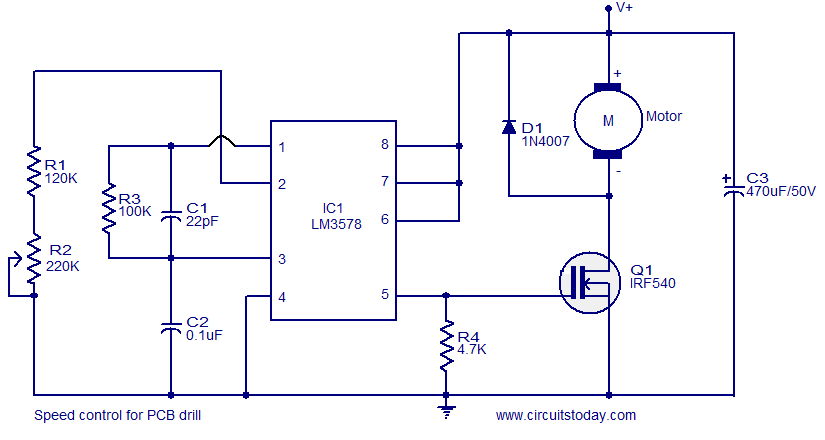
Speed control for PCB drill
This circuit is designed for controlling the speed of DC-operated PCB drills. The core component of this circuit is the ICLM3578, an efficient integrated switching regulator suitable for such applications. The LM3578 features separate inverting and non-inverting feedback inputs (pin...
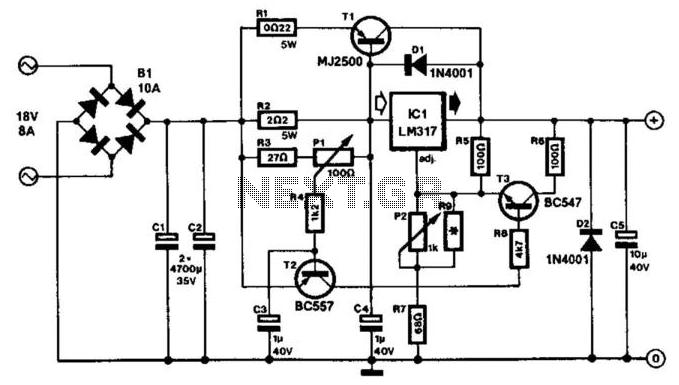
Mini-Drill Control
This circuit is designed for speed control of small DC motors commonly found in devices such as electric drills, which are utilized for precision engineering and drilling tasks. The behavior of these motors, typically permanent magnet types, resembles that of...
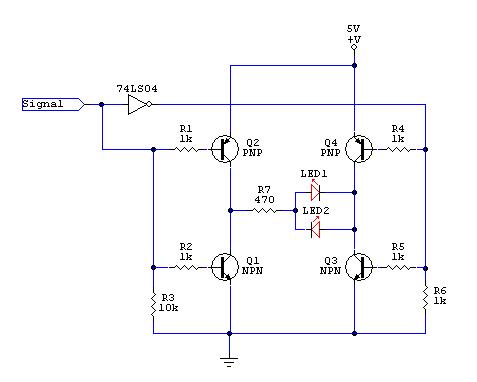
When page is bookmarked text here is referenced verbatim
The image shows a completed locked anti-phase motor controller built on a breadboard, utilizing general-purpose transistors to control small DC motors for robotics applications. A typical DC motor controller lacks a braking function, which is essential for precise control. Addressing...
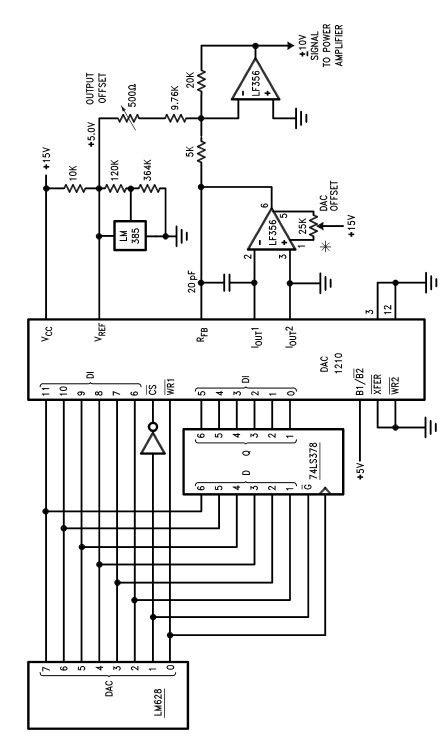
DC motor driver circuit design using LM628 LM629 dedicated motion-control processors
The LM628 and LM629 dedicated motion-control processors can be utilized to design various applications involving DC and brushless DC servo motors, as well as other servomechanisms. The power path of this electronic project, which functions as a motor driver, is...
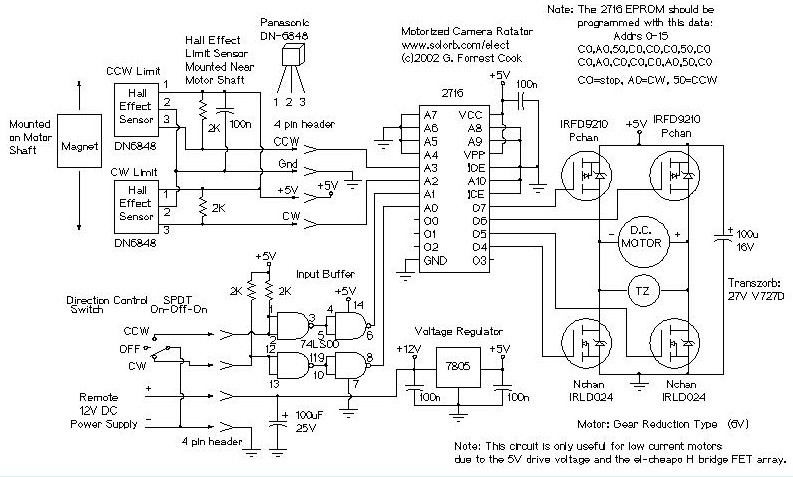
Motorized Video Camera Mount
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
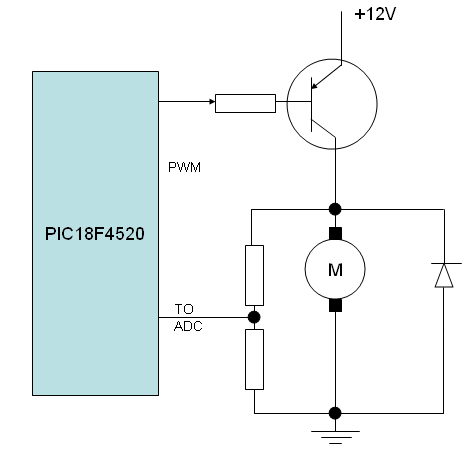
Closed loop speed control of DC motor using back emf sening
A speed closed-loop control system for a DC motor utilizes back EMF sensing. To implement this, a DC motor is operated in one direction, substituting the LED with the motor and omitting the current limit resistor. It is important to...