


Controlling DC Motors Robotics Tutorial
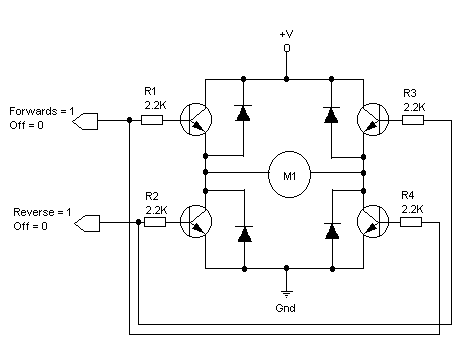
Description: The principles of DC motors are discussed in the beginner and intermediate sections of this tutorial. This section will address the electronics required to interface them with a Basic X microcontroller or other digital chips. The simplest method of controlling motors is by using the Robocore board, which contains the driver electronics necessary to control up to four DC motors or two stepper motors. It features direction LEDs for easy debugging of circuits. Transistors function as electronic switches, enabling the activation of large voltages (the motor power supply) using a very small current (such as the output pin of the Basic X). Each pair of transistors connects to a pin on the microcontroller and regulates the polarity of the current supplied to the motor. The specific components needed will depend on the size of the motors being utilized. The circuit includes diodes known as flyback diodes, which are crucial for preventing voltage spikes generated by the motors from damaging the transistors. When a motor rotates and changes direction, the coils of wire within it act as a generator, producing a current referred to as back electromotive force (back EMF). This current travels back through the circuit in the form of high-voltage spikes towards the transistor. Since transistors only permit current flow in one direction, the reverse current creates a bottleneck as the transistor attempts to block it. If this reverse current is substantial, particularly when reversing the motor's direction, it can damage the transistor, resulting in a short lifespan for the circuit. The circuit can be powered using any voltage suitable for the motors. If two power supplies are utilized—one for the Basic X and another for the motors—it is essential to connect the grounds of both supplies to ensure proper circuit functionality.
The interface between DC motors and microcontrollers is critical in many applications, including robotics and automation systems. The Robocore board serves as a versatile platform that simplifies the control of multiple motors while providing essential debugging features through its LED indicators. The use of transistors as electronic switches allows for efficient control of motor operations without the need for high-current signals from the microcontroller. Each transistor pair is strategically selected based on the required current and voltage ratings of the motors, ensuring reliable performance.
The flyback diodes are an essential component of the circuit, as they protect the transistors from voltage spikes caused by the inductive loads of the motors. When a motor is de-energized or its direction is reversed, the collapsing magnetic field generates a back EMF that can exceed the rated voltage of the transistors. Properly rated flyback diodes provide a safe path for this reverse current, effectively shunting it away from the transistors and preventing damage.
When designing the circuit, careful consideration must be given to the power supply requirements. The voltage rating should match the specifications of the motors to ensure optimal performance. Additionally, when employing separate power supplies for the microcontroller and motors, it is crucial to connect the grounds to maintain a common reference point, preventing erratic behavior or circuit malfunction.
In summary, the integration of DC motors with microcontrollers like the Basic X through the Robocore board presents a robust solution for various applications. The careful selection of components, including transistors and flyback diodes, ensures reliable operation and longevity of the circuit, while proper power supply management is vital for successful implementation.The principles of DC motors are covered in the beginner and intermediate sections of this tutorial. This section will cover the electronics needed to interface them to a Basic X microcontoller or other digital chip. The easiest way of controlling motors is using the Robocore. This board contains the driver electronics to control up to 4 DC motors or 2 stepper motors, and features direction LED`s for easy debugging of circuits. Transistors are electronic switches, they allow you to turn on large voltages (the motor power supply) using a very small current (like the output pin of the Basic X). Each pair of transistors is connected to a pin on the micro controller and control the polarity of the current supplied to the motor.
The actual components required would depend on the size of the motors that you want to use. The diodes in the circuit are very important and are called fly back diodes. They are there to prevent voltage spikes from the motors from destroying the transistors. When a motor rotates and changes direction the coils of wire inside it act as a generator and produce a current. This current is called the back electro motive force, or back E. M. F. for short. This current travels back through the circuit, in the form of powerful voltage spikes, to the transistor.
Now, because transistors only allow current to flow in one direction the current hits a bottle neck as the transistor tries to stop the reverse current. If this current is particularly large, say when your reversing the direction of the motor, it will simply blow the transistor, giving your new circuit a pretty short life.
The circuit can be powered using whatever voltage is suitable for your motors. If you are using two power supplies, one to power your Basic X and another to power your motors, you must connect the ground of each supply together or your circuit may not work properly.
The interface between DC motors and microcontrollers is critical in many applications, including robotics and automation systems. The Robocore board serves as a versatile platform that simplifies the control of multiple motors while providing essential debugging features through its LED indicators. The use of transistors as electronic switches allows for efficient control of motor operations without the need for high-current signals from the microcontroller. Each transistor pair is strategically selected based on the required current and voltage ratings of the motors, ensuring reliable performance.
The flyback diodes are an essential component of the circuit, as they protect the transistors from voltage spikes caused by the inductive loads of the motors. When a motor is de-energized or its direction is reversed, the collapsing magnetic field generates a back EMF that can exceed the rated voltage of the transistors. Properly rated flyback diodes provide a safe path for this reverse current, effectively shunting it away from the transistors and preventing damage.
When designing the circuit, careful consideration must be given to the power supply requirements. The voltage rating should match the specifications of the motors to ensure optimal performance. Additionally, when employing separate power supplies for the microcontroller and motors, it is crucial to connect the grounds to maintain a common reference point, preventing erratic behavior or circuit malfunction.
In summary, the integration of DC motors with microcontrollers like the Basic X through the Robocore board presents a robust solution for various applications. The careful selection of components, including transistors and flyback diodes, ensures reliable operation and longevity of the circuit, while proper power supply management is vital for successful implementation.The principles of DC motors are covered in the beginner and intermediate sections of this tutorial. This section will cover the electronics needed to interface them to a Basic X microcontoller or other digital chip. The easiest way of controlling motors is using the Robocore. This board contains the driver electronics to control up to 4 DC motors or 2 stepper motors, and features direction LED`s for easy debugging of circuits. Transistors are electronic switches, they allow you to turn on large voltages (the motor power supply) using a very small current (like the output pin of the Basic X). Each pair of transistors is connected to a pin on the micro controller and control the polarity of the current supplied to the motor.
The actual components required would depend on the size of the motors that you want to use. The diodes in the circuit are very important and are called fly back diodes. They are there to prevent voltage spikes from the motors from destroying the transistors. When a motor rotates and changes direction the coils of wire inside it act as a generator and produce a current. This current is called the back electro motive force, or back E. M. F. for short. This current travels back through the circuit, in the form of powerful voltage spikes, to the transistor.
Now, because transistors only allow current to flow in one direction the current hits a bottle neck as the transistor tries to stop the reverse current. If this current is particularly large, say when your reversing the direction of the motor, it will simply blow the transistor, giving your new circuit a pretty short life.
The circuit can be powered using whatever voltage is suitable for your motors. If you are using two power supplies, one to power your Basic X and another to power your motors, you must connect the ground of each supply together or your circuit may not work properly.
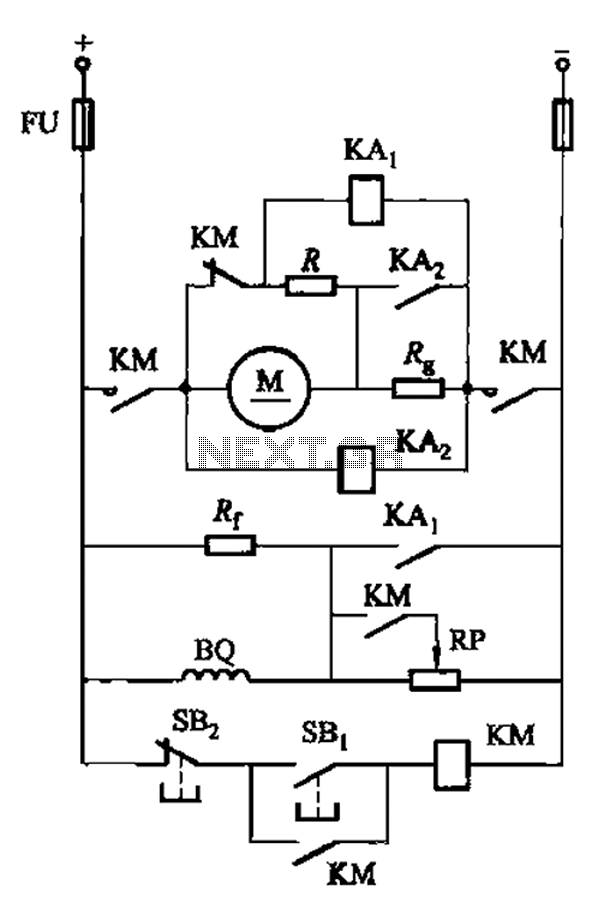
DC motor armature series resistance start dynamic braking circuit of the two-way operation
The circuit illustrated in Figure 3-197 features a dish adjust rheostat (RP) that allows for the adjustment of field current, which in turn modifies the motor speed.
The circuit operates by utilizing a rheostat, which is a variable resistor that can...
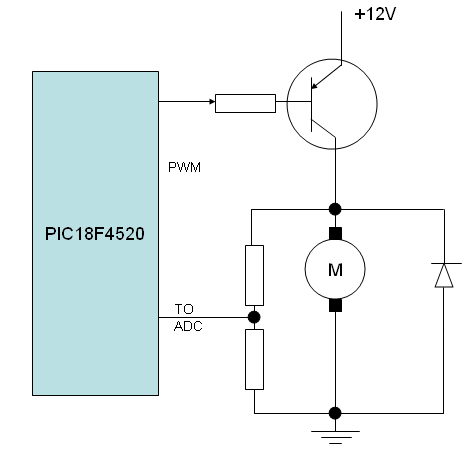
Closed loop speed control of DC motor using back emf sening
A speed closed-loop control system for a DC motor utilizes back EMF sensing. To implement this, a DC motor is operated in one direction, substituting the LED with the motor and omitting the current limit resistor. It is important to...
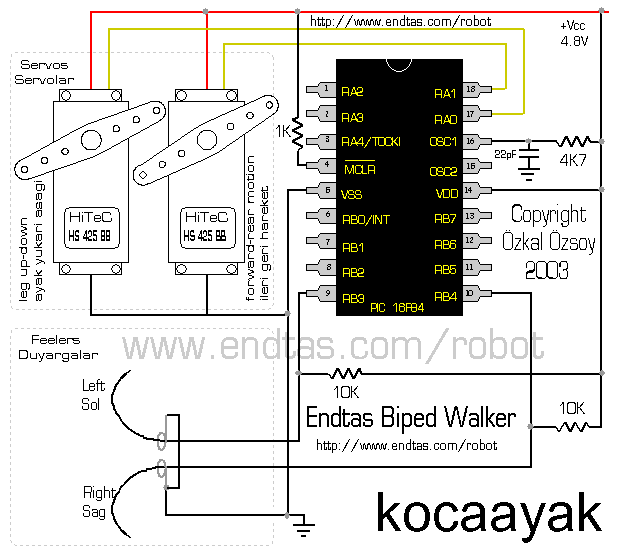
Robotrex Robotic Dinasaur
This is a robotic project named Robotrex, inspired by the words "Robot" and "Tyrannosaurus Rex." It was developed for the endtas.com fair stand at the 2004 Izmir International Fair, building on concepts from previous projects like "Bigfoot" and "the Goggles."...
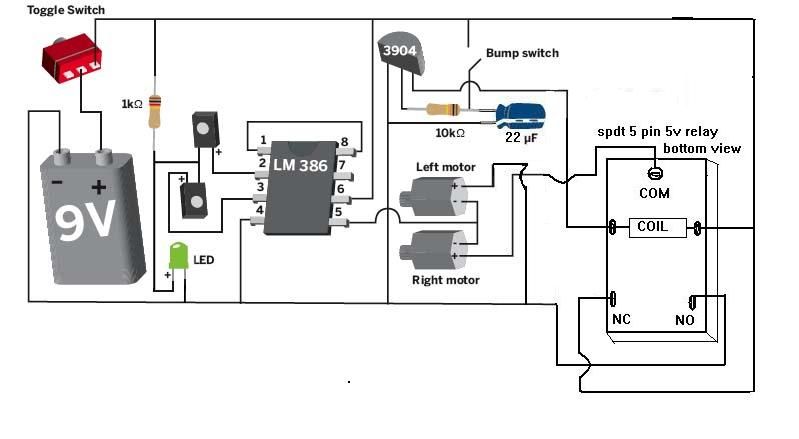
Mousebot Revisited
Mousebot from Make vol 2 is a fun introduction to robotics. This documentation provides an expanded overview of a Mousey build from start to finish.
The Mousebot project serves as an engaging entry point into the world of robotics, particularly suitable...
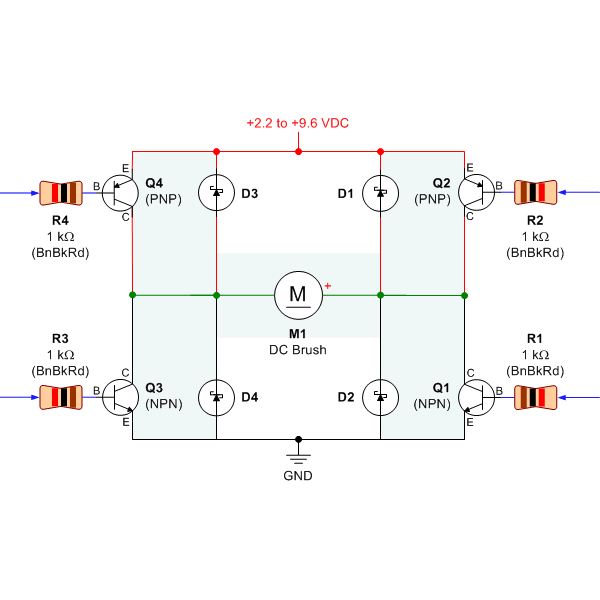
the dc motor circuit
Selecting the appropriate DC motor is essential for constructing mobile robots. Testing DC motors is straightforward and can be accomplished by assembling a basic DC motor circuit. The components needed for this circuit include a DC motor, a battery power...
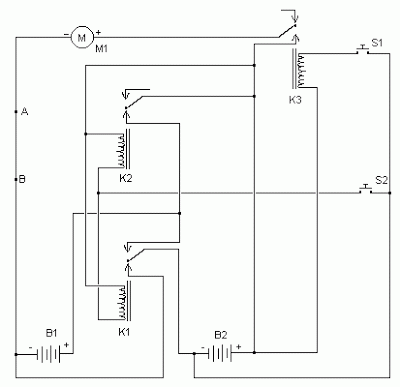
two speed contactor dc motor controller
The simplest form of motor controllers, apart from a basic on/off switch, is the contactor controller. This contactor controller is recommended for use in electric scooter projects. It is based on three 12V relays, two 12V batteries, two switches, and...
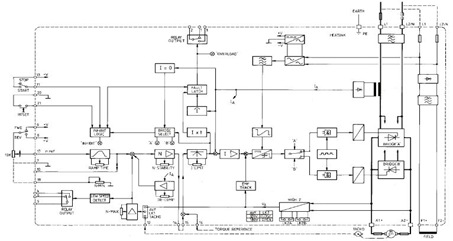
The 4Q2 DC Motor Speed Controller Circuit and Datasheet
This figure represents the 4Q2 DC Motor Speed Controller Circuit Block Diagram, designed for comprehensive control of conventional shunt-wound and permanent magnet motors with a capacity of up to 75 kW, as specified in the datasheet. This type of DC...
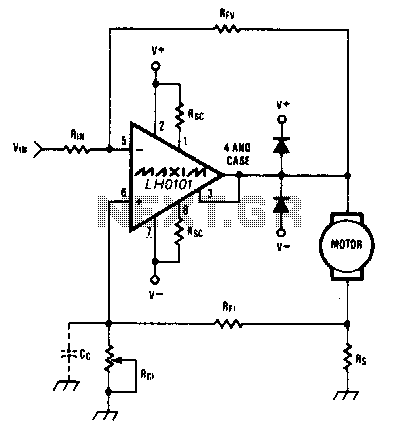
Constant-speed-motor-driver
When the torque load on the motor increases, its current also rises. This increase in current is detected across Rs, and positive feedback is applied to the noninverting terminal of the LH0101, which in turn raises the motor voltage to...
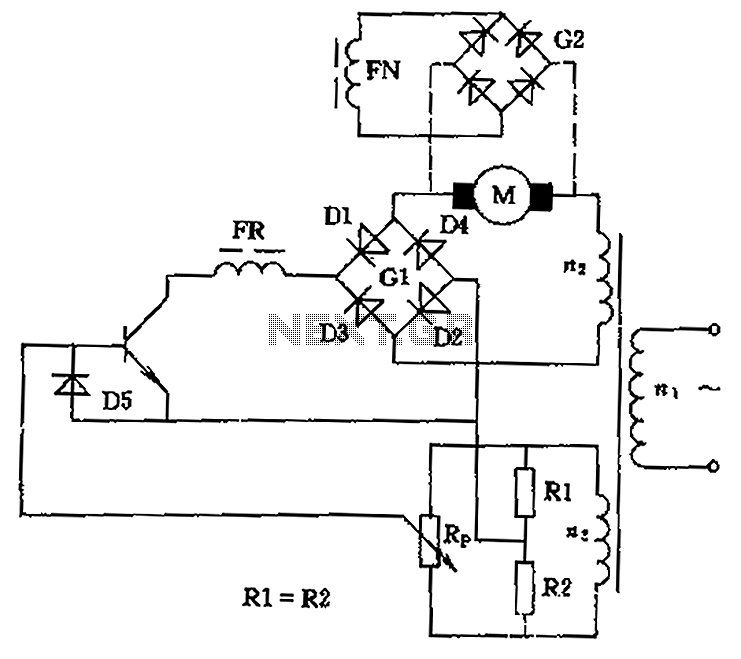
DC motor speed control circuit diagram of a song
The circuit is designed to control the speed and direction of low-power DC motors, including series and shunt motors. It utilizes a rectifier bridge (G1) connected in series with the motor and linked to the secondary winding (n2) of a...