


controlling a dc motor with an arduino uno
#arduino
#DC motor
#H-bridge
#motor control
#keyboard input
#programming
#Uno
#direction control
#PWM
#driver
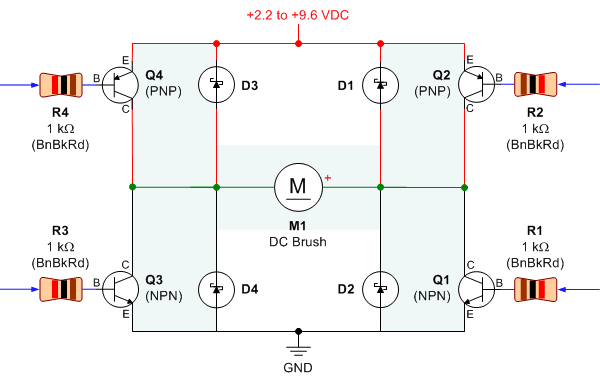
Description: Control a small DC motor using an H-bridge with an Arduino Uno. The objective is to enable the motor to rotate in different directions based on left and right key presses on a keyboard. The provided code includes the setup for the motor control but requires adjustments.
The circuit utilizes an H-bridge configuration to control the direction of a small DC motor. The H-bridge is composed of four transistors (or MOSFETs) that allow for the application of voltage across the motor terminals in either direction, enabling forward and reverse rotation. The Arduino Uno serves as the control unit, interfacing with the H-bridge through digital output pins.
In this setup, four output pins from the Arduino are designated for controlling the H-bridge: resistor1, resistor2, resistor3, and resistor4. The Arduino is programmed to listen for serial input, which corresponds to keyboard commands. The ASCII values for the keyboard inputs are utilized to determine the direction of the motor. Specifically, the left arrow key corresponds to the value 37, the up arrow to 38, the right arrow to 39, and the down arrow to 40.
The setup function initializes the serial communication at a baud rate of 9600 and configures the output pins accordingly. The loop function continuously checks for available serial input. When a key is pressed, the Arduino reads the incoming byte and compares it to the predefined ASCII values. If the left arrow key is pressed (ASCII value 37), the program sets the output pins to HIGH to activate the H-bridge, allowing the motor to rotate in one direction.
To enhance the functionality, additional conditions can be implemented for the right arrow key (ASCII value 39) to reverse the motor's direction. Furthermore, it is advisable to include error handling to manage unexpected inputs and ensure the system operates smoothly. The code may also be expanded to include features such as speed control through PWM signals, allowing for variable motor speeds based on additional keyboard inputs.Control a small DC motor through this H-bridge with an Arduino Uno, but I have never programmed one of these controllers before. I need the motor to rotate in different directions when I press left and right on a keyboard. So far I have this code: // Right Motor /* Adjust these values for your servo and setup, if necessary */ int re
sistor1 = 3; int resistor2 = 5; int resistor3 = 6; int resistor4 = 10; int moveServo; void setup() { Serial. begin(9600); pinMode(resistor1, OUTPUT); // Set servo pin as an output pin pinMode(resistor2, OUTPUT); pinMode(resistor3, OUTPUT); pinMode(resistor4, OUTPUT); } void loop() { // Wait for serial input if (Serial.
available() > 0) { // Read the incoming byte: moveServo = Serial. read(); // ASCII left = 37, up = 38, right = 39, down = 40 if (moveServo = 37) { digitalWrite(resistor4, HIGH); digitalWrite(resistor1, HIGH); } }
The circuit utilizes an H-bridge configuration to control the direction of a small DC motor. The H-bridge is composed of four transistors (or MOSFETs) that allow for the application of voltage across the motor terminals in either direction, enabling forward and reverse rotation. The Arduino Uno serves as the control unit, interfacing with the H-bridge through digital output pins.
In this setup, four output pins from the Arduino are designated for controlling the H-bridge: resistor1, resistor2, resistor3, and resistor4. The Arduino is programmed to listen for serial input, which corresponds to keyboard commands. The ASCII values for the keyboard inputs are utilized to determine the direction of the motor. Specifically, the left arrow key corresponds to the value 37, the up arrow to 38, the right arrow to 39, and the down arrow to 40.
The setup function initializes the serial communication at a baud rate of 9600 and configures the output pins accordingly. The loop function continuously checks for available serial input. When a key is pressed, the Arduino reads the incoming byte and compares it to the predefined ASCII values. If the left arrow key is pressed (ASCII value 37), the program sets the output pins to HIGH to activate the H-bridge, allowing the motor to rotate in one direction.
To enhance the functionality, additional conditions can be implemented for the right arrow key (ASCII value 39) to reverse the motor's direction. Furthermore, it is advisable to include error handling to manage unexpected inputs and ensure the system operates smoothly. The code may also be expanded to include features such as speed control through PWM signals, allowing for variable motor speeds based on additional keyboard inputs.Control a small DC motor through this H-bridge with an Arduino Uno, but I have never programmed one of these controllers before. I need the motor to rotate in different directions when I press left and right on a keyboard. So far I have this code: // Right Motor /* Adjust these values for your servo and setup, if necessary */ int re
sistor1 = 3; int resistor2 = 5; int resistor3 = 6; int resistor4 = 10; int moveServo; void setup() { Serial. begin(9600); pinMode(resistor1, OUTPUT); // Set servo pin as an output pin pinMode(resistor2, OUTPUT); pinMode(resistor3, OUTPUT); pinMode(resistor4, OUTPUT); } void loop() { // Wait for serial input if (Serial.
available() > 0) { // Read the incoming byte: moveServo = Serial. read(); // ASCII left = 37, up = 38, right = 39, down = 40 if (moveServo = 37) { digitalWrite(resistor4, HIGH); digitalWrite(resistor1, HIGH); } }
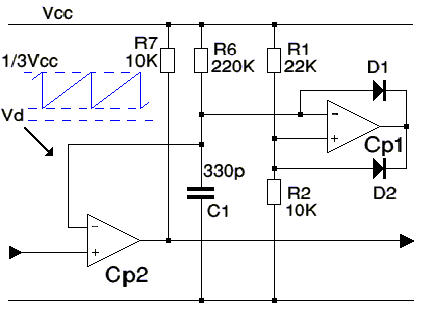
Levitation PWM
The switched controller utilized is effective; however, a pulse width modulation (PWM) circuit is more advantageous. It offers efficient operation with reduced heat generation and provides linear functioning. The implementation requires a minimal number of components. When capacitor C1 is...
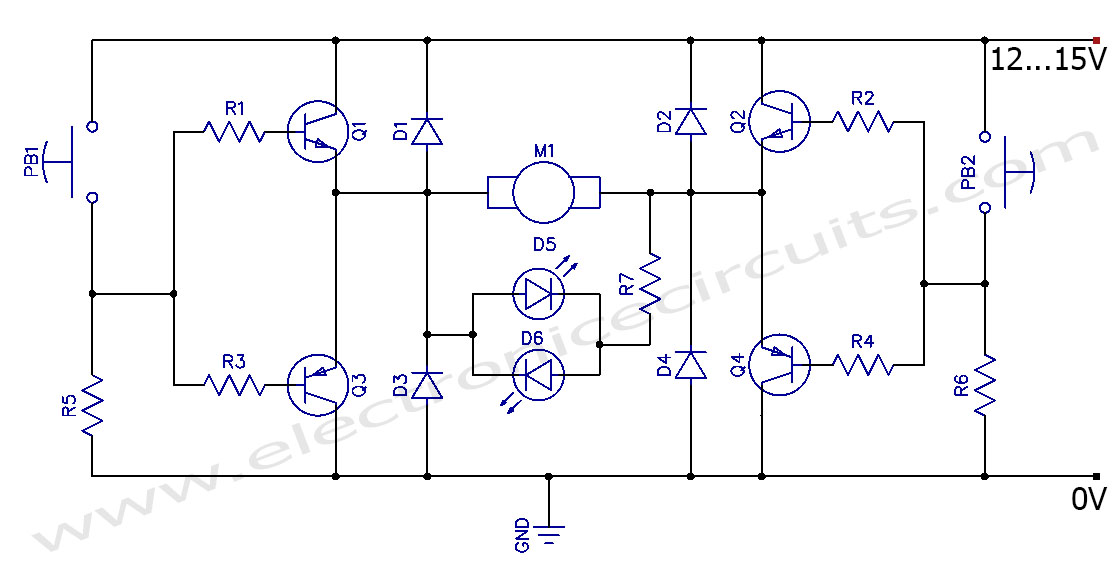
DC Motor Clockwise Anticlockwise Control H-bridge Circuit
This circuit can control the direction of a DC motor, allowing it to operate in both clockwise and counterclockwise directions (forward and backward).
The described circuit employs an H-bridge configuration, which is essential for reversing the polarity of the voltage applied...
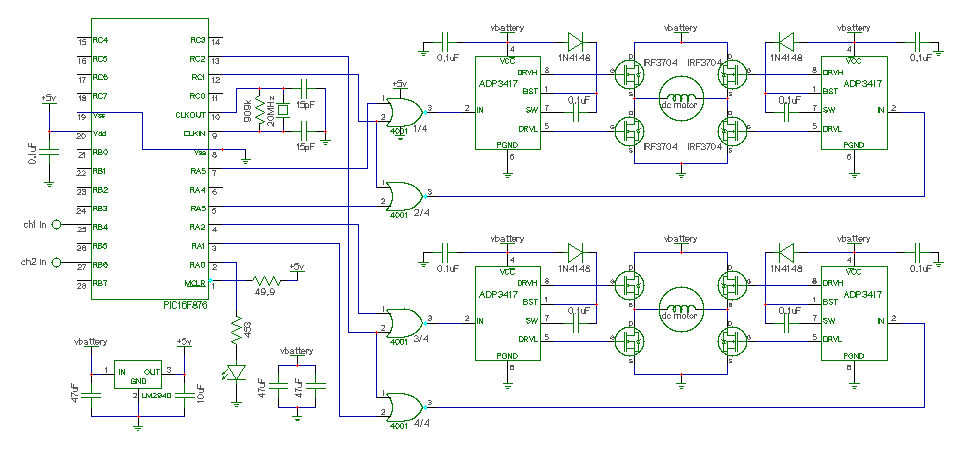
Dual DC motor speed control
Here is a design for a DC motor speed control featuring: Efficient PWM H-bridge MOSFET architecture. Supply (battery) voltage range from 4.2 to 13 volts. High current capacity for driving large motors (65 amps max). Input compatible with standard RC...
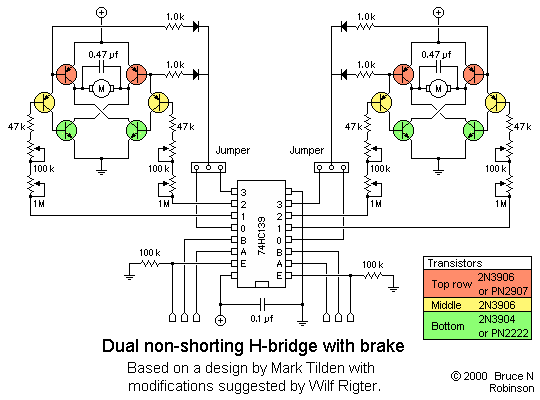
H-bridge
It was previously assumed that dynamic braking would be most effective at higher speeds. However, tests conducted with a Faulhaber (Micro Mo) gear motor demonstrated that the brake could hold the motor almost stationary. These gear motors are constructed so...
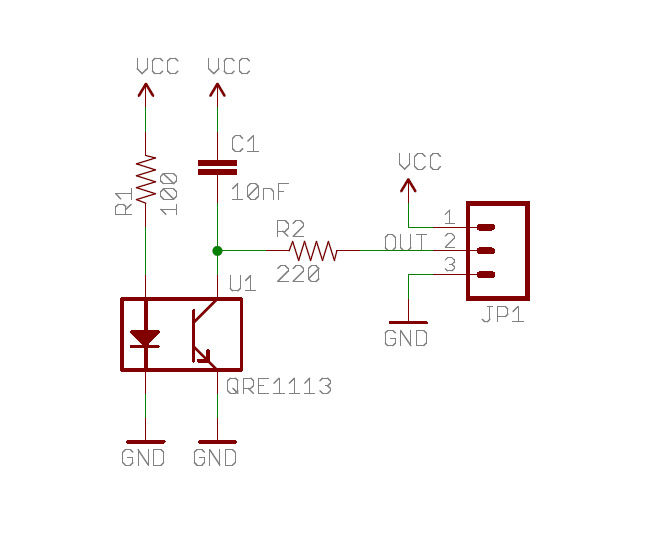
Honey Bee Counter Circuit
A real-time clock turns off the counter at night to conserve power. When a bee crosses under the LED, the light is reflected back to the sensor, which is a phototransistor, and triggers a digital input to the Arduino (or...
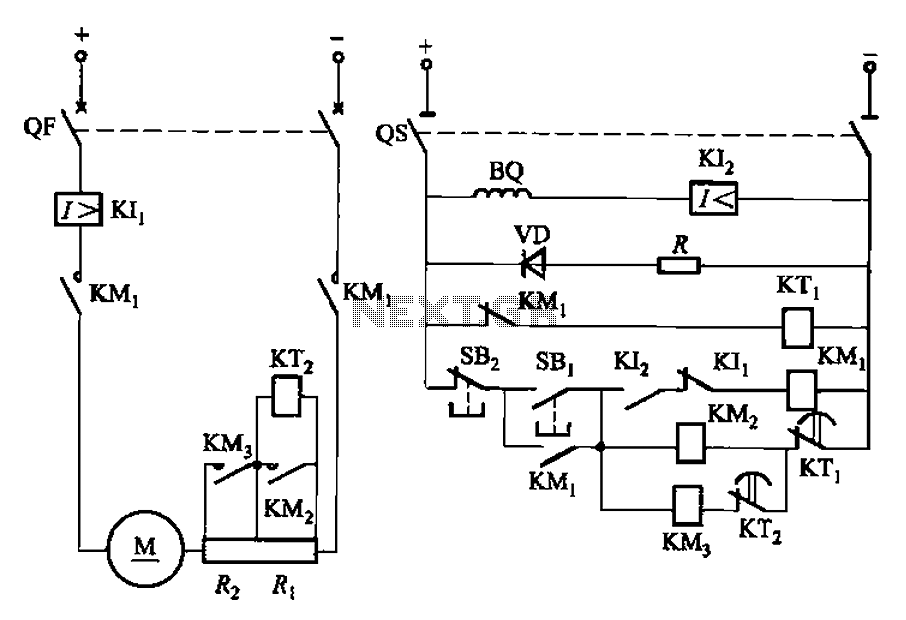
DC motor armature resistance in series to start debugging circuit 2
The circuit illustrated in Figure 3-191 features a DC motor armature circuit that includes two series startup resistors, Ri and Rz. The operation of the motor is controlled using buttons for starting and stopping. During the startup phase, two relays,...
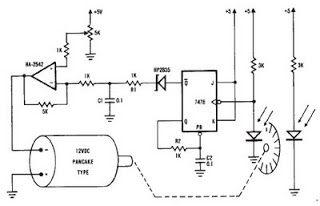
dc motor 12v speed controller circuit
A simple encoder circuit for a DC motor can be constructed using the provided circuit diagram. The system includes the HA-2542 operational amplifier, a small 12 V DC motor, and a position encoder. During operation, the encoder generates a series...
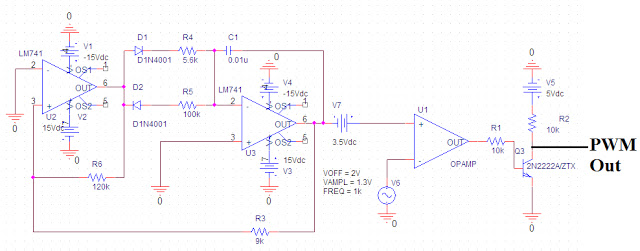
pulse width modulation
Pulse Width Modulation (PWM) is a highly efficient control scheme utilized to regulate the flow of power through various electronic devices. It is commonly found in switched-mode power supplies, LED dimming circuits, and variable speed motor controls, among other applications....
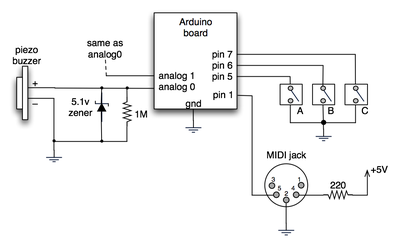
spooky arduino projects 4 and musical arduino
The notes for the fourth and final class are available on the Spooky Arduino class page. At the conclusion of the class, Mark from Machine Project awarded each student a merit badge. A project utilizing techniques from this week's class...