


Bridge motor drive circuit
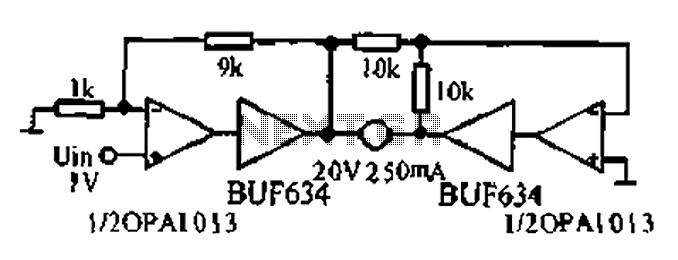
Description: A bridge motor drive circuit is illustrated, featuring a driving stage composed of four transistors. The control circuit includes four terminals labeled A, B, C, and D, which facilitate the control of forward or reverse motor rotation. The control mode can be operated either manually or automatically.
The bridge motor drive circuit is designed to control the direction and speed of a DC motor using a H-bridge configuration. The circuit consists of four transistors arranged in a bridge formation, allowing for efficient control of the motor's operation. The transistors are typically N-channel MOSFETs or bipolar junction transistors (BJTs) capable of handling the required current and voltage levels for the motor.
The four terminals A, B, C, and D serve as inputs to the control circuit. When specific combinations of these inputs are activated, they switch the transistors on and off in a manner that determines the motor's direction. For example, activating terminals A and B may cause the motor to rotate in one direction, while activating terminals C and D would reverse the rotation. This configuration enables bidirectional control of the motor, making it suitable for applications requiring precise movement.
The control mode can be set to manual, allowing an operator to directly control the motor's direction using switches or buttons connected to the terminals. Alternatively, an automatic control mode can be implemented, where a microcontroller or other automation system manages the inputs based on pre-defined parameters or sensor feedback. This flexibility in control methods enhances the circuit's versatility for various applications, from robotics to conveyor systems.
Additionally, protective components such as diodes may be included to prevent back EMF generated by the motor from damaging the transistors. Heat sinks may also be necessary to dissipate heat generated during operation, ensuring reliable performance and longevity of the circuit. Overall, the bridge motor drive circuit provides an effective solution for controlling motor functions in a wide range of electronic and electromechanical systems. Bridge motor drive circuit Bridge motor drive circuit is shown, the driving stage of the circuit is 4 transistors. The control circuit is provided with four ends, through to A, B, C, D can control the forward or reverse rotation control. Control mode can be used manually or automatically.
The bridge motor drive circuit is designed to control the direction and speed of a DC motor using a H-bridge configuration. The circuit consists of four transistors arranged in a bridge formation, allowing for efficient control of the motor's operation. The transistors are typically N-channel MOSFETs or bipolar junction transistors (BJTs) capable of handling the required current and voltage levels for the motor.
The four terminals A, B, C, and D serve as inputs to the control circuit. When specific combinations of these inputs are activated, they switch the transistors on and off in a manner that determines the motor's direction. For example, activating terminals A and B may cause the motor to rotate in one direction, while activating terminals C and D would reverse the rotation. This configuration enables bidirectional control of the motor, making it suitable for applications requiring precise movement.
The control mode can be set to manual, allowing an operator to directly control the motor's direction using switches or buttons connected to the terminals. Alternatively, an automatic control mode can be implemented, where a microcontroller or other automation system manages the inputs based on pre-defined parameters or sensor feedback. This flexibility in control methods enhances the circuit's versatility for various applications, from robotics to conveyor systems.
Additionally, protective components such as diodes may be included to prevent back EMF generated by the motor from damaging the transistors. Heat sinks may also be necessary to dissipate heat generated during operation, ensuring reliable performance and longevity of the circuit. Overall, the bridge motor drive circuit provides an effective solution for controlling motor functions in a wide range of electronic and electromechanical systems. Bridge motor drive circuit Bridge motor drive circuit is shown, the driving stage of the circuit is 4 transistors. The control circuit is provided with four ends, through to A, B, C, D can control the forward or reverse rotation control. Control mode can be used manually or automatically.
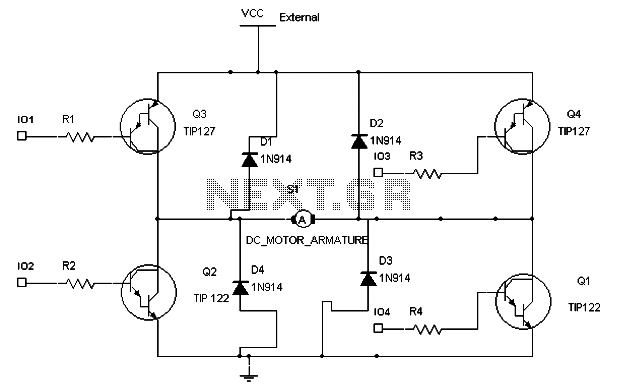
The H-Bridge Circuit Control Design in DC Motor Application
To maintain a constant speed of the motor under varying load conditions, a control application circuit is required. An H-Bridge circuit can be utilized to manage both the speed and direction of the motor. The accompanying diagram illustrates the H-Bridge...
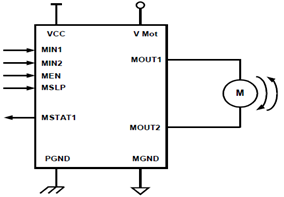
5A H-Bridge Module Pinout Circuit Schematic for Bipolar DC Motor
The schematic presented illustrates a 5A H-Bridge Module designed for the operation of a single Bipolar DC motor. The H-Bridge Module includes a header set (J2) and a connector terminal set (J1). Below is the pinout description for the J2...
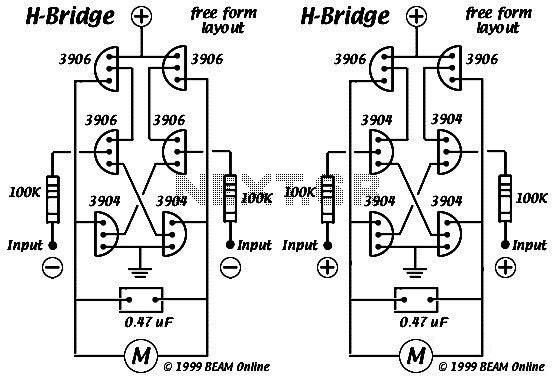
6 Transistor Tildens H-Bridge
This diagram illustrates the 6 transistor Tilden H-bridge circuit. Although it is not as old as the original basic H-bridge, it has a long history and serves as the foundation for many BEAM driver circuits. Bruce Robinson provides an explanation...
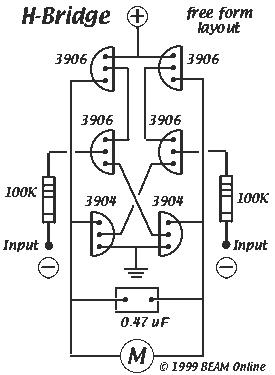
6-transistor H-bridge
Mark Tilden's 6-transistor H-bridge Design, limitations, usage
This is the six transistor "Tilden style" H-bridge; while not as old as the original "basic H-bridge," this goes "way back," and is the basis for many BEAM driver circuits.
* Up to 800 mA...
Motor Controller
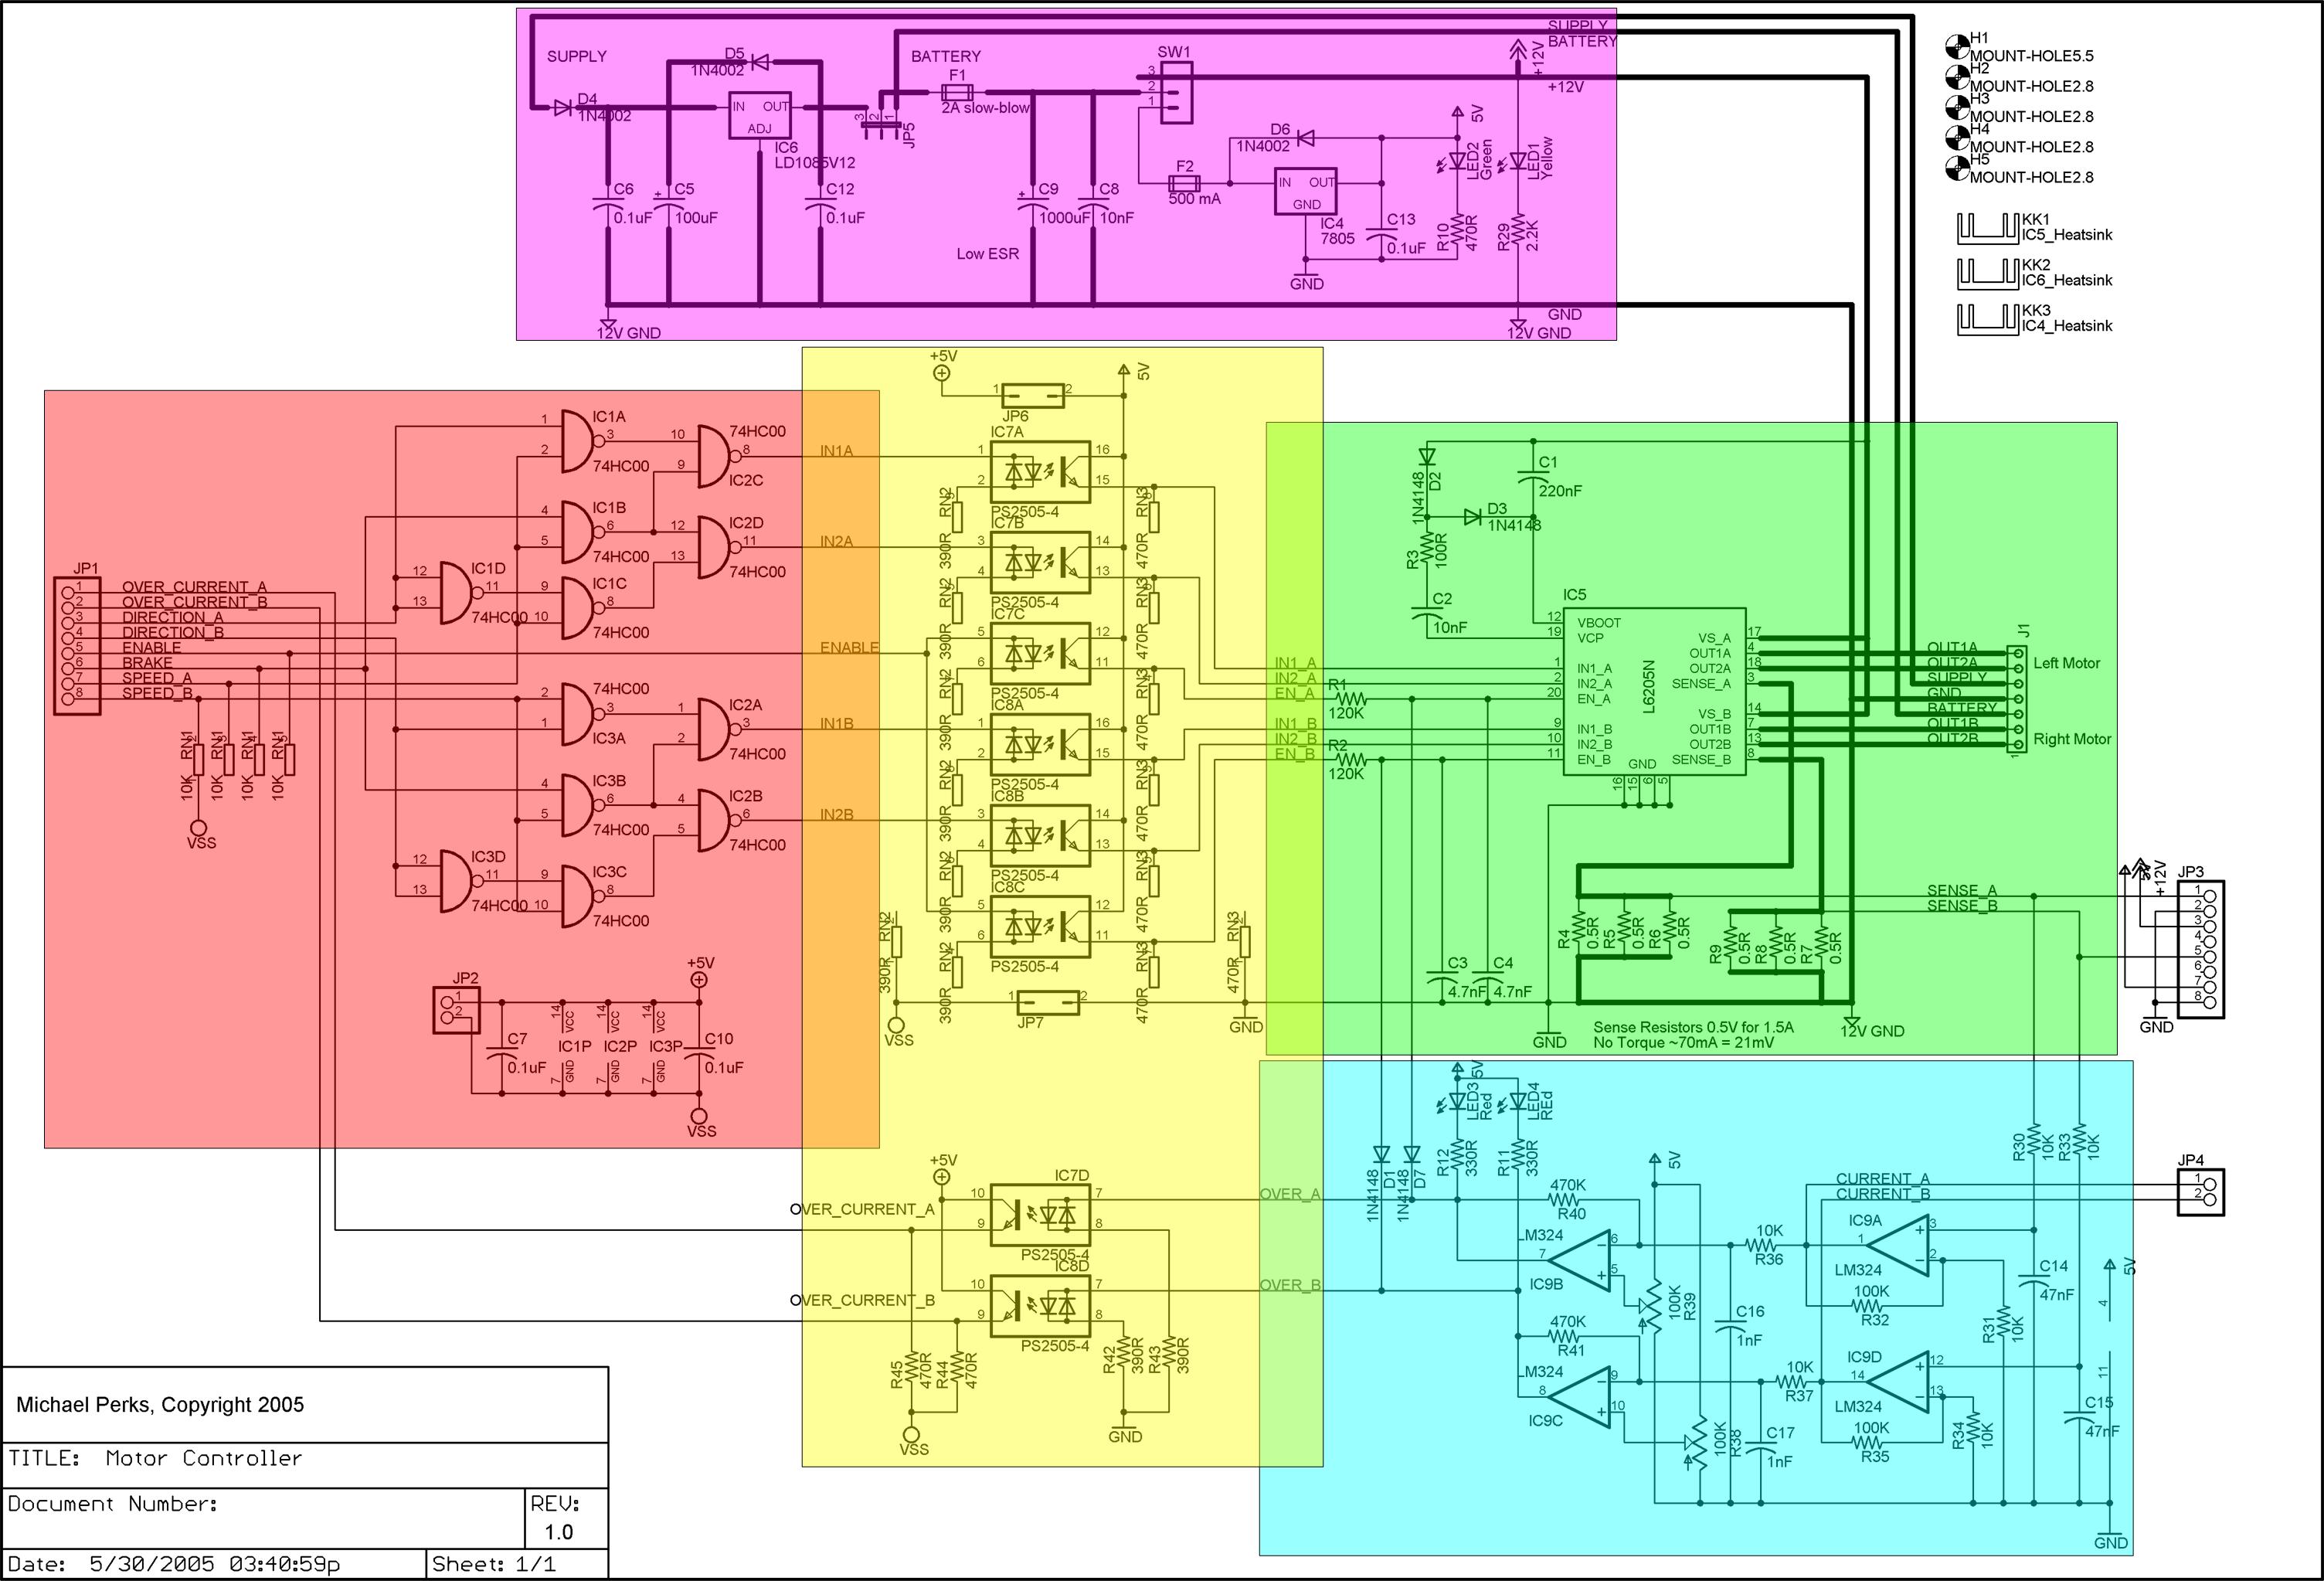
A dual DC motor controller employs an H-bridge controller chip. In addition to the standard features of the H-bridge driver chip, such as thermal and over-current protection, the circuit supports dual 12V/5V regulated power supplies, sign/magnitude and brake driver logic,...
current simple h-bridge polarity reversal
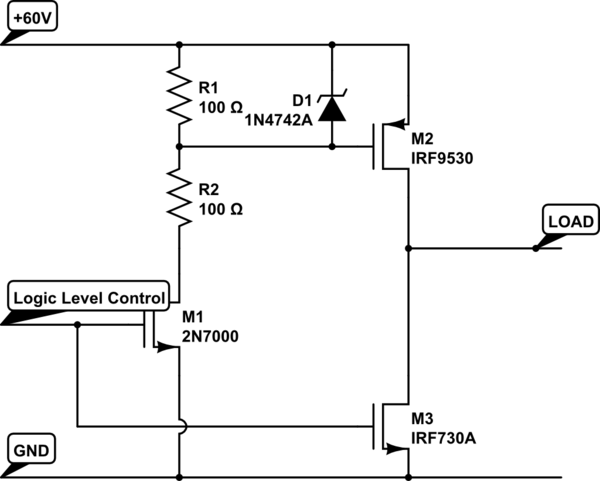
Construct an H-bridge specifically for reversing current, as speed control is managed separately. Is it feasible to connect two N-channel MOSFETs and two P-channel MOSFETs to an IO pin from the microcontroller (with appropriate resistors), or is the process more...
Lie detector
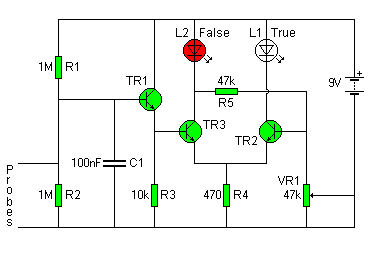
The circuit diagram of the Lie Detector is illustrated above. It consists of three transistors (TR1 to TR3), a capacitor (C1), two lights or LEDs (L1 & L2), five resistors (R1 to R5), and a variable resistor (VR1). This circuit...
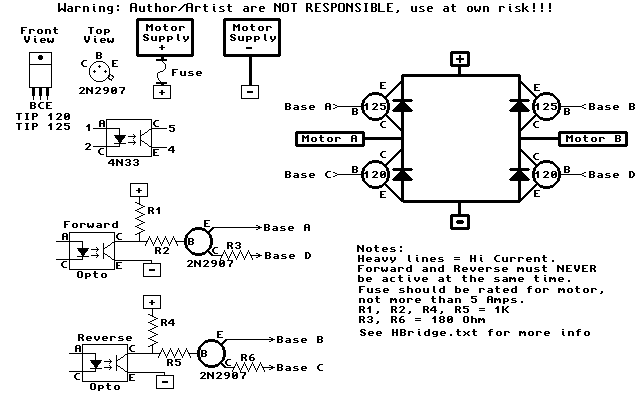
H-Bridge
The HandyBoard operates both pads using the positive supply from the battery. When one of the motors is intended to turn, the HandyBoard activates the corresponding pin to 0V. The voltage difference between the two pads causes the motor to...
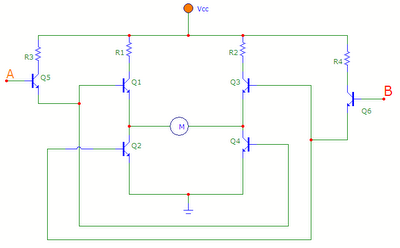
H-bridge circuit using NPN transistors
The transistors Q1, Q2, Q3, and Q4 form a bridge circuit. These are typically power transistors designed to handle high current. Transistors Q5 and Q6 drive the bridge. When input A is set high and input B is set low,...