
Bipolar stepper motor control with Picaxe and L293D
#Picaxe
#L293D
#bipolar stepper motor
#serial interface
#robot arm
#motor driver
#stepper control
#microcontroller
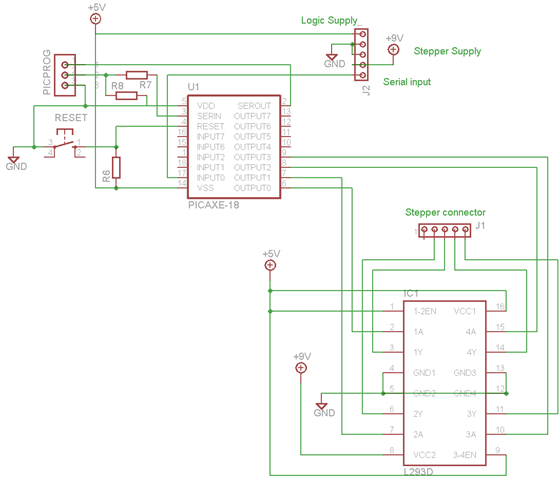
Description: A schematic and program have been developed for operating a bipolar stepper motor through a serial interface, similar to the unipolar configuration. This is significant for the robot arm project, as two of the three stepper motors will be bipolar. In contrast to the unipolar stepper, which requires only current to be applied in one direction, the bipolar stepper motor necessitates a more complex driving mechanism.
The schematic for the bipolar stepper motor control includes a microcontroller that communicates via a serial interface, allowing for precise control over the motor's operation. The bipolar stepper motor is characterized by its two coils, which must be energized in a specific sequence to achieve rotation. The microcontroller sends commands to a motor driver circuit, which handles the directional control and current flow to the coils.
In this configuration, the driver circuit typically employs H-bridge topology, enabling the reversal of current through the coils. This is essential for the bipolar motor operation, as it requires alternating current direction to step through its phases. The program running on the microcontroller includes algorithms for step control, allowing the motor to achieve desired speeds and positions based on input commands.
To ensure reliable operation, the schematic should incorporate necessary components such as current limiting resistors, flyback diodes for back EMF protection, and decoupling capacitors to stabilize the power supply. The choice of microcontroller and driver IC should be compatible with the required voltage and current specifications of the bipolar stepper motors.
Additionally, it is vital to consider the power supply requirements, as bipolar stepper motors typically require higher current ratings compared to unipolar motors. Proper heat dissipation measures should also be integrated into the design to prevent overheating of the driver circuit during prolonged operation.
In summary, the developed schematic and program provide a comprehensive solution for controlling bipolar stepper motors in robotic applications, enabling precise movement and positioning essential for the functionality of the robot arm.I`ve now got a schematic and program for running a bipolar stepper motor via a serial interface (just as for the unipolar case). This is important for the robot arm cause because two of the three steppers will be of the bipolar kind.
Where driving the unipolar stepper required only current `pushing` (ie all in.
POWER LINE MODEM FOR COMPUTER CONTROL
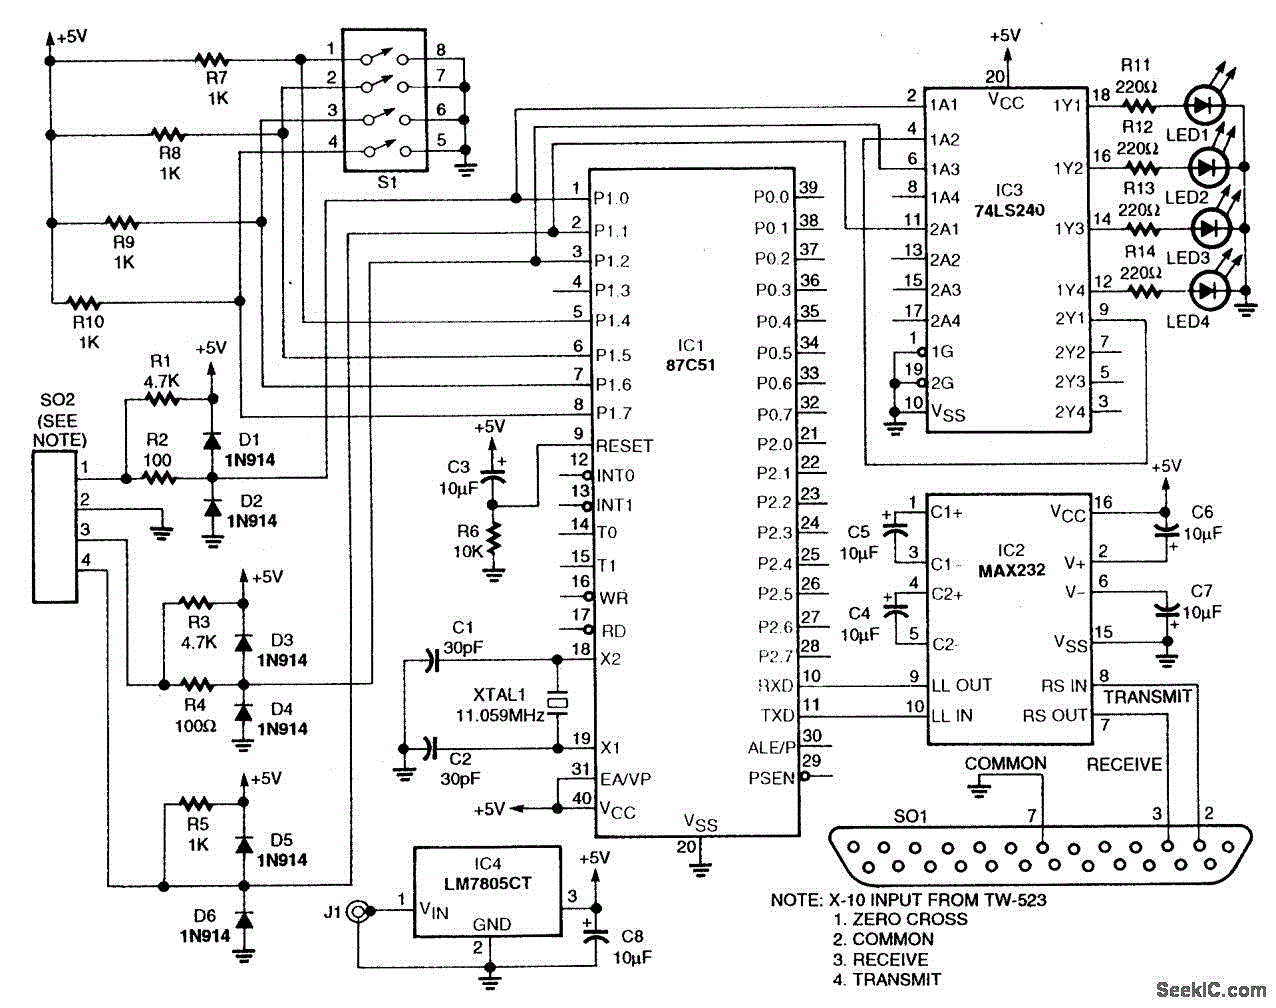
This circuit employs an 87C57 microcontroller along with several peripherals to convert X-10 power-line carrier-code formats from a personal computer for use with an X-10 power-line interface in a home-control system. Software details can be found in the reference.
The circuit...
home security system
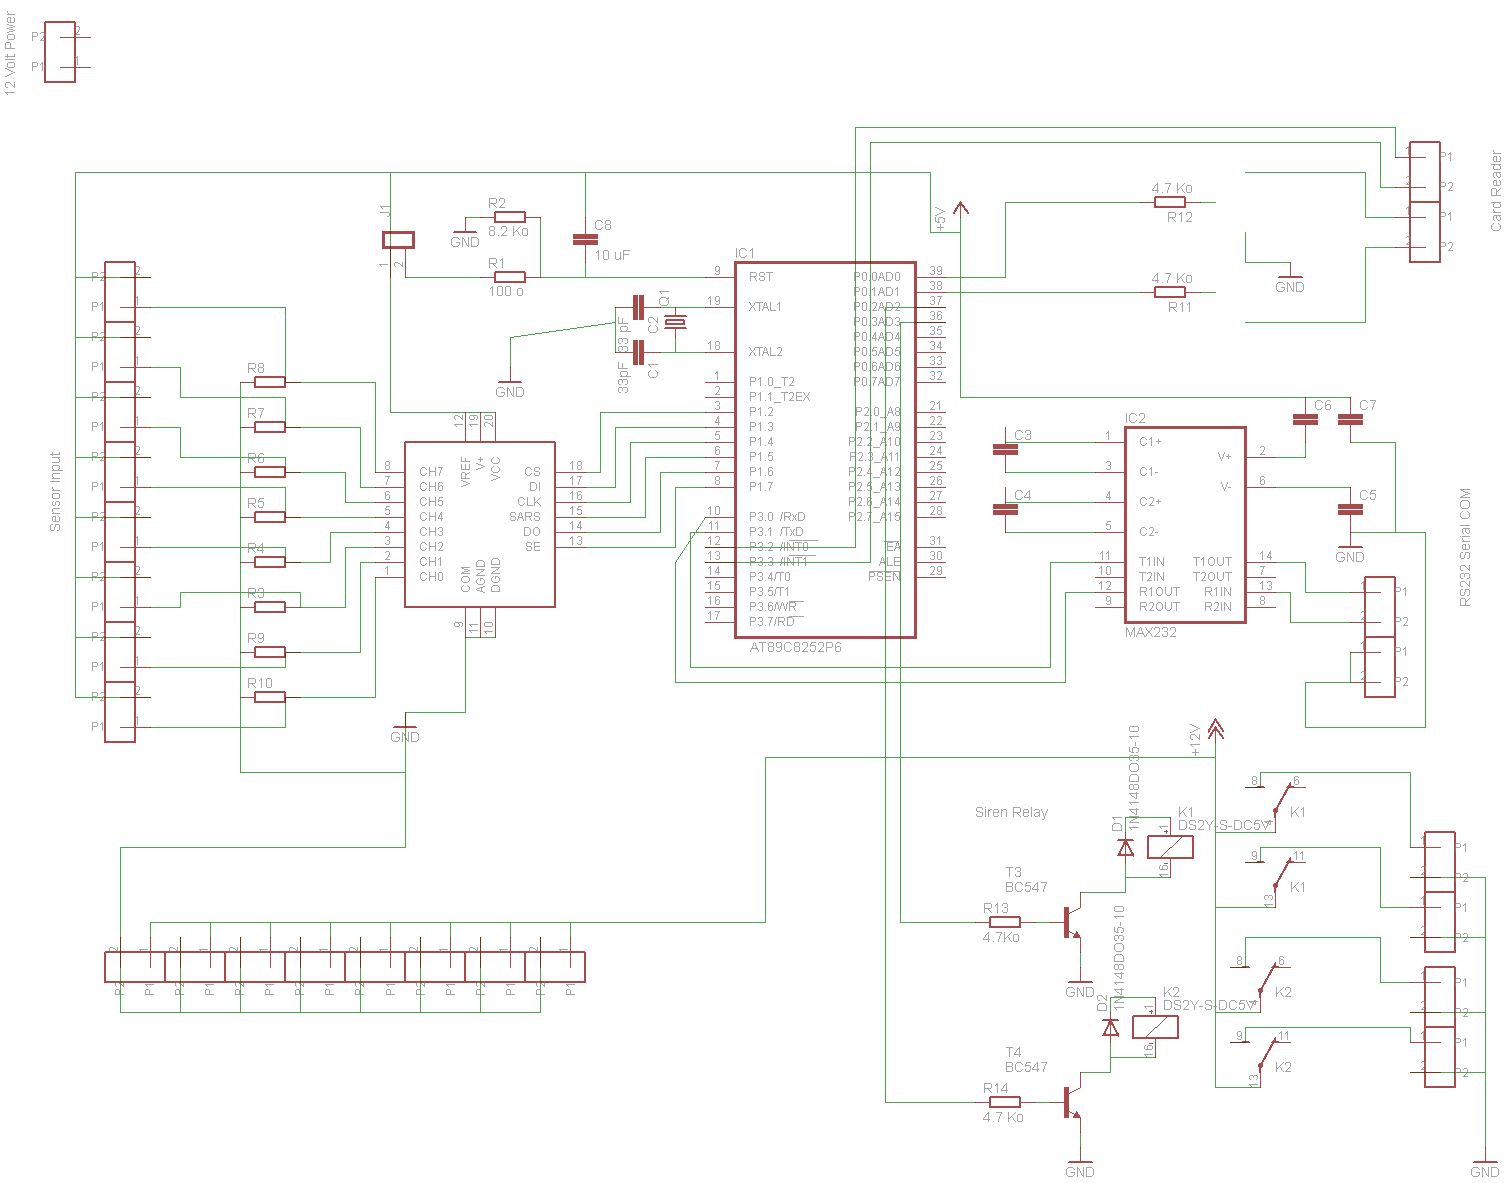
The fundamental design of this project employs an Atmel AT89S8252-24PC Microcontroller, which features 2KB of EEPROM for runtime data storage. An ADC0838CCN analog-to-digital converter will be utilized to process up to eight inputs from sensor devices, including passive infrared sensors...
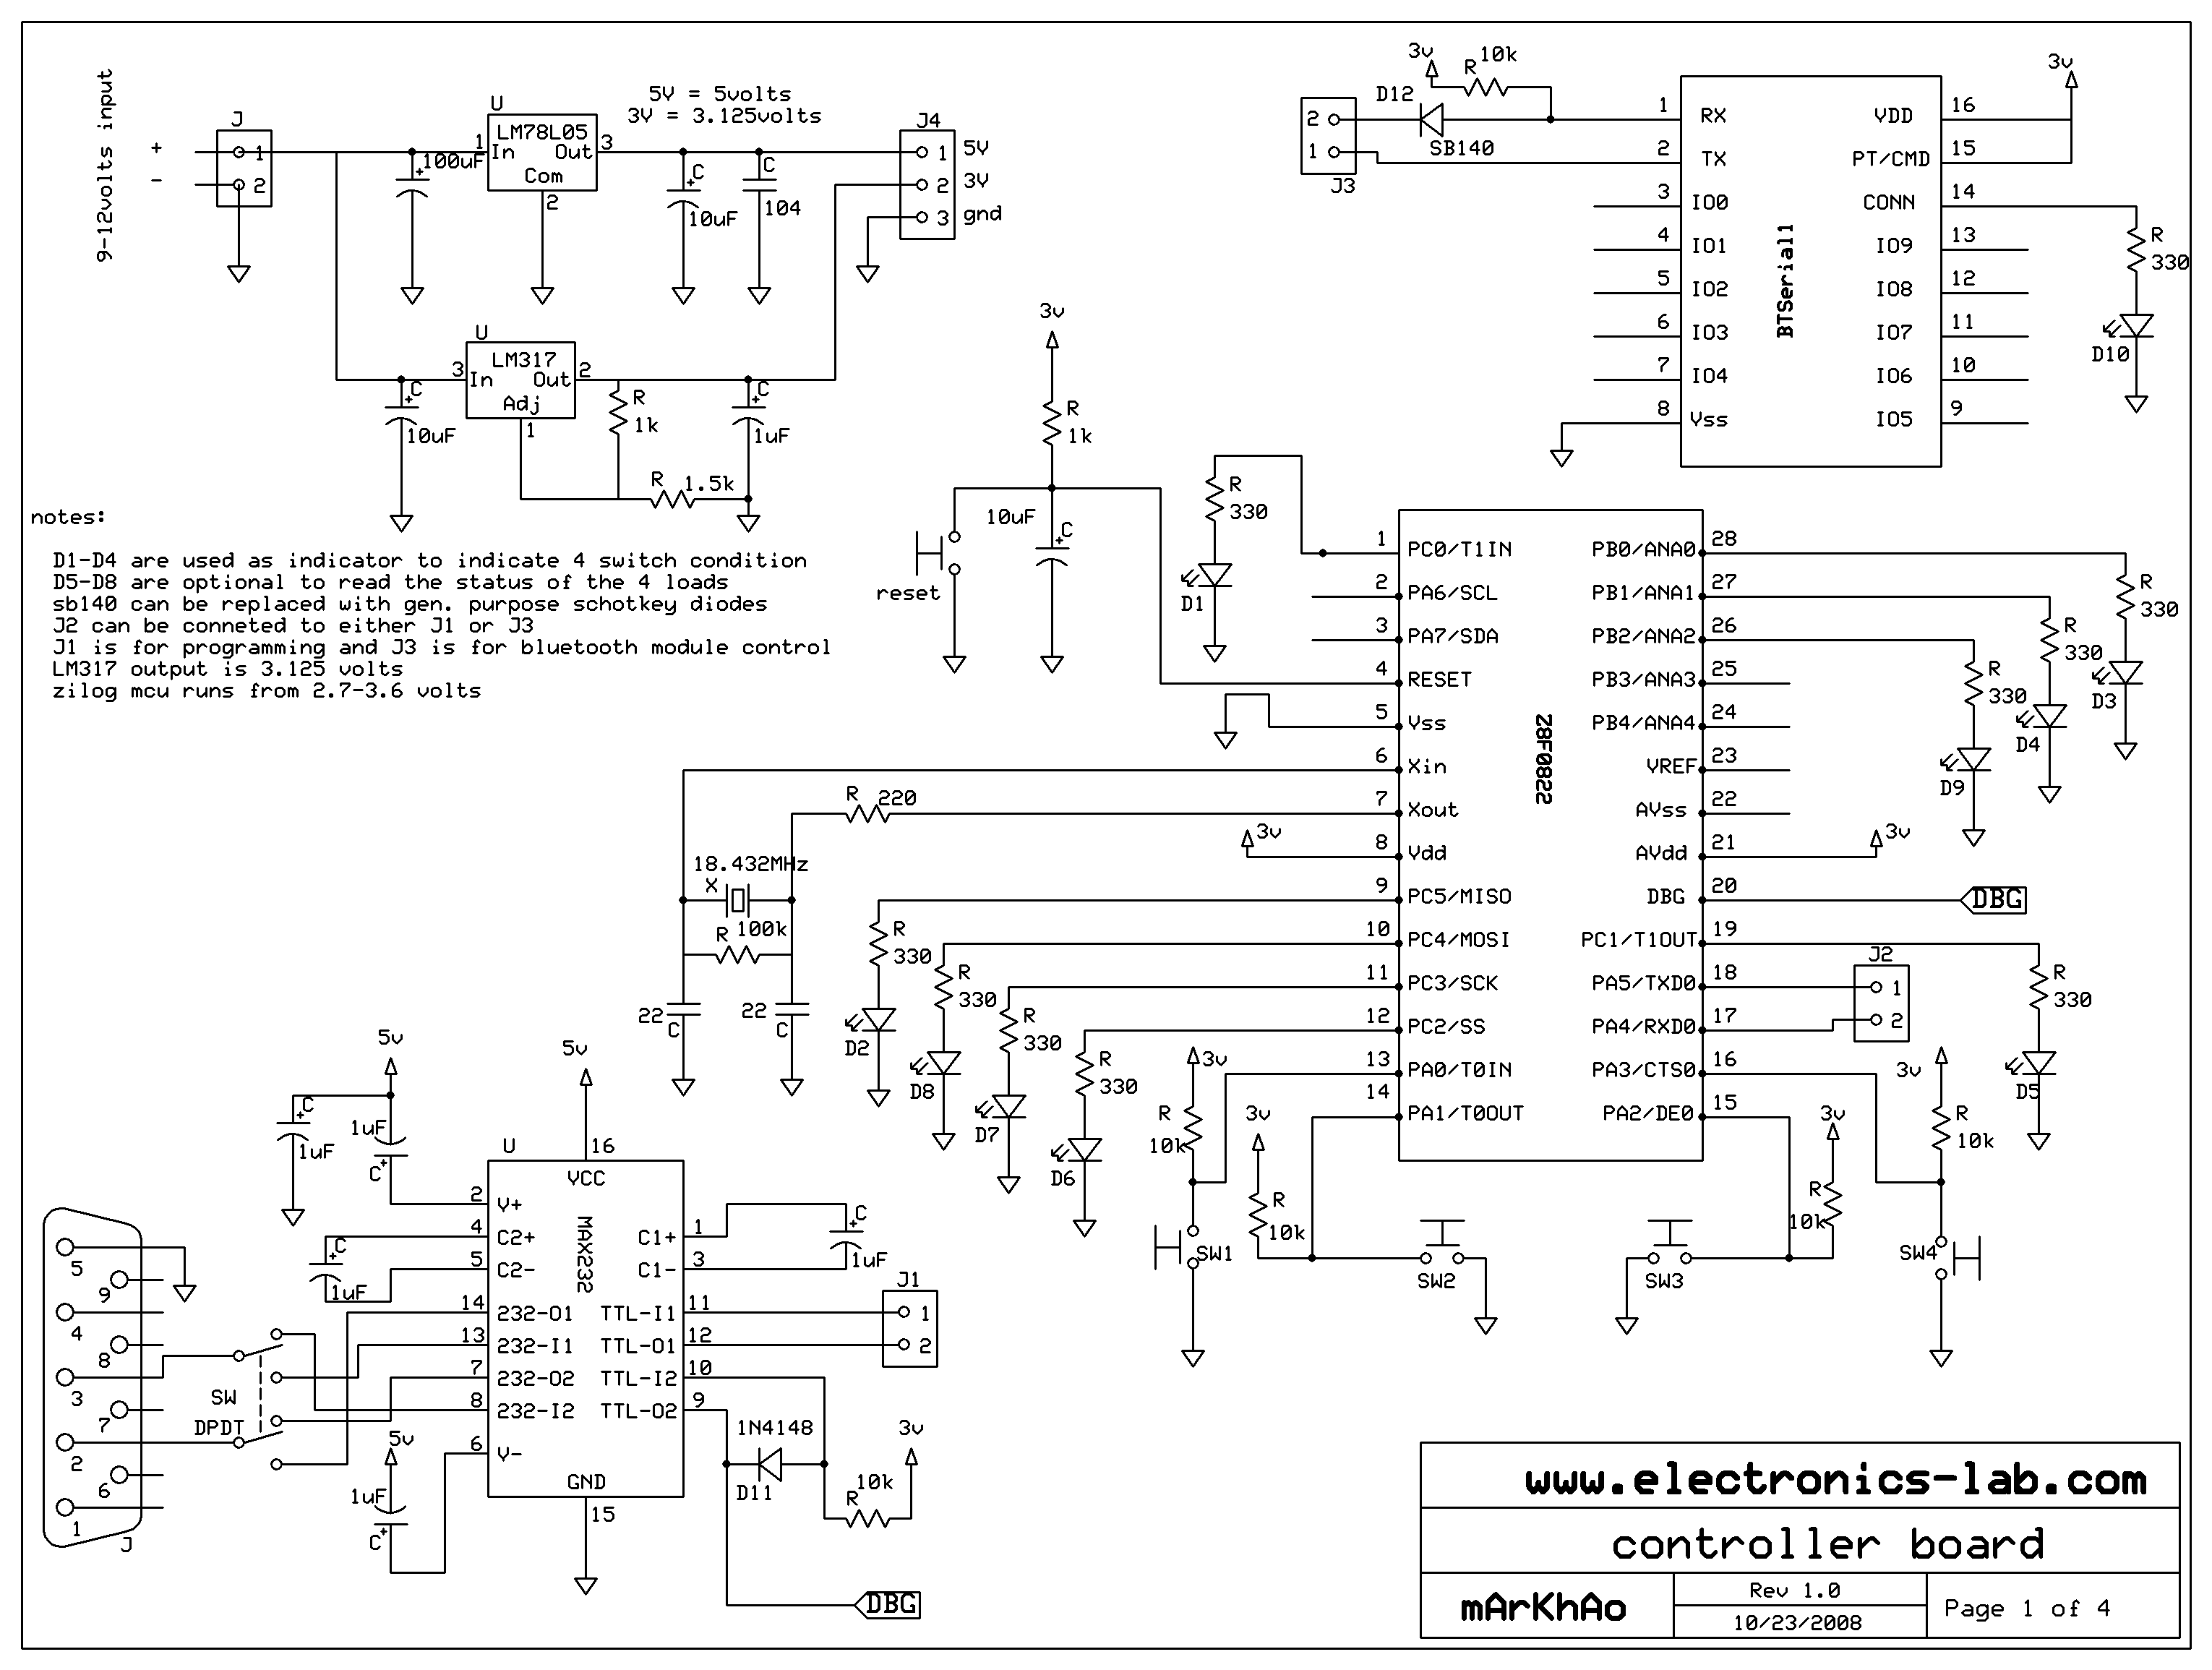
MCU controlled Bluetooth automation
The microcontroller used is 0822 zilog encore! 8k series (soic,28pin) as shown on the figure. Is a programmable microcontroller, the functions used are the GPIO and the UART of the chip. GPIO is used on led indicators, and the UART...
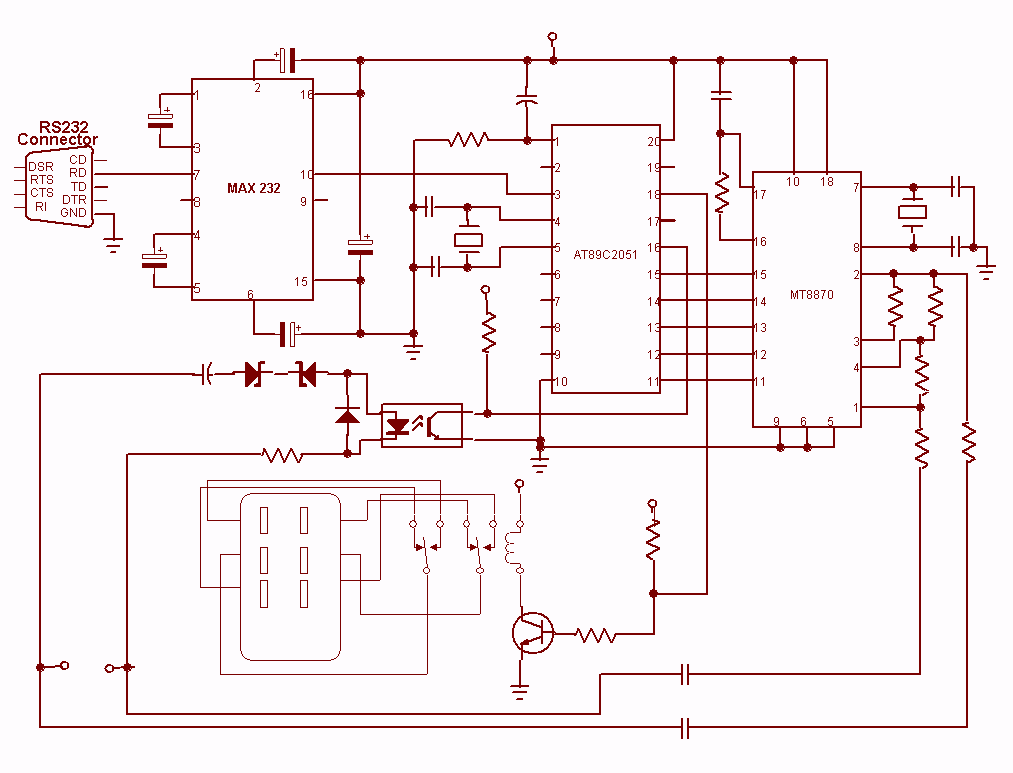
Interactive Voice Response System
Nowadays every institution needs automation. As a part of college automation, a project has been developed for a Voice Interactive System for College Automation. This project allows users to quickly access student attendance and marks through the telephone line without...
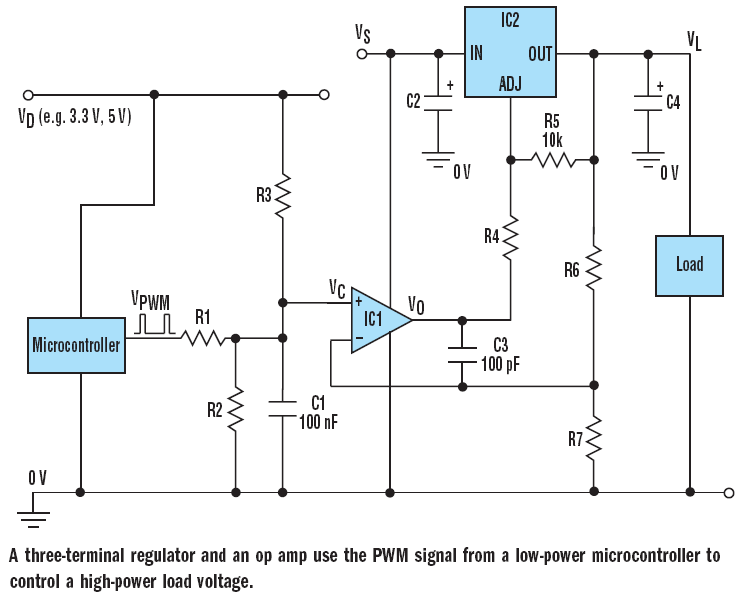
microcontroller How does this power supply circuit work? (MCU + LM317)
The filter consisting of resistors R1, R2, and capacitor C1 integrates the PWM waveform. The purpose of the operational amplifier appears to be that of a non-inverting amplifier, with the gain determined by resistors R6 and R7. However, the need...
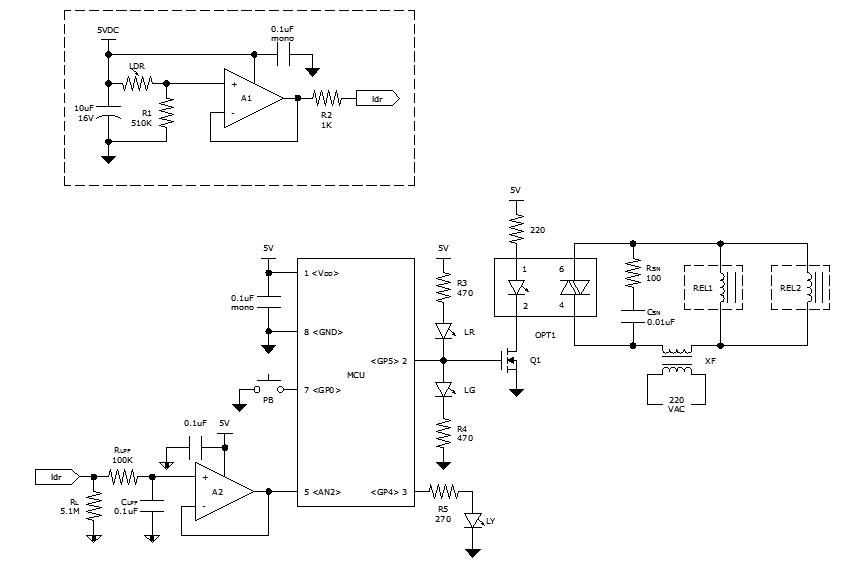
Microcontroller-based automatic night light circuit
While discussing an all-linear automatic night light circuit, it was mentioned that an MCU-based Automatic Night Light Controller (ANLC) was being tested. The firmware has been tweaked since then. Recently, the sensor was installed outdoors and connected to control 220VAC...
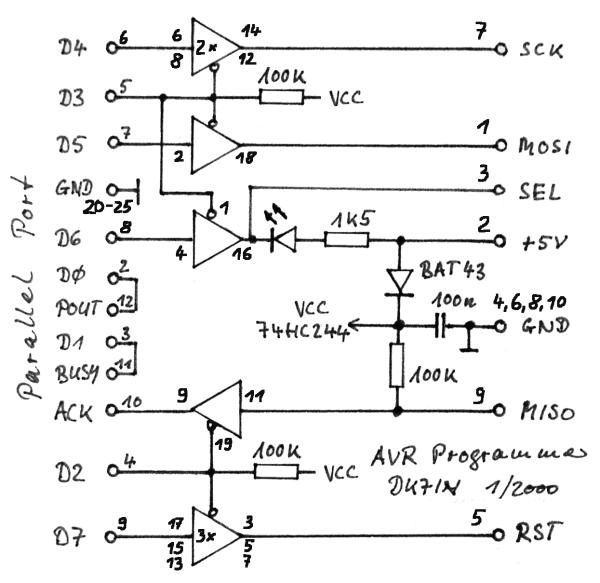
Microcontroller
The gap between TTL (Transistor-Transistor Logic) devices and personal computers can be effectively bridged with modern microcontrollers. These microcontrollers not only incorporate a central processing unit (CPU) but also include program and data memory, EEPROM, input/output (I/O) ports, timers, and...
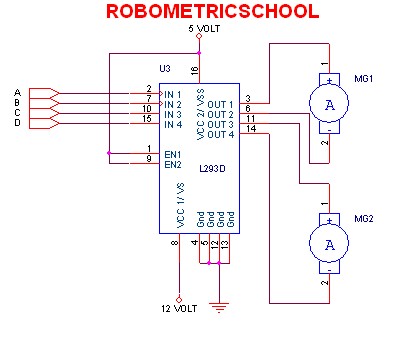
Electronic Circuit Schematic DC Motor Driver using L293D Dual H-Bridge
The electronic schematic of a DC motor driver using the L293D, as illustrated in Figure 2, enables the control of two DC motors continuously. It allows for one motor to rotate clockwise while the other rotates counterclockwise. Additionally, all motors...
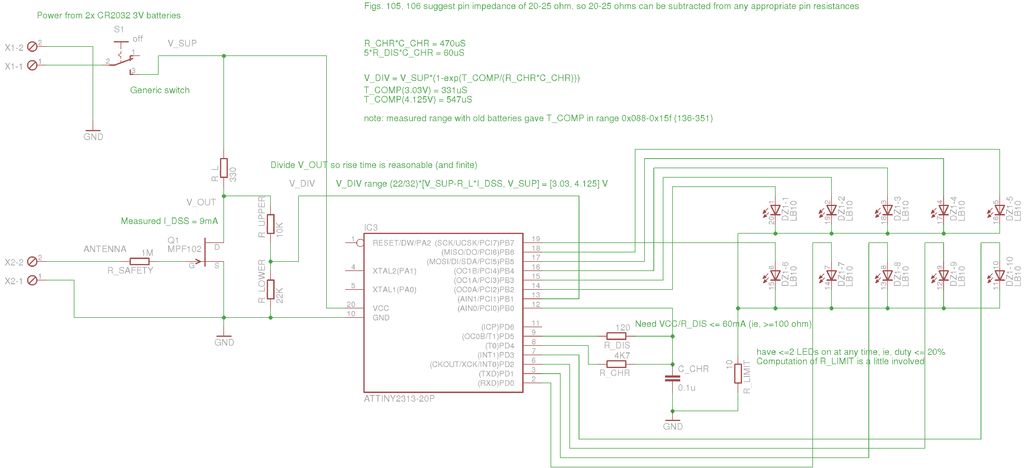
Microcontroller interface electrometer
A method for measuring static electricity for a science project was sought. An old copy of "Getting Started in Electronics" by Forrest M. Mims III was referenced for guidance.
To create a static electricity measurement circuit, a simple design can be...