
A Simple Dual H-Bridge
#H-bridge
#DC motor
#stepper motor
#L298
#MPC17529
#SN754410
#motor driver
#bipolar stepper motor
#dual H-bridge
#schematic
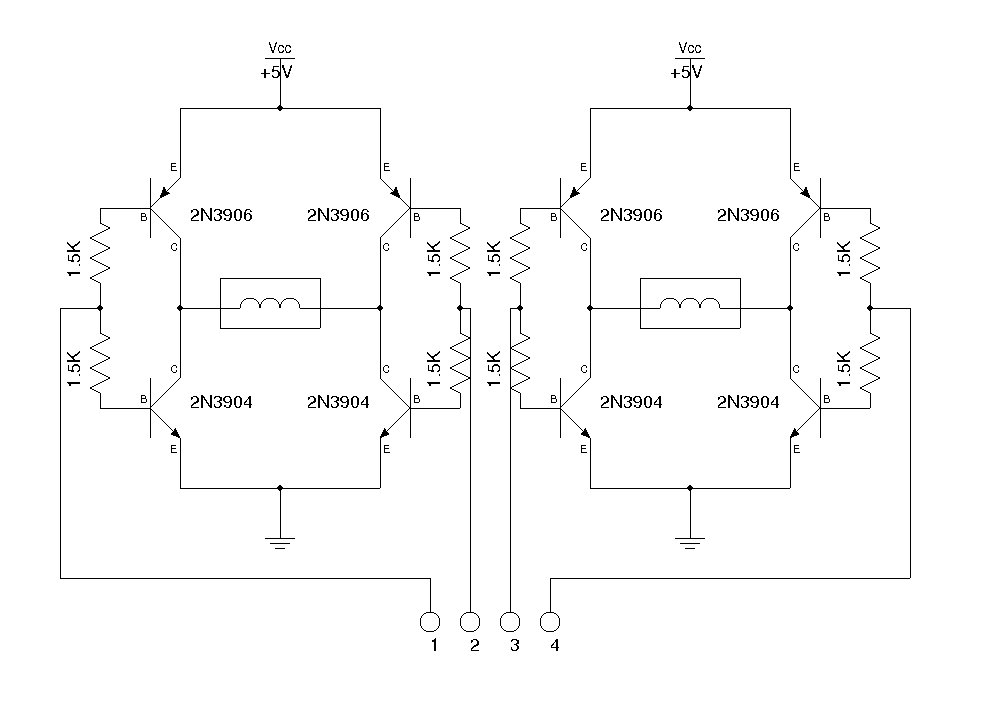
Description: An H-bridge is commonly utilized for controlling DC motors and stepper motors. When managing a bipolar stepper motor, two complete H-bridges are required. Numerous H-bridge integrated circuits (ICs) such as the L298, MPC17529, and SN754410 (a quad half H-bridge) are available for this application. However, for budget-conscious projects, constructing a dual H-bridge using discrete components is a viable option. The schematic provided illustrates a straightforward dual H-bridge design employing eight general-purpose transistors (2N3904 and 2N3906). With a maximum collector-emitter current (Iceo) of approximately 200mA, this circuit is suitable for driving small bipolar stepper motors operating within a voltage range of 5V to 12V, similar to those found in floppy drives and CD/DVD drives. The four control inputs (1, 2, 3, 4) can be directly controlled by the digital pins of an Arduino (specifically pins 2, 3, 4, and 5). The accompanying program demonstrates how to signal the four leads of a bipolar stepper motor to facilitate rotation. A dedicated stepper motor library is available for this purpose, but the provided code serves as a useful reference for understanding the pulse sequence required by bipolar stepper motors. The code initializes the control pins and defines a loop to manage the sequence of digital signals sent to the motor.
The dual H-bridge circuit configuration allows for bidirectional control of the stepper motor, enabling it to rotate in both clockwise and counterclockwise directions. Each transistor in the H-bridge acts as a switch, controlling the current flow to the motor coils. The transistors 2N3904 (NPN) and 2N3906 (PNP) are used to form the H-bridge, where pairs of transistors are activated in sequence to energize the coils of the stepper motor. This sequential activation creates a rotating magnetic field, which causes the motor to step through its phases.
The Arduino program initializes the control pins as outputs and enters a loop that cycles through a predefined sequence of HIGH and LOW signals. The delays between state changes are crucial for ensuring the stepper motor operates smoothly and accurately. Adjusting the delay values can modify the motor's speed, allowing for fine-tuning based on application requirements.
In practical applications, this setup can be employed in various devices where precise motor control is needed, such as in robotics, automated systems, or any project requiring controlled movement. The simplicity of using discrete transistors combined with the accessibility of Arduino programming makes this dual H-bridge design an excellent choice for hobbyists and engineers alike. The inclusion of an LED indicator in the circuit provides visual feedback of the power status, enhancing usability during development and testing phases.H-bridge is frequently used to control DC motors and stepper motors. When controlling a bipolar stepper motor, two full H-bridges are needed. There are many H-bridge ICs (like L298, MPC17529 and SN754410 which is a quad half H-bridge) for just that purpose. But if you are on a budget, you may want to consider building a dual H-bridge yourself. The following schematic shows a simple dual H-bridge using eight general purpose transistors ( 2N3904 and 2N3906 ). Given the maximum Iceo of roughly 200mA, this circuit can be used to drive a small bipolar stepper motor operating between 5V and 12V, such as the stepper motors found in most floppy drives and CD/DVD drives. The four control inputs (1, 2, 3, 4) can be driven with Arduino s digital pins (i. e. 2, 3, 4, 5) directly. The following program illustrates how to signal the four leads of a bipolar stepper motor for it to rotate.
Of course, there`s already a stepper motor library built for this purpose. The program below is helpful when learning the sequence of the pulses required by bipolar stepper motors. int coila1 = 2; int coila2 = 3; int coilb1 = 4; int coilb2 = 5; void setup() { pinMode(coila1, OUTPUT); pinMode(coila2, OUTPUT); pinMode(coilb1, OUTPUT); pinMode(coilb2, OUTPUT); } void loop() { digitalWrite(coila1, HIGH); digitalWrite(coila2, LOW); digitalWrite(coilb1, LOW); digitalWrite(coilb2, LOW); delay(10); digitalWrite(coila1, LOW); digitalWrite(coila2, LOW); digitalWrite(coilb1, HIGH); digitalWrite(coilb2, LOW); delay(01); digitalWrite(coila1, LOW); digitalWrite(coila2, HIGH); digitalWrite(coilb1, LOW); digitalWrite(coilb2, LOW); delay(10); digitalWrite(coila1, LOW); digitalWrite(coila2, LOW); digitalWrite(coilb1, LOW); digitalWrite(coilb2, HIGH); delay(10); } Here is a picture of an Arduino controlled CD-ROM stepper motor (the one controlling the tray mechanism) powered by the above dual H-bridge (with an added LED for power).
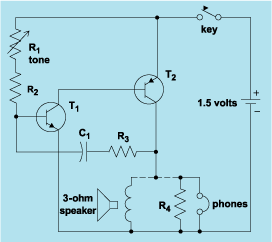
schematic diagram graphic arts
Schematic diagram. A presentation of the element-by-element relationship of all parts of a system.
A schematic diagram serves as a crucial tool in electronic design and engineering, representing the interconnections and relationships between various components within a system. It provides a...
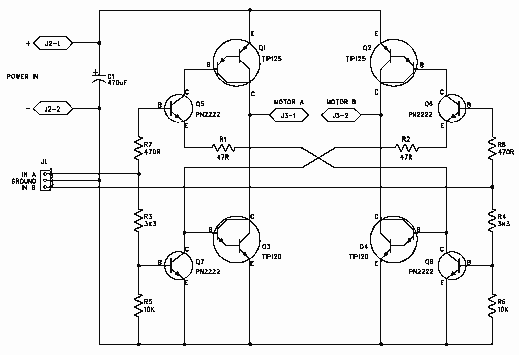
H-Bridge
H-Bridge
This circuit drives small DC motors up to about 100 watts or 5 amps or 40 volts, whichever comes first. Using bigger parts could make it more powerful. Using a real H-bridge IC makes sense for this size of motor,...
H-bridge of 40N60 mini-brick IGBTs
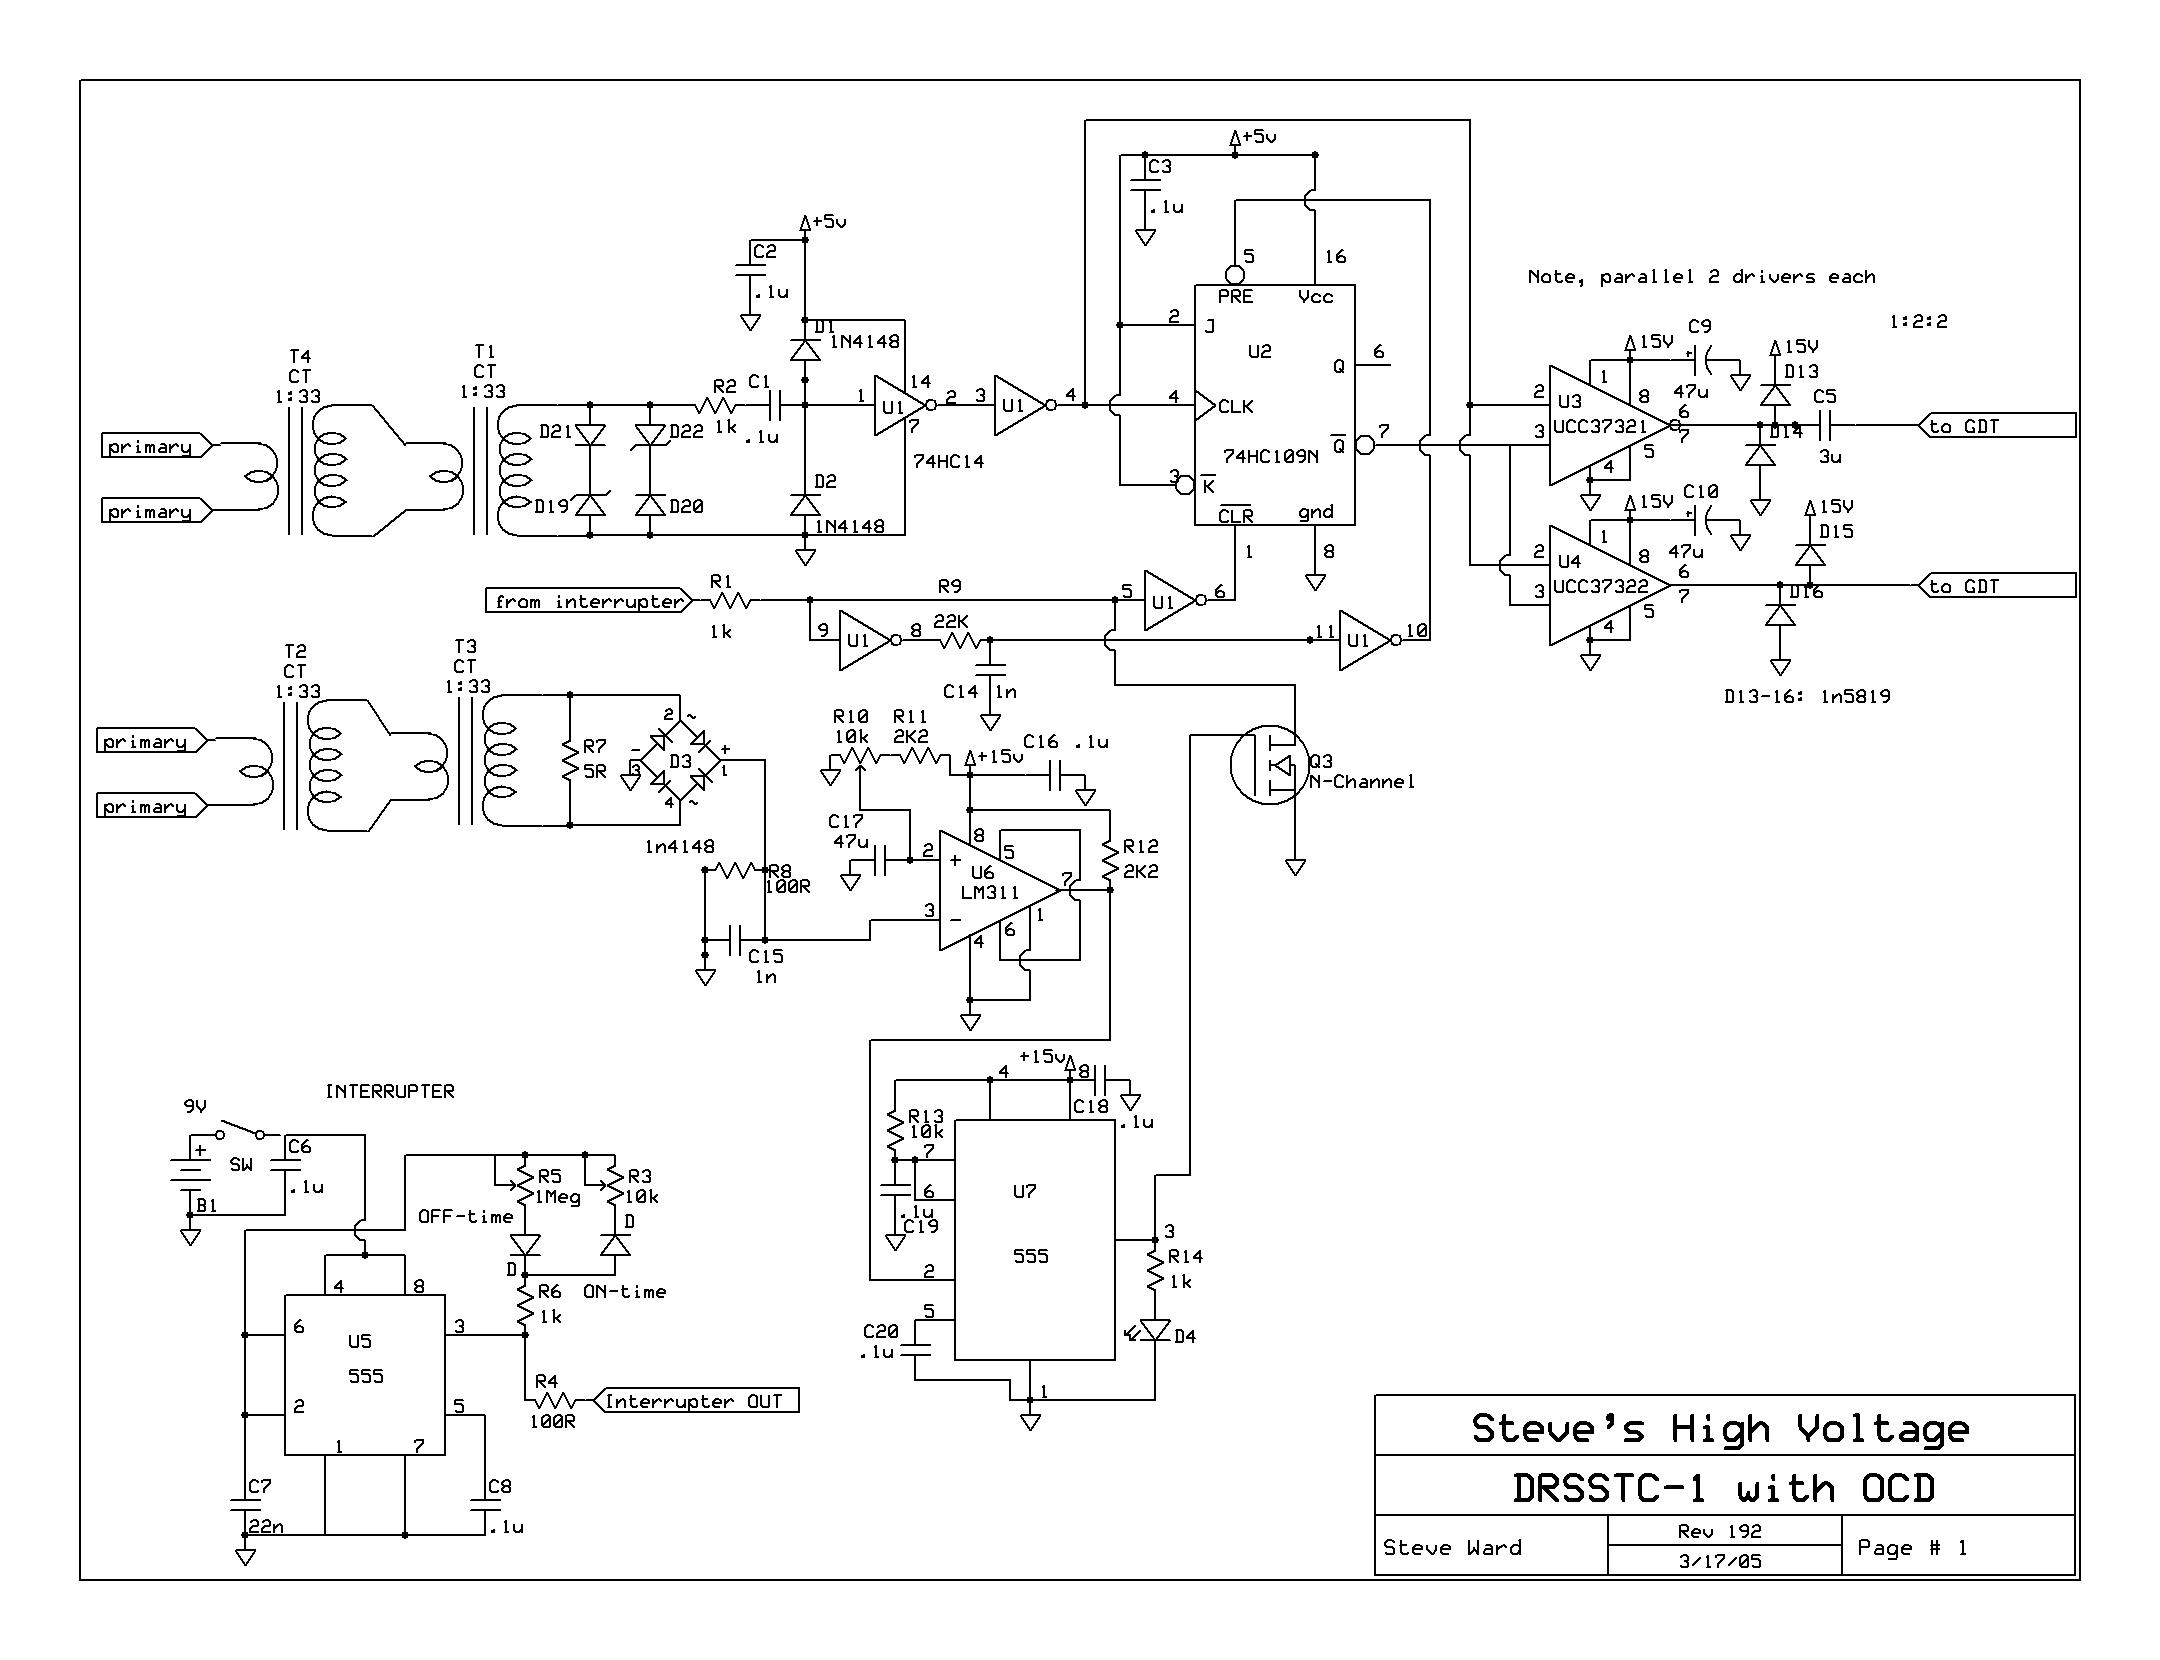
This first DRSSTC evolved from the ISSTC work previously undertaken. After discussions with Jimmy Hynes, the creator of the first DRSSTC, it was decided to implement a modified design. Hynes' DRSSTC utilized an oscillator to produce a high-frequency signal for...
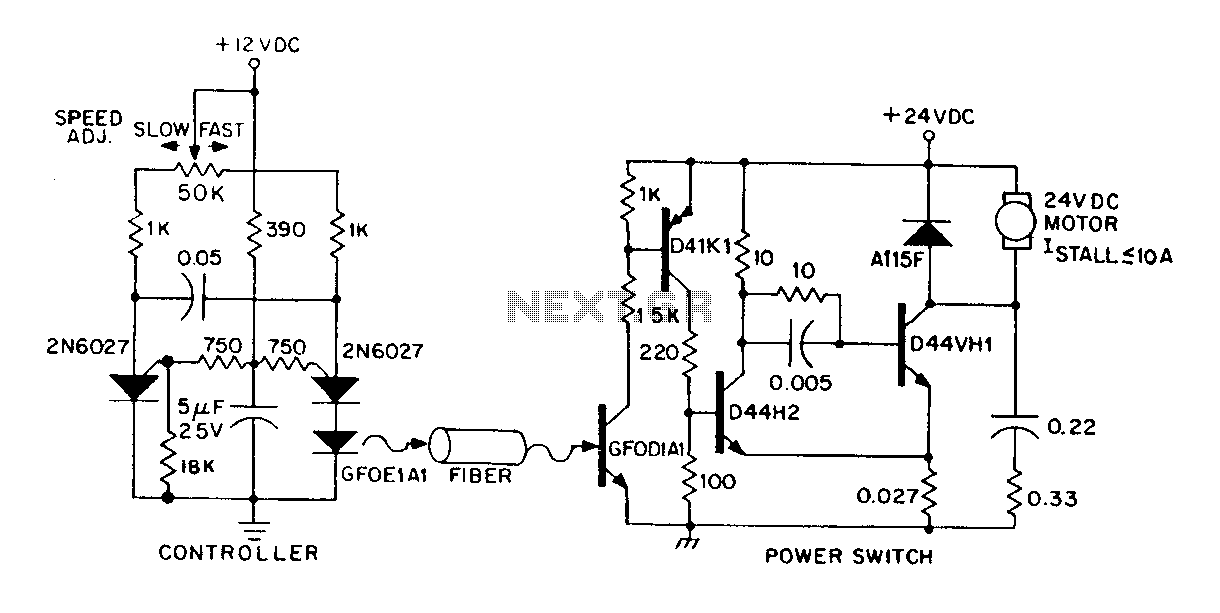
By DC variable speed motor control circuit diagram of an optical fiber
A DC power supply can be controlled through an optical fiber. The circuit includes a small DC motor (1/12 hp) that offers an isolated speed control channel. The control logic operates as an independent module, consuming 300 mW of power...
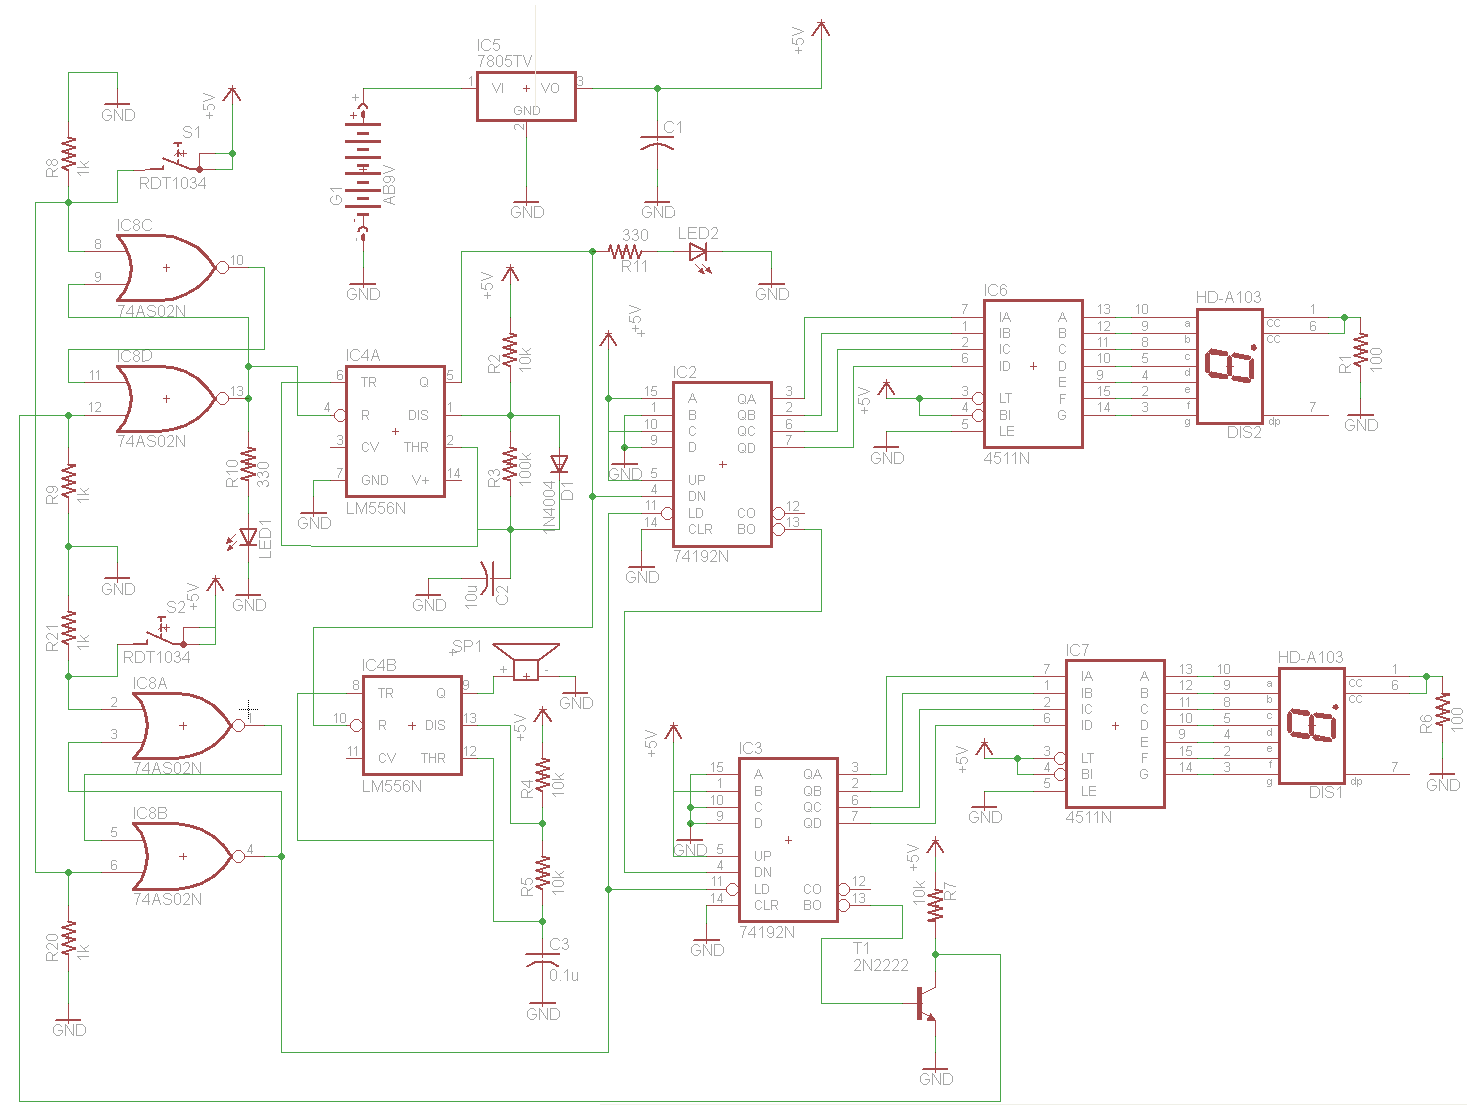
10A H-Bridge Motor Controller Circuit
The 10A H-Bridge Motor Controller circuit appears straightforward, but several critical aspects should not be overlooked. The primary components utilized in the circuit include the TIP147, TIP142, and 2N2222 transistors. The power supply circuit operates at +12V, which is fed...
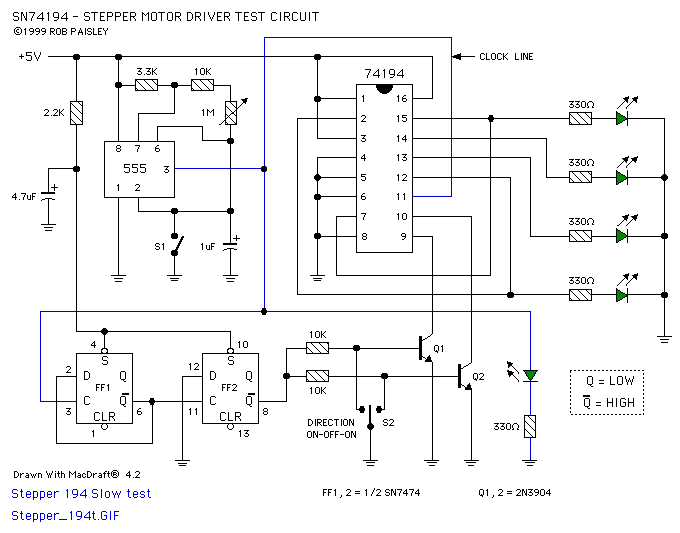
Stepper Motor Driver
The circuit is based on the SN74LS194 Bidirectional Universal Shift Register and is designed to drive unipolar stepper motors, providing basic control functions such as forward, reverse, stop, and speed adjustment. Direction control is selected by an ON-OFF-ON type toggle...
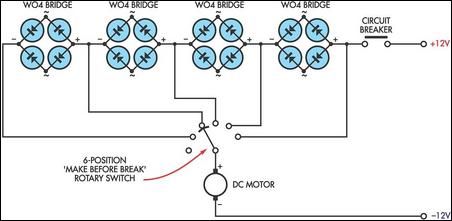
DC Motor Speed Controller
This circuit utilizes the voltage drop across bridge rectifier diodes to create a 5-position variable voltage supply for a DC fan or other small DC motors. While it is not as efficient as a switch-mode circuit, it offers advantages such...
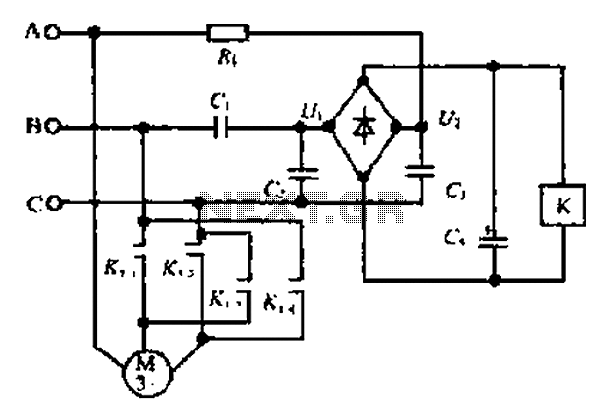
A motor reversing automatic adjustment circuit
Composition ratio circuit. The circuit consists of resistors and capacitors that form a shift register circuit with diodes VD1 to VD4, creating a bridge for electric current. Capacitor C4 is utilized for filtering applications and for eliminating instantaneous relay energization...
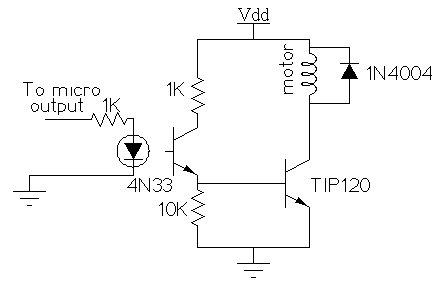
spider
The spider prop has a straightforward mechanical setup, but its electronic configuration is more complex. It utilizes a stepper motor, which requires a controller, such as a computer or microcontroller, to operate effectively. Stepper motors do not simply turn when...