


10A H-Bridge Motor Controller Circuit
#H-Bridge
#TIP147
#TIP142
#2n2222
#motor driver
#12V
#power circuit
#capacitors
#high current
#DC motor
Description: The 10A H-Bridge Motor Controller circuit appears straightforward, but several critical aspects should not be overlooked. The primary components utilized in the circuit include the TIP147, TIP142, and 2N2222 transistors. The power supply circuit operates at +12V, which is fed from the terminal block X1-1/X1-2. This voltage connects to several 100µF capacitors, and the quantity may need adjustment to ensure smooth motor operation. The power supply is also connected to the top of the H-bridge (power to collector) and the bottom (emitter to ground). Outputs 1 and 2 are located in the middle of the H-bridge circuit, and these connections lead to one of the dual terminal blocks that interface with the DC motor. It is at the Output 1/2 points where power will flow to drive the motor. The triple terminal block X3-1/X3-2/X3-3 provides a means to connect digital circuitry and ground for controlling the H-bridge. Input 1 manages one side of the H-bridge, while Input 2 governs the other side. When dealing with high currents on a PCB, it is essential to implement thick traces and adequate heatsinks. The thick traces are visible on the board, leading to the dual terminal block connected to the DC motor, while thinner traces are designated for digital connections. A yellow line indicates a trace that would disrupt a proper ground connection to one of the power transistors; this issue can be remedied with a simple jumper wire instead of a PCB trace. The bottom layer (in blue) is dedicated solely to routing signals to the appropriate devices, while the top layer is reserved for the board's name and the tops of through-hole components.
The 10A H-Bridge Motor Controller circuit is designed to facilitate the control of a DC motor with a maximum current rating of 10A. The H-bridge configuration allows for bidirectional control of the motor, enabling it to rotate in both clockwise and counterclockwise directions based on the input signals provided. The TIP147 and TIP142 transistors serve as the primary switching elements within the H-bridge, effectively controlling the flow of current to the motor. The 2N2222 transistor is utilized for signal amplification, ensuring that the control signals can adequately drive the larger power transistors.
The power supply section is critical in ensuring that the circuit operates reliably. The use of 100µF capacitors enhances the stability of the power supply by filtering out voltage fluctuations, which is particularly important in motor control applications where inductive loads can cause significant electrical noise. The careful arrangement of the power connections to the collectors and emitters of the transistors is designed to minimize voltage drops and enhance efficiency.
The outputs of the H-bridge are strategically positioned to connect with the motor through the dual terminal block, allowing for easy integration into various applications. The triple terminal block serves a dual purpose: it provides a ground reference and allows for the integration of control signals from a microcontroller or other digital circuitry. The use of thick traces for power connections is essential for handling the high current, reducing resistive losses and preventing overheating.
Signal integrity is maintained through the use of thinner traces for digital connections, which are less susceptible to interference. The design considerations also include the potential need for heatsinks on the power transistors to dissipate heat generated during operation, ensuring long-term reliability and performance of the motor controller.
In summary, this H-Bridge Motor Controller circuit is a robust solution for controlling DC motors, with careful attention to component selection, power management, and signal integrity to ensure optimal performance in various applications.The 10A H-Bridge Motor Controller circuit looks simple but there are some key points that you don`t want to miss. The main devices used in the circuit are the TIP147, TIP142 and 2n2222. The power circuit is the +12v coming in from the terminal block X1-1/X1-2. It connects to a few 100uF capacitors and you might need more or less to help the mot or run smoothly. The power also connects to the very top of the H-bridge (power to collector) and the very bottom (emitter to ground). Outputs 1 and 2 are found in the middle of the H-bridge circuit, these connections feed into one of the dual terminal blocks, which connects to the DC motor.
It is at these points of Output 1/2 where power will flow to drive the motor. The triple terminal block X3-1/X3-2/X3-3 offer a way to connect up some digital circuitry and a ground to control the h-bridge. Input 1 controls one side of the H-bridge and Input 2 controls the other side. Typically when you have high very high currents going through a PCB you want two things: thick traces and proper heatsinks.
You can see the thick traces on the board above going into the dual termianl block connecting to the DC motor. The thin traces are all digital connections. One yellow line still exists, and that is because it was a trace that would cut off a good ground connection to one of the power transistors.
To fix this, a simple jumper wire will be used instead of a PCB trace. The bottom layer (in blue) is used purely for routing the signals to the proper devices. The top layer is used purely for the name of the board and for the top of the through-hole parts.
The 10A H-Bridge Motor Controller circuit is designed to facilitate the control of a DC motor with a maximum current rating of 10A. The H-bridge configuration allows for bidirectional control of the motor, enabling it to rotate in both clockwise and counterclockwise directions based on the input signals provided. The TIP147 and TIP142 transistors serve as the primary switching elements within the H-bridge, effectively controlling the flow of current to the motor. The 2N2222 transistor is utilized for signal amplification, ensuring that the control signals can adequately drive the larger power transistors.
The power supply section is critical in ensuring that the circuit operates reliably. The use of 100µF capacitors enhances the stability of the power supply by filtering out voltage fluctuations, which is particularly important in motor control applications where inductive loads can cause significant electrical noise. The careful arrangement of the power connections to the collectors and emitters of the transistors is designed to minimize voltage drops and enhance efficiency.
The outputs of the H-bridge are strategically positioned to connect with the motor through the dual terminal block, allowing for easy integration into various applications. The triple terminal block serves a dual purpose: it provides a ground reference and allows for the integration of control signals from a microcontroller or other digital circuitry. The use of thick traces for power connections is essential for handling the high current, reducing resistive losses and preventing overheating.
Signal integrity is maintained through the use of thinner traces for digital connections, which are less susceptible to interference. The design considerations also include the potential need for heatsinks on the power transistors to dissipate heat generated during operation, ensuring long-term reliability and performance of the motor controller.
In summary, this H-Bridge Motor Controller circuit is a robust solution for controlling DC motors, with careful attention to component selection, power management, and signal integrity to ensure optimal performance in various applications.The 10A H-Bridge Motor Controller circuit looks simple but there are some key points that you don`t want to miss. The main devices used in the circuit are the TIP147, TIP142 and 2n2222. The power circuit is the +12v coming in from the terminal block X1-1/X1-2. It connects to a few 100uF capacitors and you might need more or less to help the mot or run smoothly. The power also connects to the very top of the H-bridge (power to collector) and the very bottom (emitter to ground). Outputs 1 and 2 are found in the middle of the H-bridge circuit, these connections feed into one of the dual terminal blocks, which connects to the DC motor.
It is at these points of Output 1/2 where power will flow to drive the motor. The triple terminal block X3-1/X3-2/X3-3 offer a way to connect up some digital circuitry and a ground to control the h-bridge. Input 1 controls one side of the H-bridge and Input 2 controls the other side. Typically when you have high very high currents going through a PCB you want two things: thick traces and proper heatsinks.
You can see the thick traces on the board above going into the dual termianl block connecting to the DC motor. The thin traces are all digital connections. One yellow line still exists, and that is because it was a trace that would cut off a good ground connection to one of the power transistors.
To fix this, a simple jumper wire will be used instead of a PCB trace. The bottom layer (in blue) is used purely for routing the signals to the proper devices. The top layer is used purely for the name of the board and for the top of the through-hole parts.
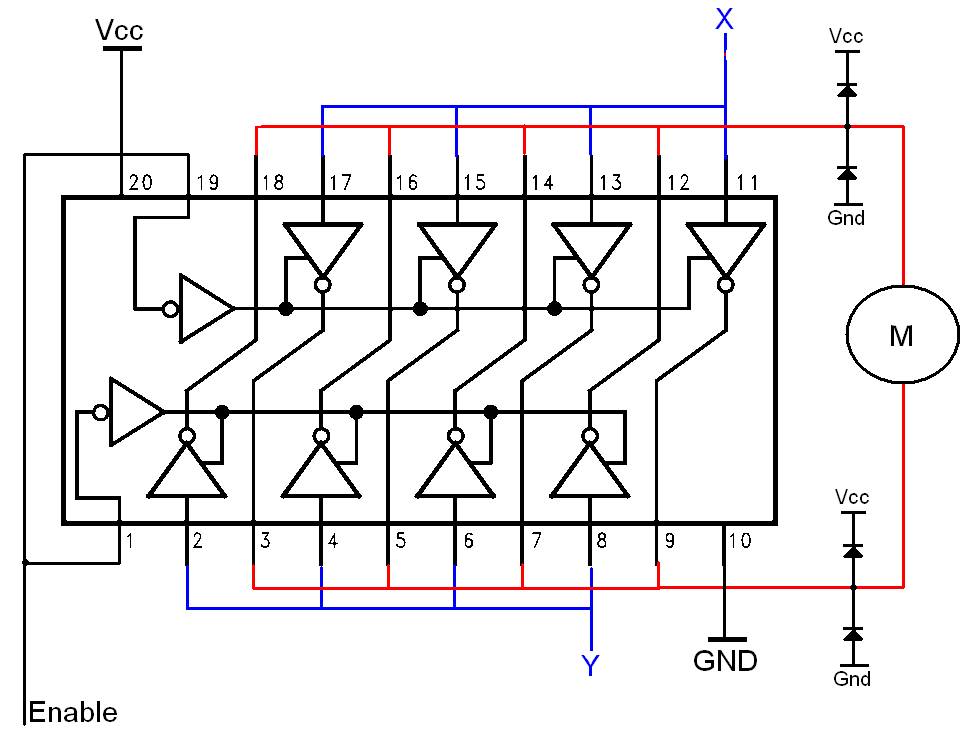
Simple H-bridges Tutorial
The H-bridge is a well-known and widely used circuit configuration for driving brushed DC motors. It enables straightforward control of motor direction, allowing for both forward and reverse operation.
The H-bridge circuit consists of four switches, typically implemented using transistors or...
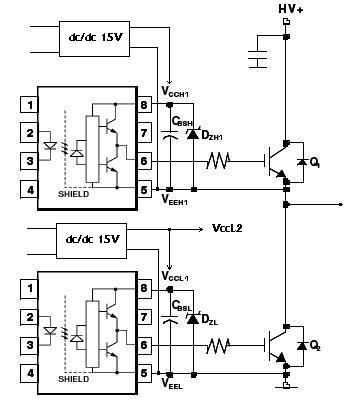
H-bridge using only n-channel mosfets
An H-bridge circuit has been developed utilizing four floating gate drivers and four insulated gate bipolar transistors (IGBTs). The attached schematic illustrates one half of the H-bridge configuration. The circuit operates effectively, but there are additional considerations to address.
The H-bridge...
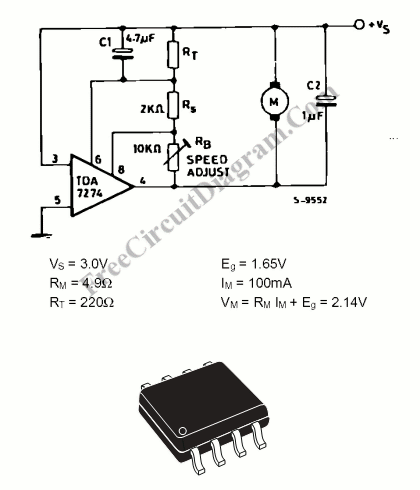
Small DC Motor Speed Controller
Electric motors have been widely used for motion control, and various types of motor controllers have been designed to provide variable speed drives for these motors.
Electric motors are integral to numerous applications requiring precise motion control, ranging from industrial automation...
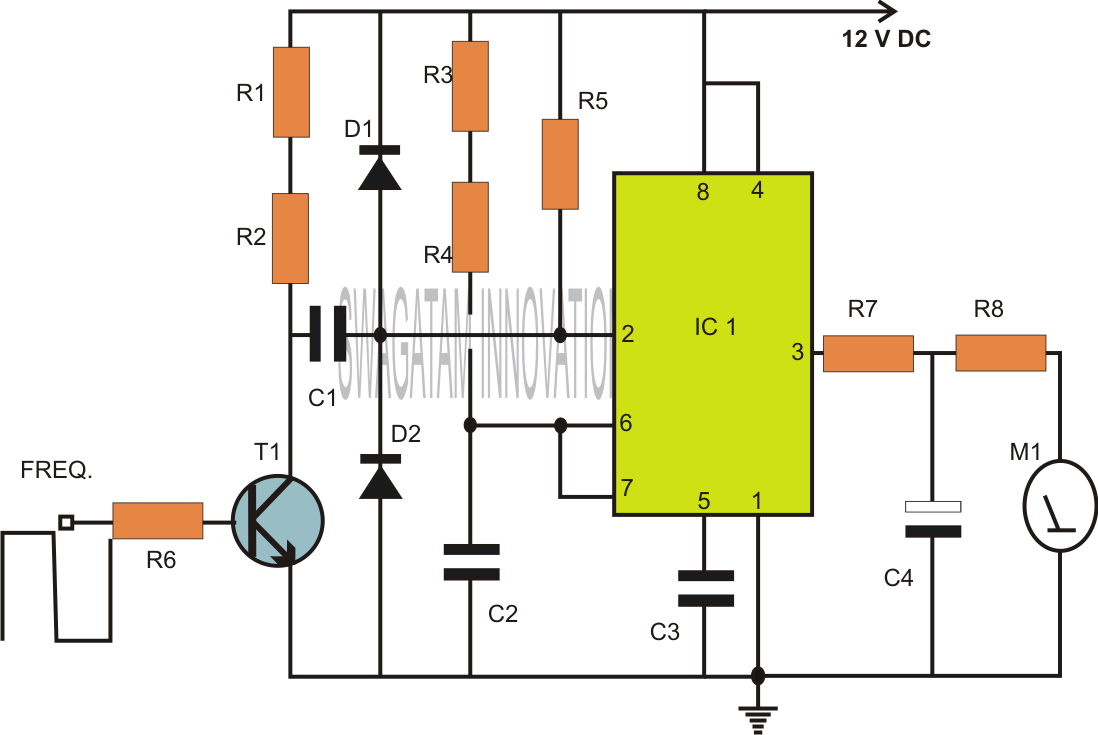
how to build inexpensive frequency
Capacitors are major electronic components classified as passive components. They are extensively used in electronic circuits, and virtually no circuit can be constructed without these essential parts. The primary function of a capacitor is to block direct current (DC) while...
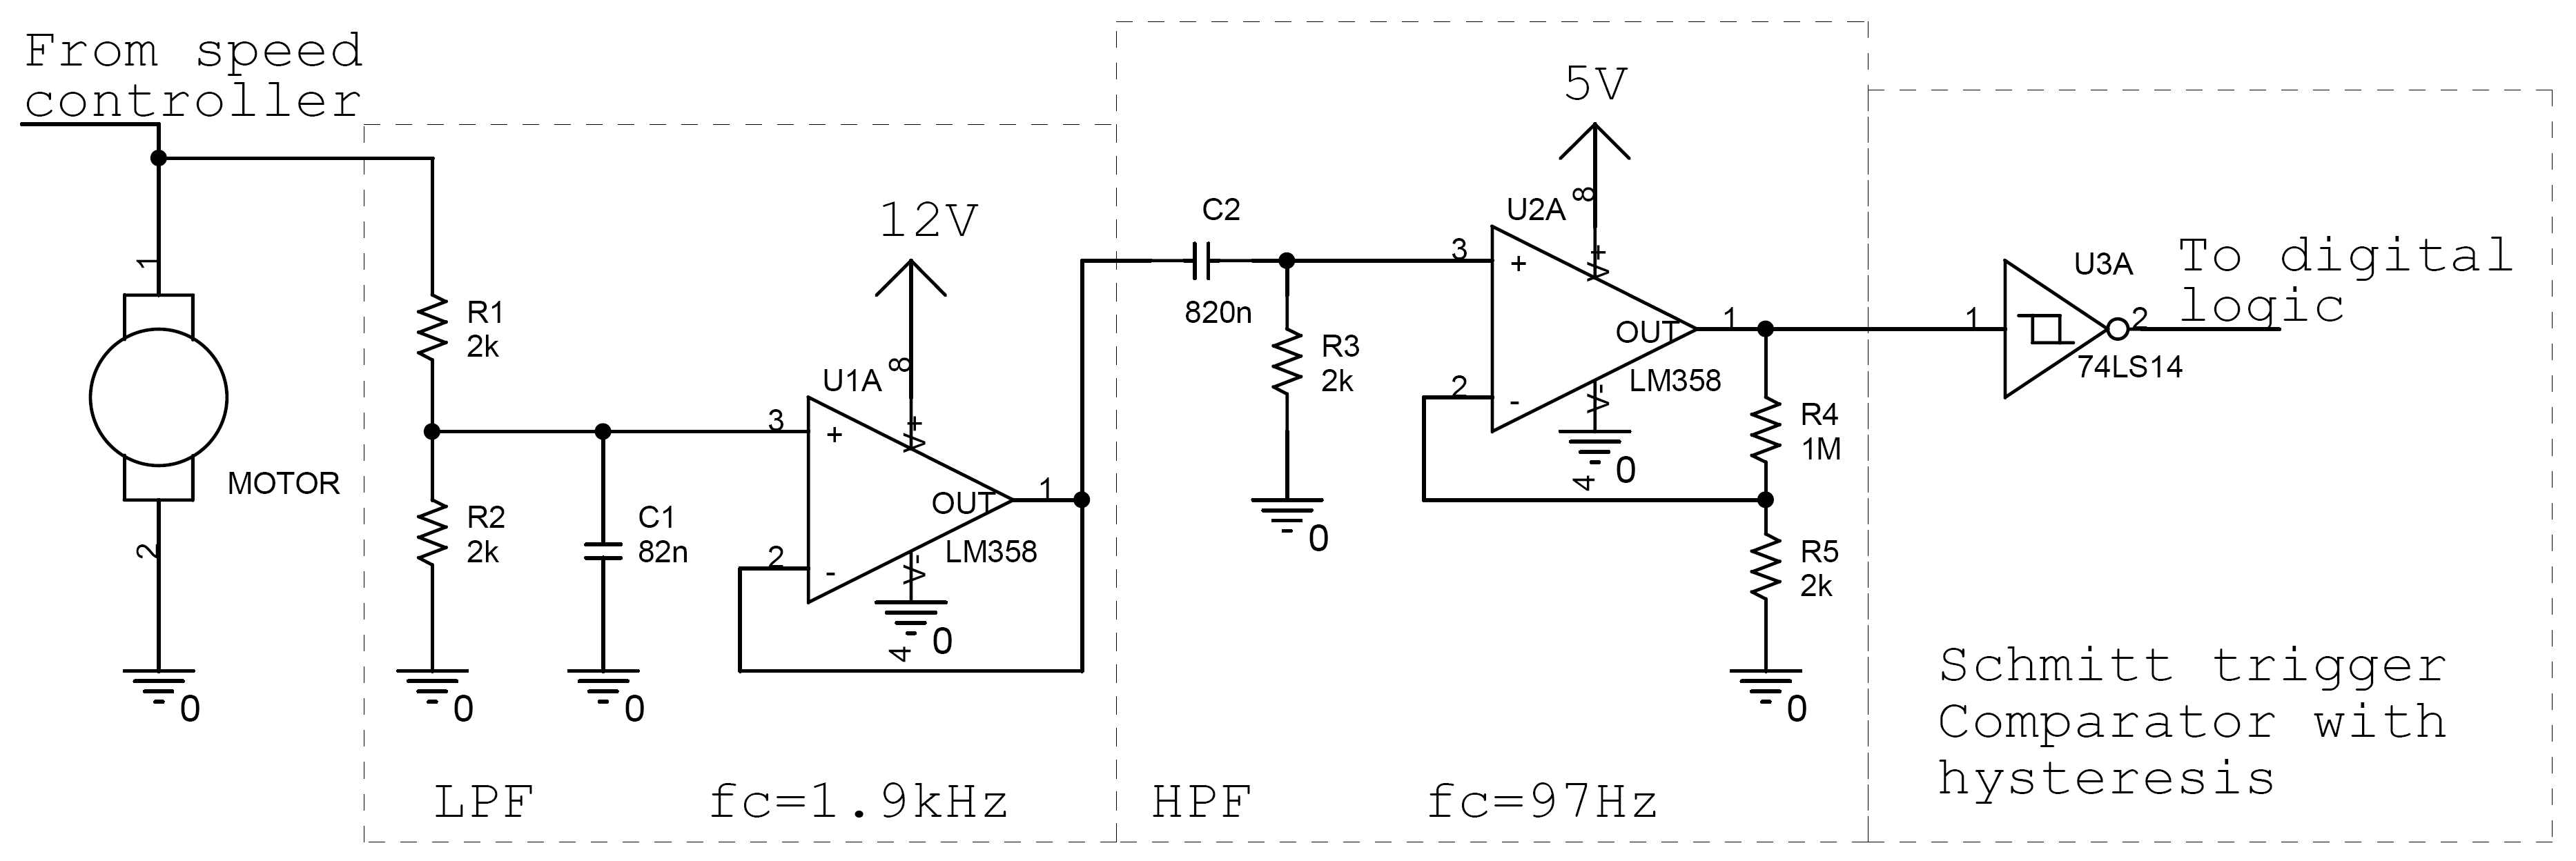
DC Motor Controller and Tachometer
Controlling the speed of a motor is crucial in various applications, particularly in robotics. Numerous techniques exist for adjusting motor speed, each offering distinct advantages and disadvantages. This document outlines the construction of a motor controller that regulates the speed...
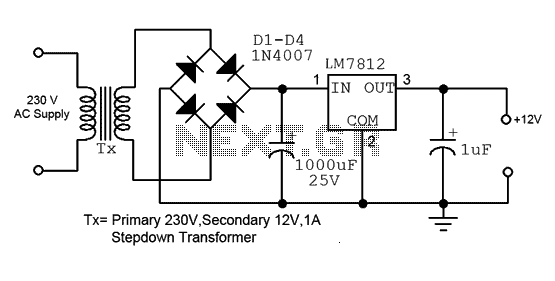
12V fixed voltage power supply circuit diagram
This is a straightforward 12V power supply circuit diagram. It features a fixed voltage output and is based on the LM7812 voltage regulator integrated circuit.
The 12V power supply circuit utilizing the LM7812 voltage regulator is designed to provide a stable...
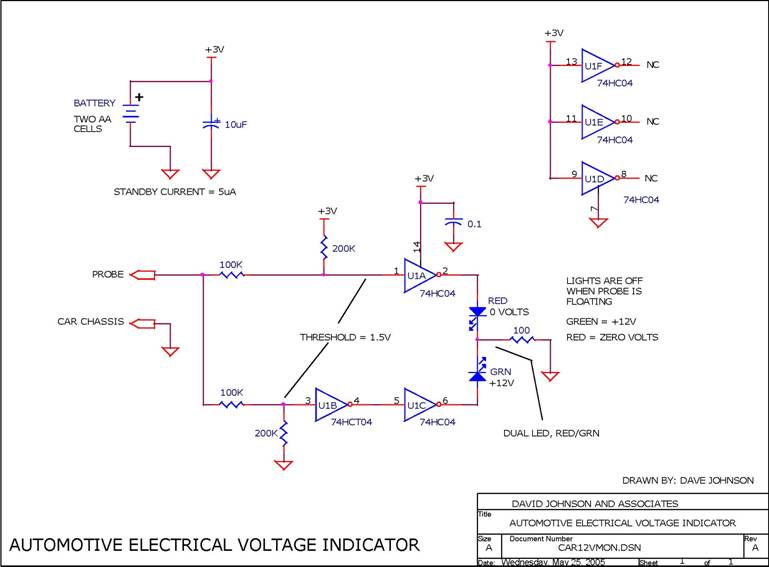
12v automotive electrical voltage
When troubleshooting the 12V electrical system of an automobile, it is beneficial to have a simple voltage indicator tool instead of a voltmeter. This electronic circuit is powered by two AA batteries or two N cells, providing sufficient energy for...
h bridge
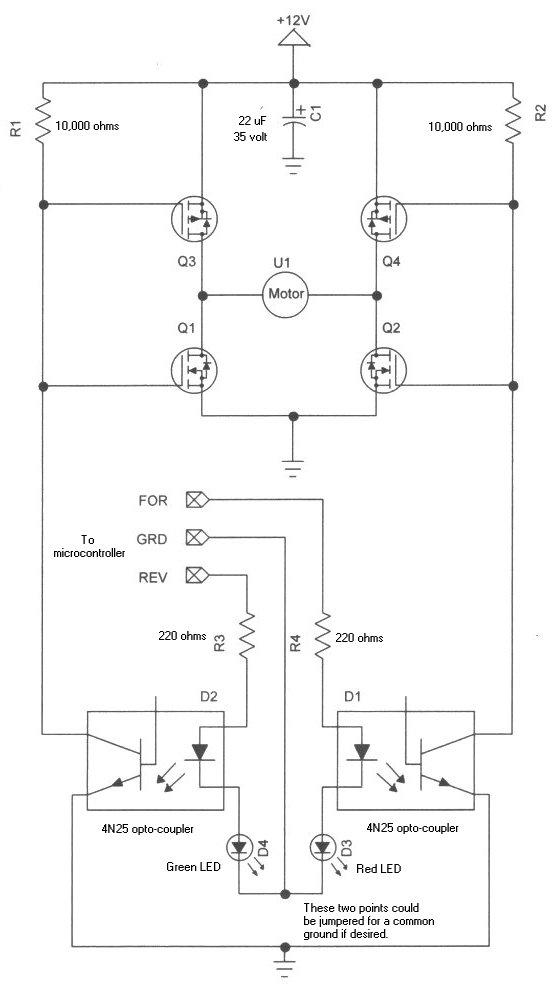
Learning how to use power MOSFETs by building an H-bridge motor control.
The H-bridge motor control circuit is an essential configuration for driving DC motors in both forward and reverse directions. It utilizes four power MOSFETs arranged in a bridge configuration,...
motor h bridge
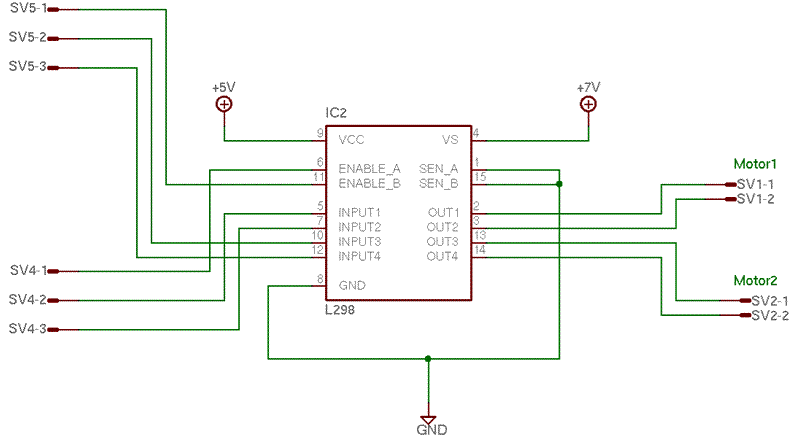
The basic stamp cannot directly power motors due to its maximum current output of only 20mA, while motors typically require around an amp or more, with even higher current spikes. To address this limitation, a circuit will be implemented where...