


Stepper motor controller Based On The PIC16F84A IC
#PIC16F84A
#stepper motor
#transistor
#microcontroller
#driver circuit
#motor controller
#embedded control
#PIC microcontroller
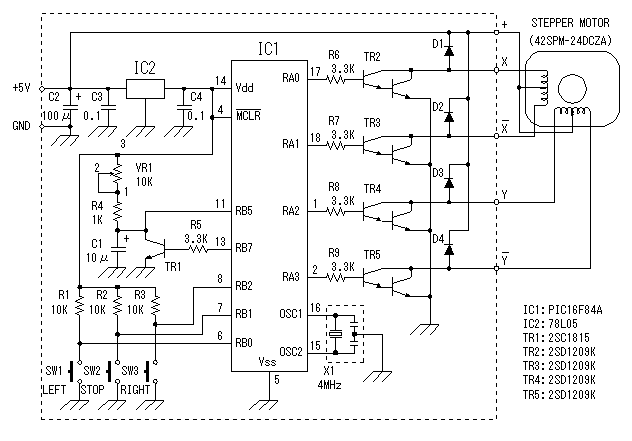
Description: The following circuit illustrates a stepper motor controller. This circuit is based on the PIC16F84A integrated circuit. Features: a transistor is utilized to drive the motor.
The stepper motor controller circuit employs the PIC16F84A microcontroller, which serves as the central processing unit for controlling the stepper motor's operation. The PIC16F84A is an 8-bit microcontroller with a 14-bit instruction set architecture, allowing for efficient control algorithms to be implemented.
The circuit typically includes a driver stage, which often consists of one or more transistors. These transistors are crucial as they amplify the control signals from the microcontroller to provide sufficient current to the stepper motor coils. The choice of transistor is important; commonly used transistors include N-channel MOSFETs or bipolar junction transistors (BJTs), depending on the current requirements of the motor.
The control logic for the stepper motor can be implemented in various modes, such as full-step, half-step, or microstepping, which can be programmed into the PIC16F84A. The microcontroller generates the necessary pulse sequences to energize the motor coils in the correct order, resulting in precise control of the motor's rotation.
Additional components in the circuit may include resistors, capacitors, and diodes. Resistors may be used for current limiting, while capacitors can help stabilize the power supply and filter out noise. Diodes are often included to protect the circuit from back EMF generated by the motor when it is turned off, ensuring the longevity of the components.
The power supply for the circuit should be chosen based on the voltage and current specifications of the stepper motor, ensuring that it meets the operational requirements without exceeding the ratings of the microcontroller and driver components. Proper layout and grounding techniques should also be employed to minimize electromagnetic interference and ensure reliable operation of the stepper motor controller.The following circuit shows about Stepper motor controller. This circuit based on the PIC16F84A IC. Features: transistor is used to drive the ..
The stepper motor controller circuit employs the PIC16F84A microcontroller, which serves as the central processing unit for controlling the stepper motor's operation. The PIC16F84A is an 8-bit microcontroller with a 14-bit instruction set architecture, allowing for efficient control algorithms to be implemented.
The circuit typically includes a driver stage, which often consists of one or more transistors. These transistors are crucial as they amplify the control signals from the microcontroller to provide sufficient current to the stepper motor coils. The choice of transistor is important; commonly used transistors include N-channel MOSFETs or bipolar junction transistors (BJTs), depending on the current requirements of the motor.
The control logic for the stepper motor can be implemented in various modes, such as full-step, half-step, or microstepping, which can be programmed into the PIC16F84A. The microcontroller generates the necessary pulse sequences to energize the motor coils in the correct order, resulting in precise control of the motor's rotation.
Additional components in the circuit may include resistors, capacitors, and diodes. Resistors may be used for current limiting, while capacitors can help stabilize the power supply and filter out noise. Diodes are often included to protect the circuit from back EMF generated by the motor when it is turned off, ensuring the longevity of the components.
The power supply for the circuit should be chosen based on the voltage and current specifications of the stepper motor, ensuring that it meets the operational requirements without exceeding the ratings of the microcontroller and driver components. Proper layout and grounding techniques should also be employed to minimize electromagnetic interference and ensure reliable operation of the stepper motor controller.The following circuit shows about Stepper motor controller. This circuit based on the PIC16F84A IC. Features: transistor is used to drive the ..
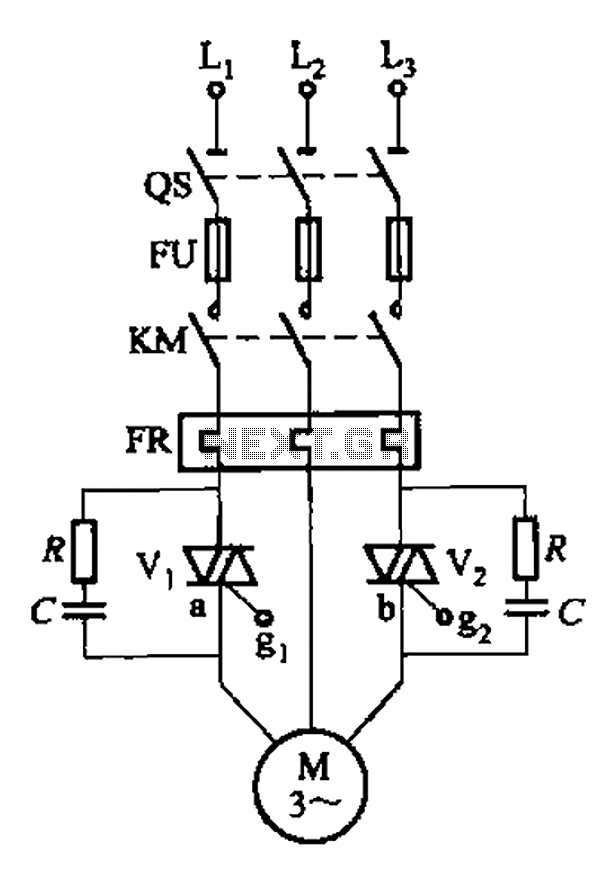
Intermittent start and stop cycle control circuit Five of a
The circuit depicted in Figure 3-80 is responsible for controlling a portion of the transistor multivibrator. A multivibrator serves as a robust positive and negative feed-forward amplifier, consisting of two branches that are interconnected through a coupled RC timing circuit,...
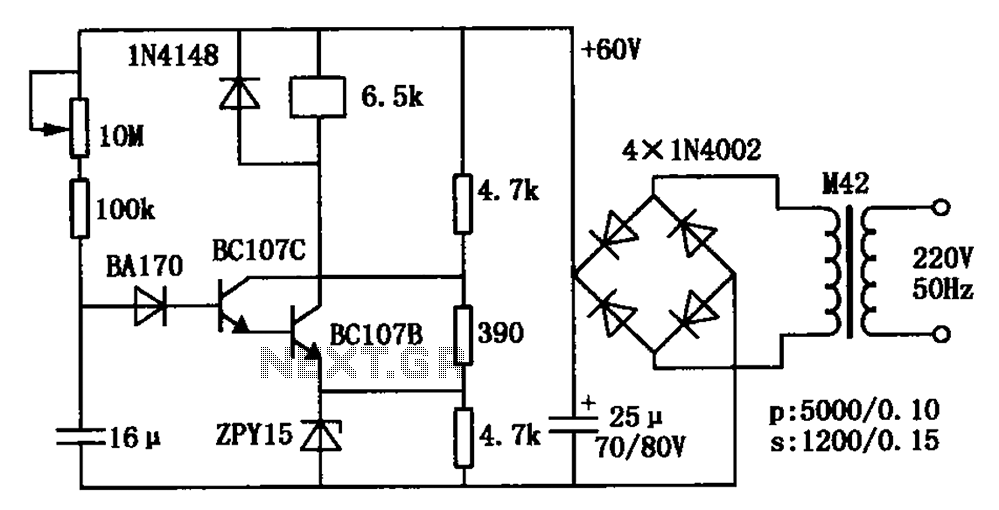
Pull transistor relay delay circuit diagrams
The circuit is a relay delay pull transistor configuration. Initially, when powered, the 16 µF capacitor has a voltage of zero, resulting in both transistors being off, and the relay remains inactive. As the 16 µF capacitor charges over time...
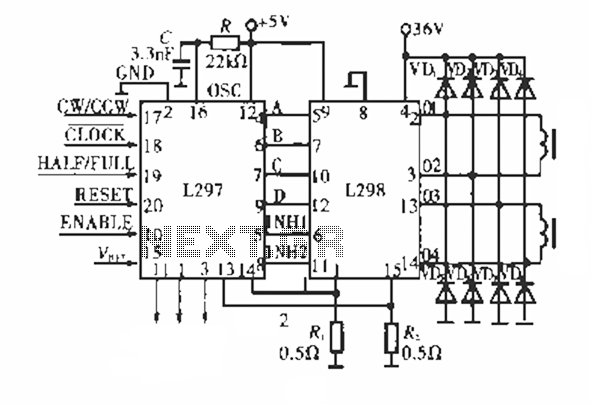
Bipolar stepper motor driver module circuit
The circuit operates using a dedicated stepping motor controller, the L297. Pin 17 (CW/CCW) is utilized to control the rotation direction of the stepper motor. Pin 18 (CLOCK) regulates the speed of the stepper motor, while pin 19 (HALF/FULL) allows...
Right-left scrolling LEDs
In this project, eight LEDs are connected to PORT B of a PIC microcontroller. A push-button switch is also connected to bit 0 of PORT A using a pull-up resistor. When the switch is pressed, the LEDs scroll to the...
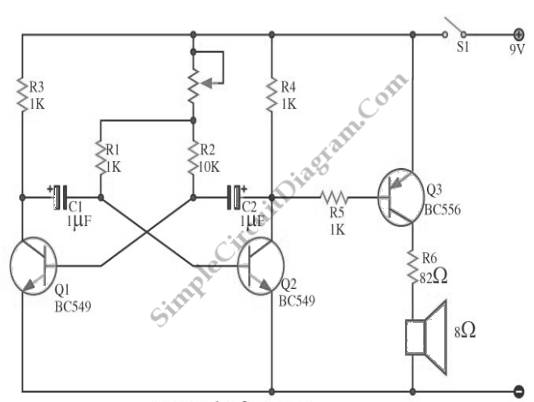
Simple Metronome With Transistors
A flip-flop, functioning as an astable multivibrator, can be utilized to generate timing signals in music applications such as a metronome. This can be achieved by adjusting the transistor bias resistor with a value of 100k.
The astable multivibrator configuration of...
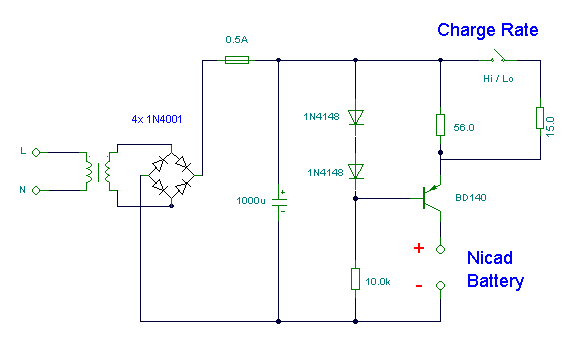
Nicad Battery Charger
This simple charger utilizes a single transistor as a constant current source. The voltage across a pair of 1N4148 diodes biases the base of the BD140 medium power transistor. The base-emitter voltage of the transistor and the forward voltage drop...
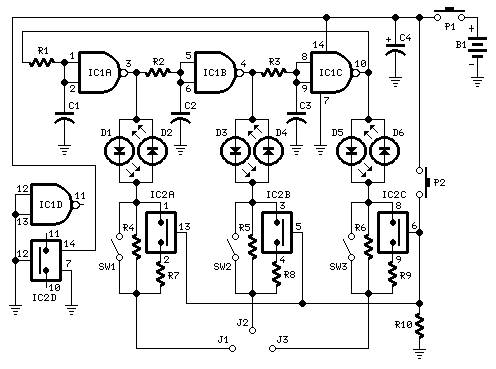
Transistor Pin Identifier
Tests transistors and diodes for polarity. A three-phase waveform is derived from the 350Hz ring-of-three oscillator formed by IC1A, IC1B, and IC1C, and applied to the device under test via the LEDs. The oscillator waveform enables each pair of device...
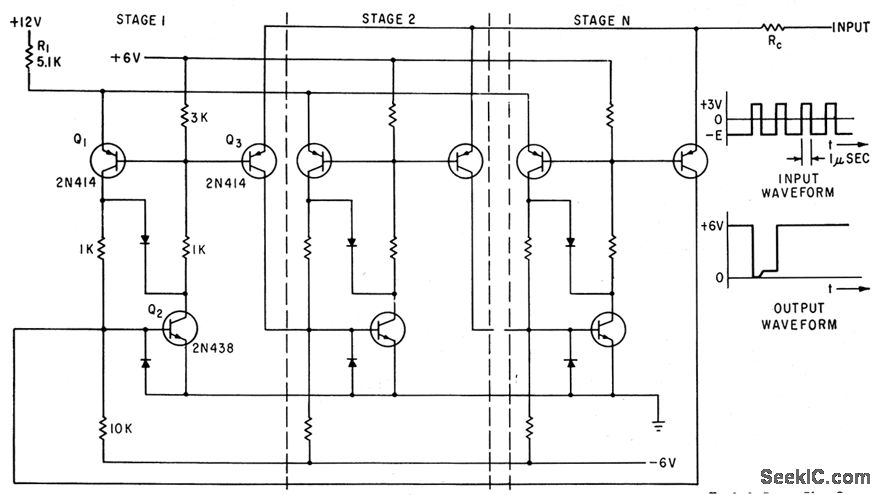
TRANSISTORIZED THYRATRON RING COUNTER
Each bistable circuit comprises two oppositely-symmetrical germanium transistors, two diodes, and four resistors. An additional transistor, Q, facilitates the transition of the conducting state to the next position when actuated by a transfer pulse. The absence of capacitors allows for...
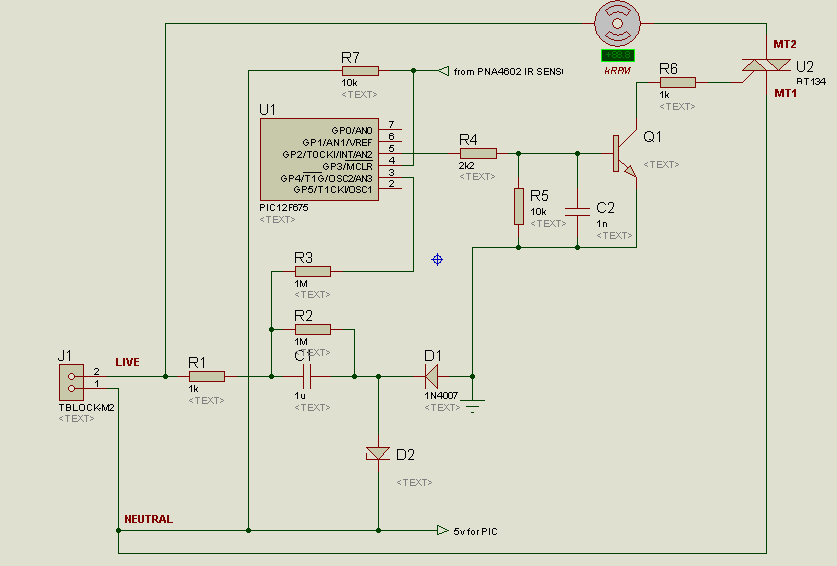
Microcontroller-based: Electric fan switching relay or triac
A project is underway to control the speed of an electric fan (220Vac, 60W, 5A max.) automatically using a microcontroller based on certain parameters.
The circuit design for controlling the speed of an electric fan involves several key components to ensure...