


Servo Motor Controller (PIC16F84)
#servo motor
#PIC16F84
#actuator
#pulse width modulation
#3-state switch
#position control
#microcontroller
#motor control
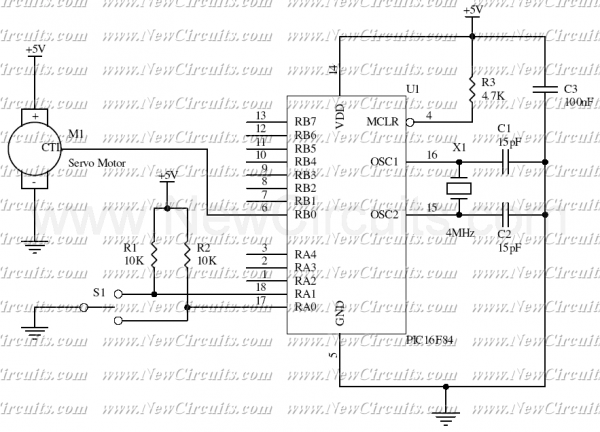
Description: This simple micro-control circuit controls a servo motor according to a 3-state switch. A servo motor acts as an actuator in 3 positions. It has 3 wires, one for VCC, one for Ground, and another one for position control. The last signal is a single pulse with variable width. The pulse width can vary between 1 and 2 mSec. A 1 mSec pulse width turns the motor axis to the -45 degrees position. A 1.5 mSec pulse width turns the motor axis to the 0 degree position. A 2 mSec pulse width turns the motor axis to the +45 degrees position. The following source code has been written in PICBasic: Symbol porta = 5 b3 = 150 start: Peek porta,b0 If bit0 = 0 Th
The described micro-control circuit is designed to operate a servo motor based on the input from a 3-state switch. The servo motor, which is an electromechanical device, is capable of precise angular positioning and is utilized here to achieve three distinct positions: -45 degrees, 0 degrees, and +45 degrees.
The servo motor consists of three primary connections: VCC (power supply), Ground, and a control signal wire. The control signal wire receives pulse-width modulation (PWM) signals that dictate the position of the motor. The PWM signal's pulse width is critical; it can vary between 1 millisecond (mSec) and 2 mSec. Specifically, a pulse width of 1 mSec corresponds to the -45 degrees position, 1.5 mSec corresponds to the 0 degrees position, and 2 mSec corresponds to the +45 degrees position.
The circuit's control logic is implemented using a microcontroller programmed with PICBasic. The code snippet indicates that the microcontroller is monitoring the state of the switch connected to one of its ports. The line `Symbol porta = 5` assigns the port number to a symbolic name, making it easier to reference in the code. The variable `b3 = 150` likely represents a delay or timing parameter used in conjunction with the PWM signal generation. The line `Peek porta, b0` suggests that the program is continuously reading the state of the switch connected to the specified port. The condition `If bit0 = 0` checks the state of the switch; if it is in the 'off' position, the subsequent actions (not fully shown in the provided snippet) would be executed.
In practice, the circuit would be powered by an appropriate voltage source connected to the VCC wire, while the ground wire ensures proper circuit completion. The control wire would receive PWM signals generated by the microcontroller based on the switch position, allowing for the precise control of the servo motor's angular position. This simple yet effective design is ideal for applications requiring basic angular positioning, such as robotics or automation systems.This simple micro-control circuit controls a servo motor according to a 3-state switch. A servo motor acts as an actuator in 3 position. It has 3 wires, one for VCC, one for Ground and another one for position control. The last signal is a single pulse with variable width. The pulse width can vary between 1 and 2 mSec. An 1 mSec pulse width turns the motor axis in -45 degrees position. An 1.5 mSec pulse width turns the motor axis in 0 degree position. A 2 mSec pulse width turns the motor axis in +45 degrees position. The following source code has been written in PICBasic: Symbol porta = 5 b3 = 150 start: Peek porta,b0 If bit0 = 0 Th
The described micro-control circuit is designed to operate a servo motor based on the input from a 3-state switch. The servo motor, which is an electromechanical device, is capable of precise angular positioning and is utilized here to achieve three distinct positions: -45 degrees, 0 degrees, and +45 degrees.
The servo motor consists of three primary connections: VCC (power supply), Ground, and a control signal wire. The control signal wire receives pulse-width modulation (PWM) signals that dictate the position of the motor. The PWM signal's pulse width is critical; it can vary between 1 millisecond (mSec) and 2 mSec. Specifically, a pulse width of 1 mSec corresponds to the -45 degrees position, 1.5 mSec corresponds to the 0 degrees position, and 2 mSec corresponds to the +45 degrees position.
The circuit's control logic is implemented using a microcontroller programmed with PICBasic. The code snippet indicates that the microcontroller is monitoring the state of the switch connected to one of its ports. The line `Symbol porta = 5` assigns the port number to a symbolic name, making it easier to reference in the code. The variable `b3 = 150` likely represents a delay or timing parameter used in conjunction with the PWM signal generation. The line `Peek porta, b0` suggests that the program is continuously reading the state of the switch connected to the specified port. The condition `If bit0 = 0` checks the state of the switch; if it is in the 'off' position, the subsequent actions (not fully shown in the provided snippet) would be executed.
In practice, the circuit would be powered by an appropriate voltage source connected to the VCC wire, while the ground wire ensures proper circuit completion. The control wire would receive PWM signals generated by the microcontroller based on the switch position, allowing for the precise control of the servo motor's angular position. This simple yet effective design is ideal for applications requiring basic angular positioning, such as robotics or automation systems.This simple micro-control circuit controls a servo motor according to a 3-state switch. A servo motor acts as an actuator in 3 position. It has 3 wires, one for VCC, one for Ground and another one for position control. The last signal is a single pulse with variable width. The pulse width can vary between 1 and 2 mSec. An 1 mSec pulse width turns the motor axis in -45 degrees position. An 1.5 mSec pulse width turns the motor axis in 0 degree position. A 2 mSec pulse width turns the motor axis in +45 degrees position. The following source code has been written in PICBasic: Symbol porta = 5 b3 = 150 start: Peek porta,b0 If bit0 = 0 Th
knight Rider
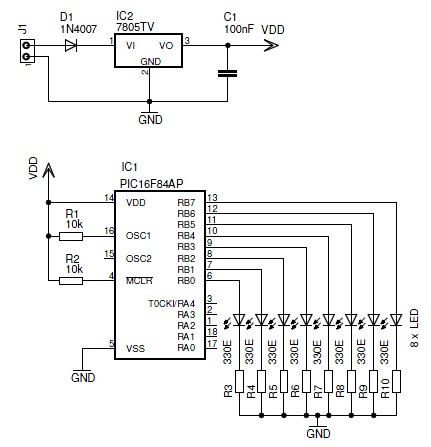
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
Greenhouse irrigation controller ( PIC16F84 )
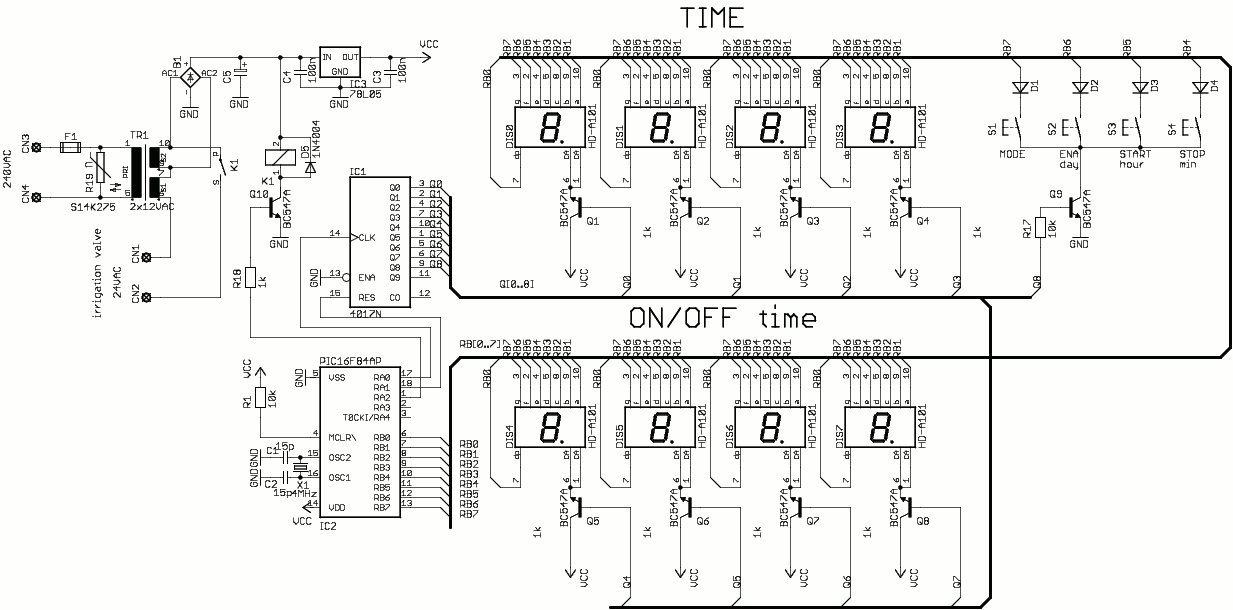
This is a simple one-valve irrigation controller made for our greenhouse. The code contains a software real-time clock (RTC) and a multiplexed 8-digit LED display and keyboard you can use in other projects. The operating software is simple, it contains...
PIC16F84 Solar Charger
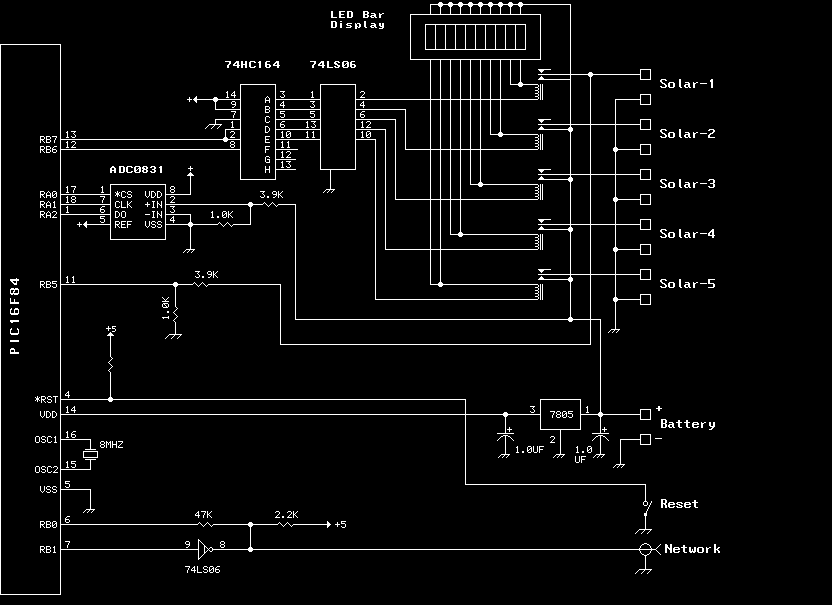
The previous version of this device used pulse width modulation (PWM) to control the power from the five solar panels to charge the battery bank. Under full sun conditions, the MOSFETs got a bit warm and the whole unit radiated...
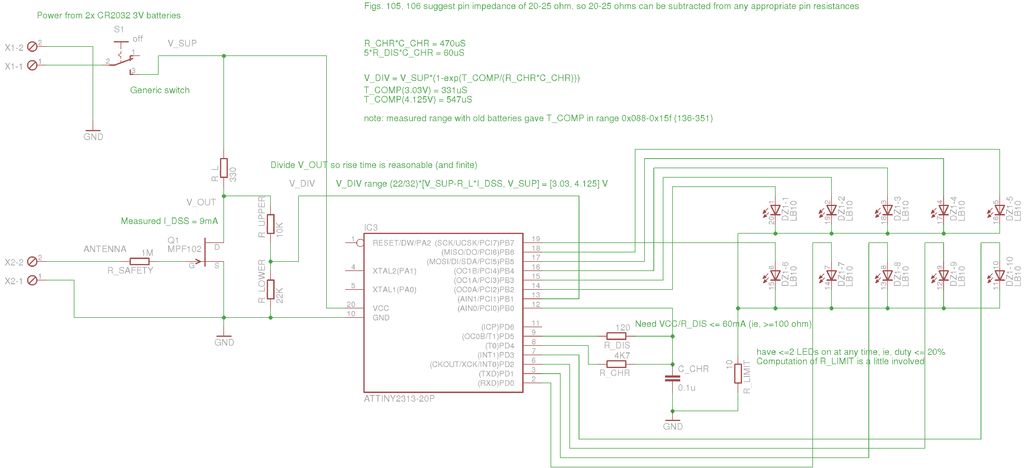
Microcontroller interface electrometer
A method for measuring static electricity for a science project was sought. An old copy of "Getting Started in Electronics" by Forrest M. Mims III was referenced for guidance.
To create a static electricity measurement circuit, a simple design can be...
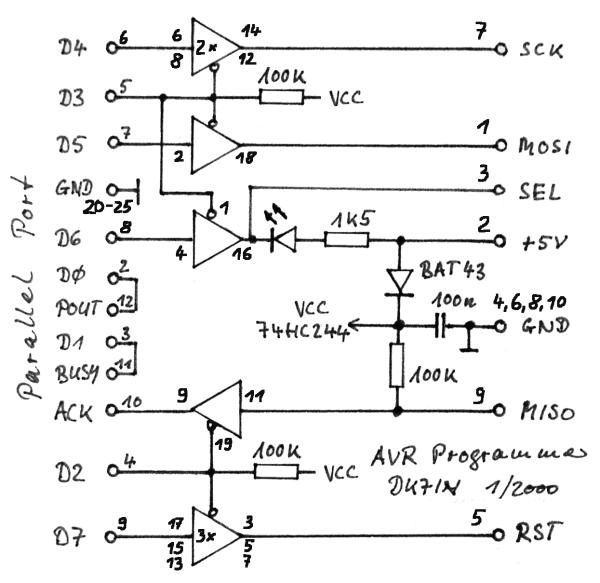
Microcontroller
The gap between TTL (Transistor-Transistor Logic) devices and personal computers can be effectively bridged with modern microcontrollers. These microcontrollers not only incorporate a central processing unit (CPU) but also include program and data memory, EEPROM, input/output (I/O) ports, timers, and...
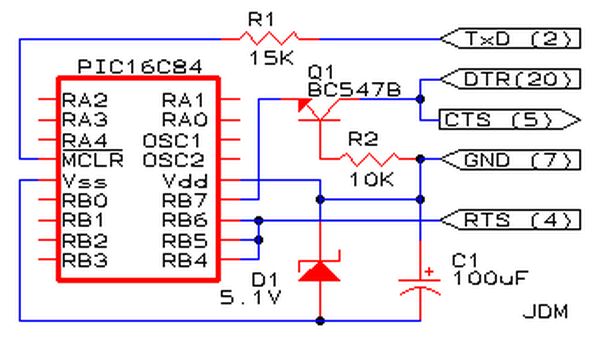
pic programmer using pic16f84 microcontroller
Affordable PIC Programmer. This programmer is compatible solely with the PIC16F84 microcontroller. It is reliable, as it rarely encounters errors, and functions well with nearly all computer systems, in contrast to some alternatives.
The PIC programmer designed for the PIC16F84 microcontroller...

servo timer
The Servo Timer II was primarily designed for parachute deployment on water rockets but can be used for other applications. The timer controls a single RC servo motor that can open a latch on a parachute door. Once triggered, the...
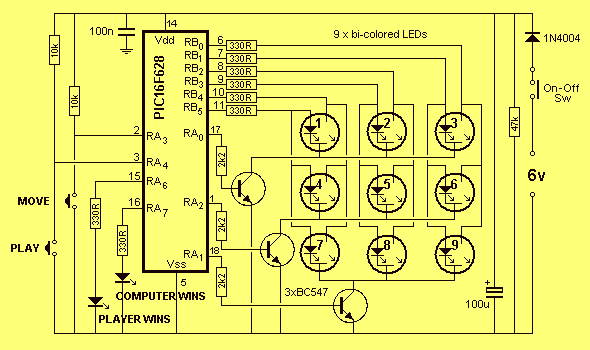
Electronic TIC TAC TOE
This project is not to introduce Tic Tac Toe. Everyone knows this game. It is to introduce two features: bi-coloured LEDs, microcontrollers, and the skill of writing an ALGORITHM. You can use the project to learn the skills of creating...
Robo Atmega328p project
This project was designed to introduce a friend to microcontrollers and circuits using various functionalities and spare parts. A PS2 numpad was utilized as the key entry mechanism, which was found at a thrift store and included the necessary connector....