


line following robot using pic16f84
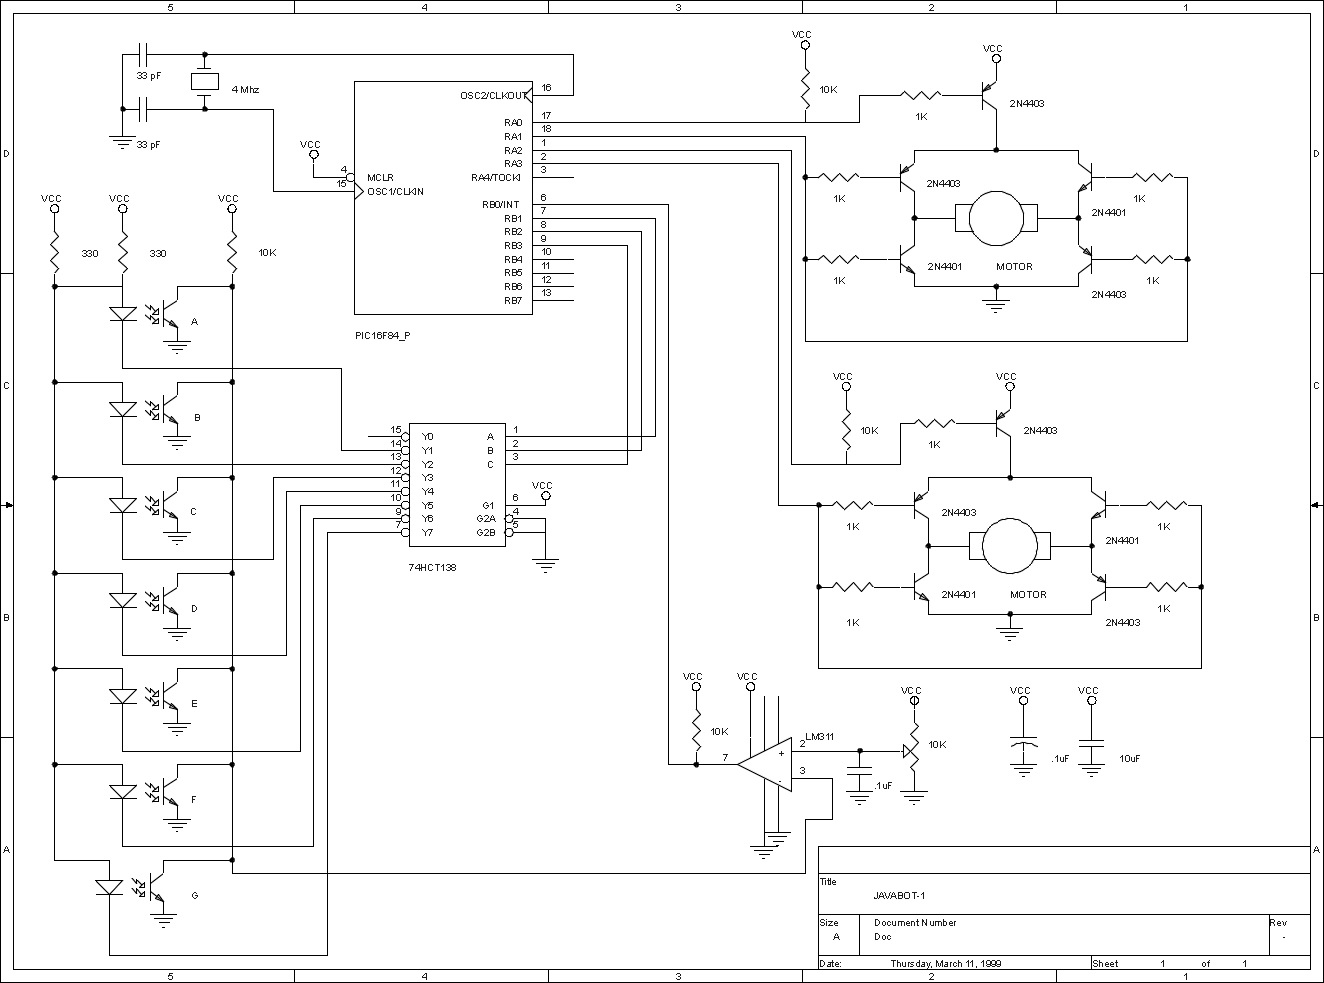
Description: The JavaBot1 is a compact line-following robot engineered to trace a black line drawn on a dry erase board. It is specifically designed to navigate along very narrow curves.
The JavaBot1 employs a differential drive mechanism, which allows it to maneuver effectively along the designated path. The robot is equipped with infrared (IR) sensors that detect the contrast between the black line and the surrounding surface. These sensors are strategically positioned at the front of the robot to ensure accurate detection of the line's edges.
The control system of the JavaBot1 consists of a microcontroller that processes the signals from the IR sensors. Based on the readings, the microcontroller adjusts the speed and direction of the motors driving the wheels. For instance, if the left sensor detects the black line, the right motor will speed up to turn the robot back onto the line, and vice versa.
Power for the JavaBot1 is supplied by a rechargeable battery pack, ensuring portability and ease of use. The robot's chassis is constructed from lightweight materials to enhance speed and maneuverability while maintaining structural integrity.
In terms of programming, the JavaBot1 can be configured using a simple algorithm that enables it to follow the line efficiently. This algorithm can be modified to improve performance on different surfaces or to handle more complex line patterns.
Overall, the JavaBot1 serves as an educational tool for demonstrating basic robotics principles, including sensor integration, motor control, and algorithmic programming, making it an ideal project for students and hobbyists interested in robotics and electronics.Design Goal: The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight c..
The JavaBot1 employs a differential drive mechanism, which allows it to maneuver effectively along the designated path. The robot is equipped with infrared (IR) sensors that detect the contrast between the black line and the surrounding surface. These sensors are strategically positioned at the front of the robot to ensure accurate detection of the line's edges.
The control system of the JavaBot1 consists of a microcontroller that processes the signals from the IR sensors. Based on the readings, the microcontroller adjusts the speed and direction of the motors driving the wheels. For instance, if the left sensor detects the black line, the right motor will speed up to turn the robot back onto the line, and vice versa.
Power for the JavaBot1 is supplied by a rechargeable battery pack, ensuring portability and ease of use. The robot's chassis is constructed from lightweight materials to enhance speed and maneuverability while maintaining structural integrity.
In terms of programming, the JavaBot1 can be configured using a simple algorithm that enables it to follow the line efficiently. This algorithm can be modified to improve performance on different surfaces or to handle more complex line patterns.
Overall, the JavaBot1 serves as an educational tool for demonstrating basic robotics principles, including sensor integration, motor control, and algorithmic programming, making it an ideal project for students and hobbyists interested in robotics and electronics.Design Goal: The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight c..
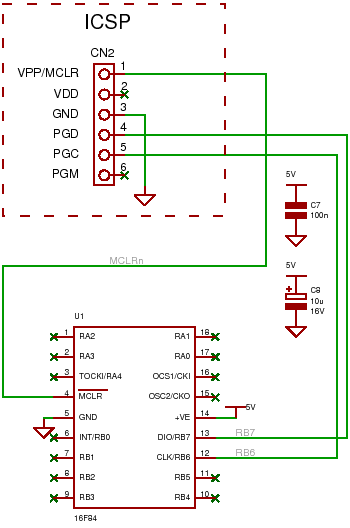
pic16f84
An introduction to the PIC16F84 microcontroller, including connections for an ICSP programmer and a circuit example.
The PIC16F84 is an 8-bit microcontroller from Microchip Technology, widely utilized in various embedded applications due to its versatility and ease of use. It features...
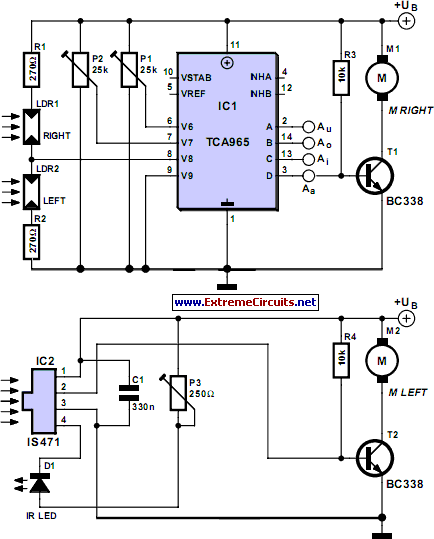
discrete robot schematics
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The primary component in the circuit is a window discriminator, which functions as an advanced window comparator. Resistors R1 and R2, in...
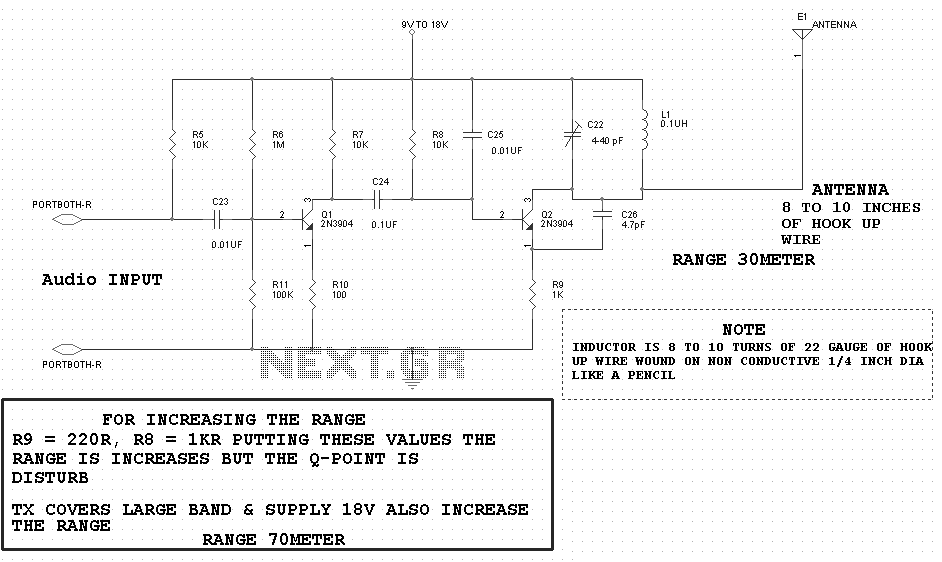
motor timer
The primary concept is to rotate the motor slightly every 15 seconds. A monofilament line conveys the motion to the ornament, which is wound by the motor and gradually unwinds as the ornament turns. The charging circuit includes a 1...
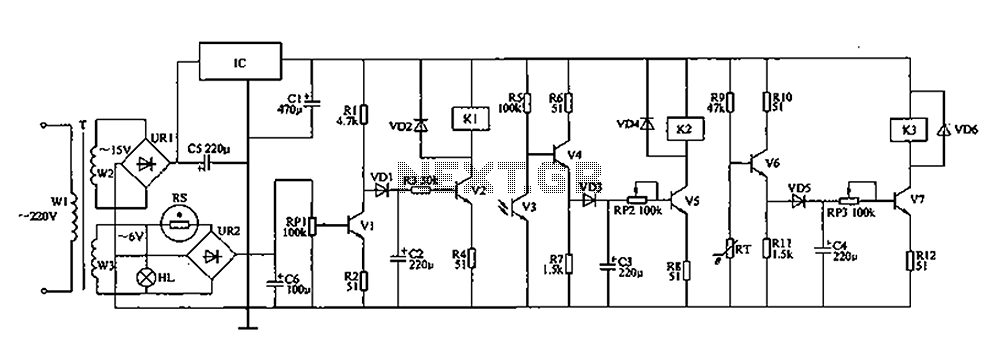
Coop automatic controller circuit diagram
The automatic controller for a chicken coop is designed to automatically regulate light, temperature, and humidity, thereby enhancing egg production and survival rates of chickens. This device is intended for specialized poultry households in rural areas. The circuit operates through...
PIC16F84 IC For 40 MHZ/400 MHZ Frequency Counter
The following circuit illustrates a 40 MHz/400 MHz Frequency Counter Circuit Diagram. This circuit is based on the PIC16F84 IC. Features:
The frequency counter circuit operates within the range of 40 MHz to 400 MHz, utilizing the PIC16F84 microcontroller as...
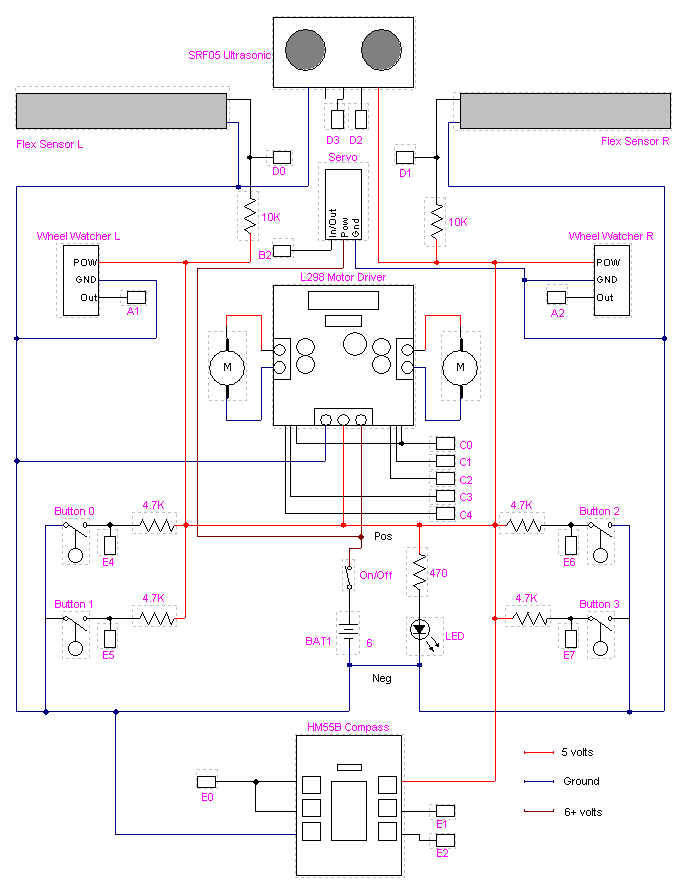
Map Bot
The purpose of this robot is to navigate and map a single floor of a house, using the created map to intelligently traverse the area. Diagnostic software has been developed to verify that all subsystems of the robot are functioning...
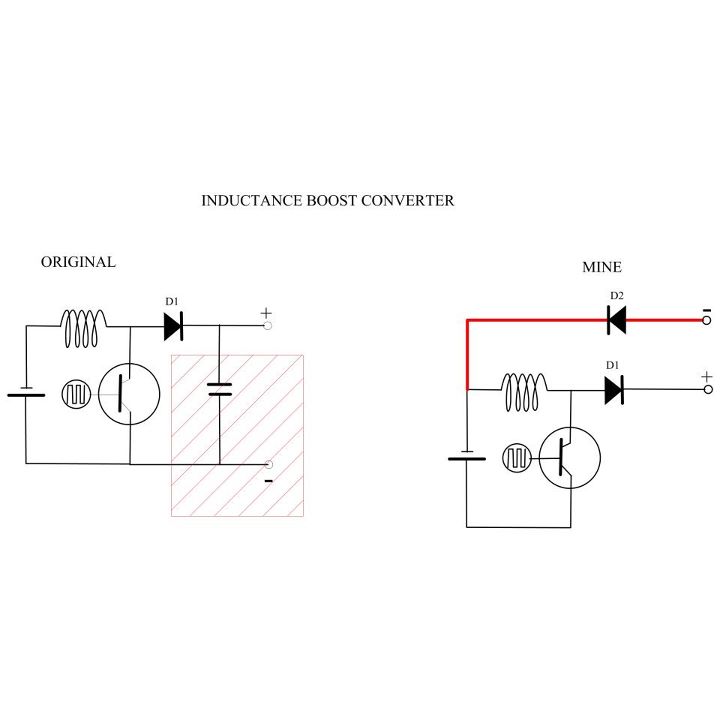
My Motors got me to Tap into Radiant Energy
A new user is seeking to share information about their experiences on this platform.
The user expresses a desire to communicate and engage with the community regarding their experiences. This indicates an interest in exchanging knowledge and possibly seeking assistance or...
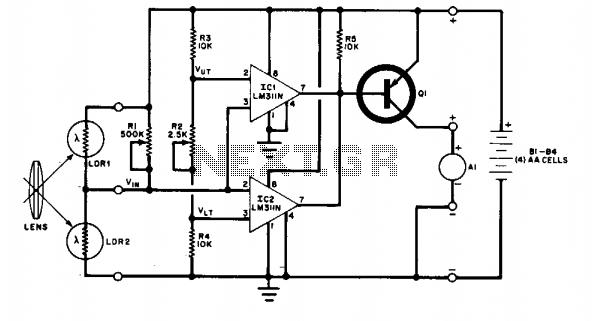
Field disturbance sensor-alarm
The change in ambient light triggers the alarm by changing the resistance of LDR1 and LDR2.
The circuit utilizes two light-dependent resistors (LDR1 and LDR2) to detect variations in ambient light levels. LDRs are passive components that exhibit a change in...
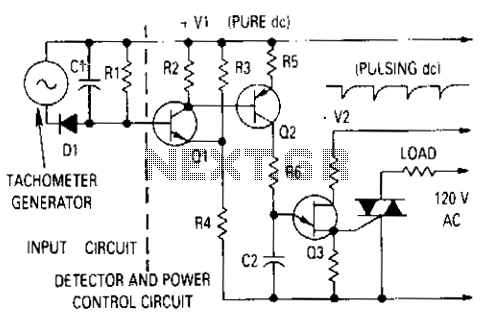
Motor control with tachometer
The generator output is rectified, filtered, and applied between the positive supply voltage and the base of the detector transistor. This configuration provides a negative voltage that reduces the base voltage as the speed increases. During normal operation, if the...