


interfacing servo motor with 8051 using keil c
#8051
#servo motor
#Keil C
#robotic arm
#angular control
#closed loop
#position feedback
#stepper motor
#embedded systems
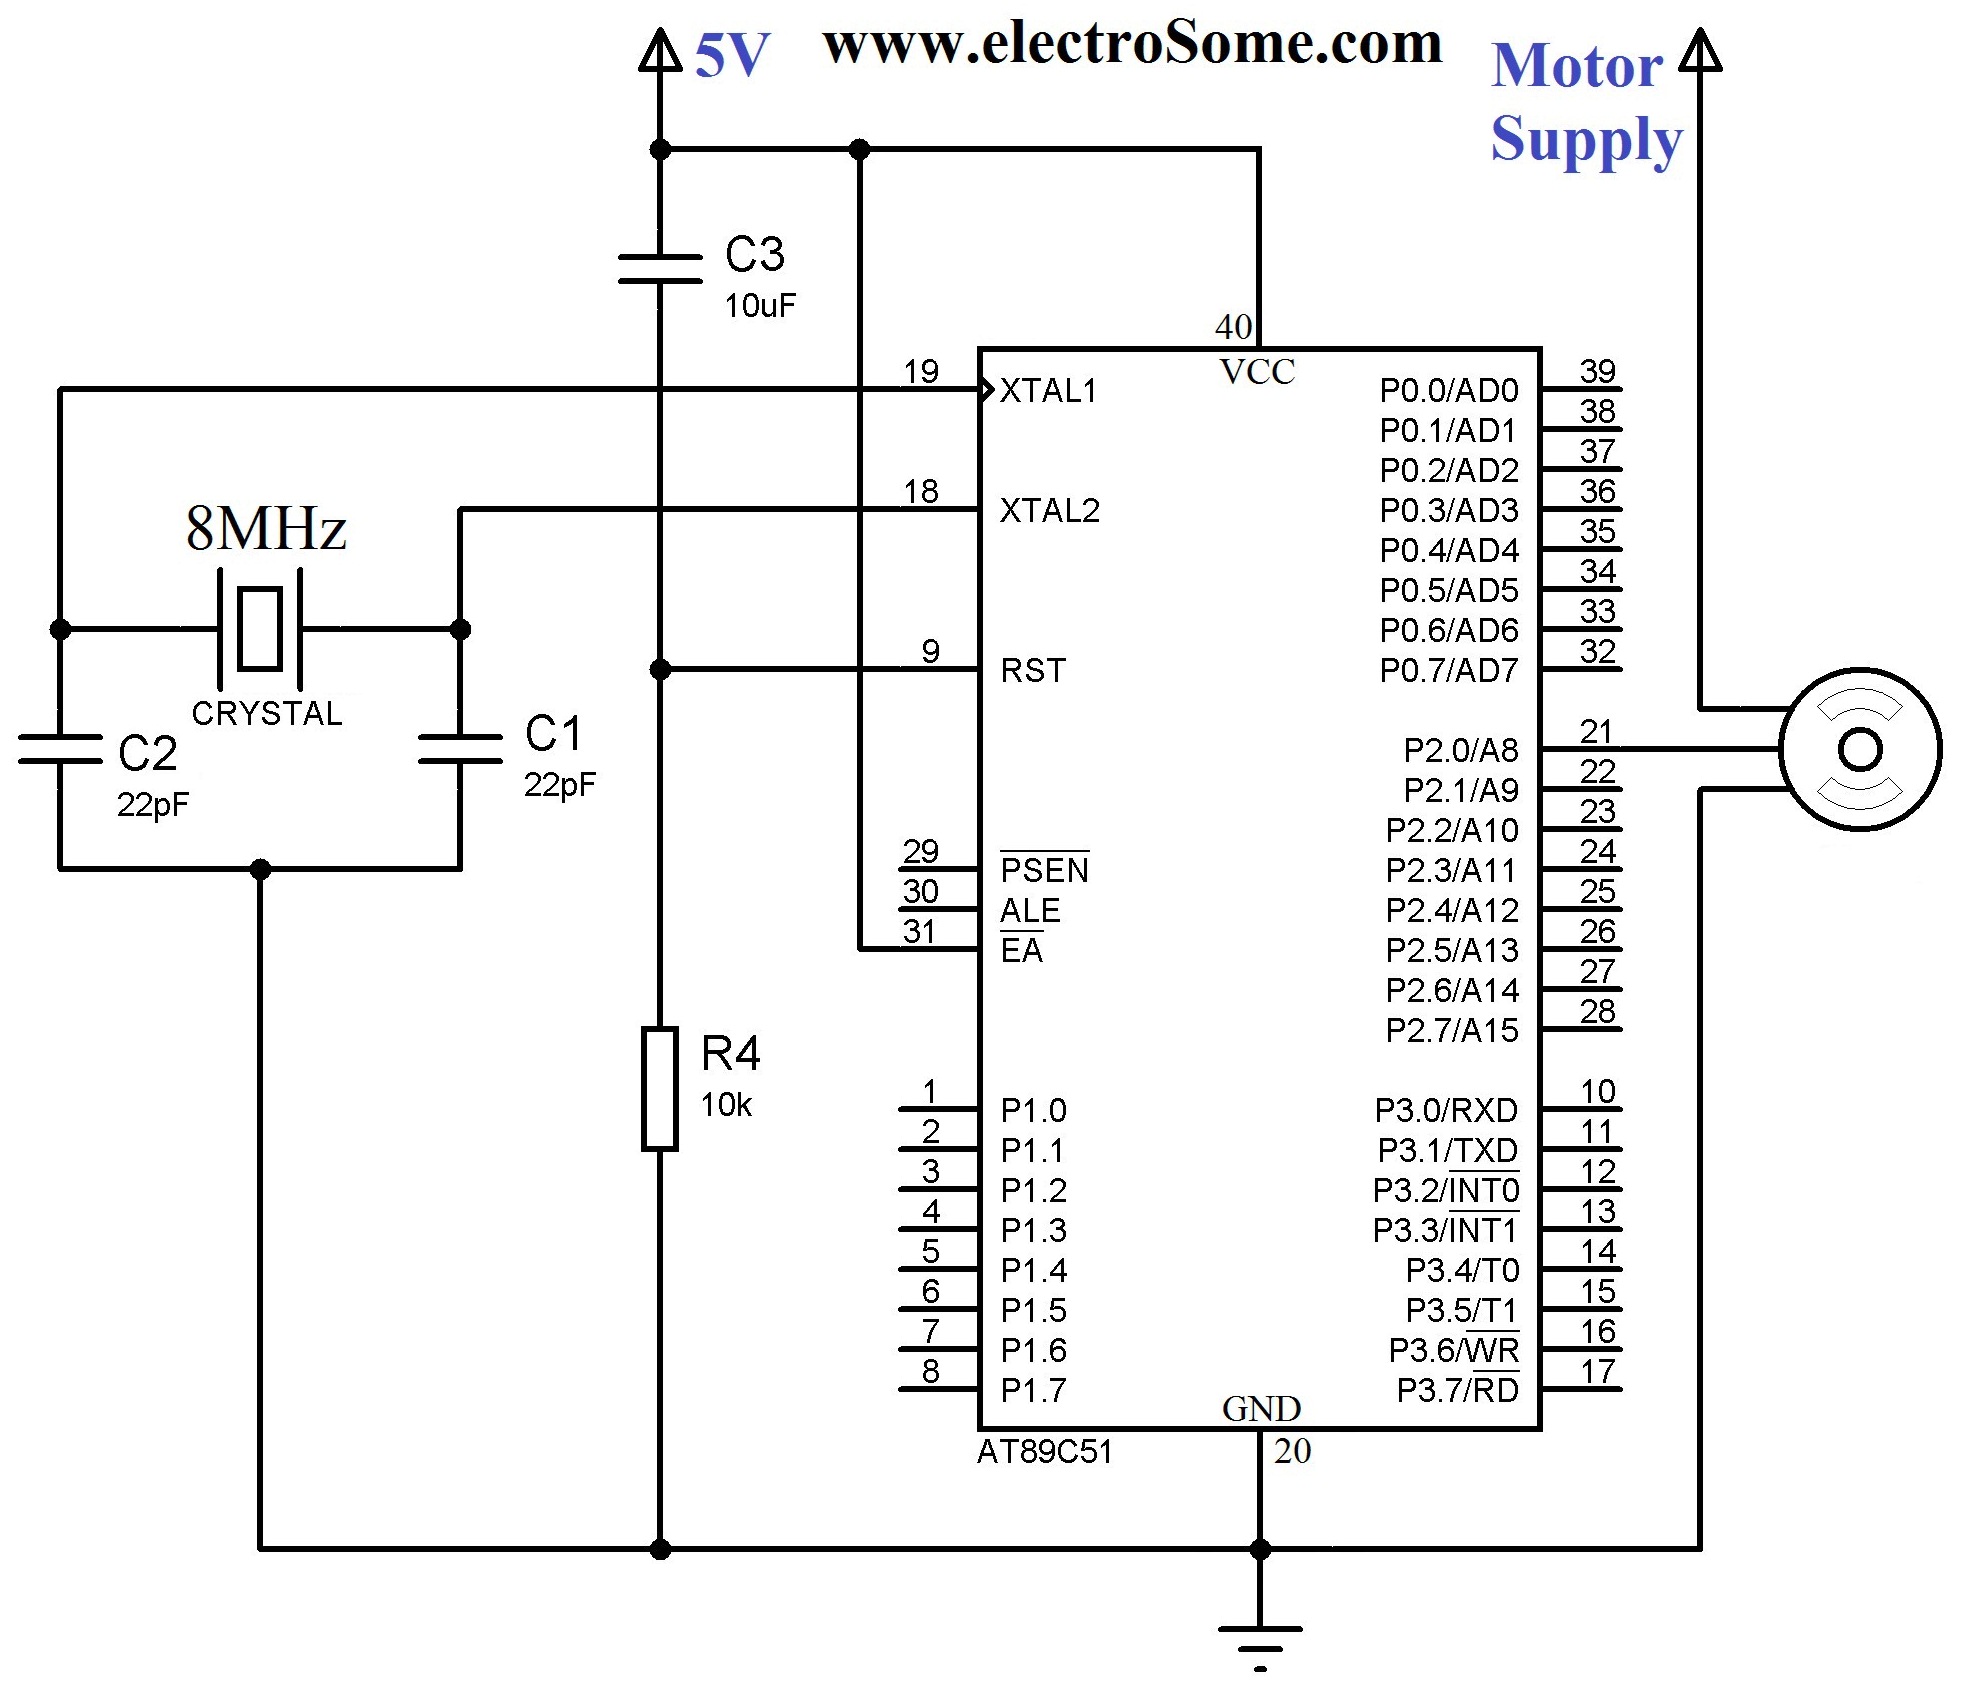
Description: A servo motor employs a servo mechanism, which is a closed-loop system that utilizes position feedback to accurately control the angular position of its shaft. Stepper motors, which operate as an open-loop system, can also achieve precise angular control, but servo motors are generally favored for angular motion applications, such as robotic arms. Additionally, controlling servo motors is straightforward and does not require extra hardware, unlike stepper motors. Typically, hobby servo motors consist of three wires: two (red and black) for power supply, and a third wire for the control signal that dictates angular position. The control signals are Pulse Width Modulated (PWM) waves, where the angle of rotation is determined by the pulse width at the control pin. The servo motor in this context has a rotation range from 0 to 180 degrees, with the exact angular position controlled by varying the pulse width between 1 ms and 2 ms. It is advisable to refer to the datasheet of the specific servo for details regarding angle and pulse width specifications. An 8 MHz crystal oscillator is employed to provide the necessary clock signal for the 8051 microcontroller, and 22 pF capacitors are used to stabilize the crystal's operation. A 10 kΩ resistor and a 10 µF capacitor are included to ensure the microcontroller receives the required Power-On Reset (POR). The control for the servo motor is connected to the first pin of Port 2.
The provided code snippet includes the necessary instructions for controlling the servo motor through the 8051 microcontroller. The servo motor control is initiated by setting the motor_pin to low, followed by a loop that sequentially rotates the motor to 0 degrees, 90 degrees, and 180 degrees. Each position is achieved by sending a high signal to the motor_pin for a specific duration, determined by the Delay_servo function, which introduces a delay in microseconds. The main function executes this loop indefinitely, allowing continuous operation of the servo motor. The Delay function introduces a longer delay in milliseconds, while the Delay_servo function is designed for finer control of the servo's movement timing. This setup is essential for applications requiring precise angular positioning, ensuring that the servo motor operates smoothly and accurately within its defined range.A servo motor uses servoG‚ mechanism, which is a closed loop mechanism that uses position feedback to control the precise angular position of the shaft. Stepper Motors, which is an open loop system can also be used for precise angular control. But Servo Motors are preferred in angular motion applications such as robotic arm. G‚Moreover controlling of servo motors are very simple, easy and needs no extra hardware like stepper motor. Usually hobby circuit servo motors have three wires. Two of them are red and black which is used to give power to the motor and the third wire is used to provide control signal for angular position. It uses Pulse Width Modulated ( PWM ) waves as control signals. The angle of rotation is determined by the width of the pulse at the control pin. The servo motor used here is having angle of rotation from 0 to 180 degrees. We can control the exact angular position by varying the pulse betweenG‚1msG‚to 2ms. Before using this in your application, please refer the datasheet of your servo for angle and pulse width informations.
8MHz crystal is used to provide the required clock for 8051 microcontroller and 22pF capacitors are used to stabilize the operation of crystal. 10KG © resistor and 10G F capacitor is used to provide the required Power On Reset (POR) to the microcontroller.
Control of Servo Motor is connected to first pin of Port 2. #include #include #include sbit motor_pin = P0; void Delay(unsigned int); void Delay_servo(unsigned int); void main() { motor_pin = 0; do { //Turn to 0 degree motor_pin = 1; Delay_servo(50); motor_pin = 0; Delay(1000); //Turn to 90 degree motor_pin=1; Delay_servo(82); motor_pin=0; Delay(1000); //Turn to 180 degree motor_pin=1; Delay_servo(110); motor_pin=0; Delay(1000); }while(1); } void Delay(unsigned int ms) { unsigned long int us = ms*1000; while(us-) { _nop_(); } } void Delay_servo(unsigned int us) { while(us-) { _nop_(); } }
The provided code snippet includes the necessary instructions for controlling the servo motor through the 8051 microcontroller. The servo motor control is initiated by setting the motor_pin to low, followed by a loop that sequentially rotates the motor to 0 degrees, 90 degrees, and 180 degrees. Each position is achieved by sending a high signal to the motor_pin for a specific duration, determined by the Delay_servo function, which introduces a delay in microseconds. The main function executes this loop indefinitely, allowing continuous operation of the servo motor. The Delay function introduces a longer delay in milliseconds, while the Delay_servo function is designed for finer control of the servo's movement timing. This setup is essential for applications requiring precise angular positioning, ensuring that the servo motor operates smoothly and accurately within its defined range.A servo motor uses servoG‚ mechanism, which is a closed loop mechanism that uses position feedback to control the precise angular position of the shaft. Stepper Motors, which is an open loop system can also be used for precise angular control. But Servo Motors are preferred in angular motion applications such as robotic arm. G‚Moreover controlling of servo motors are very simple, easy and needs no extra hardware like stepper motor. Usually hobby circuit servo motors have three wires. Two of them are red and black which is used to give power to the motor and the third wire is used to provide control signal for angular position. It uses Pulse Width Modulated ( PWM ) waves as control signals. The angle of rotation is determined by the width of the pulse at the control pin. The servo motor used here is having angle of rotation from 0 to 180 degrees. We can control the exact angular position by varying the pulse betweenG‚1msG‚to 2ms. Before using this in your application, please refer the datasheet of your servo for angle and pulse width informations.
8MHz crystal is used to provide the required clock for 8051 microcontroller and 22pF capacitors are used to stabilize the operation of crystal. 10KG © resistor and 10G F capacitor is used to provide the required Power On Reset (POR) to the microcontroller.
Control of Servo Motor is connected to first pin of Port 2. #include
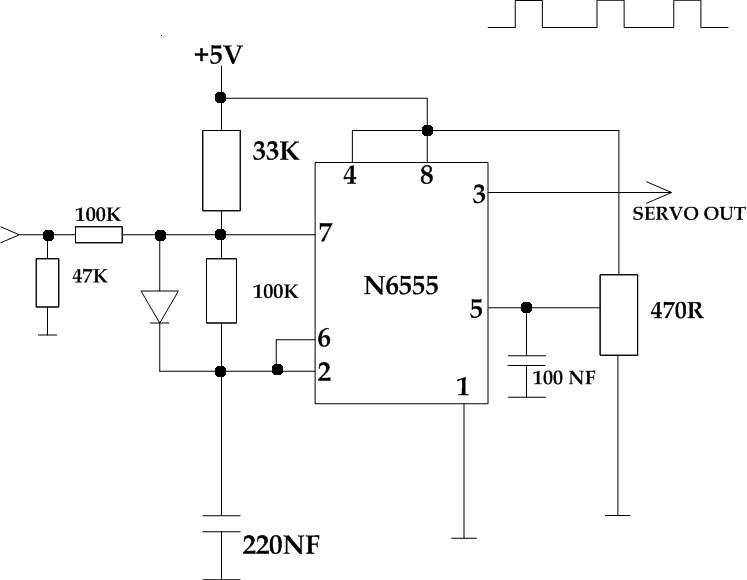
Servo controlling circuit
This circuit takes a standard 0-10V control voltage (for example, from an analog light control desk) and outputs a standard 1-2 ms control pulse for RC servo motors. The components used in this circuit include:
- 2 x 100 kΩ...
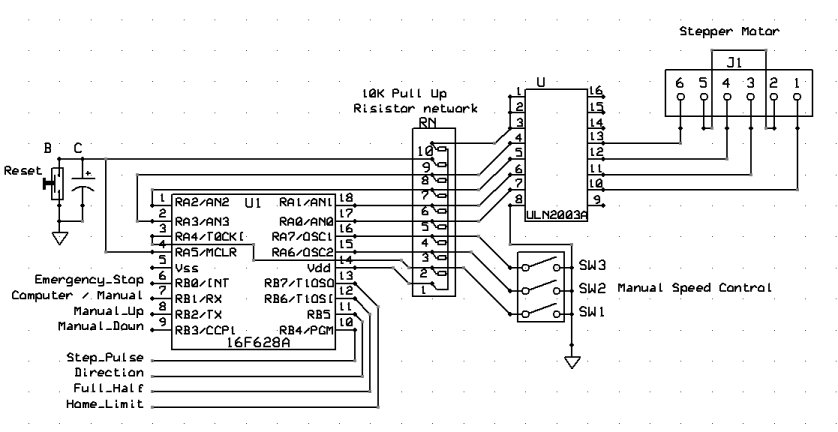
stepper motor question
The inquiry was focused not only on power consumption but also on the observation that some stepper motors have more wires than the standard four, while others are classified as bipolar.
Stepper motors are widely used in various applications due to...
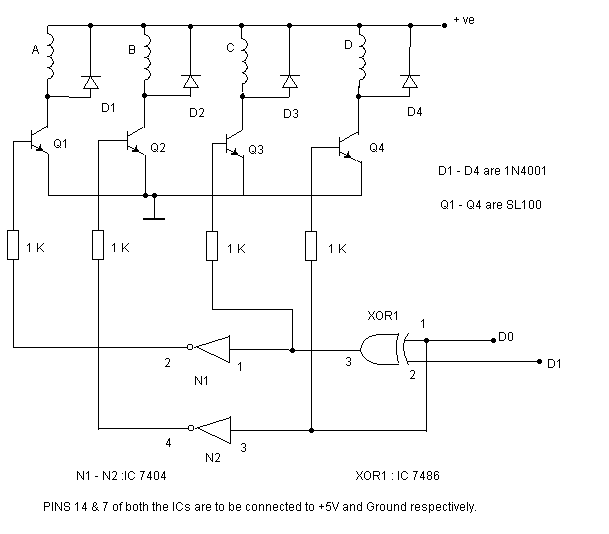
Simple stepper motor controller
The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils. The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100....
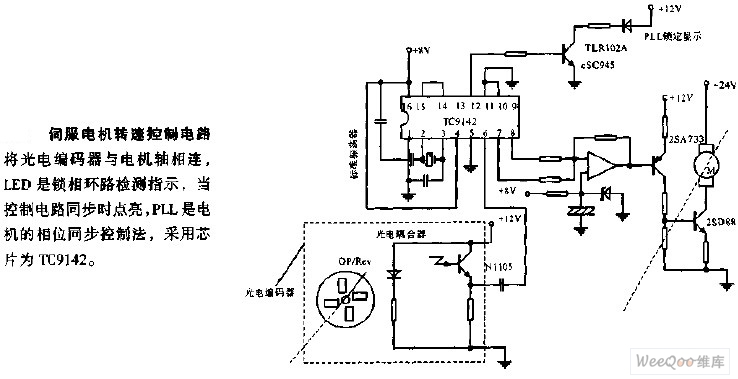
Servo motor speed control circuit
The servo motor speed control circuit connects the photoelectric encoder to the motor shaft. The LED serves as an indicator light for the phase-locked loop (PLL) detection, illuminating when the control circuit is synchronized. The PLL employs a phase synchronous...
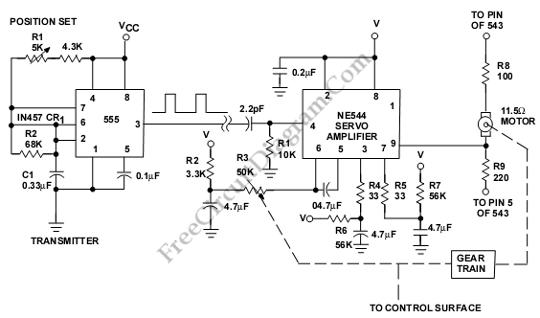
Servo Motor System Controller
This is a servo system controller circuit designed for remote control of a servo motor. The circuit utilizes a 555 timer and requires only six additional components.
The servo system controller circuit operates by generating a pulse-width modulation (PWM) signal, which...
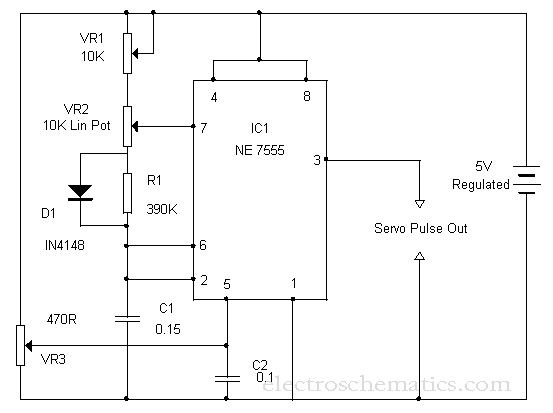
Servo Motor Controller Circuit
This is a simple basic design of a servo motor controller with a pulse generator. It utilizes the CMOS IC 7555 in astable mode to generate pulses for driving the motor.
The servo motor controller circuit employs the CMOS IC 7555...
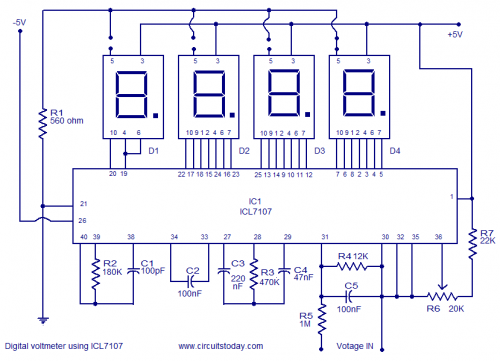
digital multimeter using 8051
Construct a digital multimeter capable of measuring DC and AC voltages up to 100V and DC and AC currents up to 1A. The circuit will be powered by a 9V battery. The design incorporates a modified voltmeter to suit specific...
Beginning Embedded Electronics - 2
Acquire all the components required for this lecture here. It is highly recommended to obtain a multimeter with a continuity setting. A quality multimeter with this feature typically costs around $60, while premium models can reach $300. The $60 option...
LCD Interfacing with 8051
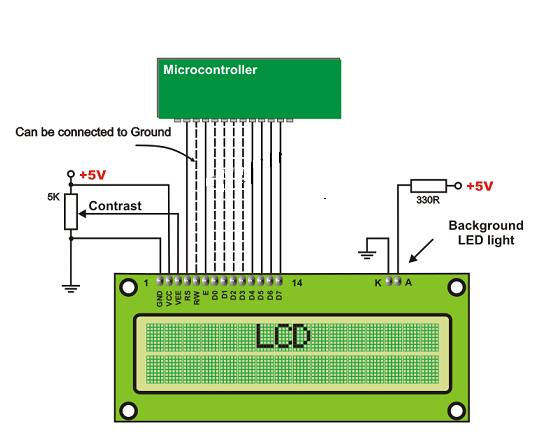
Learn how to interface a 16x2 LCD with the 8051 microcontroller. Download free source code for LCD interfacing with the 8051 microcontroller.
The interfacing of a 16x2 Liquid Crystal Display (LCD) with the 8051 microcontroller is a common practice in embedded...