


Dual Channel Servo Pulse to H-Bridge Interface
#PIC16F876
#H-Bridge
#servo control
#motor control
#current limiting
#noise rejection
#channel mixing
#robotics
#PWM
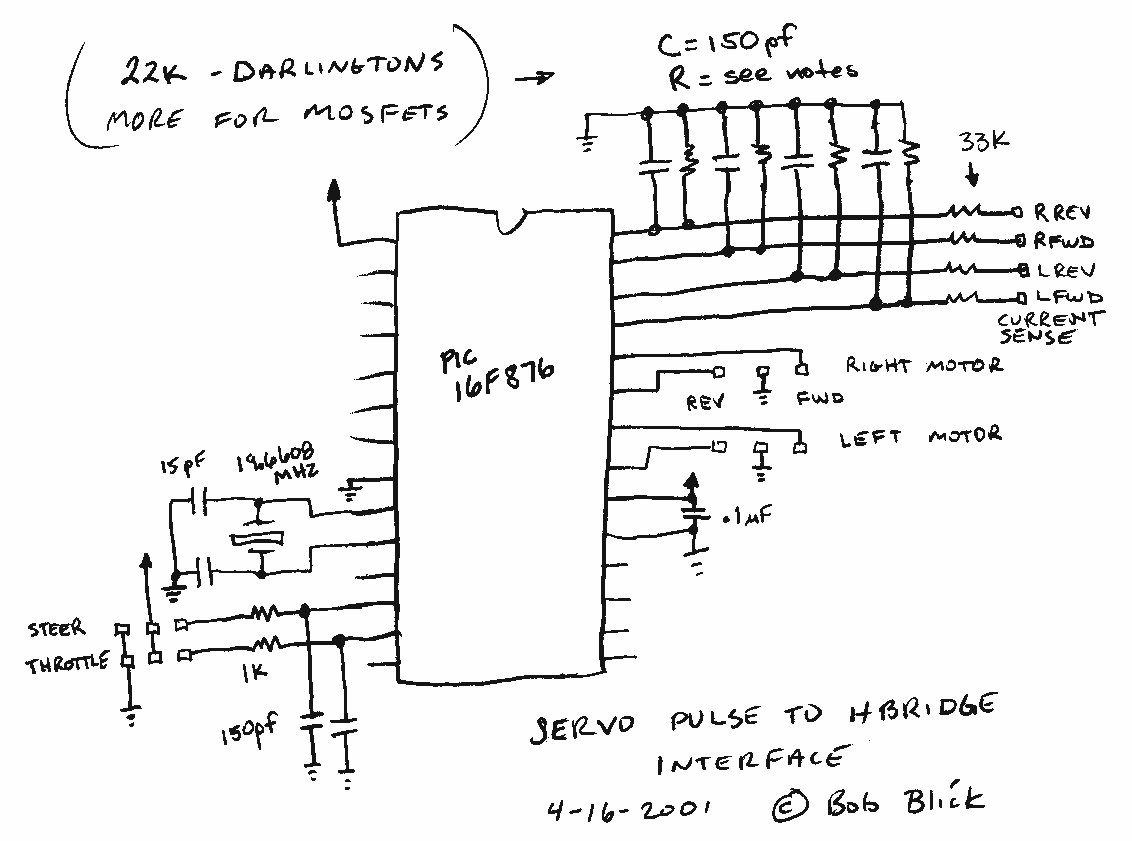
Description: The interface uses a PIC16F876 microcontroller and not much else. It performs channel mixing, current limiting, and noise rejection. Push the stick forward, both motors move forward, move the stick to the left and the robot moves left. It makes the robot very driveable. You can use a wheel transmitter meant for cars to control it, in other words, one channel is throttle(both forward and reverse), the other steering. Speed control is smooth, and the H-Bridge transistors are sensed and protected cycle-by-cycle against over-current. Noise from the receiver, whether the transmitter is on or off, is ignored. Temperature sensing is also possible, but I haven't incorporated it in this version.
The described robotic interface utilizes the PIC16F876 microcontroller, which serves as the central processing unit for managing the control signals and motor operations. The microcontroller is responsible for interpreting input from a wheel transmitter, typically used for RC cars, allowing for intuitive control over the robot's movement. The system features two primary functions: channel mixing and current limiting, which enhance the robot's maneuverability and safety.
Channel mixing is implemented to ensure that both motors respond appropriately to the control stick's position. When the stick is pushed forward, the microcontroller sends signals to both motors to operate in the forward direction, enabling straight-line movement. Conversely, when the stick is moved left, the microcontroller adjusts the speed of each motor accordingly, allowing the robot to turn left smoothly. This feature significantly improves the driveability of the robot, making it easier to navigate various terrains.
The current limiting function is crucial for protecting the H-Bridge transistors, which are used to control the direction and speed of the motors. The system incorporates cycle-by-cycle current sensing, which monitors the current flowing through the transistors. If an over-current condition is detected, the microcontroller can take corrective action to prevent damage, ensuring the longevity and reliability of the robotic system.
Noise rejection is another essential aspect of the design. The microcontroller is programmed to filter out any extraneous signals from the receiver, whether the transmitter is active or inactive. This capability ensures that the robot operates smoothly without interference from unwanted noise, which could lead to erratic movements.
Additionally, the design allows for the potential incorporation of temperature sensing. While this feature has not been implemented in the current version, it could provide valuable feedback for monitoring the operating conditions of the motors or the microcontroller itself, enhancing the overall functionality of the robotic system.
In summary, the interface developed around the PIC16F876 microcontroller effectively combines channel mixing, current limiting, and noise rejection to create a robust control system for a robotic platform. The design allows for intuitive control via a wheel transmitter, ensuring smooth and responsive operation in various driving scenarios.The interface uses a PIC16F876 microcontroller and not much else. It performs channel mixing, current limiting, and noise rejection. Push the stick forward, both motors move forward, move the stick to the left and the robot moves left. It makes the robot very driveable. You can use a wheel transmitter meant for cars to control it, in other words, one channel is throttle(both forward and reverse), the other steering.
Speed control is smooth, and the H-Bridge transistors are sensed and protected cycle-by-cycle against over-current. Noise from the receiver, whether the transmitter is on or off, is ignored. Temperature sensing is also possible, but I havent incorporated it in this version.
The described robotic interface utilizes the PIC16F876 microcontroller, which serves as the central processing unit for managing the control signals and motor operations. The microcontroller is responsible for interpreting input from a wheel transmitter, typically used for RC cars, allowing for intuitive control over the robot's movement. The system features two primary functions: channel mixing and current limiting, which enhance the robot's maneuverability and safety.
Channel mixing is implemented to ensure that both motors respond appropriately to the control stick's position. When the stick is pushed forward, the microcontroller sends signals to both motors to operate in the forward direction, enabling straight-line movement. Conversely, when the stick is moved left, the microcontroller adjusts the speed of each motor accordingly, allowing the robot to turn left smoothly. This feature significantly improves the driveability of the robot, making it easier to navigate various terrains.
The current limiting function is crucial for protecting the H-Bridge transistors, which are used to control the direction and speed of the motors. The system incorporates cycle-by-cycle current sensing, which monitors the current flowing through the transistors. If an over-current condition is detected, the microcontroller can take corrective action to prevent damage, ensuring the longevity and reliability of the robotic system.
Noise rejection is another essential aspect of the design. The microcontroller is programmed to filter out any extraneous signals from the receiver, whether the transmitter is active or inactive. This capability ensures that the robot operates smoothly without interference from unwanted noise, which could lead to erratic movements.
Additionally, the design allows for the potential incorporation of temperature sensing. While this feature has not been implemented in the current version, it could provide valuable feedback for monitoring the operating conditions of the motors or the microcontroller itself, enhancing the overall functionality of the robotic system.
In summary, the interface developed around the PIC16F876 microcontroller effectively combines channel mixing, current limiting, and noise rejection to create a robust control system for a robotic platform. The design allows for intuitive control via a wheel transmitter, ensuring smooth and responsive operation in various driving scenarios.The interface uses a PIC16F876 microcontroller and not much else. It performs channel mixing, current limiting, and noise rejection. Push the stick forward, both motors move forward, move the stick to the left and the robot moves left. It makes the robot very driveable. You can use a wheel transmitter meant for cars to control it, in other words, one channel is throttle(both forward and reverse), the other steering.
Speed control is smooth, and the H-Bridge transistors are sensed and protected cycle-by-cycle against over-current. Noise from the receiver, whether the transmitter is on or off, is ignored. Temperature sensing is also possible, but I havent incorporated it in this version.
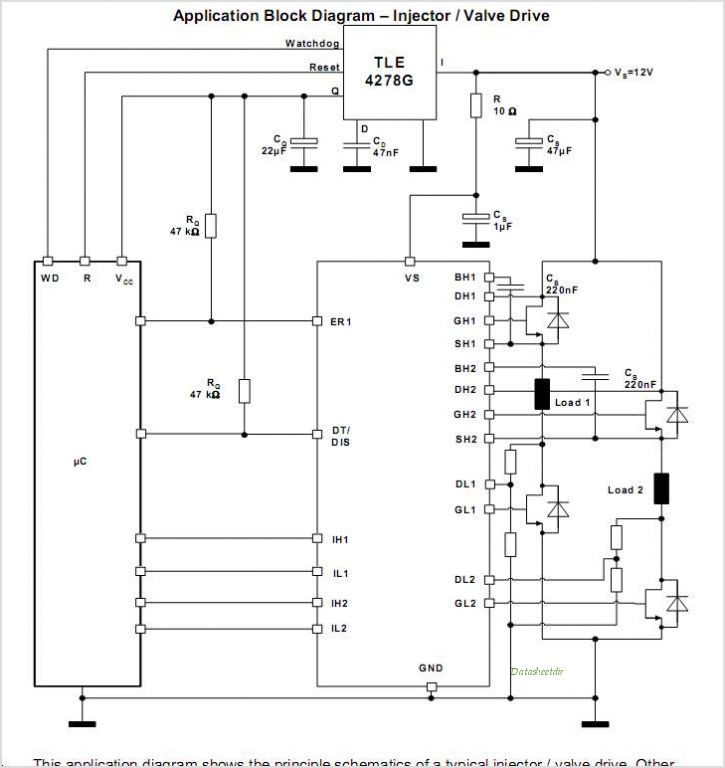
TLE6282 H-Bridge And Half Bridge Driver IC
The converter utilizes a TinySwitch-III family member (U2, a TNY279PN) to deliver up to 1.8 A of load current to six high-intensity Luxeon LEDs (LXHL series). The output voltage is slightly below the forward voltage drop of the LEDs, enabling...
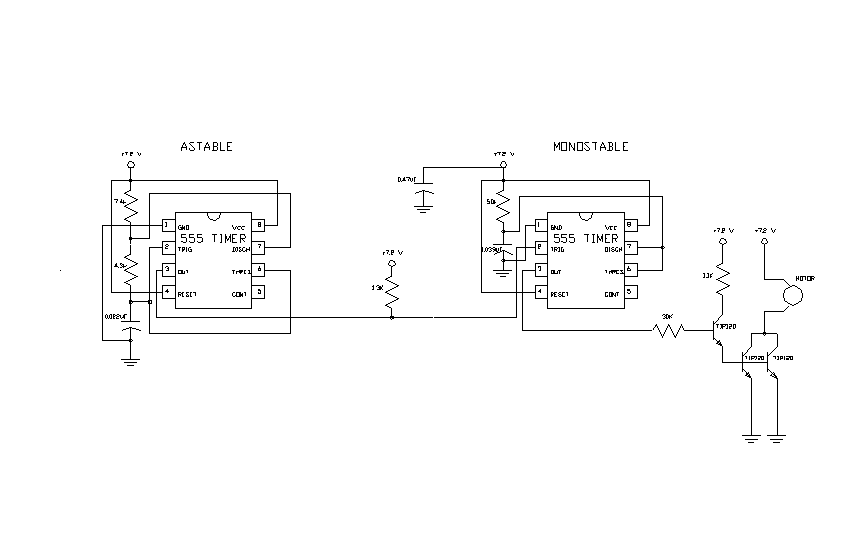
pulse width modulated (PWM) controller for high current
The second 555 timer was configured as a monostable circuit, commonly referred to as a one-shot since an output pulse only occurs if there is a trigger on the input. When this timer is triggered, the potentiometer in the RC...
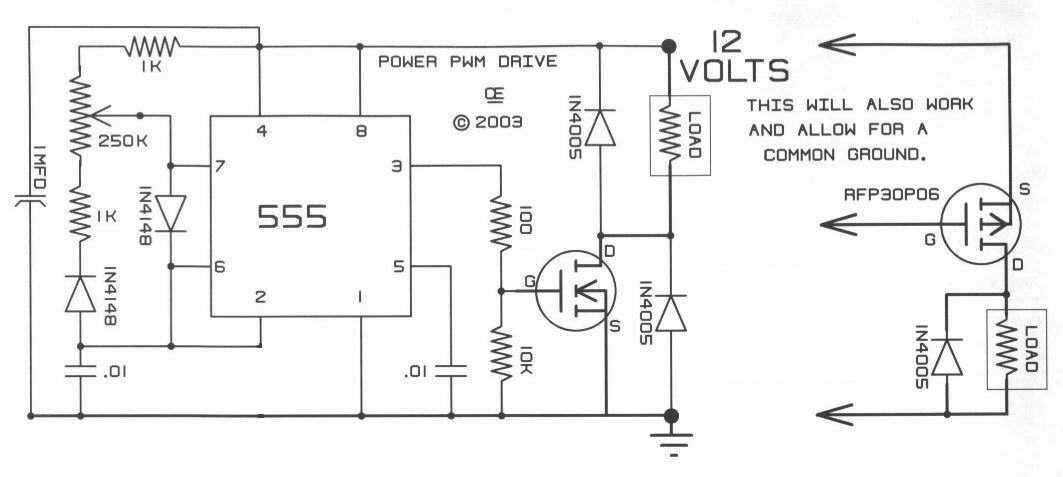
H2 PWM Generators
The Generator cell must have reasonable surface area on the Plates to generate a reasonable amount of Hydrogen/Oxygen. And a Typical construction would use Stainless Steel for the Electrodes to prevent them from being Quickly eaten away. More: DANGER: Hydrogen...
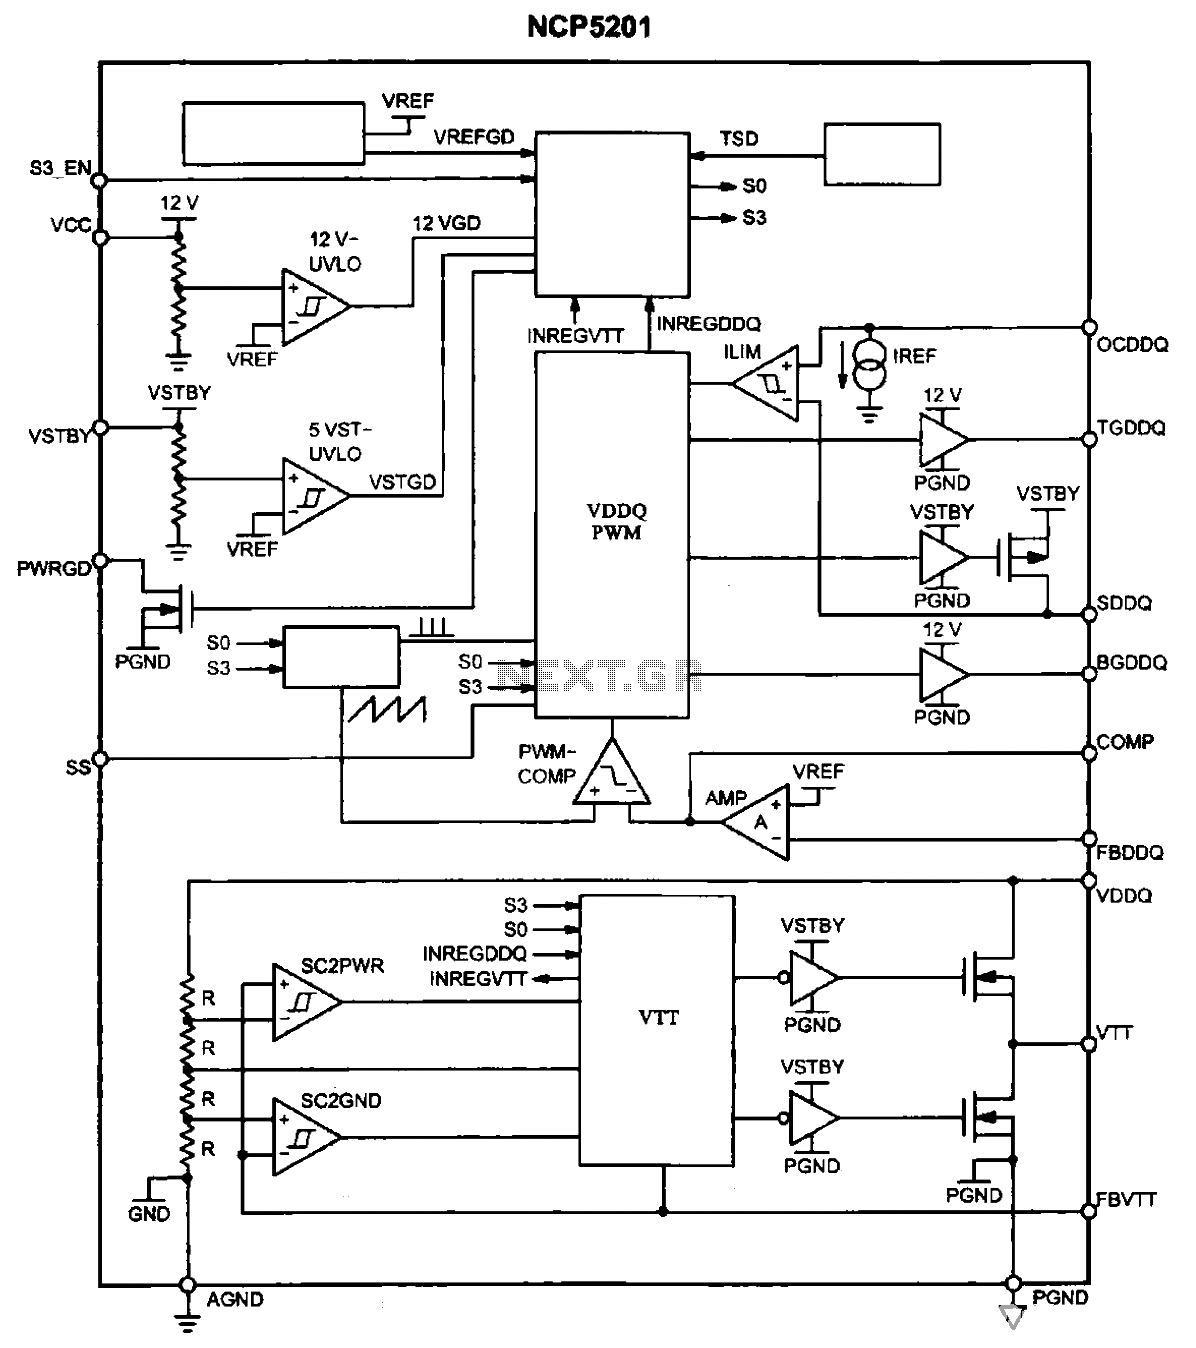
Internal functional block diagram of NCP5201
The NCP5201 chip contains two sets of PWM signal generating circuits, each with a dedicated set of output pins. These circuits produce two opposite phase PWM signals, which are applied to the gates of three field effect transistors. This arrangement...
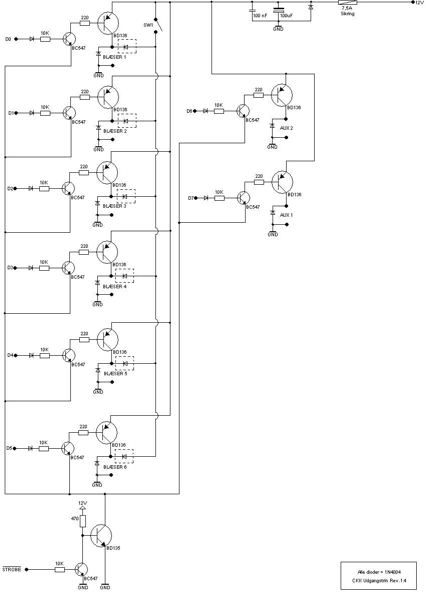
8 Channel software controlled fanbus with PWM
When discussing fan control, there are generally two methods: linear control and pulse-width modulation (PWM) control. Linear control is the most commonly used method, which involves reducing the voltage supplied to the fan. For a fan rated at 12 volts,...
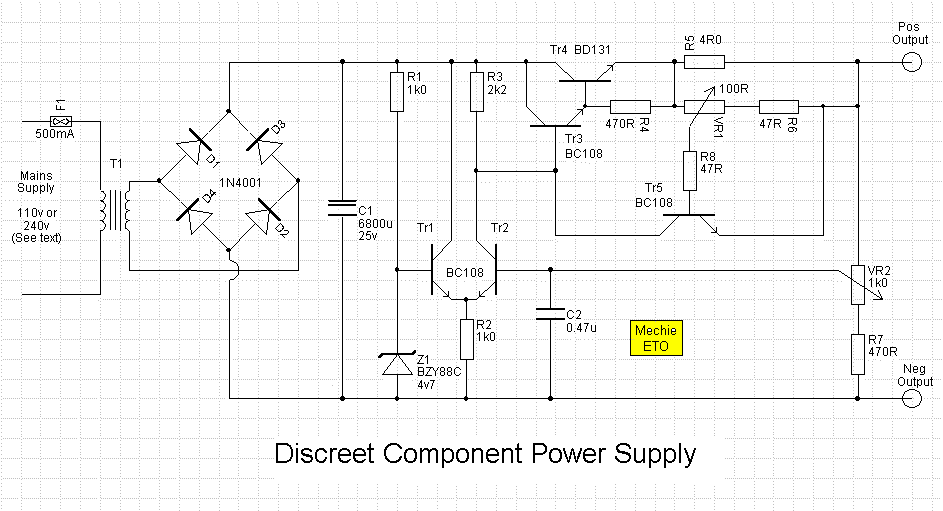
stabilised power supply current limiting
An error amplifier is constructed using transistors Tr1 and Tr2, configured as a differential amplifier, commonly referred to as a long-tailed pair, with the collector leads being a notable feature. One input of this differential amplifier is sourced from a...
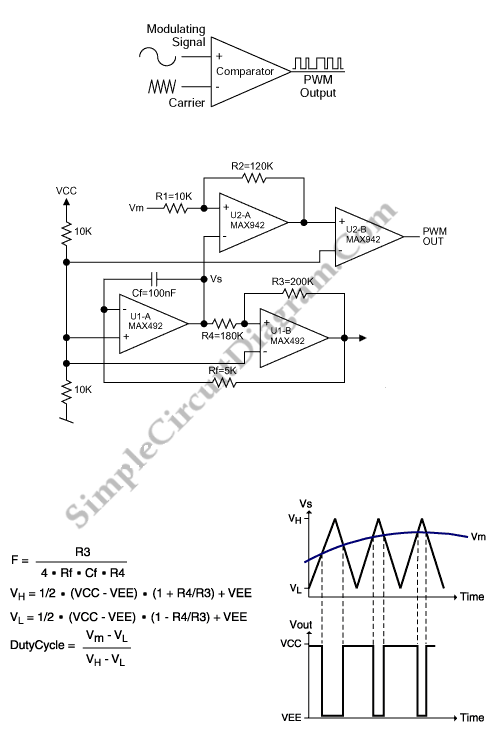
PWM Modulator Using Op-Amp
This is a simple PWM modulator circuit. Comparing the message signal to a ramp or triangular waveform is the simplest way to produce a PWM signal. When the...
The PWM (Pulse Width Modulation) modulator circuit operates by comparing a modulating signal,...
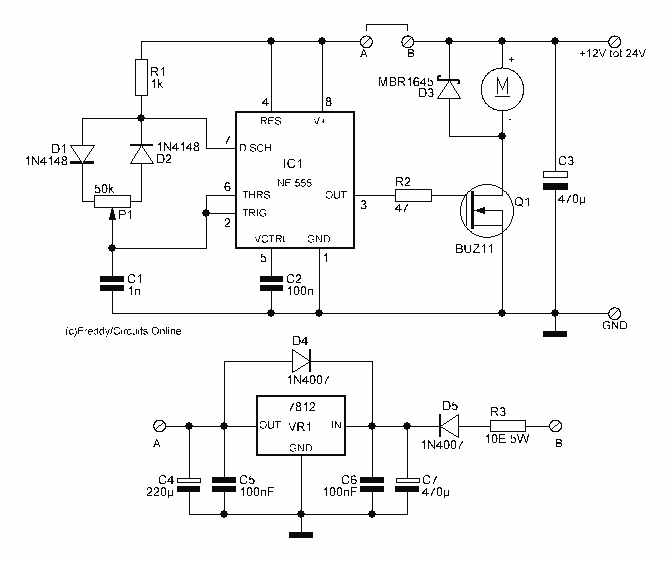
Motor Control circuit II
This circuit is 12 volt motors and lights well regulated. The scheme operates with PWM (Pulse Width Modulation). By IC1, a 555 is a square wave generated by a controllable duty cycle. This means that the width of the pulse...
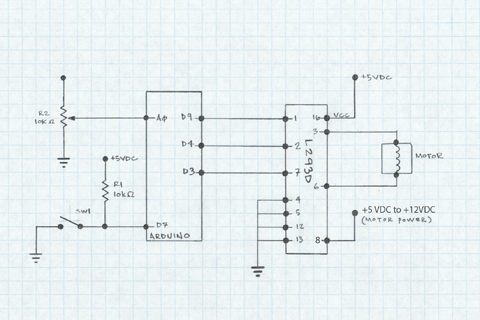
H Bridge tutorial
The L293D H-Bridge is utilized to operate a 12V DC motor with an Arduino. This H-Bridge facilitates the interfacing of the motor, which requires significantly more current and voltage than the output pins can provide. With minimal connections, it enables...