


Driving a buzzer
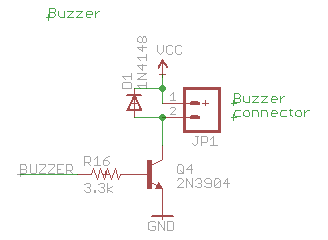
Description: To connect the buzzer to the ATMEGA168, the recommendation from the datasheet was followed: the buzzer is driven by a 2N3904 NPN transistor, and a diode is used to protect the transistor from reverse currents generated by magnetic inductance. The setup configures PB1 as an output using DDRB = _BV(PB1). The initial period is set to 1600 microseconds. In the main loop, the code toggles the output at PB1, with a delay of half the period, then toggles it off and waits for another half period. A counter increments with each loop iteration, and when it reaches 200, it resets and updates the toggling period between 2000 microseconds (500Hz) and 1600 microseconds (625Hz). While toggling the output in a loop is the simplest method for controlling the buzzer, it limits the main program's multitasking capabilities. To overcome this, a hardware timer can be employed for square wave generation. A hardware timer is a counter that increments continuously with the CPU clock, allowing actions to be triggered when the counter hits a predefined value. This method is efficient for measuring time intervals or generating signals through software interrupts or hardware pin toggling. Timer1 from the ATMEGA168 will be utilized in CTC (Clear Timer on Compare) mode to generate a square wave. The 16-bit resolution of Timer1 provides high precision for frequency selection. The timer is configured to toggle the OC1A/PB1 pin upon reaching the OCR1A value. By adjusting the OCR1A value, the period of the OC1A signal can be controlled. The expected behavior is illustrated in the schema diagram from the ATMEGA168 datasheet. A clk/8 prescaler is selected to achieve a 2MHz counter from the 16MHz main clock, resulting in a counter increment every 0.5 microseconds. When the counter reaches OCR1A, the OC1A pin toggles, and the counter resets to zero. The output frequency can be calculated using the formula: Fo = Fclk / (2 * N * (1 + OCR1A)), where N=8 is the prescaling factor and Fclk is 16MHz. To produce a 400Hz square wave, OCR1A is set to 2499, corresponding to a signal period of 2500 microseconds. In the main loop, the counter TOP value is updated to the current period, with a 1-second delay. The period is toggled between 2499 (400Hz) and 4999 (200Hz) accordingly.
The circuit design employs a 2N3904 NPN transistor configured as a switch to drive the buzzer, ensuring proper voltage and current levels are maintained. The diode connected in parallel with the buzzer acts as a flyback diode, preventing voltage spikes that can occur when the inductive load is turned off, thus protecting the transistor from potential damage. The ATMEGA168 microcontroller interfaces with the transistor through the OC1A pin, which is configured to output a PWM signal to control the buzzer's operation.
The Timer1 configuration involves setting the Control Register (TCCR1A) to define the mode of operation. In CTC mode, setting the WGM bits accordingly allows the timer to reset upon reaching the value specified in OCR1A. The prescaler is set in the TCCR1B register to achieve the desired clock speed for the timer. The initialization of Timer1 must ensure that the timer starts from a known state, and the output pin (PB1) should be configured as an output by setting the corresponding bit in the Data Direction Register (DDRB).
The main loop continuously updates the OCR1A register based on the desired frequency, allowing for dynamic adjustment of the buzzer's sound output. This approach not only conserves CPU resources but also allows the microcontroller to handle other tasks simultaneously, enhancing the overall functionality of the application.To connect it to the ATMEGA168, I followed the suggestion from the datasheet: the buzzer if driven by a 2N3904 NPN transistor and a diode protects the transistor from reverse currents from the magnetic inductance. /* Setup PB1 as an output */ DDRB = _BV(PB1); /* Initial period */ period = 1600; /* Main loop */ for(;) { PORTB |= _BV(DDB1); delay
_us(period / 2); PORTB &= ~_BV(DDB1); delay_us(period / 2); counter+; if (counter = 200) { /* Reset the counter */ counter = 0; /* Update the toggling period */ if (period = 1600) period = 2000; else period = 1600; } } The period variable contains the period in us of the generated square wave. The counter toggles the period from 2000us (500Hz) to 1600us (625Hz) every 200 periods. Toggling an output in a loop is the easiest way to control the buzzer but it doesn`t allow the main program to do much else at the same time.
To achieve this you can delegate the square wave generation to a hardware timer. An hardware timer is a counter that is constantly incremented by the CPU clock. Actions can be triggered when the counter reaches a predefined value. It is useful to measure time intervals or generate signals either for the software with an interrupt or for the hardware by toggling a pin. To generate a square wave I will use timer1 from the ATMEGA168 in CTC mode (Clear Timer on Compare). The 16-bit resolution of timer1 offers the greatest precision for selecting an output frequency. The timer is setup to toggle the OC1A/PB1 pin when it reaches the OCR1A value. By changing the OCR1A value, I can control the period of the OC1A signal. The following schema diagram excerpted from the ATMEGA168 datasheet illustrate the expected behavior: I choose a clk/8 prescaler to obtain a 2MHz counter from my 16MHz main clock.
So each 0. 5us the counter value is increased. When it reaches OCR1A, OC1A is toggled and the counter value is reset to 0. The output frequency is computed from the following formula: Fo = Fclk / (2. N. (1+OCR1A), where N=8 is the clock prescaling factor and Fclk is 16MHz. To output a 400Hz square wave: OCR1A = 2500 1 = 2499, where 2500 is the period of the signal in µs. /* Initial period */ period = (2500 - 1); /* Main loop */ for(;) { // Update the counter TOP value OCR1A = period; delay_ms(1000); /* Update the period */ if (period = (2500 - 1) period = 5000 - 1; // 200 Hz else period = 2500 - 1; // 400 Hz }
The circuit design employs a 2N3904 NPN transistor configured as a switch to drive the buzzer, ensuring proper voltage and current levels are maintained. The diode connected in parallel with the buzzer acts as a flyback diode, preventing voltage spikes that can occur when the inductive load is turned off, thus protecting the transistor from potential damage. The ATMEGA168 microcontroller interfaces with the transistor through the OC1A pin, which is configured to output a PWM signal to control the buzzer's operation.
The Timer1 configuration involves setting the Control Register (TCCR1A) to define the mode of operation. In CTC mode, setting the WGM bits accordingly allows the timer to reset upon reaching the value specified in OCR1A. The prescaler is set in the TCCR1B register to achieve the desired clock speed for the timer. The initialization of Timer1 must ensure that the timer starts from a known state, and the output pin (PB1) should be configured as an output by setting the corresponding bit in the Data Direction Register (DDRB).
The main loop continuously updates the OCR1A register based on the desired frequency, allowing for dynamic adjustment of the buzzer's sound output. This approach not only conserves CPU resources but also allows the microcontroller to handle other tasks simultaneously, enhancing the overall functionality of the application.To connect it to the ATMEGA168, I followed the suggestion from the datasheet: the buzzer if driven by a 2N3904 NPN transistor and a diode protects the transistor from reverse currents from the magnetic inductance. /* Setup PB1 as an output */ DDRB = _BV(PB1); /* Initial period */ period = 1600; /* Main loop */ for(;) { PORTB |= _BV(DDB1); delay
_us(period / 2); PORTB &= ~_BV(DDB1); delay_us(period / 2); counter+; if (counter = 200) { /* Reset the counter */ counter = 0; /* Update the toggling period */ if (period = 1600) period = 2000; else period = 1600; } } The period variable contains the period in us of the generated square wave. The counter toggles the period from 2000us (500Hz) to 1600us (625Hz) every 200 periods. Toggling an output in a loop is the easiest way to control the buzzer but it doesn`t allow the main program to do much else at the same time.
To achieve this you can delegate the square wave generation to a hardware timer. An hardware timer is a counter that is constantly incremented by the CPU clock. Actions can be triggered when the counter reaches a predefined value. It is useful to measure time intervals or generate signals either for the software with an interrupt or for the hardware by toggling a pin. To generate a square wave I will use timer1 from the ATMEGA168 in CTC mode (Clear Timer on Compare). The 16-bit resolution of timer1 offers the greatest precision for selecting an output frequency. The timer is setup to toggle the OC1A/PB1 pin when it reaches the OCR1A value. By changing the OCR1A value, I can control the period of the OC1A signal. The following schema diagram excerpted from the ATMEGA168 datasheet illustrate the expected behavior: I choose a clk/8 prescaler to obtain a 2MHz counter from my 16MHz main clock.
So each 0. 5us the counter value is increased. When it reaches OCR1A, OC1A is toggled and the counter value is reset to 0. The output frequency is computed from the following formula: Fo = Fclk / (2. N. (1+OCR1A), where N=8 is the clock prescaling factor and Fclk is 16MHz. To output a 400Hz square wave: OCR1A = 2500 1 = 2499, where 2500 is the period of the signal in µs. /* Initial period */ period = (2500 - 1); /* Main loop */ for(;) { // Update the counter TOP value OCR1A = period; delay_ms(1000); /* Update the period */ if (period = (2500 - 1) period = 5000 - 1; // 200 Hz else period = 2500 - 1; // 400 Hz }
Vehicle Detector
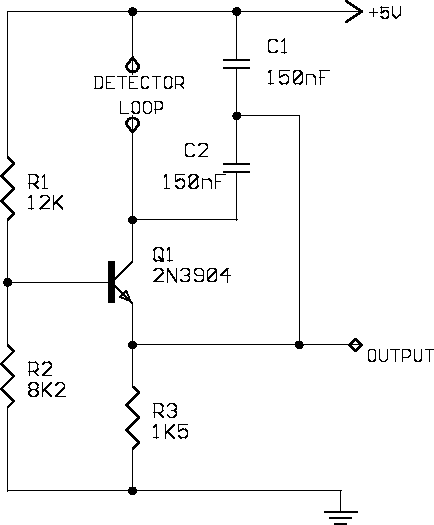
A simple single-transistor Colpitts oscillator is depicted in the schematic. When a vehicle passes over the loop, the inductance decreases, resulting in an increase in the oscillator frequency. A microprocessor measures the oscillator frequency and takes appropriate actions based on...
Low Resource Microcontroller 3 Phase BLDC Motor Speed Controller
This article discusses a minimal resource microcontroller implementation for a three-phase Brushless DC (BLDC) motor, focusing on a closed-loop speed motor controller application based on a Microchip PIC12 device. It demonstrates how minimization techniques can reduce the number of I/O...
Transistor Geiger Counter
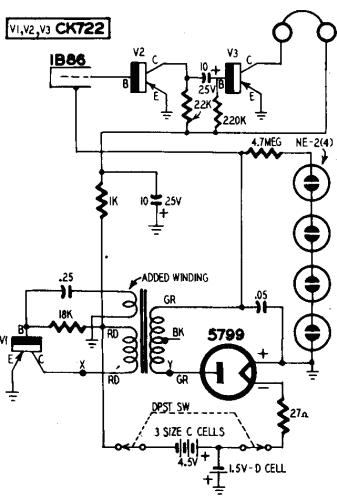
One of the most unfortunate features of the typical portable Geiger counter is the short lifespan of the costly high-voltage batteries.
The limitation of high-voltage battery life in portable Geiger counters significantly affects their usability and operational efficiency. These devices are...
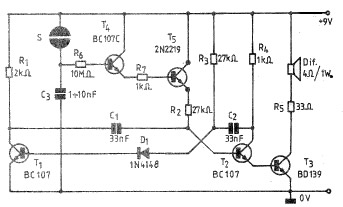
Simple Electronic bell circuit using transistors
A simple and practical electronic bell circuit can be constructed using the provided schematic diagram. This circuit can function as a doorbell or an alarm system. It utilizes only a few transistors along with several common components. The circuit is...
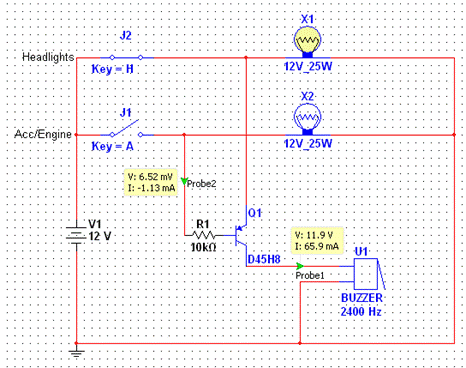
Headlight Alarm Circuit
The most extreme option would be to supply power through a battery pack. A more plausible source would be the car's battery. However, since the objective of the circuit is to activate the buzzer when the headlights are on, it...
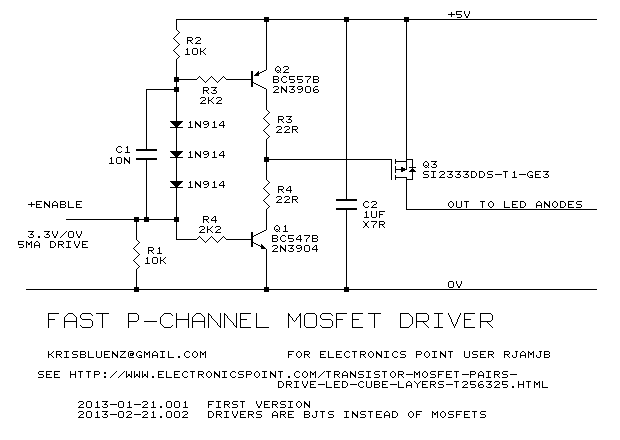
Transistor Mosfet pairs to drive LED cube layers
None of those devices is very suitable. The drivers aren't specified to operate with 3.3V gate signals, and although the typical graph shows that a...
The devices referenced in the original input are not appropriate for the intended application due to...
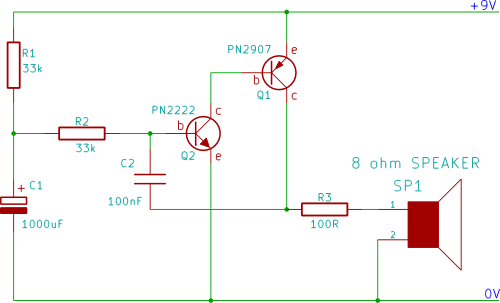
rising pitch siren
A two-transistor electronic siren breadboard circuit that produces an audible rising pitch on a loudspeaker. This circuit serves as a tutorial for beginners in electronics.
The two-transistor siren circuit operates by utilizing the properties of transistors to create an oscillating signal...
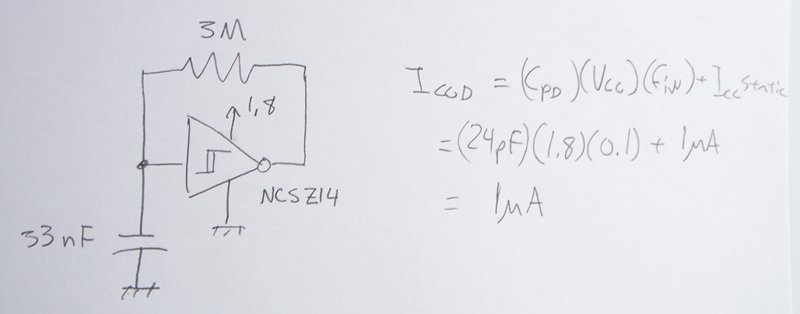
transistors Low power low voltage slow (0.1Hz) oscillator
The power supply varies, and the circuit must operate at under 10 µA of current (excluding the capacitor charging). It triggers a Silicon Controlled Rectifier (SCR) every 10 to 30 seconds as long as the power supply is above 1.8...
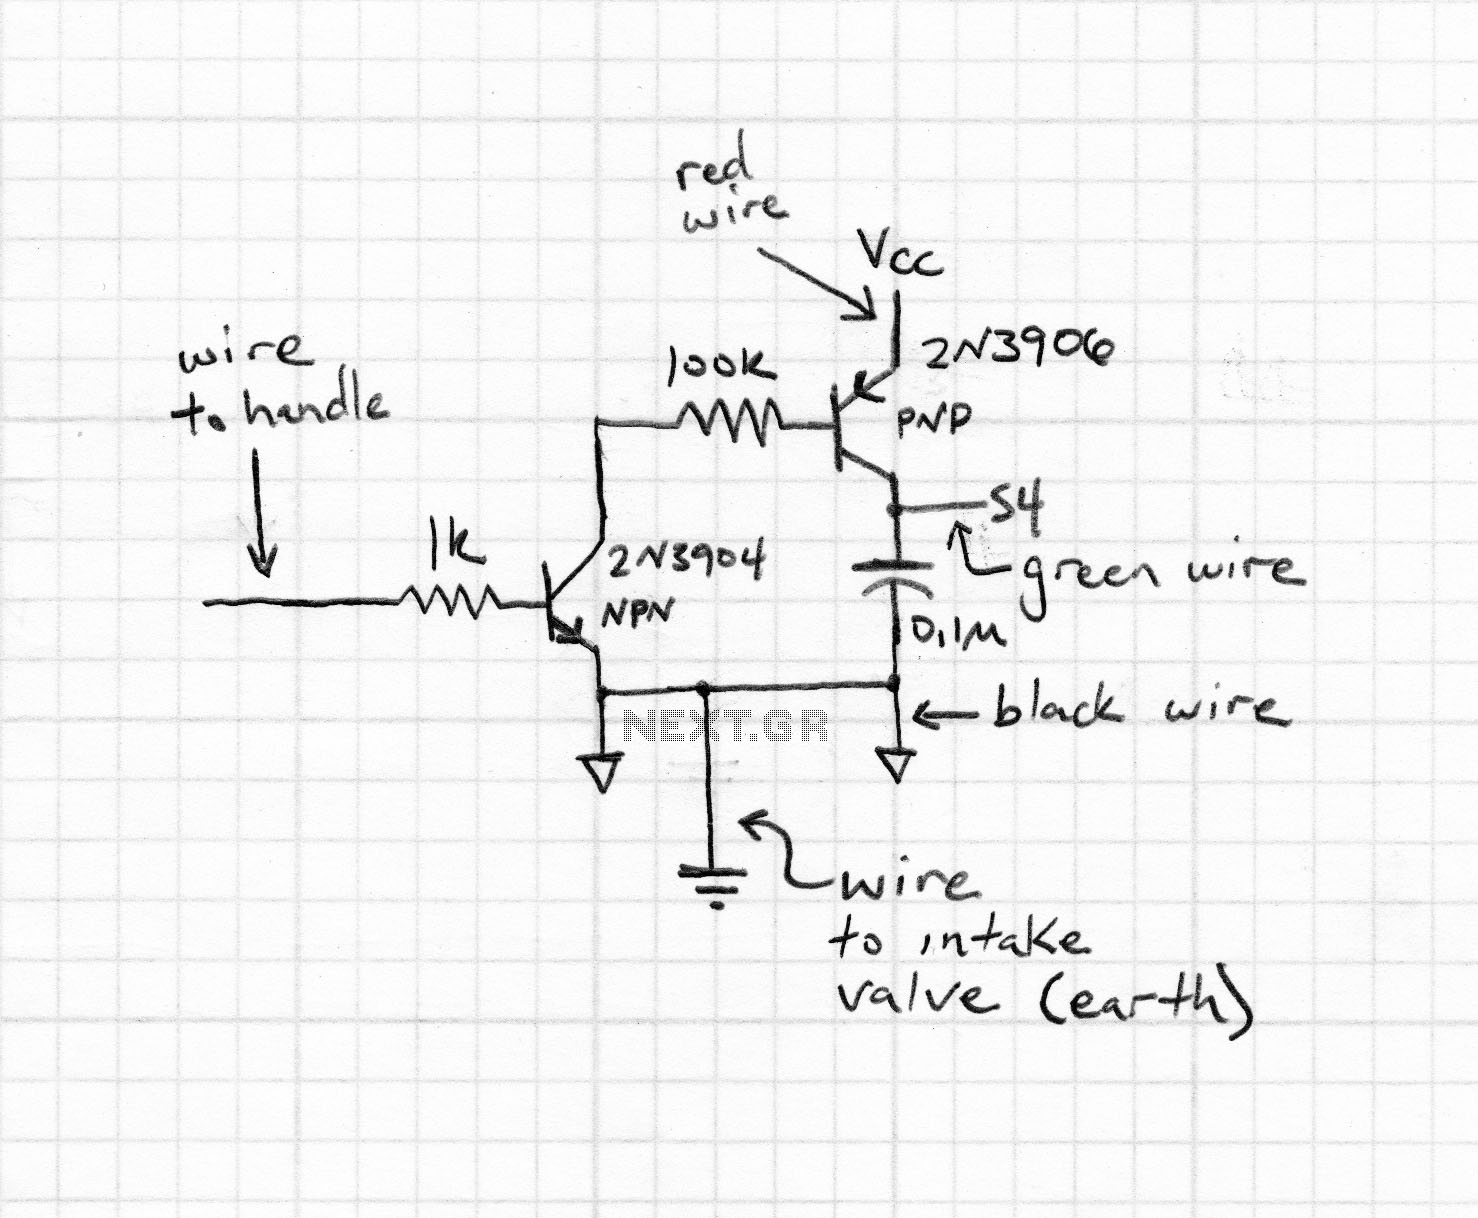
Password(code) Based Digital Locking System Using Microcontroller 89C52/89S52
Upon entering the password, the application, in this case "LED," will illuminate. In this digital locking system project, the interfacing of a keypad and a 16x2 LCD with a microcontroller will be explored, along with the accompanying code. This project...