


Vehicle Detector
#transistor
#oscillator
#vehicle detection
#inductance
#frequency measurement
#microprocessor
#Colpitts oscillator
#automotive
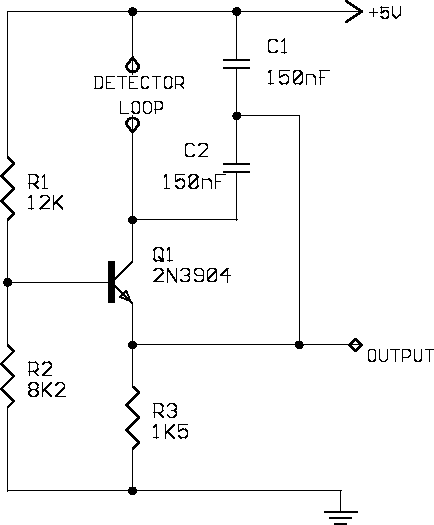
Description: A simple single-transistor Colpitts oscillator is depicted in the schematic. When a vehicle passes over the loop, the inductance decreases, resulting in an increase in the oscillator frequency. A microprocessor measures the oscillator frequency and takes appropriate actions based on changes in this value. In this setup, the microprocessor activates a light-emitting diode when a vehicle is detected. The signal conditioning block starts with a unity-gain buffer to prevent excessive loading of the oscillator output by the signal conditioning input. A comparator is employed to convert the signal to TTL levels. A low-pass filter on the comparator reference input allows tracking of slow drifts in the oscillator output. Resistors connected to the comparator input provide hysteresis to prevent noise from causing erratic comparator operation. The 2N3904 oscillator should be constructed, and its output signal measured using an oscilloscope. It is important to keep the leads between the detector loop and the oscillator as short as possible. The signal conditioning circuit must be constructed and verified to produce a stable TTL level signal when connected to the oscillator. Both the TLC2272 and the LM393 operate with a single +5V supply, and decoupling capacitors should be placed close to the device power supply pins. A program for the 87C51 microcontroller should be written to count the number of oscillator cycles in approximately a 10 ms period. The first value obtained will serve as the baseline, with the 'vehicle present' flag set to false. This approach accommodates scenarios where the oscillator frequency drifts lower or when a vehicle parked near the loop moves away. Using code developed in a previous lab, the number of vehicles detected since power-up should be displayed on an LCD screen, converting leading zeros to blanks to ensure the initial display shows 0 instead of 0000.
A single-transistor Colpitts oscillator is a simple yet effective circuit for generating oscillations based on the principle of a tank circuit comprising an inductor and capacitors. In this design, the oscillator's frequency is inversely related to the inductance of the loop, which is influenced by the presence of a vehicle. As vehicles approach or pass over the loop, the inductance decreases, causing the frequency to increase, which can be detected by the microprocessor.
The microprocessor plays a crucial role in monitoring the oscillator frequency and responding to changes by activating a light-emitting diode (LED) to indicate vehicle detection. The signal conditioning block is essential for ensuring that the output from the oscillator is suitable for digital processing. The inclusion of a unity-gain buffer prevents loading effects that could distort the oscillator's output signal.
Following the buffer, a comparator is utilized to convert the analog signal from the oscillator to a digital signal compatible with TTL logic levels. This conversion is critical for reliable digital processing. To maintain stability in the presence of noise, hysteresis is implemented through resistors at the comparator input, ensuring that minor fluctuations do not lead to false triggering of the comparator.
The design also incorporates a low-pass filter on the reference input of the comparator, allowing it to adapt to slow changes in the oscillator output, which is important for maintaining accuracy in frequency measurement.
The construction of the 2N3904 oscillator requires careful attention to lead lengths between the detector loop and the oscillator to minimize inductive effects that could alter performance. Once assembled, the output signal should be measured with an oscilloscope to verify correct operation.
For the signal conditioning circuit, both the TLC2272 and LM393 are suitable components operating on a single +5V supply. Proper decoupling capacitors should be placed near the power supply pins of these devices to ensure stable operation and minimize noise.
The programming aspect involves utilizing the capabilities of the 87C51 microcontroller to count oscillator cycles over a specified time frame (approximately 10 ms). This count will establish a baseline for subsequent measurements. The vehicle detection logic incorporates a flag mechanism to handle frequency drift scenarios effectively. The LCD display should be formatted to show the count of detected vehicles, with leading zeros replaced by blanks to enhance readability, ensuring that the display initially shows 0 instead of 0000.
This comprehensive approach combines electronic design with programming to create a reliable vehicle detection system based on frequency measurement from a Colpitts oscillator.A simple single-transistor Colpitts oscillator whose schematic is shown in figure 2. When a vehicle passes over the loop the inductance decreases and the oscillator frequency increases. A microprocessor which measures the oscillator frequency and takes appropriate action on changes in this value. In this lab, the microprocessor should activate a light-emitting diode when a vehicle is detected. The signal conditioning block, shown in figure 3, begins with a unity-gain buffer to ensure that the oscillator output is not excessively loaded by the signal conditioning input. A comparator is then used to convert the signal to TTL levels. The low-pass filter on the comparator reference input allows the reference to track slow drifts in the output of the oscillator.
The resistors connected to the comparator input provide hysteresis to ensure that small amounts of noise on the oscillator output do not cause erratic operation of the comparator. Construct the 2N3904 oscillator and use an oscilloscope to measure its output signal. Keep the leads between the detector loop and the oscillator as short as reasonably possible. Construct the signal conditioning circuit and verify that it produces a stable, TTL level signal when connected to the oscillator.
Both the TLC2272 and the LM393 operate with a single +5V supply. Remember to use decoupling capacitors close as possible to the device power supply pins. Write a program for the 87C51 which counts the number of oscillator cycles in a 10msec (approx) period (Hint - the 87C51 has hardware which can make this quite simple). The first value obtained should be used as the baseline ( and the `vehicle present` flag should be set to false.
This handles the case where the oscillator frequency drifts lower or when a vehicle which was parked near the loop moves away. Using the code developed in lab 3, display on the LCD screen the number (0 to 9999) of vehicles that have been detected since power-up.
Convert leading zeros to blanks so that the initial display is 0, not 0000.
A single-transistor Colpitts oscillator is a simple yet effective circuit for generating oscillations based on the principle of a tank circuit comprising an inductor and capacitors. In this design, the oscillator's frequency is inversely related to the inductance of the loop, which is influenced by the presence of a vehicle. As vehicles approach or pass over the loop, the inductance decreases, causing the frequency to increase, which can be detected by the microprocessor.
The microprocessor plays a crucial role in monitoring the oscillator frequency and responding to changes by activating a light-emitting diode (LED) to indicate vehicle detection. The signal conditioning block is essential for ensuring that the output from the oscillator is suitable for digital processing. The inclusion of a unity-gain buffer prevents loading effects that could distort the oscillator's output signal.
Following the buffer, a comparator is utilized to convert the analog signal from the oscillator to a digital signal compatible with TTL logic levels. This conversion is critical for reliable digital processing. To maintain stability in the presence of noise, hysteresis is implemented through resistors at the comparator input, ensuring that minor fluctuations do not lead to false triggering of the comparator.
The design also incorporates a low-pass filter on the reference input of the comparator, allowing it to adapt to slow changes in the oscillator output, which is important for maintaining accuracy in frequency measurement.
The construction of the 2N3904 oscillator requires careful attention to lead lengths between the detector loop and the oscillator to minimize inductive effects that could alter performance. Once assembled, the output signal should be measured with an oscilloscope to verify correct operation.
For the signal conditioning circuit, both the TLC2272 and LM393 are suitable components operating on a single +5V supply. Proper decoupling capacitors should be placed near the power supply pins of these devices to ensure stable operation and minimize noise.
The programming aspect involves utilizing the capabilities of the 87C51 microcontroller to count oscillator cycles over a specified time frame (approximately 10 ms). This count will establish a baseline for subsequent measurements. The vehicle detection logic incorporates a flag mechanism to handle frequency drift scenarios effectively. The LCD display should be formatted to show the count of detected vehicles, with leading zeros replaced by blanks to enhance readability, ensuring that the display initially shows 0 instead of 0000.
This comprehensive approach combines electronic design with programming to create a reliable vehicle detection system based on frequency measurement from a Colpitts oscillator.A simple single-transistor Colpitts oscillator whose schematic is shown in figure 2. When a vehicle passes over the loop the inductance decreases and the oscillator frequency increases. A microprocessor which measures the oscillator frequency and takes appropriate action on changes in this value. In this lab, the microprocessor should activate a light-emitting diode when a vehicle is detected. The signal conditioning block, shown in figure 3, begins with a unity-gain buffer to ensure that the oscillator output is not excessively loaded by the signal conditioning input. A comparator is then used to convert the signal to TTL levels. The low-pass filter on the comparator reference input allows the reference to track slow drifts in the output of the oscillator.
The resistors connected to the comparator input provide hysteresis to ensure that small amounts of noise on the oscillator output do not cause erratic operation of the comparator. Construct the 2N3904 oscillator and use an oscilloscope to measure its output signal. Keep the leads between the detector loop and the oscillator as short as reasonably possible. Construct the signal conditioning circuit and verify that it produces a stable, TTL level signal when connected to the oscillator.
Both the TLC2272 and the LM393 operate with a single +5V supply. Remember to use decoupling capacitors close as possible to the device power supply pins. Write a program for the 87C51 which counts the number of oscillator cycles in a 10msec (approx) period (Hint - the 87C51 has hardware which can make this quite simple). The first value obtained should be used as the baseline ( and the `vehicle present` flag should be set to false.
This handles the case where the oscillator frequency drifts lower or when a vehicle which was parked near the loop moves away. Using the code developed in lab 3, display on the LCD screen the number (0 to 9999) of vehicles that have been detected since power-up.
Convert leading zeros to blanks so that the initial display is 0, not 0000.
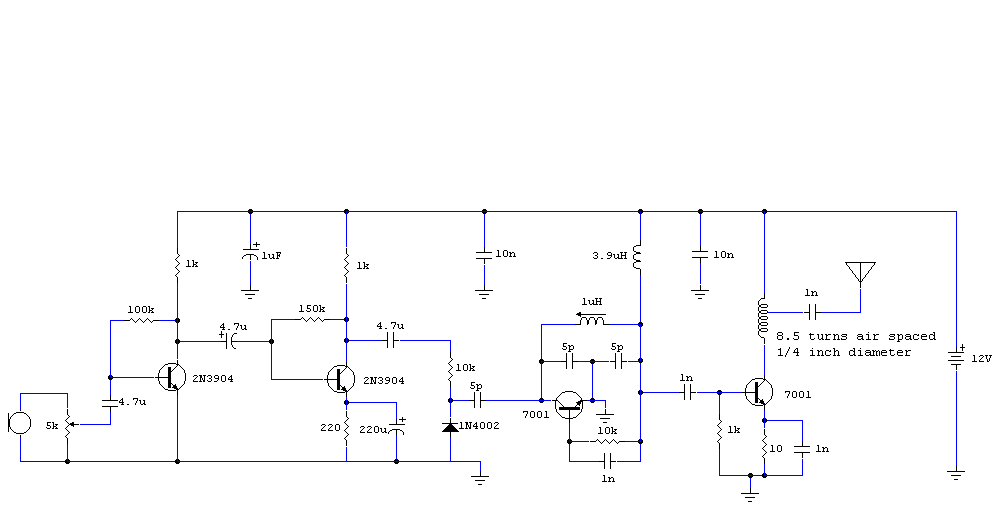
4 transistor 500mw fm transmitter
The audio circuit described is a microphone utilizing two 2N3904 transistors as the audio preamplifier. The audio/microphone gain is adjustable via a 5k preset potentiometer. The circuit employs a Colpitts oscillator for frequency generation, which is free-running and operates at...
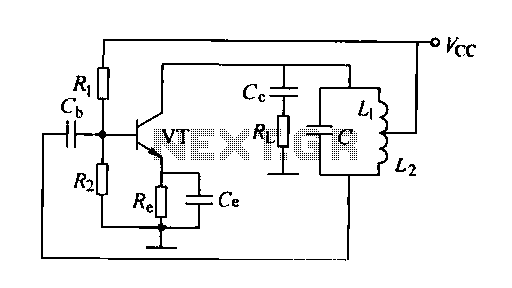
Inductance feedback oscillator circuit
A feedback oscillator circuit utilizing inductance is presented, featuring the 3DG3 transistor. The component parameters reference values include: 1) transistors 3DG6, 2) resistances R1 at 91 kΩ, R2 at 11 kΩ, and R3 unspecified, 3) capacitance values of C at...

Bedini SSG
The transistor activates, causing the magnet to move away. When the transistor deactivates, the energy stored in the coil collapses, directing its flow into the charging battery. As the next magnet approaches, the cycle repeats. This process effectively recaptures energy...
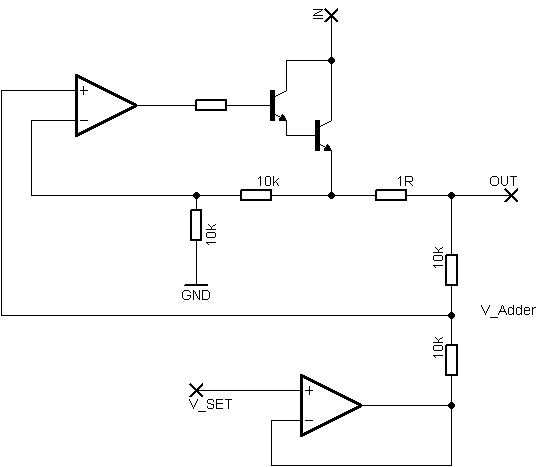
power supply Transistor current limiter microcontroller controlled
Rsense will cause Q2 to conduct when a threshold of approximately 0.65V is reached. Rbias will determine the extent of this limitation, although this aspect remains unclear. Particularly, if Rsense is positioned on the high side, simply activating Q2 with...
stable low frequency crystal
This is a design circuit for a Colpitts crystal oscillator. It is suitable for low-frequency crystal oscillator applications. Utilizing the 2N3823 JFET, this circuit exhibits excellent stability as temperature variations do not affect the loading of the 2N3823 JFET circuit.
The...
Transistorized flashers
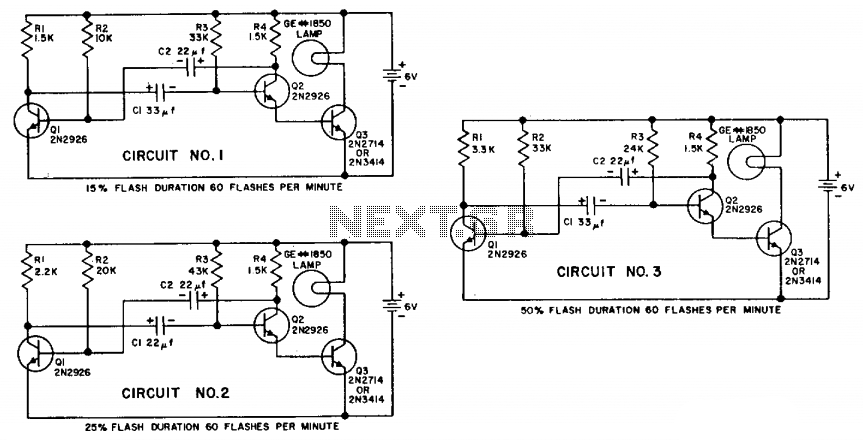
Transistors Q1 and Q2 are configured as a free-running multivibrator. The output at the emitter of Q2 drives the base of the common emitter amplifier Q3, which controls the lamp. This circuit configuration allows for independent variation of flash duration,...
Digitally controlled threshold detector
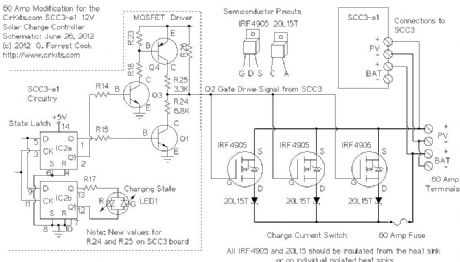
This circuit utilizes small switching transistors, with a maximum motor drive current limited to approximately 250 mA at 5V. Testing has been conducted across a voltage range from 3V to 21V, and with certain component modifications, it may be applicable...
Camshaft Position Sensor
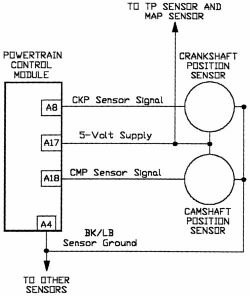
AutoZone Repair Guide for Engine Performance and Emission Control Components and Systems, specifically focusing on the Camshaft Position Sensor.
The Camshaft Position Sensor (CMP) is a critical component in modern internal combustion engines, playing a vital role in the management of...
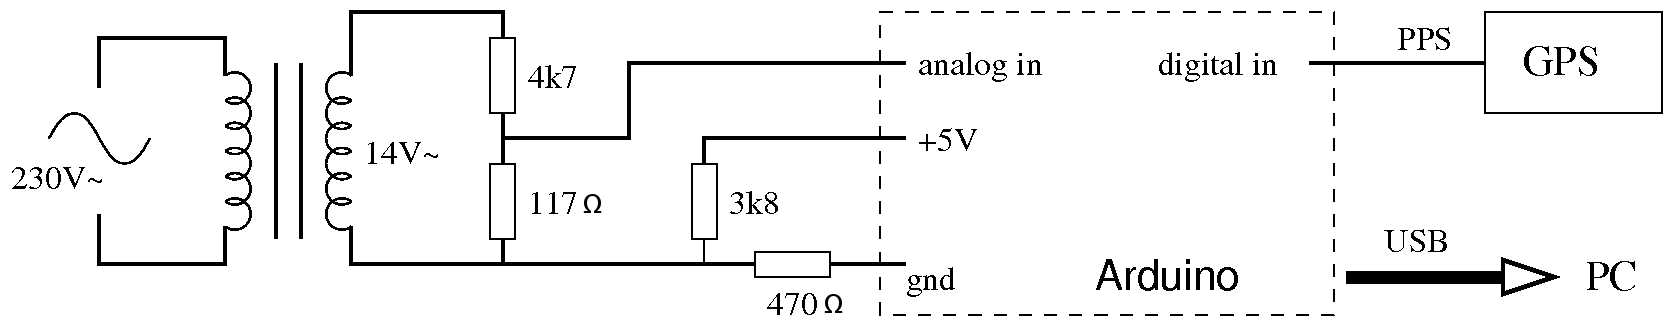
grid frequency
Wall sockets provide power in the form of a 230-volt sine wave, operating at a frequency of 50 hertz. This means that the voltage alternates between positive and negative at a rate of 50 full cycles per second. Different countries...