


Controlling of Stepper Motor rotation in both direction using 8051 Microcontroller
#8051
#stepper motor
#motor control
#rotation control
#microcontroller
#electromagnets
#stator
#rotor
#bidirectional
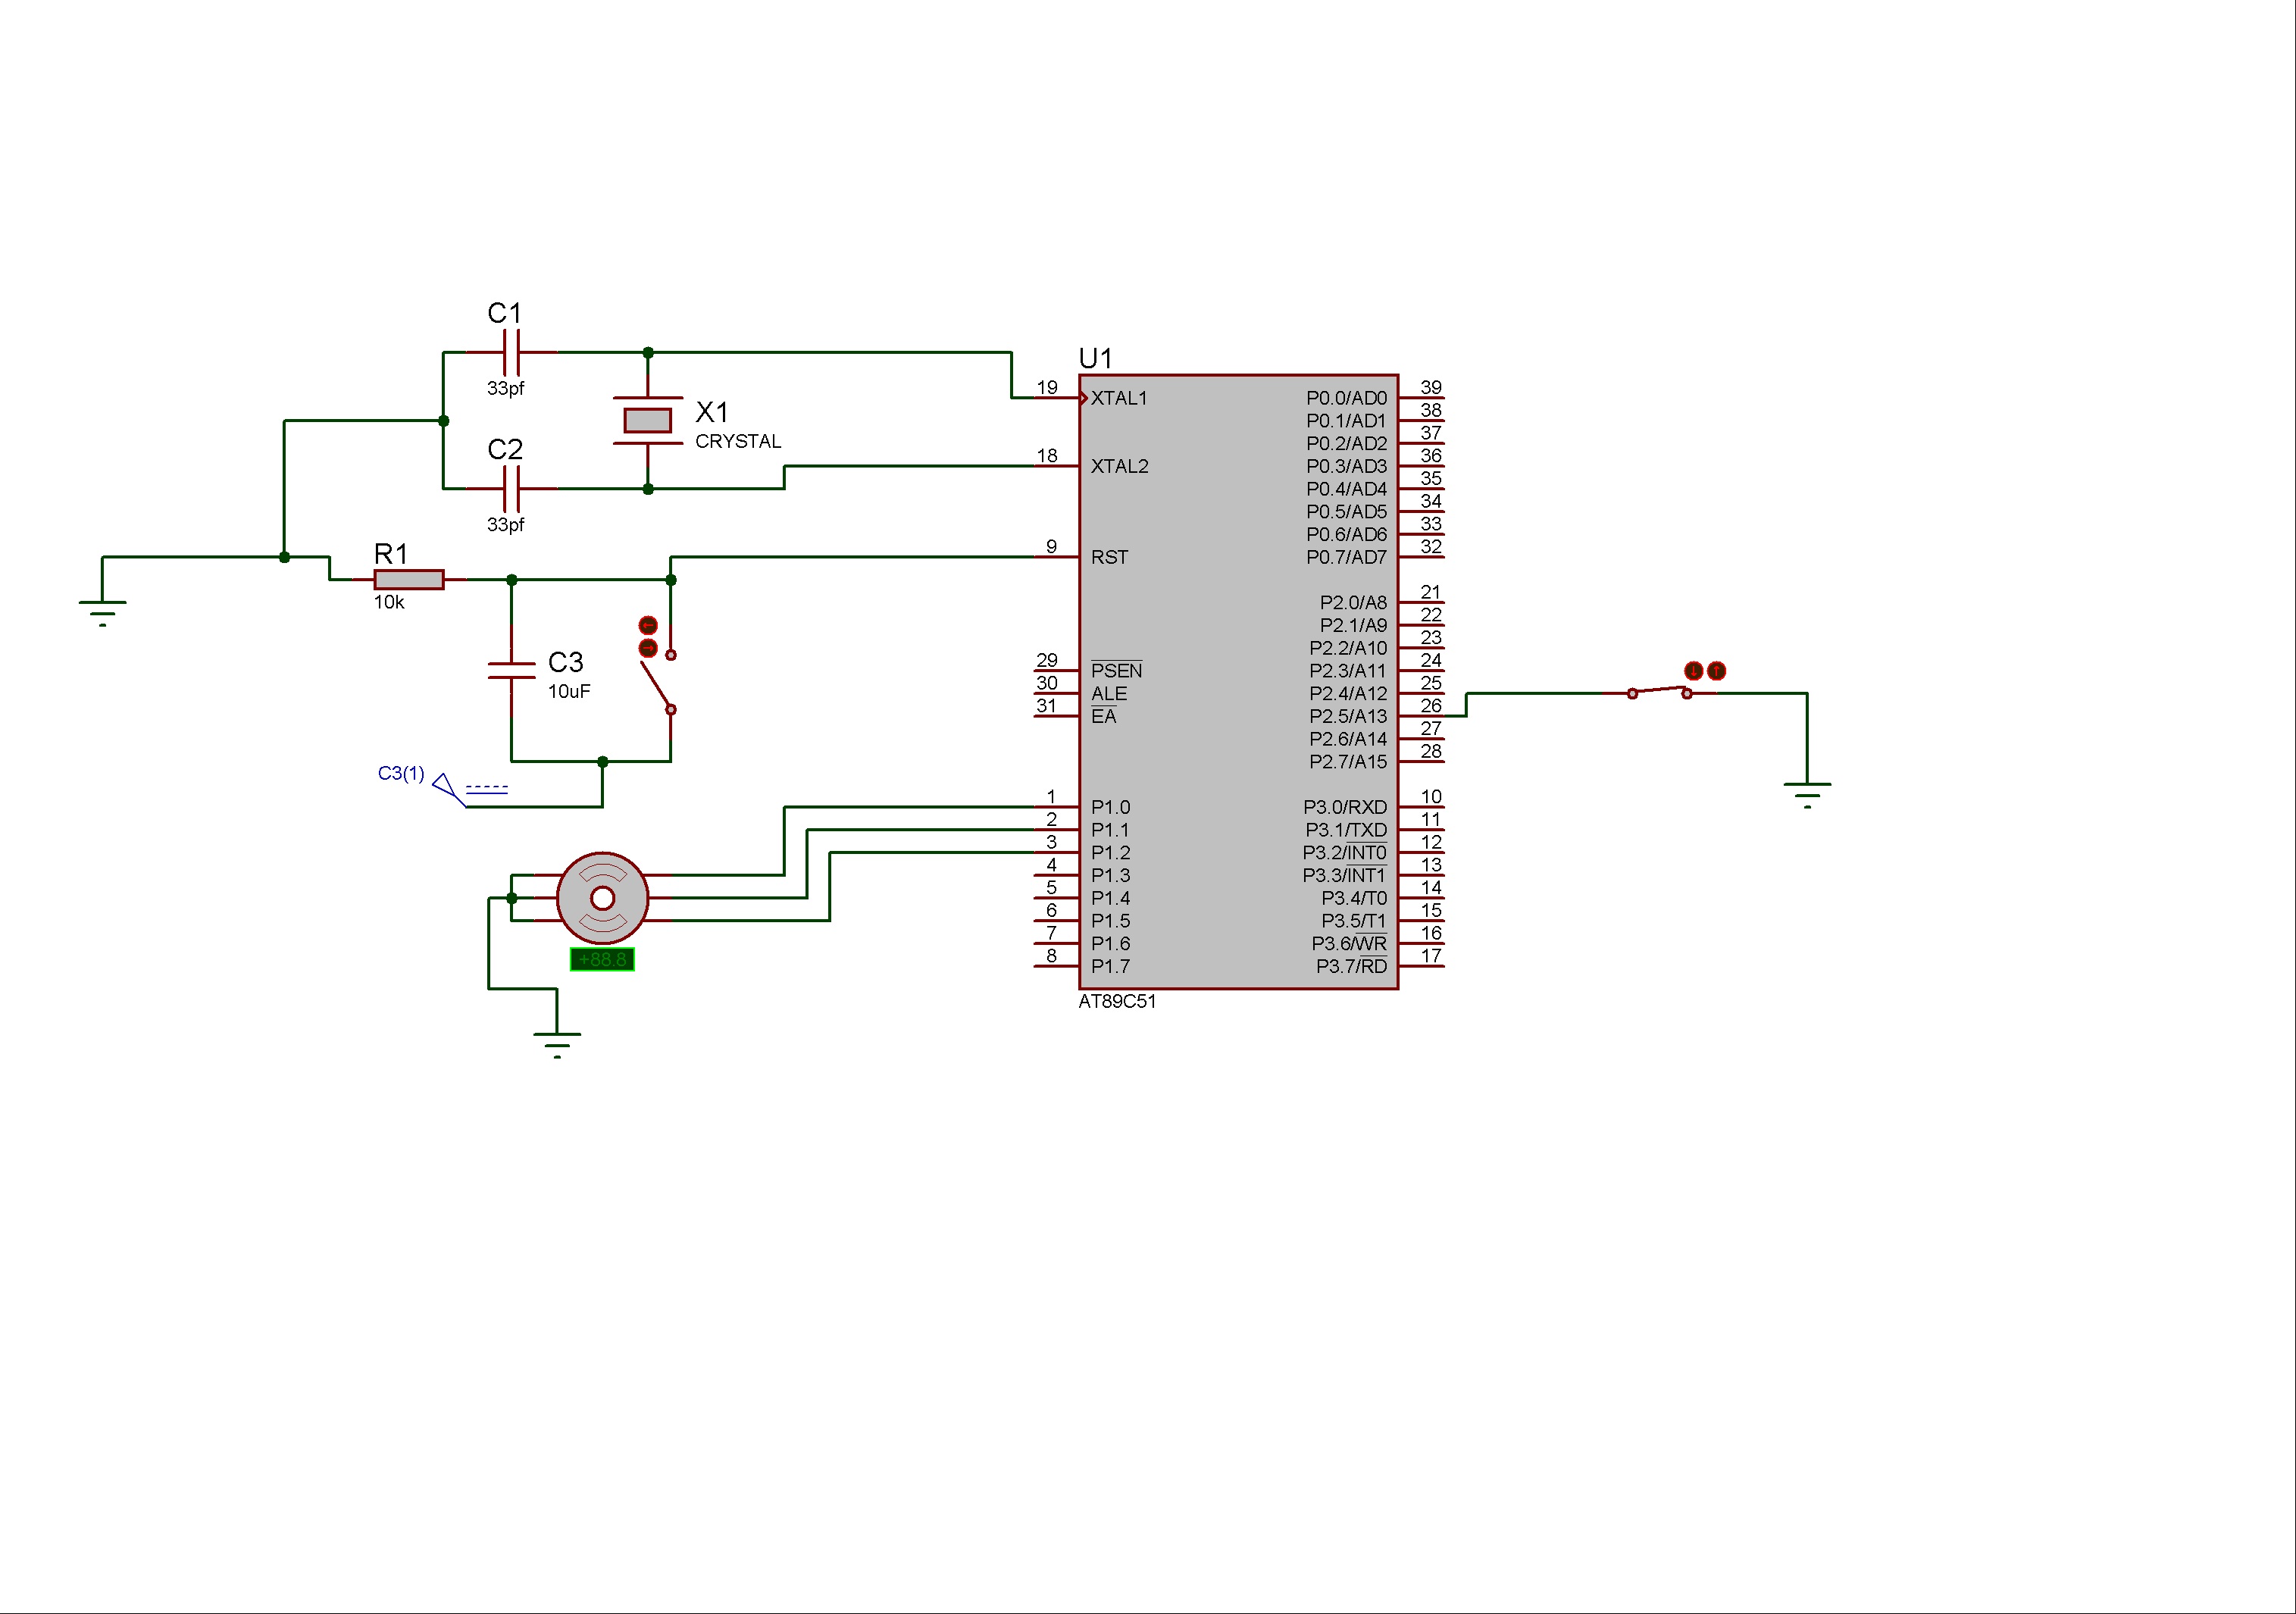
Description: Stepper motors consist of a permanent magnet rotating shaft, known as the rotor, and electromagnets on the stationary part that surrounds the motor, referred to as the stator. One complete rotation of a stepper motor is illustrated. At position 1, the rotor begins at the upper electromagnet, which is currently active and has voltage applied.
Stepper motors operate based on the principle of electromagnetic induction. The rotor, which is a permanent magnet, aligns itself with the magnetic field generated by the stator's electromagnets. The stator typically consists of multiple coils arranged in a specific sequence. When voltage is applied to these coils in a precise order, the magnetic field produced causes the rotor to step from one position to another, allowing for controlled movement.
The stepper motor's movement is characterized by discrete steps, which are defined by the number of poles in the rotor and the arrangement of the stator coils. The total number of steps per revolution can vary, with common configurations offering 200 steps per revolution (1.8 degrees per step) or 400 steps per revolution (0.9 degrees per step). This capability enables stepper motors to achieve high precision in positioning applications.
Control of a stepper motor is typically achieved through a driver circuit that sequences the voltage applied to the stator coils. The driver can be controlled using various methods, such as full-step, half-step, or microstepping techniques. Full-step operation energizes two coils at a time, while half-stepping alternates between energizing one and two coils, effectively doubling the resolution. Microstepping further divides each step into smaller increments, allowing for smoother motion and finer control.
In practical applications, stepper motors are widely used in robotics, CNC machinery, and 3D printers due to their ability to provide precise control of position and speed without the need for feedback systems. The simplicity of their control mechanisms and their robustness in various environments make them a popular choice for applications requiring accurate and repeatable motion.Stepper motors consist of a permanent magnet rotating shaft, called the rotor, and electromagnets on the stationary portion that surrounds the motor, called the stator. illustrates one complete rotation of a stepper motor. At position 1, we can see that the rotor is beginning at the upper electromagnet, which is currently active (has voltage applied.
Stepper motors operate based on the principle of electromagnetic induction. The rotor, which is a permanent magnet, aligns itself with the magnetic field generated by the stator's electromagnets. The stator typically consists of multiple coils arranged in a specific sequence. When voltage is applied to these coils in a precise order, the magnetic field produced causes the rotor to step from one position to another, allowing for controlled movement.
The stepper motor's movement is characterized by discrete steps, which are defined by the number of poles in the rotor and the arrangement of the stator coils. The total number of steps per revolution can vary, with common configurations offering 200 steps per revolution (1.8 degrees per step) or 400 steps per revolution (0.9 degrees per step). This capability enables stepper motors to achieve high precision in positioning applications.
Control of a stepper motor is typically achieved through a driver circuit that sequences the voltage applied to the stator coils. The driver can be controlled using various methods, such as full-step, half-step, or microstepping techniques. Full-step operation energizes two coils at a time, while half-stepping alternates between energizing one and two coils, effectively doubling the resolution. Microstepping further divides each step into smaller increments, allowing for smoother motion and finer control.
In practical applications, stepper motors are widely used in robotics, CNC machinery, and 3D printers due to their ability to provide precise control of position and speed without the need for feedback systems. The simplicity of their control mechanisms and their robustness in various environments make them a popular choice for applications requiring accurate and repeatable motion.Stepper motors consist of a permanent magnet rotating shaft, called the rotor, and electromagnets on the stationary portion that surrounds the motor, called the stator. illustrates one complete rotation of a stepper motor. At position 1, we can see that the rotor is beginning at the upper electromagnet, which is currently active (has voltage applied.
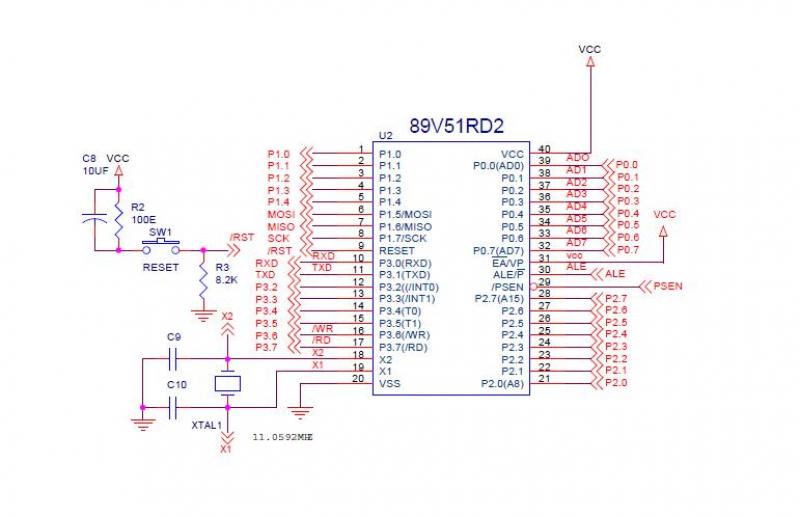
P89v51rd2 Interface With Adc Mcp3202
This interface session involves connecting the MCP3202 ADC with the 8051 microcontroller. The MCP3202 is a 12-bit SPI protocol ADC interfaced with the P89V51RD2 microcontroller, which supports SPI protocol, eliminating concerns about SDI, SDO, and SCK connections. The MCP3202 is...
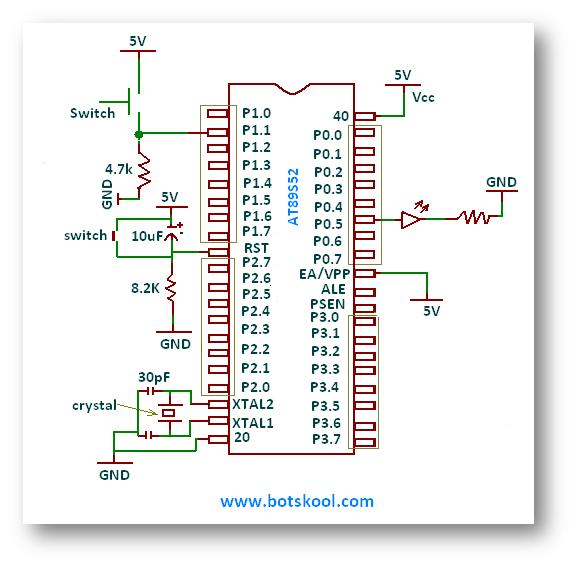
input output instructions 8051 assembly language
This tutorial continues the discussion on 8051 Assembly Programming by teaching input and output instructions for 8051 microcontrollers using assembly language. The microcontroller comprises a total of forty pins, most of which serve multiple functions. The primary function is input/output...
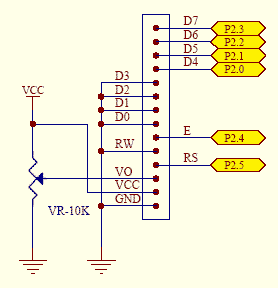
lcd interfacing
This document provides an example of how to interface with the standard Hitachi HD44780 LCD using an 8051 microcontroller and the SDCC C compiler. A standard 16-character by 2-line LCD module is utilized, as illustrated in the schematic below. The...
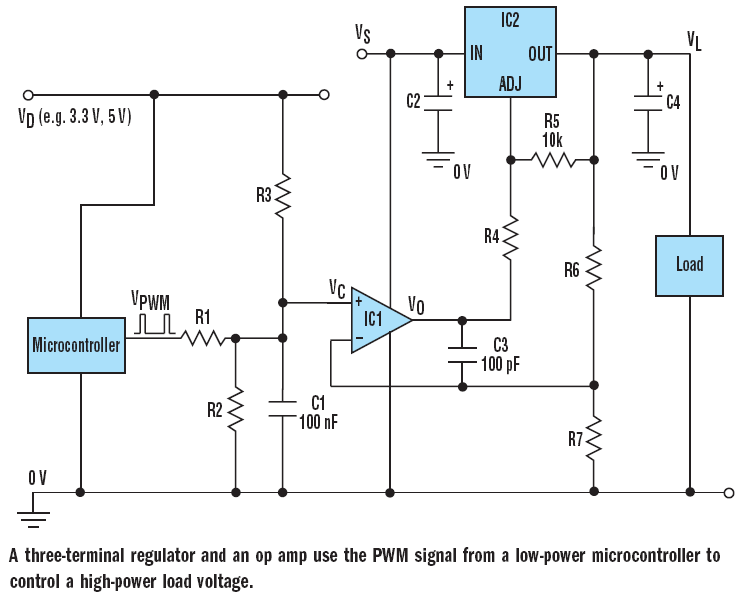
microcontroller How does this power supply circuit work? (MCU + LM317)
The filter consisting of resistors R1, R2, and capacitor C1 integrates the PWM waveform. The purpose of the operational amplifier appears to be that of a non-inverting amplifier, with the gain determined by resistors R6 and R7. However, the need...
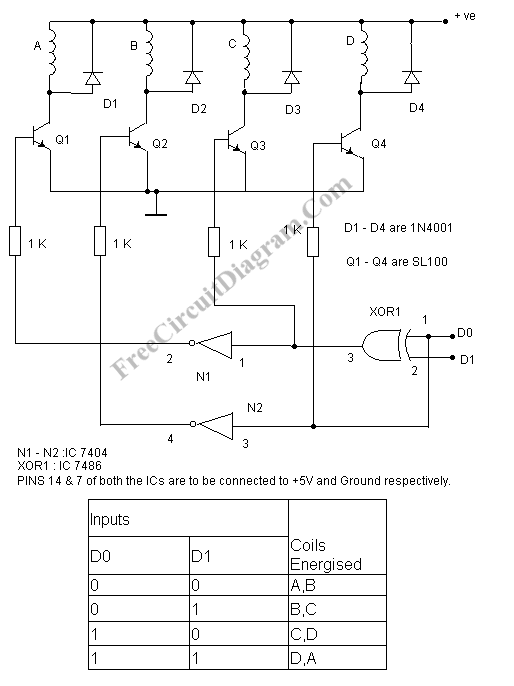
Simple Stepper Motor Controller
A stepper motor controller is required to operate a stepper motor, as a stepper motor cannot function merely by connecting it to a power supply.
A stepper motor controller is an essential component for the effective operation of stepper motors,...
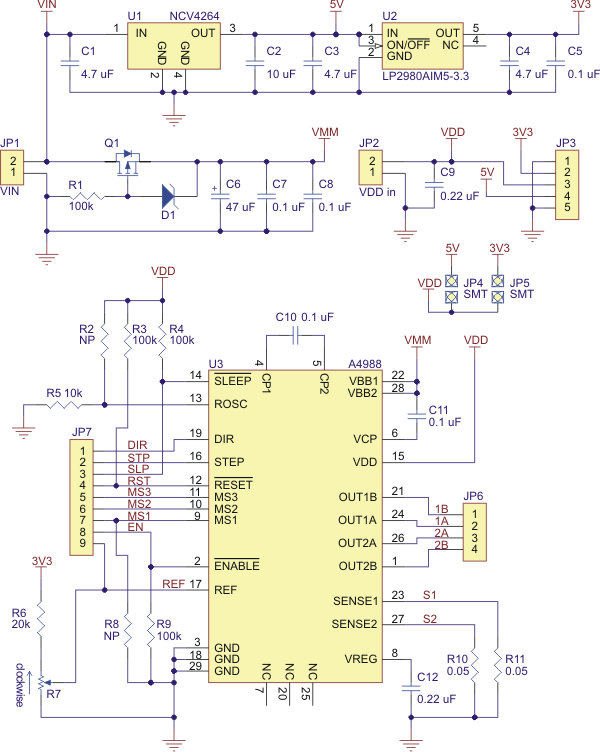
Stepper Motor Driver Carrier with Voltage Regulator
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...
Low Resource Microcontroller 3 Phase BLDC Motor Speed Controller
This article discusses a minimal resource microcontroller implementation for a three-phase Brushless DC (BLDC) motor, focusing on a closed-loop speed motor controller application based on a Microchip PIC12 device. It demonstrates how minimization techniques can reduce the number of I/O...
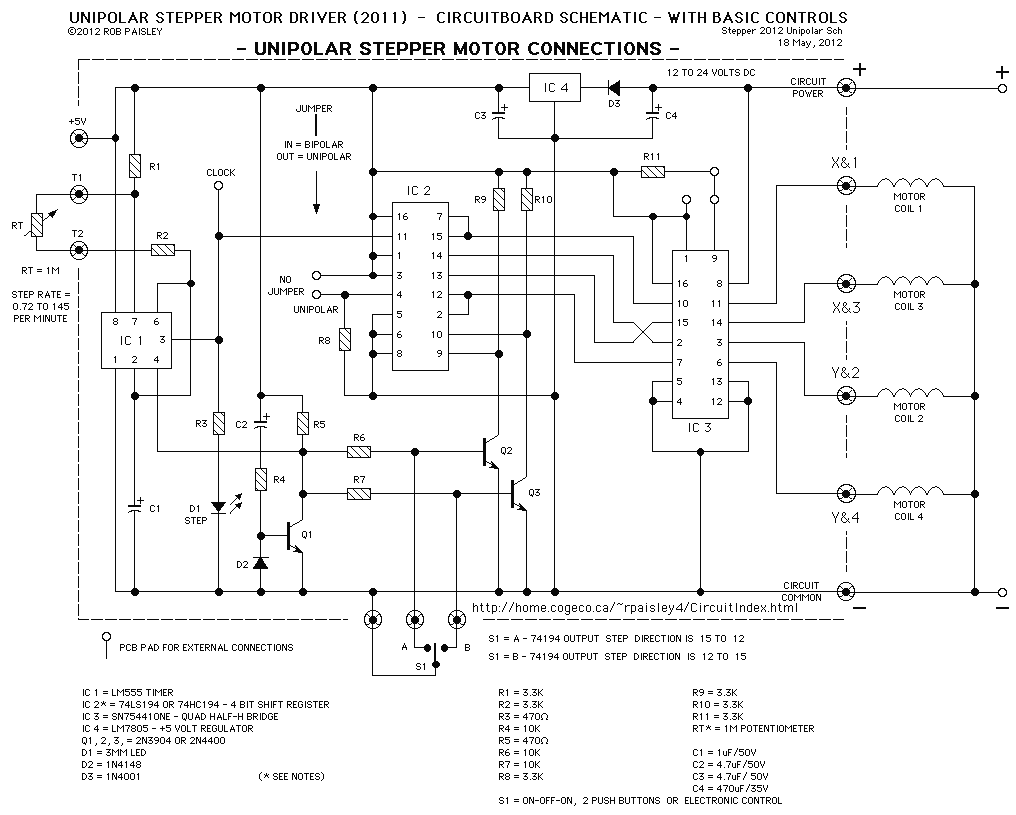
Stepper Motor Driver Circuit
The following diagram is for the main circuit of the motor driver. A testing version is shown near the end of this page. It is laid out differently and shows the SN7474 in logic block form and LEDs are used...
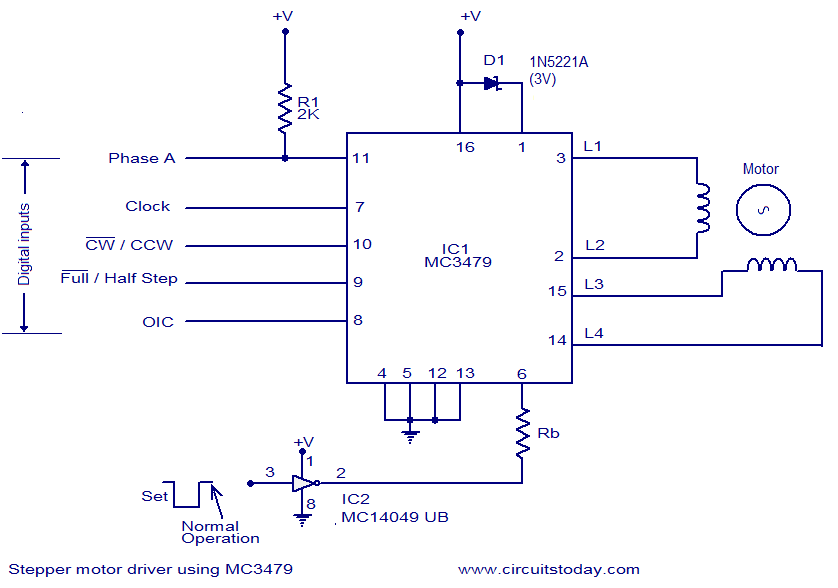
Stepper motor driver using MC3479
The circuit diagram presented is for a stepper motor driver utilizing the MC3479 integrated circuit from Motorola. The MC3479 is specifically engineered for driving a two-phase stepper motor in bipolar mode and is available in both standard DIP and surface...