


analog line follower robot
#line follower
#analog circuit
#sensor
#robot
#track following
#autonomous
#light sensor
#motor control
#DIY
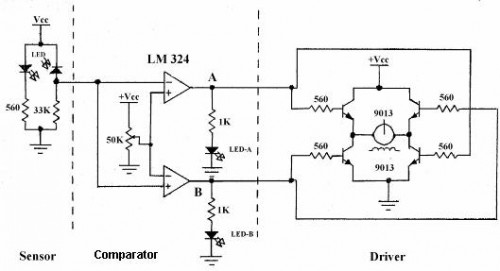
Description: Line follower robots are commonly designed to follow a specific path on a track. Typically, these robots are controlled by microcontrollers; however, this article discusses a line follower robot designed without using a microcontroller. The assembly consists of three main components: a sensor circuit, a comparator, and a driver circuit. The sensor employed is a photodiode, which decreases its resistance when exposed to light and operates under reverse bias conditions. A super-bright LED provides sufficient illumination for the photodiode. When the photodiode is not exposed to light, its resistance is high, leading to minimal current flow into the comparator, indicating a logic 0. Conversely, when the photodiode is illuminated, it acts as a voltage source with low resistance, allowing current to flow into the comparator, indicating a logic 1. The comparator circuit utilizes the LM324 integrated circuit, which contains multiple operational amplifiers to compare sensor inputs and output a logic high signal. The LM324 operates within a voltage range of 3 to 30 volts, with a typical starting voltage of 6 volts. The circuit includes four LEDs that serve as indicators. A variable resistor is connected between two operational amplifiers to set the comparison voltage. If no current flows from the sensor, the input voltage to the comparator is 0 volts, resulting in LED A being on and LED B being off. Conversely, if the sensor input voltage approaches Vcc, LED B will be on while LED A will be off. The states of LEDs A and B will continuously alternate. The driver circuit consists of transistors that control DC motors. When the input A is logic 1, current flows through the circuit, biasing transistors 1 and 4, which results in motor rotation. If input A is logic 1 and input B is logic 0, transistors 2 and 3 will be off. When input B is logic 1, current flows through the circuit, biasing transistors 2 and 3, causing the motor to spin in the opposite direction.
The line follower robot operates based on a simple yet effective design that utilizes analog components instead of a microcontroller for control. The photodiode acts as the primary sensor, detecting the presence of light reflected from the track. This light detection is crucial for determining the robot's position relative to the line it is following. The LED provides the necessary illumination for the photodiode, ensuring reliable operation even in varying ambient light conditions.
The comparator, implemented with the LM324, plays a vital role in processing the signals from the photodiode. By comparing the voltage levels generated by the photodiode under different lighting conditions, the comparator can determine whether the robot is on the line or off it. The output from the LM324 is used to control the driver circuit, which consists of transistors configured to manage the direction and speed of the DC motors.
In the driver circuit, the transistors act as electronic switches that enable or disable the motors based on the logic levels received from the comparator. The configuration allows for forward and backward movement, enabling the robot to adjust its path dynamically in response to the detected line.
The inclusion of variable resistors allows for calibration of the sensitivity of the sensor circuit, making it adaptable to different line colors and surface materials. This adaptability is essential for ensuring optimal performance in various environments.
Overall, this line follower robot design exemplifies an efficient and straightforward approach to robotic control, showcasing the potential of analog components in automation and robotics without relying on complex microcontroller systems.Perhaps we often see robots line follower robot which is going to follow the line on the track. in general line follower robot is controlled by a microcontroller, but in this article online follower robots in the design without using the microcontroller. For that you should try to assemble his Line Follower Robot series consists of three main part s, namely the sensor circuit, a comparator (comparison) and a set of drivers work. The following is a schematic drawing line follower robot: Sensor used consists of photo diode. This sensor resistance value will decrease when exposed to light and work on riverse bias conditions. The light sensor is used for LED Superbright, this component has a very bright light, enough to supply the light for the photo diode.
If the photo diode is not exposed to light, then the resistance will be large or can we assume infinite. So that current flows into the comparator is very small or can be assumed to be logic 0 if exposed to light photo diodes, photo diodes will act as a source of voltage and resistance will be small, so there will be currents flowing into the comparator and logic 1.
The following is a schematic line follower robotimage sensor: Comparator in this circuit using the LM 324 IC that contains a series of Op Amp is used to compare the input from sensors. Where will compare the input from the Op Amp IC LM 324 is output to logic high. So no need to draw on the output. This IC can work on range 3 volts to 30 volts and can work with a normal starting voltage 6 volts. In this series there are also 4 LED, which serves as an indicator. To set the voltage in comparison, connected variable resistor (VR) between the two OP Amp IC LM 324. If no current flows from circuit to circuit sensor is input to the circuit voltage is 0 volts, so the voltage at IC terminals 1 (+)> (-), LED-A in, whereas 2-D IC LED off.
If the current flows from circuit to circuit was the voltage sensor input for this circuit near Vcc, so the voltage at IC terminal 2 (+) <(-), LED-B on, whereas the IC 1-LED A off. Conditions between points A and b will always turn around. The following is a schematic drawing line follower robotcomparator: Driver is a circuit consisting of transistors used to drive DC motors.
Where is the main component of the transistor assembled according to the input character in A to logic 1, then the current flows in the circuit, consequently the transistor 1 and 4 on that basis, the bias, so that the motor rotates. So that when input A logic 1 is input to logic B 0, so the transistor 2 and 3 will be turned off. In logic inputs B 1, then the current flows in the circuit, consequently the transistor 2 and 3 on the basis of bias, so that the motor spinning, but in the opposite direction.
The following is a schematic drawing line follower robot motor driver:
The line follower robot operates based on a simple yet effective design that utilizes analog components instead of a microcontroller for control. The photodiode acts as the primary sensor, detecting the presence of light reflected from the track. This light detection is crucial for determining the robot's position relative to the line it is following. The LED provides the necessary illumination for the photodiode, ensuring reliable operation even in varying ambient light conditions.
The comparator, implemented with the LM324, plays a vital role in processing the signals from the photodiode. By comparing the voltage levels generated by the photodiode under different lighting conditions, the comparator can determine whether the robot is on the line or off it. The output from the LM324 is used to control the driver circuit, which consists of transistors configured to manage the direction and speed of the DC motors.
In the driver circuit, the transistors act as electronic switches that enable or disable the motors based on the logic levels received from the comparator. The configuration allows for forward and backward movement, enabling the robot to adjust its path dynamically in response to the detected line.
The inclusion of variable resistors allows for calibration of the sensitivity of the sensor circuit, making it adaptable to different line colors and surface materials. This adaptability is essential for ensuring optimal performance in various environments.
Overall, this line follower robot design exemplifies an efficient and straightforward approach to robotic control, showcasing the potential of analog components in automation and robotics without relying on complex microcontroller systems.Perhaps we often see robots line follower robot which is going to follow the line on the track. in general line follower robot is controlled by a microcontroller, but in this article online follower robots in the design without using the microcontroller. For that you should try to assemble his Line Follower Robot series consists of three main part s, namely the sensor circuit, a comparator (comparison) and a set of drivers work. The following is a schematic drawing line follower robot: Sensor used consists of photo diode. This sensor resistance value will decrease when exposed to light and work on riverse bias conditions. The light sensor is used for LED Superbright, this component has a very bright light, enough to supply the light for the photo diode.
If the photo diode is not exposed to light, then the resistance will be large or can we assume infinite. So that current flows into the comparator is very small or can be assumed to be logic 0 if exposed to light photo diodes, photo diodes will act as a source of voltage and resistance will be small, so there will be currents flowing into the comparator and logic 1.
The following is a schematic line follower robotimage sensor: Comparator in this circuit using the LM 324 IC that contains a series of Op Amp is used to compare the input from sensors. Where will compare the input from the Op Amp IC LM 324 is output to logic high. So no need to draw on the output. This IC can work on range 3 volts to 30 volts and can work with a normal starting voltage 6 volts. In this series there are also 4 LED, which serves as an indicator. To set the voltage in comparison, connected variable resistor (VR) between the two OP Amp IC LM 324. If no current flows from circuit to circuit sensor is input to the circuit voltage is 0 volts, so the voltage at IC terminals 1 (+)> (-), LED-A in, whereas 2-D IC LED off.
If the current flows from circuit to circuit was the voltage sensor input for this circuit near Vcc, so the voltage at IC terminal 2 (+) <(-), LED-B on, whereas the IC 1-LED A off. Conditions between points A and b will always turn around. The following is a schematic drawing line follower robotcomparator: Driver is a circuit consisting of transistors used to drive DC motors.
Where is the main component of the transistor assembled according to the input character in A to logic 1, then the current flows in the circuit, consequently the transistor 1 and 4 on that basis, the bias, so that the motor rotates. So that when input A logic 1 is input to logic B 0, so the transistor 2 and 3 will be turned off. In logic inputs B 1, then the current flows in the circuit, consequently the transistor 2 and 3 on the basis of bias, so that the motor spinning, but in the opposite direction.
The following is a schematic drawing line follower robot motor driver:
Autonomous Parallel Parking RC Car
An RC car has been developed that can autonomously identify a parking space and execute parallel parking maneuvers. The car navigates along a street using a distance sensor to locate potential parking spaces on its right. Upon identifying a suitable...
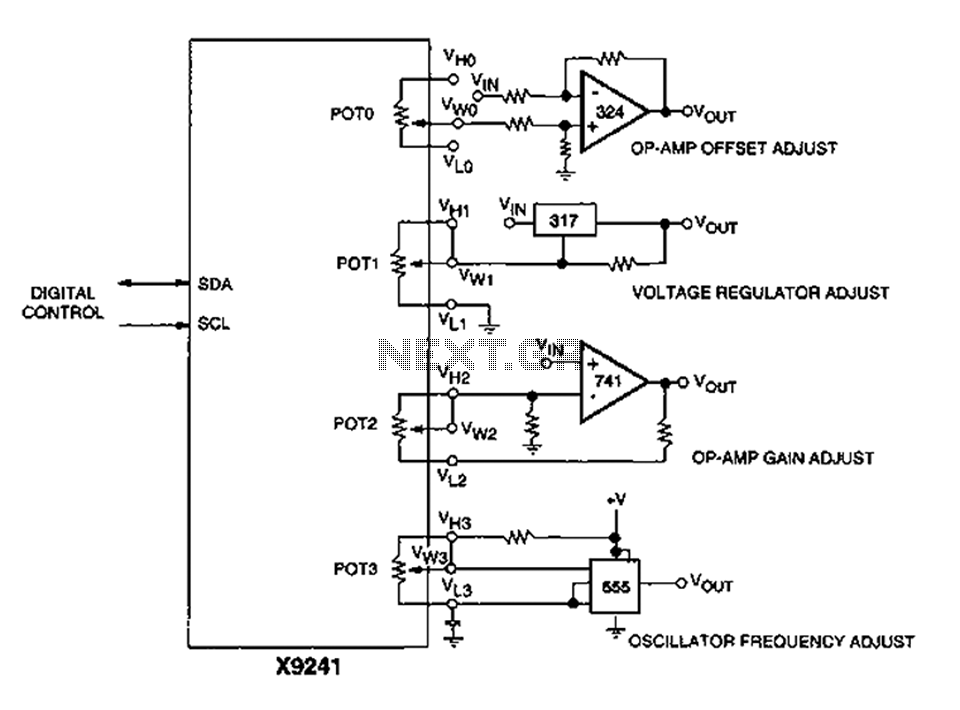
Corrector circuit diagram of an analog circuit
A XICOR X9241 POT IC module can be utilized to modify the four digital analog circuits, as depicted in the schematic.
The XICOR X9241 is a digital potentiometer integrated circuit designed for precise adjustment of analog signal levels in various electronic...
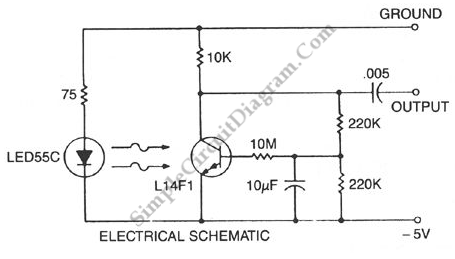
Light Level Droplets Detector
This circuit is a Low-Light Level Drop Detector. It utilizes a self-biasing configuration to detect small changes in light levels.
The Low-Light Level Drop Detector circuit is designed to sense minute variations in ambient light conditions, making it suitable for applications...
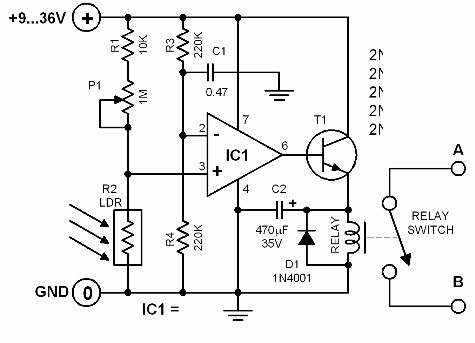
light activated switch
The brightness of the surrounding light controls the function of this circuit. The light sensor used in this circuit is a light-dependent resistor (LDR). This LDR is connected to the non-inverting input of the 741 op-amp IC. Once the intensity...
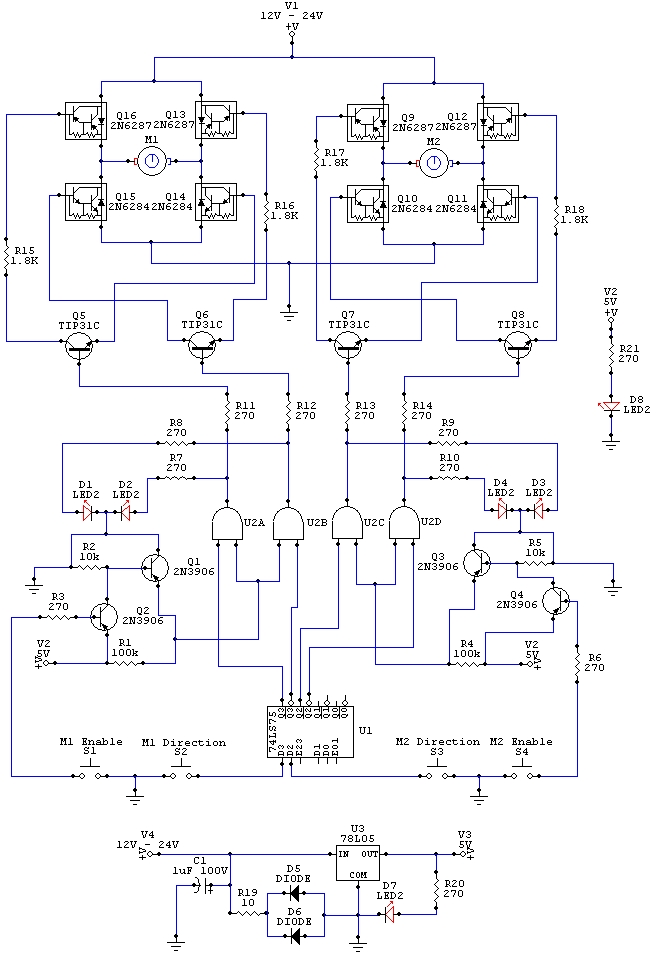
Electronic robot wiring schematic
The wiring schematic played a significant role in the robot. This diagram is used to graphically display all the wiring of the motor-controlling micro-components that enabled the robot to physically move forward, backward, left, right, and stop. This diagram was...
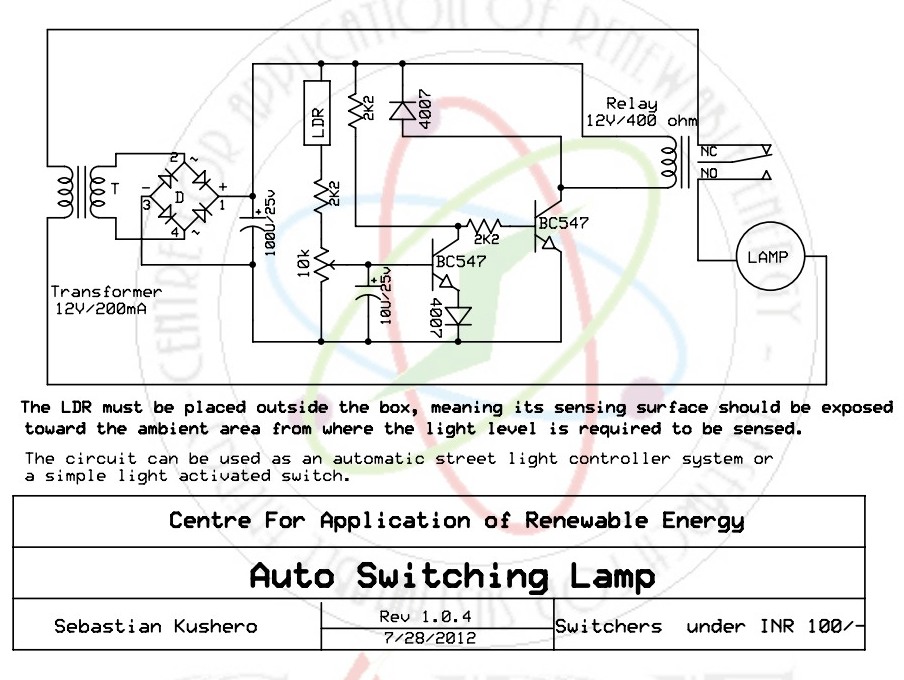
Light Activated Switch
The light-activated switch circuit can be used for switching off a particular lamp or group of lamps in response to varying ambient light levels.
The light-activated switch circuit utilizes a light-dependent resistor (LDR) as the primary sensing element to detect ambient...
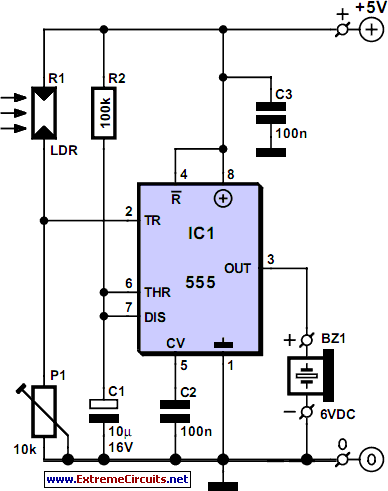
Light Sensitive trigger
All components have been placed on the PCB, but there is uncertainty regarding the connection of the power and load in relation to the relays.
The integration of relays into a printed circuit board (PCB) design requires a clear understanding of...
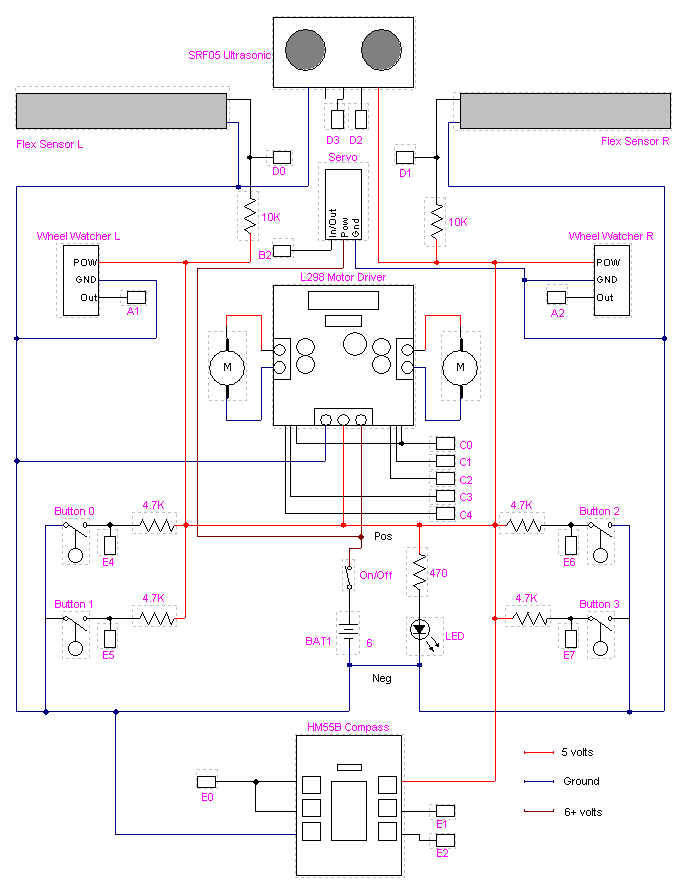
Map Bot
The purpose of this robot is to navigate and map a single floor of a house, using the created map to intelligently traverse the area. Diagnostic software has been developed to verify that all subsystems of the robot are functioning...
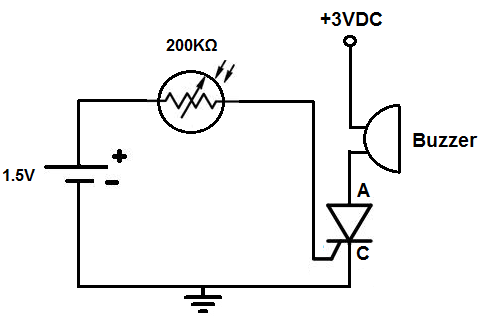
Light Alarm Circuit
This circuit activates an alarm when it detects a specific level of light. When the light exposure increases beyond a predetermined threshold, a loud buzzer sounds, providing an alert. The alarm remains inactive in low-light conditions but triggers in bright...