


2N4401-2N4403 Connection Diagram
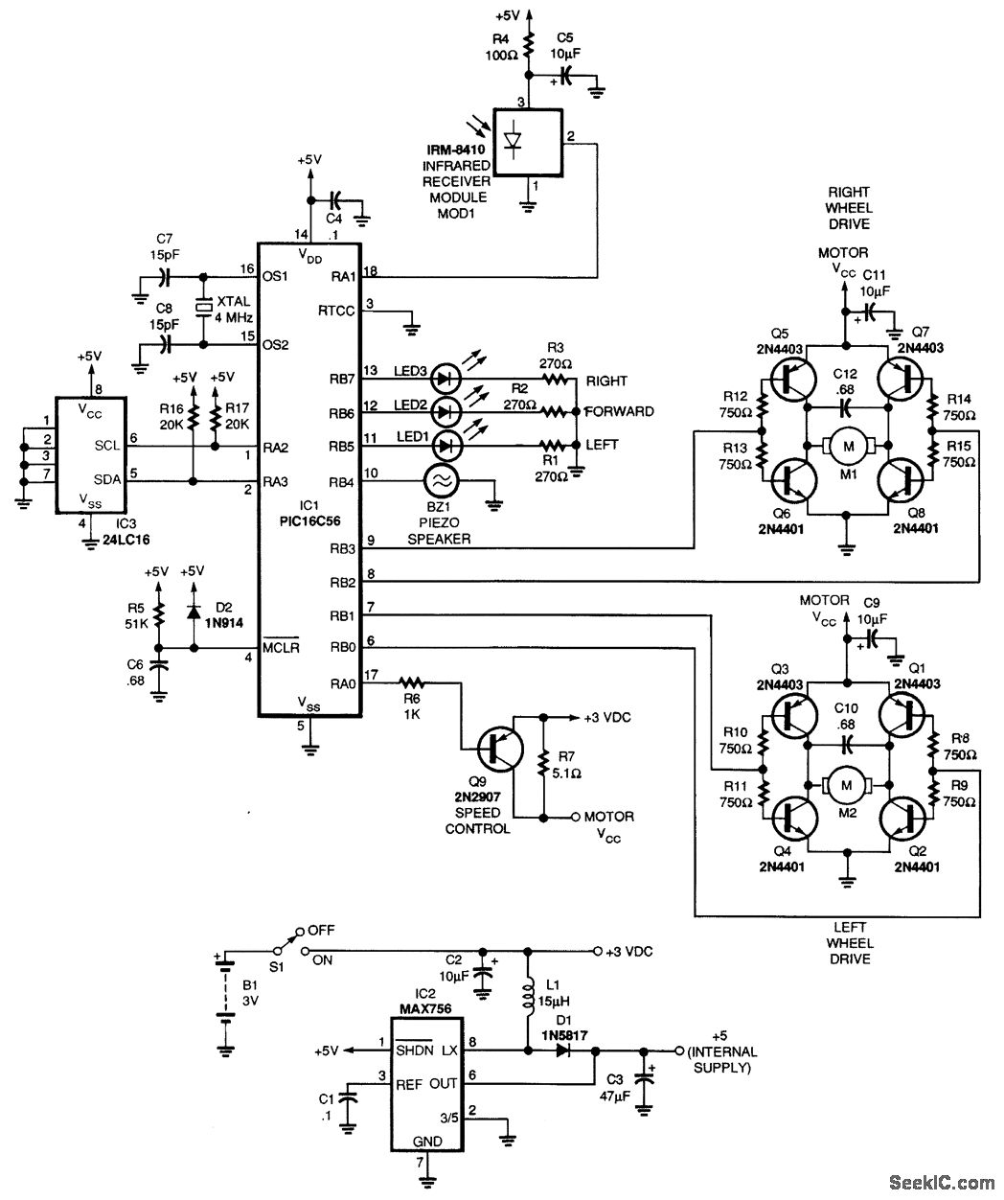
Description: This project utilizes a microcontroller that is programmed with software available on the Gernsback BBS at 516-293-2283 as part of RUNABOUT.ZIP. The robot can be operated using a universal remote control.
The project involves the integration of a microcontroller, which serves as the central processing unit for the robot. This microcontroller is programmed with specific software that enables it to interpret commands received from a universal remote control. The use of a universal remote allows for flexible control options, making it user-friendly and accessible for various applications.
The microcontroller can be interfaced with several peripheral components, including motor drivers that control the movement of the robot. These motor drivers receive signals from the microcontroller and adjust the power supplied to the motors, allowing for precise control over the robot's motion. Additionally, sensors can be incorporated into the design to provide feedback to the microcontroller, enabling the robot to navigate its environment autonomously or semi-autonomously.
Power management is also a crucial aspect of this project. A suitable power supply must be chosen to ensure that the microcontroller and all connected components operate efficiently. Battery options should be considered, along with voltage regulators if necessary, to provide stable power to the system.
In summary, this project exemplifies the application of microcontroller technology in robotics, leveraging software programming and remote control capabilities to create an interactive and functional robotic system. The design can be further enhanced by integrating additional features such as obstacle detection, automated navigation, and advanced control algorithms to expand its operational capabilities.This project uses a microcontroller programmed with software that is posted on the Gerns-back BBS at 516-293-2283 as part of RUNABOUT. ZIP. The robot can be controlled via a universal remote control.
The project involves the integration of a microcontroller, which serves as the central processing unit for the robot. This microcontroller is programmed with specific software that enables it to interpret commands received from a universal remote control. The use of a universal remote allows for flexible control options, making it user-friendly and accessible for various applications.
The microcontroller can be interfaced with several peripheral components, including motor drivers that control the movement of the robot. These motor drivers receive signals from the microcontroller and adjust the power supplied to the motors, allowing for precise control over the robot's motion. Additionally, sensors can be incorporated into the design to provide feedback to the microcontroller, enabling the robot to navigate its environment autonomously or semi-autonomously.
Power management is also a crucial aspect of this project. A suitable power supply must be chosen to ensure that the microcontroller and all connected components operate efficiently. Battery options should be considered, along with voltage regulators if necessary, to provide stable power to the system.
In summary, this project exemplifies the application of microcontroller technology in robotics, leveraging software programming and remote control capabilities to create an interactive and functional robotic system. The design can be further enhanced by integrating additional features such as obstacle detection, automated navigation, and advanced control algorithms to expand its operational capabilities.This project uses a microcontroller programmed with software that is posted on the Gerns-back BBS at 516-293-2283 as part of RUNABOUT. ZIP. The robot can be controlled via a universal remote control.
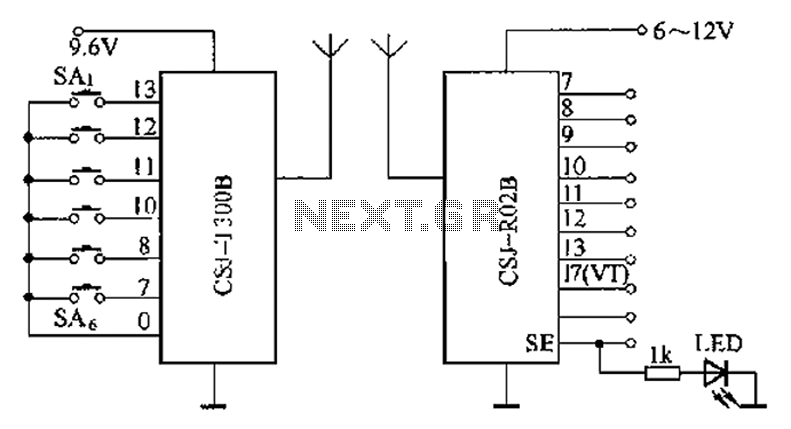
Remote schematic CSJ-T300B with CSJ-R02B composition
The CSJ-T300B/CSJ-R02B is an enhanced digital encoding and decoding circuit developed based on the CSJ-T300A/CSJ-R02A. It forms a remote control circuit that includes the CSJ-T300B and CSJ-R02B components, as illustrated below.
The CSJ-T300B/CSJ-R02B circuit architecture is designed to facilitate improved digital...
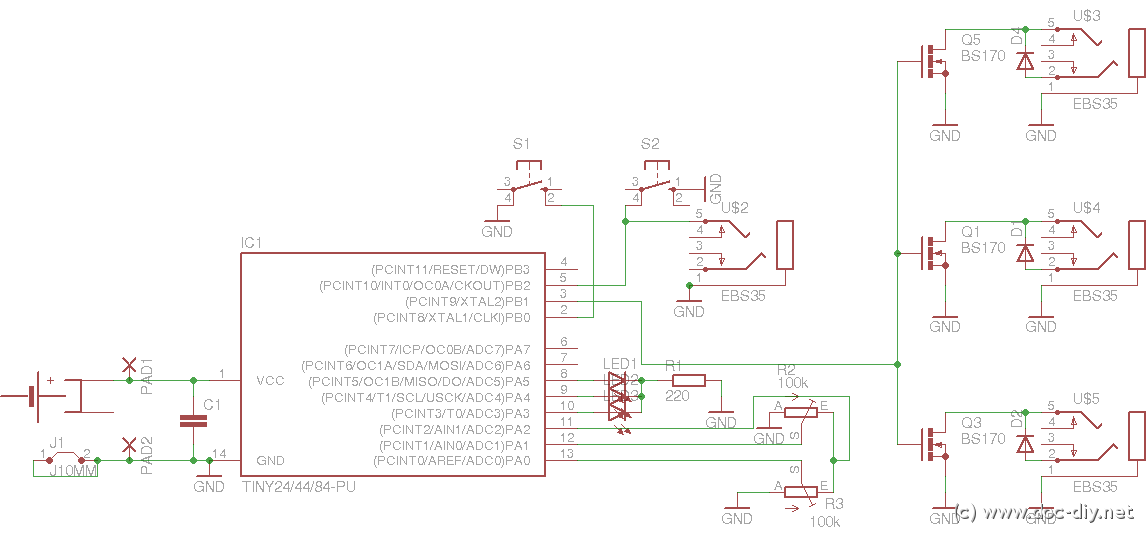
delay
This article outlines the construction of a simple microcontroller-based delay circuit designed for photographic applications, such as drop or high-speed photography. It is capable of controlling the trigger lag for cameras and flash units, generating periodic trigger pulses, or managing...
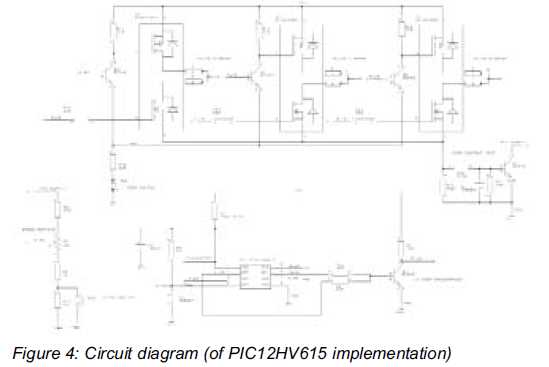
Low Resource Microcontroller 3 Phase BLDC Motor Speed Controller
This article discusses a minimal resource microcontroller implementation for a three-phase Brushless DC (BLDC) motor, focusing on a closed-loop speed motor controller application based on a Microchip PIC12 device. It demonstrates how minimization techniques can reduce the number of I/O...
Jet
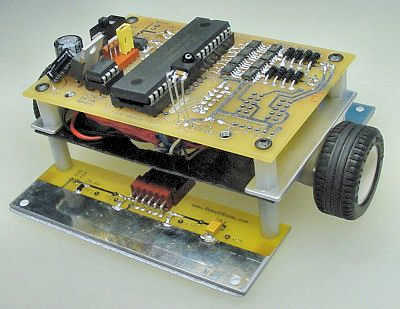
The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous...
knight Rider
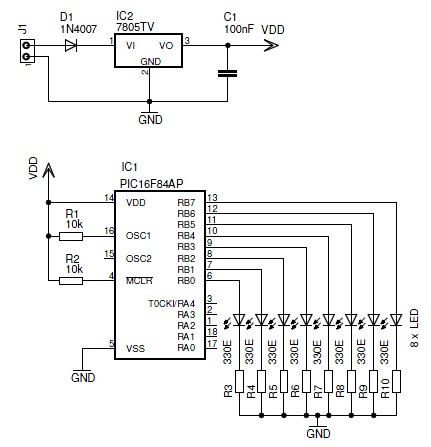
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
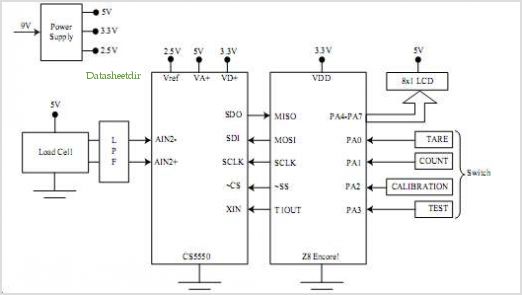
High Resolution Digital Weigh-scale Design Using Z8 Encore! ?® Microcontrollers
The SP6691 circuit is designed to provide a high output voltage using a lower voltage boost regulator by incorporating a charge pump circuit. This configuration can convert a standard 30V boost regulator into a 60V boost regulator if necessary. Testing...
microcontroller led interfacing
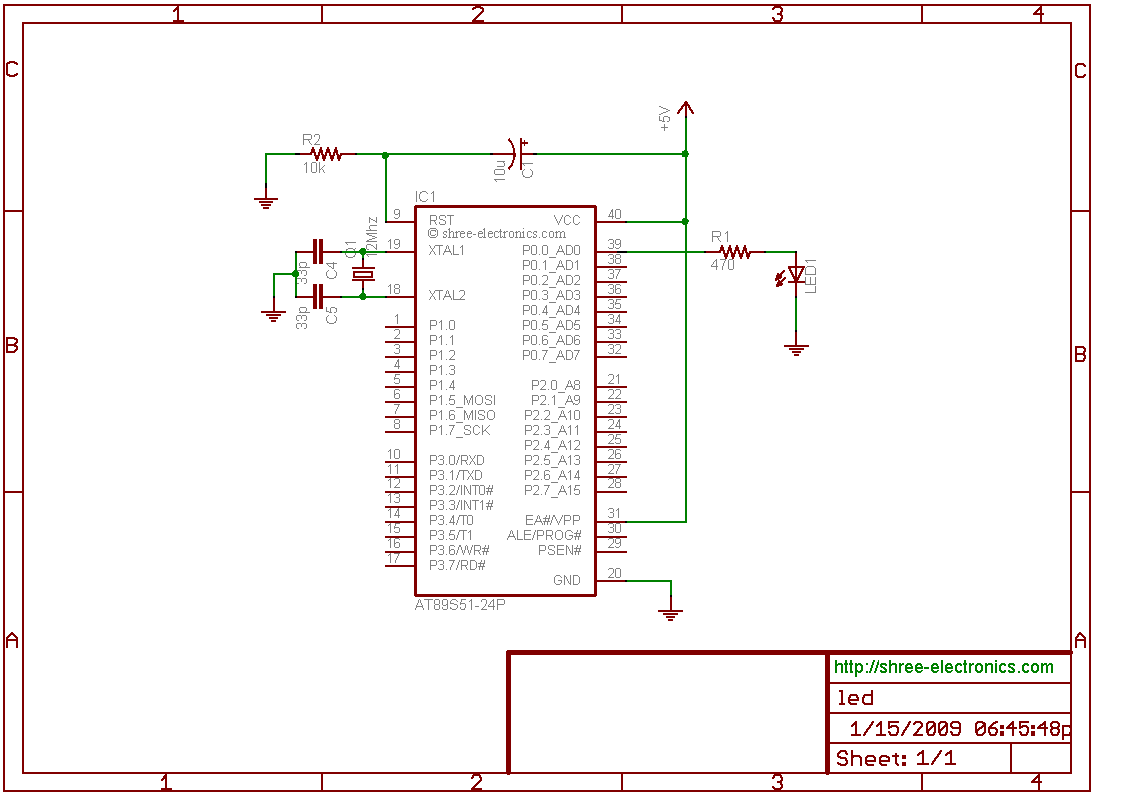
The initial step often taken when learning about any microcontroller or embedded system is to make an LED blink. The circuit presented below illustrates the setup for interfacing an LED. Note: Due to the large dimensions of the circuit diagram,...
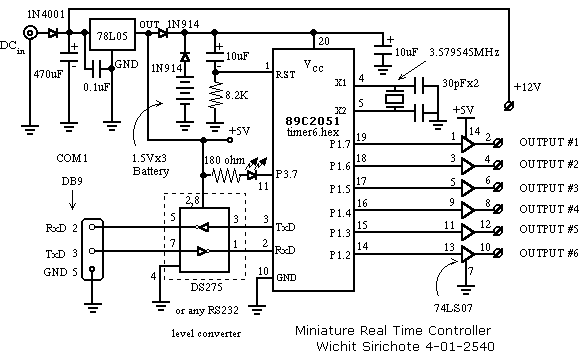
Miniature Real-time Controller
This is my long history the device that controls my home's night light, air-conditioner, etc. The device is a Miniature Real-time Controller. The circuit uses only three chips, a 89C2051, DS275 (or MAX232), and 74LS07 open collector driver. The scheduler...
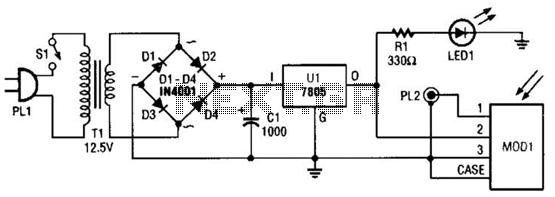
Remote-Control Analyzer Circuit
A schematic diagram for the remote analyzer is presented. The circuit is powered by a simple 5-V supply, which includes components such as PL1, SI, Tl, a bridge rectifier formed by diodes D1 through D4, capacitor CI, and a standard...