


cruddy v 2 line follower mobile robot
#line follower
#robot
#digital logic
#sensor
#motor control
#no microcontroller
#DIY
#electronics
#automation
#circuit design
Description: This is the fifth iteration of a robot named Cruddy version 2. It functions as a line-following robot and features an improved circuit design, originally conceived by the designer. Notably, this project does not utilize a microcontroller; instead, it is constructed entirely using digital logic gates.
The Cruddy version 2 robot operates as a line-following device, employing a series of digital logic gates to process input signals from sensors that detect the line on the ground. The design typically includes two main components: the sensor array and the logic circuit.
The sensor array is composed of infrared (IR) sensors that continuously monitor the surface beneath the robot. When the sensors detect a change in reflectivity—indicating the presence of a line—the output signal is directed to the digital logic gates. The gates are configured to interpret these signals and control the motors that drive the robot's wheels.
The logic circuit may consist of various gates such as AND, OR, and NOT gates, which work together to create a control logic that determines the movement of the robot. For example, if the left sensor detects the line, the logic circuit can be designed to stop the left motor while allowing the right motor to continue, thus steering the robot back onto the line.
The absence of a microcontroller simplifies the design and reduces costs, making it an excellent educational project for understanding the fundamentals of digital electronics and robotics. Furthermore, the aesthetic enhancements contribute to the robot's appeal, showcasing how functional design can merge with visual creativity in electronic projects.
Overall, the Cruddy version 2 robot exemplifies a practical application of digital logic in robotics, illustrating the principles of sensor integration and motor control without the complexity of programmable components.This is my 5th robot. He is Cruddy version 2. Still he is a line following robot but has now abetter circuit design (originally designed by me) and has cool appearance :D This project doesn`t have any microcontroller. It is designed through digital logic gates only. I used two..
The Cruddy version 2 robot operates as a line-following device, employing a series of digital logic gates to process input signals from sensors that detect the line on the ground. The design typically includes two main components: the sensor array and the logic circuit.
The sensor array is composed of infrared (IR) sensors that continuously monitor the surface beneath the robot. When the sensors detect a change in reflectivity—indicating the presence of a line—the output signal is directed to the digital logic gates. The gates are configured to interpret these signals and control the motors that drive the robot's wheels.
The logic circuit may consist of various gates such as AND, OR, and NOT gates, which work together to create a control logic that determines the movement of the robot. For example, if the left sensor detects the line, the logic circuit can be designed to stop the left motor while allowing the right motor to continue, thus steering the robot back onto the line.
The absence of a microcontroller simplifies the design and reduces costs, making it an excellent educational project for understanding the fundamentals of digital electronics and robotics. Furthermore, the aesthetic enhancements contribute to the robot's appeal, showcasing how functional design can merge with visual creativity in electronic projects.
Overall, the Cruddy version 2 robot exemplifies a practical application of digital logic in robotics, illustrating the principles of sensor integration and motor control without the complexity of programmable components.This is my 5th robot. He is Cruddy version 2. Still he is a line following robot but has now abetter circuit design (originally designed by me) and has cool appearance :D This project doesn`t have any microcontroller. It is designed through digital logic gates only. I used two..
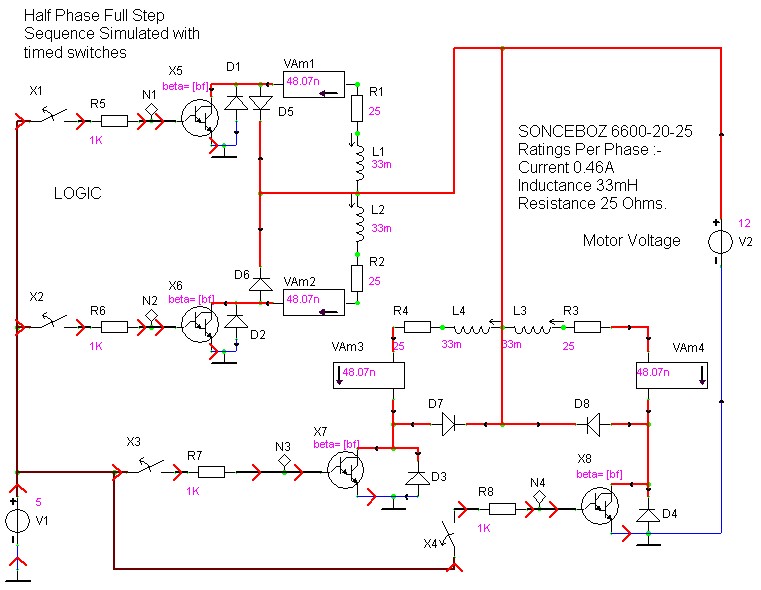
case stepper
Beige Bag Software has been offering affordable and innovative circuit design tools since 1990. B2 Spice provides schematics as well as analog, digital, and mixed-mode electronic circuit simulation. It integrates with EAGLE and CADSTAR PCB software.
B2 Spice is a powerful...
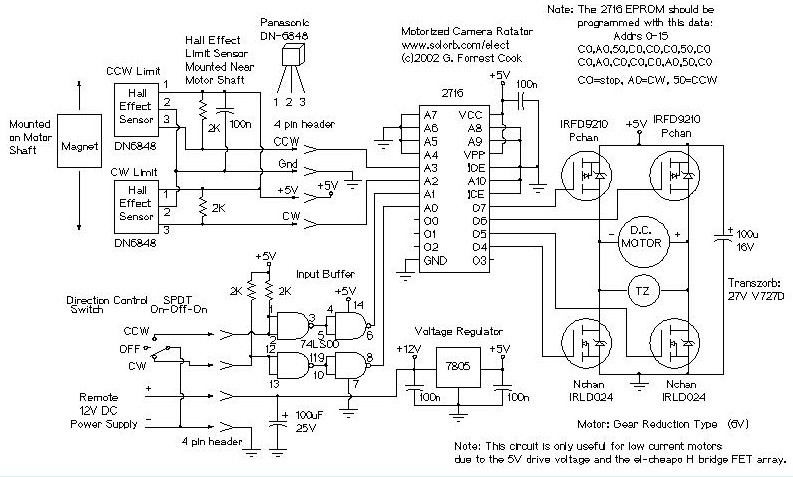
Motorized Video Camera Mount
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
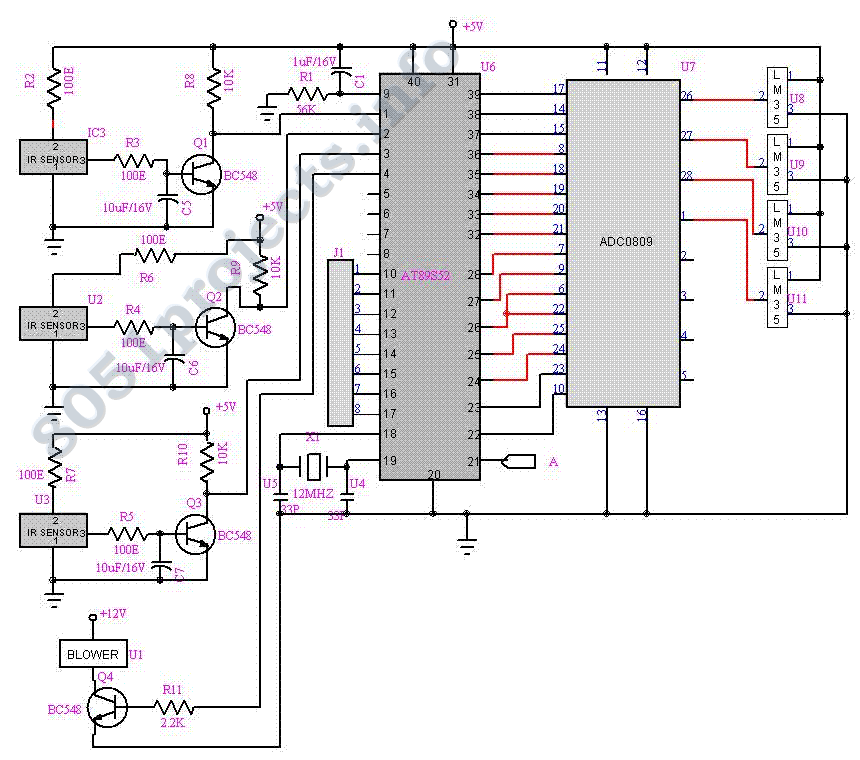
Fighting Robot circuit
The need for a device that can detect and extinguish a fire on its own is long past due. Many house fires originate when someone is either sleeping or not home. With the invention of such a device, people and...
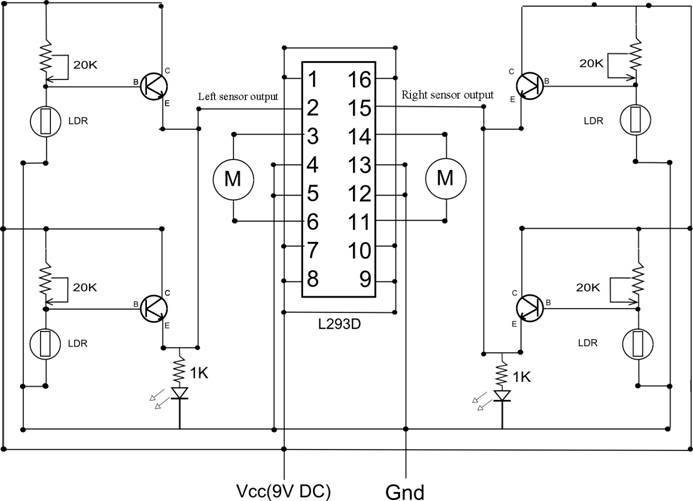
Line follower obstacle avoider
This tutorial outlines the construction of a simple and low-cost robot primarily designed as a line follower. It can also function as a photovore, photophobe, and obstacle avoider, all for less than $40. Notably, the robot does not utilize a...
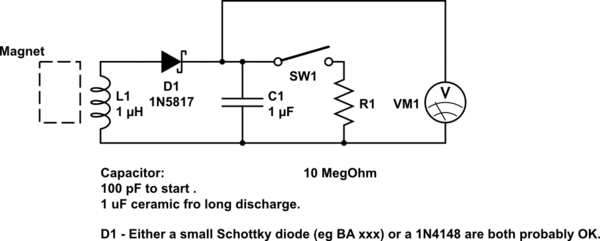
DIY kinetic energy harvester
A DIY kinetic energy harvester utilizing the electromagnetic method to generate electricity. The materials that will be used are currently known.
The project involves creating a kinetic energy harvester that converts mechanical energy from motion into electrical energy through electromagnetic induction....
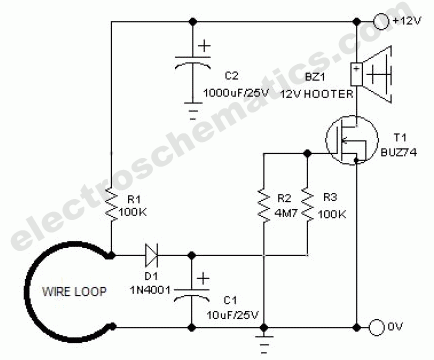
Wire Break Sensor Alarm Circuit Schematic
The circuit of a loop sensor-based simple security alarm is described here. The sensor loop consists of a short length of thin enamelled copper wire.
The loop sensor security alarm operates on the principle of detecting interruptions in the circuit formed...
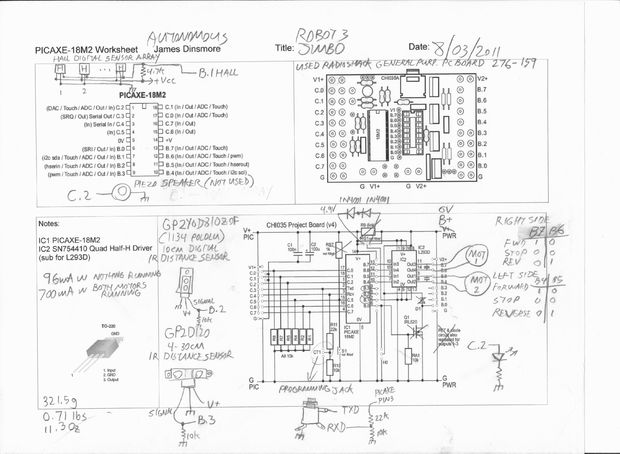
Robot Autonomous Sensor Platform
This is an autonomous robot designed to explore the interfacing of various sensors with a PICAXE processor. Its mission is to search for a magnet.
The autonomous robot operates based on a microcontroller architecture centered around the PICAXE processor, which is...
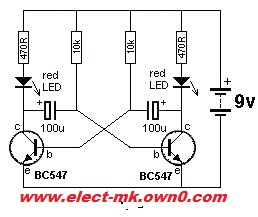
Robot eyes circuit
Robot eyes circuit of Service. A simple circuit to simulate a man appointed to it. It consists of a dual-lamp working in an unsteady manner. Circuit diagram.
The robot eyes circuit is designed to create a visual effect that simulates the...
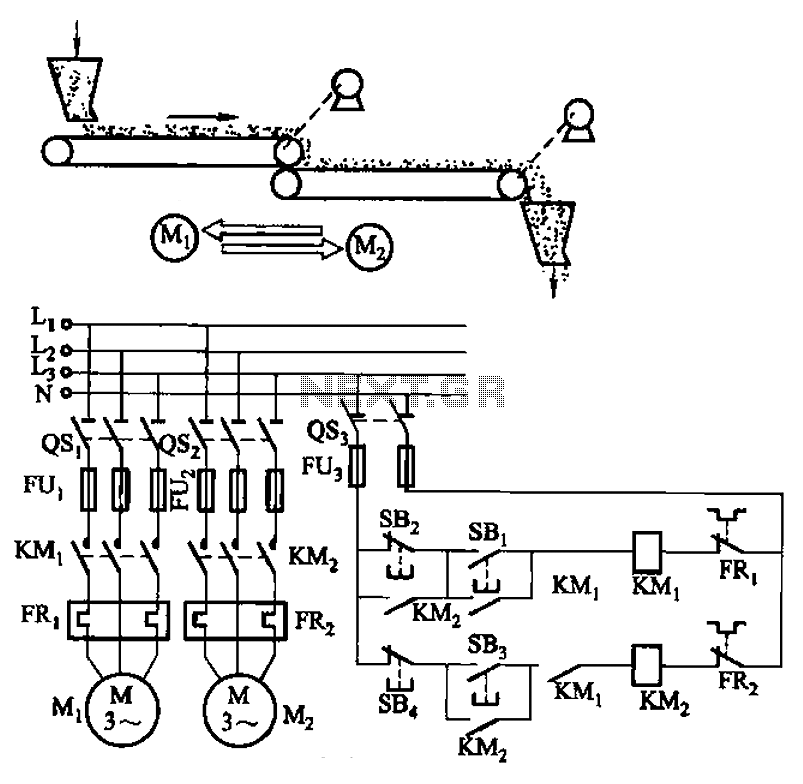
Belt conveyor interlock motor operation sequence control circuit
The circuit depicted in Figure 3-86 utilizes a line utilization time relay to control two motors, starting one before the other after an initial stall. The time relay KTi can be adjusted to modify the starting interval of the two...