


pic raymarine seatalk bus interface
#PIC
#Raymarine
#SeaTalk
#bus interface
#schematic
#TX
#RX
#marine electronics
#serial communication
#microcontroller
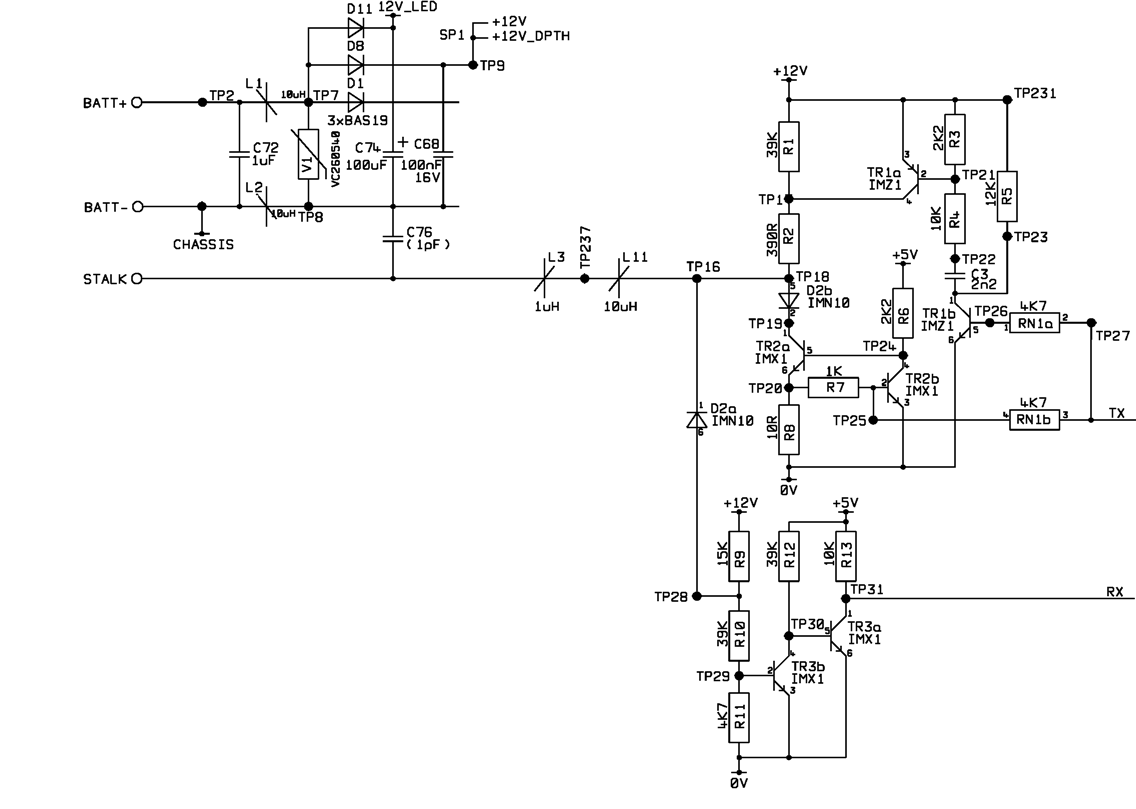
Description: A project involves using a PIC microcontroller to communicate with the Raymarine SeaTalk bus. The schematic diagram for a Raymarine instrument shows a logic chip connected to the TX and RX connections on the right side, while the SeaTalk signals and power input are located at the top left. The aim is to simplify the right half of this circuit. It is acknowledged that fewer components can be utilized, as demonstrated by a simple circuit; however, this simple circuit was developed without access to the original schematic. The original circuit is expected to aid in designing a more efficient simple version. Challenges have been encountered in replicating the functionalities of the original circuit that are absent in the simplified version. Inversion is not a concern since the bit-banging method can be adjusted. The baud rate is set at 4800, with the SeaTalk bus operating at 12V and the original logic side at 5V, while the device operates at 3.3V. Although a "bus driver IC" was suggested, there seems to be a contradiction in seeking to reduce component count. From an engineering perspective, using two transistors and three resistors may be more efficient than employing a specialized IC along with its necessary support components. The simple circuit was created without knowledge of the original design, and if such a simple solution were adequate, it is likely that the original manufacturers would have implemented it over a decade ago. Numerous driver ICs are now available at a low cost, making it reasonable to consider using one, provided a suitable option can be identified.
A schematic for a communication interface between a PIC microcontroller and the Raymarine SeaTalk bus can be developed by focusing on essential components while ensuring functionality and reliability. The design should include a level-shifting mechanism to accommodate the voltage difference between the SeaTalk bus (12V) and the logic side of the microcontroller (3.3V). The use of a dedicated bus driver IC is advisable, as it can simplify the design by integrating multiple functionalities into a single component, thereby reducing the overall component count and enhancing reliability.
The circuit may consist of a bus driver IC capable of translating signals between the 12V SeaTalk bus and the 3.3V logic levels of the PIC. This IC should support the required baud rate of 4800 and be compatible with the bidirectional nature of the SeaTalk protocol. Additionally, the circuit should include bypass capacitors to filter noise and stabilize the power supply for the bus driver IC.
To further simplify the design, two N-channel MOSFETs can be employed as level shifters for the RX and TX lines. The gates of these MOSFETs can be driven by the PIC microcontroller's GPIO pins, allowing for bidirectional communication. Resistors can be used for pull-up and pull-down configurations to ensure proper signal integrity.
The final design must also incorporate adequate protection features, such as diodes to prevent reverse polarity and transient voltage suppression, ensuring the longevity of the components involved. This approach, while initially appearing to involve more components, ultimately leads to a more robust and maintainable circuit that adheres to the specifications of the SeaTalk communication protocol.I`m working on a project with a PIC to communicate with the Raymarine SeaTalk bus. The link below is the part of the schematic diagram of a Raymarine instrument. The logic chip is connected to the TX and RX connections on the right, and the SeaTalk signals and power enter top left. I want to simplify the right half of this circuit. I know it can b e done with fewer components, as this Simple Circuit shows: This simple circuit however was done without prior access the the official circuit above; I was hoping that having the original circuit would help in designing a better simple one. I`ve tried to follow what the original circuit does that the simple one doesn`t, but I`m struggling. Inversion doesn`t matter, as I can chose how I bit-bang the bus. Baud rate is 4800, the SeaTalk bus is a 12V bus, the logic side is 5V in the original, but 3. 3V in my device. I saw you asked for a "bus driver IC" but in the same sentence you asked about "reducing the component count".
In engineering terms using two transistors and 3 resistors beats using a specialised IC and whatever support components the IC needs. Like I said, the simple circuit was created without prior knowledge of the original. If such a simple circuit was sufficient, the original manufacturers would have used it when the product was designed over 10 years ago.
There are many driver ICs now available at little cost, so it seems sensible to use one, assuming a suitable one can be found.
A schematic for a communication interface between a PIC microcontroller and the Raymarine SeaTalk bus can be developed by focusing on essential components while ensuring functionality and reliability. The design should include a level-shifting mechanism to accommodate the voltage difference between the SeaTalk bus (12V) and the logic side of the microcontroller (3.3V). The use of a dedicated bus driver IC is advisable, as it can simplify the design by integrating multiple functionalities into a single component, thereby reducing the overall component count and enhancing reliability.
The circuit may consist of a bus driver IC capable of translating signals between the 12V SeaTalk bus and the 3.3V logic levels of the PIC. This IC should support the required baud rate of 4800 and be compatible with the bidirectional nature of the SeaTalk protocol. Additionally, the circuit should include bypass capacitors to filter noise and stabilize the power supply for the bus driver IC.
To further simplify the design, two N-channel MOSFETs can be employed as level shifters for the RX and TX lines. The gates of these MOSFETs can be driven by the PIC microcontroller's GPIO pins, allowing for bidirectional communication. Resistors can be used for pull-up and pull-down configurations to ensure proper signal integrity.
The final design must also incorporate adequate protection features, such as diodes to prevent reverse polarity and transient voltage suppression, ensuring the longevity of the components involved. This approach, while initially appearing to involve more components, ultimately leads to a more robust and maintainable circuit that adheres to the specifications of the SeaTalk communication protocol.I`m working on a project with a PIC to communicate with the Raymarine SeaTalk bus. The link below is the part of the schematic diagram of a Raymarine instrument. The logic chip is connected to the TX and RX connections on the right, and the SeaTalk signals and power enter top left. I want to simplify the right half of this circuit. I know it can b e done with fewer components, as this Simple Circuit shows: This simple circuit however was done without prior access the the official circuit above; I was hoping that having the original circuit would help in designing a better simple one. I`ve tried to follow what the original circuit does that the simple one doesn`t, but I`m struggling. Inversion doesn`t matter, as I can chose how I bit-bang the bus. Baud rate is 4800, the SeaTalk bus is a 12V bus, the logic side is 5V in the original, but 3. 3V in my device. I saw you asked for a "bus driver IC" but in the same sentence you asked about "reducing the component count".
In engineering terms using two transistors and 3 resistors beats using a specialised IC and whatever support components the IC needs. Like I said, the simple circuit was created without prior knowledge of the original. If such a simple circuit was sufficient, the original manufacturers would have used it when the product was designed over 10 years ago.
There are many driver ICs now available at little cost, so it seems sensible to use one, assuming a suitable one can be found.
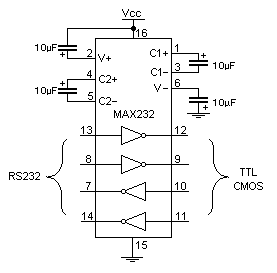
Microcontroller interfacing with RS 232
Standard serial interfacing of a microcontroller (TTL) with a PC or any RS232C standard device requires a TTL to RS232 level converter. A MAX232 is used for this purpose. It provides a 2-channel RS232C port and requires external 10µF capacitors.
The...
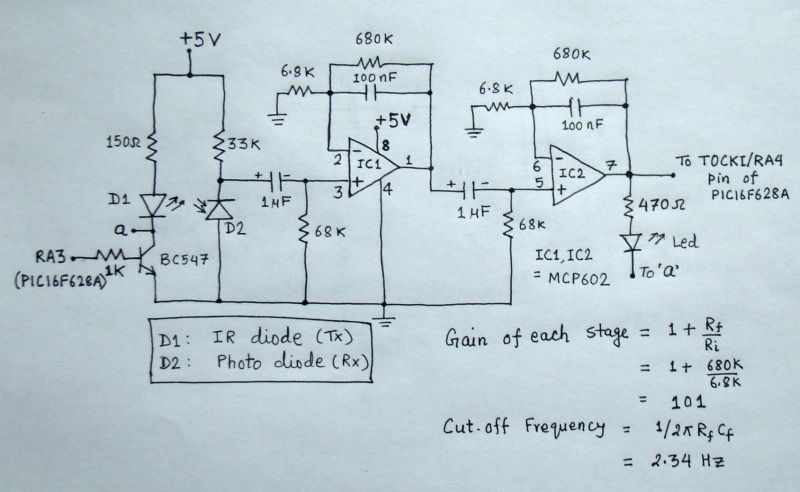
Microcontroller measures heart rate through fingertip
The reflected infrared (IR) signal detected by the photodiode is sent to a signal conditioning circuit, which filters out unwanted signals and amplifies the desired output.
The circuit begins with a photodiode that captures the reflected IR signals. The photodiode operates...
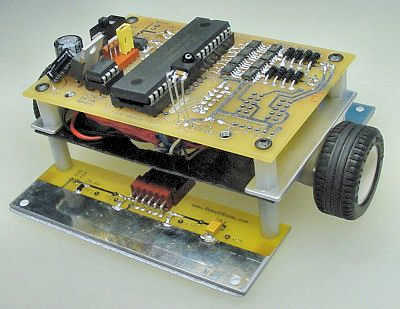
Jet
The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous...
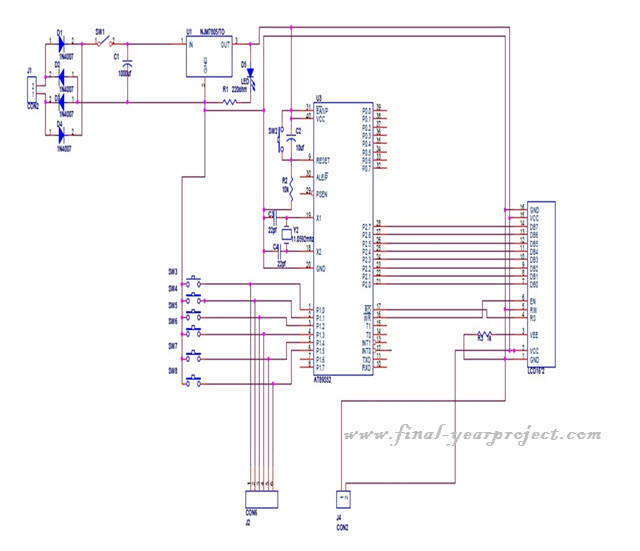
Microcontroller based College Automation System
This project is a microcontroller-based college automation system aimed at addressing the challenges faced in educational institutions. It replaces the conventional notice board with an automated device that allows users to both hear and read the information being announced through...
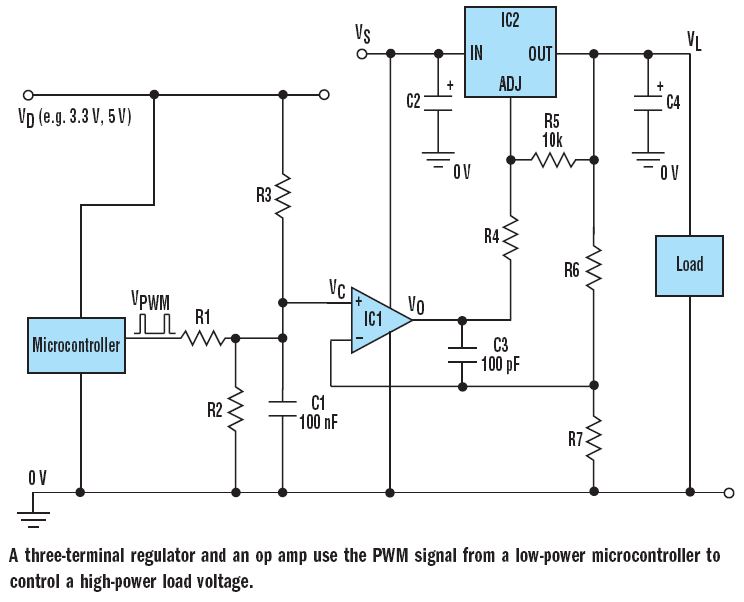
microcontroller How does this power supply circuit work? (MCU + LM317)
The filter consisting of resistors R1, R2, and capacitor C1 integrates the PWM waveform. The purpose of the operational amplifier appears to be that of a non-inverting amplifier, with the gain determined by resistors R6 and R7. However, the need...
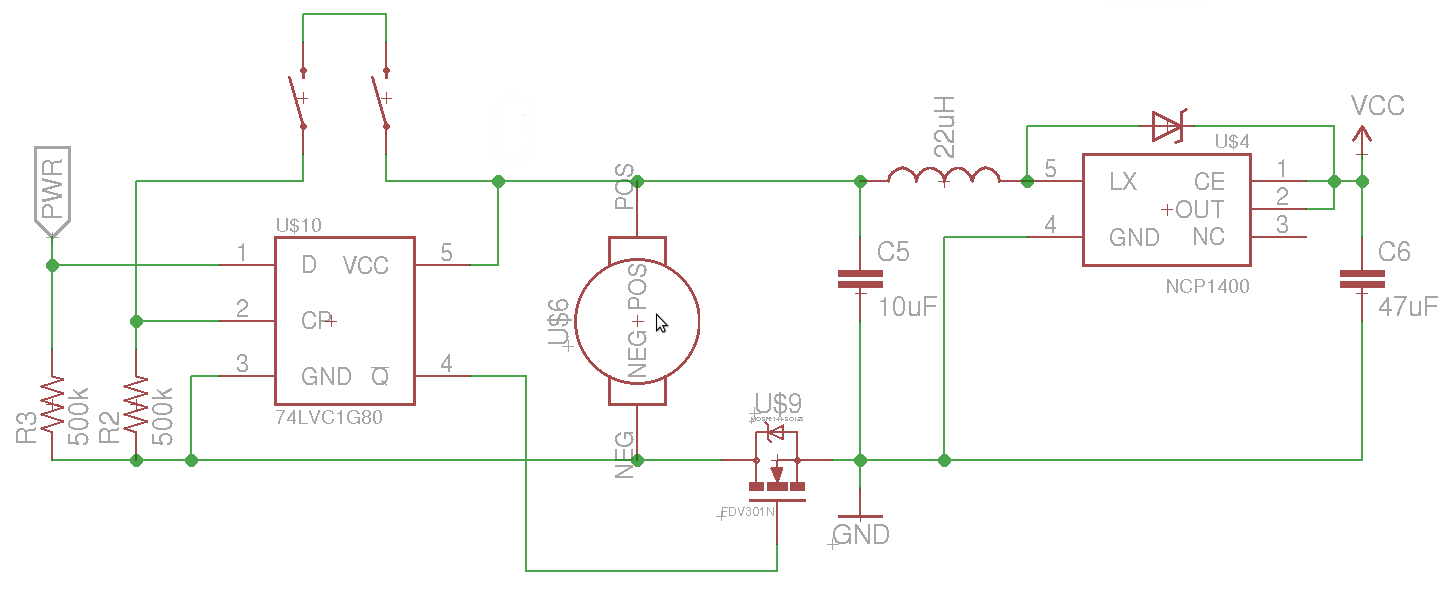
mosfet Turning a microcontroller on with a flip flop
The objective is to control the power to a load, specifically an 8051-based microcontroller (uC), using two switches. When the uC is powered on, it sets the PWR pin high. Upon pressing the switches again, pin 4 of the flip-flop...
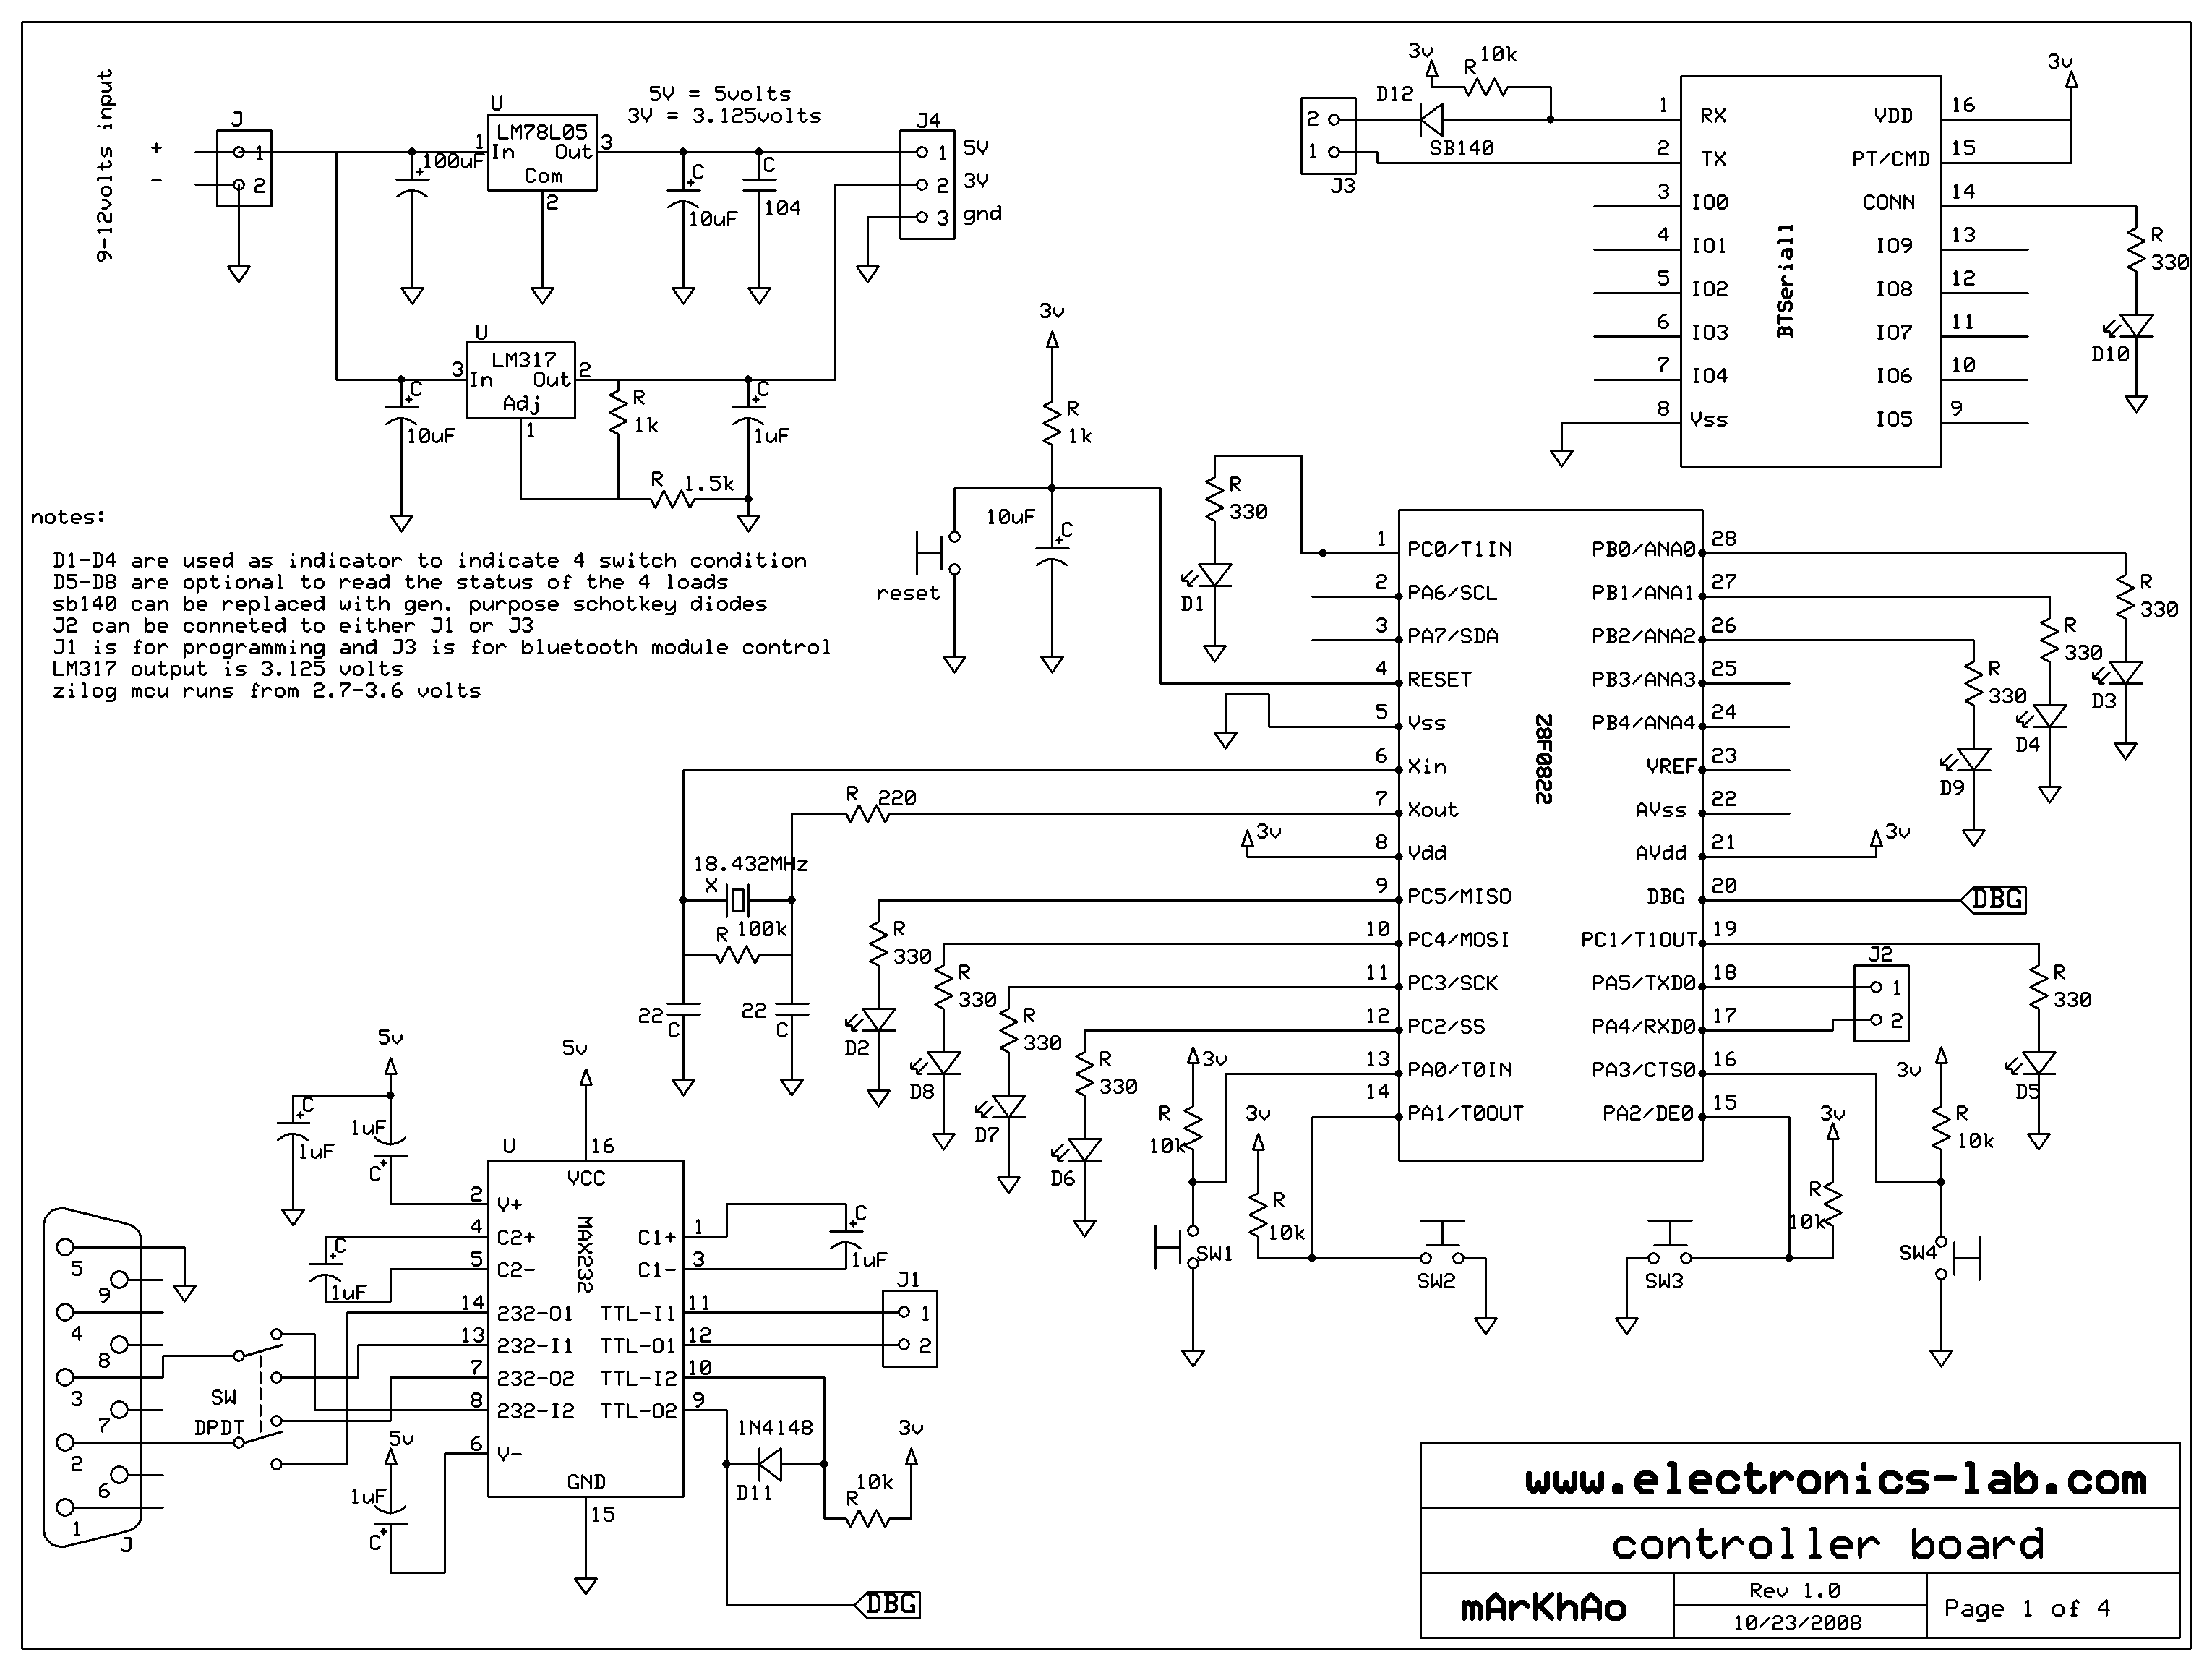
MCU controlled Bluetooth automation
The microcontroller used is 0822 zilog encore! 8k series (soic,28pin) as shown on the figure. Is a programmable microcontroller, the functions used are the GPIO and the UART of the chip. GPIO is used on led indicators, and the UART...
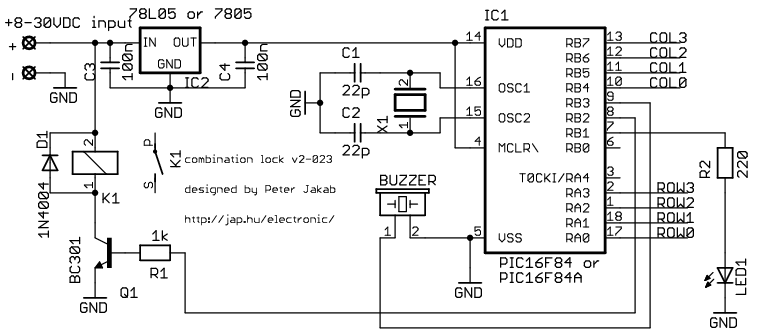
Electronic combination lock with PIC
This is my electronic combination lock to use with an outdoor gate. The functionality is implemented in software. It turns on a relay (usually to open a door) for a few seconds if someone enters the valid code. This relay...
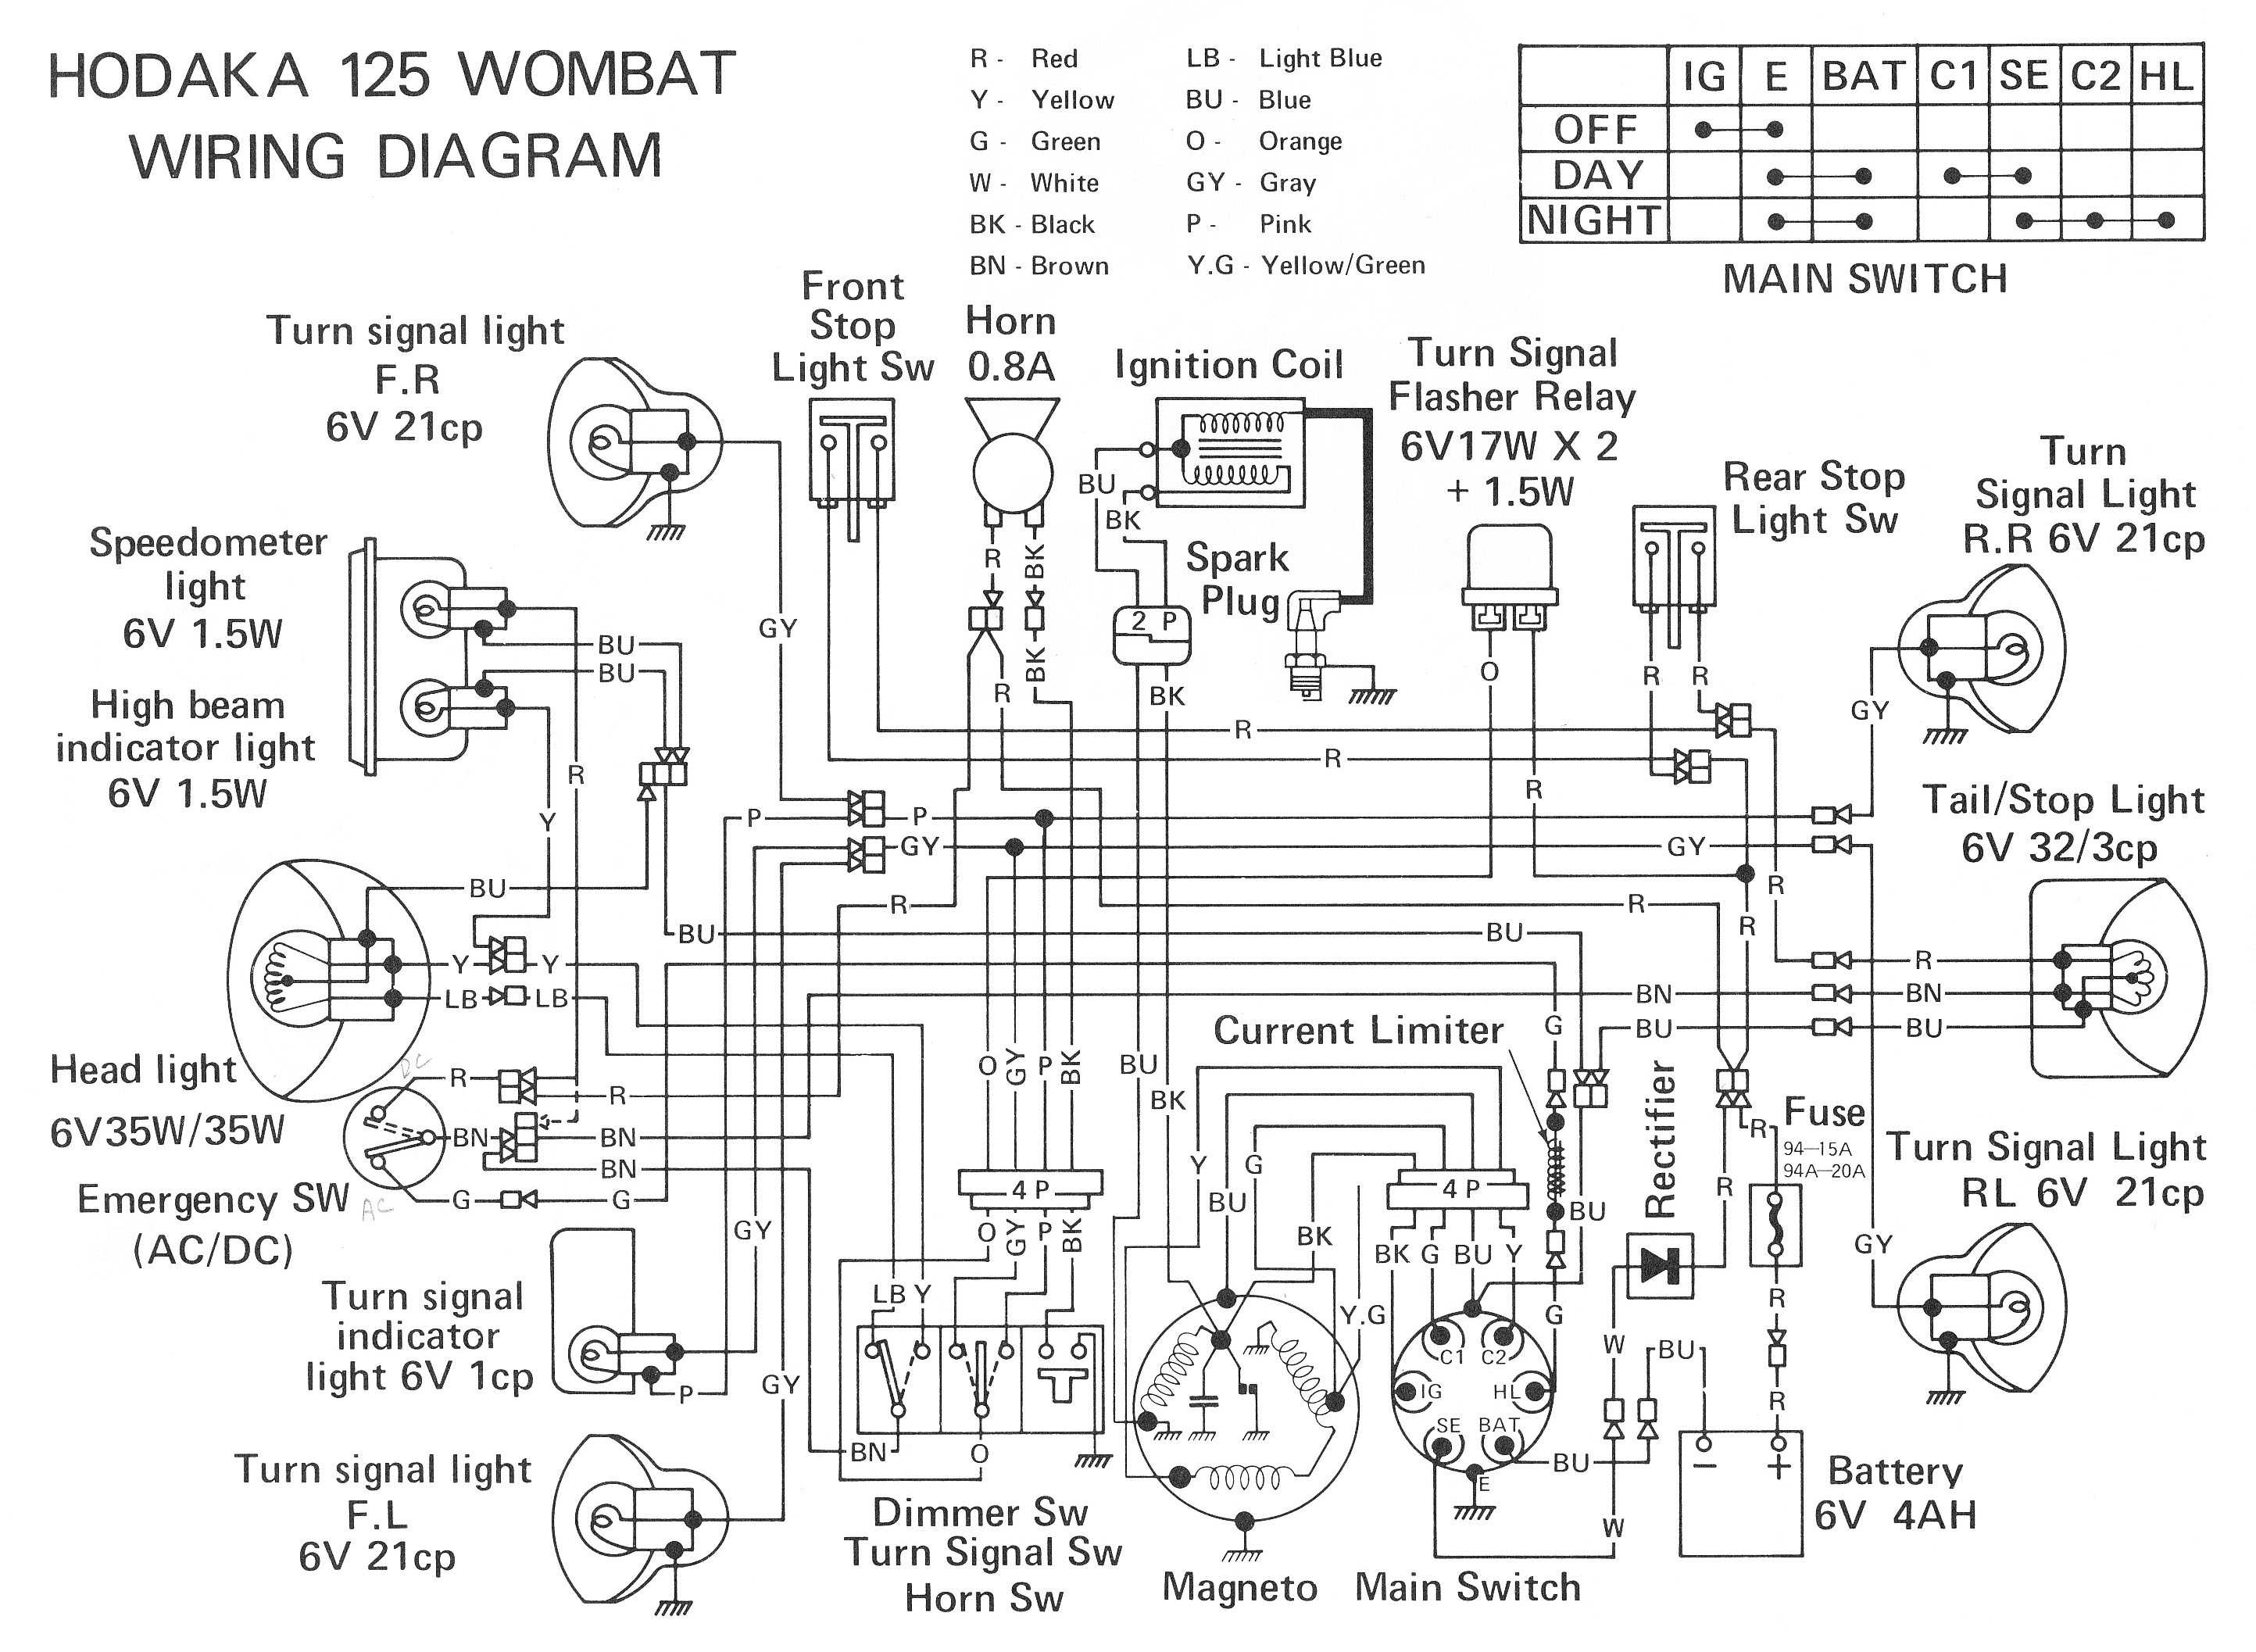
ELECTRONIC SCHEMATIC CIRCUIT DIAGRAMS
Electronic Schematic Circuit Diagrams Manual PDF Download.
The document provides a comprehensive manual that focuses on electronic schematic circuit diagrams. These diagrams are essential tools for understanding and designing electronic circuits, offering visual representations of circuit components and their interconnections. The...