


Arduino Ping
#arduino
#ultrasonic
#sensor
#distance measurement
#ping
#parallax
#microcontroller
#echo
#range finder
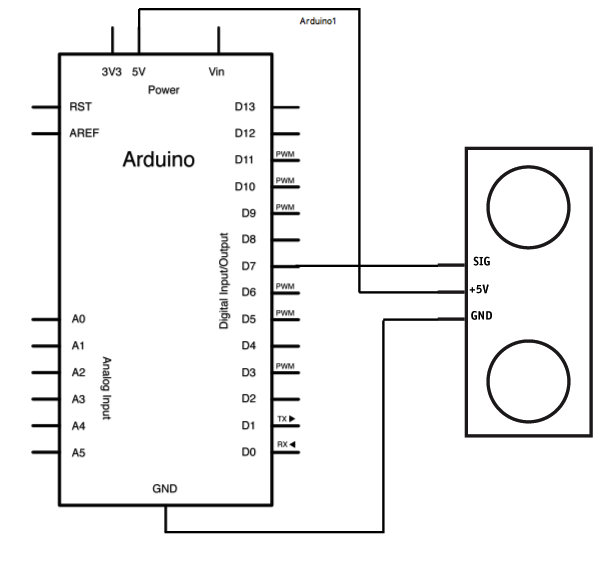
Description: The Ping is an ultrasonic range finder from Parallax. It detects the distance of the closest object in front of the sensor (from 2 cm up to 3 meters). It operates by emitting a burst of ultrasound and listening for the echo that returns after bouncing off an object. The Arduino board sends a short pulse to trigger the detection and subsequently listens for a pulse on the same pin using the pulseIn() function. The duration of this second pulse corresponds to the time taken by the ultrasound to travel to the object and back to the sensor. By utilizing the speed of sound, this time can be converted into a distance measurement. The 5V pin of the Ping is connected to the 5V pin on the Arduino, the GND pin is connected to the GND pin, and the SIG (signal) pin is connected to digital pin 7 on the Arduino.
The Ping ultrasonic range finder is a compact and efficient device designed for distance measurement applications. Its operation is based on the principles of sonar, where it emits a high-frequency sound wave and measures the time taken for the sound wave to reflect off an object and return to the sensor. This capability allows the Ping to accurately measure distances ranging from 2 centimeters to 3 meters, making it suitable for various robotics and automation projects.
In a typical configuration, the Ping sensor is powered by a 5V supply, which is commonly provided by an Arduino board. The GND pin establishes a common ground between the sensor and the Arduino, ensuring proper operation. The SIG pin is the critical interface for communication between the sensor and the Arduino. When the Arduino sends a trigger pulse to the SIG pin, the Ping sensor emits an ultrasonic pulse. The Arduino then listens for the returning echo using the pulseIn() function, which measures the duration of the received signal.
To calculate the distance to the object, the time measured is divided by two (to account for the round trip of the sound wave) and multiplied by the speed of sound in air, which is approximately 343 meters per second at room temperature. This calculated distance can then be used in various applications, such as obstacle avoidance in mobile robots, distance measurement in automation systems, or even simple range-finding tasks in hobby projects.
The integration of the Ping sensor with an Arduino is straightforward, requiring only a few connections and a simple program to handle the timing and calculations. The versatility and ease of use of the Ping ultrasonic range finder make it an ideal choice for both beginners and experienced developers in the field of electronics and robotics.The Ping is an ultrasonic range finder from Parallax. It detects the distance of the closest object in front of the sensor (from 2 cm up to 3m). It works by sending out a burst of ultrasound and listening for the echo when it bounces off of an object. The Arduino board sends a short pulse to trigger the detection, then listens for a pulse on the s ame pin using the pulseIn() function. The duration of this second pulse is equal to the time taken by the ultrasound to travel to the object and back to the sensor. Using the speed of sound, this time can be converted to distance. The 5V pin of the PING) is connected to the 5V pin on the Arduino, the GND pin is connected to the GND pin, and the SIG (signal) pin is connected to digital pin 7 on the Arduino.
The Ping ultrasonic range finder is a compact and efficient device designed for distance measurement applications. Its operation is based on the principles of sonar, where it emits a high-frequency sound wave and measures the time taken for the sound wave to reflect off an object and return to the sensor. This capability allows the Ping to accurately measure distances ranging from 2 centimeters to 3 meters, making it suitable for various robotics and automation projects.
In a typical configuration, the Ping sensor is powered by a 5V supply, which is commonly provided by an Arduino board. The GND pin establishes a common ground between the sensor and the Arduino, ensuring proper operation. The SIG pin is the critical interface for communication between the sensor and the Arduino. When the Arduino sends a trigger pulse to the SIG pin, the Ping sensor emits an ultrasonic pulse. The Arduino then listens for the returning echo using the pulseIn() function, which measures the duration of the received signal.
To calculate the distance to the object, the time measured is divided by two (to account for the round trip of the sound wave) and multiplied by the speed of sound in air, which is approximately 343 meters per second at room temperature. This calculated distance can then be used in various applications, such as obstacle avoidance in mobile robots, distance measurement in automation systems, or even simple range-finding tasks in hobby projects.
The integration of the Ping sensor with an Arduino is straightforward, requiring only a few connections and a simple program to handle the timing and calculations. The versatility and ease of use of the Ping ultrasonic range finder make it an ideal choice for both beginners and experienced developers in the field of electronics and robotics.The Ping is an ultrasonic range finder from Parallax. It detects the distance of the closest object in front of the sensor (from 2 cm up to 3m). It works by sending out a burst of ultrasound and listening for the echo when it bounces off of an object. The Arduino board sends a short pulse to trigger the detection, then listens for a pulse on the s ame pin using the pulseIn() function. The duration of this second pulse is equal to the time taken by the ultrasound to travel to the object and back to the sensor. Using the speed of sound, this time can be converted to distance. The 5V pin of the PING) is connected to the 5V pin on the Arduino, the GND pin is connected to the GND pin, and the SIG (signal) pin is connected to digital pin 7 on the Arduino.
Perfect Pitch Circuit
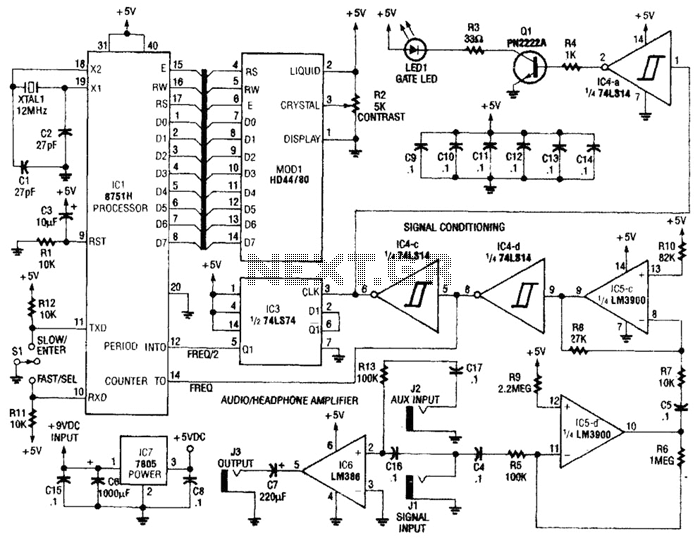
Perfect Pitch, which is based on the 8751 microprocessor, is an affordable and straightforward instrument tuner and frequency counter that features a built-in headphone amplifier and a visual metronome. Perfect Pitch converts the audio signal from an instrument into a...
trigger
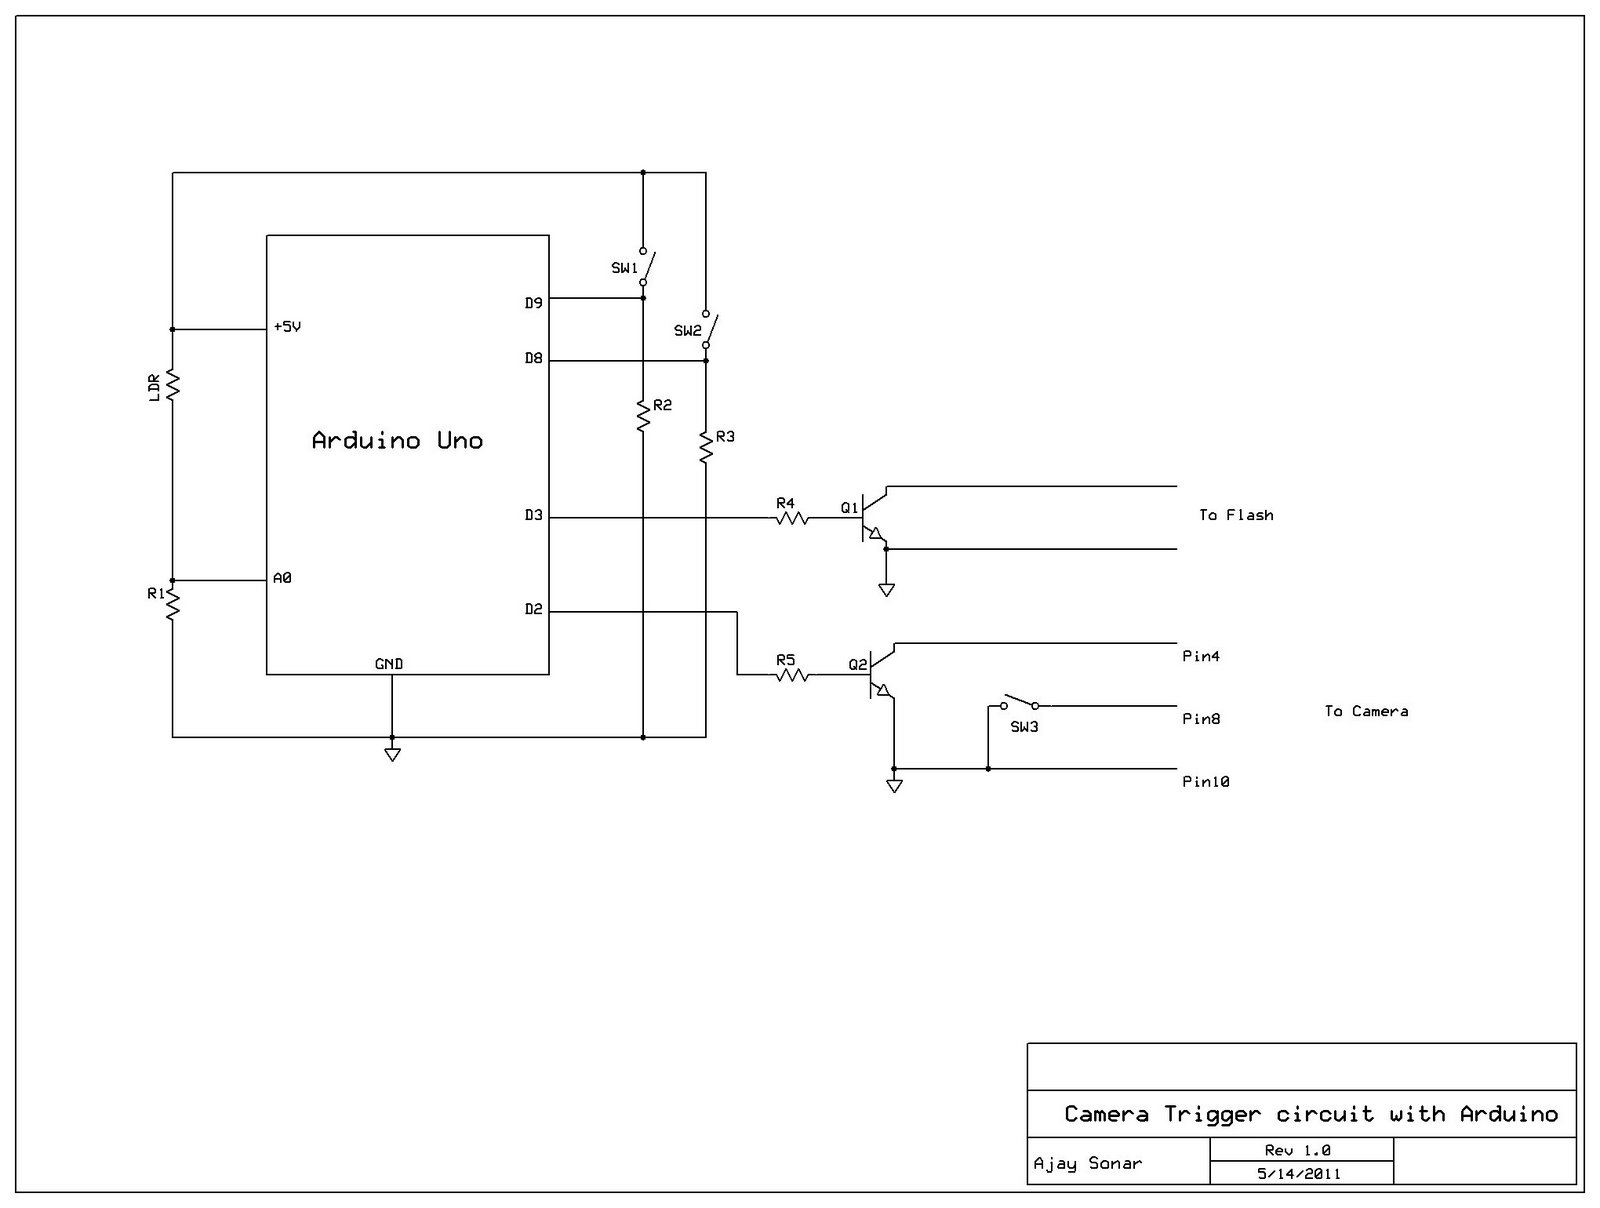
The objective of this project is to establish a system for capturing images of a falling or moving object at a precise moment using a DSLR camera and an Arduino microcontroller. Various methods can be employed to achieve this, but...
arduino Relay takes time to close
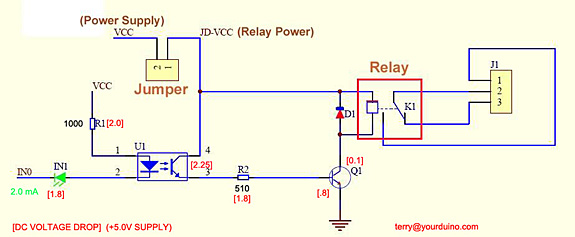
Control a relay from an Arduino-compatible board. When attempting to activate the relay from the Arduino, it takes at least a second to close, and sometimes it does not close at all. Digital pin 2 of the Arduino is connected...
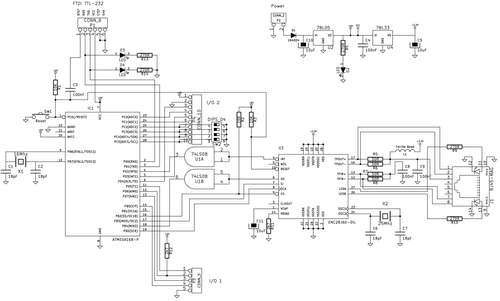
Credit card sized ethernet arduino controller
The Arduino is a user-friendly and versatile controller platform suitable for various projects. Recently, an Ethernet shield was purchased for the Arduino to enable remote control of projects, which proved to be highly effective. This led to the idea of...
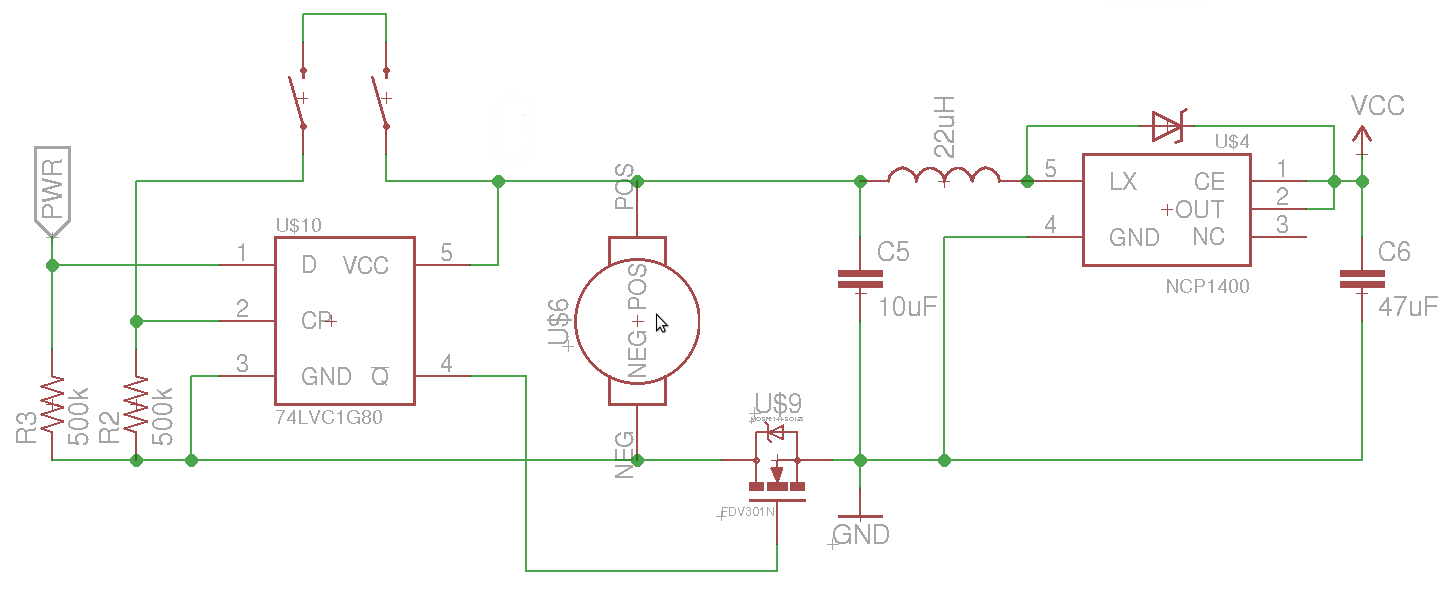
mosfet Turning a microcontroller on with a flip flop
The objective is to control the power to a load, specifically an 8051-based microcontroller (uC), using two switches. When the uC is powered on, it sets the PWR pin high. Upon pressing the switches again, pin 4 of the flip-flop...
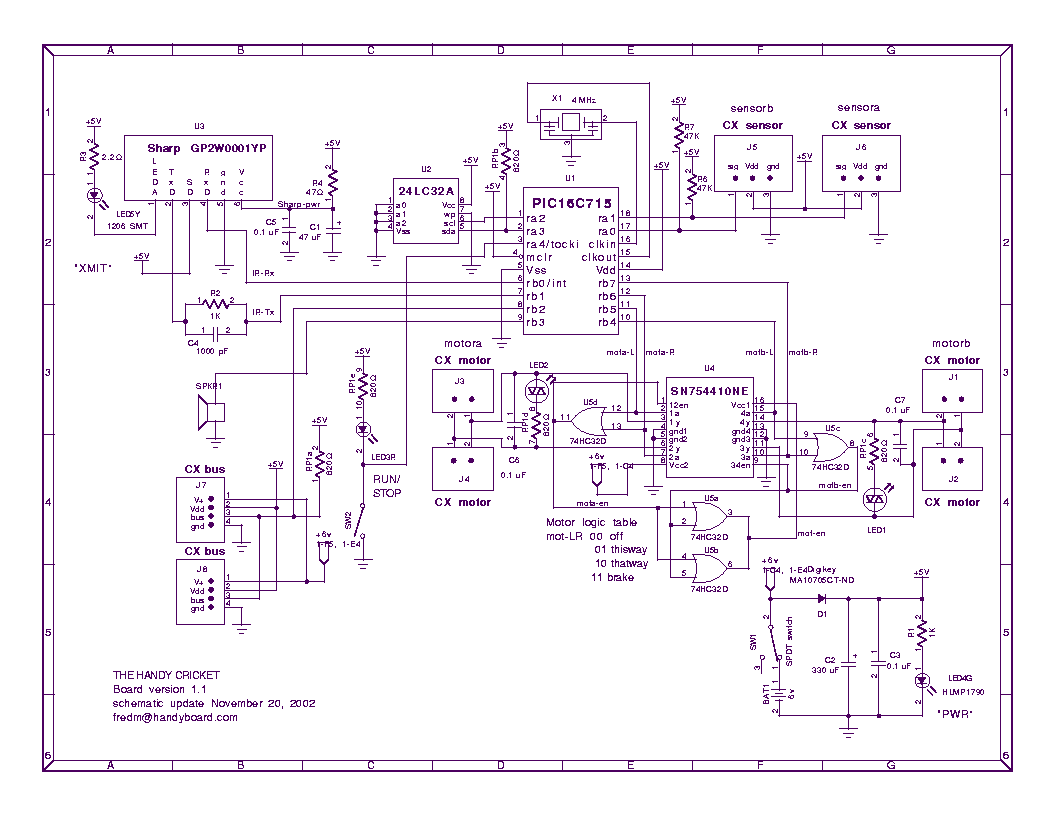
Handy Cricket Hardware Description
This document presents an overview of the hardware design of the Handy Cricket.
The Handy Cricket is a compact electronic device designed for educational and recreational purposes, primarily aimed at children. The hardware design incorporates various components that work together to...
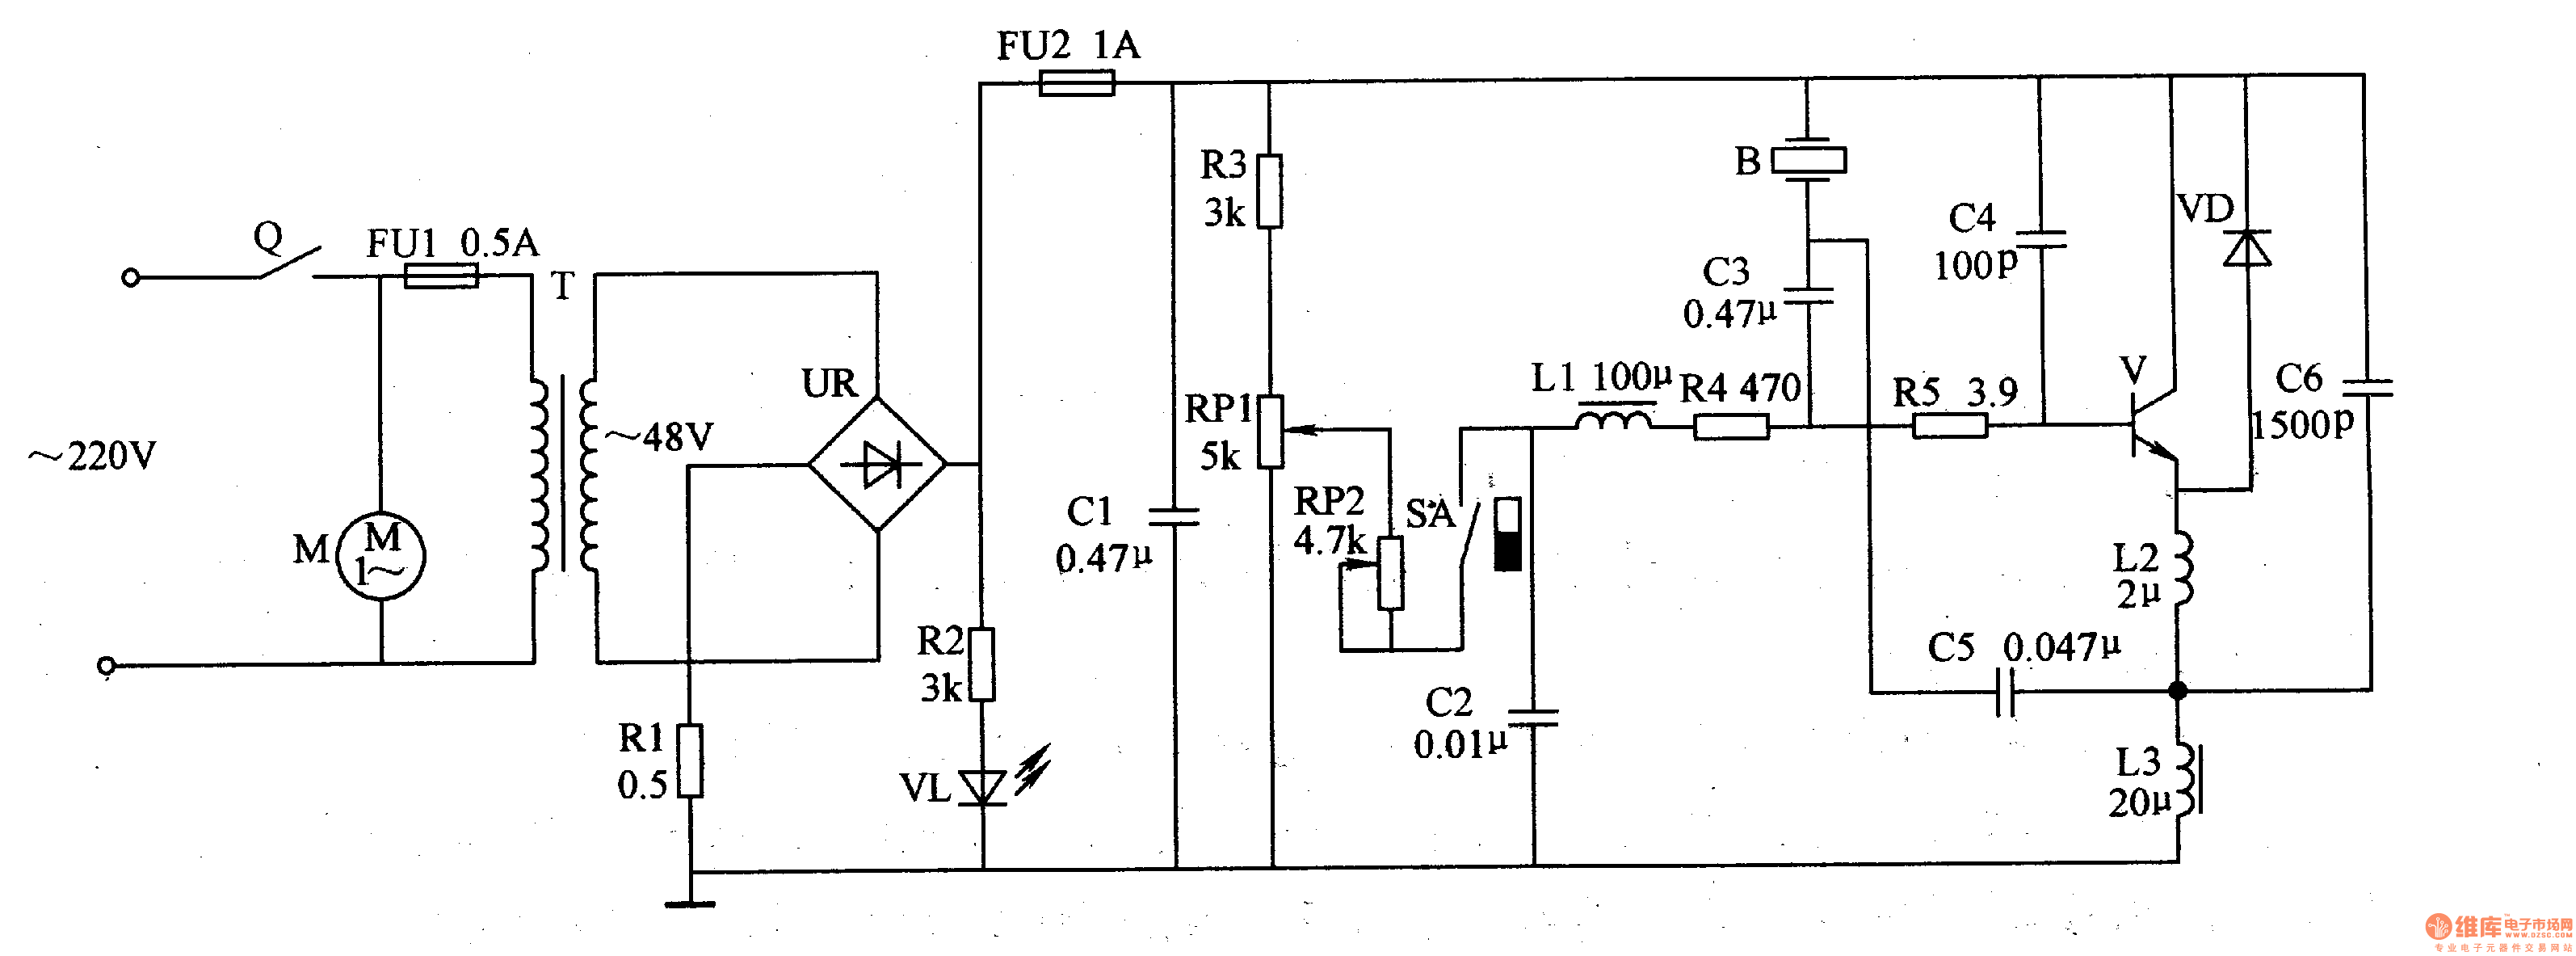
Medical ultrasonic atomizer 2
The medical ultrasonic atomizer circuit consists of a power supply circuit, an atomization amount liquid level detection control circuit, an ultrasonic oscillator, and a fan motor (M). The power supply circuit includes a timer (Q), fuses (FU1, FU2), a power...
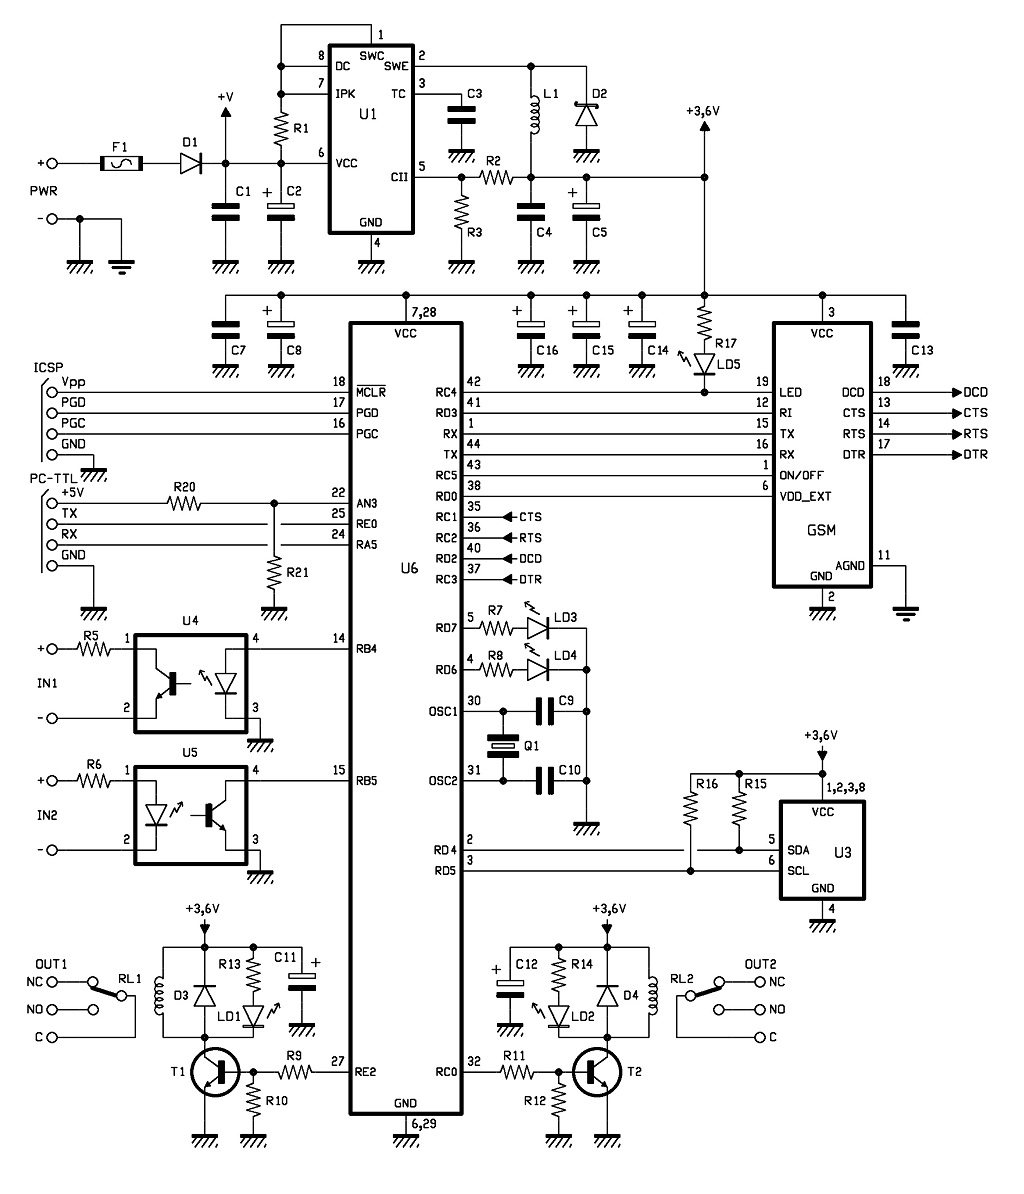
GSM Remote Control 2 IN and 2 OUT Part 2 Schematic
The control of the system is managed by a Microchip PIC18F46K20-I/PT microcontroller, which is programmed with firmware to oversee the activity of the GSM/GPRS module, monitor the logic conditions of two opto-isolated inputs, and send commands to two relays within...
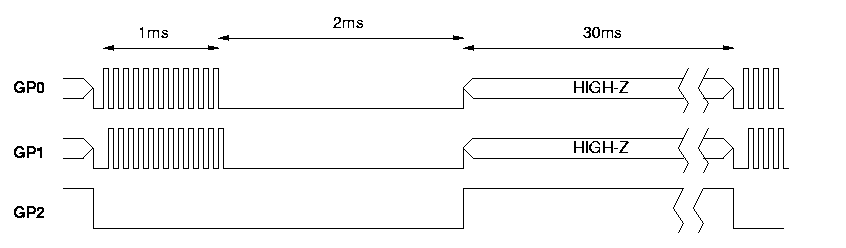
Ultrasonic Range & Imager
The electronic schematic of the homebuilt SONAR utilizes a single piezoelectric transducer for both transmission and reception. This transducer is switched from transmission (TX) to reception (RX) using four 4016 switches. A high-gain amplifier stage and rectifier convert the received...