


Ultrasonic Range & Imager
#ultrasonic
#PIC12C508
#transducer
#amplifier
#rectifier
#4016 switches
#range finder
#SONAR
#echo detection
#timing control
Description: The electronic schematic of the homebuilt SONAR utilizes a single piezoelectric transducer for both transmission and reception. This transducer is switched from transmission (TX) to reception (RX) using four 4016 switches. A high-gain amplifier stage and rectifier convert the received echoes into voltage pulses. The timing is managed by the PIC12C508 8-pin microcontroller, as illustrated in the accompanying figure. The SONAR system interfaces with an analog input on a 68HC11 prototype board. Echoes are sampled at approximately 18 kHz with an 8-bit resolution. The captured data reveals that the initial decay is a result of residual transducer oscillation, which limits the minimum range of the SONAR to around 50 cm. The peak observed around sample 230 corresponds to an echo from a wall located 2.5 meters away from the SONAR. The subsequent graph demonstrates the echo from a nearby obstacle. Two successive scans are presented; the SONAR was mechanically scanned using a stepper motor controlled by the 68HC11. The transmitted beam was also focused through a paper horn, resulting in a significant reduction in beam divergence. However, this introduced a new challenge: a considerable portion of the ultrasonic power is reflected back, leading to unwanted echoes that can be misinterpreted at short ranges. The following graph displays the results obtained with the lens, where close echoes on the left represent back echoes, while distant echoes show improved resolution.
The SONAR system operates by alternating the function of the piezoelectric transducer, allowing it to emit ultrasonic waves and subsequently listen for echoes. The four 4016 analog switches facilitate this switching process, ensuring that the transducer can rapidly toggle between TX and RX modes without significant delay. The high-gain amplifier stage is crucial for amplifying the weak signals received from distant objects, enabling the detection of echoes that may otherwise be too faint to discern. The rectifier converts these amplified signals into a usable voltage form for further processing.
The PIC12C508 microcontroller plays a vital role in managing the timing and control of the entire SONAR system. By executing programmed instructions, it ensures that the sampling rate of 18 kHz is maintained, allowing for accurate capture and processing of the echo data. The 68HC11 prototype board serves as the primary interface for data acquisition, where the analog input channel receives the voltage pulses corresponding to the detected echoes.
The mechanical scanning of the SONAR is facilitated by a stepper motor, which allows for precise angular movements and thus broadens the detection area. The use of a paper horn to focus the ultrasonic beam enhances the system's directionality, reducing beam divergence and improving the resolution of distant objects. However, the trade-off is an increase in back reflections, which complicates the interpretation of close-range echoes. This phenomenon illustrates the challenges faced in SONAR design, where optimizing for one parameter can adversely affect another.
Overall, the described SONAR system demonstrates an innovative approach to distance measurement and object detection using a combination of analog and digital technologies, showcasing the intricate balance between various design elements to achieve effective performance.This is the electronic schematic of the homebuilt SONAR. Only one piezoelectric transducer is used for both transmit & receive. This transducer is switched from TX to RX via the four 4016 switches. A high gain amplifier stage & rectifier translates the received echoes into voltage pulses. The timing is controlled by the PIC12C508 8-pin microcontro ller as it is shown in the following figure: The SONAR system is connected to an analog input of a 68HC11 prototype board. The echoes are sampled at about 18KHz, with 8 bit resolution. The captured data looks like this: The starting decay is due to the residual transducer oscillation. This decay limits the minimum range of the SONAR to about 50 cm. The peak around sample 230 is due to a wall echo. The wall was located 2. 5m away from the SONAR. The next graph shows the echo of a close obstacle (me :) Two successive scans are shown: Then, the SONAR was mechanically scanned with the help of an stepper motor controlled by the 68HC11.
The transmitted beam was also focused through a paper horn. The results were: With the use of this lens the beam divergence was greatly reduced, but another problem arises: a notable fraction of the ultrasonic power is reflected back, causing undesired echoes that can be misinterpreted in the short range. The following graph shows the results obtained with the lens. The close echoes in the left are in fact back echoes. In the other hand, the distant echoes are a lot better resolved.
The SONAR system operates by alternating the function of the piezoelectric transducer, allowing it to emit ultrasonic waves and subsequently listen for echoes. The four 4016 analog switches facilitate this switching process, ensuring that the transducer can rapidly toggle between TX and RX modes without significant delay. The high-gain amplifier stage is crucial for amplifying the weak signals received from distant objects, enabling the detection of echoes that may otherwise be too faint to discern. The rectifier converts these amplified signals into a usable voltage form for further processing.
The PIC12C508 microcontroller plays a vital role in managing the timing and control of the entire SONAR system. By executing programmed instructions, it ensures that the sampling rate of 18 kHz is maintained, allowing for accurate capture and processing of the echo data. The 68HC11 prototype board serves as the primary interface for data acquisition, where the analog input channel receives the voltage pulses corresponding to the detected echoes.
The mechanical scanning of the SONAR is facilitated by a stepper motor, which allows for precise angular movements and thus broadens the detection area. The use of a paper horn to focus the ultrasonic beam enhances the system's directionality, reducing beam divergence and improving the resolution of distant objects. However, the trade-off is an increase in back reflections, which complicates the interpretation of close-range echoes. This phenomenon illustrates the challenges faced in SONAR design, where optimizing for one parameter can adversely affect another.
Overall, the described SONAR system demonstrates an innovative approach to distance measurement and object detection using a combination of analog and digital technologies, showcasing the intricate balance between various design elements to achieve effective performance.This is the electronic schematic of the homebuilt SONAR. Only one piezoelectric transducer is used for both transmit & receive. This transducer is switched from TX to RX via the four 4016 switches. A high gain amplifier stage & rectifier translates the received echoes into voltage pulses. The timing is controlled by the PIC12C508 8-pin microcontro ller as it is shown in the following figure: The SONAR system is connected to an analog input of a 68HC11 prototype board. The echoes are sampled at about 18KHz, with 8 bit resolution. The captured data looks like this: The starting decay is due to the residual transducer oscillation. This decay limits the minimum range of the SONAR to about 50 cm. The peak around sample 230 is due to a wall echo. The wall was located 2. 5m away from the SONAR. The next graph shows the echo of a close obstacle (me :) Two successive scans are shown: Then, the SONAR was mechanically scanned with the help of an stepper motor controlled by the 68HC11.
The transmitted beam was also focused through a paper horn. The results were: With the use of this lens the beam divergence was greatly reduced, but another problem arises: a notable fraction of the ultrasonic power is reflected back, causing undesired echoes that can be misinterpreted in the short range. The following graph shows the results obtained with the lens. The close echoes in the left are in fact back echoes. In the other hand, the distant echoes are a lot better resolved.
Ultrasonic ranging
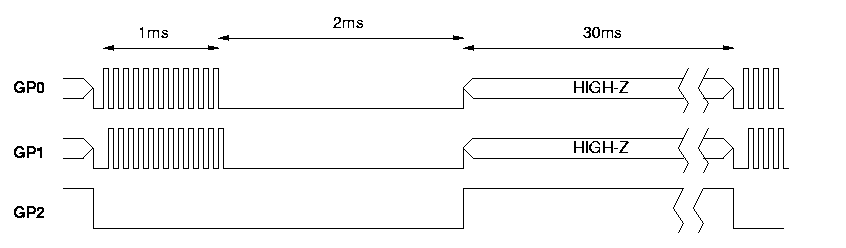
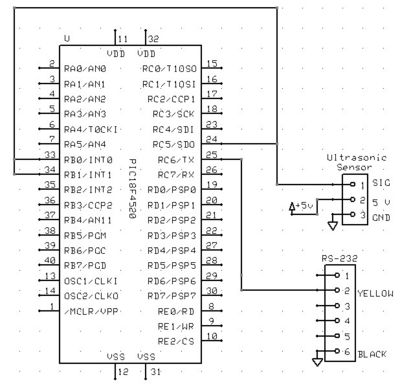
The Ping Ultrasonic Distance Sensor by Parallax features three pins: +5V, I/O, and Ground. To activate the sensor, a 5-microsecond 5V signal must be sent to the I/O pin. Following this, the sensor waits 750 microseconds before emitting an ultrasonic...
remote control and Intruder detector
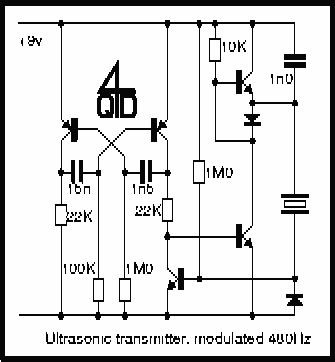
These ultrasonic circuits are all quite old: my notes date them at mid-70s so they don’t use ICs. Nevertheless there are several places where an op-amp would possibly simplify things. Despite their age I hope they are of interest: certainly...
Ultrasonic Surveillance Bug circuit
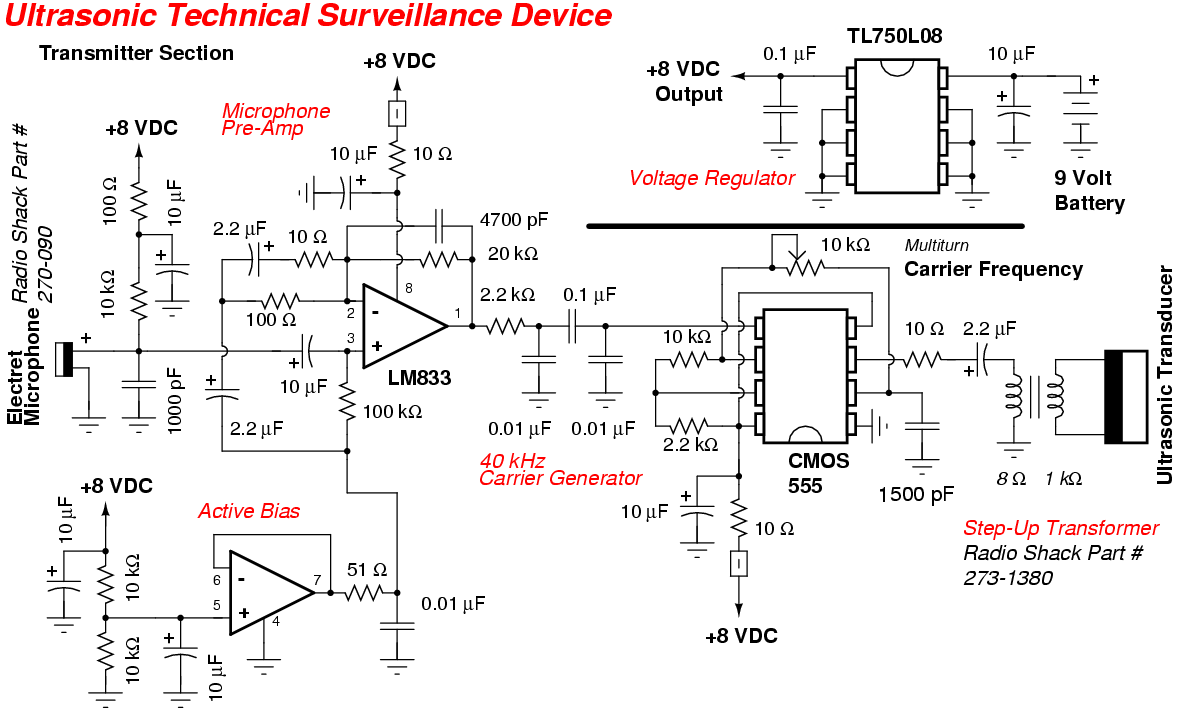
The file being accessed no longer exists. It may have been renamed or removed from the archive. Navigation links are available on the left to browse the desired area of the archive. The connection is to cdn.preterhuman.net, which mirrors the...
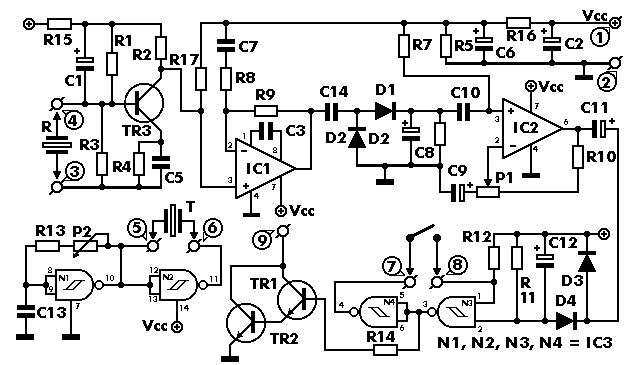
UltraSonic Radar
This project has numerous practical applications in security and alarm systems for homes, shops, and vehicles. It consists of a set of ultrasonic receivers and transmitters operating at the same frequency. When movement occurs in the area monitored by the...
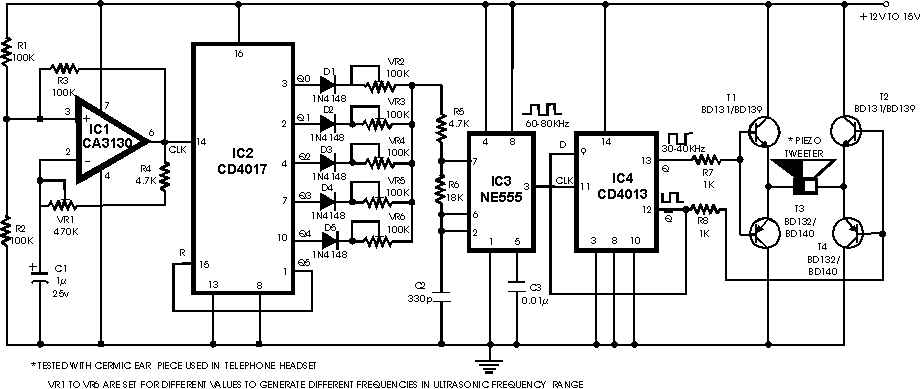
Electronic Pest Repellent Circuit
There are many ultrasonic pest repellent devices available on the market, but a major drawback is that their power output is low and their effectiveness suffers.
Ultrasonic pest repellent devices utilize high-frequency sound waves to deter pests such as rodents and...
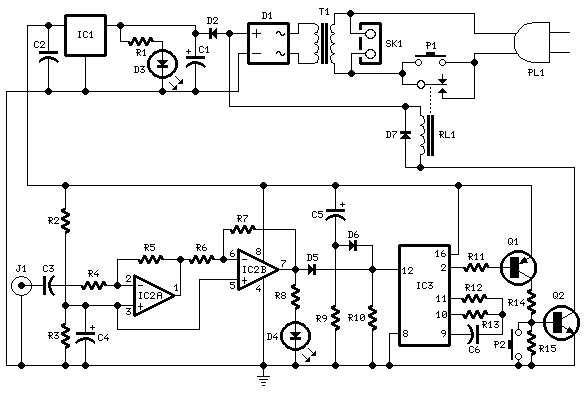
Amplifier Timer
This circuit turns off an amplifier or any other device when a low-level audio signal fed to its input is absent for 15 minutes at least. Pushing P1, the device is switched on, feeding any appliance connected to SK1. Input...
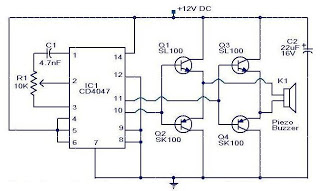
circuit ultrasonic mosquito
This is a small circuit designed as an insect repellent, targeting mosquitoes and birds by producing high-frequency audio signals. These signals interfere with the hearing of insects, making it unbearable for them, causing them to flee. The operation of this...
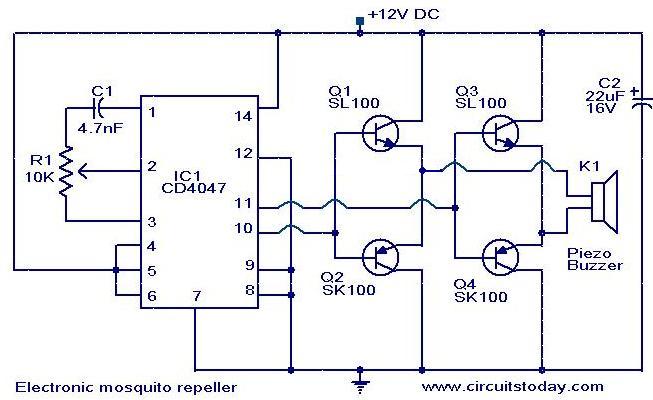
Electronic mosquito repeller
The circuit diagram of an ultrasonic mosquito repeller is based on the principle that insects, such as mosquitoes, can be repelled using sound frequencies in the ultrasonic range (above 20 kHz). The circuit utilizes a CMOS 4047 PLL IC configured...
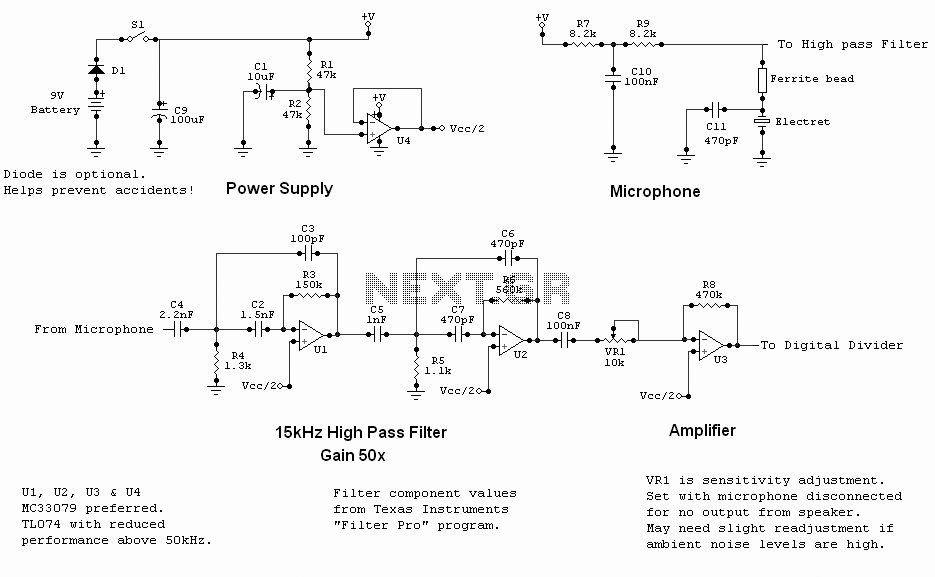
Ultrasonic / Bat detector
I have found this circuit to have better sensitivity, both in distance to a visible bat and in audio frequency, than some other published circuits using a 40kHz transducer with 4000x gain amplification, though the 40kHz transducer I used for...