


Xbee Wireless Servo Motor Control Circuit
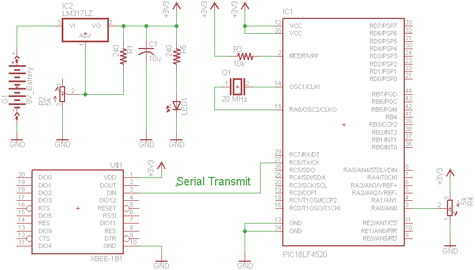
Description: There are two schematics to examine for constructing a transmitter/receiver system. The first schematic is the transmitter, featuring a variable trimpot connected to RA0. The trimpot's value will be transmitted from the Tx pin of the PIC to the Din pin of the Xbee module for wireless signal transmission. The receiver circuit will receive the transmitted signal through the Xbee module, from the Dout pin to the PIC's Rx pin. The receiving PIC will interpret the data into movement coordinates for a servo motor. The input to the PIC will come from the output of a standard trimpot. The trimpot is connected to power and ground, with the middle pin providing a variable voltage to the PIC's A/D converter on pin RA0. The PIC will convert this input into an integer value ranging from 0 to 50, which will be sent via the PIC's serial communication module at 9600 BPS to the Din pin of the Xbee. Once the serial data is received by the PIC, it will use the dynamic integer value to set the delay cycle for generating a PWM output to control the servo motor. Each integer value from 0 to 50 corresponds to a specific position for the motor. The Xbee receiver will automatically connect to the transmitter and start receiving data. All data will be transmitted and output through the Dout pin on the Xbee module, which is directly connected to the PIC's Rx pin to facilitate data reception.
The transmitter circuit consists of a PIC microcontroller that utilizes a trimpot to provide an adjustable voltage input to its analog-to-digital (A/D) converter on pin RA0. The trimpot is configured such that its outer pins are connected to the power supply and ground, while the central pin outputs a variable voltage based on the trimpot's position. The A/D converter digitizes this voltage into an integer value ranging from 0 to 50. This digitized value is then transmitted via the PIC's UART (Universal Asynchronous Receiver-Transmitter) at a baud rate of 9600 BPS to the Din pin of the Xbee module, which is responsible for wireless communication.
On the receiving end, the Xbee module captures the transmitted data through its Dout pin, which is directly connected to the Rx pin of another PIC microcontroller. The receiving PIC decodes the incoming serial data and translates it into movement coordinates for a servo motor. The integer value received is utilized to adjust the PWM signal that controls the position of the servo motor, enabling precise movement based on the input from the trimpot.
The design allows for seamless communication between the transmitter and receiver using Xbee modules, which are known for their robust wireless capabilities. The automatic connection feature of the Xbee ensures that once powered on, the receiver will initiate communication with the transmitter without requiring additional configuration. This setup is ideal for applications requiring remote control of servo motors based on variable input signals.There are two schematics that we`ll look at to see how to build this transmitter/receiver system. The first one is the transmitter, with a variable trimpot input into RA0. The trimpot value will be sent out of the Tx pin of the PIC and to the Din pin of the Xbee module to send the signal wirelessly. The receiver circuit, will receieve the transmitted signal through the Xbee module, out of the Dout pin and to the PIC`s Rx pin. The receiving PIC will then translate the data to movement coordinates for the servo motor. The input we will give to the PIC`s will come from a standard trimpot`s output. The trimpot is tied to power and ground, with the middle pin being a variable voltage send to the PIC`s A/D converter on pin RA0. The PIC will then translate this input to an integer of value 0-50 and send it via the PIC`s serial communication module at 9600 BPS to the Xbee`s Din pin.
After the serial data is receieved by the PIC, it will put the dynamic integer value into the the delay cycle that is creating a PWM output to control the servo motor. Each specific value of 0 to 50 correlates to a specific location that the motor can move to. The Xbee receiver will automatically connect with the transmitter and begin receiving data. All data will be receiving and output via the Dout pin on the Xbee module. The Dout pin is conneceted directly to the PIC`s Rx pin so that the PIC can catch the data.
The transmitter circuit consists of a PIC microcontroller that utilizes a trimpot to provide an adjustable voltage input to its analog-to-digital (A/D) converter on pin RA0. The trimpot is configured such that its outer pins are connected to the power supply and ground, while the central pin outputs a variable voltage based on the trimpot's position. The A/D converter digitizes this voltage into an integer value ranging from 0 to 50. This digitized value is then transmitted via the PIC's UART (Universal Asynchronous Receiver-Transmitter) at a baud rate of 9600 BPS to the Din pin of the Xbee module, which is responsible for wireless communication.
On the receiving end, the Xbee module captures the transmitted data through its Dout pin, which is directly connected to the Rx pin of another PIC microcontroller. The receiving PIC decodes the incoming serial data and translates it into movement coordinates for a servo motor. The integer value received is utilized to adjust the PWM signal that controls the position of the servo motor, enabling precise movement based on the input from the trimpot.
The design allows for seamless communication between the transmitter and receiver using Xbee modules, which are known for their robust wireless capabilities. The automatic connection feature of the Xbee ensures that once powered on, the receiver will initiate communication with the transmitter without requiring additional configuration. This setup is ideal for applications requiring remote control of servo motors based on variable input signals.There are two schematics that we`ll look at to see how to build this transmitter/receiver system. The first one is the transmitter, with a variable trimpot input into RA0. The trimpot value will be sent out of the Tx pin of the PIC and to the Din pin of the Xbee module to send the signal wirelessly. The receiver circuit, will receieve the transmitted signal through the Xbee module, out of the Dout pin and to the PIC`s Rx pin. The receiving PIC will then translate the data to movement coordinates for the servo motor. The input we will give to the PIC`s will come from a standard trimpot`s output. The trimpot is tied to power and ground, with the middle pin being a variable voltage send to the PIC`s A/D converter on pin RA0. The PIC will then translate this input to an integer of value 0-50 and send it via the PIC`s serial communication module at 9600 BPS to the Xbee`s Din pin.
After the serial data is receieved by the PIC, it will put the dynamic integer value into the the delay cycle that is creating a PWM output to control the servo motor. Each specific value of 0 to 50 correlates to a specific location that the motor can move to. The Xbee receiver will automatically connect with the transmitter and begin receiving data. All data will be receiving and output via the Dout pin on the Xbee module. The Dout pin is conneceted directly to the PIC`s Rx pin so that the PIC can catch the data.
pic LM032
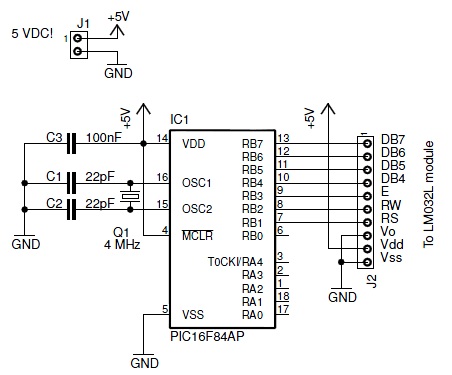
This document discusses an older LM032L LCD module from Hitachi. It details the process of making the module operational with a PIC 16F84A microcontroller. The module is capable of displaying two lines with 20 characters each. The initial step involved...
pic icsp
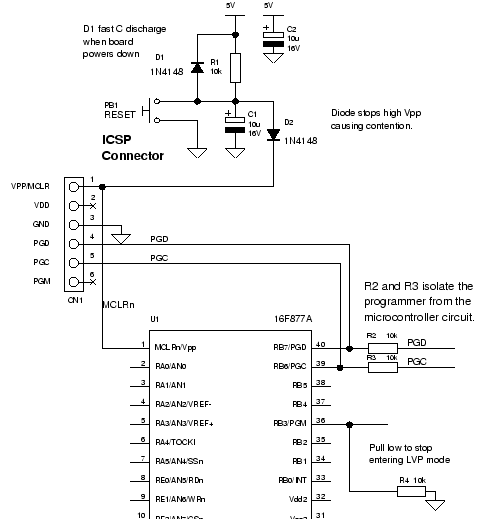
The connections made in this order on the connector ensure that it does not matter if the connector is inserted incorrectly, as GND and VCC are applied to the clock and data. If VCC and GND were located at opposite...
Remote Control Transmitter Circuit
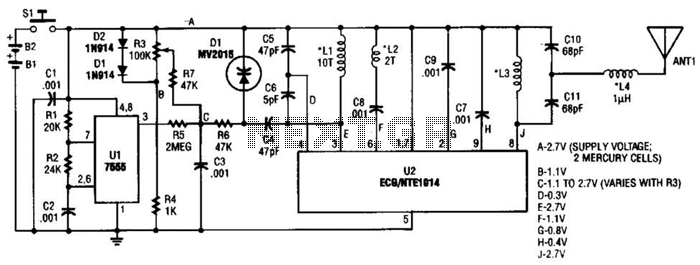
This transmitter can be utilized for multiple applications. An INS8048L microprocessor produces various codes based on keypad inputs. These codes are modulated onto a 40-kHz carrier frequency. Additionally, Q1 drives infrared LEDs LED1 and LED2.
The transmitter circuit primarily consists of...
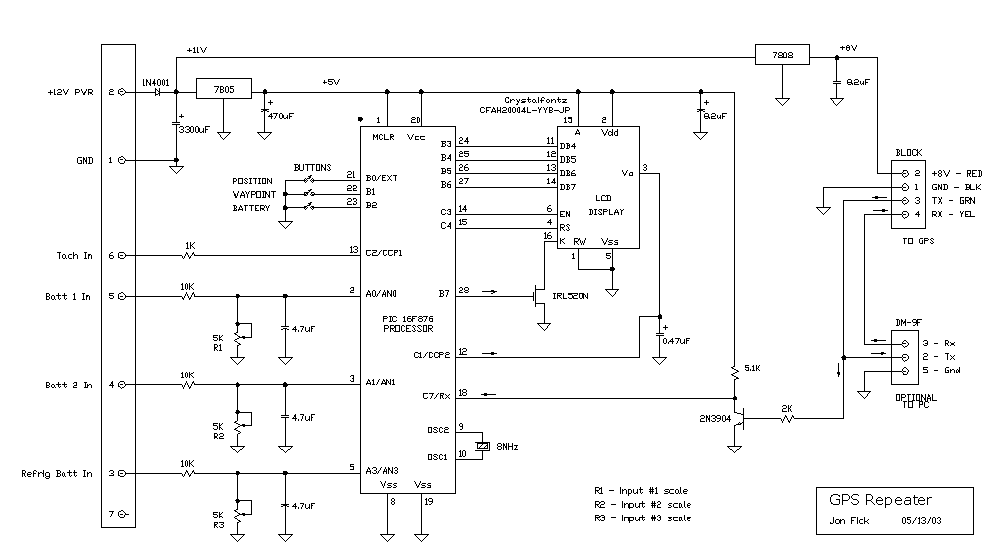
PIC-based applications from Westford MicroSystems descriptions C source code and schematics
PIC C Compilers are utilized to compile source code, leveraging the extensive built-in functions offered by these compilers. A single C statement can produce multiple pages of PIC RISC instructions, eliminating the need for manual coding. CCS charges $125 for...
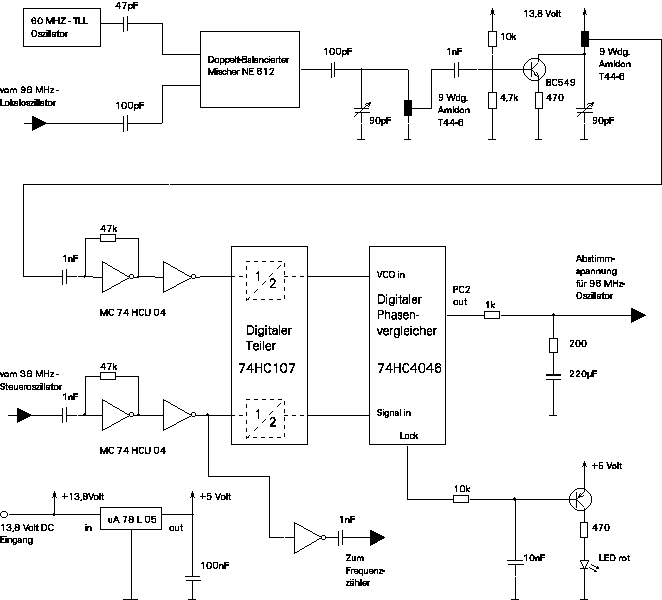
Circuit diagramms of the 144 SBB/RX - Receiver
To comprehend the interconnections between the following circuits, it is essential to first review the concept chapter. It is at the discretion of the user to select one or two of these circuits for personal development. The discussion begins with...
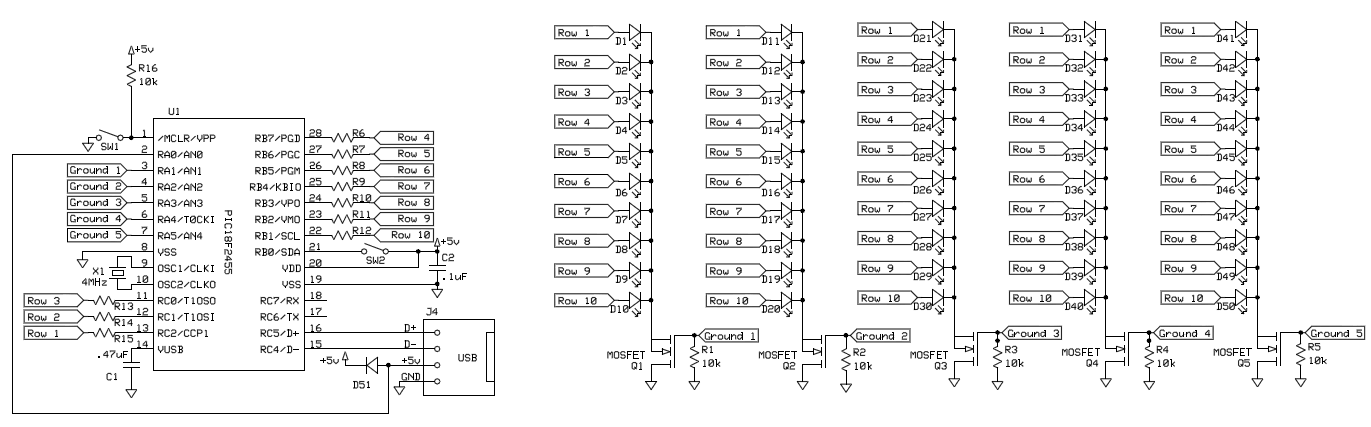
LED control system for 40 LEDs using a single PIC
To control 40 LEDs using a single PIC 18F2455 microcontroller, the LEDs were organized into a configuration of four columns, each containing 10 rows of LEDs. Each LED in a column was connected to a separate pin on the PIC....
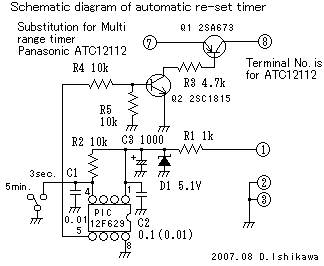
Production of automatic re-set timer for crime prevention buzzer that uses PIC
The crime prevention bell device produced approximately 20 years ago remains in active service. It has effectively deterred thieves on multiple occasions by triggering an alarm as they attempt to enter. The bell continues to ring, functioning as a crime...
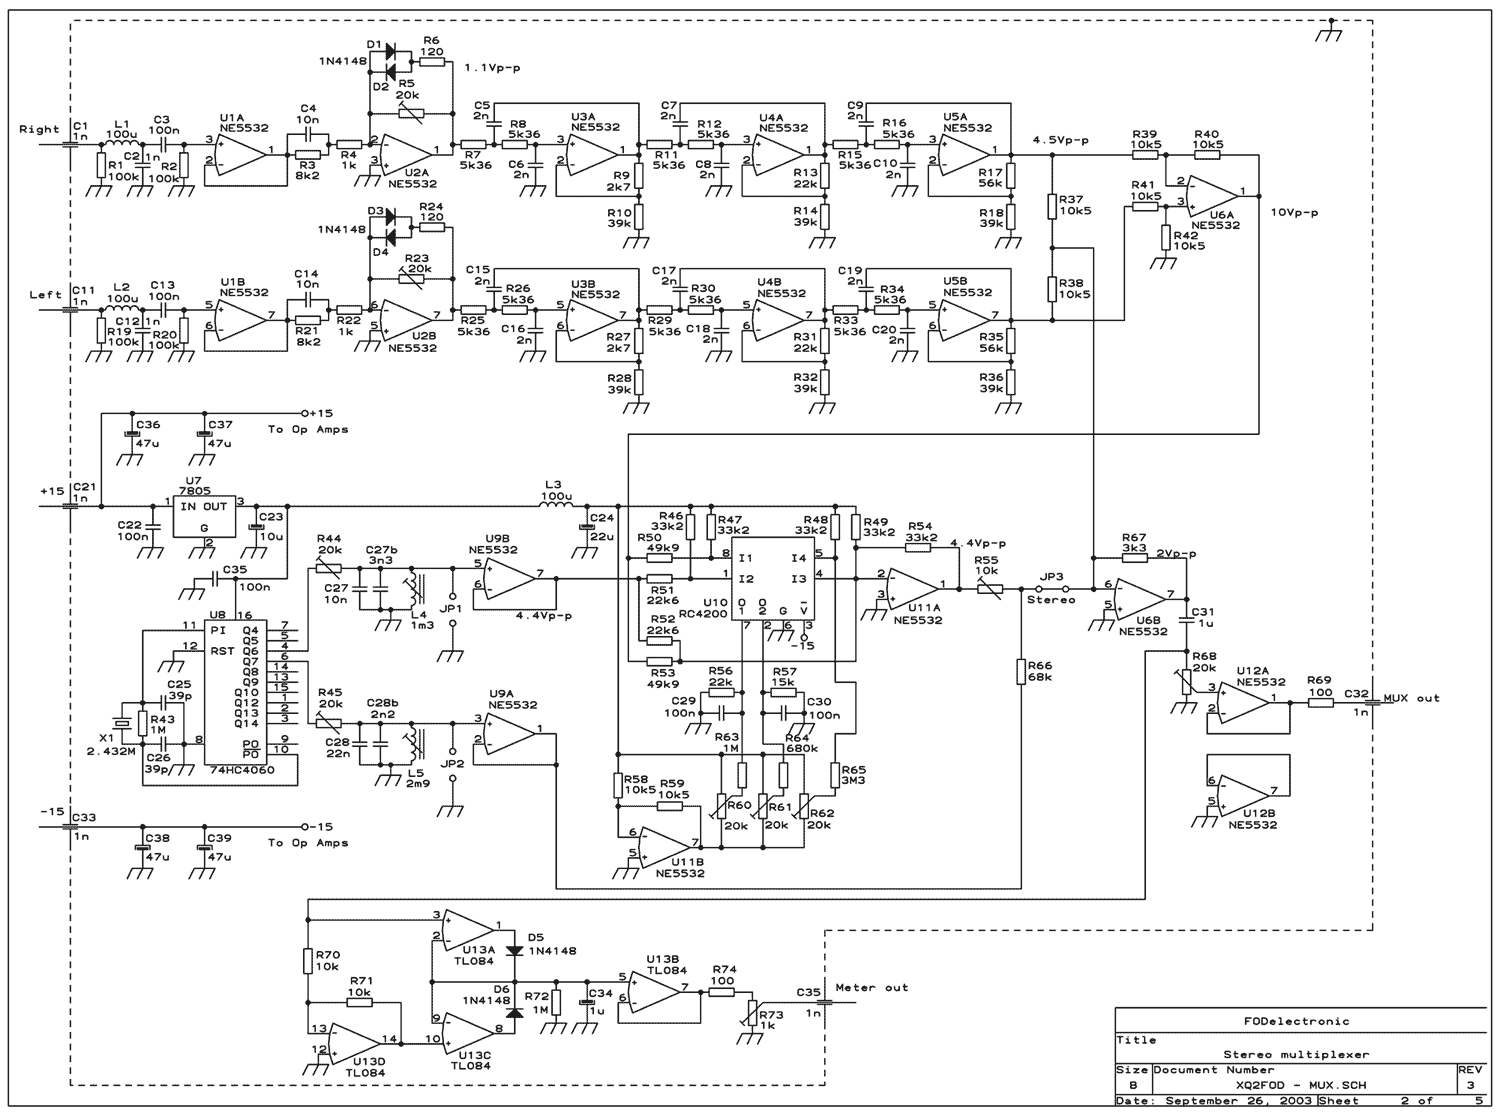
80 Watt stereo transmitter
This transmitter was designed from the ground up to provide very high sound quality, coupled with excellent frequency stability, reliability, etc. It can be used as a standalone transmitter to serve a medium-sized town, or as an exciter to drive...
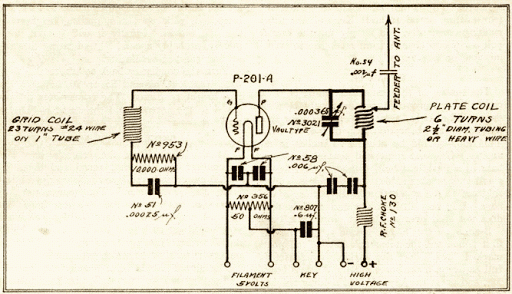
Telegraph Transmitter in the Pilot Radios Radio Design magazine 1930s
The TPTG transmitter has been transformed into a modern TNT model. This transmitter can utilize the existing K-111 power pack for both the transmitter and receiver, eliminating the need for a separate power supply unit. Building this compact transmitter allows...