


servo tester using 4538
#servo tester
#4538
#pulse generator
#modeling
#servo control
#pulse width modulation
#DIY
#electronics
#hobbyist
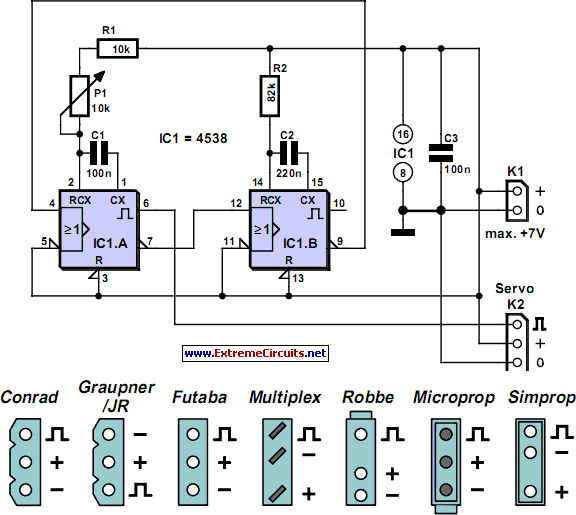
Description: A small servo tester for modeling can be very useful in various situations for those who frequently work with servos. The primary function of a servo tester is to produce a pulsing signal with a positive pulse width that can be varied between 1 and 2 milliseconds. This pulse width determines the position to which the servo should move. The signal must repeat continuously, with a frequency ranging from approximately 40 to 60 Hz. Typically, circuits of this nature utilize an NE555 timer or its derivatives to generate the pulses; however, this design employs a 4538 IC for variety. The 4538 contains two astable multivibrators, and the circuit diagram indicates that few additional components are necessary beyond the 4538. The astable multivibrator in the 4538 can be activated in two ways: when input I0 (pins 5 or 11) is high, a rising edge on input I1 (pins 4 or 12) serves as the start signal for pulse generation. The pulse width at the output of IC1a is calculated as (R1 + P1) × C1. When the potentiometer P1 is set to its minimum resistance, the pulse width will be 1 ms (10 kΩ × 100 nF). Conversely, when P1 is adjusted to its maximum (10 kΩ), the pulse width increases to 2 ms (20 kΩ × 100 nF). At the conclusion of this pulse, the inverting output Q generates a rising edge, which triggers IC1b to produce a pulse with a width of 18 ms (82 kΩ × 220 nF). Following this pulse, the Q output also generates a rising edge, prompting IC1a to generate another pulse, thus completing the cycle. Depending on the setting of P1, the total period ranges between 19 and 20 ms, corresponding to a frequency of approximately 50 to 53 Hz, which is well within the acceptable frequency range.
The servo tester circuit utilizing the 4538 integrated circuit is designed to provide reliable control of servo motors by generating precise pulse-width modulation (PWM) signals. The circuit architecture consists of a 4538 dual astable multivibrator, which is configured to produce a continuous square wave output. The frequency and duty cycle of this output are adjustable through the use of a potentiometer (P1) and fixed resistors (R1) in conjunction with a timing capacitor (C1).
In this configuration, the output pulse width is directly influenced by the resistance values selected. By varying the resistance of the potentiometer, the user can fine-tune the pulse width to achieve the desired servo position, allowing for precise control over the servo's movement. The output from the first multivibrator (IC1a) triggers the second multivibrator (IC1b), creating a feedback loop that maintains the oscillation of the signal. The calculated total period of the output signal ensures that the servo tester operates within the specified frequency range, making it suitable for a variety of servo applications.
The simplicity of the circuit design, requiring minimal external components, contributes to its effectiveness and ease of use. This makes the servo tester an invaluable tool for hobbyists and professionals alike, enabling them to test and calibrate servo motors efficiently. Additionally, the use of the 4538 IC, with its dual multivibrator capability, provides a unique alternative to more commonly used timer ICs, showcasing versatility in circuit design and functionality.There are times when a small servo tester for modeling comes in very useful. Everybody who regularly works with servos will know several instances when such a servo tester will come in handy. The function of a servo tester is to generate a pulsing signal where the width of the positive pulse can be varied between 1 and 2 ms.
This pulse-width deter mines the position the servo should move to. The signal has to repeat itself continuously, with a frequency of about 40 to 60 Hz. These circuits often use an NE555 or one of its derivatives to generate the pulses. This time we have used a 4538 for variety. This IC contains two astable multi-vibrators. You can see from the circuit diagram that not many other components are required besides the 4538. The astable multi-vibrator in a 4538 can be started in two ways. When input I 0 (pin 5 or 11) is high, a rising edge on input I 1 (pin 4 or 12) is the start signal to generate a pulse. The pulse-width at the output of IC1a is equal to (R1+P1)G—C1. This means that when potentiometer P1 is turned to its minimum resistance, the pulse-width will be 10 k G— 100 n = 1 ms.
When P1 is set to maximum (10 k), the pulse-width becomes 20 k G— 100 n = 2 ms. At the end of this pulse inverting output Q generates a rising edge. This edge triggers IC1. B, which then generates a pulse. The pulse-width here is 82 k G— 220 n 18 ms. At the end of this pulse the Q output will also generate a rising edge. This in turn makes IC1. A generate a pulse again. This completes the circle. Depending on P1, the total period is between 19 and 20 ms. This corresponds to a frequency of about 50 to 53 Hz and is therefore well within the permitted frequency range.
The servo tester circuit utilizing the 4538 integrated circuit is designed to provide reliable control of servo motors by generating precise pulse-width modulation (PWM) signals. The circuit architecture consists of a 4538 dual astable multivibrator, which is configured to produce a continuous square wave output. The frequency and duty cycle of this output are adjustable through the use of a potentiometer (P1) and fixed resistors (R1) in conjunction with a timing capacitor (C1).
In this configuration, the output pulse width is directly influenced by the resistance values selected. By varying the resistance of the potentiometer, the user can fine-tune the pulse width to achieve the desired servo position, allowing for precise control over the servo's movement. The output from the first multivibrator (IC1a) triggers the second multivibrator (IC1b), creating a feedback loop that maintains the oscillation of the signal. The calculated total period of the output signal ensures that the servo tester operates within the specified frequency range, making it suitable for a variety of servo applications.
The simplicity of the circuit design, requiring minimal external components, contributes to its effectiveness and ease of use. This makes the servo tester an invaluable tool for hobbyists and professionals alike, enabling them to test and calibrate servo motors efficiently. Additionally, the use of the 4538 IC, with its dual multivibrator capability, provides a unique alternative to more commonly used timer ICs, showcasing versatility in circuit design and functionality.There are times when a small servo tester for modeling comes in very useful. Everybody who regularly works with servos will know several instances when such a servo tester will come in handy. The function of a servo tester is to generate a pulsing signal where the width of the positive pulse can be varied between 1 and 2 ms.
This pulse-width deter mines the position the servo should move to. The signal has to repeat itself continuously, with a frequency of about 40 to 60 Hz. These circuits often use an NE555 or one of its derivatives to generate the pulses. This time we have used a 4538 for variety. This IC contains two astable multi-vibrators. You can see from the circuit diagram that not many other components are required besides the 4538. The astable multi-vibrator in a 4538 can be started in two ways. When input I 0 (pin 5 or 11) is high, a rising edge on input I 1 (pin 4 or 12) is the start signal to generate a pulse. The pulse-width at the output of IC1a is equal to (R1+P1)G—C1. This means that when potentiometer P1 is turned to its minimum resistance, the pulse-width will be 10 k G— 100 n = 1 ms.
When P1 is set to maximum (10 k), the pulse-width becomes 20 k G— 100 n = 2 ms. At the end of this pulse inverting output Q generates a rising edge. This edge triggers IC1. B, which then generates a pulse. The pulse-width here is 82 k G— 220 n 18 ms. At the end of this pulse the Q output will also generate a rising edge. This in turn makes IC1. A generate a pulse again. This completes the circle. Depending on P1, the total period is between 19 and 20 ms. This corresponds to a frequency of about 50 to 53 Hz and is therefore well within the permitted frequency range.
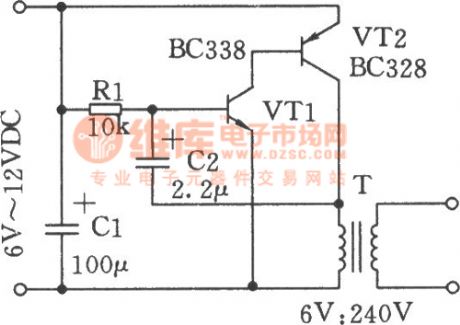
Pulse Signal Generator
The volt-ampere characteristics of a tunnel diode exhibit an S-shaped curve. The peak current point, referred to as point P, represents the maximum current, while the valley point, denoted as point V, indicates the minimum current. Key parameters of the...
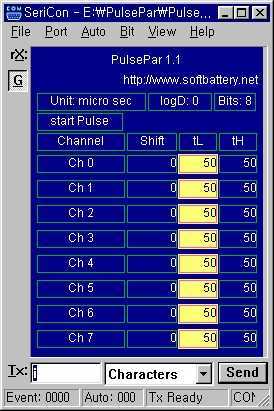
Turn an old PC into a multi-channel pulse generator, for PWM/servo/stepper
PulsePar turns a PC into a multi-channel pulse generator utilizing the parallel port. The period, duty and phase of each channel are adjustable so as to be used in PWM systems as well as in testing servo and stepper (stepping)...
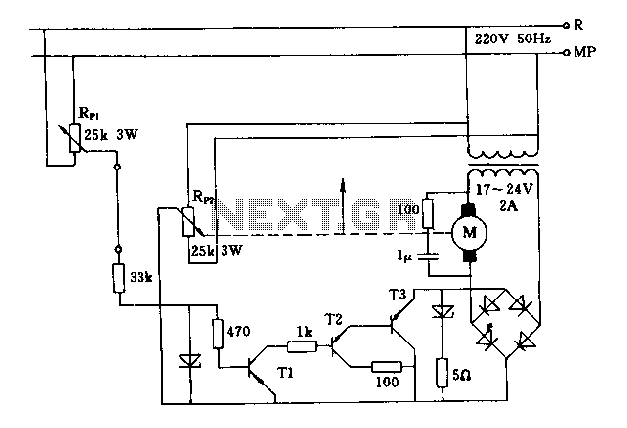
Satellite receiver antenna servo control circuit diagram
The FIG potentiometer RP2 has a sliding contact that is directly connected to the antenna. The system operates such that only when potentiometers RP1 and RP2 are positioned identically, do the non-conductive transistors and rectifier bridge remain off, resulting in...
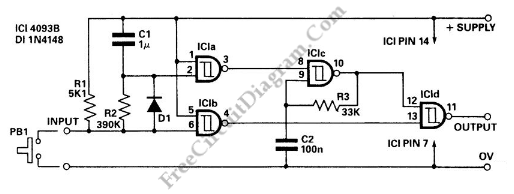
Pulse Delay Generator
This circuit is a delayed pulse generator that provides pulse rate and independent control of the initial delay. The pulse generator of this circuit is.
The delayed pulse generator circuit is designed to produce a pulse output after a specified delay,...
Pulse Signal Generator
The volt-ampere characteristics of a tunnel diode exhibit an S-shaped curve. The peak current point, referred to as point P, represents the maximum current, while the valley point, denoted as point V, indicates the minimum current. Key parameters of the...
dyi setup and debugging guide
This page discusses the differences between assembled Open USB FXS dongle boards and DIY boards. While the assembled boards are fully tested and quality control approved, DIY boards may encounter various issues during assembly. Fortunately, most of these issues can...
Electronics Projects Circuits
Over 1400 top electronics projects and electronic circuits with photos, datasheets, and easy-to-read schematics, along with explanations of how they work and how to build them.
The collection comprises a vast array of electronics projects suitable for enthusiasts and professionals alike....
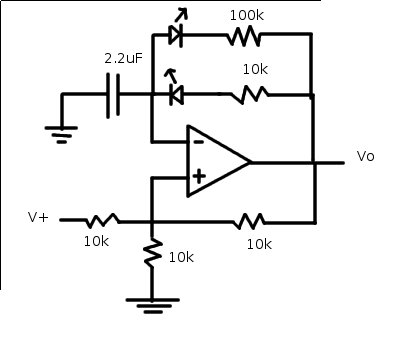
pulse generator circuit
The relaxation oscillator generates a relatively consistent square wave. By altering the duty cycle, the effect can be visualized using LEDs. The following variation of the relaxation oscillator circuit can be assembled.
The relaxation oscillator circuit typically consists of a resistor,...
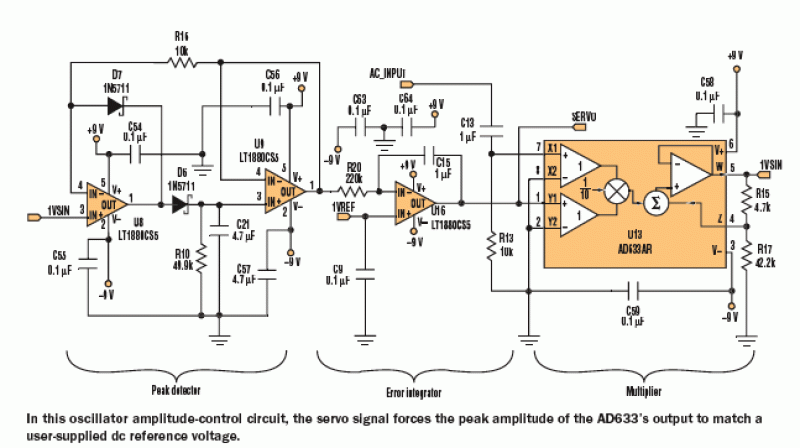
Servo Circuit Controls Sine-Wave Amplitude
The figure illustrates a schematic for an oscillator amplitude-control servo system. The circuit establishes a closed-loop system that provides a fixed and adjustable peak-to-peak amplitude AC signal centered around 0 V. A 1 kHz sine wave, designated as AC_INPUT, is...