


GSM localizer without GPS Schematic
Description: The circuit for the localizer is based on a quad-band GSM/GPRS module interfaced with a microcontroller. After initializing the I/Os and UARTs, the microcontroller enters a loop waiting for events, such as the arrival of an SMS or the pressing of button P1, which corresponds to a logical 1/0 transition of the RB1 line, equipped with a pull-up resistor. Upon receiving an SMS, the localizer differentiates between configuration messages and those requesting positional information. The procedure for determining position is similar for both manual requests and pressing P1 (for alarm or SOS). When a request is received, the PIC instructs the cellular module to connect to the Google Maps server in data mode (via GPRS) and send a position request along with the cell ID that Enfora is connected to. The localizer is then prepared to receive data transmitted over the RX channel of its UART. Once the data containing the estimated position (latitude and longitude, approximate street or square location) and accuracy is received, it prepares an SMS to send to the requesting number or the number associated with the alarm function. The cell phone is controlled by the microcontroller through the RF1 line, which reads the Ring Indicator (RI) for incoming calls, and the RB4 line, which detects incoming SMS messages. The reception and transmission lines of the UART are RC7/RX1 and RC6/TX1, respectively, used for handling cellular functions and SMS messages. The RA4 line manages the power function, controlled by PWRCTL to turn the GSM module on and off, ensuring it can be restarted if necessary. The reset function is managed by the PIC through the RC3 line, which utilizes a T1 transistor as a static switch to modify the module’s RST. The system is powered through the SW1 switch with a continuous voltage of 3.6 volts, sourced from either a 1.2-V NiMH AAA rechargeable battery or a 3.7-V Li-Ion battery. Numerous filter capacitors are placed along the power line to mitigate disturbances generated during the cell phone's transmission, which could otherwise cause significant power fluctuations that might disrupt the microcontroller's operation.
The localizer circuit design emphasizes simplicity and functionality, effectively combining a GSM/GPRS communication module with a microcontroller for real-time location tracking. The microcontroller's role as the central processing unit is critical, as it manages various input and output operations, ensuring seamless communication with the GSM module. The UART interface facilitates reliable data transmission and reception, allowing the system to process SMS messages and respond to requests efficiently.
The power management strategy is crucial for maintaining system stability, especially given the potential for voltage fluctuations during GSM transmissions. The inclusion of multiple filter capacitors along the power supply line serves to smooth out these fluctuations, protecting the microcontroller from potential disruptions. The choice of a 3.6-volt power supply, compatible with commonly available rechargeable battery types, enhances the circuit's portability and ease of use in various applications.
Moreover, the design incorporates a robust reset mechanism via the T1 transistor, ensuring that the GSM module can recover from any state of unresponsiveness without requiring physical intervention. This feature is particularly valuable in remote applications where accessibility may be limited.
Overall, the localizer circuit exemplifies an effective integration of communication technology with microcontroller capabilities, providing a reliable solution for location tracking and emergency signaling.The circuit our localizer is based on consists only of a quad-band GSM/GPRS module interfaced with a a microchip microcontroller which, after initializing the I/Os and UARTs it has at its disposal, puts the main program in a loop waiting for some event, which could be the arrival of an SMS or someone pressing the button P1 (that is, the logical 1/ 0 transition of the RB1 line, internally equipped with a pull-up resistor). In the event that an SMS is received, the localizer distinguishes between a message that is setting up a configuration and one that is requesting information regarding the position. Let us look more closely at the procedure that allows to find out the position, which is essentially the same in the case of manual requests as well as when pressing P1 (alarm or SOS): as soon as a request is received, the PIC orders the cellular module to connect to the Google Maps server in data mode (via GPRS, hence on the Internet) and to send a position request along with the cell ID to which Enfora is connected; now the localizer is ready to receive Internet-transmitted data on the RX channel of its own UART.
Once the localizer receives the data with conjectured position (latitude and longitude, approximate street or square location) and accuracy, it prepares an SMS and sends it to the number that requested it or to the one that is stored and associated with this particular alarm function. That is all: simple and functional. The cell phone is handled by the microcontroller by means of the RF1 line (through which it reads the RI, that is, the Ring Indicator used by the module to signal the arrival of a call), as well as RB4 line, which allows it to detect receipt of SMS messages.
RC7/RX1 and RC6/TX1 are, respectively, the reception and transmission lines of the UART, which is used not only to handle the cell phone`s functions (except for reset and power), but also to read and send SMS messages. The power function is handled by the RA4 line, which relies on PWRCTL to turn GSM1 on and off and which is essentially used to start the cell phone after initialization, that is, to turn it off and on again in the event it should get stuck and the reset function should not be enough to set it back to normal.
The reset function is handled by the PIC through the RC3 line, which relies on the T1 transistor, employed here as a static switch that effectively changes the module`s RST. This compound unit (that is, the cell phone and microcontroller) is powered through the SW1 switch by a continuous 3.
6-volt tension, applied to both + and PWR, which can easily be obtained from a 1. 2-V NiMh AAA rechargeable battery or from a 3. 7-V Li-Ion battery. Notice how many filter condensers are placed along the power line. They are needed to filter out disturbances produced by the input when the cell phone is transmitting disturbances that would otherwise create enough power fluctuations to block the microcontroller.
The localizer circuit design emphasizes simplicity and functionality, effectively combining a GSM/GPRS communication module with a microcontroller for real-time location tracking. The microcontroller's role as the central processing unit is critical, as it manages various input and output operations, ensuring seamless communication with the GSM module. The UART interface facilitates reliable data transmission and reception, allowing the system to process SMS messages and respond to requests efficiently.
The power management strategy is crucial for maintaining system stability, especially given the potential for voltage fluctuations during GSM transmissions. The inclusion of multiple filter capacitors along the power supply line serves to smooth out these fluctuations, protecting the microcontroller from potential disruptions. The choice of a 3.6-volt power supply, compatible with commonly available rechargeable battery types, enhances the circuit's portability and ease of use in various applications.
Moreover, the design incorporates a robust reset mechanism via the T1 transistor, ensuring that the GSM module can recover from any state of unresponsiveness without requiring physical intervention. This feature is particularly valuable in remote applications where accessibility may be limited.
Overall, the localizer circuit exemplifies an effective integration of communication technology with microcontroller capabilities, providing a reliable solution for location tracking and emergency signaling.The circuit our localizer is based on consists only of a quad-band GSM/GPRS module interfaced with a a microchip microcontroller which, after initializing the I/Os and UARTs it has at its disposal, puts the main program in a loop waiting for some event, which could be the arrival of an SMS or someone pressing the button P1 (that is, the logical 1/ 0 transition of the RB1 line, internally equipped with a pull-up resistor). In the event that an SMS is received, the localizer distinguishes between a message that is setting up a configuration and one that is requesting information regarding the position. Let us look more closely at the procedure that allows to find out the position, which is essentially the same in the case of manual requests as well as when pressing P1 (alarm or SOS): as soon as a request is received, the PIC orders the cellular module to connect to the Google Maps server in data mode (via GPRS, hence on the Internet) and to send a position request along with the cell ID to which Enfora is connected; now the localizer is ready to receive Internet-transmitted data on the RX channel of its own UART.
Once the localizer receives the data with conjectured position (latitude and longitude, approximate street or square location) and accuracy, it prepares an SMS and sends it to the number that requested it or to the one that is stored and associated with this particular alarm function. That is all: simple and functional. The cell phone is handled by the microcontroller by means of the RF1 line (through which it reads the RI, that is, the Ring Indicator used by the module to signal the arrival of a call), as well as RB4 line, which allows it to detect receipt of SMS messages.
RC7/RX1 and RC6/TX1 are, respectively, the reception and transmission lines of the UART, which is used not only to handle the cell phone`s functions (except for reset and power), but also to read and send SMS messages. The power function is handled by the RA4 line, which relies on PWRCTL to turn GSM1 on and off and which is essentially used to start the cell phone after initialization, that is, to turn it off and on again in the event it should get stuck and the reset function should not be enough to set it back to normal.
The reset function is handled by the PIC through the RC3 line, which relies on the T1 transistor, employed here as a static switch that effectively changes the module`s RST. This compound unit (that is, the cell phone and microcontroller) is powered through the SW1 switch by a continuous 3.
6-volt tension, applied to both + and PWR, which can easily be obtained from a 1. 2-V NiMh AAA rechargeable battery or from a 3. 7-V Li-Ion battery. Notice how many filter condensers are placed along the power line. They are needed to filter out disturbances produced by the input when the cell phone is transmitting disturbances that would otherwise create enough power fluctuations to block the microcontroller.
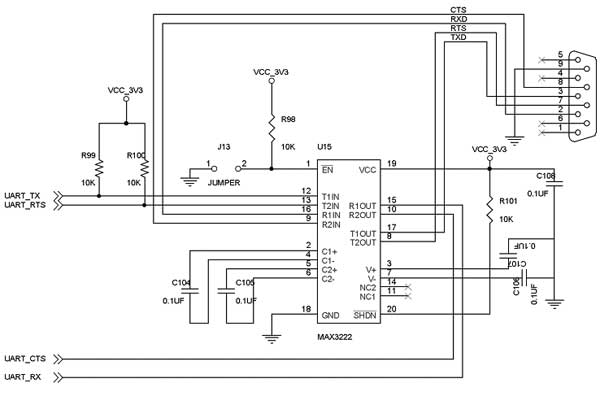
uart interfacing with tms320c5505 tyro
The TMS320C5505 Evaluation Board is specifically designed for developers in the DSP field as well as for beginners. The kit is structured in such a way that all possible features of the DSP can be easily utilized by everyone. UART...
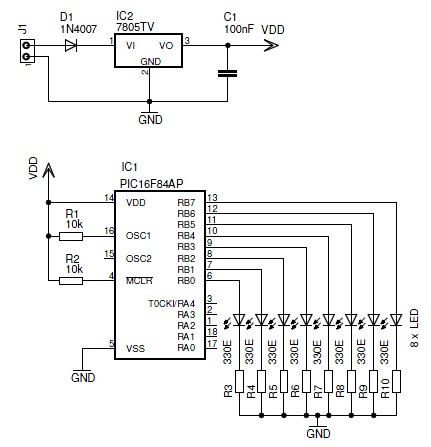
knight Rider
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
DC motor driver for DCMP(AVR-008)
A microcontroller is used to control various types of DC motors, including permanent magnet DC motors, DC servo motors, and stepper motors. This project utilizes the AVR-008 microcontroller from Circuits-Home, which is frequently referred to as the 3-in-1 driver motor...
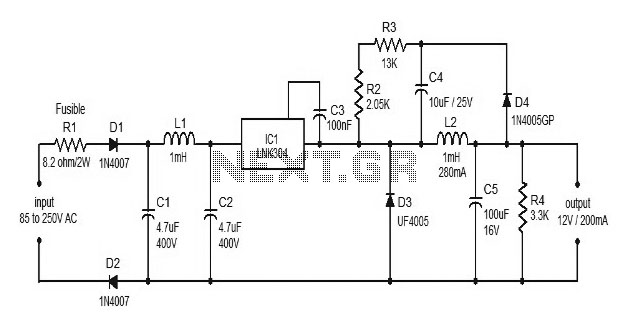
Power supplies for microcontroller based projects
This document discusses the use of small microcontrollers, such as those from the PIC and Atmel series, which typically operate at 5V and require less than 100mA for complete system functionality. Some PICs can function at lower voltages, such as...
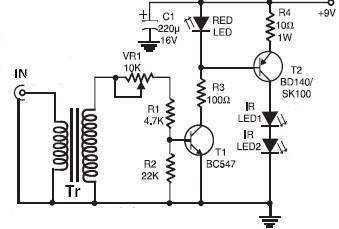
Wireless IR Headphones circuit
This wireless infrared (IR) headphones circuit project enables the transmission of audio signals through an infrared connection. The circuit consists of two main components: a transmitter and a receiver. Unlike radio frequency (RF) transmitters, both parts of this application must...
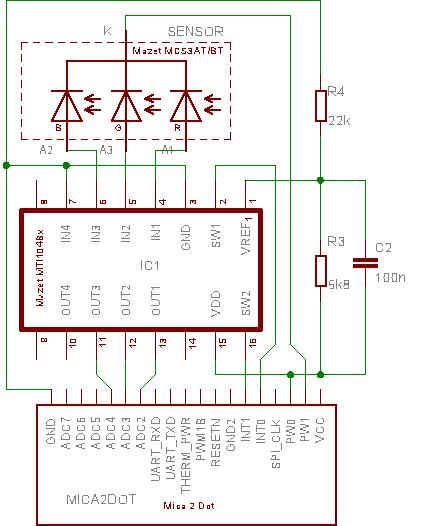
Wireless Color Sensor
Close to human perception and stable color sensing is a pervasive challenge encountered in various disciplines, such as machine vision for classification and recognition, as well as in intelligent systems like smart illumination systems in home or workplace environments. In...
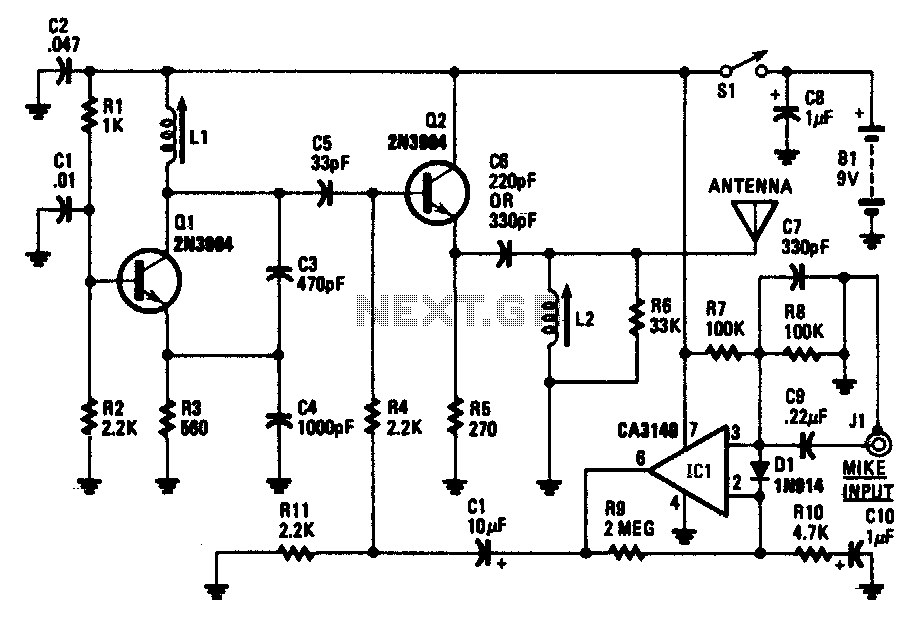
Wireless am microphone
The transistor Q1 and its associated components form a tunable RF oscillator. The RF signal is directed to transistor Q2, which functions as the modulator. Operational amplifier IC1 amplifies the audio signal and transmits it through resistor R4 to the...
IR On/Off Switch Using Microcontroller
The ability to turn electrical devices ON or OFF using a remote control is a well-established concept, with numerous devices effectively performing this function.
To implement a remote control system for switching electrical devices, a typical schematic would include several key...
Wireless-fm-microphone
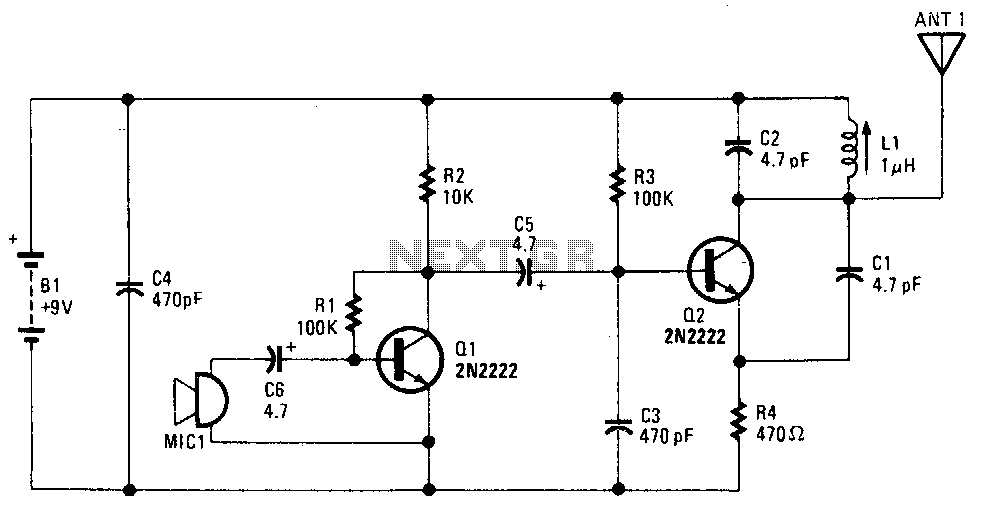
Transistor Q1 functions as an amplifier for the condenser microphone MIC1. The output from Q1 is fed to the base of transistor Q2 through a 4.7 µF capacitor. Capacitors C2 and L1 form an LC tank circuit, which is utilized...