


Ultrasound Sensor
#ultrasound
#distance measurement
#Arduino
#Parallax
#Ping sensor
#echo detection
#range finder
#object detection
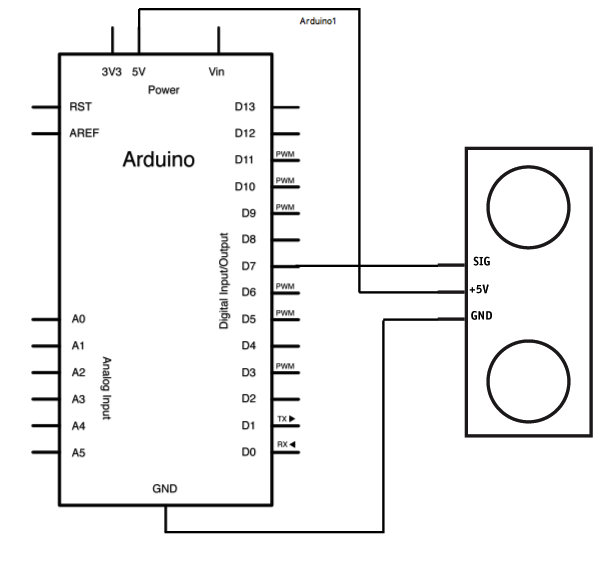
Description: The Ping is an ultrasonic range finder from Parallax. It detects the distance of the closest object in front of the sensor (from 2 cm up to 3 m). It works by sending out a burst of ultrasound and listening for the echo when it bounces off an object. The Arduino board sends a short pulse to trigger the detection, then listens for a pulse on the same pin using the pulseIn() function. The duration of this second pulse is equal to the time taken by the ultrasound to travel to the object and back to the sensor. Using the speed of sound, this time can be converted to distance. The 5V pin of the Ping is connected to the 5V pin on the Arduino, the GND pin is connected to the GND pin, and the SIG (signal) pin is connected to digital pin 7 on the Arduino.
The Ping ultrasonic range finder operates on the principle of echolocation, emitting ultrasonic sound waves and measuring the time it takes for the waves to reflect back from nearby objects. This device is particularly effective for measuring distances in the range of 2 cm to 3 m, making it suitable for applications such as obstacle detection and distance measurement in robotics and automation.
To integrate the Ping sensor with an Arduino board, the following connections must be established: the 5V power pin of the Ping sensor should be connected to the 5V output pin of the Arduino, providing the necessary power for the sensor's operation. The GND pin of the Ping must be connected to a ground pin on the Arduino to complete the electrical circuit. The SIG pin, which transmits the signal back to the Arduino, is connected to digital pin 7.
The operation begins when the Arduino sends a short pulse to the SIG pin, which triggers the Ping sensor to emit an ultrasonic pulse. The Arduino then uses the pulseIn() function to measure the duration of the pulse that returns to the SIG pin. This duration is critical, as it represents the time taken for the sound waves to travel to the object and back. The speed of sound in air is approximately 343 meters per second; thus, the distance can be calculated using the formula:
Distance = (Time * Speed of Sound) / 2
The division by 2 accounts for the round trip of the sound wave. This method allows for precise distance measurements, enabling various applications in robotics, automation, and other fields where proximity sensing is required. The simplicity of the setup, combined with the effectiveness of the Ping sensor, makes it a popular choice for hobbyists and professionals alike.The Ping) is an ultrasonic range finder from Parallax. It detects the distance of the closest object in front of the sensor (from 2 cm up to 3m). It works by sending out a burst of ultrasound and listening for the echo when it bounces off of an object. The Arduino board sends a short pulse to trigger the detection, then listens for a pulse on th e same pin using the pulseIn() function. The duration of this second pulse is equal to the time taken by the ultrasound to travel to the object and back to the sensor. Using the speed of sound, this time can be converted to distance. The 5V pin of the PING) is connected to the 5V pin on the Arduino, the GND pin is connected to the GND pin, and the SIG (signal) pin is connected to digital pin 7 on the Arduino.
The Ping ultrasonic range finder operates on the principle of echolocation, emitting ultrasonic sound waves and measuring the time it takes for the waves to reflect back from nearby objects. This device is particularly effective for measuring distances in the range of 2 cm to 3 m, making it suitable for applications such as obstacle detection and distance measurement in robotics and automation.
To integrate the Ping sensor with an Arduino board, the following connections must be established: the 5V power pin of the Ping sensor should be connected to the 5V output pin of the Arduino, providing the necessary power for the sensor's operation. The GND pin of the Ping must be connected to a ground pin on the Arduino to complete the electrical circuit. The SIG pin, which transmits the signal back to the Arduino, is connected to digital pin 7.
The operation begins when the Arduino sends a short pulse to the SIG pin, which triggers the Ping sensor to emit an ultrasonic pulse. The Arduino then uses the pulseIn() function to measure the duration of the pulse that returns to the SIG pin. This duration is critical, as it represents the time taken for the sound waves to travel to the object and back. The speed of sound in air is approximately 343 meters per second; thus, the distance can be calculated using the formula:
Distance = (Time * Speed of Sound) / 2
The division by 2 accounts for the round trip of the sound wave. This method allows for precise distance measurements, enabling various applications in robotics, automation, and other fields where proximity sensing is required. The simplicity of the setup, combined with the effectiveness of the Ping sensor, makes it a popular choice for hobbyists and professionals alike.The Ping) is an ultrasonic range finder from Parallax. It detects the distance of the closest object in front of the sensor (from 2 cm up to 3m). It works by sending out a burst of ultrasound and listening for the echo when it bounces off of an object. The Arduino board sends a short pulse to trigger the detection, then listens for a pulse on th e same pin using the pulseIn() function. The duration of this second pulse is equal to the time taken by the ultrasound to travel to the object and back to the sensor. Using the speed of sound, this time can be converted to distance. The 5V pin of the PING) is connected to the 5V pin on the Arduino, the GND pin is connected to the GND pin, and the SIG (signal) pin is connected to digital pin 7 on the Arduino.
project crystal
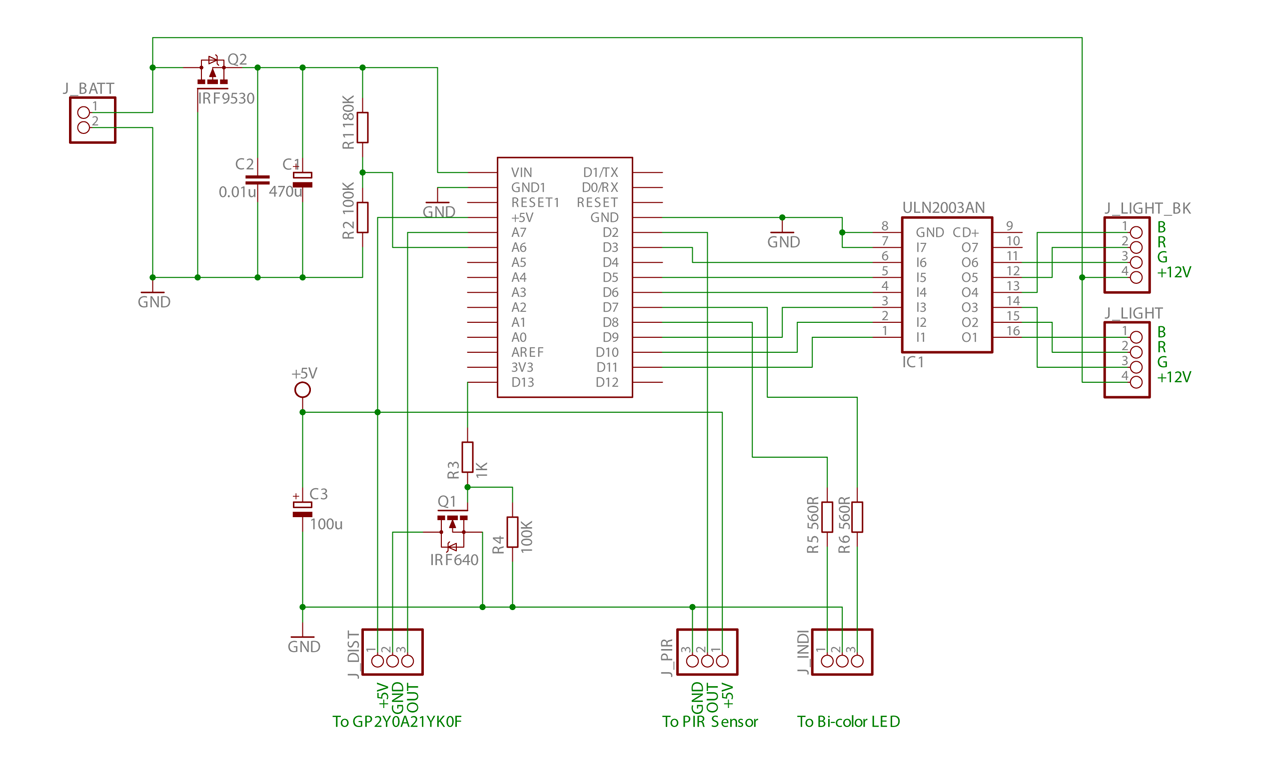
This is the initial phase of an Arduino-controlled PWM RGB LED project, which incorporates distance and PIR sensor control along with a sleep mode feature.
The project utilizes an Arduino microcontroller to manage a Pulse Width Modulation (PWM) RGB LED, allowing...
An Efficient Low-Power Arduino Switching Voltage Regulator
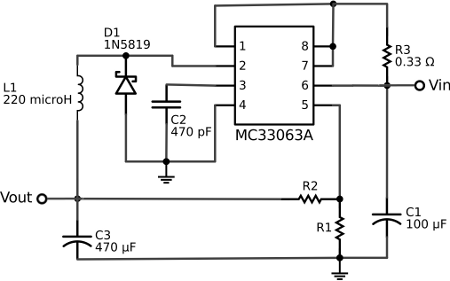
The voltage regulator integrated into the Arduino Uno is a linear-type regulator, which exhibits poor efficiency. When operating the ATmega238 at 5V with a 9V battery, nearly half of the battery's energy is wasted as heat by the regulator. This...
ultrasound How do I drive an ultrasonic transducer with an Arduino
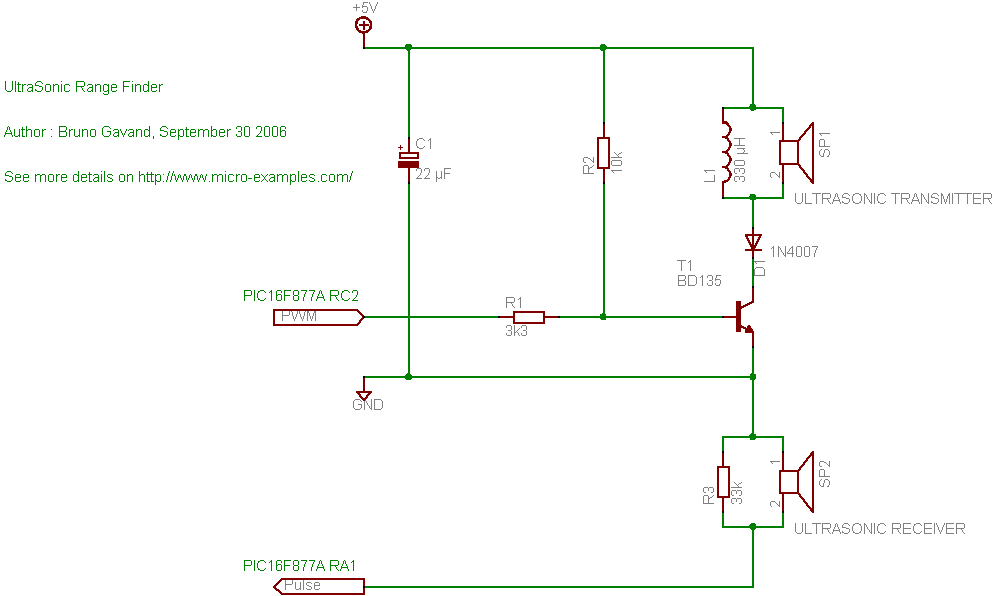
A cat deterrent system utilizing an Arduino, similar to existing models. Detection has been successfully implemented, and it has been determined that an ultrasonic transducer is required to generate the necessary deterrent sound.
The proposed cat deterrent system employs an Arduino...
Programming
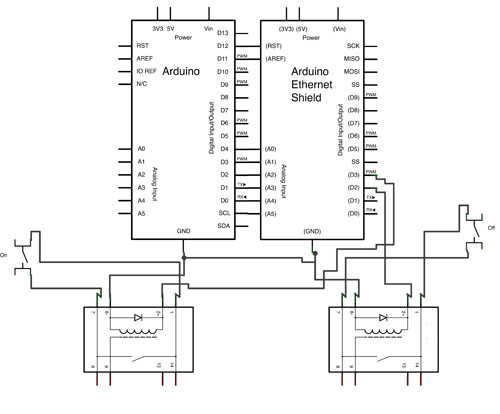
This article discusses the use of a Raspberry Pi to create a compact interface for controlling fireplaces through a home automation system, replacing a previous Arduino setup. The project aims to reduce bulkiness by placing the controller under the fireplace....
Small Engine ECU EFI Moped Using Ardrino UNO
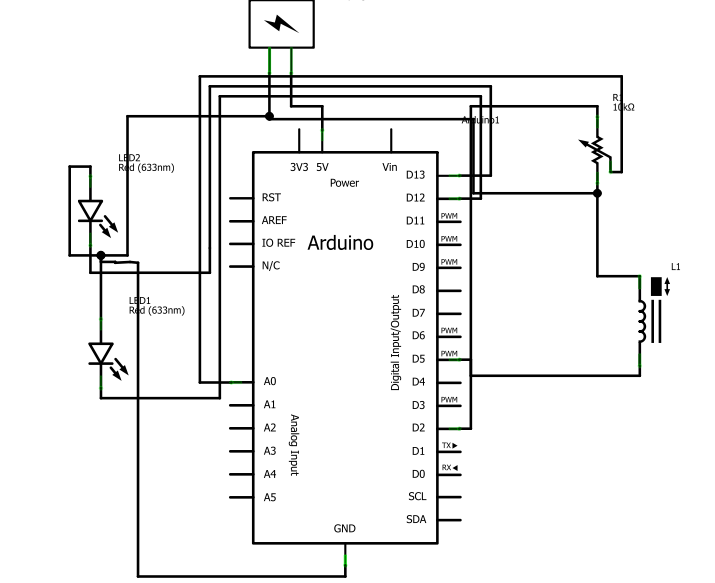
After several days of considering electronic fuel injection for a moped, a decision has been made to proceed with the project. The required parts have been identified, and the remaining task involves programming.
The implementation of electronic fuel injection (EFI) in...
Hear with Ultrasound Using Flanagan Neurophone
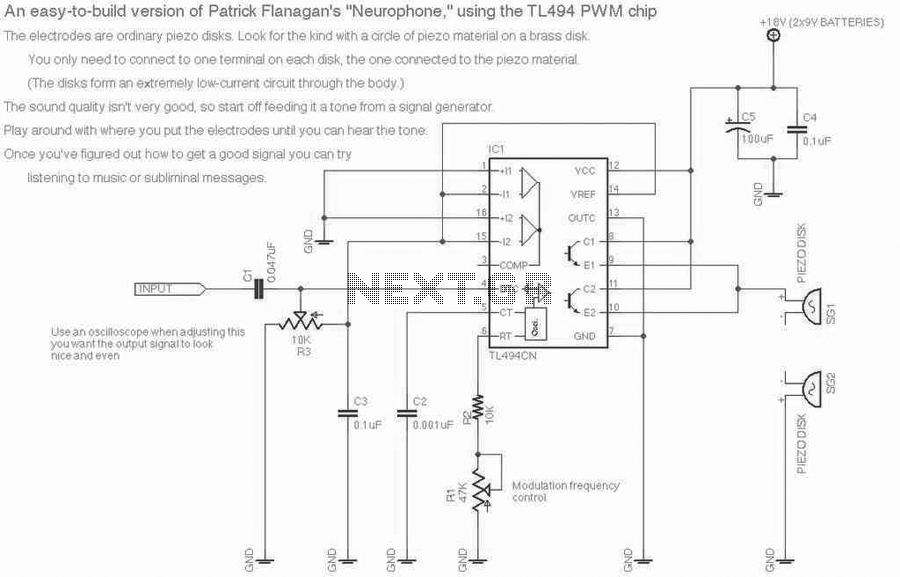
By mixing an audio signal with ultrasound, it is possible to perceive the audio as if it originates from within the head, even when the 'headphones' are positioned far from the ears. Patrick Flanagan invented the "Neurophone" over 40 years...
Arduino V-USB / HID 14 channel data logger
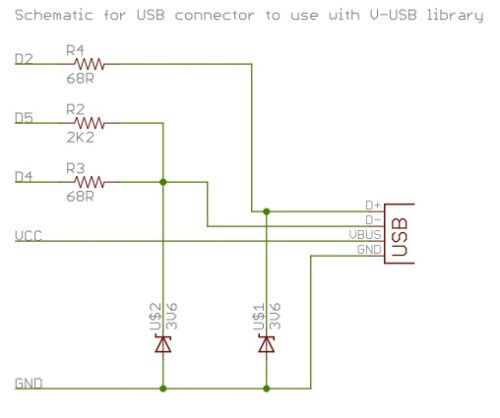
To successfully complete this project, it is necessary to construct the circuit as illustrated or as previously demonstrated. While the construction process is straightforward, any errors may prevent the V-USB software from functioning properly, potentially resulting in project failure. Furthermore,...
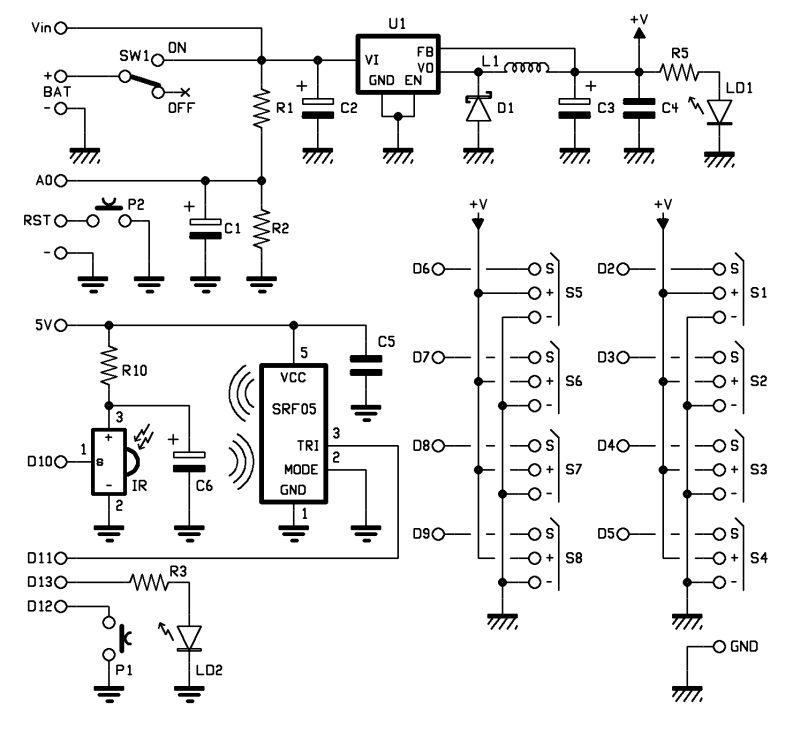
Robot shield for Arduino
The objective of this post is to consolidate various robot designs and transform them into a new device featuring updated hardware and standardized software, specifically using Arduino, to enhance usability. These robots share three common elements: a mechanical structure, hardware,...
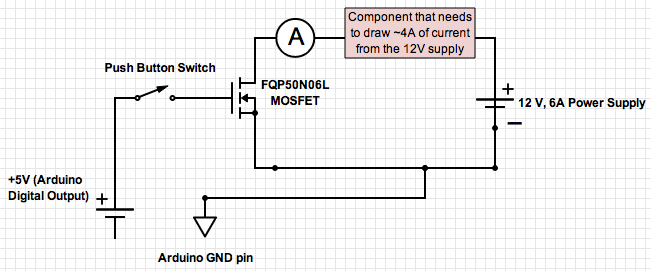
arduino Circuit with switching MOSFET not working
If the ground of the Arduino is disconnected from the negative terminal of the power supply, current flows through the MOSFET, even when the switch is not closed.
In an electronic circuit involving an Arduino and a MOSFET, maintaining a common...