


Ultrasonic Distant Obstacle Detector
#ultrasonic
#obstacle detection
#robot
#distance measurement
#sensor circuit
#automation
#Arduino
#microcontroller
#proximity sensor
#DIY electronics
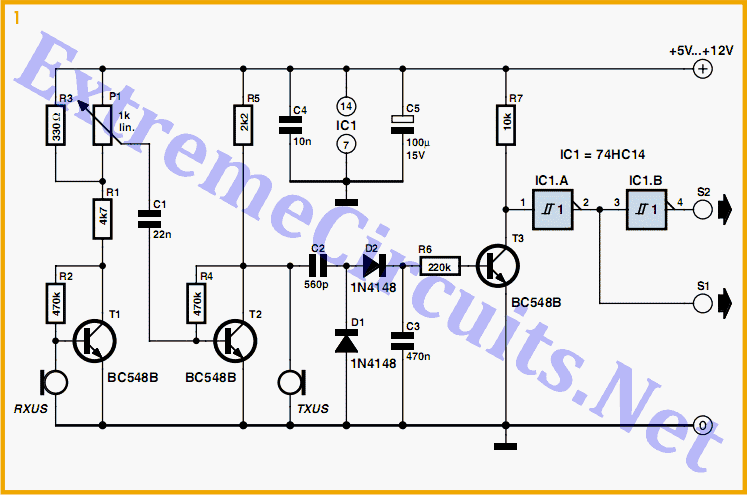
Description: The first sensor that a robot is typically equipped with is an obstacle detector. It can take three different forms, depending on the type of obstacle to be detected.
Obstacle detectors are essential components in robotic systems, designed to enhance navigation and safety by identifying and responding to physical barriers in the robot's environment. These sensors can be categorized into three primary types: ultrasonic sensors, infrared sensors, and LIDAR systems, each with its unique operational principles and applications.
Ultrasonic sensors operate by emitting high-frequency sound waves and measuring the time it takes for the echo to return after bouncing off an obstacle. This time delay is then converted into distance, allowing the robot to detect objects within a specified range. These sensors are particularly effective in indoor environments and can be used to avoid collisions with stationary or moving obstacles.
Infrared sensors, on the other hand, utilize infrared light to detect obstacles. They emit infrared radiation and measure the intensity of the reflected light. When an object is in proximity, the amount of reflected light changes, indicating the presence of an obstacle. Infrared sensors are commonly used in line-following robots and applications where quick response times are required.
LIDAR (Light Detection and Ranging) systems represent a more advanced form of obstacle detection. They use laser pulses to measure distances with high precision. By scanning the environment and creating a detailed map, LIDAR systems can identify obstacles with great accuracy, making them suitable for complex navigation tasks in dynamic environments.
In summary, the choice of obstacle detector depends on factors such as the environment, required precision, and the nature of the obstacles to be detected. Each sensor type has its advantages and limitations, and selecting the appropriate one is crucial for effective robotic operation and navigation.The first sensor a robot usually gets fitted with is an obstacle detector. It may take three different forms, depending on the type of obstacle you want t..
Obstacle detectors are essential components in robotic systems, designed to enhance navigation and safety by identifying and responding to physical barriers in the robot's environment. These sensors can be categorized into three primary types: ultrasonic sensors, infrared sensors, and LIDAR systems, each with its unique operational principles and applications.
Ultrasonic sensors operate by emitting high-frequency sound waves and measuring the time it takes for the echo to return after bouncing off an obstacle. This time delay is then converted into distance, allowing the robot to detect objects within a specified range. These sensors are particularly effective in indoor environments and can be used to avoid collisions with stationary or moving obstacles.
Infrared sensors, on the other hand, utilize infrared light to detect obstacles. They emit infrared radiation and measure the intensity of the reflected light. When an object is in proximity, the amount of reflected light changes, indicating the presence of an obstacle. Infrared sensors are commonly used in line-following robots and applications where quick response times are required.
LIDAR (Light Detection and Ranging) systems represent a more advanced form of obstacle detection. They use laser pulses to measure distances with high precision. By scanning the environment and creating a detailed map, LIDAR systems can identify obstacles with great accuracy, making them suitable for complex navigation tasks in dynamic environments.
In summary, the choice of obstacle detector depends on factors such as the environment, required precision, and the nature of the obstacles to be detected. Each sensor type has its advantages and limitations, and selecting the appropriate one is crucial for effective robotic operation and navigation.The first sensor a robot usually gets fitted with is an obstacle detector. It may take three different forms, depending on the type of obstacle you want t..

Microcontroller Voltmeter / Ammeter with LCD
The rectifier bridge voltage is determined by the U2 element; refer to its datasheet for the maximum voltage specifications. The minimum voltage at this pin should not fall below approximately 9V, or 6.5V if low-dropout type U2 and U3 voltage...
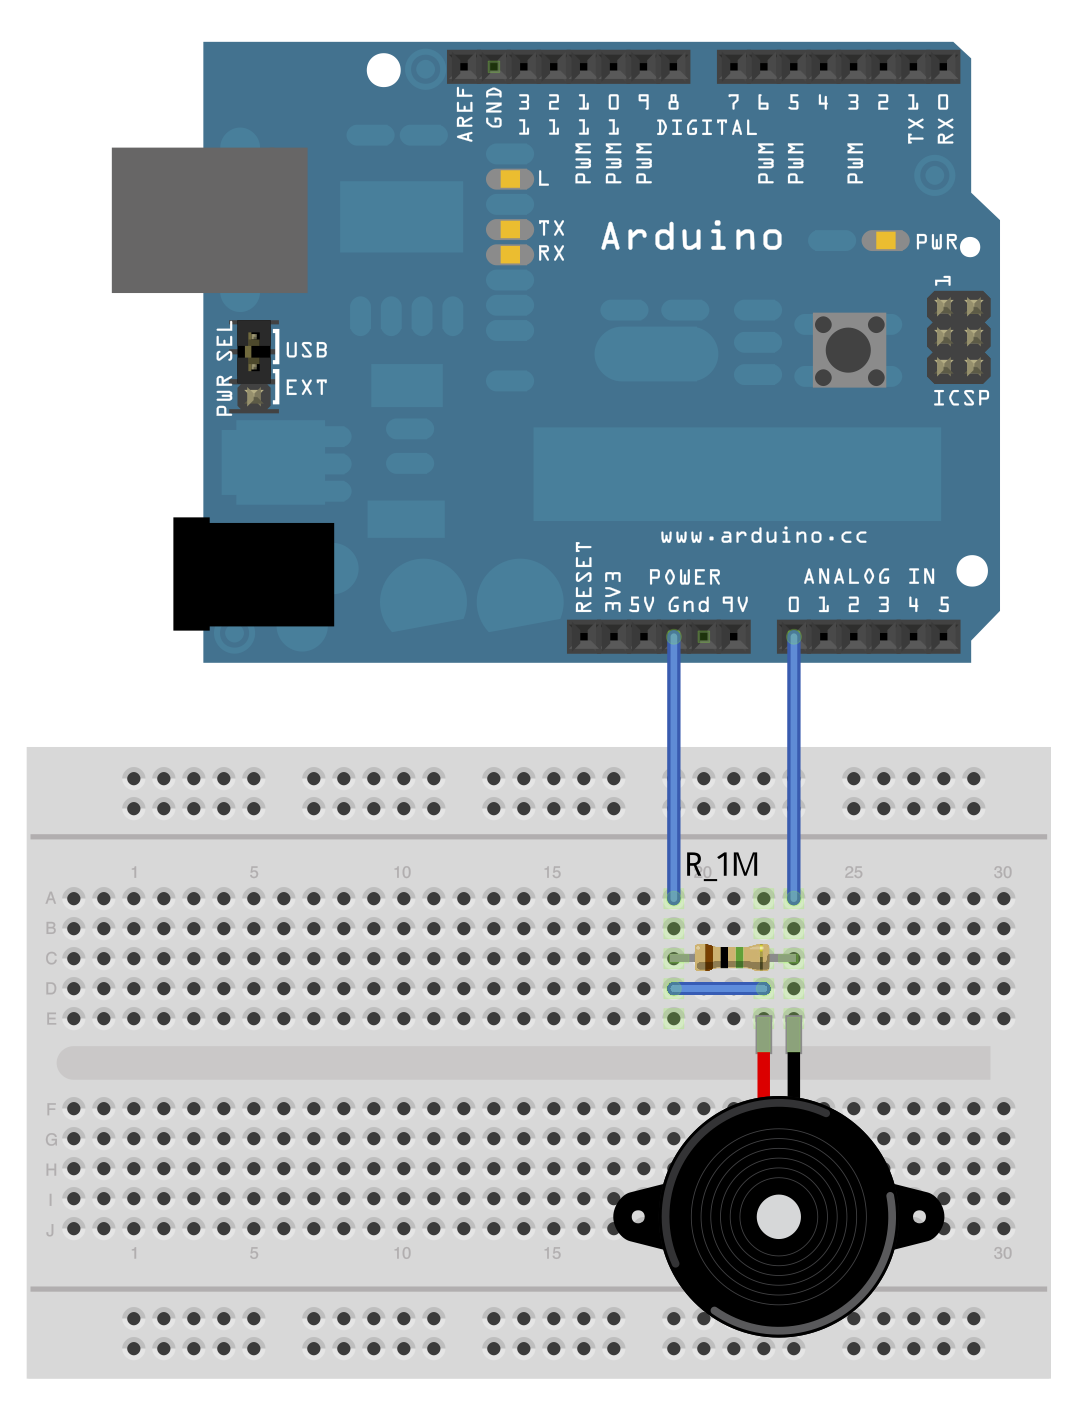
Arduino driving a motor with MC33887 Motor Driver
Posts about a tutorial written by Harandi and Amirsab.
The content refers to a series of instructional posts focused on a particular tutorial authored by individuals identified as Harandi and Amirsab. These posts likely encompass various topics related to electronics, providing...
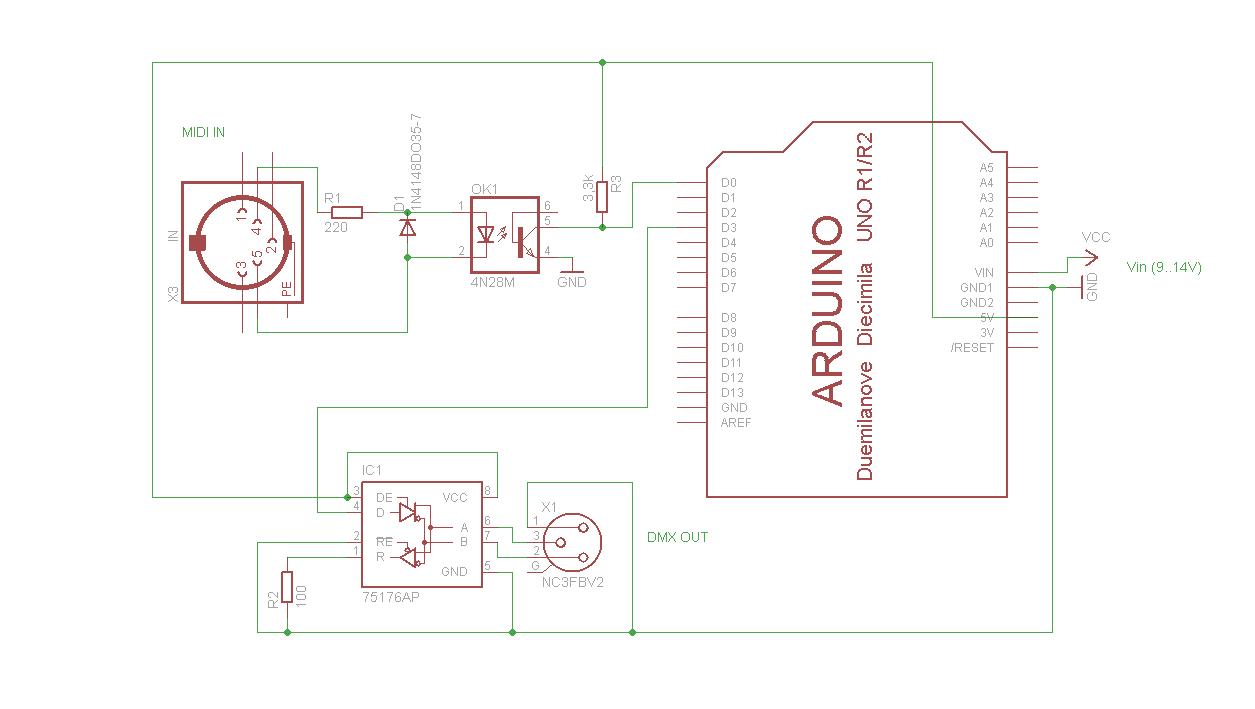
midi to dmx arduino control shield
A simple Arduino MIDI-to-DMX control was created for a robot band named Science Fiction Children. The setup consists of two inexpensive LED Par56 lights from Stairville, a basic DMX dimmer pack, and Ableton Live for sound management. The objective is...
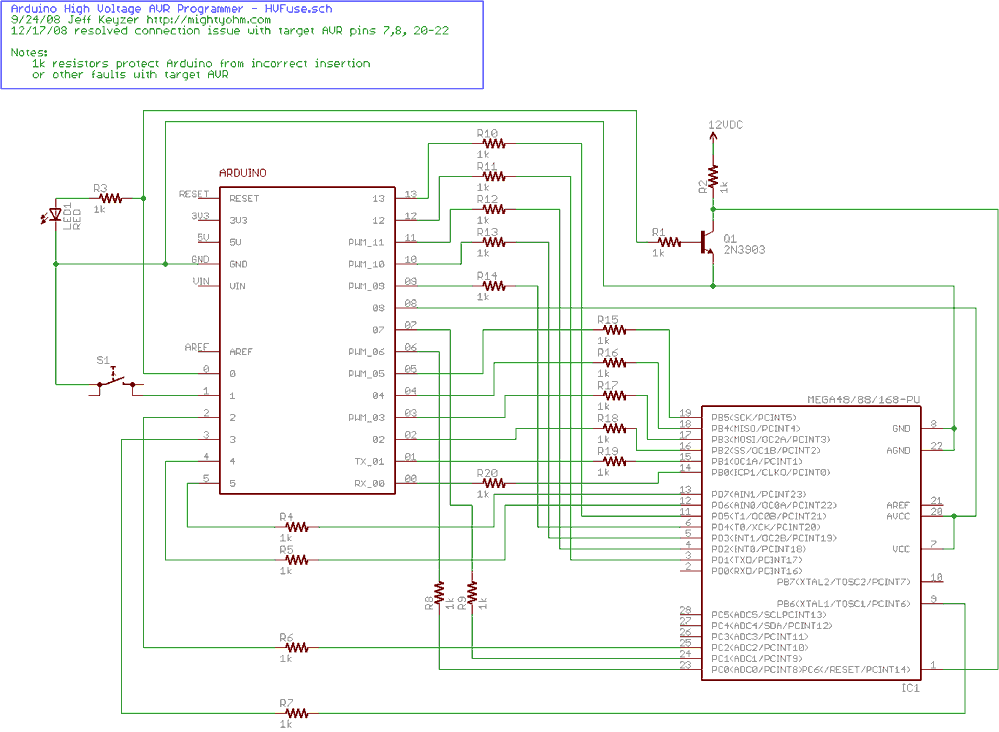
Arduino-based AVR High Voltage Programmer
Fortunately, my trusty Arduino came to the rescue. I created an Arduino-based AVR programmer that uses the high voltage programming mode and can fix pesky fuses like RSTDISBL. The Arduino has just enough IO to implement the entire HV protocol...
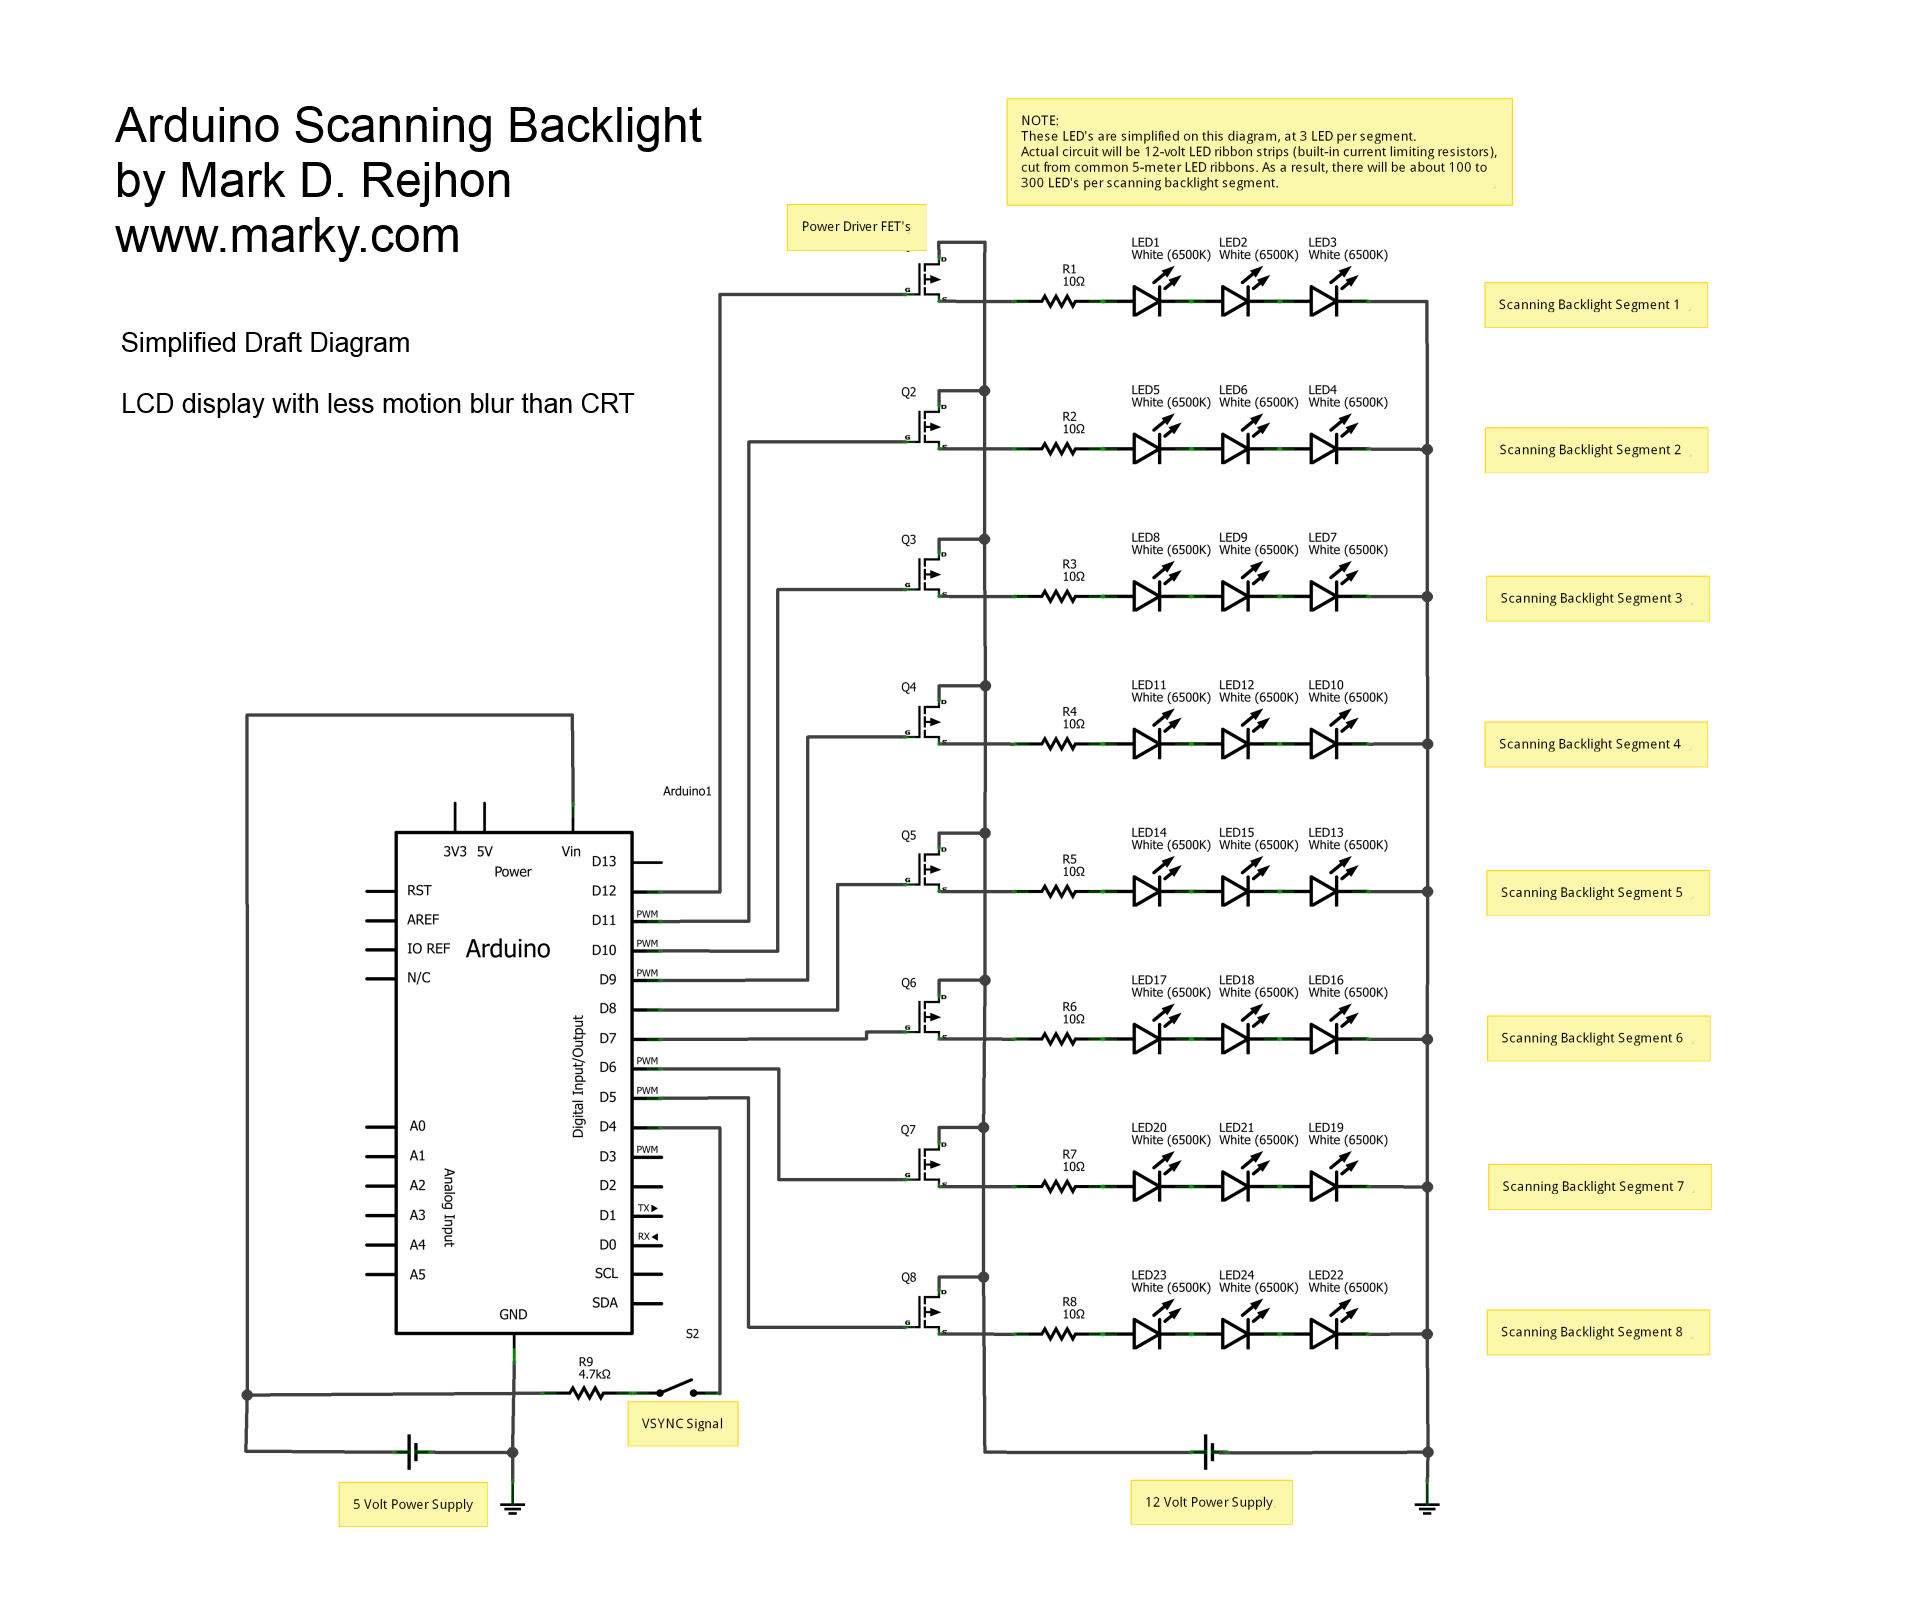
arduino scanning backlight
This is a simplified schematic diagram for a homemade scanning backlight driven by an Arduino, an open-source electronics prototyping platform. The Arduino monitors the VSYNC signal (input-lag compensated) and executes a backlight scanning sequence, using ultra-short strobes of super bright...
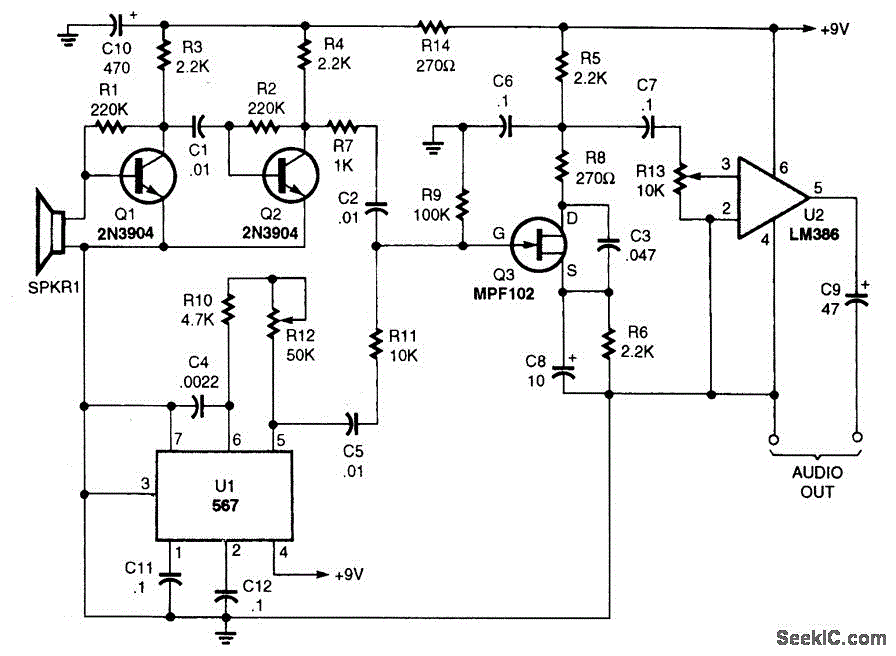
ULTRASONIC SOUND RECEIVER
The performance of this sensitive ultrasonic receiver is impressive. It allows users to listen to various sources of ultrasonic sounds, including bugs, bats, and engines. The circuit utilizes a piezo tweeter as an ultrasonic microphone, with amplifier stages Q1 and...
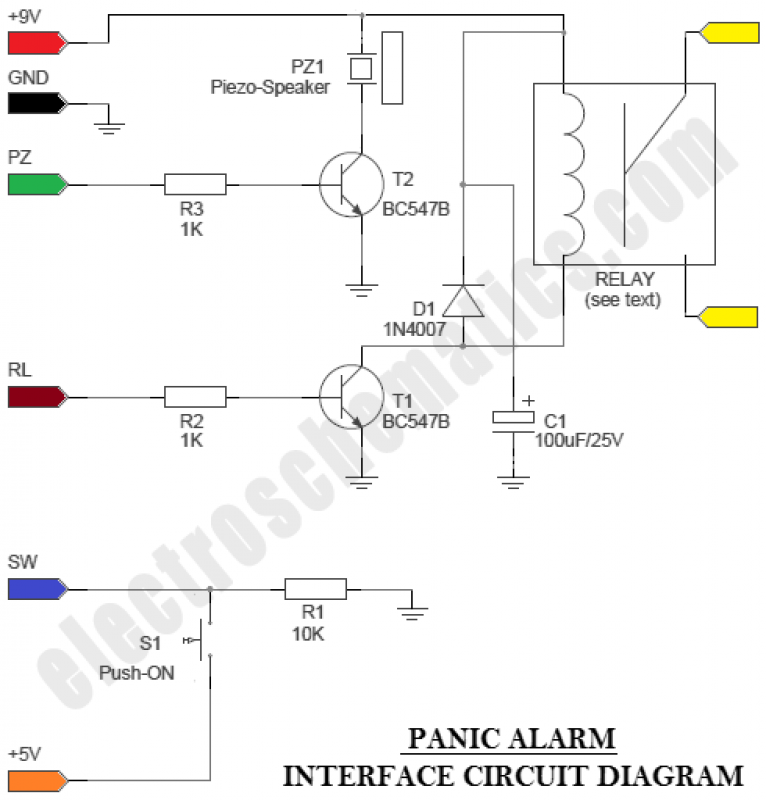
Arduino Panic Alarm Project
The circuit is an Arduino-based Panic Alarm. The wiring is straightforward, enabling even novices to construct this interesting circuit with ease. Arduino is a family of microcontrollers and a software environment (Arduino IDE) that facilitates the creation of programs, referred...
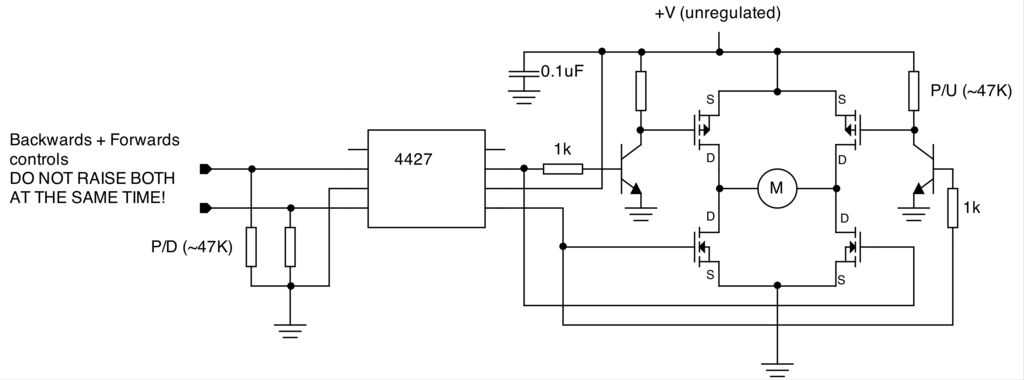
Augmenting a Microcontroller Circuit
To create a versatile and generic microcontroller board, the information provided thus far is sufficient. It covers the essential components needed to achieve this.
The design of a microcontroller board requires careful consideration of various factors to ensure versatility and functionality....
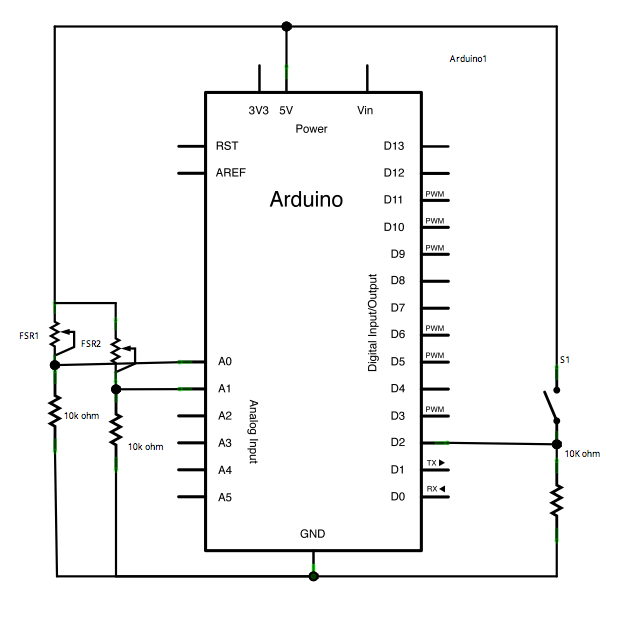
Arduino Serial Call Response
This sketch transmits an ASCII 'A' (byte value 65) upon startup and continues to do so until it receives a serial response from the computer. After receiving a response, it sends three sensor values as individual bytes and waits for...