


Ultrasonic anemometer Ultrasonic wind sensor
#ultrasonic
#wind speed
#wind direction
#temperature
#measurement
#anemometer
#gust capture
#peak value
#environmental sensor
#weather
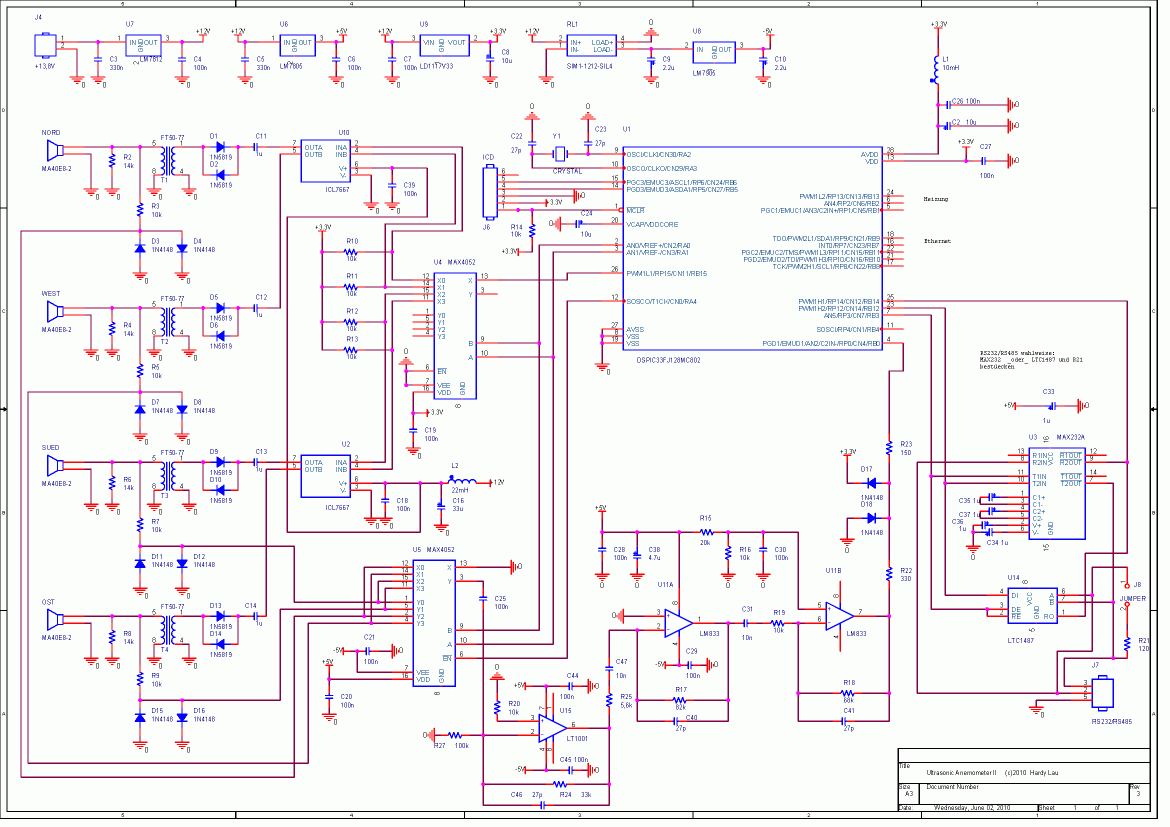
Description: This ultrasonic anemometer is designed for the two-dimensional measurement of horizontal wind speed components and wind direction, as well as virtual temperature. Due to its high measurement rate, the device effectively captures gusts and peak values without delay. The accuracy of the virtual temperature measurement often surpasses that of traditional methods that utilize temperature sensors in weather and radiation protection. Measurement data is transmitted via a serial interface. The sensors and device housing are heated to prevent frost formation, ensuring functionality during snowfall and freezing rain while minimizing the risk of ice accumulation. The anemometer comprises four ultrasonic transducers arranged to measure in two orthogonal directions, with a distance of approximately 21 cm between them. These transducers operate as both sonic transmitters and receivers. Upon initiating a measurement, a sequence of four individual measurements occurs in all four directions. The sound propagation directions are rotated, and from the four single measurements in each direction, one wind vector is calculated for further analysis. The measurement sequence takes 10 milliseconds. Although the time measurement involves repeated assessments of a short sound impulse, it essentially relies on phase measurement with subsequent assignment of the absolute phase through time measurement. The phase is derived from measuring several zero crossings of the received signal at large amplitude after the signal arrives. Any delays and offsets from the comparator are compensated by averaging positive and negative zero crossings. The accurate zero crossing for phase measurement is determined by an adaptive digital filter that compares the received signal with a reference signal, evaluating part of the signal's envelope indirectly. The primary challenge in time measurement is recognizing the slow rise in amplitude, which is influenced by turbulence in the air that dissipates energy, rather than being consistent across the signal. This turbulence, which can be exacerbated by the sound transducers themselves, becomes more pronounced at higher wind speeds. The combination of zero crossing recognition enhances measurement resolution. If an unexpected decrease in amplitude occurs, it poses a risk of misinterpreting the measurement. This potential error could lead to detecting the wrong amplitude cycle within the signal. A digital post-processing method, which includes plausibility testing, addresses this issue by enhancing detection reliability. Furthermore, multiple measurements are necessary for accurately capturing two-dimensional wind speed. For instance, the measured temperature must remain consistent across both linearly independent directions. The wind speeds in both forward and reverse directions must align. Additionally, changes in wind speed and temperature can only occur at a limited rate, even with high measurement frequencies. These checks ensure reliable detection. The speed of sound in still air is influenced by the air movement in the direction of the wind. A wind speed component aligned with the sound propagation direction increases sound speed, while a component against it decreases sound speed. The resulting propagation speed variations lead to different sound travel times under varying wind speeds and directions across a stationary measurement distance. The speed of sound is notably affected by temperature, which must be accounted for in precise measurements.This ultrasonic anemometer serves for the 2-dimensional capture of the horizontal components of the wind speed and the wind direction as well as the virtual temperature. On account of the high measuring rate this device is suited very well to capture gusts and peak value measurement without sluggishness.
The accessible exactness with the measureme nt of the air temperature (virtual temperature) partially excels those of the classical procedures with which temperature measuring feelers are used in a weather and radiation protection. The measuring values are provided as a data telegrams above a serial interface. The sensors and the device body are heated in frost. Therefore the function is also guaranteed with snowfall and ice rain, as well as the possibility of an ice formation is prevented to a great extent.
This ultrasonic anemometer consists of 4 ultrasonic converters forming two measuring directions orthogonal to each other. The distance is approx. 21 cm. The converters function as a sonic transmitter as well as a sonic receiver. With the start of a measurement a sequence of four single measurements starts in all 4 directions of the measuring distances.
The measuring directions (sound propagation directions) proceed rotary. From four single measurements into each direction one wind vector is formed and used to the further calculation. The required time for a measuring sequence is 10 milliseconds. Even if on this side the time measurement of a short sound impulse appears over and over again, actually, it is a phase measurement with post regular assignment of the absolute phase by time measurement.
The phase is won by a measurement of several zero passageways of the receipt signal in the area of large amplitude after arrival of the signal. Rushing and a possible offset of the comparator are compensated by the averaging of positive and negative zero passageways.
The "correct" zero passageway of the phase measurement is assigned by an adaptive digital filter which compares the received signal to a reference signal. A part of the wrapping curve of the signal is evaluated therefore indirectly. With the time measurement the essential problem is the recognition of the slow rising amplitude. However, this amplitude and their increase are caused by turbulence in the air which takes away energy, not from the signal consistently.
This turbulence is caused among other things by the sound converters itself and is more distinctive with higher wind speed. With a combination with zero passageway recognition the possible resolution of the measurement rises.
If now an amplitude decrease precipitates unexpectedly the threat consists to find out a jump in the measurements. The error could be to detect the right amplitude an cycle sooner or later within the signal. Solution for this problem is a digital post-treatment by plausibility test. By the digital post-treatment we incorporated the safety at the detection. Further several measurements are required for a two dimensional capture of wind speed. Besides, e. g. , the measured temperature may not be different between both linearly independent directions. The speeds in execution and reverse direction must correspond. Also the wind speed and temperature can change with a high measuring frequency only limited fast. With all this checks certain detection can be guaranteed. The propagation speed of the sound in calm air overlaps the speed component of an air movement in wind direction.
A wind speed component in propagation direction of the sound supports its propagation speed, leads to an increase the same, a wind speed component against the propagation direction leads against it to a reduction of the propagation speed. From the addition resulting propagation speed leads to different terms of the sound with different wind speeds and directions about a stationary measuring distance.
Because the speed of sound is strongly dependent on the
The accessible exactness with the measureme nt of the air temperature (virtual temperature) partially excels those of the classical procedures with which temperature measuring feelers are used in a weather and radiation protection. The measuring values are provided as a data telegrams above a serial interface. The sensors and the device body are heated in frost. Therefore the function is also guaranteed with snowfall and ice rain, as well as the possibility of an ice formation is prevented to a great extent.
This ultrasonic anemometer consists of 4 ultrasonic converters forming two measuring directions orthogonal to each other. The distance is approx. 21 cm. The converters function as a sonic transmitter as well as a sonic receiver. With the start of a measurement a sequence of four single measurements starts in all 4 directions of the measuring distances.
The measuring directions (sound propagation directions) proceed rotary. From four single measurements into each direction one wind vector is formed and used to the further calculation. The required time for a measuring sequence is 10 milliseconds. Even if on this side the time measurement of a short sound impulse appears over and over again, actually, it is a phase measurement with post regular assignment of the absolute phase by time measurement.
The phase is won by a measurement of several zero passageways of the receipt signal in the area of large amplitude after arrival of the signal. Rushing and a possible offset of the comparator are compensated by the averaging of positive and negative zero passageways.
The "correct" zero passageway of the phase measurement is assigned by an adaptive digital filter which compares the received signal to a reference signal. A part of the wrapping curve of the signal is evaluated therefore indirectly. With the time measurement the essential problem is the recognition of the slow rising amplitude. However, this amplitude and their increase are caused by turbulence in the air which takes away energy, not from the signal consistently.
This turbulence is caused among other things by the sound converters itself and is more distinctive with higher wind speed. With a combination with zero passageway recognition the possible resolution of the measurement rises.
If now an amplitude decrease precipitates unexpectedly the threat consists to find out a jump in the measurements. The error could be to detect the right amplitude an cycle sooner or later within the signal. Solution for this problem is a digital post-treatment by plausibility test. By the digital post-treatment we incorporated the safety at the detection. Further several measurements are required for a two dimensional capture of wind speed. Besides, e. g. , the measured temperature may not be different between both linearly independent directions. The speeds in execution and reverse direction must correspond. Also the wind speed and temperature can change with a high measuring frequency only limited fast. With all this checks certain detection can be guaranteed. The propagation speed of the sound in calm air overlaps the speed component of an air movement in wind direction.
A wind speed component in propagation direction of the sound supports its propagation speed, leads to an increase the same, a wind speed component against the propagation direction leads against it to a reduction of the propagation speed. From the addition resulting propagation speed leads to different terms of the sound with different wind speeds and directions about a stationary measuring distance.
Because the speed of sound is strongly dependent on the
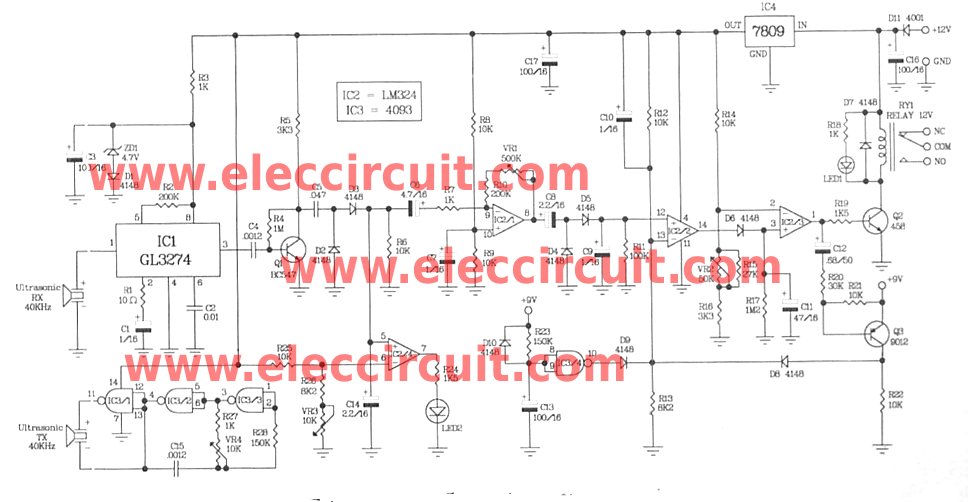
Ultrasonic motion detector circuits
The motion sensor circuit depicted in Figure 1 operates when a 12-volt power supply is applied to the input point.
The motion sensor circuit is designed to detect movement and trigger a response based on the presence of motion in...
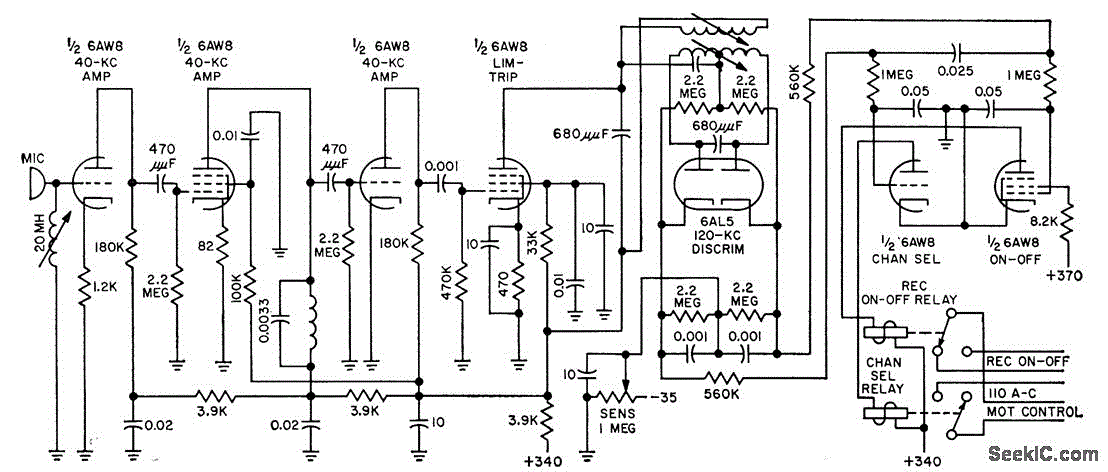
TV_CONTROL_RECEIVER
Utilizes a barium titanate transducer as a microphone, tuned with a 20 mH coil to generate peaks at control frequencies of 38.5 kHz and 41.5 kHz. A balanced discriminator detects the two ultrasonic tones. A frequency shift in the continuous...
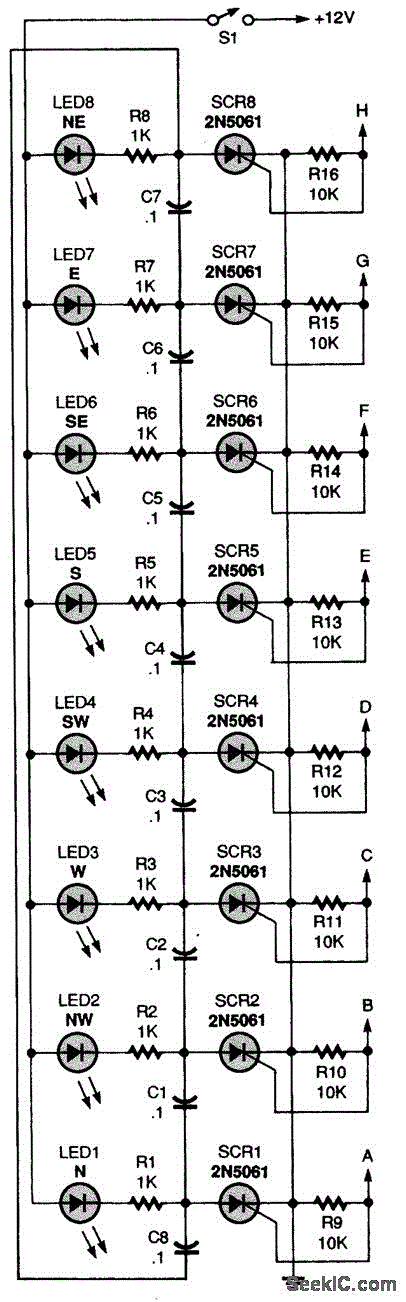
WIND DIRECTION SENSOR
To utilize the circuit, a wind vane similar to the one illustrated is required. It must feature a weighted front end and an air paddle at the rear. A small, strong magnet should be affixed to the front section of...
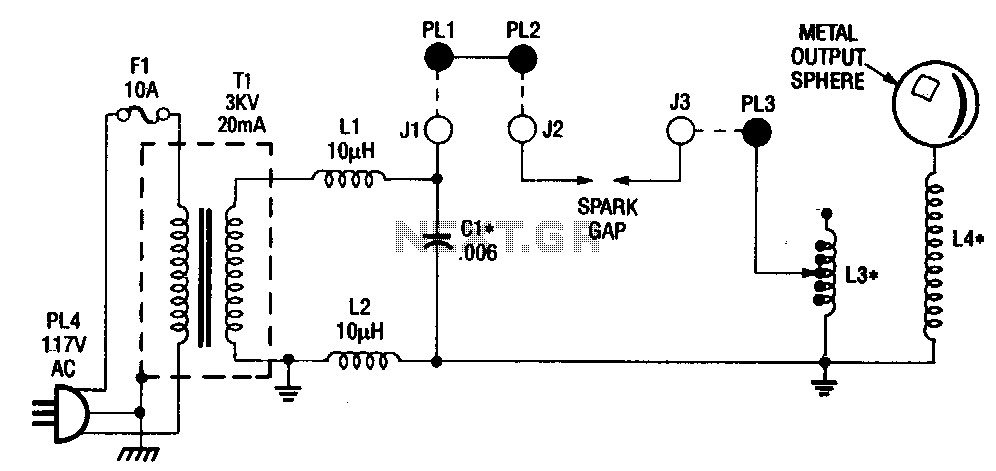
Differential-thermometer
The differential thermometer utilizes two probes to display the temperature difference between them instead of indicating the precise temperature. It employs a conventional meter as an indicator and has a total range of -10°C to 20°C.
The differential thermometer operates on...
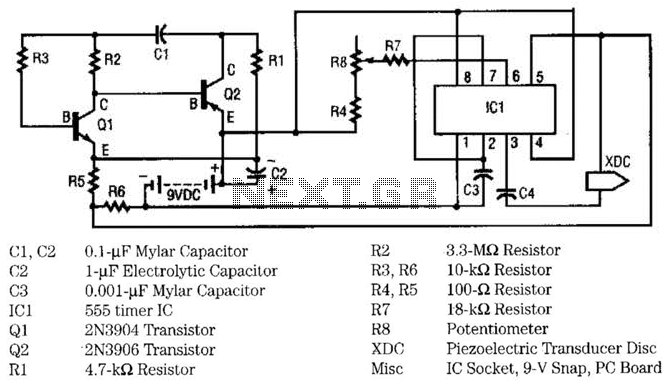
Ultrasonic Pest Repeller Circuit
This circuit utilizes two transistors and one integrated circuit (555 timer IC) to generate a pulsating ultrasonic frequency. Transistors Q1 and Q2 are configured in a direct-coupled oscillator arrangement. The frequency of the oscillator is determined by capacitor C1. The...
Cat And Dog Repellent
The electronic dog repellent circuit diagram below is a high-output ultrasonic transmitter primarily intended to act as a dog and cat repeller.
The electronic dog repellent circuit utilizes high-frequency ultrasonic sound waves to deter unwanted animals such as dogs and cats....
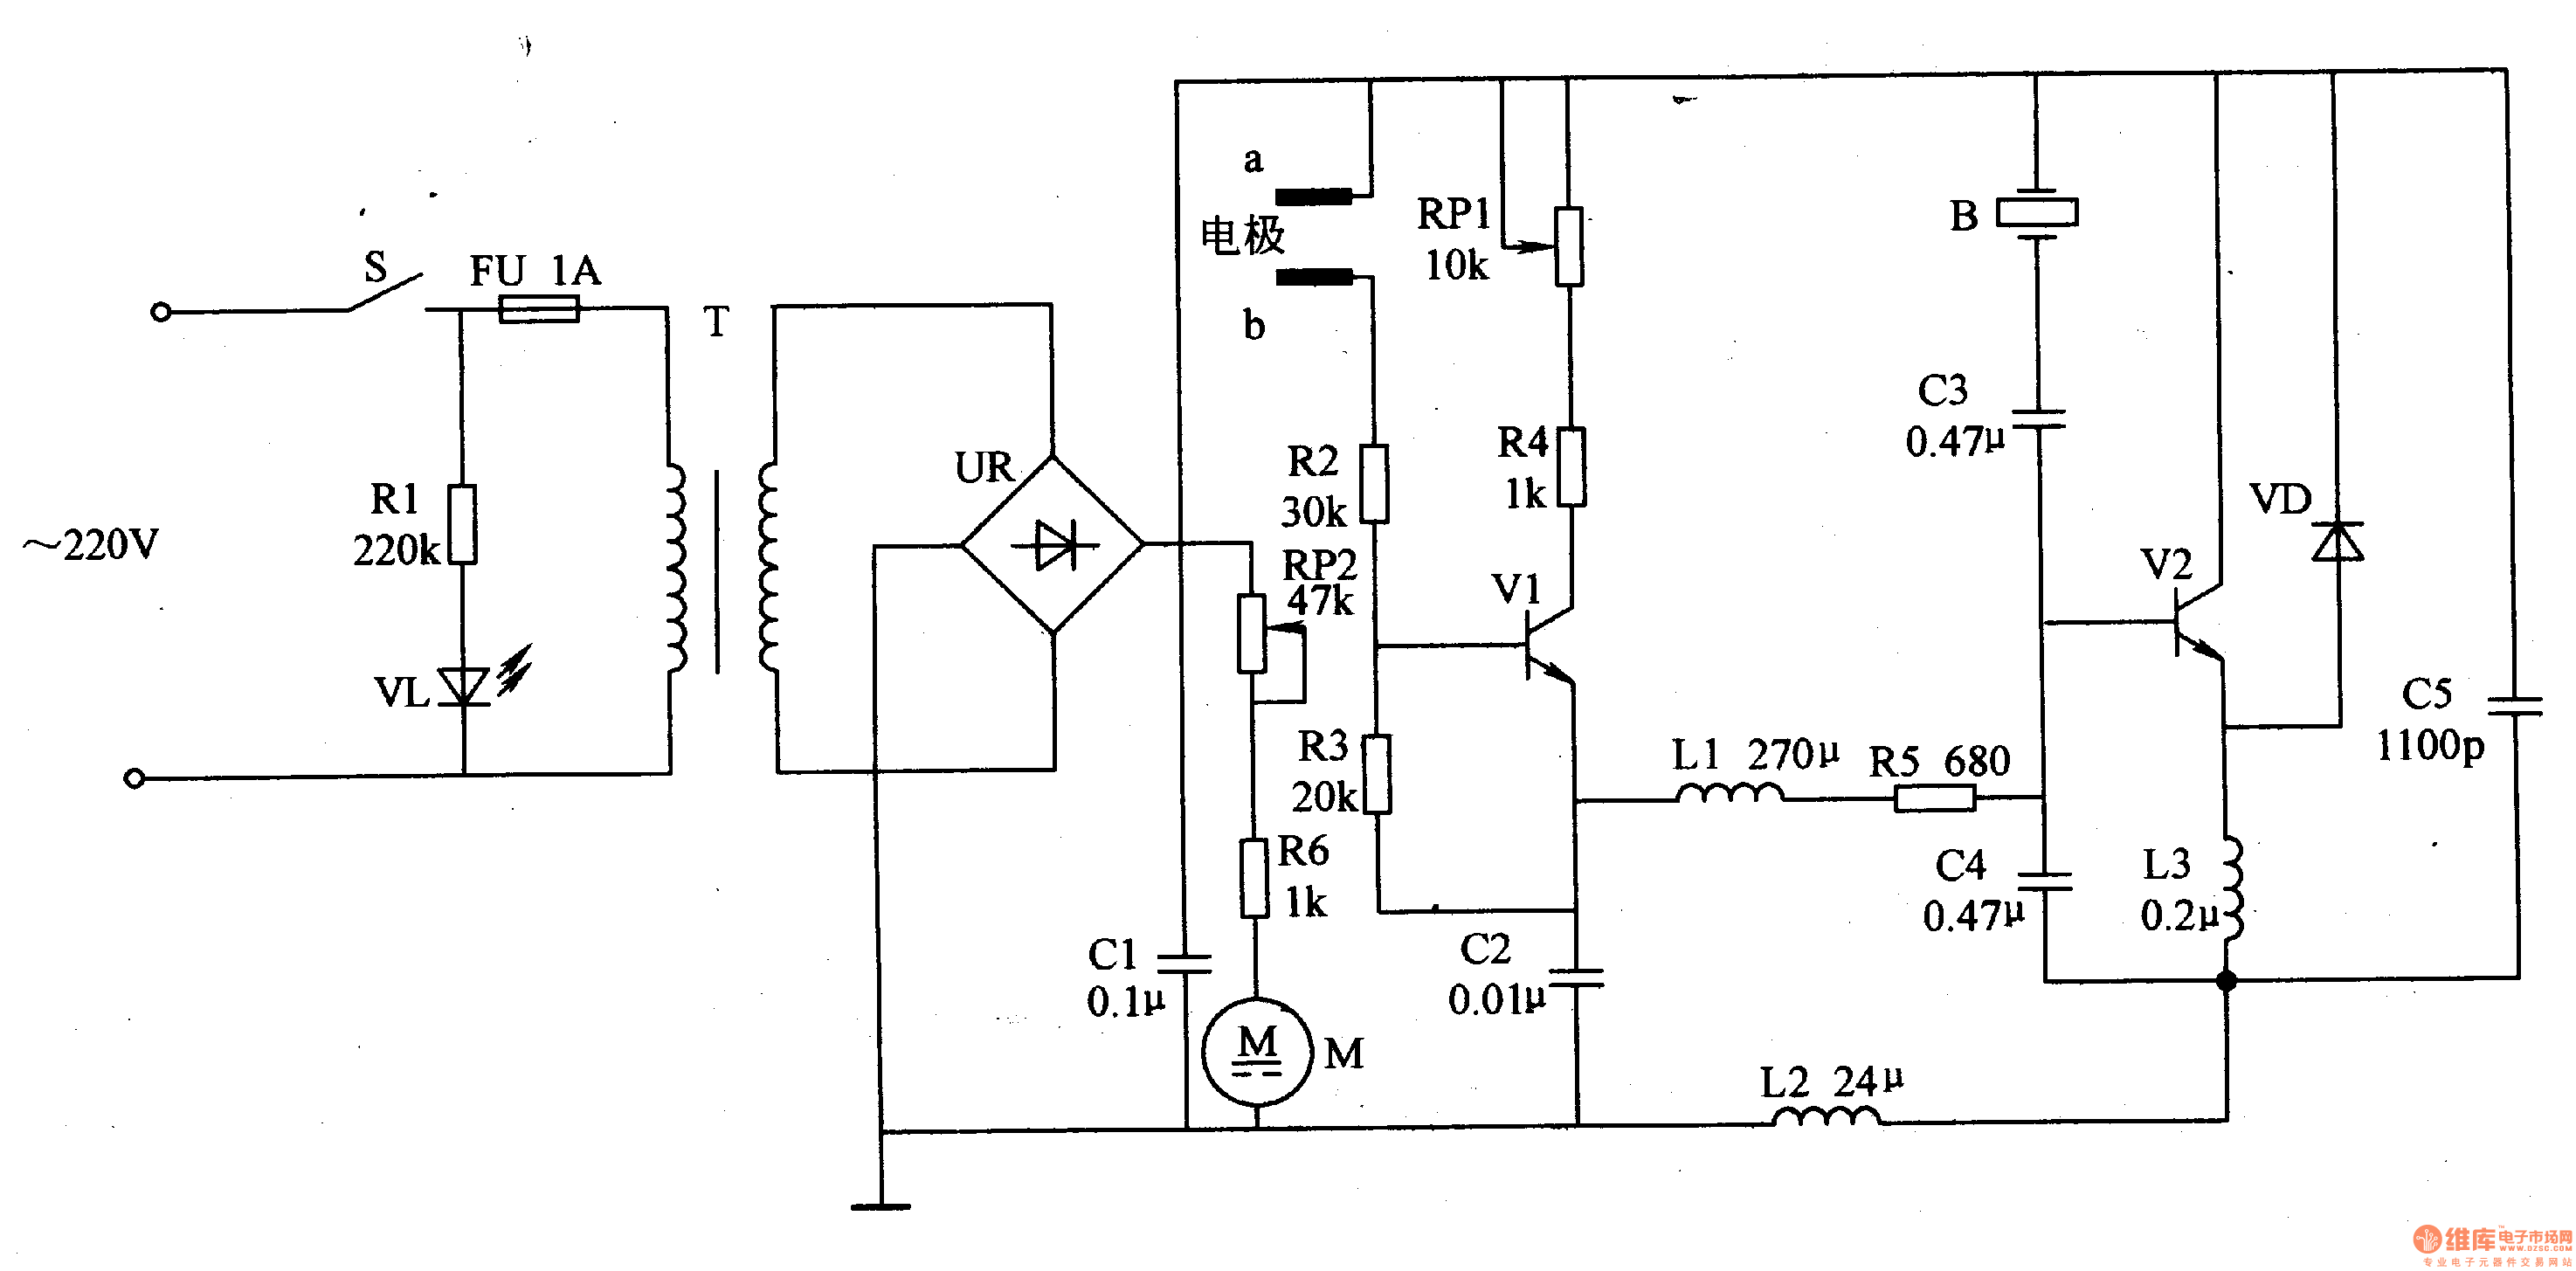
Medical ultrasonic atomizer 3
The medical ultrasonic atomizer circuit consists of a power supply circuit, a low side liquid level protection control circuit, an ultrasonic oscillator, and a fan drive circuit, as depicted in figure 9-112. The power supply circuit includes a power supply...
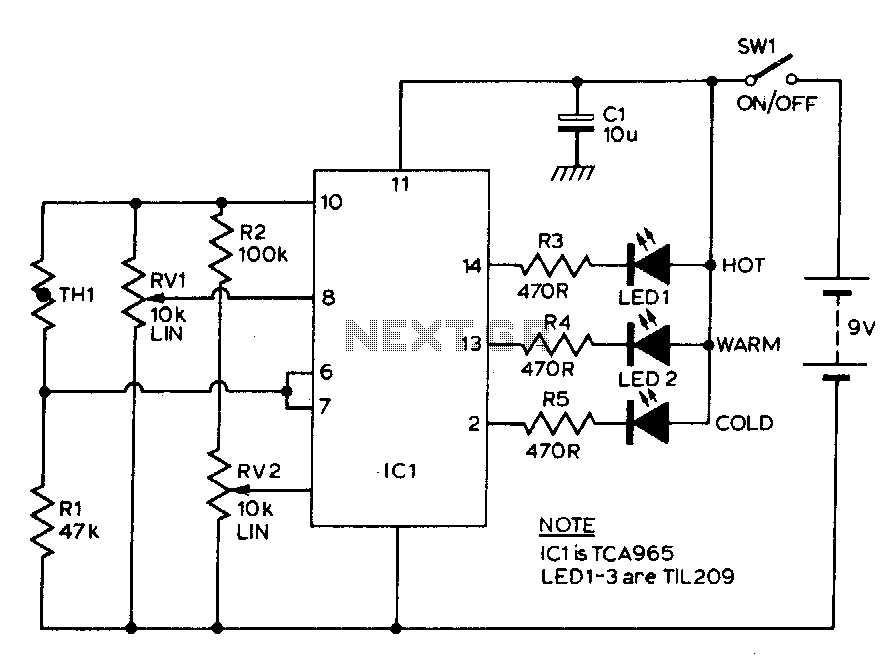
Temperature meter
The TCA965 window discriminator IC enables the use of potentiometers RV1 and RV2 to configure the window height and window width, respectively. Resistor R1 and thermistor TH1 form a potential divider connected across the supply lines. Resistor R1 is selected...
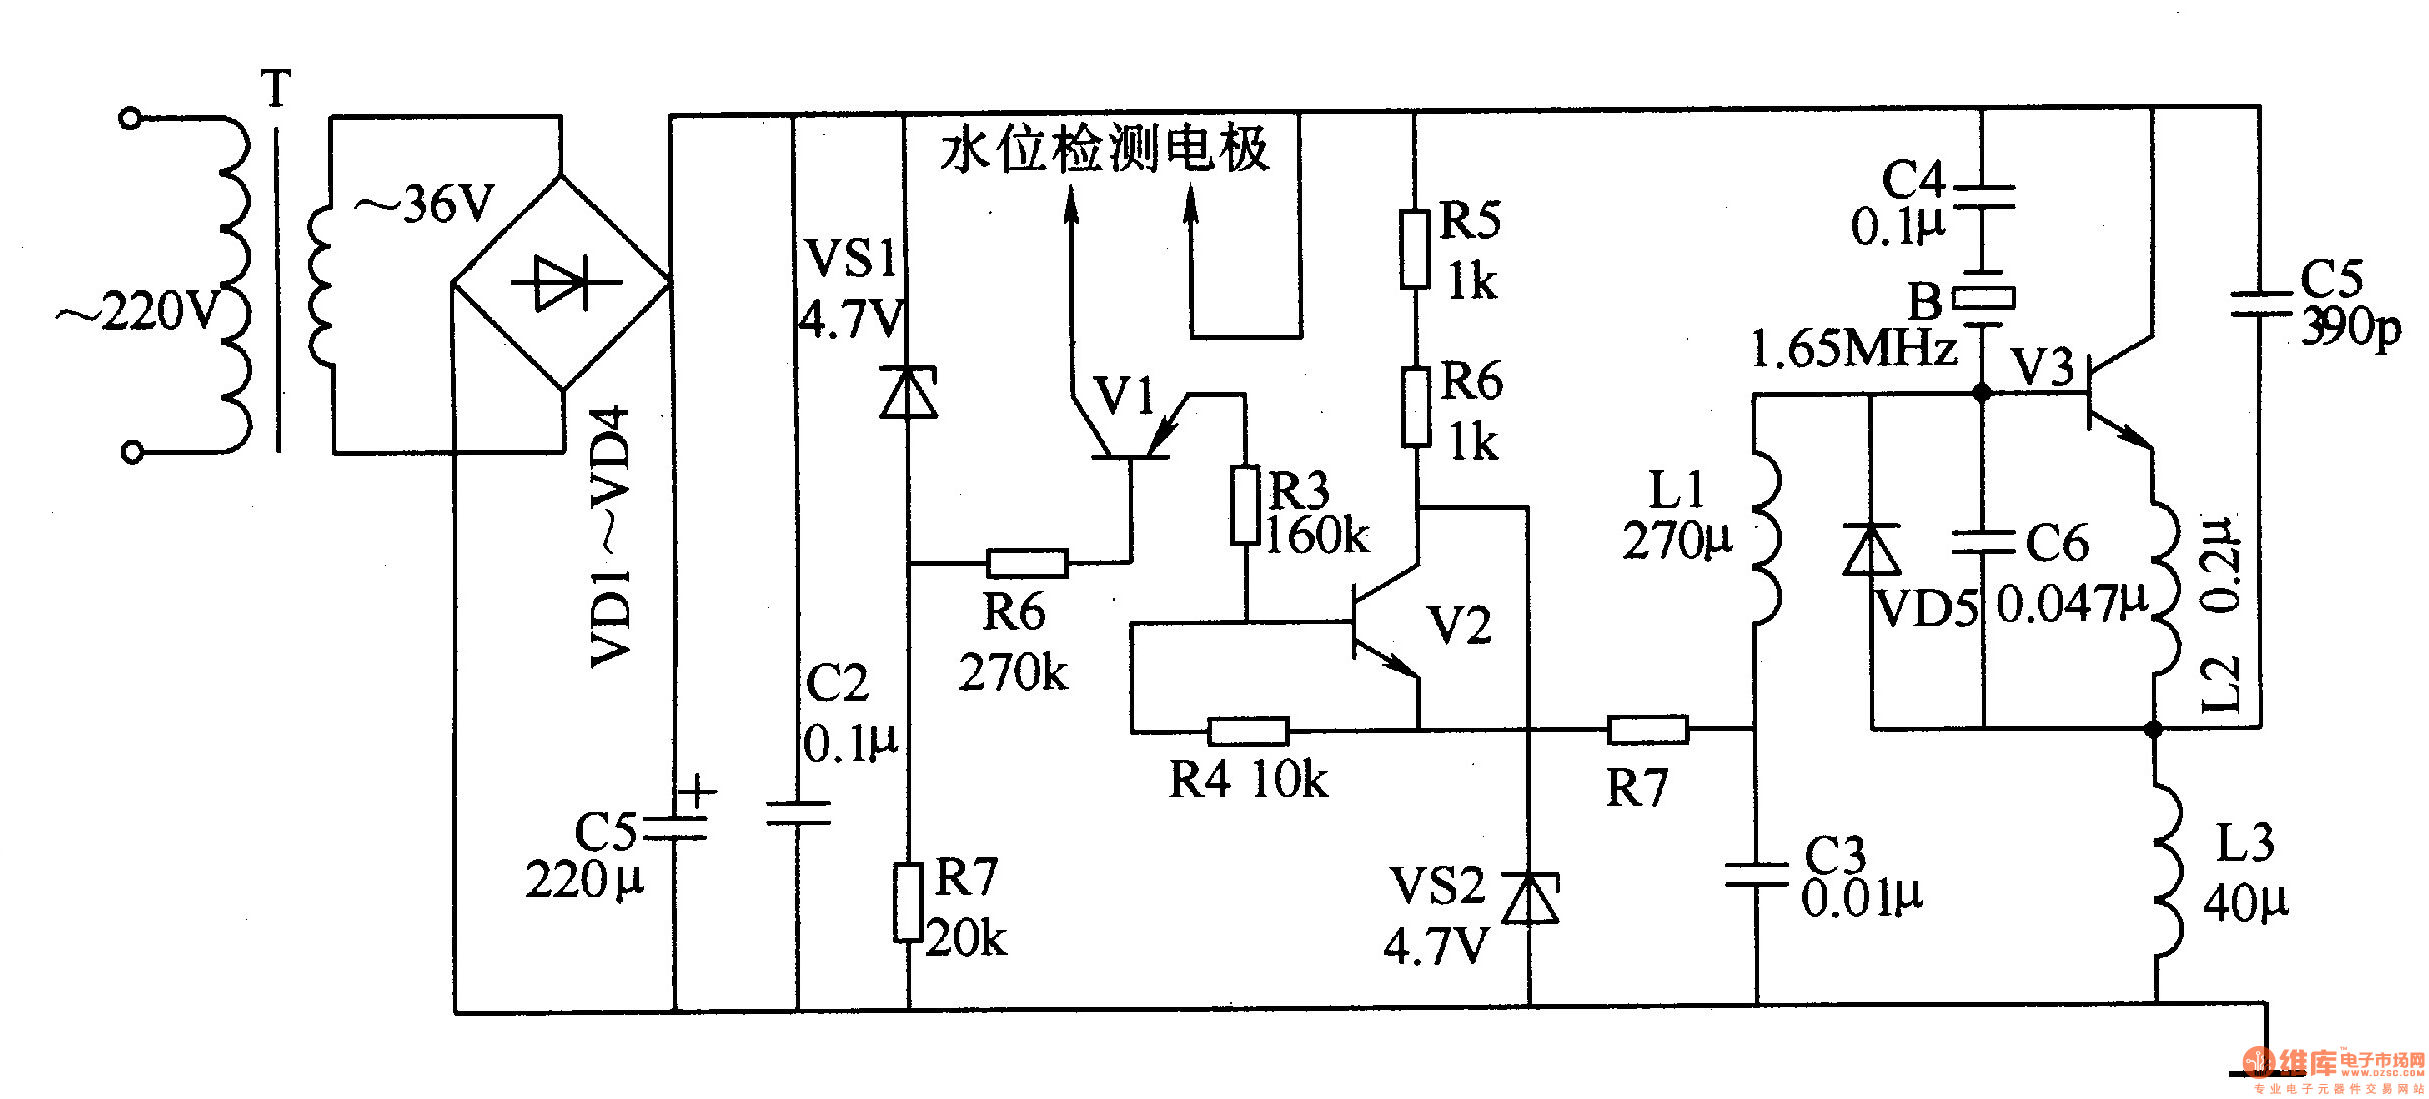
Ultrasonic atomizer 1
The ultrasonic atomizer circuit consists of the power supply circuit, oscillator circuit, and water level control circuit, as illustrated in Figure 3-189. The power supply circuit includes a power transformer (T), rectifier diodes (VD1-VD4), filter capacitors (C1, C2), a zener...