


The Accelerometer Circuit
Description: The schematic for this tutorial is straightforward. It involves connecting the ADXL320 sensor to the PIC microcontroller and an LED. The power supply is assumed to be a +5V battery to power the PIC. A custom power circuit can be designed, or a battery array can be utilized, depending on preference. The PIC serves as the central processing unit of the circuit. It will sample data through its Analog-to-Digital (A/D) converters, which will be evaluated to determine the tilt or acceleration of the board. The sensor outputs an analog signal to the PIC, which is interpreted based on the change in voltage to measure the gravitational force (g's) being experienced. The circuit includes a single LED, which will blink at varying rates to indicate the amount of acceleration or tilt detected by the ADXL320 sensor. This functionality will be implemented through software running on the PIC.
The schematic consists of the following key components: the ADXL320 accelerometer, the PIC microcontroller, and an LED indicator. The ADXL320 sensor is a three-axis accelerometer capable of providing analog output signals corresponding to acceleration along the X, Y, and Z axes. The output signals are fed into the PIC's A/D converter inputs.
The PIC microcontroller is programmed to continuously sample the analog voltage signals from the ADXL320. The software will convert these analog values into digital representations that correspond to the acceleration forces acting on the sensor. By analyzing these values, the microcontroller determines the tilt angle or the rate of acceleration.
The LED is connected to one of the output pins of the PIC. The blinking frequency of the LED is modulated based on the processed acceleration data. For instance, a higher acceleration detected by the ADXL320 will result in a faster blinking rate of the LED, while lower acceleration will cause a slower blink. This visual feedback provides an intuitive way to observe the sensor's response to motion.
The power supply circuitry must ensure that the PIC receives a stable +5V supply. This can be achieved using a simple battery configuration or a more complex power management circuit, depending on the application requirements. Proper decoupling capacitors should be included near the power pins of the PIC and ADXL320 to filter any noise and ensure stable operation.
Overall, this circuit provides a basic yet effective demonstration of interfacing an accelerometer with a microcontroller, showcasing how sensor data can be processed and represented visually through an LED indicator.The schematic is very simple for this tutorial. It is just a matter of wiring up the ADXL320 sensor to the PIC and the LED. The power circuitry assumes you have a battery of +5v to power the PIC. You can create your own custom circuitry for this or just use a battery array. whatever you like. The PIC is the brains of the circuit. Using the A/D`s on the PIC data samples will be taken as input and then evaluated. Based off different inputs the LEDs will blink faster or slower to show how much the board has been tilted or accelerated. This sensor will output an analog signal to the PIC to be interpreted. The signal is measured by its change in voltage when you want to find out how many g`s are currently being `pulled`.
This is just one single LED added to the circuit. Depending on how fast it is blink will tell us how much acceleration or tilt is being applied to the ADXL320 sensor. This will of course all be done in software in the PIC.
The schematic consists of the following key components: the ADXL320 accelerometer, the PIC microcontroller, and an LED indicator. The ADXL320 sensor is a three-axis accelerometer capable of providing analog output signals corresponding to acceleration along the X, Y, and Z axes. The output signals are fed into the PIC's A/D converter inputs.
The PIC microcontroller is programmed to continuously sample the analog voltage signals from the ADXL320. The software will convert these analog values into digital representations that correspond to the acceleration forces acting on the sensor. By analyzing these values, the microcontroller determines the tilt angle or the rate of acceleration.
The LED is connected to one of the output pins of the PIC. The blinking frequency of the LED is modulated based on the processed acceleration data. For instance, a higher acceleration detected by the ADXL320 will result in a faster blinking rate of the LED, while lower acceleration will cause a slower blink. This visual feedback provides an intuitive way to observe the sensor's response to motion.
The power supply circuitry must ensure that the PIC receives a stable +5V supply. This can be achieved using a simple battery configuration or a more complex power management circuit, depending on the application requirements. Proper decoupling capacitors should be included near the power pins of the PIC and ADXL320 to filter any noise and ensure stable operation.
Overall, this circuit provides a basic yet effective demonstration of interfacing an accelerometer with a microcontroller, showcasing how sensor data can be processed and represented visually through an LED indicator.The schematic is very simple for this tutorial. It is just a matter of wiring up the ADXL320 sensor to the PIC and the LED. The power circuitry assumes you have a battery of +5v to power the PIC. You can create your own custom circuitry for this or just use a battery array. whatever you like. The PIC is the brains of the circuit. Using the A/D`s on the PIC data samples will be taken as input and then evaluated. Based off different inputs the LEDs will blink faster or slower to show how much the board has been tilted or accelerated. This sensor will output an analog signal to the PIC to be interpreted. The signal is measured by its change in voltage when you want to find out how many g`s are currently being `pulled`.
This is just one single LED added to the circuit. Depending on how fast it is blink will tell us how much acceleration or tilt is being applied to the ADXL320 sensor. This will of course all be done in software in the PIC.
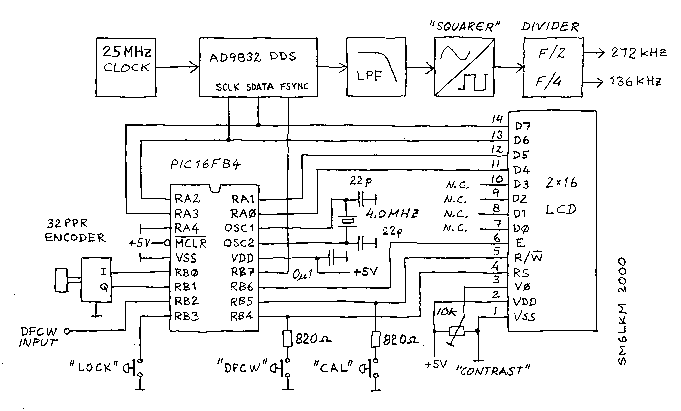
Build a PIC controlled DDS VFO, 0 to 6 MHz
Almost any 2x16 character LCD module with Hitachi HD44780 controller chip will work. The LCD pin numbers on the schematic are not valid for all LCD modules. Please check the actual signal names on your particular LCD module. The selected...
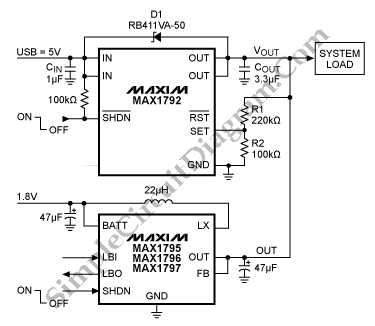
Automatic Switching for Battery USB Power Connection
This is a simple circuit for automatic switchover between battery and USB port. This circuit uses a more general step-up converter architecture.
The circuit designed for automatic switchover between a battery and a USB power source employs a step-up converter...
LED
This series of light switches operates differently from traditional voltage-based systems. These light switches can function directly on the AC power network. The primary components utilized in this circuit are a TRIAC and a Light Dependent Resistor (LDR). The circuit...
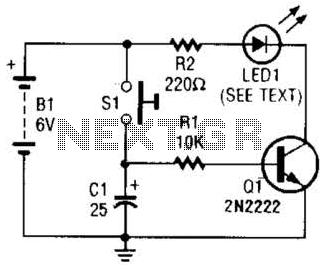
Key Illuminator Circuit
Used as a 10-second momentary illuminator, this circuit can be useful in other applications as well. Pressing SI charges CI, which holds Q1 on and keeps the LED lit for about 10 seconds.
The circuit described functions as a momentary illuminator,...
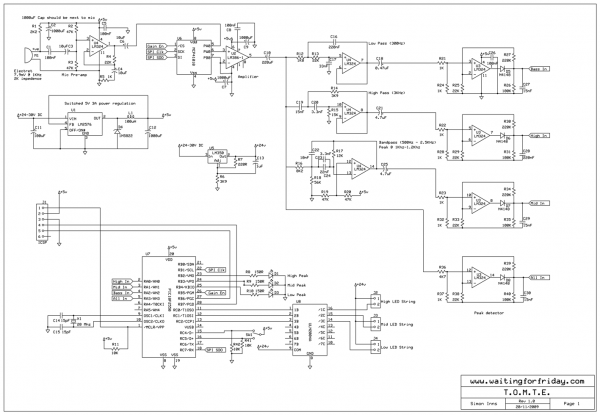
LED Colour Organ circuit
Most existing designs utilize direct switching of lights without any software control and include manual potentiometers for light sensitivity and overall gain settings. There are limited references regarding the frequency filter circuitry, explaining the specific frequencies the circuit is designed...
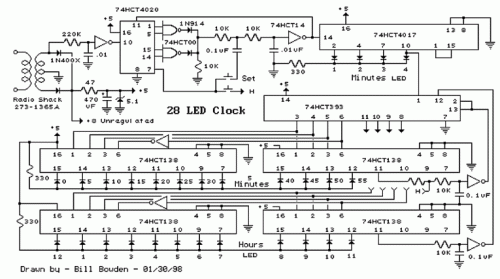
28 LED Clock Timer
This is a programmable clock timer circuit that utilizes individual LEDs to indicate hours and minutes. Twelve LEDs can be arranged in a circle to represent the 12 hours of a clock face, and an additional 12 LEDs can be...
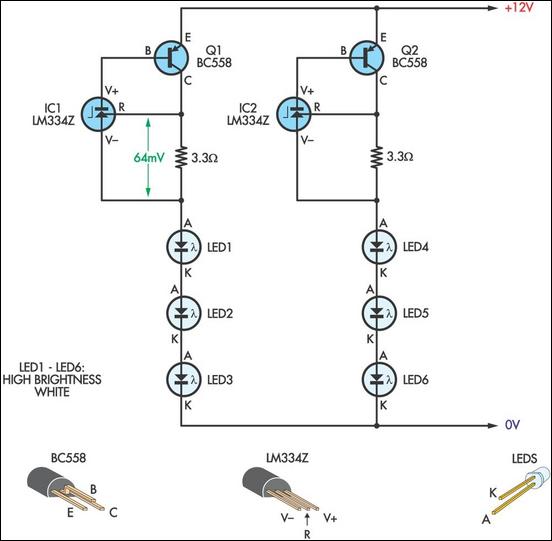
Economical Desk Lamp For Camping
This LED lamp was originally designed for use on a budget solar-charged 12V electrical system. It is bright enough for comfortable reading at night and features constant LED brightness with diminishing battery voltage. The circuit uses six high-brightness white LEDs...
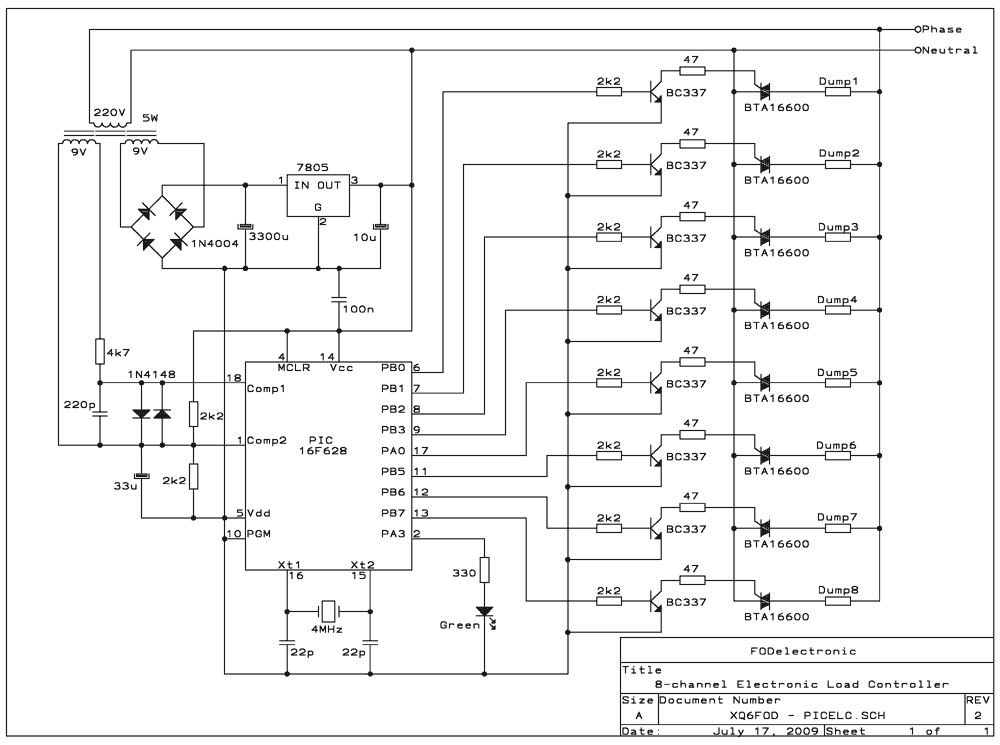
PIC hydro system controller
The ELC presented here has some flexibility, thanks to being software-controlled, but also has its limitations: It's intended for microhydro systems that employ a single-phase synchronous alternator, working at 220-240V, 50Hz, in a power range up to 25 kilowatts, and...
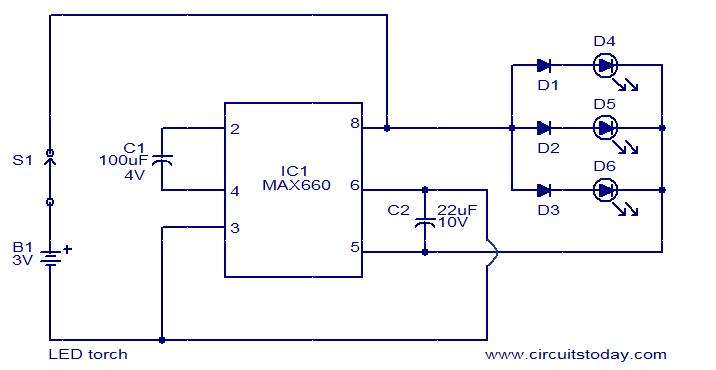
LED torch using MAX660
This is a simple LED torch circuit based on the MAX660 integrated circuit from MAXIM semiconductors. The MAX660 is a CMOS monolithic voltage converter IC capable of driving three bright white LEDs connected in parallel to output pin 8. The...