


Robot eyes
#infrared
#LED
#phototransistor
#555 timer
#obstacle detection
#multivibrator
#transistor
#sensor
#reflection
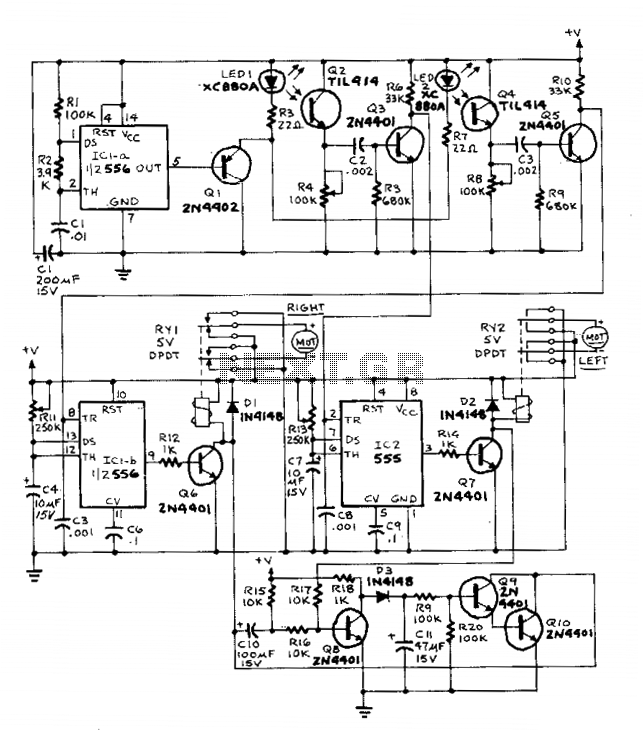
Description: An infrared LED and a phototransistor are utilized for each eye. Half of a 556 timer IC (IC1-a) operates as an astable multivibrator oscillating at a frequency of approximately 1 kHz. This IC drives transistor Q1, which subsequently controls two infrared LEDs, LED1 and LED2. The right eye consists of LED1 and Q2. When an obstacle is detected in front of the right eye, the pulses emitted from LED1 are reflected by the obstacle and received by Q2. The signal from Q2 is then amplified by Q3, triggering IC2, a 555 timer. This IC functions in monostable mode, generating a pulse output that can last up to 2.75 seconds, depending on the resistance value of R11. This pulse output activates relay RY1, which reverses the polarity of the voltage supplied to the motor. The corresponding components of the left eye operate similarly, using the unused half of the 556 (IC1-b). This mechanism causes the robot to turn away from an obstacle.
The circuit design incorporates a dual-eye obstacle detection system, employing infrared technology to enhance the robot's navigation capabilities. Each eye consists of an infrared LED paired with a phototransistor, enabling the detection of obstacles through reflected infrared light. The astable multivibrator functionality of the 556 timer IC (IC1-a) is crucial for generating a continuous square wave signal at approximately 1 kHz, which drives the infrared LEDs.
When an obstacle interrupts the path of the right eye, the reflected light is captured by the phototransistor Q2, which converts the light signal into an electrical signal. This signal is then amplified by transistor Q3, providing sufficient current to trigger the 555 timer IC (IC2). Operating in monostable mode, IC2 produces a pulse output that can be adjusted for duration based on the resistance value of R11, allowing for flexibility in response time. The output pulse energizes relay RY1, which alters the voltage polarity supplied to the motor, enabling the robot to change direction away from the detected obstacle.
The left eye mirrors this functionality, utilizing the second half of the 556 timer IC (IC1-b) to ensure synchronized operation. This dual-eye system enhances the robot's ability to navigate its environment autonomously, effectively avoiding obstacles through real-time detection and response. The design emphasizes reliability and efficiency, making it suitable for various robotic applications requiring obstacle avoidance.An infrared LED and a phototransistor are used for each eye. Half of a 556 timer IC (ICl-a) functions as an as table multivibrator oscillating at a frequency of about 1 kHz. That IC drives transistor Ql which in turn drives the two infrared LED's, LED1 and LED2. The right eye is composed of LED1 and Q2. If an obstacle appears in front of the right eye, pulses from LED1 are reflected by the obstacle and detected by Q2.
The signal from Q2 is amplified by Q3, which triggers IC2, a 555. That IC operates in the monostable mode, and it provides a pulse output with a width of as much as 2.75 seconds, depending on the setting of Rll. That pulse output energizes relay RY1, and that reverses the polarity of the voltage applied to the motor.
Corresponding portions of the circuit of the left eye operate in the same fashion, using the unused half of the 556 (ICl-b). That action causes the robot to turn away from an obstacle.
The circuit design incorporates a dual-eye obstacle detection system, employing infrared technology to enhance the robot's navigation capabilities. Each eye consists of an infrared LED paired with a phototransistor, enabling the detection of obstacles through reflected infrared light. The astable multivibrator functionality of the 556 timer IC (IC1-a) is crucial for generating a continuous square wave signal at approximately 1 kHz, which drives the infrared LEDs.
When an obstacle interrupts the path of the right eye, the reflected light is captured by the phototransistor Q2, which converts the light signal into an electrical signal. This signal is then amplified by transistor Q3, providing sufficient current to trigger the 555 timer IC (IC2). Operating in monostable mode, IC2 produces a pulse output that can be adjusted for duration based on the resistance value of R11, allowing for flexibility in response time. The output pulse energizes relay RY1, which alters the voltage polarity supplied to the motor, enabling the robot to change direction away from the detected obstacle.
The left eye mirrors this functionality, utilizing the second half of the 556 timer IC (IC1-b) to ensure synchronized operation. This dual-eye system enhances the robot's ability to navigate its environment autonomously, effectively avoiding obstacles through real-time detection and response. The design emphasizes reliability and efficiency, making it suitable for various robotic applications requiring obstacle avoidance.An infrared LED and a phototransistor are used for each eye. Half of a 556 timer IC (ICl-a) functions as an as table multivibrator oscillating at a frequency of about 1 kHz. That IC drives transistor Ql which in turn drives the two infrared LED's, LED1 and LED2. The right eye is composed of LED1 and Q2. If an obstacle appears in front of the right eye, pulses from LED1 are reflected by the obstacle and detected by Q2.
The signal from Q2 is amplified by Q3, which triggers IC2, a 555. That IC operates in the monostable mode, and it provides a pulse output with a width of as much as 2.75 seconds, depending on the setting of Rll. That pulse output energizes relay RY1, and that reverses the polarity of the voltage applied to the motor.
Corresponding portions of the circuit of the left eye operate in the same fashion, using the unused half of the 556 (ICl-b). That action causes the robot to turn away from an obstacle.
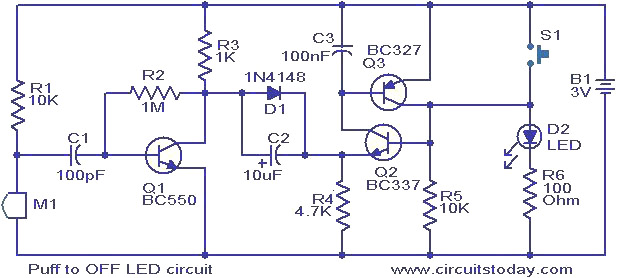
Puff to OFF LED circuit
This circuit features an LED that can be turned off with a puff of air. A condenser microphone (M1) detects the puff. When the push button switch S1 is activated, transistors Q2 and Q3, configured as a latching pair, are...
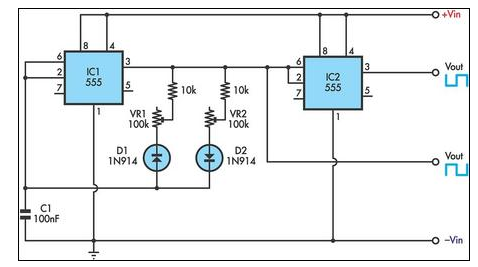
555 Timer Circuit With Variable On/Off Times
This circuit allows for the independent variation of the on/off times of a 555 timer across a wide range. This capability is not achievable with a conventional 555 timer circuit.
The described circuit enhances the functionality of the standard 555 timer...
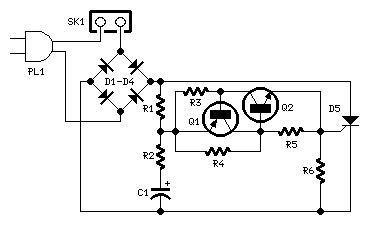
220V LED Flasher
This is a 200W lamp flasher circuit diagram. The frequency of the lamp flashing can be adjusted within a range of 1Hz to 5Hz using the PR1 variable resistor (trimpot). The duty cycle of the lamp flashing can be adjusted...
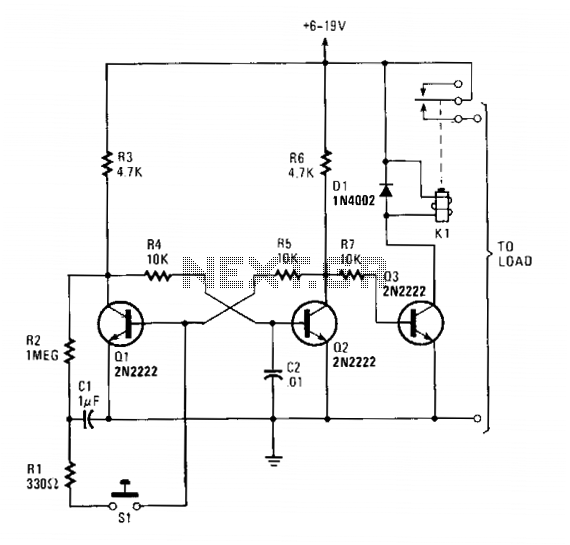
Push-on-push-off electronic switch
Transistors Q1 and Q2 form a flip-flop configuration, while Q3 operates a reed relay. Upon initial power application to the circuit, Q1 and Q3 are in a conducting state, whereas Q2 remains off. A momentary closure of switch S1 triggers...
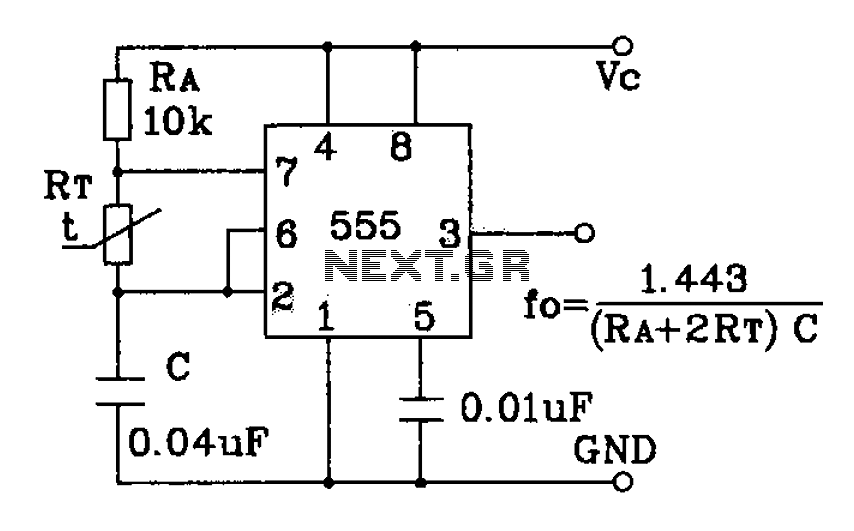
555 precision temperature sensor with temperature frequency converting circuit diagram
555 precision temperature sensor with temperature frequency converting circuit diagram consisting of:
The 555 precision temperature sensor operates by converting temperature variations into frequency signals. This circuit typically utilizes a 555 timer IC configured in astable mode to generate a...
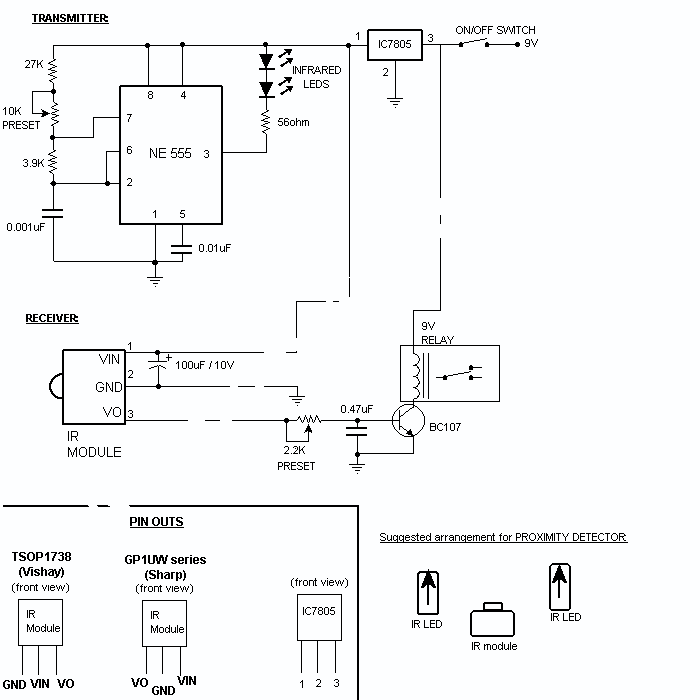
infrared beam proximity detector
This circuit can be used as an infrared beam barrier as well as a proximity detector. The circuit uses the very popular Sharp IR module (Vishay module can also be used). The pin numbers shown in the circuit are for...
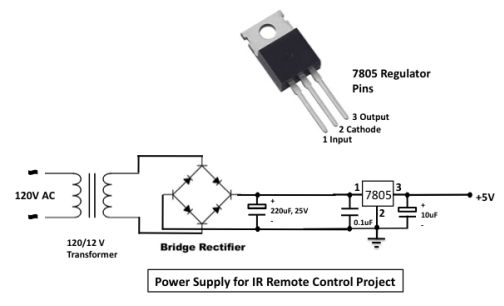
infrared toggle switch for home
The infrared (IR) toggle switch project aims to provide a control mechanism for electrical appliances lacking remote operation features. The objective is to create a device that allows users to plug in a 120V AC appliance and control its ON...
555 circuits
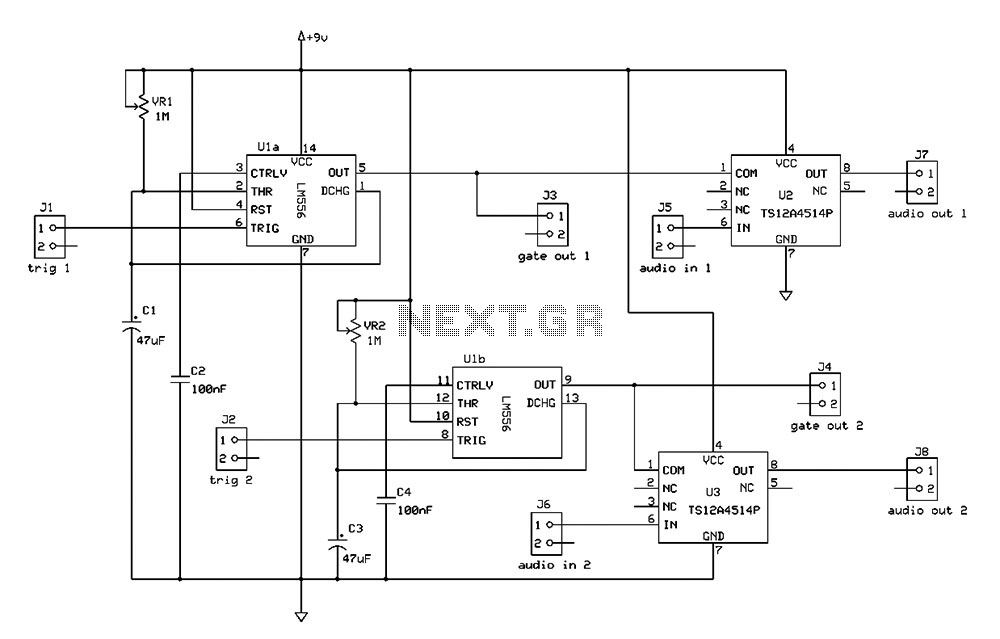
The Switchgate is a simple dual gate circuit based on a 556 timer configured in monostable mode, featuring a trigger input that activates two switches. The outputs of the monostables are also available individually. Recent research has led to the...
Light Related
Watch the video below to gain a better understanding of how a light-emitting diode (LED) functions. An LED is recognized as one of the most effective optoelectronic devices available. This device emits a relatively narrow bandwidth of visible or invisible...