


Line Detector
#IR sensor
#voltage comparator
#autonomous robot
#line following
#optical sensor
#robot motion
#black line detection
#white line detection
#maze solving
#high contrast
Description: One of the simplest methods to demonstrate the autonomous motion of a robot is by having it follow a line. There are competitions for the fastest robots or those capable of navigating complex line mazes. Lines can be high-contrast black on a white background or white on a dark background. A standard detector circuit in this domain employs an infrared (IR) optical sensor in conjunction with a voltage comparator. The IR sensor comprises an infrared LED and a phototransistor positioned side by side. The phototransistor generates a variable voltage based on the reflective surface nearby. The comparator's negative input connects to the IR sensor, while the positive input connects to an adjustable voltage. By fine-tuning this voltage, the comparator can output either a low or high voltage depending on the reflective surface it detects. For this project, the Vishay TCRT5000 optical sensor, which has a maximum output at a distance of 2mm but operates effectively in a range from 1mm to 12mm, is utilized. A table derived through experimentation clarifies the voltage output from various sources. Research conducted using online resources revealed several documents that were instrumental in constructing the circuit for the line detector. One noteworthy document was the manual for the CBA Line Following Module, featuring multiple socketed detectors and a straightforward comparator circuit. Most line-following robots utilize multiple sensors; articles discussing the advantages of using two, three, four, or even five sensors were also found. However, simultaneous activation of multiple sensors may lead to false readings, necessitating that only one sensor be active at a time. Although this approach prolongs the reading process, it enhances accuracy. Up to eight sensors can be supported, with fixed positions based on experience regarding optimal placement for detecting acute line angles and junctions. The final circuit is available as an Eagle schematic file for download. JP1 interfaces with a microcontroller, such as BasicX, while signals A, B, and C serve as inputs to a decoder. Each decoded line produces a low signal that activates both the IR diode and the IR receiver transistor of the corresponding optical sensor OSx. All IR diode anodes connect to 5V through a single 220 Ohm resistor, and the collectors of the IR transistors connect to JP2. For normal operation, JP2 is jumpered, allowing the output from the optical sensors to connect to the A comparator of the LM339 quad comparator chip. The potentiometer R2 can be adjusted to ensure that the comparator output is low when the optical sensor is over a recognized surface, such as a black line. Conversely, for white lines on a black surface, the output should go high when the sensor detects the white line. An LED assists in setting the potentiometer and indicates when the output is low, signifying the recognition of a black surface. The comparator output is routed back to the microcontroller via output X on JP1. A stand-alone remote IR sensor can connect to JP3, featuring its own potentiometer R5, comparator IC1B, monitor LED, and microcontroller output Y on JP1. Similarly, a second stand-alone remote IR sensor can be connected to JP4, with its comparator output Z available on JP1. The line detector is constructed on strip board, with EAGLE used for the layout.
The circuit design for this line-following robot integrates several key components to ensure effective operation. The Vishay TCRT5000 optical sensor, known for its reliability, serves as the primary detection mechanism. The arrangement of the IR LED and phototransistor allows for efficient reflection detection, with the phototransistor's output voltage varying according to the surface's reflectivity. The LM339 quad comparator chip performs the critical function of comparing the output voltage from the sensors against a reference voltage, which can be adjusted using the potentiometer R2. This adaptability allows the system to differentiate between various surface types, ensuring accurate line detection.
The layout of the circuit is optimized for performance, with careful consideration given to the positioning of the sensors to maximize detection accuracy, particularly at line junctions and acute angles. The use of multiple sensors enhances the robot's ability to navigate complex paths, although the design incorporates mechanisms to prevent false readings from simultaneous sensor activation. The integration of additional remote IR sensors through JP3 and JP4 expands the system's capabilities, allowing for more versatile applications in line-following scenarios. The inclusion of monitoring LEDs provides visual feedback during calibration, facilitating easier adjustments to the comparator settings.
In conclusion, this line-following robot circuit exemplifies a well-thought-out design that balances simplicity with functionality, enabling effective autonomous navigation through various line-following challenges. The use of established components and careful circuit layout ensures reliability and performance in competitive environments.One of the simplest ways to show autonomous motion of a robot is to have it follow a line. In fact there are competitions for the fastest or for robots that can follow complex line mazes. Lines are either high contrast black lines on a white background or white lines on a dark background. Following numerous other circuits in this area, the standard detector circuit is to use an infrared (IR) optical sensor and a voltage comparator.
The IR sensor consists of an infrared LED and phototransistor side by side. The phototransistor outputs a variable voltage depending on the reflective surface that it is placed near. The comparator has the negative input connected to the IR sensor and the positive input connected to an adjustable voltage.
By adjusting this voltage appropriately the comparator can output a low or high voltage depending on the reflective surface it is placed near. For this project I decided to use the commonly available Vishay TCRT5000 optical sensor. This sensor has its maximum output at a distance of 2mm (0. 08 ) but can operate in the range from 1mm to 12mm (0. 5 ). To make sense of the voltage output from different sources here is a table that I derived through experimentation: After doing some research using my favorite tool (Google) I found a number of documents are proved useful in building the circuit for my line detector.
One document was the manual for the CBA Line Following Module that features multiple socketed detectors and a simple comparator circuit. Most line-following robots utilize more than one sensor. Here is an excellent article that discusses why multiple sensors are useful and how to use 2, 3, 4 or even 5 sensors.
However the light from two sensors can cause false readings and therefore it is important that only one sensor is active at a time. It takes longer to get readings from all the sensors but the readings are more accurate. · Up to 8 sensors are supported but the positions of these sensors are fixed. These positions are based on experience of where best to position sensors to detect acute line angles and line junctions.
Below is my final circuit which is also available as an Eagle schematic file for download. JP1 is used to interface with a microcontroller such as BasicX. The three signals A, B and C are used as input to a decoder. The output of each decoded line is a low signal that activates both the IR diode and the IR receiver transistor of the correspondingly named optical sensor OSx. The anodes of the IR diodes are all connected to 5V via a single 220 Ohm resistor. The collectors of the IR transistors are all connected to JP2. The header JP2 can be used for other IR input but for normal operation, JP2 is simply jumpered and the output from the optical sensors is connected into the A comparator of the LM339 quad comparator chip.
The potentiometer R2 can be adjusted so that the comparator output is low when the optical sensor is over the surface that needs to be recognized such as a black line. For white lines on a black surface then the output should go high when the sensor is over the white line.
A LED is used to help set the potentiometer and show when the output is low and a black surface has been recognized. The comparator output is sent back to the microcontroller via output X on JP1. A stand-alone remote IR sensor can be plugged into JP3. This sensor has its own potentiometer R5, comparator IC1B, monitor LED and microcontroller output Y on JP1.
Similarly a second stand-alone remote IR sensor can be plugged into JP4 and its comparator output Z is available on JP1. I built the line detector on strip board and used EAGLE to help layout the board
The circuit design for this line-following robot integrates several key components to ensure effective operation. The Vishay TCRT5000 optical sensor, known for its reliability, serves as the primary detection mechanism. The arrangement of the IR LED and phototransistor allows for efficient reflection detection, with the phototransistor's output voltage varying according to the surface's reflectivity. The LM339 quad comparator chip performs the critical function of comparing the output voltage from the sensors against a reference voltage, which can be adjusted using the potentiometer R2. This adaptability allows the system to differentiate between various surface types, ensuring accurate line detection.
The layout of the circuit is optimized for performance, with careful consideration given to the positioning of the sensors to maximize detection accuracy, particularly at line junctions and acute angles. The use of multiple sensors enhances the robot's ability to navigate complex paths, although the design incorporates mechanisms to prevent false readings from simultaneous sensor activation. The integration of additional remote IR sensors through JP3 and JP4 expands the system's capabilities, allowing for more versatile applications in line-following scenarios. The inclusion of monitoring LEDs provides visual feedback during calibration, facilitating easier adjustments to the comparator settings.
In conclusion, this line-following robot circuit exemplifies a well-thought-out design that balances simplicity with functionality, enabling effective autonomous navigation through various line-following challenges. The use of established components and careful circuit layout ensures reliability and performance in competitive environments.One of the simplest ways to show autonomous motion of a robot is to have it follow a line. In fact there are competitions for the fastest or for robots that can follow complex line mazes. Lines are either high contrast black lines on a white background or white lines on a dark background. Following numerous other circuits in this area, the standard detector circuit is to use an infrared (IR) optical sensor and a voltage comparator.
The IR sensor consists of an infrared LED and phototransistor side by side. The phototransistor outputs a variable voltage depending on the reflective surface that it is placed near. The comparator has the negative input connected to the IR sensor and the positive input connected to an adjustable voltage.
By adjusting this voltage appropriately the comparator can output a low or high voltage depending on the reflective surface it is placed near. For this project I decided to use the commonly available Vishay TCRT5000 optical sensor. This sensor has its maximum output at a distance of 2mm (0. 08 ) but can operate in the range from 1mm to 12mm (0. 5 ). To make sense of the voltage output from different sources here is a table that I derived through experimentation: After doing some research using my favorite tool (Google) I found a number of documents are proved useful in building the circuit for my line detector.
One document was the manual for the CBA Line Following Module that features multiple socketed detectors and a simple comparator circuit. Most line-following robots utilize more than one sensor. Here is an excellent article that discusses why multiple sensors are useful and how to use 2, 3, 4 or even 5 sensors.
However the light from two sensors can cause false readings and therefore it is important that only one sensor is active at a time. It takes longer to get readings from all the sensors but the readings are more accurate. · Up to 8 sensors are supported but the positions of these sensors are fixed. These positions are based on experience of where best to position sensors to detect acute line angles and line junctions.
Below is my final circuit which is also available as an Eagle schematic file for download. JP1 is used to interface with a microcontroller such as BasicX. The three signals A, B and C are used as input to a decoder. The output of each decoded line is a low signal that activates both the IR diode and the IR receiver transistor of the correspondingly named optical sensor OSx. The anodes of the IR diodes are all connected to 5V via a single 220 Ohm resistor. The collectors of the IR transistors are all connected to JP2. The header JP2 can be used for other IR input but for normal operation, JP2 is simply jumpered and the output from the optical sensors is connected into the A comparator of the LM339 quad comparator chip.
The potentiometer R2 can be adjusted so that the comparator output is low when the optical sensor is over the surface that needs to be recognized such as a black line. For white lines on a black surface then the output should go high when the sensor is over the white line.
A LED is used to help set the potentiometer and show when the output is low and a black surface has been recognized. The comparator output is sent back to the microcontroller via output X on JP1. A stand-alone remote IR sensor can be plugged into JP3. This sensor has its own potentiometer R5, comparator IC1B, monitor LED and microcontroller output Y on JP1.
Similarly a second stand-alone remote IR sensor can be plugged into JP4 and its comparator output Z is available on JP1. I built the line detector on strip board and used EAGLE to help layout the board
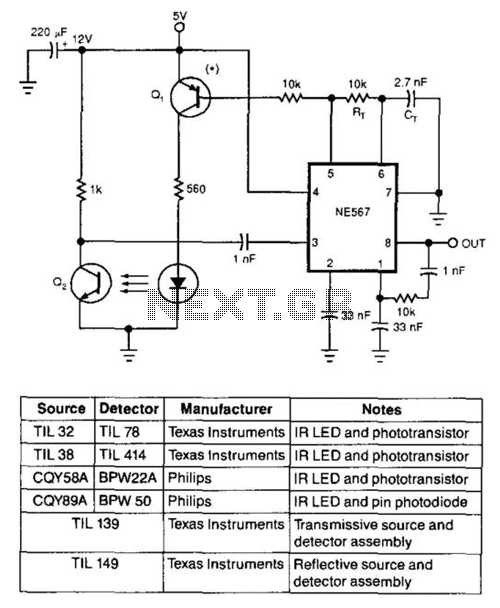
Optical Interruption Sensor
Using only an 8-pin integrated circuit (IC) and a few discrete components, an infrared optical interrupter can be constructed. The NE567 tone decoder includes all necessary circuit elements: a local oscillator, a phase-locked loop (PLL) decoder, and a 100-mA output...
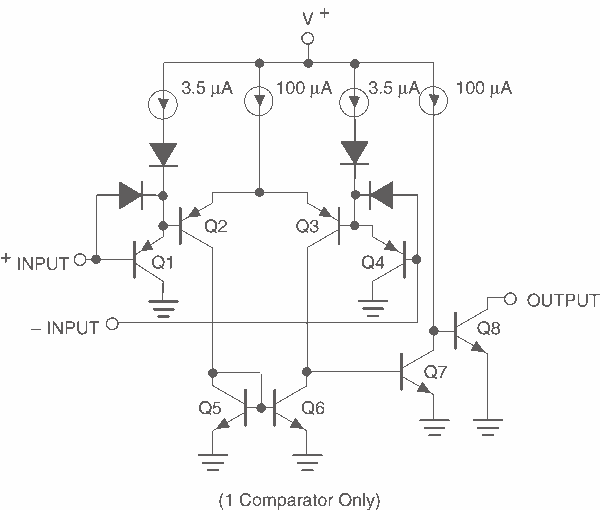
Voltage Comparator Circuits
This page provides basic information about voltage comparator integrated circuits and is to act as reference material for other circuits. The circuits shown are based on the LM339 Quad Voltage Comparator chip or the LM393 Dual Voltage Comparator chip. These...
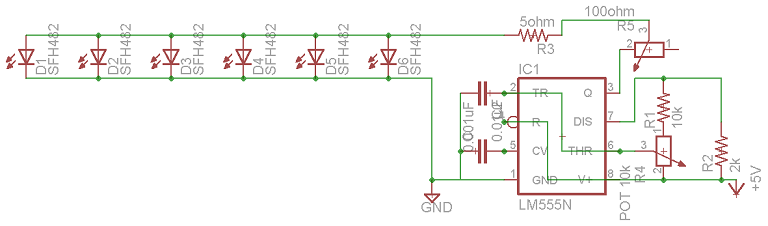
IR Harp
A harp without strings, where infrared (IR) sensor-receiver pairs function as strings in the device. The device detects when a string is plucked, causing blockage of the IR signal, and produces corresponding sounds using Direct Digital Synthesis. Six TSOP sensors...
Bugdozer
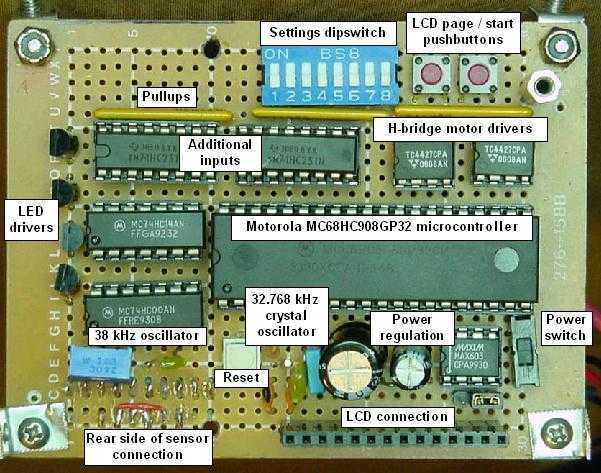
Bugdozer is an autonomous mini-Sumo robot. Her main board consists of a MC68HC908GP32 microcontroller along with input/output support chips, a voltage regulator, a crystal oscillator, and the usual assortment of resistors, capacitors, and switches. All chips are socket mounted.
The...
Connecting an IR Sensor
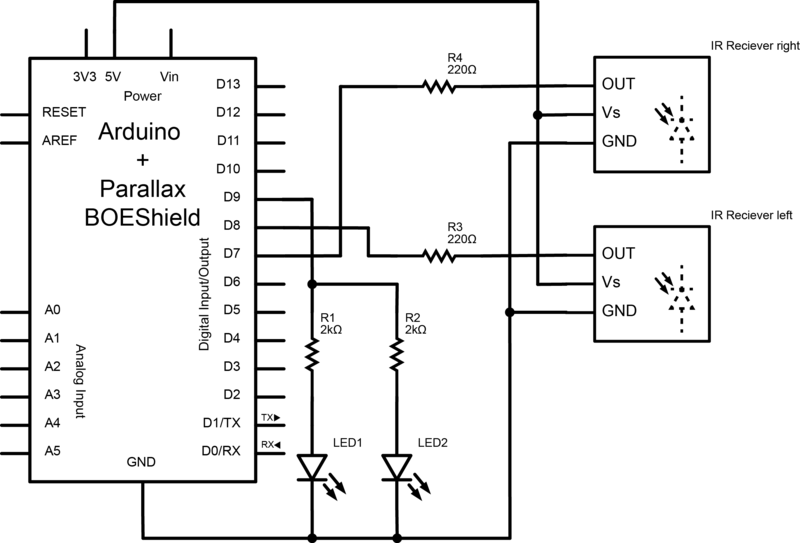
The final step involves connecting the IR LEDs, resistors, and IR receivers to the Arduino. Begin by connecting the +5V pins of the IR receivers (the right pin when facing the receiver) with red wires directly to the +5V port...
ir sensors from scratch line follower
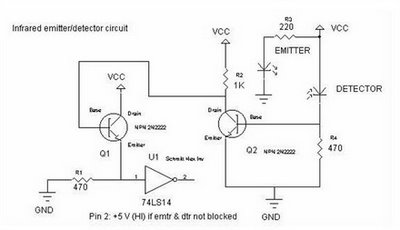
To achieve an optimal voltage swing, the resistance value of R1 must be selected with precision. The sensor resistance, Rsensor, equals a when there is no light exposure and b when light is present. The voltage difference between these two...
IR Short Distance Beam Cut Detector
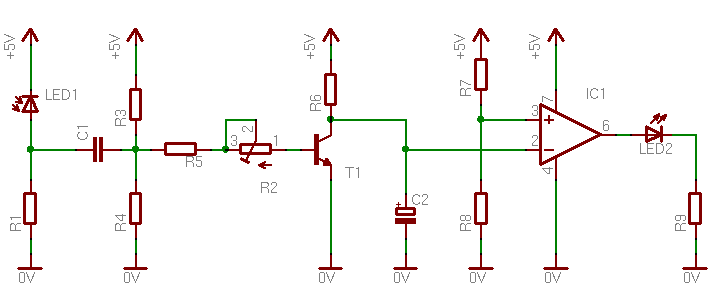
A circuit designed to detect the interruption of a light beam. The initial circuit was a light/dark detector using a photoresistor, which, while capable of detecting light interruptions, suffered from significant interference due to ambient light. This led to the...
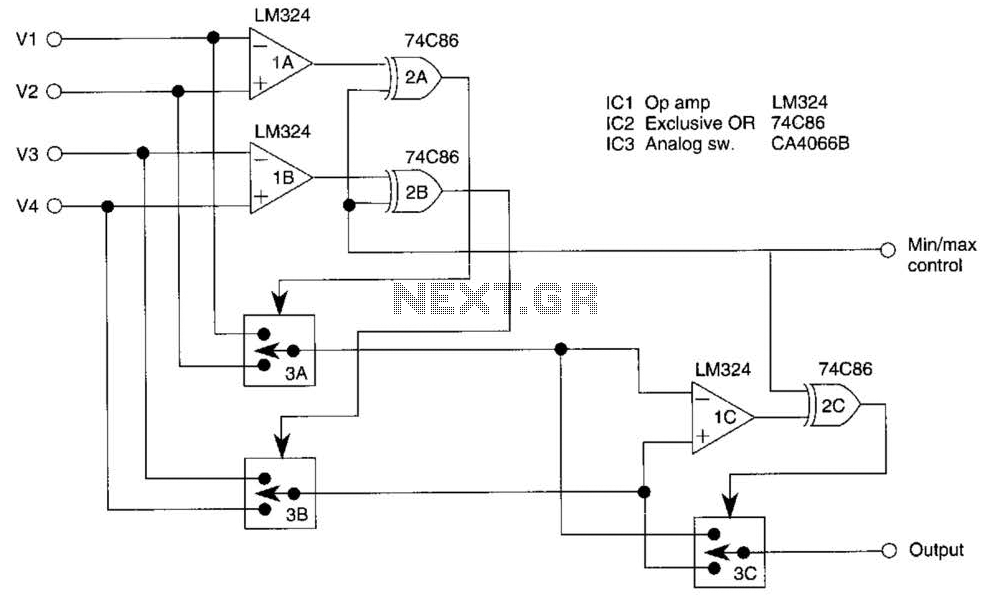
Four-Input Minimum Maximum Selector Circuit
This circuit outputs the maximum or minimum of four input voltages, V1, V2, V3, and V4. Each of these input voltages ranges from 0 to 5 V. The output of the circuit is the maximum of V1, V2, V3, and...
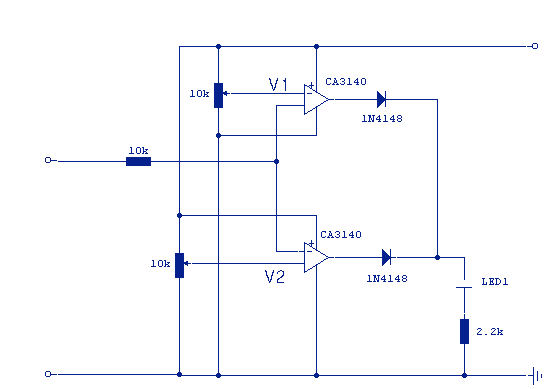
Voltage Comparator Switch
This circuit will provide an indication whenever the input voltage differs from two defined limits, V1 and V2. The supply voltage, Vcc must be higher than the highest input voltage by at least 2 volts. One application here is to...