


Home Brew Compass Sensor
#compass
#sensor
#RCX
#angle measurement
#Dinsmore
#power management
#software integration
#magnetic field
#navigation
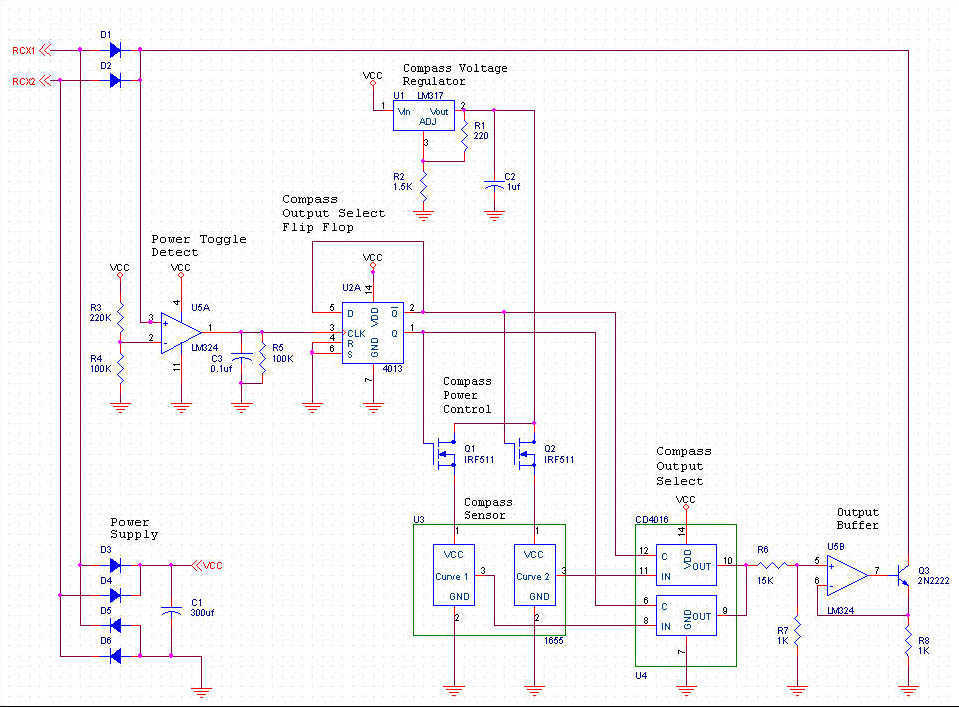
Description: With our design, it takes two readings by the RCX to get one complete reading from the compass sensor. Software then must combine those readings together to determine the angle the compass is pointing. We had to do it this way because of power demands by the Dinsmore part and power limitations of the RCX. More: The Dinsmore compass sensor has two outputs that need to be combined to know the direction you are pointing. Figure 1 shows the compass outputs as they look across a 360 degree turn. It took me a while to make sense of the compass sensor outputs.
The described system involves a Dinsmore compass sensor, which is utilized to determine directional orientation. The sensor produces two distinct outputs that must be processed to yield a single, accurate compass reading. The readings are obtained through an RCX microcontroller, which facilitates the integration of the sensor data.
In operation, the RCX microcontroller captures two sequential readings from the compass sensor. These readings are essential for calculating the angle of orientation relative to magnetic north. The combination of the two readings is necessary due to the inherent power constraints associated with the RCX and the Dinsmore sensor's power requirements. This design choice ensures that the system operates efficiently while still providing reliable directional information.
The outputs from the Dinsmore compass sensor are typically represented as analog voltage levels, corresponding to the compass orientation across a full 360-degree rotation. The software implemented on the RCX is responsible for interpreting these voltage levels, converting them into a usable format, and performing the necessary calculations to derive the final compass heading.
To visualize the sensor outputs, a graphical representation (referred to as Figure 1) would typically illustrate the variations in output voltage as the sensor is rotated. This graphical data can aid in understanding the relationship between the compass sensor's outputs and the physical orientation it represents.
Overall, the design effectively balances power consumption with the need for accurate and reliable compass readings, making it suitable for applications where power resources are limited.With our design, it takes two readings by the RCX to get one complete reading from the compass sensor. Software then must combine those readings together to determine the angle the compass is pointing. We had to do it this way because of power demands by the Dinsmore part and power limitations of the RCX.
The Dinsmore compass sensor has two outputs that need to be combined to know the direction you are pointing. Figure 1 shows the compass outputs as they look across a 360 degree turn. It took me a while to make sense of the compass sensor outputs. To de
The described system involves a Dinsmore compass sensor, which is utilized to determine directional orientation. The sensor produces two distinct outputs that must be processed to yield a single, accurate compass reading. The readings are obtained through an RCX microcontroller, which facilitates the integration of the sensor data.
In operation, the RCX microcontroller captures two sequential readings from the compass sensor. These readings are essential for calculating the angle of orientation relative to magnetic north. The combination of the two readings is necessary due to the inherent power constraints associated with the RCX and the Dinsmore sensor's power requirements. This design choice ensures that the system operates efficiently while still providing reliable directional information.
The outputs from the Dinsmore compass sensor are typically represented as analog voltage levels, corresponding to the compass orientation across a full 360-degree rotation. The software implemented on the RCX is responsible for interpreting these voltage levels, converting them into a usable format, and performing the necessary calculations to derive the final compass heading.
To visualize the sensor outputs, a graphical representation (referred to as Figure 1) would typically illustrate the variations in output voltage as the sensor is rotated. This graphical data can aid in understanding the relationship between the compass sensor's outputs and the physical orientation it represents.
Overall, the design effectively balances power consumption with the need for accurate and reliable compass readings, making it suitable for applications where power resources are limited.With our design, it takes two readings by the RCX to get one complete reading from the compass sensor. Software then must combine those readings together to determine the angle the compass is pointing. We had to do it this way because of power demands by the Dinsmore part and power limitations of the RCX.
The Dinsmore compass sensor has two outputs that need to be combined to know the direction you are pointing. Figure 1 shows the compass outputs as they look across a 360 degree turn. It took me a while to make sense of the compass sensor outputs. To de
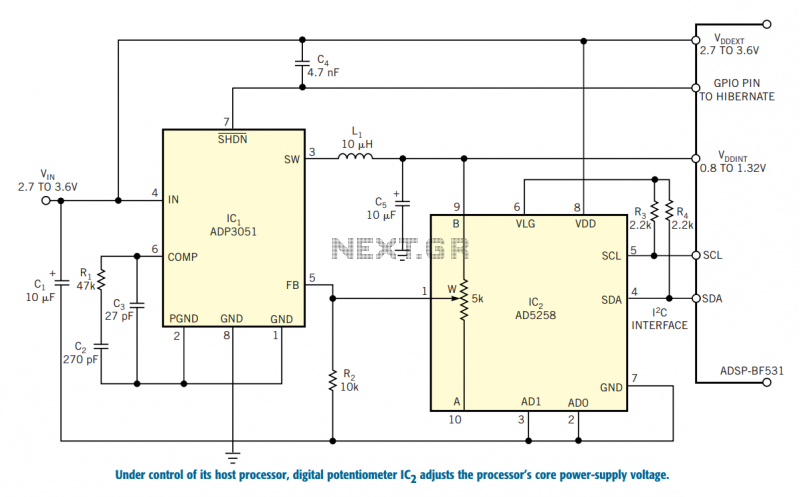
Control a processor`s power supply in real time
In battery-powered applications in which power management is key, a microprocessor may adjust its core voltage corresponding to an increase or a decrease in clock speed, allowing full processing power when necessary but not wasting excess power when idle. The...
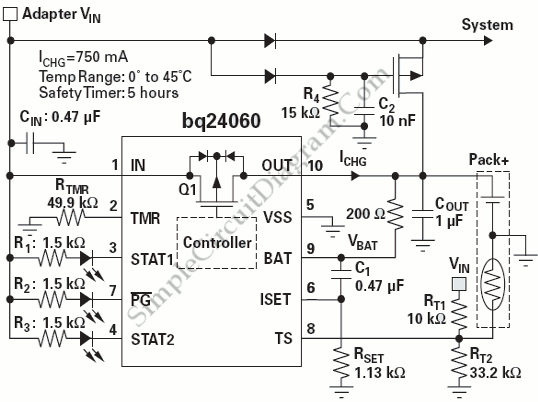
Power Path Management Battery Charger
Powering the system is required by many applications while charging the battery simultaneously. Interaction between the system and charger may result in a...
Power management in electronic systems is critical, particularly in applications that necessitate simultaneous operation and battery charging. This...
A Power Management Interface Circuit For Telecom Hot Swap With Local Dc/dc Conve
New cellular phones have incorporated high-resolution cameras that require bright illumination of the surrounding area to achieve high-quality pictures. Traditional xenon-filled photo flashes cannot be used due to the limited space available in cellular phone cameras. Instead, design engineers utilize...
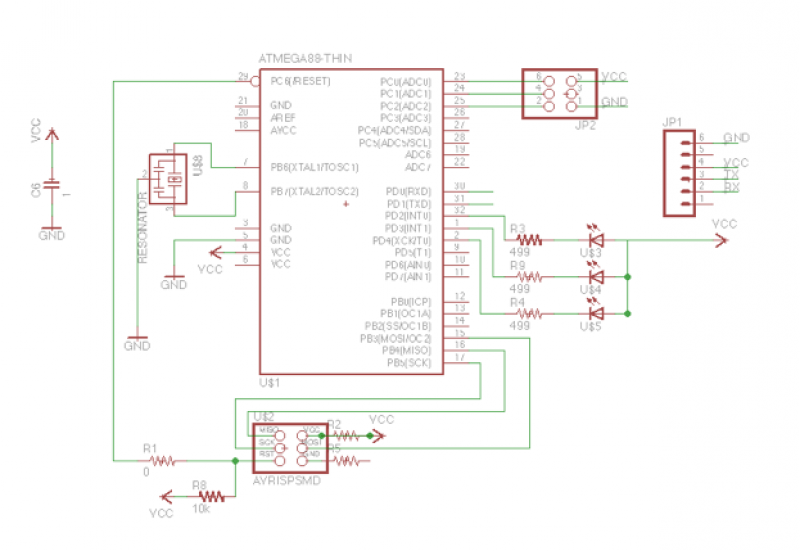
Add a sensor to a board and measure something with it
This week's plan is to build a device that warns of the potential for a knockdown, which is the process by which an over-canvassed ship is laid over on her beam-ends. The risk of sinking is high during this event,...
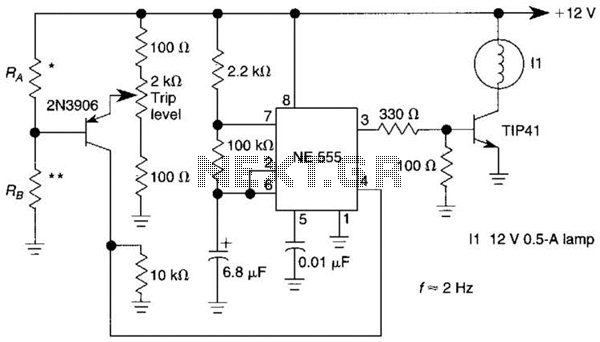
Sensor-Activated Relay Pulser Circuit
A sensor activates transistor Q1 to turn on the low-frequency 555 oscillator, which generates pulses to control LAMP II. The sensor may respond to variations in light or temperature. Either resistor RA or RB can function as the sensor, depending...
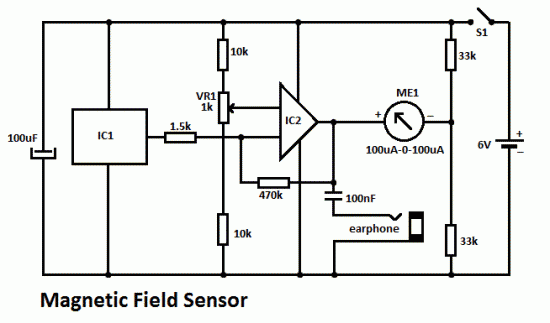
Magnetic Field Sensor circuit
This DIY magnetic field sensor circuit is straightforward and capable of detecting both fixed magnetic fields and those that vary at audio frequencies. The device is not designed for precise measurement of magnetic field strength. A small and relatively weak...
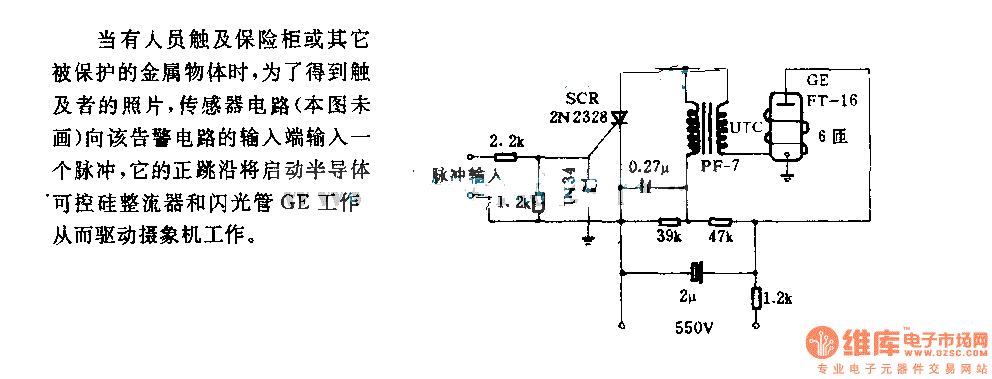
The alarm circuit diagram for safety box and other metal objects
When an individual touches the safety box or other protected metal objects, the sensor circuit generates a pulse to the alarm circuit. The positive edge of this pulse activates the semiconductor and thyristor flash GE, subsequently triggering the camera to...
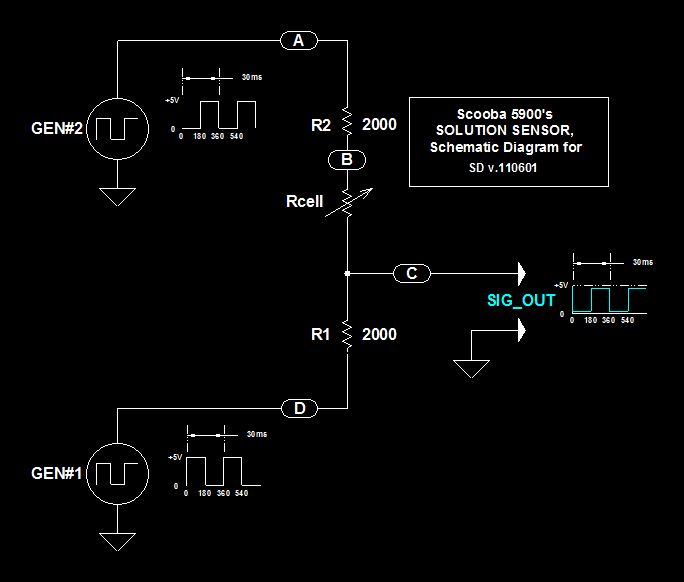
Scoobas Solution Sensing Tactic
This document serves multiple purposes, primarily to document the methods employed by a Scooba robot to detect: a) the presence of an acceptable cleaning solution being delivered to its pump, and b) the excess presence of used solution collected off...
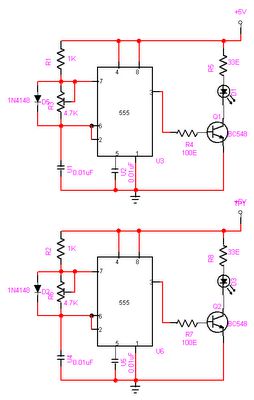
Automatic Room light Control With Bi Directional Visitor Counter
The objective of this project is to create a controller-based model that counts the number of individuals entering a specific room and activates the lighting accordingly. This is achieved through the use of sensors that detect the current number of...