


fotovoor schema
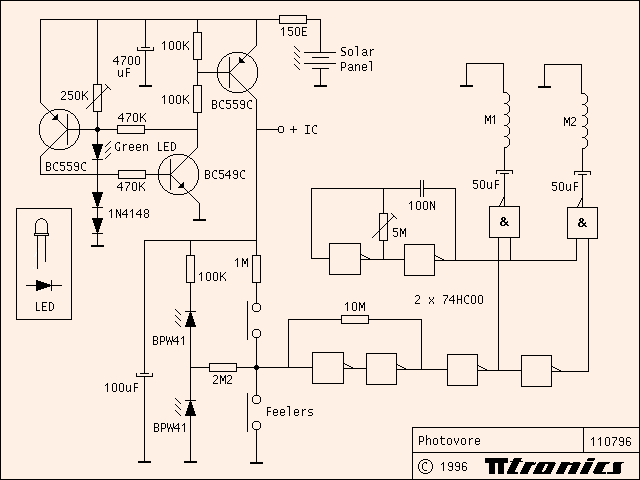
Description: The Photovore's brain consists of two NAND gates and six inverters, utilizing four elements from two 74HC00 integrated circuits (ICs). It incorporates two photodiodes, referred to as "eyes," and two feelers that provide input to a Schmitt trigger, which determines which of the two stepping motors (designated as m1 and m2) receives pulses from the oscillator. The feelers take precedence over the eyes, with the feeler connected to ground having priority over the one connected to the positive supply. If both feelers encounter obstacles, the robot attempts to extricate itself from the situation. The oscillator's frequency can be adjusted using a 5M variable resistor, allowing the seconds hand to achieve approximately 17 revolutions per minute. While faster operation is feasible, it risks the stepper motor turning in the incorrect direction, undermining the Photovore's functionality. Two 47uF capacitors are employed to convert the oscillator's square wave into pulses for the stepping motors of the clocks. The capacitor values are contingent upon the specific stepper motors used; hence, 47uF is appropriate only for the type of clock specified in the parts list. Other stepper-driven clocks (excluding those with synchronous motors) may be utilized if the capacitor is appropriately matched to the load. The ohmic resistance of the stepper coil serves as a useful reference: for a resistance of 300 ohms, 47uF is ideal, whereas a lady's watch with a resistance of 2.6K requires a 4.7uF capacitor. The circuit involving three transistors activates the robot when the solar panel charges a 4700uF capacitor to approximately 2.7 volts and deactivates it if the voltage falls below about 2.2 volts. A 250K variable resistor is utilized to adjust the cutoff voltage. The system functions adequately as long as the clocks operate correctly until they cease. Diodes and the first BC559 transistor limit the voltage supplied to the robot to roughly 4V. An LED indicator illuminates when the voltage limiter is engaged. If the voltage continues to rise in direct sunlight, no damage occurs; however, the clocks will stop, and the robot will no longer exhibit signs of activity.
The Photovore circuit design is a sophisticated integration of components that work together to create a responsive and adaptive robotic system. The use of two NAND gates and six inverters from the 74HC00 ICs allows for effective logic operations, enabling the robot to process inputs from its sensory apparatus. The photodiodes serve as light sensors, providing essential feedback to the control system, while the feelers act as tactile sensors that prioritize immediate environmental interactions.
The Schmitt trigger plays a crucial role in ensuring that the signals from the photodiodes and feelers are clean and free from noise, which can be critical in determining the correct motor response. The stepping motors m1 and m2 are responsible for the robot's movement, and the ability to adjust the oscillator frequency using a variable resistor allows for fine-tuning of the robot's speed. The design's flexibility in accommodating various stepping motors through capacitor selection highlights the versatility of the circuit.
The power management aspect of the circuit is equally important. The solar panel's ability to charge the 4700uF capacitor ensures that the Photovore can operate autonomously in sunlight. The voltage cutoff mechanism, adjustable via a variable resistor, protects the circuit from low voltage conditions that could lead to malfunction. Furthermore, the inclusion of diodes and the BC559 transistor as voltage limiters safeguards the sensitive components from over-voltage conditions, ensuring longevity and reliability in operation.
Overall, the Photovore's design is a well-thought-out system that combines various electronic principles to create a functional and efficient robotic entity capable of navigating its environment. The careful selection of components and their arrangement within the circuit contributes to the robot's ability to perform its intended tasks effectively.The Photovore`s brain is built around two NAND-gates and six inverters, four elements each in two 74HC00 IC`s. Two photodiodes (the `eyes`) and two feelers provide input for a Schmitt-trigger, determining which of the two stepping motors (clocks m1 and m2) receives pulses from the oscillator.
The feelers have priority over the eyes, and the feeler connected to zero has priority over the one connected to plus. So if both feelers touch obstacles, the robot will try to push itself out of trouble. The frequency of the oscillator can be increased with the 5M variable resistor until the seconds hand makes about 17 revolutions per minute. Faster running is possible, but then the stepper will just as easily turn in the wrong direction, which would rob the Photovore of its sense of purpose.
The two 47uF capacitors convert the square wave from the oscillator into pulses for the stepping motors in the clocks. Their value depends on the steppers, so 47uF is correct only for the type of clock mentioned in the parts list.
Other stepper-driven clocks (not those equipped with a synchronous motor) can be used if you match the capacitor to the load. Ohmic resistance of the stepper coil is a useful guide: At 300 ohms, 47uF was perfect, while a lady`s watch having a resistance of 2K6 needed 4.
7uF (Yes, a Photovore using lady`s watches is possible :) The circuit around the three transistors turns the robot on when the solar panel has charged the capacitor (4700uF) to about 2. 7 volts, and off if the voltage drops below some 2. 2 volts. Use the 250K variable resistor to adjust the switch-off level. You`re OK if the clocks run well until they stop. The diodes and the first BC559 also limit the voltage supplied to the robot to about 4 V. The LED lits up when the limiter is active. If the voltage (in direct sunlight) still rises nothing will be damaged, but the clocks stop. The robot doesn`t feel hungry anymore.
The Photovore circuit design is a sophisticated integration of components that work together to create a responsive and adaptive robotic system. The use of two NAND gates and six inverters from the 74HC00 ICs allows for effective logic operations, enabling the robot to process inputs from its sensory apparatus. The photodiodes serve as light sensors, providing essential feedback to the control system, while the feelers act as tactile sensors that prioritize immediate environmental interactions.
The Schmitt trigger plays a crucial role in ensuring that the signals from the photodiodes and feelers are clean and free from noise, which can be critical in determining the correct motor response. The stepping motors m1 and m2 are responsible for the robot's movement, and the ability to adjust the oscillator frequency using a variable resistor allows for fine-tuning of the robot's speed. The design's flexibility in accommodating various stepping motors through capacitor selection highlights the versatility of the circuit.
The power management aspect of the circuit is equally important. The solar panel's ability to charge the 4700uF capacitor ensures that the Photovore can operate autonomously in sunlight. The voltage cutoff mechanism, adjustable via a variable resistor, protects the circuit from low voltage conditions that could lead to malfunction. Furthermore, the inclusion of diodes and the BC559 transistor as voltage limiters safeguards the sensitive components from over-voltage conditions, ensuring longevity and reliability in operation.
Overall, the Photovore's design is a well-thought-out system that combines various electronic principles to create a functional and efficient robotic entity capable of navigating its environment. The careful selection of components and their arrangement within the circuit contributes to the robot's ability to perform its intended tasks effectively.The Photovore`s brain is built around two NAND-gates and six inverters, four elements each in two 74HC00 IC`s. Two photodiodes (the `eyes`) and two feelers provide input for a Schmitt-trigger, determining which of the two stepping motors (clocks m1 and m2) receives pulses from the oscillator.
The feelers have priority over the eyes, and the feeler connected to zero has priority over the one connected to plus. So if both feelers touch obstacles, the robot will try to push itself out of trouble. The frequency of the oscillator can be increased with the 5M variable resistor until the seconds hand makes about 17 revolutions per minute. Faster running is possible, but then the stepper will just as easily turn in the wrong direction, which would rob the Photovore of its sense of purpose.
The two 47uF capacitors convert the square wave from the oscillator into pulses for the stepping motors in the clocks. Their value depends on the steppers, so 47uF is correct only for the type of clock mentioned in the parts list.
Other stepper-driven clocks (not those equipped with a synchronous motor) can be used if you match the capacitor to the load. Ohmic resistance of the stepper coil is a useful guide: At 300 ohms, 47uF was perfect, while a lady`s watch having a resistance of 2K6 needed 4.
7uF (Yes, a Photovore using lady`s watches is possible :) The circuit around the three transistors turns the robot on when the solar panel has charged the capacitor (4700uF) to about 2. 7 volts, and off if the voltage drops below some 2. 2 volts. Use the 250K variable resistor to adjust the switch-off level. You`re OK if the clocks run well until they stop. The diodes and the first BC559 also limit the voltage supplied to the robot to about 4 V. The LED lits up when the limiter is active. If the voltage (in direct sunlight) still rises nothing will be damaged, but the clocks stop. The robot doesn`t feel hungry anymore.
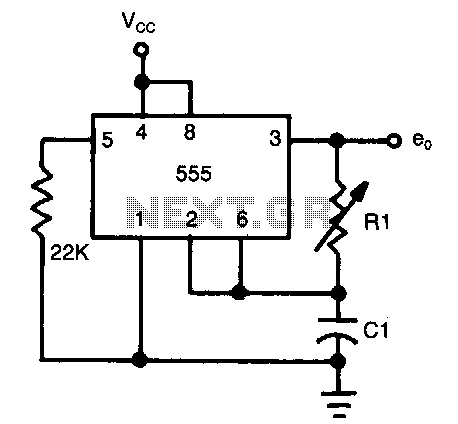
Half-duty-cycle-oscillator
The frequency of oscillation depends on the Rl/Cl time constant, allowing for frequency adjustment by varying Rl. This is a basic circuit.
The described circuit operates based on the relationship between resistance (Rl) and capacitance (Cl), which together form a time...
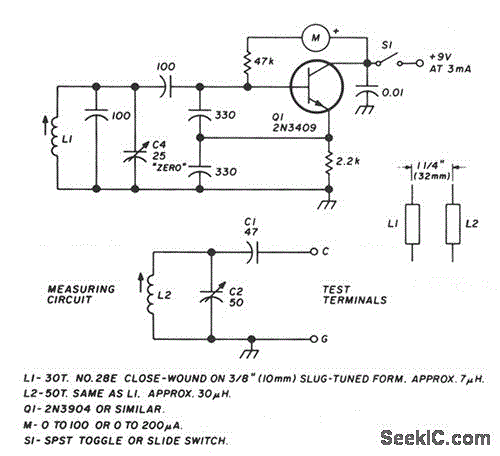
LC CHECKER
The circuit operates on the principle of the grid-dip or absorption effect, which takes place when a parallel resonant circuit is coupled to an oscillator operating at the same frequency. Transistor Q1 functions within a standard Colpitts oscillator circuit, maintaining...
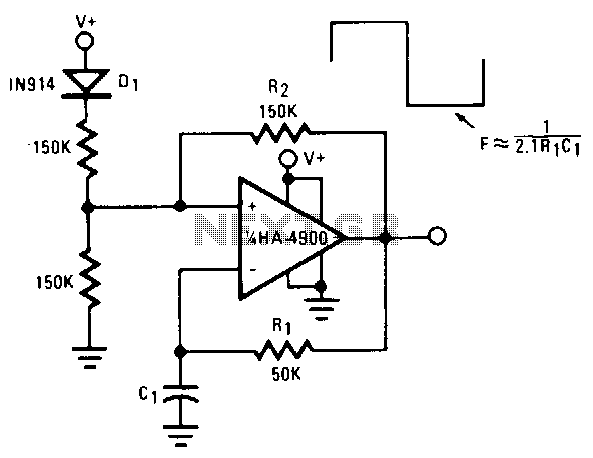
Oscillator-clock-generator
This self-starting fixed-frequency oscillator circuit provides excellent frequency stability. R1 and C1 form the frequency-determining network, while R2 delivers the regenerative feedback. Diode D1 improves stability by compensating for the difference between VaH and VsurrLY. In applications where a precision...
High drive oscillator-flasher
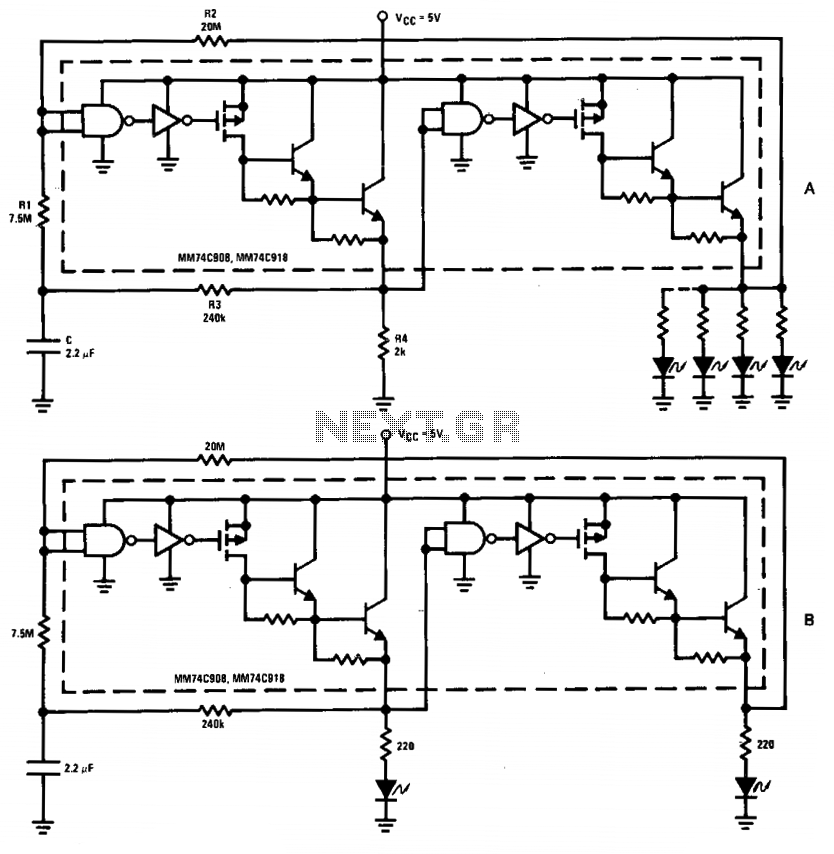
The driver in the package is configured as a Schmitt trigger oscillator (A), utilizing resistors R1 and R2 to create hysteresis. The inverting feedback timing components consist of resistor R3 and capacitor C, while resistor R4 serves as the pull-down...
5-V-oscillator
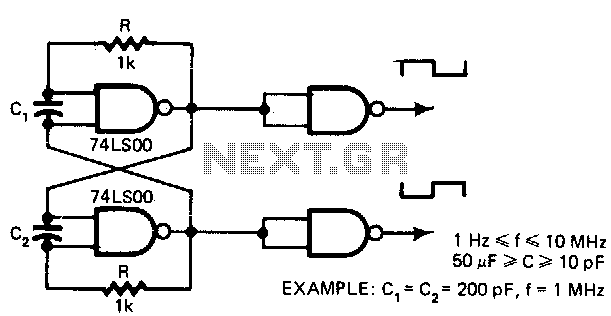
This low-cost oscillator is consistently self-starting and capable of operating from over 1 Hz to 10 MHz, requiring only five components. The period of oscillation can be calculated using the relationship: P = 5 x 10^3 C seconds when C...
Oscillator with frequency doubled output
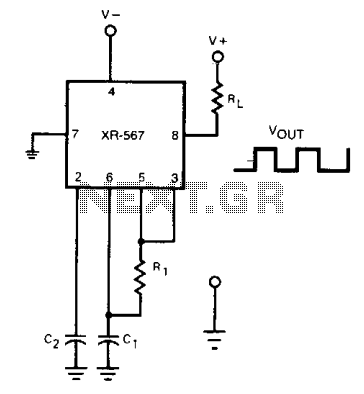
The frequency of the current-controlled oscillator can be doubled by feeding a portion of the square-wave output from pin 5 back to the input at pin 3. This configuration allows the quadrature detector to operate as a frequency doubler, resulting...
Metal detector circuit diagram 6
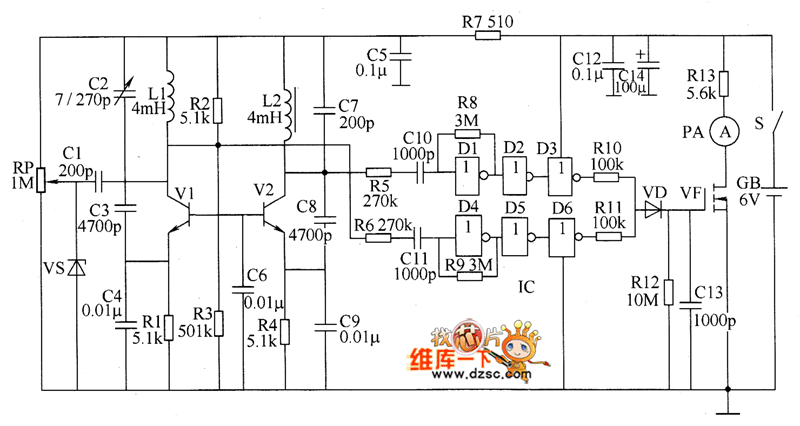
The metal detector circuit consists of several key components including the probe oscillator, reference oscillator, oscillation signal processor, mixing amplifier, and ammeter PA. The probe oscillator is made up of the oscillating tube VI, exploration coil L1, capacitors C1 to...
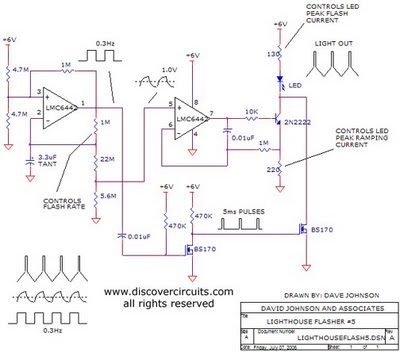
Schematic Diagram Schema HO Train Model Lighthouse Flasher
The aboriginal accessory forms a typical oscillator circuit that produces both a triangle waveform signal and a square wave signal. The triangle signal is fed into a voltage regulator circuit, which converts the triangle voltage signal to a triangle current...
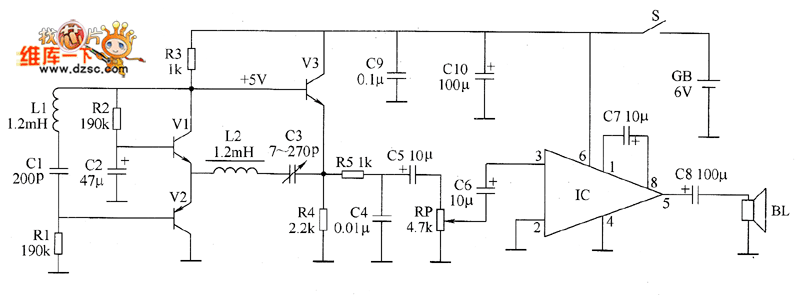
Metal detector circuit diagram 3
The metal detector consists of a probe oscillator, a reference oscillator, an audio amplifier, and various other components, as illustrated in the schematic. The probe oscillator is made up of transistors V1 and V2, a detection coil L1, a capacitor...