


Detecting an ultrasonic beacon
#ultrasonic
#beacon
#receiver
#robotics
#target detection
#distance measurement
#sensor array
#navigation
#automation
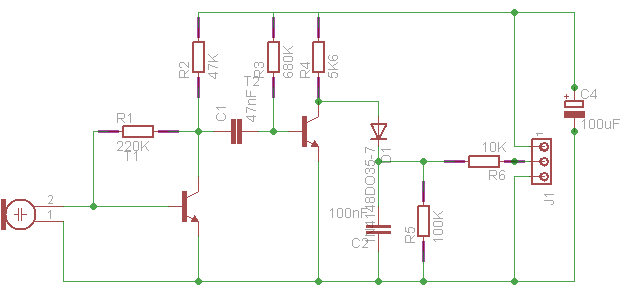
Description: An ultrasonic beacon and an ultrasonic receiver function similarly to a beam barrier circuit. However, instead of sounding an alarm when an object interrupts the ultrasonic path, the goal is to locate the ultrasonic beacon by moving the receiver. This application is particularly useful in robotics, where ultrasounds are employed to detect a target, which is essentially the beacon itself. For the emitter, or the beacon, an oscillator configured to operate at a frequency of 35-45 kHz is required. This can be accomplished using a 555 timer, a microcontroller with PWM, or discrete components. A simpler design is preferred, even though it may result in less control over the signal shape. The effective range of the system is approximately 4 meters, with the receiver outputting over 100 mV for a detected signal at this distance, and 4 V when the object is within 1 meter. The emission cone has an angle of nearly 40 degrees, making it an excellent module for robotics applications. These modules can be connected to a microcontroller's ADC port, providing distance-dependent voltage outputs. This functionality allows not only for determining the direction of the incoming sound but also for estimating the distance to the beacon. The output is available via the "signal" pin, which delivers approximately 0.5 V in relation to the power level of the detected ultrasonic signal. There is a proposal to create an MP3 file containing pulses at 35 to 45 kHz and connect the ultrasonic transducer directly to a phone using the headphone jack to eliminate the need for a transmitter circuit.
An ultrasonic beacon and receiver system is integral to various applications, particularly in robotics, where precise location tracking is essential. The beacon operates by emitting ultrasonic waves at a frequency typically ranging from 35 kHz to 45 kHz. This frequency range is chosen for its effective propagation characteristics and minimal interference from ambient noise.
The design of the beacon can utilize several methods for generating the ultrasonic waves. A 555 timer can be configured in astable mode to produce a square wave signal, which drives an ultrasonic transducer. Alternatively, a microcontroller can be programmed to generate the desired frequency using PWM techniques, allowing for more control over the waveform characteristics. Discrete components can also be employed to create an oscillator circuit, though this may require more precise tuning.
The receiver detects the ultrasonic waves emitted by the beacon and converts them into an electrical signal. The output voltage of the receiver is directly proportional to the strength of the detected signal, which varies based on the distance from the beacon. At a distance of 4 meters, the receiver typically provides an output of over 100 mV, while at closer ranges (less than 1 meter), the output can reach up to 4 V. This significant variation in output voltage allows for effective distance measurement.
The wide emission cone of approximately 40 degrees enhances the system's ability to detect the beacon from various angles, making it suitable for dynamic environments where the orientation of the receiver may change. The output from the receiver can be interfaced with a microcontroller's ADC port, enabling the system to not only determine the direction of the incoming ultrasonic waves but also to estimate the distance to the beacon based on the output voltage.
In addition, the concept of using an MP3 file to generate the ultrasonic pulses presents an innovative approach to simplify the design. By encoding the ultrasonic frequency into an audio file and playing it through a smartphone's headphone jack, the need for a dedicated transmitter circuit can be eliminated. This method leverages existing technology to facilitate the generation of ultrasonic signals, potentially reducing costs and complexity in the overall system design.An ultrasonic beacon and a ultrasonic receiver is very similar to a beam barrier circuit, the only difference is we don`t sound an alarm when an object breaks the ultrasonic path, but instead we try to locate the ultrasonic beacon by moving the receiver. This can be useful in robotics, when we use ultrasounds to detect a target (which in fact is t he beacon itself). For the emitter (the beacon itself), all we need is an oscillator set for a 35-45KHz frequency. We can achieve this using a 555 timer, a microcontroller and PWM, or discrete components. The simple the better, even though we lack some control over the signal shape: The range is excellent, at about 4 meters, the receiver was returning more than 100mV, for the detected signal, while at less than 1 meter it was putting out 4 V. The emission cone`s angle is almost 40 degrees wide. An excellent module for robotics! These modules can be hooked up to a microcontroller`s ADC port, and will return distance dependent voltages.
So not only you can use them to spot the direction the sound is coming from, but you can also estimate the distance. The output is via the "signal" pin, which will provide approximately 0. 5V depending on the power level of the detected ultrasonic signal. i have an idea that if we craete a mp3 file which has pulses of 35 to 45khz and then connect the ultrasonic transducer directly to the phone and using head phone jack and play that mp3 file then the tx side ckt can be eliminated what say
An ultrasonic beacon and receiver system is integral to various applications, particularly in robotics, where precise location tracking is essential. The beacon operates by emitting ultrasonic waves at a frequency typically ranging from 35 kHz to 45 kHz. This frequency range is chosen for its effective propagation characteristics and minimal interference from ambient noise.
The design of the beacon can utilize several methods for generating the ultrasonic waves. A 555 timer can be configured in astable mode to produce a square wave signal, which drives an ultrasonic transducer. Alternatively, a microcontroller can be programmed to generate the desired frequency using PWM techniques, allowing for more control over the waveform characteristics. Discrete components can also be employed to create an oscillator circuit, though this may require more precise tuning.
The receiver detects the ultrasonic waves emitted by the beacon and converts them into an electrical signal. The output voltage of the receiver is directly proportional to the strength of the detected signal, which varies based on the distance from the beacon. At a distance of 4 meters, the receiver typically provides an output of over 100 mV, while at closer ranges (less than 1 meter), the output can reach up to 4 V. This significant variation in output voltage allows for effective distance measurement.
The wide emission cone of approximately 40 degrees enhances the system's ability to detect the beacon from various angles, making it suitable for dynamic environments where the orientation of the receiver may change. The output from the receiver can be interfaced with a microcontroller's ADC port, enabling the system to not only determine the direction of the incoming ultrasonic waves but also to estimate the distance to the beacon based on the output voltage.
In addition, the concept of using an MP3 file to generate the ultrasonic pulses presents an innovative approach to simplify the design. By encoding the ultrasonic frequency into an audio file and playing it through a smartphone's headphone jack, the need for a dedicated transmitter circuit can be eliminated. This method leverages existing technology to facilitate the generation of ultrasonic signals, potentially reducing costs and complexity in the overall system design.An ultrasonic beacon and a ultrasonic receiver is very similar to a beam barrier circuit, the only difference is we don`t sound an alarm when an object breaks the ultrasonic path, but instead we try to locate the ultrasonic beacon by moving the receiver. This can be useful in robotics, when we use ultrasounds to detect a target (which in fact is t he beacon itself). For the emitter (the beacon itself), all we need is an oscillator set for a 35-45KHz frequency. We can achieve this using a 555 timer, a microcontroller and PWM, or discrete components. The simple the better, even though we lack some control over the signal shape: The range is excellent, at about 4 meters, the receiver was returning more than 100mV, for the detected signal, while at less than 1 meter it was putting out 4 V. The emission cone`s angle is almost 40 degrees wide. An excellent module for robotics! These modules can be hooked up to a microcontroller`s ADC port, and will return distance dependent voltages.
So not only you can use them to spot the direction the sound is coming from, but you can also estimate the distance. The output is via the "signal" pin, which will provide approximately 0. 5V depending on the power level of the detected ultrasonic signal. i have an idea that if we craete a mp3 file which has pulses of 35 to 45khz and then connect the ultrasonic transducer directly to the phone and using head phone jack and play that mp3 file then the tx side ckt can be eliminated what say
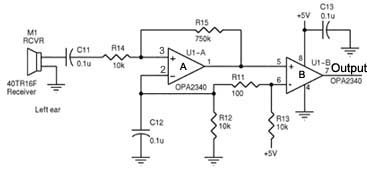
Opamps and ultrasonic receiver circuitry
Assistance is required regarding the circuits provided below. The focus is on an ultrasonic receiver circuit that utilizes two ultrasonic components.
The ultrasonic receiver circuit is designed to detect ultrasonic waves, typically in the frequency range of 20 kHz to several...
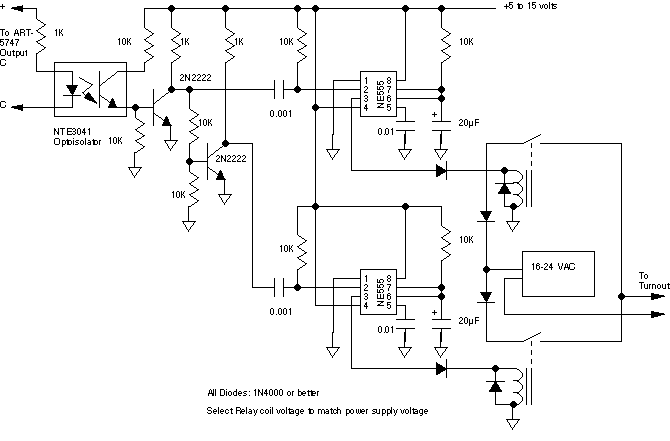
5474 tips
The Aristo ART-5474 Accessory Panel is a complete receiver designed to control accessories using buttons A through E on the Train Engineer transmitter. The ART-5474 is capable of controlling two turnouts, one constant load such as lights, and can trigger...
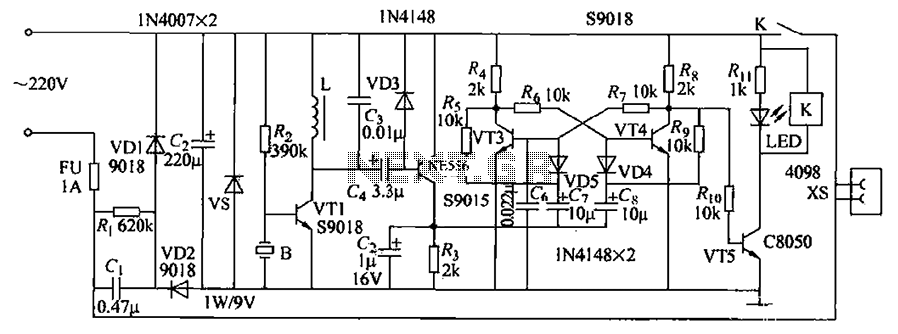
Asia ultrasonic remote control circuit
Asia ultrasonic remote control switch. This example describes the use of a gas pressure bisulfite ultrasound flute (made of rubber, available in olive and flat round shapes) for control. When the ultrasonic flute is activated, the remote control switch turns...
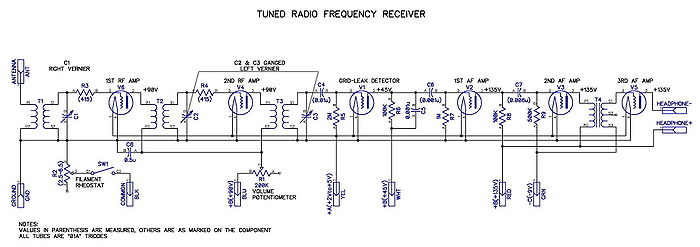
Tuned radio frequency receiver
A tuned radio frequency (TRF) receiver is a radio receiver typically consisting of multiple tuned radio frequency amplifiers followed by circuits for detecting and amplifying the audio signal. A three-stage TRF receiver includes an RF stage, a detector stage, and...
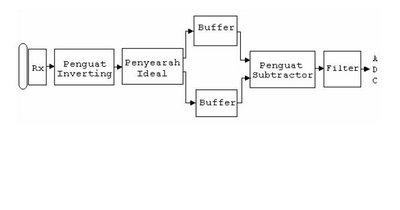
ultrasonic receiver
The barrier measurement method for distance is based on assessing the strength of a bound signal. A reflection wave is captured with an acceptor transducer, which emits a sine wave signal. The amplitude of this signal varies with the distance...
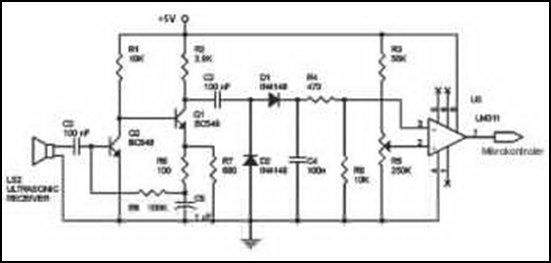
Ultrasonic Wave Receiver Circuit Schematic Diagram
Ultrasonic receivers detect an ultrasonic signal emitted by an ultrasonic transmitter at a specific frequency. The received signal is filtered using a band-pass filter circuit that allows only the predetermined frequency range to pass. The output signal is then amplified...
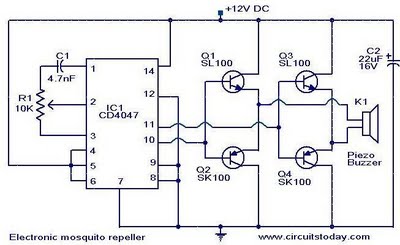
ultrasonic mosquito repeller
The circuit diagram of an ultrasonic mosquito repeller is presented. This circuit operates on the principle that sound frequencies in the ultrasonic range, above 20 kHz, can repel insects such as mosquitoes. It utilizes a Phase-Locked Loop (PLL) integrated circuit,...
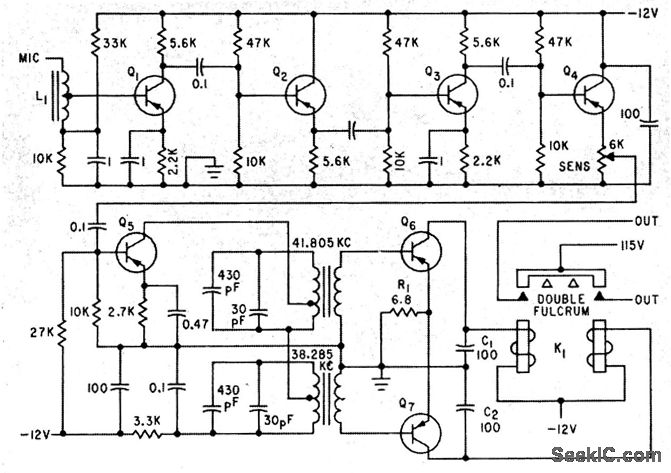
ULTRASONIC CONTROL RECEIVER
A five-stage amplifier consisting of transistors Q1 through Q5 amplifies the control signals at frequencies of 38.285 kHz and 41.805 kHz. Transistors Q6 and Q7 function as class B detector-amplifiers, thereby eliminating the need for separate diode detectors. The desired...
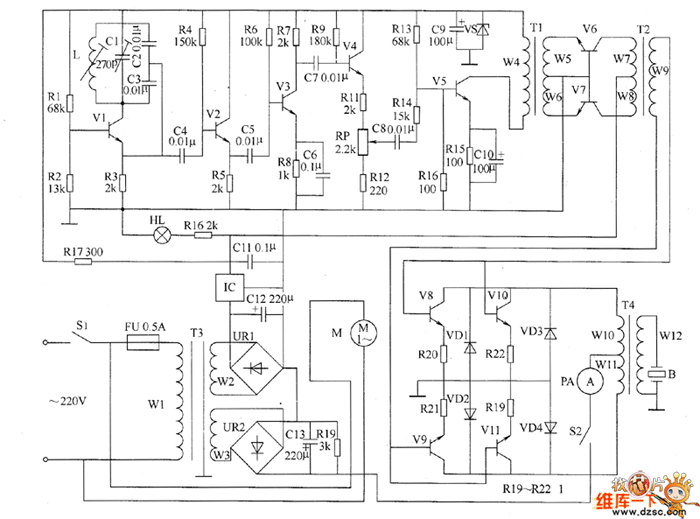
Ultrasonic drilling machine circuit diagram 2
The ultrasonic drilling machine circuit consists of a power supply circuit, an ultrasonic oscillator circuit, a preamplifier, a promoting amplifier circuit, and a power amplifier output circuit, as depicted in the accompanying diagram. The ultrasonic oscillator circuit is made up...