


Current Loop Sensor Interface
#current loop
#sensor interface
#voltage input
#potentiometer
#inductive throttle
#motor controller
#contactless sensor
#golf car
#Eze-Go
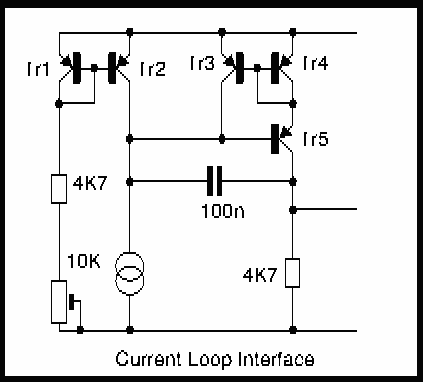
Description: This is a very simple circuit to interface a current loop sensor to an input which is designed for a voltage, such as that from a standard potentiometer. This page is technical so that interested persons can build the circuit themselves, but 4QD can also supply the interface on a 'postage stamp' sized (22mm x 27mm) board as shown in the first diagram. It is a relatively trivial circuit! This circuit was developed to interface one of the new type contactless (inductive) throttle sensors to 4QD's motor controllers for use in a conversion to an Eze-Go golf car.
More: The throttle itself consists of a coil and some electronics with a steel jacketed brass slug which is moved in and out of the coil by the throttle movement. The assembly has only two contacts and draws a current of between 600 microamps and 2 milliamps: the current varies with slug position as the throttle is moved. As such it is a system which borrows much from the industrial 4-20mA current loop sensor standard.
The sensor will work down to about 5 to 6 volts minimum. 4QD's NCC and Pro-120 use an internal 9v rail, so there is not a huge 'overhead' to allow any voltage swing across the sensor, hence this circuit.
The sensor is shown by the standard symbol for a current source (two intersecting circles).
Tr1 and Tr2 are a current mirror arranged to source about 1mA into the sensor, via Tr2. This current can be adjusted by the preset to 'back-off' the zero position current. This allows an electrical zero adjust (in practise the customers usually prefer to use the throttle's mechanical zero adjust).
Tr3, 4 and 5 are a second mirror which reflect the sensor's output current (less the backed off zero portion) into the 4K7 resistor - a resistor is a current to voltage converter! We have therefore developed an output voltage proportional to throttle position and it has the same 3 wires as a standard potentiometer.
This circuit is designed to facilitate the integration of a current loop sensor, specifically a contactless throttle sensor, with existing voltage-based input systems, such as those found in motor controllers. The fundamental operation is based on the principle of current mirroring and conversion, where the throttle sensor's output current is accurately translated into a corresponding voltage signal.
The throttle sensor operates on the principle of inductance, utilizing a moving brass slug within a coil to modulate the current draw between 600 microamps and 2 milliamps, depending on the position of the slug. This current range is typical for industrial applications, aligning with the 4-20mA standard. The circuit is powered by a minimum of 5 to 6 volts, with the 9V rail from the 4QD motor controllers providing adequate voltage for operation without significant overhead.
The current mirror configuration, consisting of transistors Tr1 and Tr2, ensures a stable 1mA current is supplied to the sensor, with a preset adjustment allowing for fine-tuning of the zero position. The output from the sensor is processed by a second current mirror formed by transistors Tr3, Tr4, and Tr5. This arrangement reflects the sensor's output current, minus the adjusted zero current, through a 4.7kΩ resistor, effectively converting the current signal into a voltage output that is linearly proportional to the throttle position.
The output voltage is then compatible with standard potentiometer inputs, featuring three wires for easy integration with existing systems. This design allows for seamless interfacing and provides users with a straightforward method for implementing a modern throttle control solution in electric vehicle applications.This is a very simple circuit to interface a current loop sensor to an input which is designed for a voltage, such as that from a standard potentiometer. This page is technical so that interested persons can build the circuit themselves, but 4QD can also supply the interface on a 'postage stamp' sized (22mm x 27mm) board as shown in the first diagram.
It is a relatively trivial circuit! This circuit was developed to interface one of the new type contactless (inductive) throttle sensors to 4QD's motor controllers for use in a conversion to an Eze-Go golf car. The throttle itself consists of a coil and some electronics with a steel jacketed brass slug which is moved in and out of the coil by the throttle movement. The assembly has only two contacts and draws a current of between 600 microamps and 2 milliamps: the current varies with slug position as the throttle is moved.
As such it is a system which borrows much from the industrial 4-20mA current loop sensor standard. The sensor will work down to about 5 to 6 volts minimum. 4QD's NCC and Pro-120 use an internal 9v rail, so there is not a huge 'overhead' to allow any voltage swing across the sensor, hence this circuit. The sensor is shown by the standard symbol for a current source (two intersecting circles). Tr1 and Tr2 are a current mirror arranged to source about 1mA into the sensor, via Tr2. This current can be adjusted by the preset to 'back-off' the zero position current. This allows an electrical zero adjust (in practise the customers usually prefer to use the throttle's mechanical zero adjust).
Tr3, 4 and 5 are a second mirror which reflect the sensor's output current (less the backed off zero portion) into the 4K7 resistor - a resistor is a current to voltage converter! We have therefore developed an output voltage proportional to throttle position and it has the same 3 wires as a standard potentiometer.
More: The throttle itself consists of a coil and some electronics with a steel jacketed brass slug which is moved in and out of the coil by the throttle movement. The assembly has only two contacts and draws a current of between 600 microamps and 2 milliamps: the current varies with slug position as the throttle is moved. As such it is a system which borrows much from the industrial 4-20mA current loop sensor standard.
The sensor will work down to about 5 to 6 volts minimum. 4QD's NCC and Pro-120 use an internal 9v rail, so there is not a huge 'overhead' to allow any voltage swing across the sensor, hence this circuit.
The sensor is shown by the standard symbol for a current source (two intersecting circles).
Tr1 and Tr2 are a current mirror arranged to source about 1mA into the sensor, via Tr2. This current can be adjusted by the preset to 'back-off' the zero position current. This allows an electrical zero adjust (in practise the customers usually prefer to use the throttle's mechanical zero adjust).
Tr3, 4 and 5 are a second mirror which reflect the sensor's output current (less the backed off zero portion) into the 4K7 resistor - a resistor is a current to voltage converter! We have therefore developed an output voltage proportional to throttle position and it has the same 3 wires as a standard potentiometer.
This circuit is designed to facilitate the integration of a current loop sensor, specifically a contactless throttle sensor, with existing voltage-based input systems, such as those found in motor controllers. The fundamental operation is based on the principle of current mirroring and conversion, where the throttle sensor's output current is accurately translated into a corresponding voltage signal.
The throttle sensor operates on the principle of inductance, utilizing a moving brass slug within a coil to modulate the current draw between 600 microamps and 2 milliamps, depending on the position of the slug. This current range is typical for industrial applications, aligning with the 4-20mA standard. The circuit is powered by a minimum of 5 to 6 volts, with the 9V rail from the 4QD motor controllers providing adequate voltage for operation without significant overhead.
The current mirror configuration, consisting of transistors Tr1 and Tr2, ensures a stable 1mA current is supplied to the sensor, with a preset adjustment allowing for fine-tuning of the zero position. The output from the sensor is processed by a second current mirror formed by transistors Tr3, Tr4, and Tr5. This arrangement reflects the sensor's output current, minus the adjusted zero current, through a 4.7kΩ resistor, effectively converting the current signal into a voltage output that is linearly proportional to the throttle position.
The output voltage is then compatible with standard potentiometer inputs, featuring three wires for easy integration with existing systems. This design allows for seamless interfacing and provides users with a straightforward method for implementing a modern throttle control solution in electric vehicle applications.This is a very simple circuit to interface a current loop sensor to an input which is designed for a voltage, such as that from a standard potentiometer. This page is technical so that interested persons can build the circuit themselves, but 4QD can also supply the interface on a 'postage stamp' sized (22mm x 27mm) board as shown in the first diagram.
It is a relatively trivial circuit! This circuit was developed to interface one of the new type contactless (inductive) throttle sensors to 4QD's motor controllers for use in a conversion to an Eze-Go golf car. The throttle itself consists of a coil and some electronics with a steel jacketed brass slug which is moved in and out of the coil by the throttle movement. The assembly has only two contacts and draws a current of between 600 microamps and 2 milliamps: the current varies with slug position as the throttle is moved.
As such it is a system which borrows much from the industrial 4-20mA current loop sensor standard. The sensor will work down to about 5 to 6 volts minimum. 4QD's NCC and Pro-120 use an internal 9v rail, so there is not a huge 'overhead' to allow any voltage swing across the sensor, hence this circuit. The sensor is shown by the standard symbol for a current source (two intersecting circles). Tr1 and Tr2 are a current mirror arranged to source about 1mA into the sensor, via Tr2. This current can be adjusted by the preset to 'back-off' the zero position current. This allows an electrical zero adjust (in practise the customers usually prefer to use the throttle's mechanical zero adjust).
Tr3, 4 and 5 are a second mirror which reflect the sensor's output current (less the backed off zero portion) into the 4K7 resistor - a resistor is a current to voltage converter! We have therefore developed an output voltage proportional to throttle position and it has the same 3 wires as a standard potentiometer.
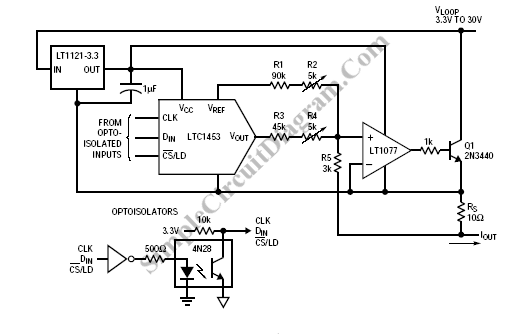
Computer-Controlled 4-20mA Current Loop
In certain industries, a computer-controlled 4-20 mA current loop is utilized to manage various equipment. This current loop is employed to transmit a signal over a distance.
The 4-20 mA current loop is a standard method for transmitting analog signals in...
Computer-Controlled 4-20mA Current Loop
In certain industries, a computer-controlled 4-20 mA current loop is utilized to manage various equipment. This current loop is employed to transmit a signal over a distance.
The 4-20 mA current loop is a standard method for transmitting analog signals in...
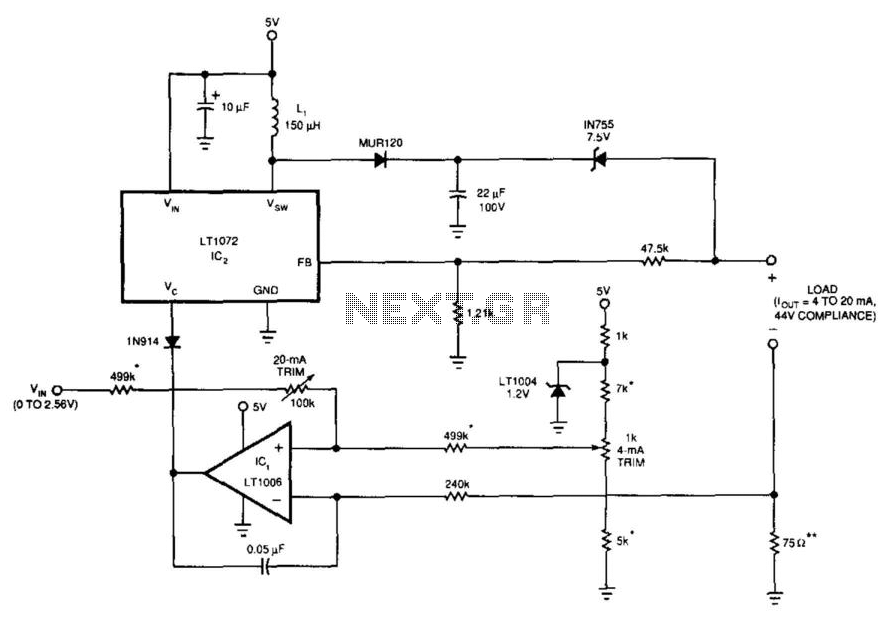
Current Loop
This 5-V circuit employs a servo-controlled DC/DC converter to generate the compliance voltage necessary for current requirements. It is designed to drive 4 to 20 mA into loads as high as 2200 ohms with 44 V of compliance. The circuit...
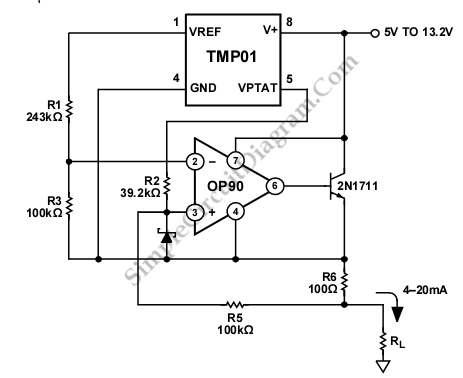
TMP01 4 to 20mA Current Loop
This is a 4 mA to 20 mA current loop circuit. This circuit is used to transmit a signal over long distances. The accuracy of this circuit is not compromised.
The 4 mA to 20 mA current loop circuit is a...

working principles of motor control
After dismantling a Chinese copy of a Segway, an examination of the motor controller was conducted. After several hours of work with a multimeter, pen, paper, and KiCad, a block diagram and schematic of the motor controller were developed. This...
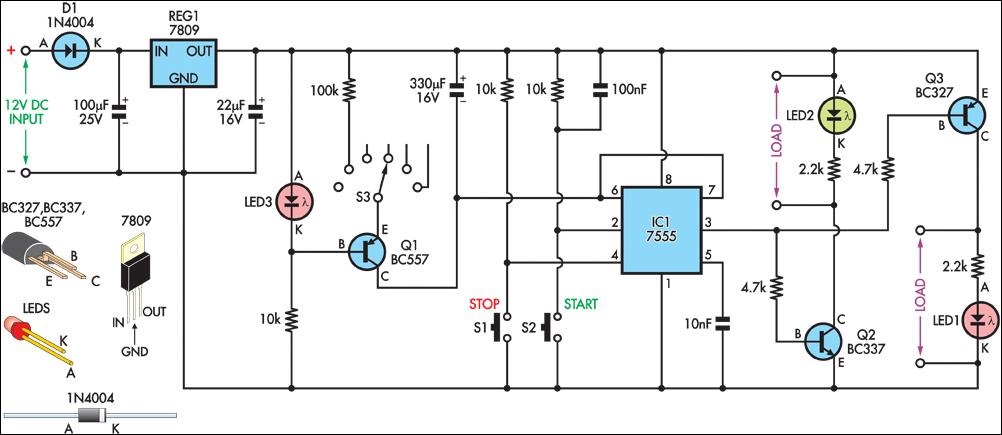
4 20ma current loop tester
This design will appeal to technicians working with pneumatically operated valves and other devices controlled by a 4-20mA current loop. While 4-20mA signal injectors and calibrators are available, this particular model is cost-effective to construct and user-friendly. Upon initial power-up,...
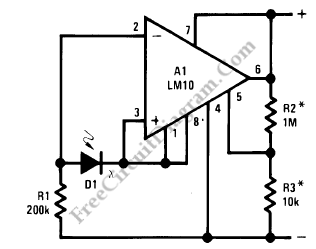
Current Loop Light Level Detector
This circuit is a two-wire light level detector. The power supply and output signal are delivered through the same wires, utilizing a current loop.
This two-wire light level detector circuit operates by using a single pair of wires for both power...
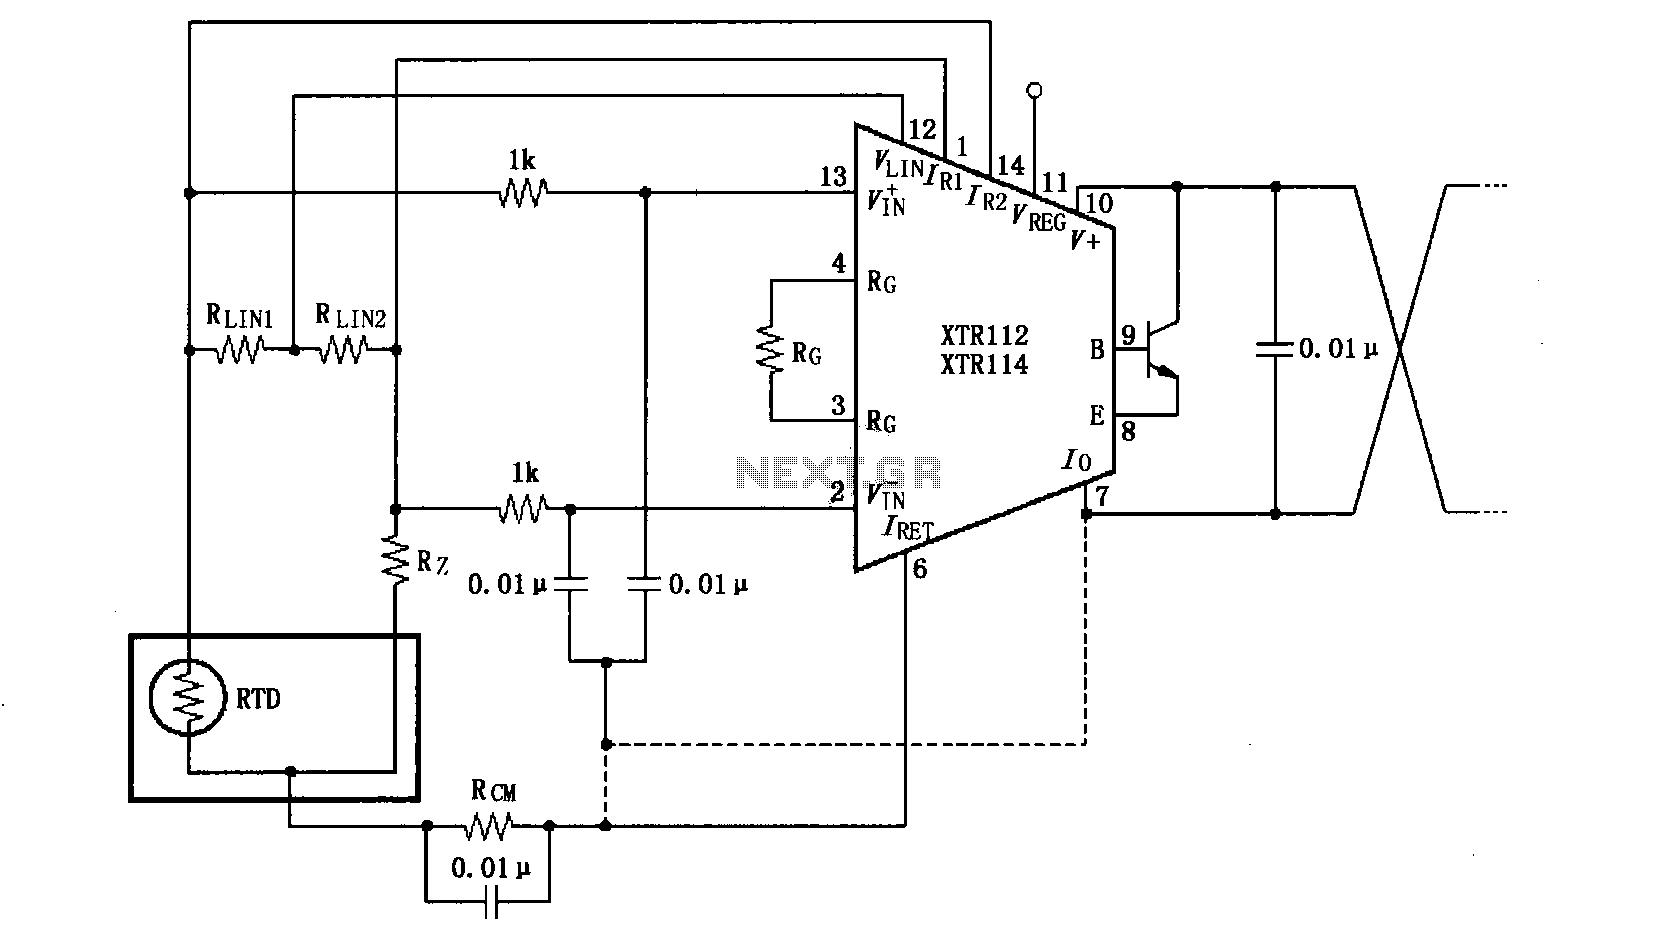
Linearized input bypass circuit XTR112
The length of the transmission wire in a current loop circuit can introduce radio frequency (RF) interference. This RF energy may lead to input errors in sensitive devices such as the XT112/114, causing instability in loop current or input line...
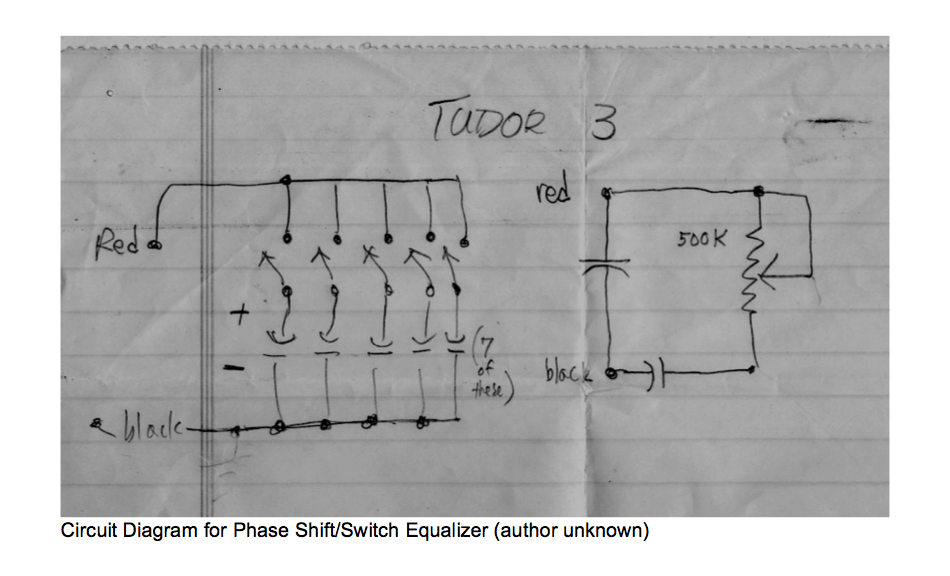
music circuit
This circuit allows for the adjustment of resistance using a potentiometer and the adjustment of capacitance by opening or closing switches. By manipulating the configuration of these switches, various combinations can be achieved to obtain different effective capacitance values. It...