


Bicycle Sensing
#bicycle
#motion sensing
#collision detection
#durable sensors
#control signals
#safety
#cycling
#impact resistance
#navigation
#feedback system
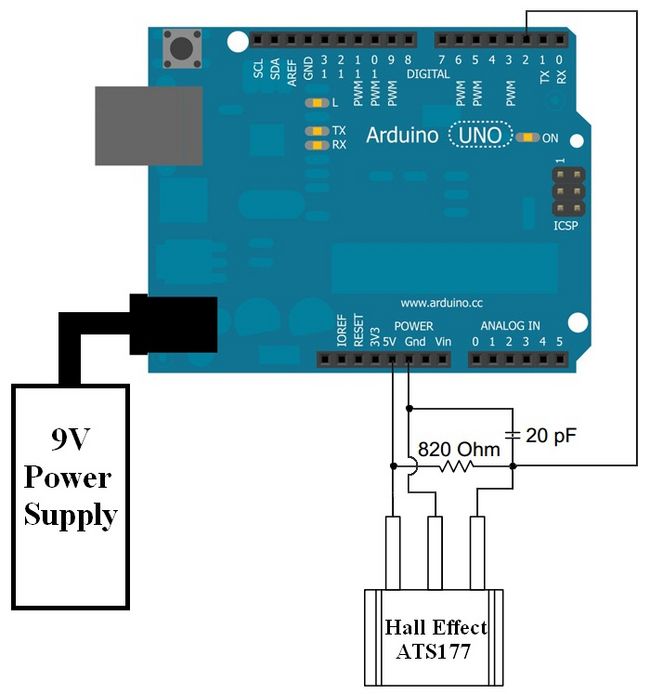
Description: Bicycle sensors serve two primary functions: recording the motion of the bicycle for collision reconstruction and transmitting signals to the bicycle controls to ensure proper navigation. This necessitates several component specifications, as the sensors need to be robust enough to endure collisions. Additionally, the sensors must be adaptable for installation on various bicycle models with minimal modifications. Accuracy is crucial to prevent erroneous signals from reaching the bicycle controls, which could lead to incorrect maneuvers. A 3-axis accelerometer will be the primary sensor for detecting impact forces during a crash. The sensor will be aligned such that the x-axis corresponds to the horizontal bicycle frame, the y-axis is perpendicular to the horizontal frame, and the z-axis is directed downward, in line with gravity. This orientation enables the measurement of forward acceleration along the x-axis, while acceleration on the y-axis indicates lateral movement, suggesting that the bicycle is veering off course. A cyclometer will be utilized to monitor the bike's velocity profile prior to a collision, measuring tire revolutions and converting these into speed. Most commercial systems are designed for long rides, recording one sample per full tire revolution. However, for this application, a custom cyclometer design may be necessary to capture multiple samples per revolution. Data from the 2011 Carleton University Crash Test Dummy Project indicated that it took approximately 0.1 seconds for a bicycle to decelerate from 25 km/hr to 0 km/hr, resulting in an average deceleration rate of 69.4 m/s² (7.08 g's) during collision scenarios. This deceleration is anticipated to be the maximum g-force experienced; however, if the pulley cable tension is not maintained, impulse forces could exceed sensor limits. This was observed in the 40 km/hr test from the 2011 CUCD, where slack in the cable allowed the motor to ramp up to 10 km/hr over 0.56 seconds before abruptly accelerating the dummy. Such rapid changes could produce g-forces greater than those experienced during the collision, necessitating careful track design to avoid unintended forces that could compromise sensor integrity. Initial testing with a USB Impact Accelerometer (model X250-2) from Gulf Coast Data Concepts was conducted to evaluate whether an accelerometer alone could effectively capture the bicycle's velocity profile. This accelerometer is suitable for measuring collision impact forces, capable of handling up to ±250g and featuring a protective casing for bicycle mounting. The first test involved recording acceleration on a horizontal plane with the accelerometer correctly oriented, resulting in predominantly x-axis acceleration, with minor y and z-axis movement due to slight constraints. The second test placed the accelerometer on its side, making it more susceptible to rotation about the x-axis, leading to perceived positive velocity gains in the z-axis and negative gains in the y-axis due to gravitational effects. The third test replicated the first but on an inclined plane, showing reduced x-axis acceleration due to upward pitch, which also influenced z-axis readings. The fourth test, similar to the second but on an incline, demonstrated similar phenomena with pitch and rotation affecting acceleration readings. Across all tests, the velocity profiles exhibited consistent patterns and magnitudes, indicating that a properly positioned accelerometer can effectively capture an object's velocity profile. The g-forces recorded during impacts ranged from 31g's to 87g's, correlating with pre-impact velocities of approximately 5.4 km/hr and 8.1 km/hr, respectively, remaining within the accelerometer's operational limits.Bicycle sensors provide two main purposes: to record the motion of the bicycle in order to assist with collision reconstruction, and to relay signals to the bicycle controls to keep the bicycle on course. This will pose several component requirements, as the sensors shall be durable enough to withstand a collision.
Also, the sensors shall be able to be installed on various bicycles with minimal modifications to the bicycle or sensors. Finally, the sensors have to be accurate in order to avoid relaying bad signals to the bicycle controls which may cause the bicycle to maneuver off course. A 3-axis accelerometer will be the main sensor for detecting the impact forces on the bicycle during the crash.
The sensor will be oriented so that the x-axis will align with the horizontal bicycle frame; the y-axis will be perpendicular to the horizontal bicycle frame; and the z-axis to be oriented downwards in the direction of gravity, as shown in Figure 1. This will allow the measurement of forward acceleration, i. e. , along the x-Axis. As well if there is acceleration in the y-axis it means that the bicycle has some type of lateral movement and is maneuvering off-course.
A cyclometer will be the main sensor for detecting the in velocity profile of the bike prior to the crash. The cyclometer will measure the revolutions of the tire and then the revolutions and be converted into velocity.
Most commercial systems are designed to measure average velocity over long bicycle rids, so there system of records a sample for every full revolution; however, for our purpose we would like to get as many samples in a short amount of time as possible so we may have to implement our own cyclometer design in order to get multiple samples per revolution. From the video recorded from the 2011 Carleton University Crash Test Dummy Project (2011 CUCD) [2] it took approximately 0.
1 second for the bicycle to go from 25 km/hr to 0 km/hr. Therefore, an average deceleration rate of 69. 4 m/s2, or 7. 08g`s, should be expected during our collision scenarios. The deceleration during the crash is expected to be the maximum g-force experience during the collision; however, if the tension of the pulley cable does not maintain constant tension there may be an impulse force that can exceed the limits of our sensors. This was experienced in the 40km/hr test from the 2011 CUCD. They tried to ramp up the motor for a duration of 2 seconds in order to get the bicycle and crash test dummy up to a speed of 40 km/hr; however, because the cable was slack the motor ramped up for 0.
56 seconds before moving the bicycle and crash test dummy. In this time the motor was able to ramp up to approximately 10 km/hr and then it tried to instantaneously move the dummy from rest to 10km/hr. If this occurred under 0. 04 seconds then the g-force created would be greater than the g-force experienced during the collision.
This creates a track requirement as we do not want the track to produce any unwanted forces that may cause the sensors to fail. In order to determine if an accelerometer alone is suffice to capture velocity profile of the bicycle some initial testing was performed using a USB Impact Accelerometer (model X250-2) from Gulf Coast Data Concepts.
This accelerometer is ideal to measure the impact forces of the bicycle in a collision as it is a 3-axis accelerometer that can handle up to ±250g; as well it is manufactured with a protective casing which can be mounted on the bicycle. The first test performed was to record the acceleration along a horizontal plane while the accelerometer is placed in its correct orientation.
The accelerometer was constrained so it would only accelerate in the positive X coordinate. Hence, the majority of the acceleration was in the X direction; however, there was still slight acceleration in the Y and Z plane are due to the apparatus not fully constraining the movement about those planes. The second test performed was to record the acceleration along a horizontal plane while the accelerometer is placed on its side.
In this test the accelerometer was more acceptable to rotate about the X axis. When the accelerometer was accelerated, the Z coordinate moved towards the gravitational field gaining a fraction of the gravitational acceleration. This is why the accelerometer appeared to be constantly gaining positive velocity. For a similar reason this is why the accelerometer appeared to constantly gain negative velocity in the Y coordinate.
The reason it is negative is because the Y axis moved away from the gravitational field, causing it to lose a fraction of the gravitational acceleration. The third test performed was similar to the first test; however, rather than following a horizontal path the accelerometer was accelerated along an inclined plane.
Again in this configuration there was little movement in the Y and Z plane. One thing to notice is that the distance along the X direction is less than the other test. This is because the apparatus allowed the accelerometer to pitch upwards causing a lower acceleration reading in the X plane, hence, the lower total distance traveled. This pitch up also affected the Z plane as it caused the accelerometer gain a fraction of the gravitational acceleration.
However, there was also a slight rotation around the X axis which caused the Z plane to lose a fraction of the gravitational field, therefore, cancelling out the gain caused by the pitch up. The rotation also caused the Y axis to gain a fraction of the gravitational field, hence the appearance of a constant gain in velocity produced in the positive Y plane.
The fourth test performed was similar to the second test; however, rather than following a horizontal path the accelerometer was accelerated along an inclined plane. In this test there was a slight pitch up as well as rotation about the X axis. The rotation about the X axis caused the Z axis to gain a fraction of the gravitational acceleration, hence the appearance of a constant gain in velocity in the positive Z plane.
Also the rotation caused the Y axis to lose a fraction of the gravitational acceleration; however, this is offset by the fraction of the gravitational field gained in the Y axis due to the pitch up. For all the tests the velocity profile is similar as it follows the same pattern and has similar magnitudes.
From this we can conclude that if the accelerometer is correctly positioned it can effectively capture the velocity profile of an object. Another point to notice from the four test is that the G-Force generated from the impact was between 31g`s and 87g`s, these values correspond to when the accelerometer`s velocity prior to the impact was approximately 5.
4 km/hr and 8. 1 km/hr respectively. Also note that those values are well below the limit of the accelerometer. The fifth test pngs.
Also, the sensors shall be able to be installed on various bicycles with minimal modifications to the bicycle or sensors. Finally, the sensors have to be accurate in order to avoid relaying bad signals to the bicycle controls which may cause the bicycle to maneuver off course. A 3-axis accelerometer will be the main sensor for detecting the impact forces on the bicycle during the crash.
The sensor will be oriented so that the x-axis will align with the horizontal bicycle frame; the y-axis will be perpendicular to the horizontal bicycle frame; and the z-axis to be oriented downwards in the direction of gravity, as shown in Figure 1. This will allow the measurement of forward acceleration, i. e. , along the x-Axis. As well if there is acceleration in the y-axis it means that the bicycle has some type of lateral movement and is maneuvering off-course.
A cyclometer will be the main sensor for detecting the in velocity profile of the bike prior to the crash. The cyclometer will measure the revolutions of the tire and then the revolutions and be converted into velocity.
Most commercial systems are designed to measure average velocity over long bicycle rids, so there system of records a sample for every full revolution; however, for our purpose we would like to get as many samples in a short amount of time as possible so we may have to implement our own cyclometer design in order to get multiple samples per revolution. From the video recorded from the 2011 Carleton University Crash Test Dummy Project (2011 CUCD) [2] it took approximately 0.
1 second for the bicycle to go from 25 km/hr to 0 km/hr. Therefore, an average deceleration rate of 69. 4 m/s2, or 7. 08g`s, should be expected during our collision scenarios. The deceleration during the crash is expected to be the maximum g-force experience during the collision; however, if the tension of the pulley cable does not maintain constant tension there may be an impulse force that can exceed the limits of our sensors. This was experienced in the 40km/hr test from the 2011 CUCD. They tried to ramp up the motor for a duration of 2 seconds in order to get the bicycle and crash test dummy up to a speed of 40 km/hr; however, because the cable was slack the motor ramped up for 0.
56 seconds before moving the bicycle and crash test dummy. In this time the motor was able to ramp up to approximately 10 km/hr and then it tried to instantaneously move the dummy from rest to 10km/hr. If this occurred under 0. 04 seconds then the g-force created would be greater than the g-force experienced during the collision.
This creates a track requirement as we do not want the track to produce any unwanted forces that may cause the sensors to fail. In order to determine if an accelerometer alone is suffice to capture velocity profile of the bicycle some initial testing was performed using a USB Impact Accelerometer (model X250-2) from Gulf Coast Data Concepts.
This accelerometer is ideal to measure the impact forces of the bicycle in a collision as it is a 3-axis accelerometer that can handle up to ±250g; as well it is manufactured with a protective casing which can be mounted on the bicycle. The first test performed was to record the acceleration along a horizontal plane while the accelerometer is placed in its correct orientation.
The accelerometer was constrained so it would only accelerate in the positive X coordinate. Hence, the majority of the acceleration was in the X direction; however, there was still slight acceleration in the Y and Z plane are due to the apparatus not fully constraining the movement about those planes. The second test performed was to record the acceleration along a horizontal plane while the accelerometer is placed on its side.
In this test the accelerometer was more acceptable to rotate about the X axis. When the accelerometer was accelerated, the Z coordinate moved towards the gravitational field gaining a fraction of the gravitational acceleration. This is why the accelerometer appeared to be constantly gaining positive velocity. For a similar reason this is why the accelerometer appeared to constantly gain negative velocity in the Y coordinate.
The reason it is negative is because the Y axis moved away from the gravitational field, causing it to lose a fraction of the gravitational acceleration. The third test performed was similar to the first test; however, rather than following a horizontal path the accelerometer was accelerated along an inclined plane.
Again in this configuration there was little movement in the Y and Z plane. One thing to notice is that the distance along the X direction is less than the other test. This is because the apparatus allowed the accelerometer to pitch upwards causing a lower acceleration reading in the X plane, hence, the lower total distance traveled. This pitch up also affected the Z plane as it caused the accelerometer gain a fraction of the gravitational acceleration.
However, there was also a slight rotation around the X axis which caused the Z plane to lose a fraction of the gravitational field, therefore, cancelling out the gain caused by the pitch up. The rotation also caused the Y axis to gain a fraction of the gravitational field, hence the appearance of a constant gain in velocity produced in the positive Y plane.
The fourth test performed was similar to the second test; however, rather than following a horizontal path the accelerometer was accelerated along an inclined plane. In this test there was a slight pitch up as well as rotation about the X axis. The rotation about the X axis caused the Z axis to gain a fraction of the gravitational acceleration, hence the appearance of a constant gain in velocity in the positive Z plane.
Also the rotation caused the Y axis to lose a fraction of the gravitational acceleration; however, this is offset by the fraction of the gravitational field gained in the Y axis due to the pitch up. For all the tests the velocity profile is similar as it follows the same pattern and has similar magnitudes.
From this we can conclude that if the accelerometer is correctly positioned it can effectively capture the velocity profile of an object. Another point to notice from the four test is that the G-Force generated from the impact was between 31g`s and 87g`s, these values correspond to when the accelerometer`s velocity prior to the impact was approximately 5.
4 km/hr and 8. 1 km/hr respectively. Also note that those values are well below the limit of the accelerometer. The fifth test pngs.
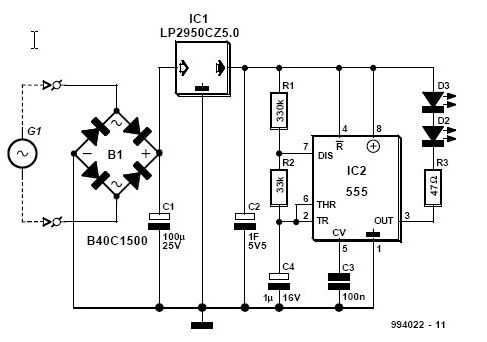
Bicycle Rear-Light Afterglow Circuit
This article is relevant only to readers whose bicycle lights are powered by a dynamo. The regulations regarding bicycle lights in the United Kingdom are stricter than in many other countries, making dynamos a rarity in the UK. For safety...
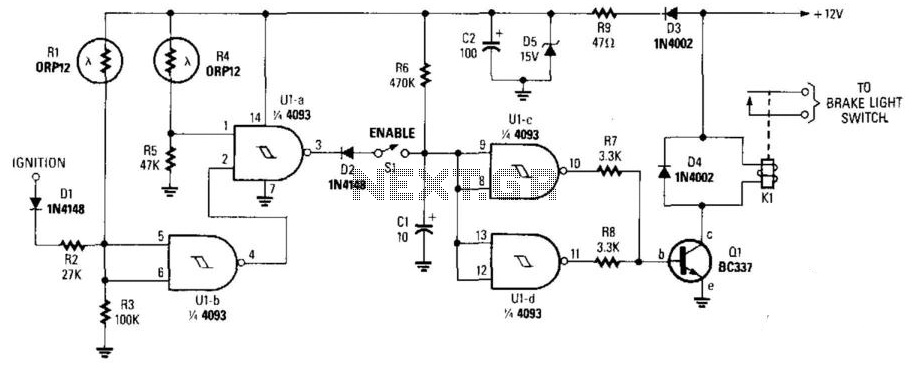
Night Safety Light For Autos
This circuit activates the brake lights of a parked car when headlights from an approaching vehicle are detected, alerting the driver of the oncoming vehicle about the stationary car. LDR4 serves as the sensor, while LDR1 deactivates the circuit by...
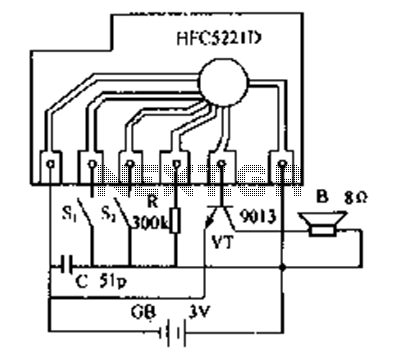
Do not drink and drive I wish you a safe journey home Language Integrated Circuits
Do not drink and drive. Wishing you a safe journey home. Language Integrated Circuits.
Language Integrated Circuits (LICs) are specialized electronic components designed to facilitate the processing of language-based data within various applications. These circuits integrate multiple functions, such as signal...
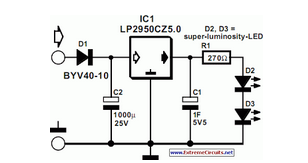
Rear Light After Glow (For Bicycles)
This article is relevant only to readers whose bicycle lights are powered by a dynamo. The regulations regarding bicycle lights in the United Kingdom are more stringent.
Dynamo-powered bicycle lights are an essential component for cyclists, providing illumination without the need...
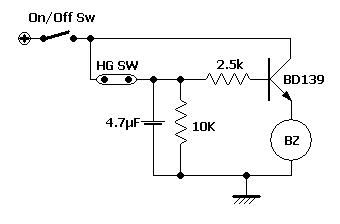
Simple bicycle alarm
The switch has been installed within the handlebar's tap. A battery holder has been created from a repurposed flashlight. As demonstrated in the video in step 1, the siren has been placed inside the left end-bar grip, with the wires...
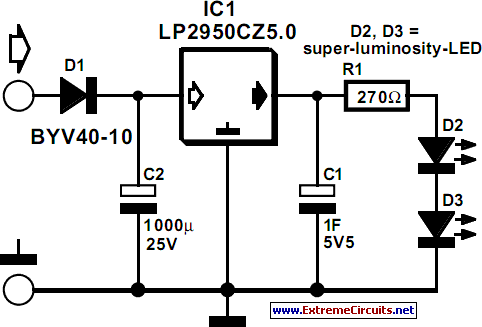
Rear Light After Glow (For Bicycles)
This article is relevant only to readers whose bicycle lights are powered by a dynamo. The regulations regarding bicycle lights in the United Kingdom are stricter than in other countries, making the use of a dynamo uncommon in this region....
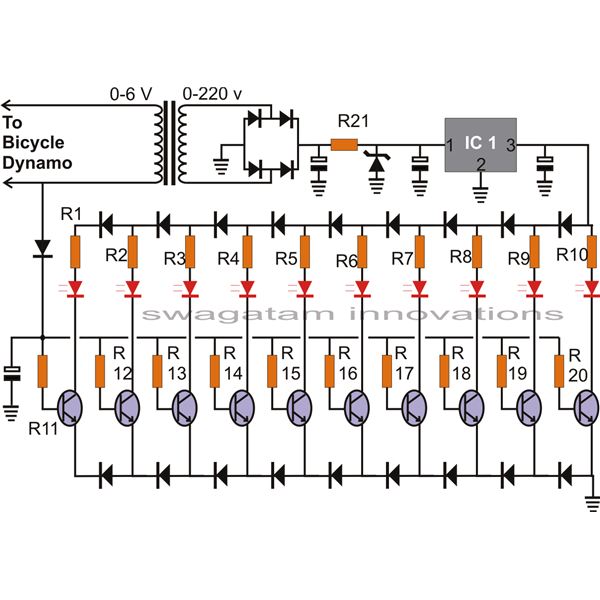
bicycle speed indicator circuit explained
The article presents a circuit that can be used for indicating the riding speed of a bicycle. The bicycle speedometer circuit explained here utilizes standard components such as transistors and LEDs to effectively display a clear 10-step, accurately calibrated linear...
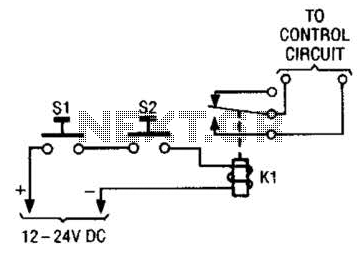
Simple Safety Circuit Circuit
The simple two-hand safety control switch consists of two pushbutton switches connected in series; both must be depressed to energize the relay.
The two-hand safety control switch is designed to enhance safety in applications where the operation of machinery or equipment...
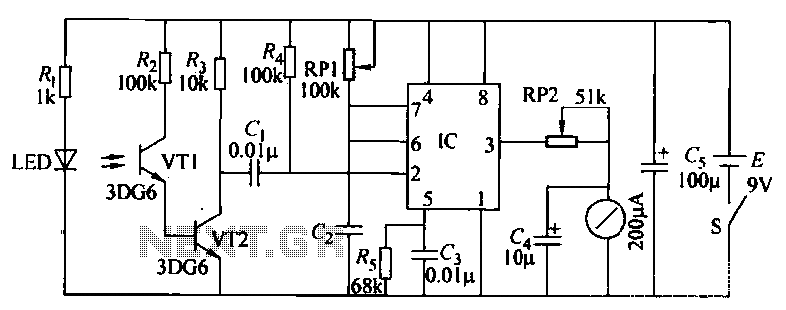
Bicycle speed circuit
Cycling is a common mode of transportation. When paired with a bicycle speedometer, cyclists can effectively monitor their speed, which is particularly beneficial for training purposes. The bicycle speedometer circuit, as illustrated in Figure 5-33, utilizes the relationship between the...