


lezers bijdrage
#BEAM robotics
#solar engine
#transistor
#capacitor
#solar powered
#tiny motor
#Mark Tilden
#energy storage
#mechanical device
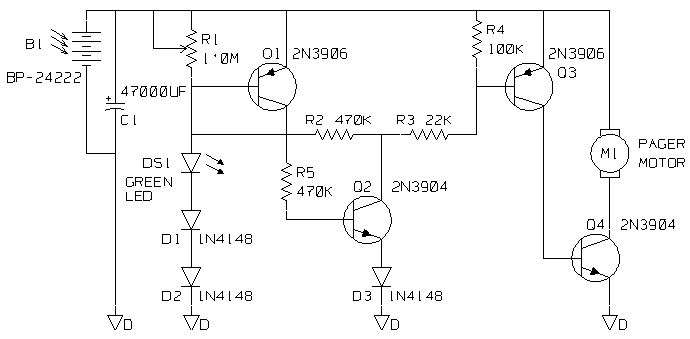
Description: A primary building block in BEAM robotics is the Solar Engine, a simple two-transistor circuit originally designed by Mark Tilden. This circuit allows energy to be stored in a capacitor until the charge is sufficient to briefly run a small motor. It enables the creation of solar-powered mechanical devices that can operate in less-than-direct sunlight, provided continuous movement is not required. Powered by a Solar Engine, devices will function in short bursts with pauses in between, the duration of which is determined by the available solar current. While the original Solar Engine is extremely simple, it has some drawbacks, particularly in its reset mechanism, which only occurs when the load nearly completely discharges the capacitor. This can lead to energy waste, as the motor may stop running before the capacitor is fully discharged, or the reset may not occur at all if the device cannot discharge the capacitor sufficiently. A modified version of the Solar Engine was used to control the Photovore, featuring a reset that is independent of load. Ken Huntington, a Canadian BEAMer, improved upon this circuit, resulting in a more efficient Solar Engine. The design presented here closely resembles circuits found on Steven Bolt's web pages, with minor modifications made based on testing and recognition of the circuit's potential. The circuit can drive a pager motor with a power source providing 2.5V DC at 10 µA, activating the motor at 2.3 to 2.5V DC and turning it off at 1.2 to 1.5V DC. The design includes a single adjustable resistor, necessitating a calibration procedure to ensure proper operation. The procedure involves setting the resistor to maximum, connecting a digital voltmeter across the storage capacitor, enabling power, and adjusting the resistor until the voltage rises to the minimum operational threshold. The final resistance value used was 560K, demonstrating the design's repeatability.
The Solar Engine circuit is a fundamental component in the realm of BEAM robotics, specifically designed to harness solar energy effectively for mechanical operations. The circuit consists of two primary transistors (Q1 and Q2), which function as a switch to control the flow of current from the capacitor to the motor. The energy storage component, usually a capacitor, is charged by a solar panel. When the voltage across the capacitor reaches a predetermined threshold, the transistors turn on, allowing current to flow to the motor, thus activating it for a brief period.
One of the critical aspects of this circuit is the adjustable resistor (R1), which plays a vital role in calibrating the circuit's sensitivity to the capacitor's voltage. The calibration process is essential to ensure that the motor operates reliably under varying solar conditions. By adjusting R1, the user can set the voltage level at which the motor will activate, thereby optimizing performance based on the specific characteristics of the solar panel and the load being driven.
In the improved design by Ken Huntington, the circuit maintains its simplicity while enhancing efficiency and reliability. The modifications made allow for a more effective reset mechanism, ensuring that the motor can operate closer to the capacitor's full discharge potential without wasting energy. This is particularly advantageous for applications where energy efficiency is paramount.
Overall, the Solar Engine circuit exemplifies a practical application of basic electronic principles in the development of autonomous solar-powered devices, making it an essential building block for hobbyists and professionals in the field of robotics and renewable energy. The ongoing exploration and refinement of such circuits continue to contribute to advancements in low-power, sustainable robotics.A primary building block in BEAM robotics is the Solar Engine, a very simple two transistor circuit originally designed by Mark Tilden, which allows energy to be stored in a capacitor, until the charge is sufficient to briefly run a tiny motor. This means you can easily make a solar powered mechanical device `live` with just a small solar panel in far less than direct sunlight - as long as you don`t need continuous movement. Powered by a Solar Engine, your device will be active in short bursts, with pauses in between. The length of a pause is determined by the available solar current. The original Solar Engine has the advantage of extreme simplicity, but also a few disadvantages. One of them is the way it achieves reset. This happens only when the load almost completely discharges the capacitor. Depending on your type of device, this may waste energy because the motor stops long before the capacitor is fully discharged, or reset may not be achieved at all, because the device is incapable of discharging the capacitor to a sufficiently low level.
I used a circuit much like the Solar Engine to switch the Photovore on and off, the most important change being a reset independent of load. The Canadian BEAMer Ken Huntington took my circuit and changed it into a more efficient Solar Engine.
Below you find his diagram and his description of it. He also supplied some oscilloscope images of the circuit in operation. Enjoy! A `micro power solar engine` has been a goal since my introduction to BEAM Robotics. I believe that if there wasn`t one before, I there is one now. What I`m presenting to you looks very similar to one of the circuits found in Steven Bolt`s web pages. As you will see, I made only minor changes to that design and not without help. My contributions have been to recognize the potential of the circuit, bread board and test it. The bottom line is that if you have a power source which will provide 2. 5Vdc at 10uA this circuit should drive a pager motor. It turns on the motor at 2. 3 to 2. 5Vdc and switches off at 1. 2 to 1. 5Vdc. Both Steve and I have built (bread boarded or haywired) the business end of the design and achieved similar results.
This does not mean that it will work for everyone but it should. [I used a BC559C (Q1), a BC549C (Q2) a BC559B (Q3) and a BC337-25 (Q4), which happened to be in the bitbox. SB] There is one adjustable resistor which is the only real complication and it means that there is a calibration procedure which is as follows: 1) Set R1 to max.
(1. 0M). 2) Connect a DVM across the storage capacitor. 3) Enable power to the circuit. If the circuit works properly, the voltage will rise to a firing point, turn on the motor momentarily which discharges the capacitor to level where motor has little current passing through it but Q1 and Q2 are still conducting. At this point, . 4) Slowly adjust R1 until the voltage starts to rise again. This is the threshold for minimum operation. 5) Adjust R1 just a little further to assure reliable operation. In practice, I removed R1, measured its value and replaced it with a standard resistor value 5 to 10% less.
560K was the value that both Steve and I used which shows just how repeatable this design is or how lucky we were. Note: It is realized that this presentation is very cryptic. If it were delayed until a complete circuit description and circuit layout were complete, it may not have been presented at all.
It is hard for many to realize the time and effort it takes to create the circuit cards, obtain the correct parts, make up the kits and write assembly/debug instructions. The dollar cost and other risks are not minimal. If there is a need for this circuit, it shall come to pass. KG
The Solar Engine circuit is a fundamental component in the realm of BEAM robotics, specifically designed to harness solar energy effectively for mechanical operations. The circuit consists of two primary transistors (Q1 and Q2), which function as a switch to control the flow of current from the capacitor to the motor. The energy storage component, usually a capacitor, is charged by a solar panel. When the voltage across the capacitor reaches a predetermined threshold, the transistors turn on, allowing current to flow to the motor, thus activating it for a brief period.
One of the critical aspects of this circuit is the adjustable resistor (R1), which plays a vital role in calibrating the circuit's sensitivity to the capacitor's voltage. The calibration process is essential to ensure that the motor operates reliably under varying solar conditions. By adjusting R1, the user can set the voltage level at which the motor will activate, thereby optimizing performance based on the specific characteristics of the solar panel and the load being driven.
In the improved design by Ken Huntington, the circuit maintains its simplicity while enhancing efficiency and reliability. The modifications made allow for a more effective reset mechanism, ensuring that the motor can operate closer to the capacitor's full discharge potential without wasting energy. This is particularly advantageous for applications where energy efficiency is paramount.
Overall, the Solar Engine circuit exemplifies a practical application of basic electronic principles in the development of autonomous solar-powered devices, making it an essential building block for hobbyists and professionals in the field of robotics and renewable energy. The ongoing exploration and refinement of such circuits continue to contribute to advancements in low-power, sustainable robotics.A primary building block in BEAM robotics is the Solar Engine, a very simple two transistor circuit originally designed by Mark Tilden, which allows energy to be stored in a capacitor, until the charge is sufficient to briefly run a tiny motor. This means you can easily make a solar powered mechanical device `live` with just a small solar panel in far less than direct sunlight - as long as you don`t need continuous movement. Powered by a Solar Engine, your device will be active in short bursts, with pauses in between. The length of a pause is determined by the available solar current. The original Solar Engine has the advantage of extreme simplicity, but also a few disadvantages. One of them is the way it achieves reset. This happens only when the load almost completely discharges the capacitor. Depending on your type of device, this may waste energy because the motor stops long before the capacitor is fully discharged, or reset may not be achieved at all, because the device is incapable of discharging the capacitor to a sufficiently low level.
I used a circuit much like the Solar Engine to switch the Photovore on and off, the most important change being a reset independent of load. The Canadian BEAMer Ken Huntington took my circuit and changed it into a more efficient Solar Engine.
Below you find his diagram and his description of it. He also supplied some oscilloscope images of the circuit in operation. Enjoy! A `micro power solar engine` has been a goal since my introduction to BEAM Robotics. I believe that if there wasn`t one before, I there is one now. What I`m presenting to you looks very similar to one of the circuits found in Steven Bolt`s web pages. As you will see, I made only minor changes to that design and not without help. My contributions have been to recognize the potential of the circuit, bread board and test it. The bottom line is that if you have a power source which will provide 2. 5Vdc at 10uA this circuit should drive a pager motor. It turns on the motor at 2. 3 to 2. 5Vdc and switches off at 1. 2 to 1. 5Vdc. Both Steve and I have built (bread boarded or haywired) the business end of the design and achieved similar results.
This does not mean that it will work for everyone but it should. [I used a BC559C (Q1), a BC549C (Q2) a BC559B (Q3) and a BC337-25 (Q4), which happened to be in the bitbox. SB] There is one adjustable resistor which is the only real complication and it means that there is a calibration procedure which is as follows: 1) Set R1 to max.
(1. 0M). 2) Connect a DVM across the storage capacitor. 3) Enable power to the circuit. If the circuit works properly, the voltage will rise to a firing point, turn on the motor momentarily which discharges the capacitor to level where motor has little current passing through it but Q1 and Q2 are still conducting. At this point, . 4) Slowly adjust R1 until the voltage starts to rise again. This is the threshold for minimum operation. 5) Adjust R1 just a little further to assure reliable operation. In practice, I removed R1, measured its value and replaced it with a standard resistor value 5 to 10% less.
560K was the value that both Steve and I used which shows just how repeatable this design is or how lucky we were. Note: It is realized that this presentation is very cryptic. If it were delayed until a complete circuit description and circuit layout were complete, it may not have been presented at all.
It is hard for many to realize the time and effort it takes to create the circuit cards, obtain the correct parts, make up the kits and write assembly/debug instructions. The dollar cost and other risks are not minimal. If there is a need for this circuit, it shall come to pass. KG
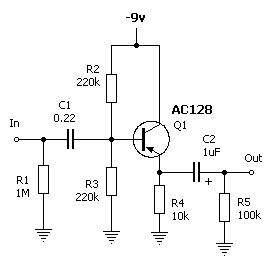
Leaky Transistor Buffer
The wah pedal operates before the amplifier but produces a low volume and a scratchy sound when the pedal is rocked back and forth. It functions correctly without the buffer. When placed in front of a Fuzz Face, no sound...
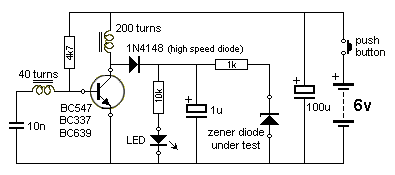
The Transistor Amplifier-P2
The three circuits described provide a constant current to the LED (or LEDs) when the supply voltage reaches 15V or higher. The second and third circuits can be activated or deactivated through the input line by turning on the top...
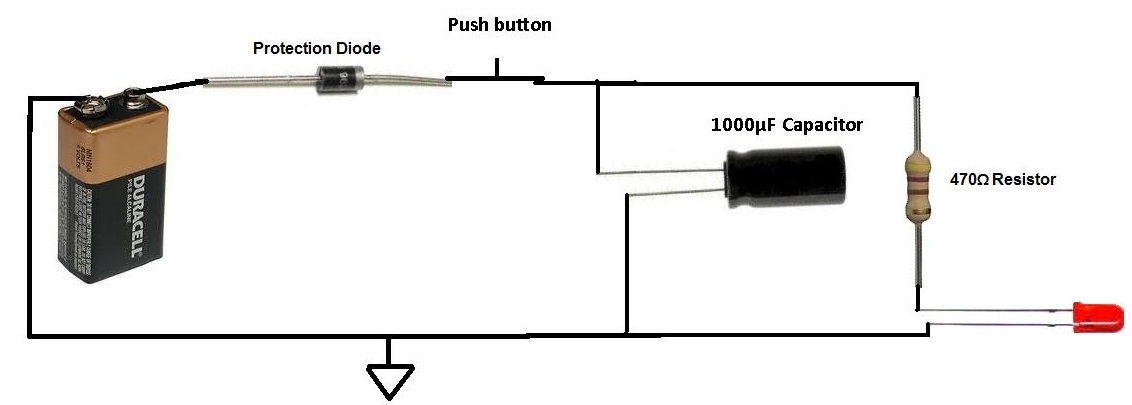
Charged Capacitor to Light an LED
This project involves charging a capacitor with voltage, which will subsequently serve as a temporary power source for the circuit. After charging the capacitor with a battery, the battery is disconnected from the circuit. The capacitor then provides current to...
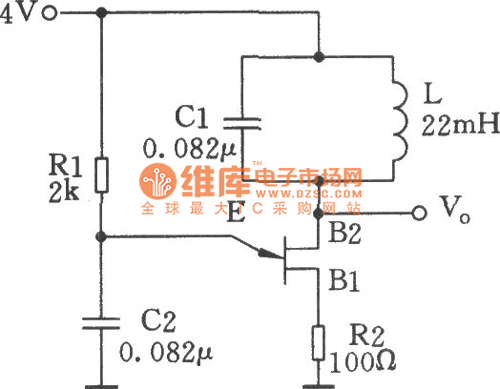
Single-junction transistor sine wave oscillator circuit
The single-junction transistor is commonly utilized in sawtooth and pulse generators, and it can also be configured to create a basic sine wave generation circuit. As an oscillator circuit composed of discrete components, it requires a minimal number of parts....
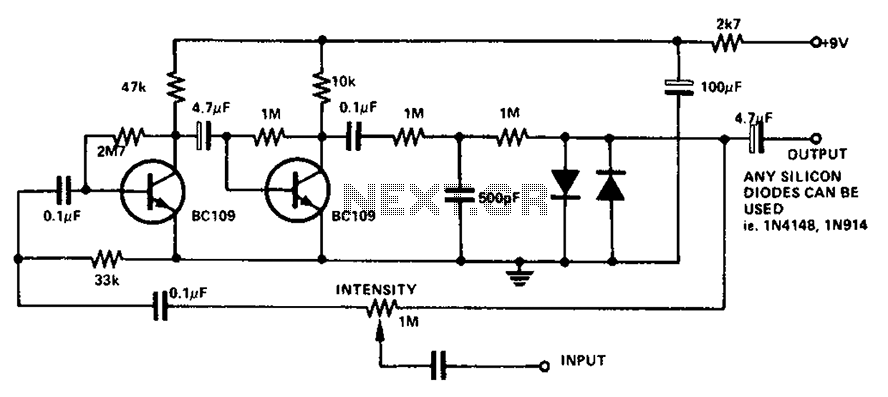
Boombox circuit diagram
The circuit utilizes a transistor to amplify the input signal. Two diodes are employed to clamp the distorted output, while a 500 pF capacitor filters out high-frequency noise. Under normal conditions, a 1M slide rheostat is used to adjust the...
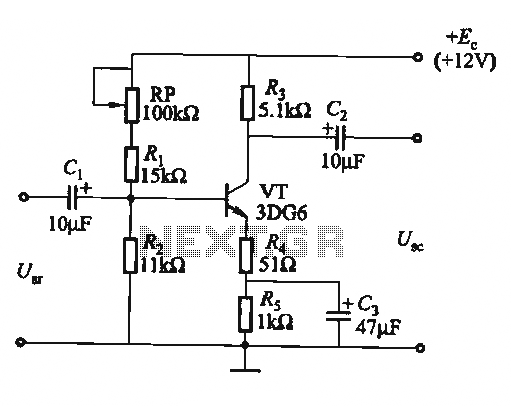
Transistor common emitter amplifier circuit
The circuit is a bias circuit for automatic stabilizers that maintains a stable quiescent operating point with good thermal stability. It utilizes a three-pole tube with an NPN type transistor, characterized by a small Iceo. An adjustment potentiometer, RP, is...
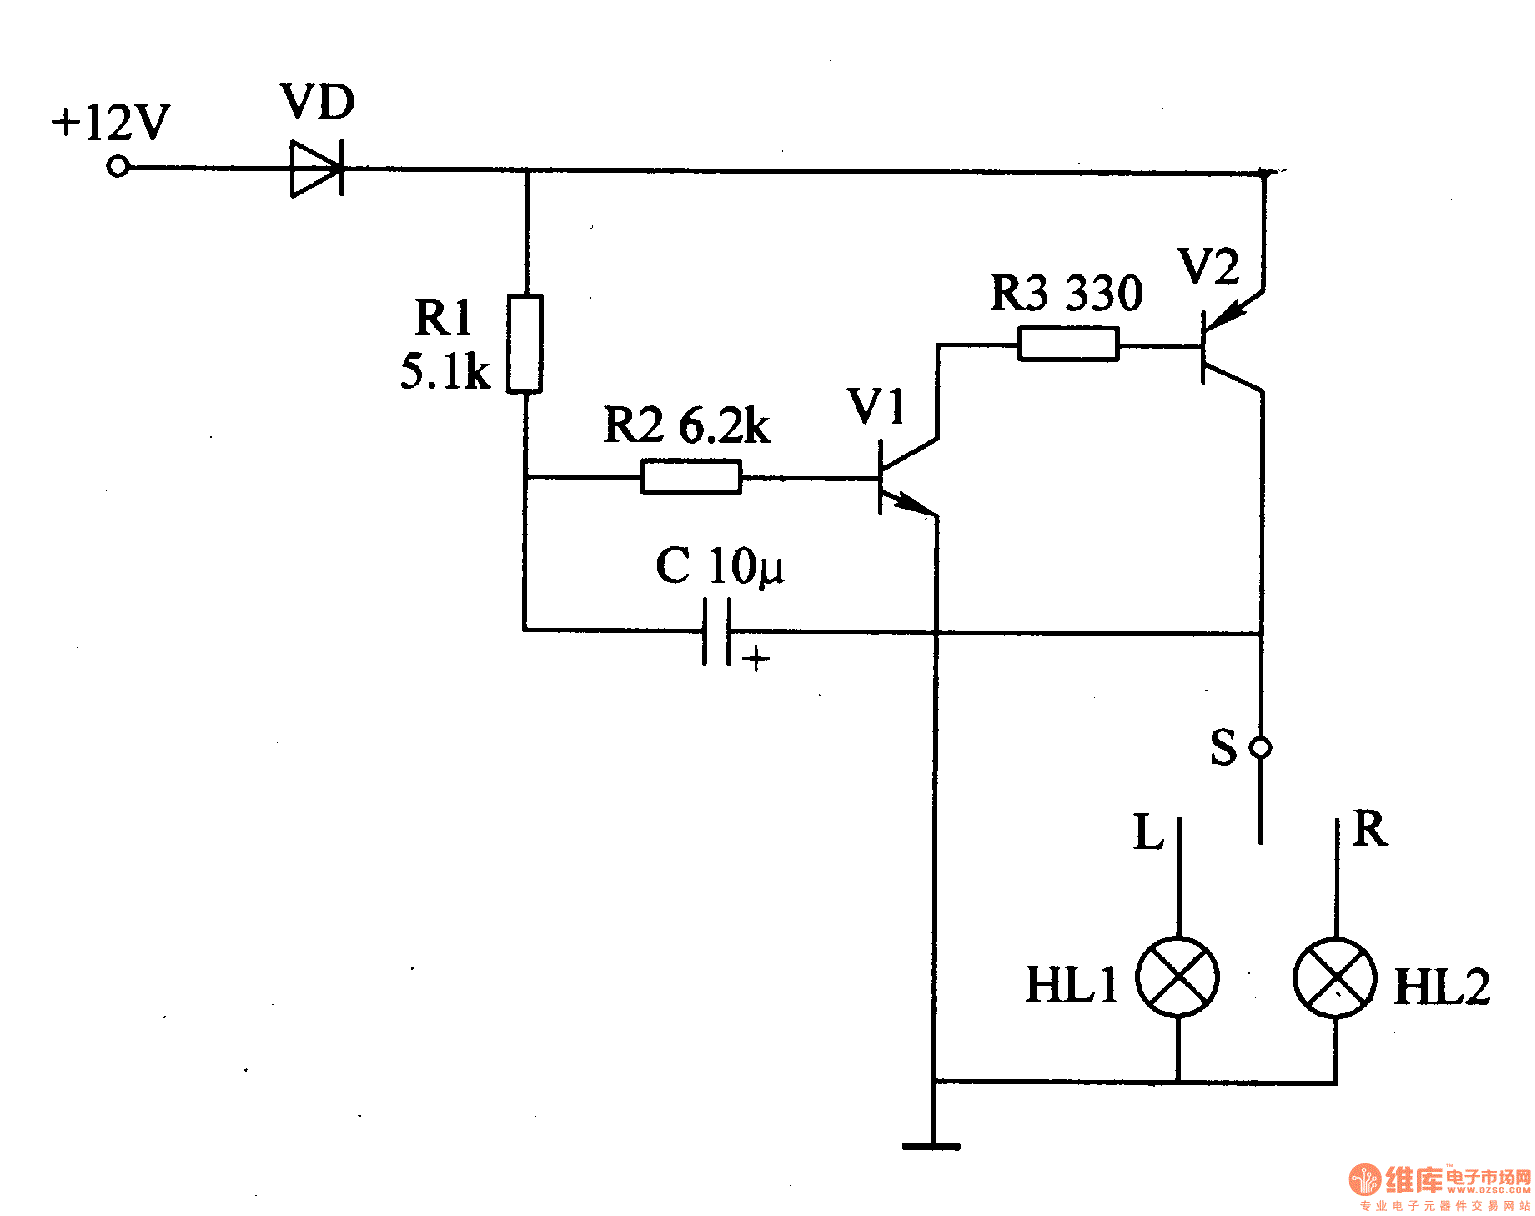
Motor vehicle steering flasher 12
The motor vehicle steering flasher described in the example utilizes high-power transistors as electronic switches, and the circuit is simple and easy to construct. The motor vehicle steering flasher consists of the flash circuit with resistors R1-R3, a capacitor C,...
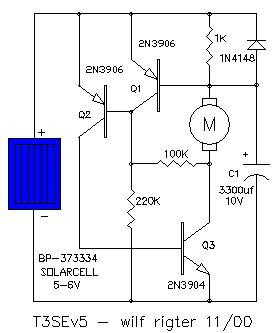
T3SE type 3 SE
The all-transistor T3SE operates similarly to a conventional switch mode power supply (SE). Like the Tritium model, it activates when the charging current falls below a specified threshold. After the circuit is triggered, positive feedback is utilized to latch the...
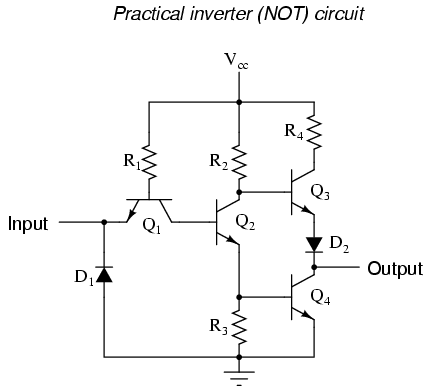
The NOT gate
The single-transistor inverter circuit discussed earlier is too simplistic for practical use as a gate. Real inverter circuits utilize multiple transistors to enhance voltage gain, ensuring that the final output transistor is either in full cutoff or full saturation, while...