


Travel schematic model remote control
#NE556
#dual timer
#Schmitt trigger
#remote control
#time base IC
#555 timer
#circuit diagram
#travel model
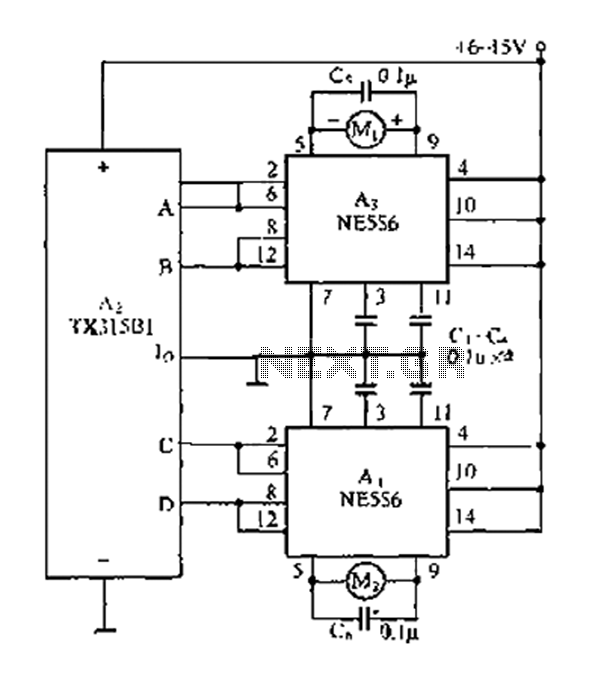
Description: The travel remote control model is represented by a circuit diagram. The NE556 is a dual time base IC that includes two separate circuits, each consisting of a Schmitt trigger circuit. The output control is achieved through the TX315B1, which is realized by a flip-flop. When the input to the Schmitt trigger is low, the output terminal produces a high signal; conversely, when the input is high, the output is low. The motor operation is determined by the levels at both ends: if both ends are high or low, the motor remains stopped; if one end is high and the other low, the motor rotates in one direction. If the high and low signals are swapped, the motor reverses its direction of rotation.
The circuit utilizes the NE556 integrated circuit, which is an evolution of the classic 555 timer, designed for more complex timing and control applications. The dual functionality of the NE556 allows for simultaneous control of two independent timing operations or trigger events. Each section of the NE556 integrates a Schmitt trigger, which is essential for providing clean transitions between high and low states. This characteristic is particularly useful in noisy environments, as it minimizes false triggering.
The TX315B1 module functions as a transmitter in the remote control system, interfacing with the NE556 to manage motor control based on the received signals. The flip-flop configuration is employed to maintain the state of the output, ensuring that the motor's direction can be controlled by the logic levels applied to the Schmitt trigger inputs.
The motor control logic is straightforward: when both inputs to the Schmitt trigger are at the same level (either high or low), the output is designed to disable the motor, effectively stopping it. This safety feature prevents accidental motor activation. When one input is high and the other is low, the output signals the motor to rotate in a designated direction. The ability to reverse the motor's direction by swapping the high and low signals provides versatility in applications where bidirectional motion is required.
Overall, this circuit design is well-suited for remote control applications, offering reliable motor control with the added benefit of reversing capability, making it ideal for various robotic and automation projects. The integration of the NE556 and TX315B1 components ensures efficient operation and responsiveness to control commands. As shown in FIG travel remote control model is a circuit diagram, NE556 is a dual time base IC 555 includes two separate circuits, each consisting of a Schmitt trigger circuit 555, the output of the control TX315B1 realized by flip-flop flip. When the input of the Schmitt trigger is low, its output terminal output high; when the input is high, its output of low output. When both ends of the motor are high or low, the motor is stopped; when both ends of the motor is high end, and the other side is low, the motor rotation; if the motor across the high, low swap, reverse the direction of rotation of the motor.
The circuit utilizes the NE556 integrated circuit, which is an evolution of the classic 555 timer, designed for more complex timing and control applications. The dual functionality of the NE556 allows for simultaneous control of two independent timing operations or trigger events. Each section of the NE556 integrates a Schmitt trigger, which is essential for providing clean transitions between high and low states. This characteristic is particularly useful in noisy environments, as it minimizes false triggering.
The TX315B1 module functions as a transmitter in the remote control system, interfacing with the NE556 to manage motor control based on the received signals. The flip-flop configuration is employed to maintain the state of the output, ensuring that the motor's direction can be controlled by the logic levels applied to the Schmitt trigger inputs.
The motor control logic is straightforward: when both inputs to the Schmitt trigger are at the same level (either high or low), the output is designed to disable the motor, effectively stopping it. This safety feature prevents accidental motor activation. When one input is high and the other is low, the output signals the motor to rotate in a designated direction. The ability to reverse the motor's direction by swapping the high and low signals provides versatility in applications where bidirectional motion is required.
Overall, this circuit design is well-suited for remote control applications, offering reliable motor control with the added benefit of reversing capability, making it ideal for various robotic and automation projects. The integration of the NE556 and TX315B1 components ensures efficient operation and responsiveness to control commands. As shown in FIG travel remote control model is a circuit diagram, NE556 is a dual time base IC 555 includes two separate circuits, each consisting of a Schmitt trigger circuit 555, the output of the control TX315B1 realized by flip-flop flip. When the input of the Schmitt trigger is low, its output terminal output high; when the input is high, its output of low output. When both ends of the motor are high or low, the motor is stopped; when both ends of the motor is high end, and the other side is low, the motor rotation; if the motor across the high, low swap, reverse the direction of rotation of the motor.
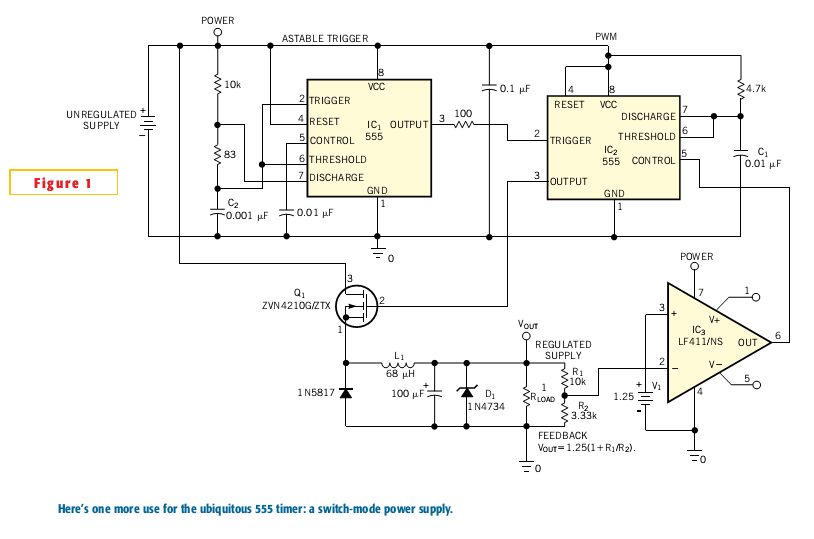
555 Timer As A Switch-Mode Power Supply
Most switch-mode power supplies utilize a PWM (pulse-width-modulated) output that is regulated through voltage feedback. A 555-timer IC can be used to generate PWM at a low cost. The circuit diagram illustrates how to convert a 555 PWM circuit into...
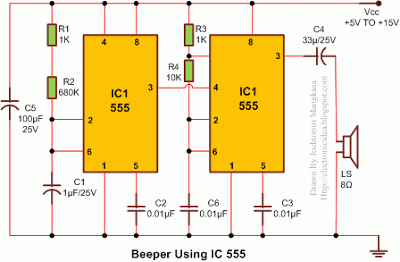
Beeper Using 1C 555
This beeper circuit utilizes two 555 integrated circuits (ICs) and can operate within a supply voltage range of 5 to 15V DC. It is suitable for applications requiring an alarm or beeping signal. The first IC (IC1) is configured in...
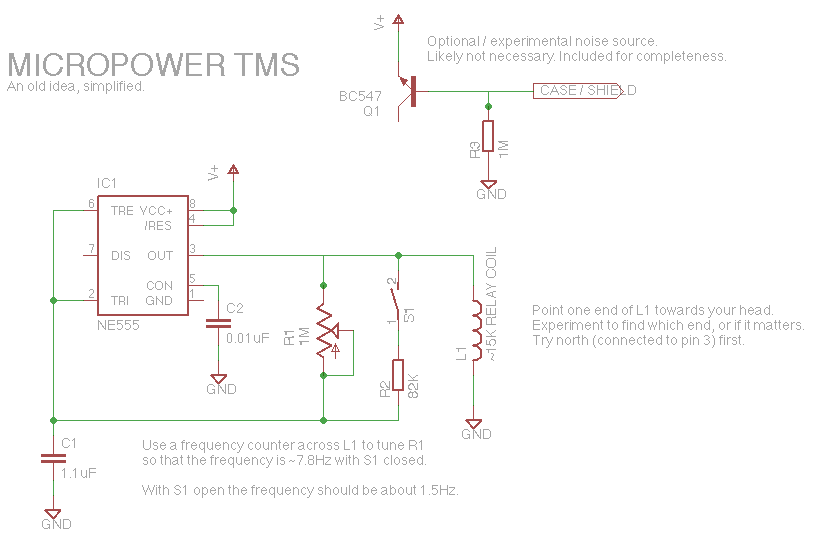
Tune Your Brainwaves Instantly with an Ultra-Simple 555 Circuit
Let's face it, not every day is the greatest. Sometimes, one may not feel like doing much of anything. Wouldn't it be nice if there was a way to change brain waves at the push of a button? Transcranial magnetic...
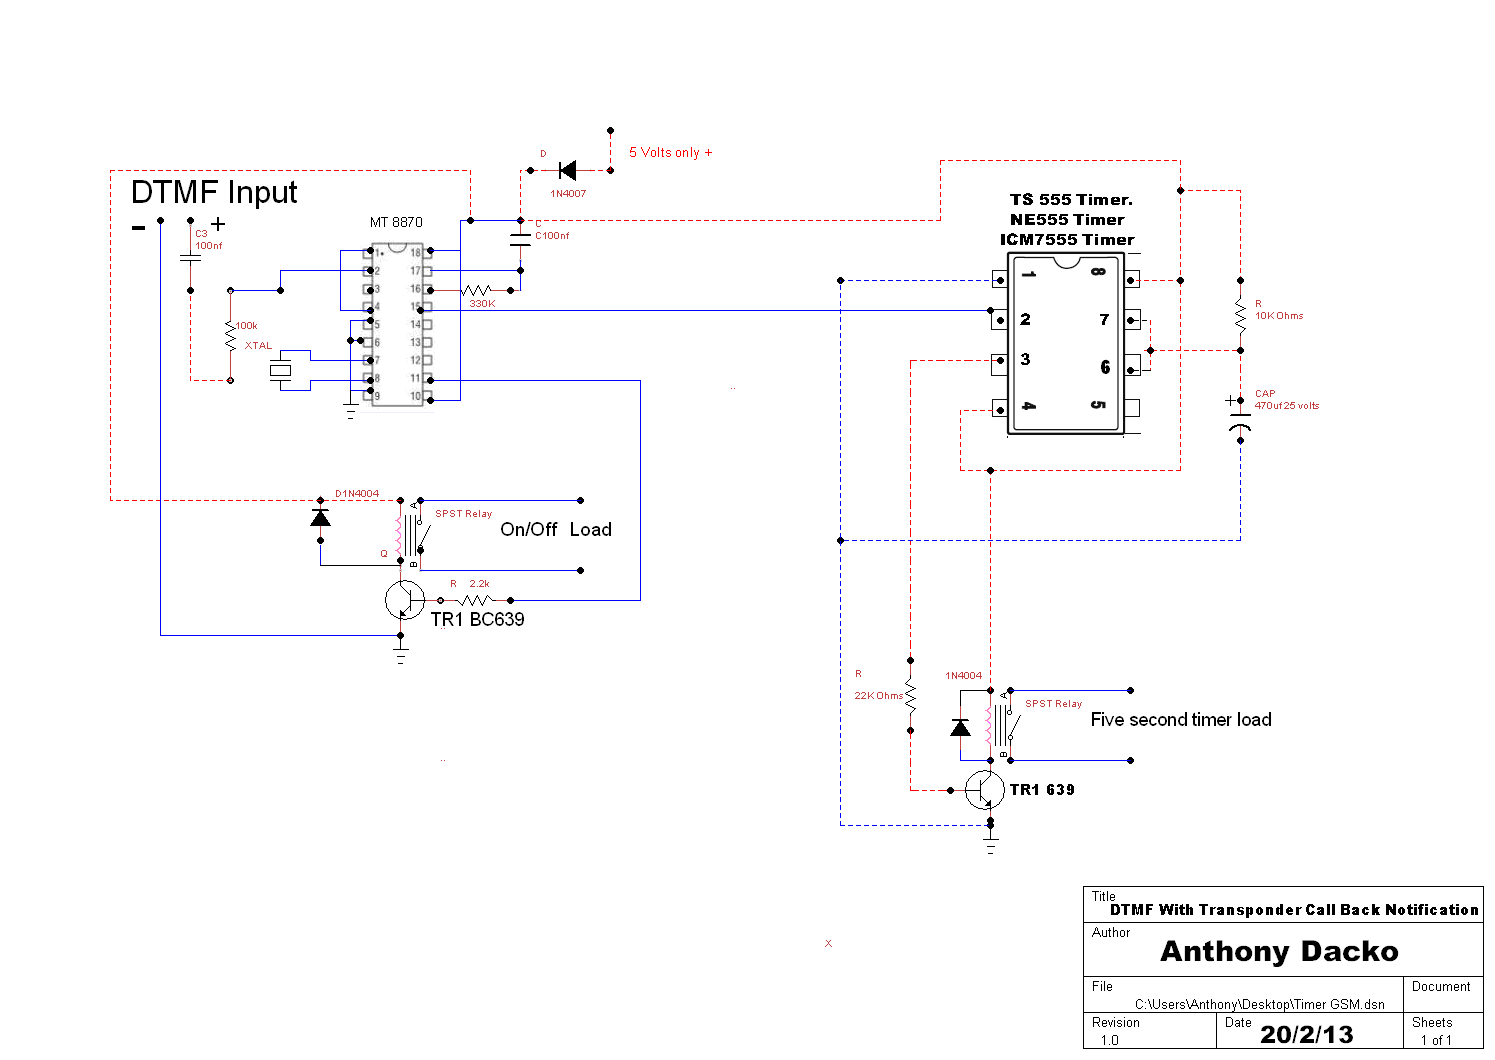
TS555 Timer
The operation of the circuit is straightforward. When a DTMF tone is sent to the decoder, pin 15 goes high for a brief period, which serves as an effective trigger by supplying a few volts to pin 2 of the...
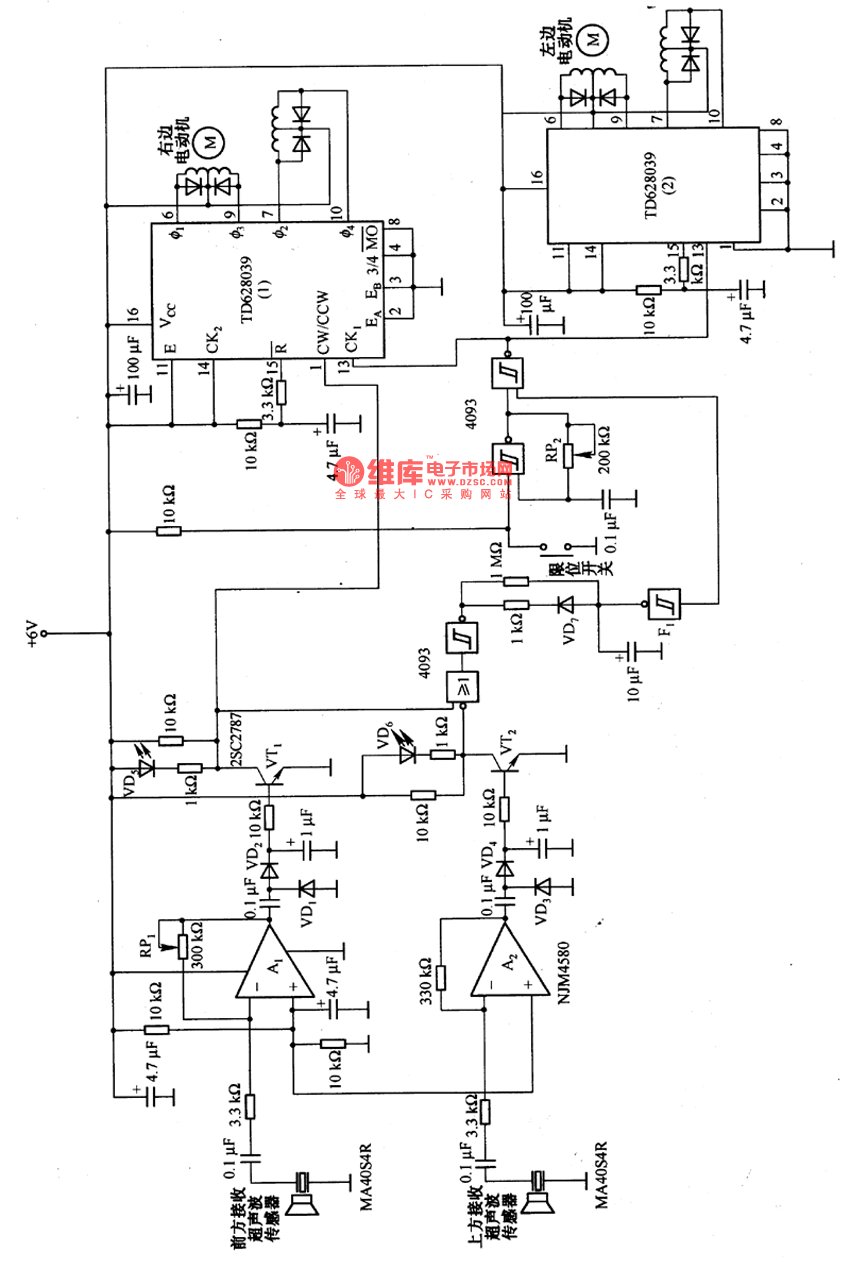
Remote control robot circuit
The remote control robot circuit is illustrated in the accompanying figure. Figure 2-36(a) presents the circuit diagram, while figure 2-36(b) depicts the operating timing diagram. The robot's rotation process involves an ultrasonic launching circuit, which consists of a 40 kHz...
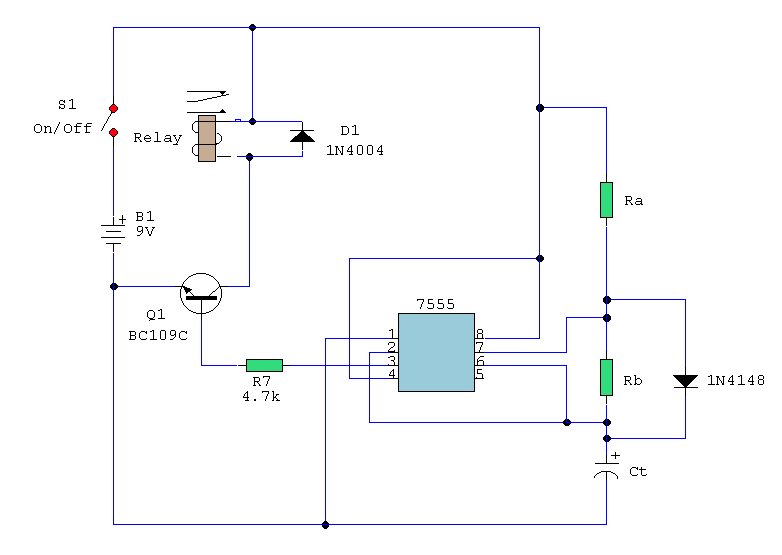
asymmetric timer
A simple astable timer is constructed using a 555 timer IC. The mark (on) and space (off) durations can be set independently. The timing circuit comprises resistors Ra, Rb, and capacitor Ct. The capacitor Ct charges through resistor Ra, which...
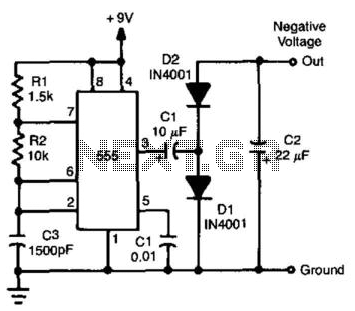
Negative Voltage From A Positive Supply
By utilizing a 555 timer to produce a square wave and employing a voltage-doubling technique on the output, a negative voltage that is nearly equivalent to the positive supply can be achieved. The available current ranges from 20 to 30...
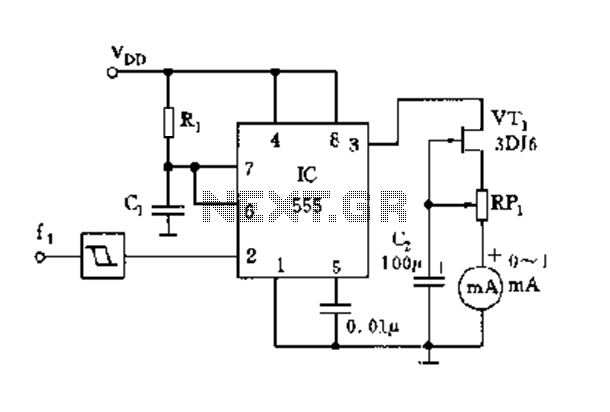
555 meter frequency meter schematic
The circuit consists of a 555 timer along with components R1, C1, and other elements configured as a monostable delay circuit. The input square wave signal is shaped by a Schmitt trigger to meet the triggering requirements.
The 555 timer in...
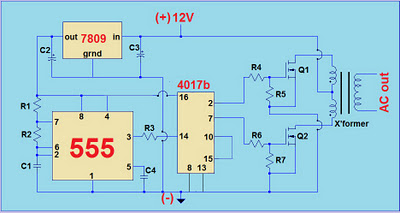
12V-220V Modified Sine-wave Inverter Circuit
This project involves a simple 12V to 220V modified sine-wave inverter utilizing a 555 timer IC and a CD4017 decade counter. The inverter is capable of delivering 300W of continuous power and approximately 500W of maximum power output for short...