


GSM Remote Control MotherBoard Schematic
#GSM
#PIC microcontroller
#DTMF decoder
#opto-isolated inputs
#relays
#temperature sensor
#GPRS module
#telecommunication
#home automation
#wireless control
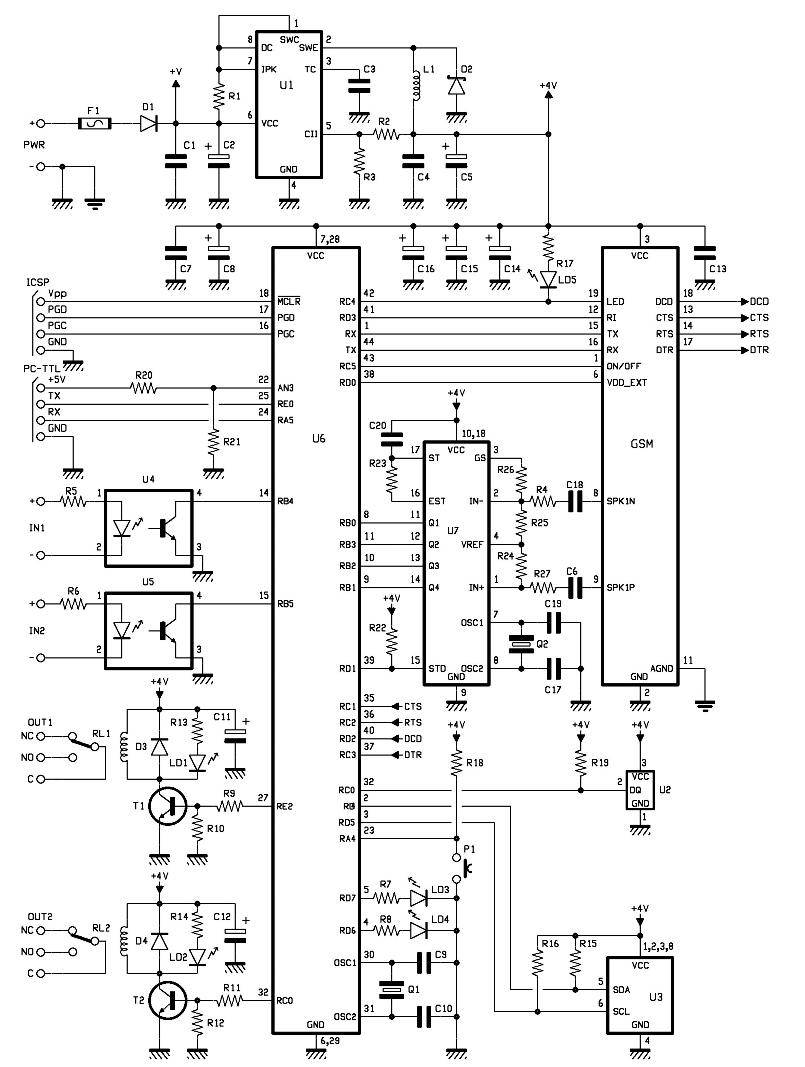
Description: The entire remote control is managed by a PIC that oversees the GSM/GPRS module's operations, monitors room temperature via a Dallas DS1820 smart probe, controls the logical state of two opto-isolated inputs, and sends commands to two relays. Additionally, the circuit includes a DTMF decoder designed to recognize the bi-tones generated by modern telecommunication systems when the keys on a phone's keypad are pressed. This identifier is essential for the DTMF functionality to operate effectively.
Power is supplied by a continuous voltage source, which may not always be stabilized, ranging from 5 to 32V; this voltage is filtered at the input using a diode (D1) to protect against polarity inversion, followed by capacitors C1 and C2. A fuse (F1) protects both the circuit and the power source in the event of a short circuit in the integrated regulator, which is necessary to provide the 4 volts required for the rest of the circuit's operation. The switching regulator utilizes an MC34063 chip, configured as a series PWM regulator powered by an inductor (L1), with the output voltage determined by the energy stored in the inductor. The regulator is stabilized by a resistive divider (R2/R3), ensuring the output voltage is set to 4V across capacitors C4 and C5.
The 4 volts at the output of these capacitors are adequately filtered by additional capacitors on the power lines of the microcontroller and the GSM module. During transmission, the GSM module experiences peak current demands, which are compensated by capacitors C7, C8, C13, C14, C15, and C16, preventing any impulsive current requests from disturbing the microcontroller's operation. The microcontroller controlling the entire system is a PIC18F46K20-I/PT from Microchip, configured with an internal clock oscillator. Both the schematic and the printed circuit board are designed to accommodate an external quartz oscillator for users who may wish to modify the firmware or develop specific applications requiring this feature.
After initializing the I/O lines, the microcontroller checks the logical state of the opto-isolated inputs (RB4 and RB5) and the lines (RC4, RC5, RD0, RD3, RX) needed for receiving notifications from the cellular module. Specifically, RD3 detects incoming calls by interfacing with the RI pin of the cellular module, while RC4 controls the GSM reception LED (STATLED), which blinks at a frequency of 1 Hz when the module searches for the mobile network and emits pulses at logical low for 0.5 seconds followed by a 2-second pause once a signal is detected. The frequency and duration of these pulses allow the PIC to assess the mobile network's status and respond appropriately. For instance, if an opto-isolated input is triggered and the system needs to send SMS messages or make calls but detects no reception from the cellular module, it will wait for the Telit module to reconnect to the GSM/GPRS network before proceeding with any calls. The system attempts to make calls or send SMS messages a maximum of three times before ceasing attempts. The microcontroller also includes a UART for serial communication.The entire remote control is handled by a PIC that controls the GSM/GPRS module`s activity, reads the room temperature through a Dallas DS1820 smart probe, controls the logical state of two opto-isolated inputs, and gives commands to the two relays. In addition, the circuit is equipped with a DTMF decoder whose purpose it is to identify the bi-tones involved in the phone
selection found within modern telecommunication systems bi-tones which every phone emits and sends out on phone lines when its keyboard keys are pressed. The identifier is necessary in order for the DTMF functionality to work. Having said that, let`s take a better look at the electric scheme: power is supplied by continuous voltage, not always stabilized (applied to PWR + and -) at a value between 5 and 32V; such voltage is filtered at the bottom by the diode protecting against polarity inversion (D1) through condensers C1 and C2.
Fuse F1 enables us to protect both the circuit and the power source in case of a short circuit in the integrated regulator discussed below, which is necessary to obtain the 4 volts needed for the rest of the circuit to work. The switching regulator is based on a MC34063 chip, utilized in the classic configuration of series PWM regulators charged by inductance, whose output voltage depends on the energy stored in L1; the regulator is stabilized by the component demoted from resistive divider R2/R3, which is needed to set at 4V the component leveled at the top of both C4 e C5.
The 4 volts at the bottom of the abovementioned condensers are sufficiently filtered by other condensers placed on the power lines of the microcontroller and of the GSM module; which presents, during transmission, absorption peaks compensated for by C7, C8, C13, C14, C15 e C16, thus avoiding that an impulsive current request may cause the microcontroller to be disturbed. The microcontroller used to handle the whole system is a powerful PIC18F46K20-I/PT by Microchip, which we use in its configuration with an internal clock oscillator; both the scheme and in the printed circuit are nevertheless equipped with external quartz, which we included for those who may want to modify the firmware and develop specific applications requiring an external oscillator.
Once the I/O lines have been initialized, the microcontroller verifies the logical state of the opto-isolated inputs at voltage level (RB4 and RB5) as well as that of lines RC4, RC5, RD0, RD3, RX, which are needed to receive the main notifications from the cellular module; more specifically, RD3 is used to detect incoming calls (it interfaces with RI of the cellular module), while RC4 controls the GSM`s reception led, whose output (dubbed STATLED) pulsates at a frequency of 1 Hz when the module is searching for the radio-mobile network, and supplies impulses at logical zero, lasting 0. 5 seconds and followed by a 2-second pause, when the module has grasped the signal. The frequency and duration of the impulses enable the PIC to understand the conditions of the radio-mobile network range and to behave accordingly; for example, if the opto-isolated input goes off and it needs, therefore, to send SMSs or make calls, but detects that the cellular module has no reception, it waits for the Telit module to get reconnected to the GSM/GPRS network before making any calls.
The attempt to make calls or send SMSs is repeated only three times, after which the device gives up. The microcontroller contains a UART a
Power is supplied by a continuous voltage source, which may not always be stabilized, ranging from 5 to 32V; this voltage is filtered at the input using a diode (D1) to protect against polarity inversion, followed by capacitors C1 and C2. A fuse (F1) protects both the circuit and the power source in the event of a short circuit in the integrated regulator, which is necessary to provide the 4 volts required for the rest of the circuit's operation. The switching regulator utilizes an MC34063 chip, configured as a series PWM regulator powered by an inductor (L1), with the output voltage determined by the energy stored in the inductor. The regulator is stabilized by a resistive divider (R2/R3), ensuring the output voltage is set to 4V across capacitors C4 and C5.
The 4 volts at the output of these capacitors are adequately filtered by additional capacitors on the power lines of the microcontroller and the GSM module. During transmission, the GSM module experiences peak current demands, which are compensated by capacitors C7, C8, C13, C14, C15, and C16, preventing any impulsive current requests from disturbing the microcontroller's operation. The microcontroller controlling the entire system is a PIC18F46K20-I/PT from Microchip, configured with an internal clock oscillator. Both the schematic and the printed circuit board are designed to accommodate an external quartz oscillator for users who may wish to modify the firmware or develop specific applications requiring this feature.
After initializing the I/O lines, the microcontroller checks the logical state of the opto-isolated inputs (RB4 and RB5) and the lines (RC4, RC5, RD0, RD3, RX) needed for receiving notifications from the cellular module. Specifically, RD3 detects incoming calls by interfacing with the RI pin of the cellular module, while RC4 controls the GSM reception LED (STATLED), which blinks at a frequency of 1 Hz when the module searches for the mobile network and emits pulses at logical low for 0.5 seconds followed by a 2-second pause once a signal is detected. The frequency and duration of these pulses allow the PIC to assess the mobile network's status and respond appropriately. For instance, if an opto-isolated input is triggered and the system needs to send SMS messages or make calls but detects no reception from the cellular module, it will wait for the Telit module to reconnect to the GSM/GPRS network before proceeding with any calls. The system attempts to make calls or send SMS messages a maximum of three times before ceasing attempts. The microcontroller also includes a UART for serial communication.The entire remote control is handled by a PIC that controls the GSM/GPRS module`s activity, reads the room temperature through a Dallas DS1820 smart probe, controls the logical state of two opto-isolated inputs, and gives commands to the two relays. In addition, the circuit is equipped with a DTMF decoder whose purpose it is to identify the bi-tones involved in the phone
selection found within modern telecommunication systems bi-tones which every phone emits and sends out on phone lines when its keyboard keys are pressed. The identifier is necessary in order for the DTMF functionality to work. Having said that, let`s take a better look at the electric scheme: power is supplied by continuous voltage, not always stabilized (applied to PWR + and -) at a value between 5 and 32V; such voltage is filtered at the bottom by the diode protecting against polarity inversion (D1) through condensers C1 and C2.
Fuse F1 enables us to protect both the circuit and the power source in case of a short circuit in the integrated regulator discussed below, which is necessary to obtain the 4 volts needed for the rest of the circuit to work. The switching regulator is based on a MC34063 chip, utilized in the classic configuration of series PWM regulators charged by inductance, whose output voltage depends on the energy stored in L1; the regulator is stabilized by the component demoted from resistive divider R2/R3, which is needed to set at 4V the component leveled at the top of both C4 e C5.
The 4 volts at the bottom of the abovementioned condensers are sufficiently filtered by other condensers placed on the power lines of the microcontroller and of the GSM module; which presents, during transmission, absorption peaks compensated for by C7, C8, C13, C14, C15 e C16, thus avoiding that an impulsive current request may cause the microcontroller to be disturbed. The microcontroller used to handle the whole system is a powerful PIC18F46K20-I/PT by Microchip, which we use in its configuration with an internal clock oscillator; both the scheme and in the printed circuit are nevertheless equipped with external quartz, which we included for those who may want to modify the firmware and develop specific applications requiring an external oscillator.
Once the I/O lines have been initialized, the microcontroller verifies the logical state of the opto-isolated inputs at voltage level (RB4 and RB5) as well as that of lines RC4, RC5, RD0, RD3, RX, which are needed to receive the main notifications from the cellular module; more specifically, RD3 is used to detect incoming calls (it interfaces with RI of the cellular module), while RC4 controls the GSM`s reception led, whose output (dubbed STATLED) pulsates at a frequency of 1 Hz when the module is searching for the radio-mobile network, and supplies impulses at logical zero, lasting 0. 5 seconds and followed by a 2-second pause, when the module has grasped the signal. The frequency and duration of the impulses enable the PIC to understand the conditions of the radio-mobile network range and to behave accordingly; for example, if the opto-isolated input goes off and it needs, therefore, to send SMSs or make calls, but detects that the cellular module has no reception, it waits for the Telit module to get reconnected to the GSM/GPRS network before making any calls.
The attempt to make calls or send SMSs is repeated only three times, after which the device gives up. The microcontroller contains a UART a
Temperature Sensor
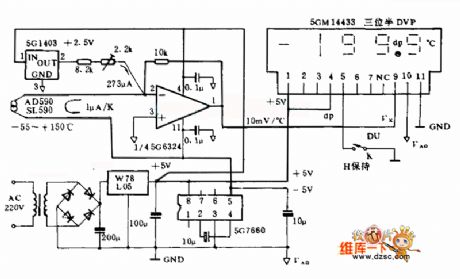
The LM35 temperature sensor provides an output of 10 mV/°C for every degree Celsius over 0°C. At 20°C, the output voltage is 20 x 10 = 200 mV. The circuit consumes 60 µA. The load resistance should not be less...
Electronic-heat-sniffer
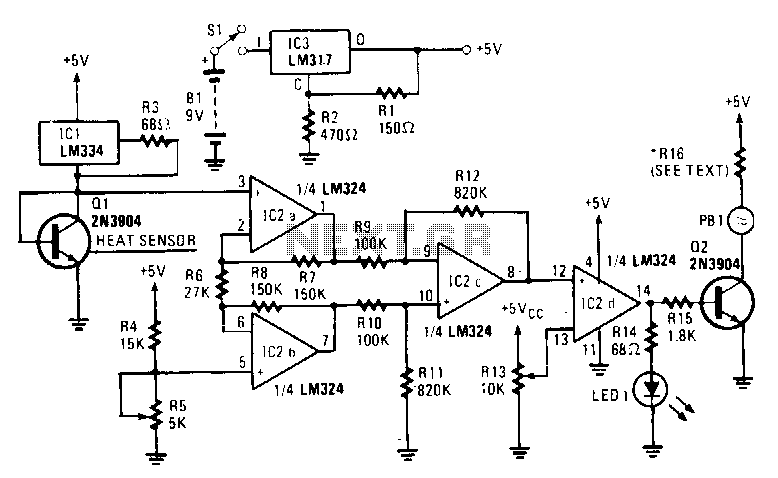
The sensing element Q1 is a 2N3904 general-purpose NPN transistor, although any general-purpose NPN unit in a TO-92 style case will suffice. IC1, an LM334, provides Q1 with a constant current that remains stable regardless of temperature variations. An LM324...
Energy Leak Detector
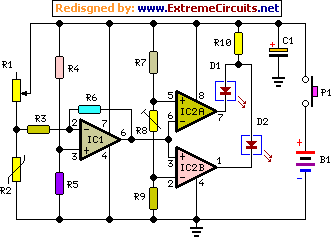
This sensitive circuit functions primarily as a comparator, capable of detecting minimal temperature changes relative to ambient temperature. It was originally designed to identify drafts around doors and windows that lead to energy loss, but it can be utilized in...
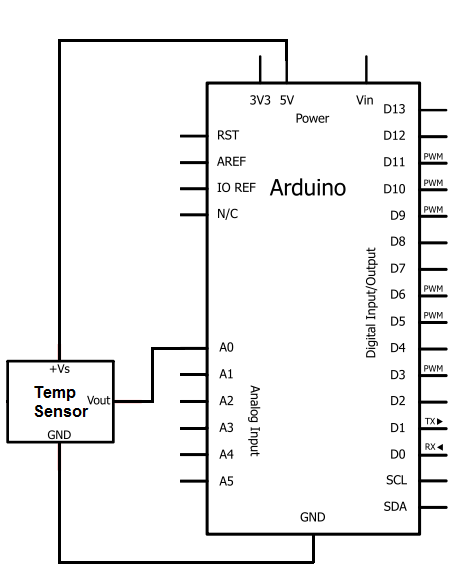
Temperature Sensor Circuit
The integrated circuit (IC) used for temperature measurement is the TMP36. This IC will be integrated with an Arduino to obtain temperature readings. The Arduino will read the measured value from the TMP36 and convert it into degrees Fahrenheit, which...
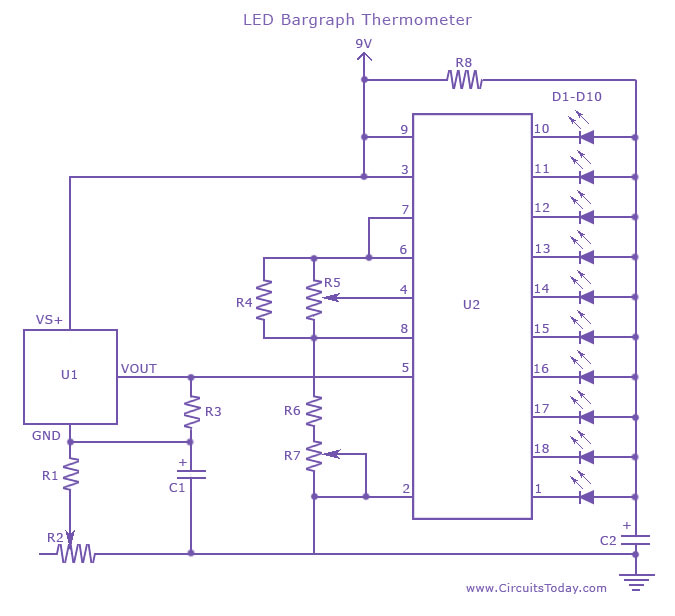
LED Thermometer-Temperature Measurement Circuit using LM 34 IC
An LED thermometer that can function as a temperature sensor or temperature measurement circuit, utilizing the LM34 for Fahrenheit display or the LM35 for degree Celsius display.
The LED thermometer circuit is designed to provide accurate temperature readings using either the...
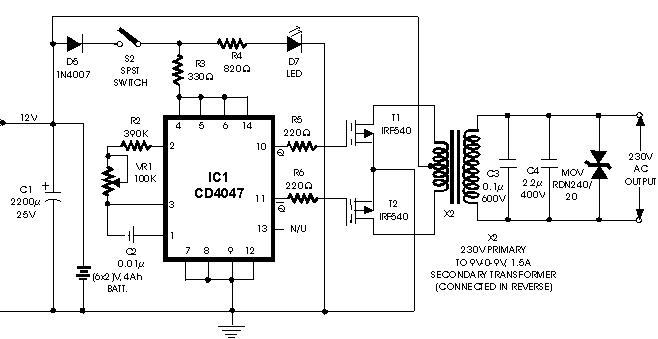
pic based modified sine wave inverter
A PIC-based inverter circuit is being developed that utilizes two P-channel MOSFETs (F9540N) along with a center-tapped 12-0-12/230V transformer.
The proposed circuit design incorporates a microcontroller from the PIC family, which serves as the main control unit for the inverter operation....
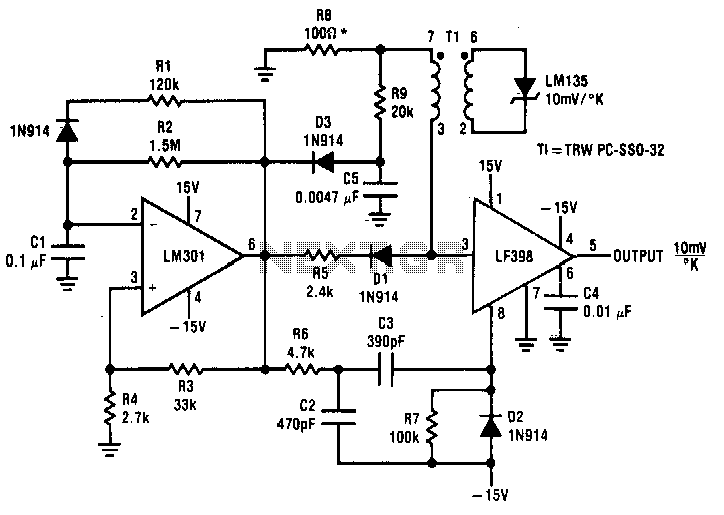
Two-simple-temperature-to-time-converters
Both converters utilize CMOS inverters. Figure 105-1A illustrates a free-running circuit where both pulse duration and pulse pause are influenced by the temperature of diode D8. This configuration is suitable for applications where synchronization between the converter and other systems...
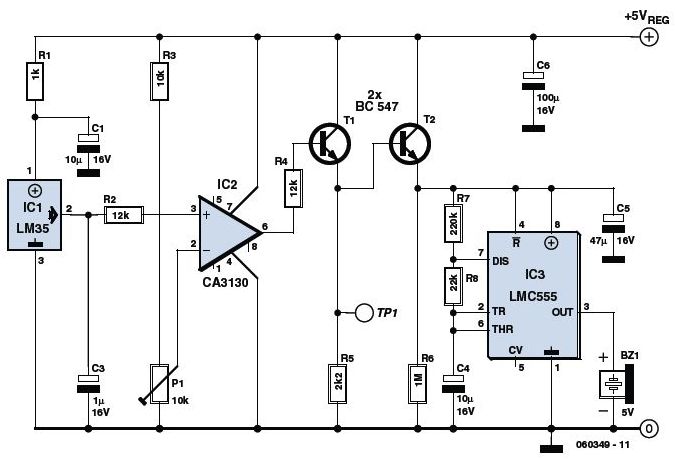
Detector circuit
This is an Overheat Detector Alarm Switch using the Temperature Sensor IC LM35. The core of this overheat detector (fire alarm) circuit is a precision integrated temperature sensor, the LM35 (IC1), which provides an accurately linear and directly proportional output...
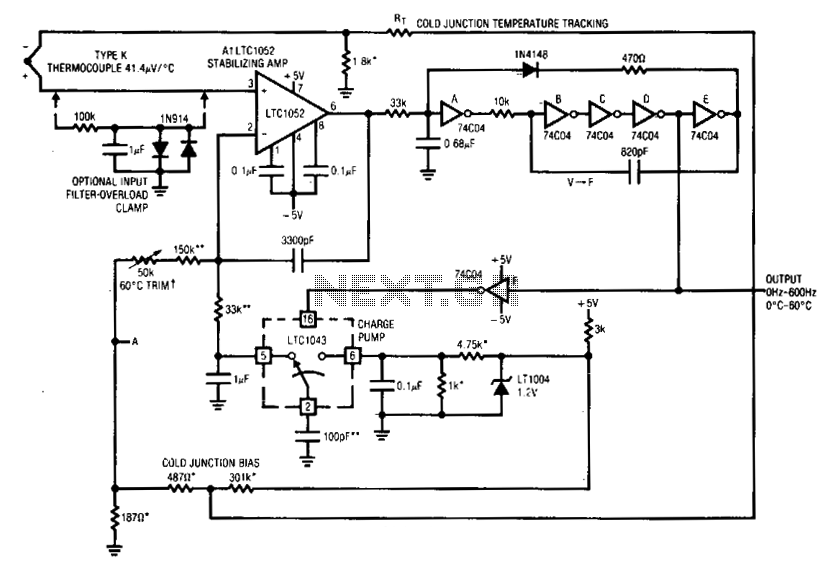
Temperature-to-frequency converter
Al's positive input is biased by the thermocouple. Al's output drives a basic voltage-to-frequency (V-F) converter, which consists of 74C04 inverters and related components. Each V-F output pulse results in a fixed amount of charge being transferred from a 100...