


Tachless-motor-speed-controller
#motor speed control
#back EMF
#digital control
#robotics
#positioning systems
#5V logic
#sampled loop
#pulse train
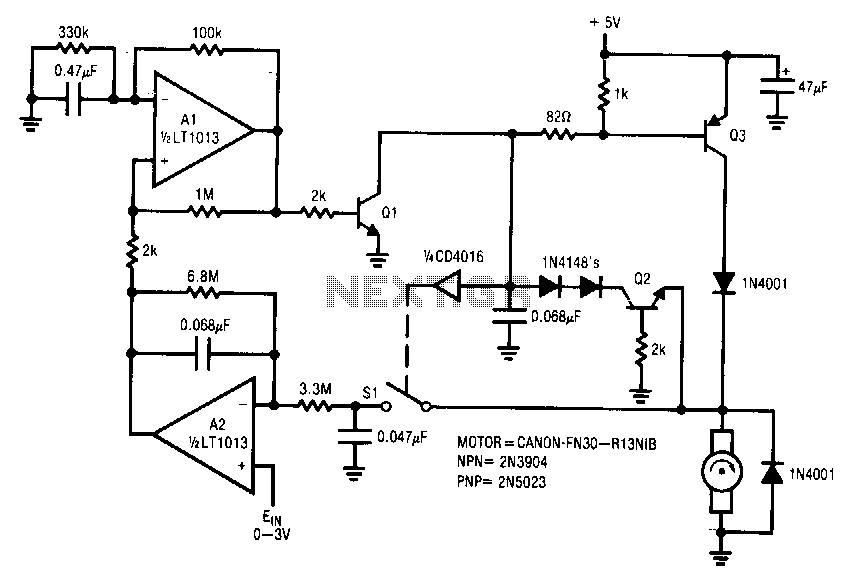
Description: This circuit is particularly applicable to digitally controlled systems in robotic and X-Y positioning applications. By operating from a 5-V logic supply, it eliminates the need for additional motor drive supplies. The tachless feedback mechanism saves both space and cost. The circuit senses the motor's back EMF to determine its speed. The difference between the actual speed and a set point is utilized to close a sampled loop around the motor, with an operational amplifier (A1) generating a pulse train. When A1's output is high, transistor Q1 is biased, allowing transistor Q3 to drive the motor's ungrounded terminal. As A1's output decreases, Q3 turns off, and the motor's back EMF becomes available after the inductive flyback ceases. During this period, the input of switch S1 is activated, and the 0.047-µF capacitor captures the value of the back EMF. Operational amplifier A2 compares this captured value with the set point, and the amplified difference adjusts A1's duty cycle, thereby controlling the motor speed.
The circuit operates on a closed-loop feedback mechanism that enhances the precision of motor control in robotic applications. The use of a 5-V logic supply simplifies the design by eliminating the need for additional power sources, which can lead to reduced complexity and cost. The tachless feedback approach is particularly advantageous as it utilizes the back EMF generated by the motor, allowing for real-time speed measurement without the need for external sensors, which can further minimize the physical footprint of the system.
In operation, when the output from operational amplifier A1 is high, it activates transistor Q1, which in turn biases transistor Q3. This action allows current to flow to the motor's ungrounded terminal, enabling motor operation. As the motor accelerates, it generates back EMF proportional to its speed. When A1's output decreases, indicating a reduction in the desired speed, transistor Q3 turns off, ceasing the power to the motor. The back EMF is then available for measurement after the inductive flyback period, which is when the motor's internal inductance generates a brief voltage spike as the current flow is interrupted.
At this point, switch S1 is engaged, and the 0.047-µF capacitor charges to the voltage level of the back EMF. This stored voltage is then compared to the predetermined set point by operational amplifier A2. The output from A2 represents the difference between the measured back EMF and the set point, which is amplified to provide a control signal back to A1. This feedback loop adjusts A1's duty cycle, effectively modulating the power delivered to the motor, thereby achieving precise control over its speed.
This circuit design exemplifies efficient motor control for applications requiring high accuracy and responsiveness, particularly in environments where space and cost are critical considerations. The integration of feedback mechanisms and the elimination of additional power supplies contribute to a streamlined and effective solution for modern robotic systems.This circuit is particularly applicable to digitally-controlled systems in robotic and X-Y positioning applications. By functioning from the 5-V logic supply, it eliminates additional motor-drive supplies. The tachless feedback saves additional space and cost. The circuit senses the motor"s back EMF to determine its speed. The difference between the speed and a set point is used to close a sampled loop around the motor. Al generates a pulse train. When Al"s output is high, Ql is biased, and Q3 drives the motor"s ungrounded terminal. When Al decreases, Q3 turns off and the motor"s back EMF appears after the inductive flyback ceases. During this period, Sl"s input is turned on, and the 0.047-I"F capacitor acquires the back EMF"s value.
A2 compares this value with the set point and the amplified difference (trace D) changes Al "s duty cycle, controlling the motor speed.
The circuit operates on a closed-loop feedback mechanism that enhances the precision of motor control in robotic applications. The use of a 5-V logic supply simplifies the design by eliminating the need for additional power sources, which can lead to reduced complexity and cost. The tachless feedback approach is particularly advantageous as it utilizes the back EMF generated by the motor, allowing for real-time speed measurement without the need for external sensors, which can further minimize the physical footprint of the system.
In operation, when the output from operational amplifier A1 is high, it activates transistor Q1, which in turn biases transistor Q3. This action allows current to flow to the motor's ungrounded terminal, enabling motor operation. As the motor accelerates, it generates back EMF proportional to its speed. When A1's output decreases, indicating a reduction in the desired speed, transistor Q3 turns off, ceasing the power to the motor. The back EMF is then available for measurement after the inductive flyback period, which is when the motor's internal inductance generates a brief voltage spike as the current flow is interrupted.
At this point, switch S1 is engaged, and the 0.047-µF capacitor charges to the voltage level of the back EMF. This stored voltage is then compared to the predetermined set point by operational amplifier A2. The output from A2 represents the difference between the measured back EMF and the set point, which is amplified to provide a control signal back to A1. This feedback loop adjusts A1's duty cycle, effectively modulating the power delivered to the motor, thereby achieving precise control over its speed.
This circuit design exemplifies efficient motor control for applications requiring high accuracy and responsiveness, particularly in environments where space and cost are critical considerations. The integration of feedback mechanisms and the elimination of additional power supplies contribute to a streamlined and effective solution for modern robotic systems.This circuit is particularly applicable to digitally-controlled systems in robotic and X-Y positioning applications. By functioning from the 5-V logic supply, it eliminates additional motor-drive supplies. The tachless feedback saves additional space and cost. The circuit senses the motor"s back EMF to determine its speed. The difference between the speed and a set point is used to close a sampled loop around the motor. Al generates a pulse train. When Al"s output is high, Ql is biased, and Q3 drives the motor"s ungrounded terminal. When Al decreases, Q3 turns off and the motor"s back EMF appears after the inductive flyback ceases. During this period, Sl"s input is turned on, and the 0.047-I"F capacitor acquires the back EMF"s value.
A2 compares this value with the set point and the amplified difference (trace D) changes Al "s duty cycle, controlling the motor speed.
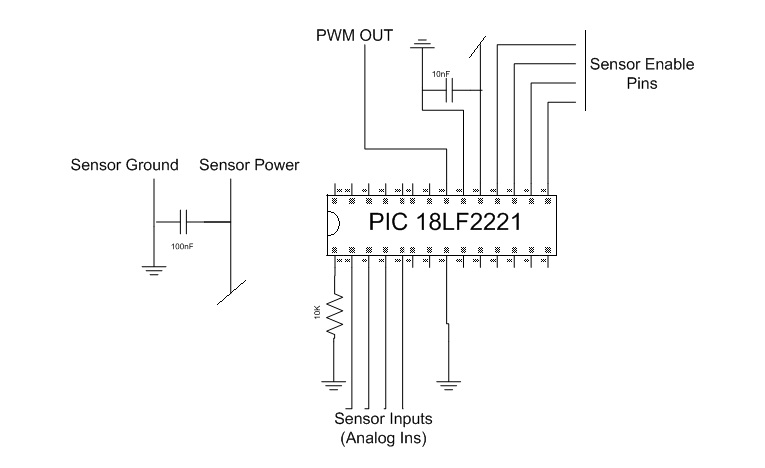
maze robot sensor integration
This project was completed during a robotics course taught by Prof. Dave Barret at Olin College. The final project aimed to navigate a maze using a Surveyor robotic platform. Additional sensors were incorporated into the robot, with a focus on...
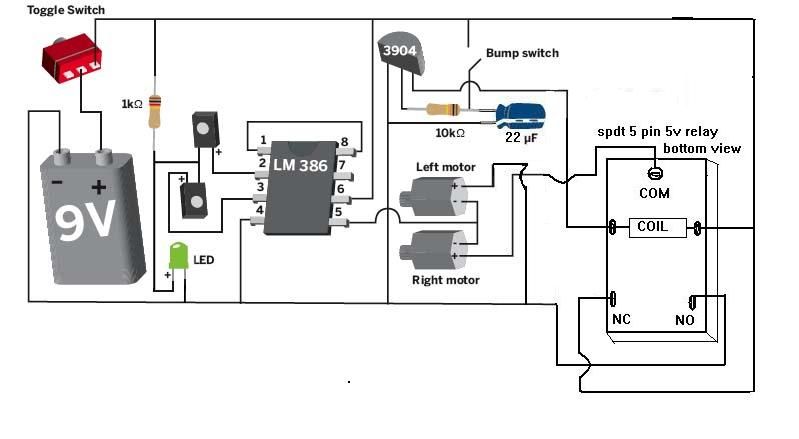
Mousebot Revisited
Mousebot from Make vol 2 is a fun introduction to robotics. This documentation provides an expanded overview of a Mousey build from start to finish.
The Mousebot project serves as an engaging entry point into the world of robotics, particularly suitable...
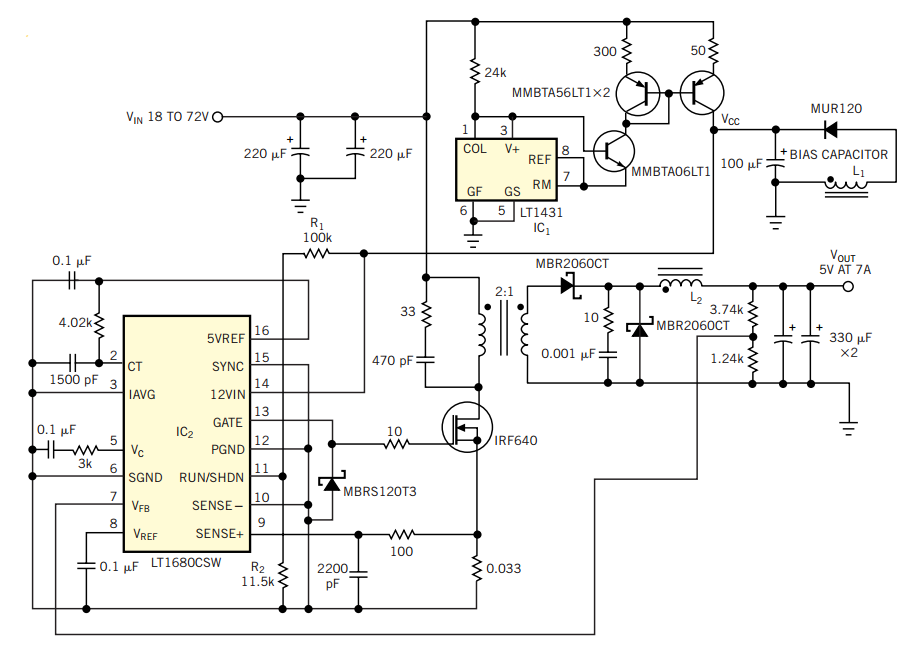
5V logic pulser is battery-powered
A battery-powered, pushbutton-triggered TTL/CMOS-compatible source of debounced 5V logic pulses is a simple but handy piece of test equipment to have in any tool kit. The circuit's battery-powered operation complicates what would otherwise be a trivial exercise in switch-bounce and...
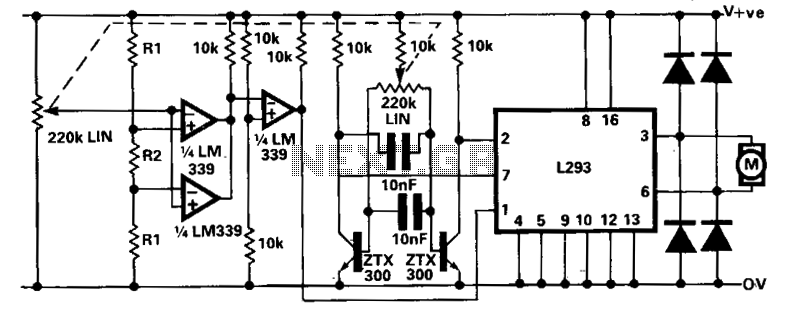
Motor speed control circuit
A limitation of the bi-directional proportional motor control circuit is that when the potentiometer is in its center position, the motor does not stop but continues to creep. This occurs due to the challenge of precisely adjusting the potentiometer to...
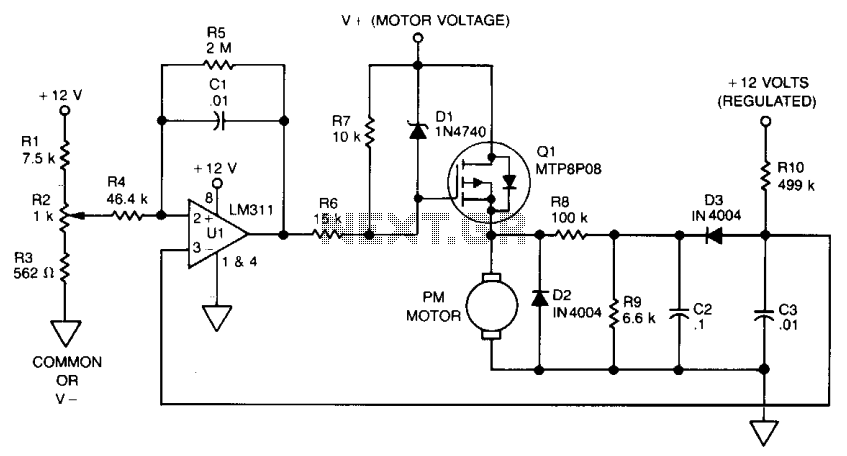
Back emf motor speed control
The use of power MOSFETs facilitates a direct interface between logic and motor power, enabling circuit simplicity and high efficiency. This speed control circuit can be implemented on a 22-pin, double-sided, 3.5 x 4-inch printed circuit board (PCB). A 12...
5V logic pulser is battery-powered
A battery-powered, pushbutton-triggered TTL/CMOS-compatible source of debounced 5V logic pulses is a simple but handy piece of test equipment to have in any tool kit. The circuit's battery-powered operation complicates what would otherwise be a trivial exercise in switch-bounce and...
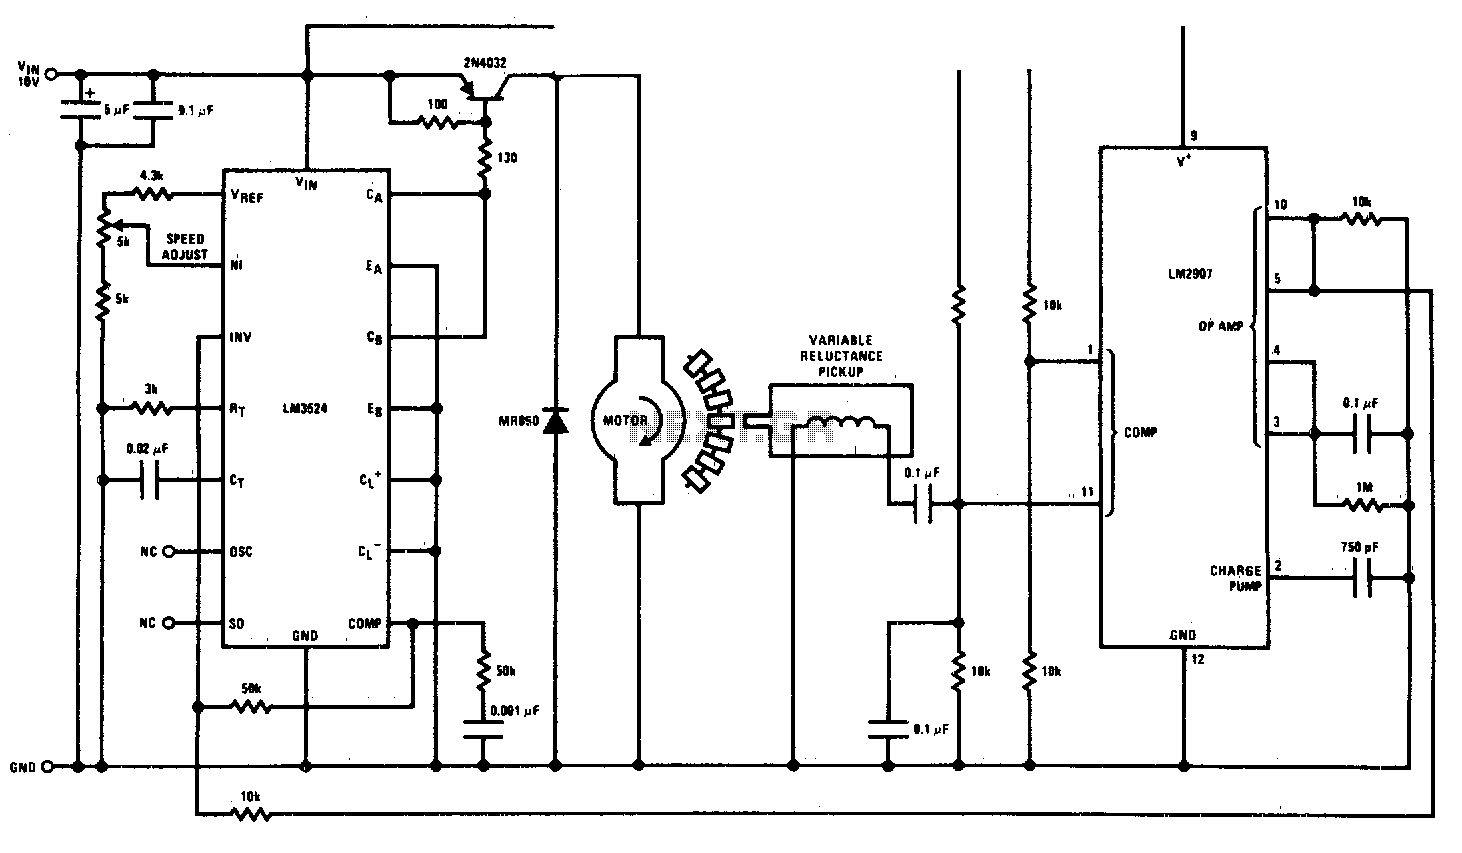
Motor speed control
This circuit is a regulating series DC motor speed control using the LM3524 for the control and drive of the motor and the LM2907 as a speed sensor for the feedback network.
The circuit employs the LM3524 integrated circuit, which serves...
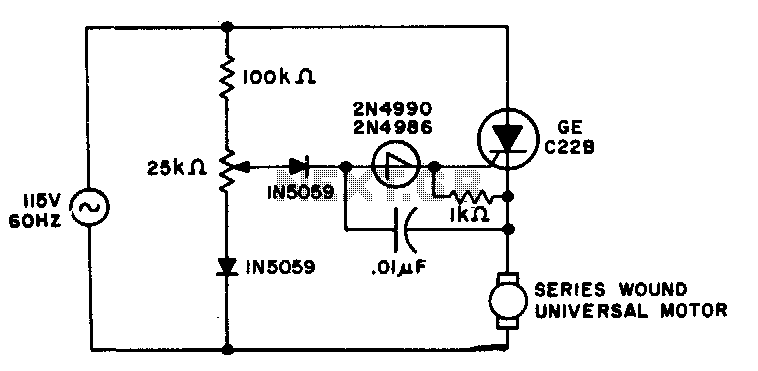
Motor speed control
The switching action of the 2N4990 enables the use of smaller capacitors while ensuring reliable triggering of thyristors.
The 2N4990 is a high-speed switching transistor that plays a crucial role in applications requiring efficient control of thyristors. The device's rapid switching...
Code Collection
CrustCrawler develops and manufactures advanced walking robots and robotic accessories.
CrustCrawler specializes in the design and production of innovative walking robots, which incorporate advanced technologies and engineering principles to achieve improved mobility and functionality. These robots are typically characterized by their...