


Servo Motor Control with PIC16F84
#servo motor
#PIC16F84
#microcontroller
#actuator
#pulse width modulation
#3-state switch
#position control
#VCC
#Ground
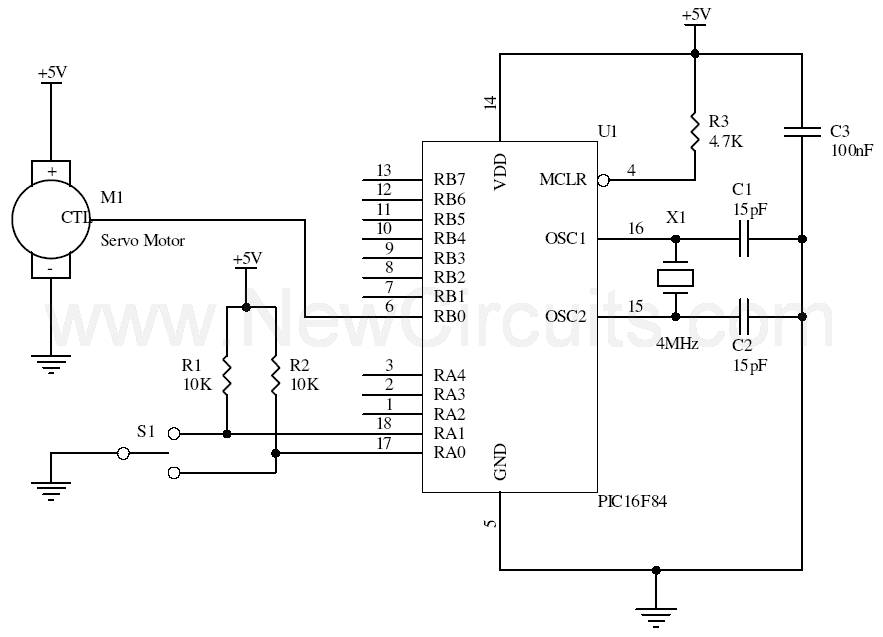
Description: This simple microcontroller circuit regulates a servo motor based on a 3-state switch. The servo motor functions as an actuator with three positions. It consists of three wires: one for VCC, one for ground, and a third for position control. The position control signal is a single pulse with a variable width, which can range from 1 to 2 milliseconds. A pulse width of 1 millisecond positions the motor axis at -45 degrees, a pulse width of 1.5 milliseconds positions it at 0 degrees, and a pulse width of 2 milliseconds positions it at +45 degrees. The accompanying source code has been developed in PICBasic.
The described circuit utilizes a microcontroller, which serves as the central processing unit for controlling the servo motor. The 3-state switch is connected to the microcontroller's input pins, allowing users to select one of three positions for the servo motor. The switch typically connects to ground when not pressed, and when a state is selected, it sends a signal to the microcontroller.
The microcontroller interprets the switch's state and generates a corresponding pulse-width modulation (PWM) signal to control the servo motor. The PWM signal is crucial for determining the position of the motor. The signal's pulse width is generated by configuring a timer within the microcontroller, which can be programmed to output a high signal for the specified duration (1 ms, 1.5 ms, or 2 ms) based on the input from the switch.
The servo motor itself is powered by the VCC wire, while the ground wire completes the circuit. The position control wire receives the PWM signal from the microcontroller, allowing the servo motor to move to the desired position.
In terms of circuit connections, the VCC wire of the servo motor is connected to a suitable power supply, typically 5V, while the ground wire connects to the common ground of the circuit. The position control wire connects to the designated output pin on the microcontroller, which is configured for PWM output.
The source code written in PICBasic includes routines for initializing the microcontroller, reading the state of the switch, and generating the appropriate PWM signal based on the switch's position. This code is essential for the operation of the circuit, as it dictates how the microcontroller responds to user input and controls the servo motor accordingly. Proper implementation of this code ensures smooth and accurate positioning of the servo motor, making it suitable for various applications requiring precise control.This simple micro-control circuit controls a servo motor according to a 3-state switch. A servo motor acts as an actuator in 3 position. It has 3 wires, one for VCC, one for Ground and another one for position control. The last signal is a single pulse with variable width. The pulse width can vary between 1 and 2 mSec. An 1 mSec pulse width turns the motor axis in -45 degrees position. An 1. 5 mSec pulse width turns the motor axis in 0 degree position. A 2 mSec pulse width turns the motor axis in +45 degrees position. The following source code has been written in PICBasic:
The described circuit utilizes a microcontroller, which serves as the central processing unit for controlling the servo motor. The 3-state switch is connected to the microcontroller's input pins, allowing users to select one of three positions for the servo motor. The switch typically connects to ground when not pressed, and when a state is selected, it sends a signal to the microcontroller.
The microcontroller interprets the switch's state and generates a corresponding pulse-width modulation (PWM) signal to control the servo motor. The PWM signal is crucial for determining the position of the motor. The signal's pulse width is generated by configuring a timer within the microcontroller, which can be programmed to output a high signal for the specified duration (1 ms, 1.5 ms, or 2 ms) based on the input from the switch.
The servo motor itself is powered by the VCC wire, while the ground wire completes the circuit. The position control wire receives the PWM signal from the microcontroller, allowing the servo motor to move to the desired position.
In terms of circuit connections, the VCC wire of the servo motor is connected to a suitable power supply, typically 5V, while the ground wire connects to the common ground of the circuit. The position control wire connects to the designated output pin on the microcontroller, which is configured for PWM output.
The source code written in PICBasic includes routines for initializing the microcontroller, reading the state of the switch, and generating the appropriate PWM signal based on the switch's position. This code is essential for the operation of the circuit, as it dictates how the microcontroller responds to user input and controls the servo motor accordingly. Proper implementation of this code ensures smooth and accurate positioning of the servo motor, making it suitable for various applications requiring precise control.This simple micro-control circuit controls a servo motor according to a 3-state switch. A servo motor acts as an actuator in 3 position. It has 3 wires, one for VCC, one for Ground and another one for position control. The last signal is a single pulse with variable width. The pulse width can vary between 1 and 2 mSec. An 1 mSec pulse width turns the motor axis in -45 degrees position. An 1. 5 mSec pulse width turns the motor axis in 0 degree position. A 2 mSec pulse width turns the motor axis in +45 degrees position. The following source code has been written in PICBasic:
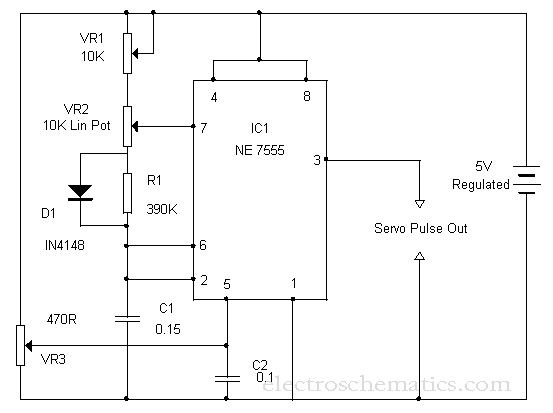
Servo Motor Controller Circuit
This is a simple basic design of a servo motor controller with a pulse generator. It utilizes the CMOS IC 7555 in astable mode to generate pulses for driving the motor.
The servo motor controller circuit employs the CMOS IC 7555...
Digital Calender Circuit
This is a digital calendar circuit that utilizes a microcontroller to display the date, day, and month on an LED display. The entire system is managed by an 8-bit microcontroller, which operates based on a program embedded in its ROM....
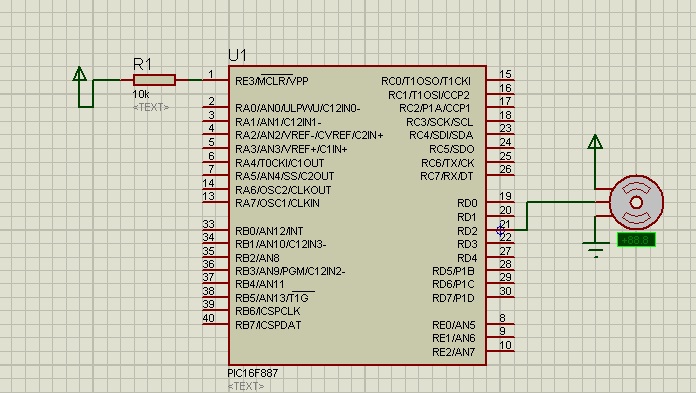
servo motor control with microcontroller
The shaft can be positioned at specific angular positions by sending a coded signal to the servo. As long as the coded signal is present on the input line, the servo will maintain the angular position of the shaft. Changes...
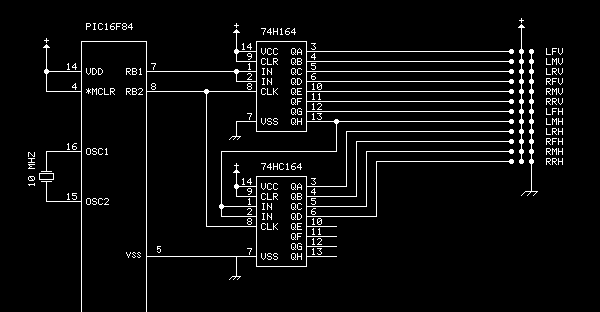
Spider robot with PIC16F84
To get enough outputs from the PIC chip, a pair of 74HC164 shift registers was used. These need only two lines from the PIC (data & shift) to produce the twelve signal pulses for the servos. A single bit is...
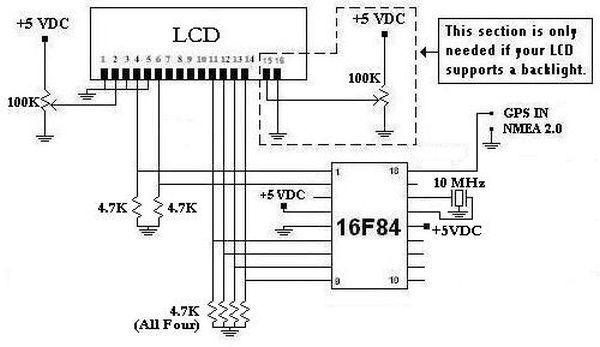
my gps lcd display project using pic16f84
This project was initiated in late 2003 with the aim of learning PIC programming. The goal was to create a functional device that performed a specific task.
The project involves the design and implementation of a microcontroller-based system utilizing a PIC...
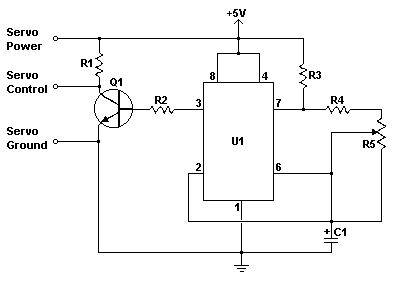
servo circuit
Servo motors are utilized in various applications, including robotics, puppetry, photography, and more. These compact motors can adjust their output shaft to a specified position on command and maintain that position. Most servos offer a range of motion of approximately...
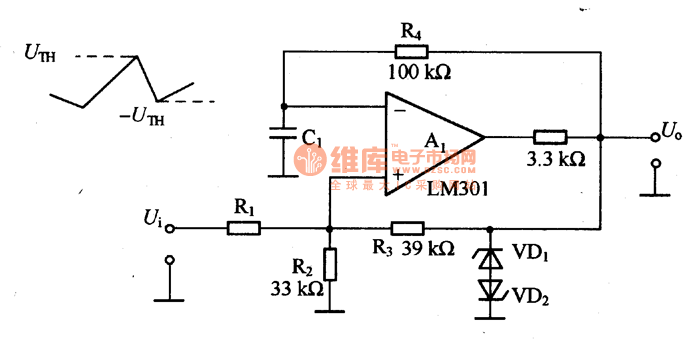
Simple pulse width modulation circuit
The simple pulse width modulation circuit is illustrated in the figure. It utilizes an operational amplifier to create a multivibrator, resulting in a symmetrical oscillation output signal with a duty cycle of 50%. By adjusting the external threshold voltage, pulse...
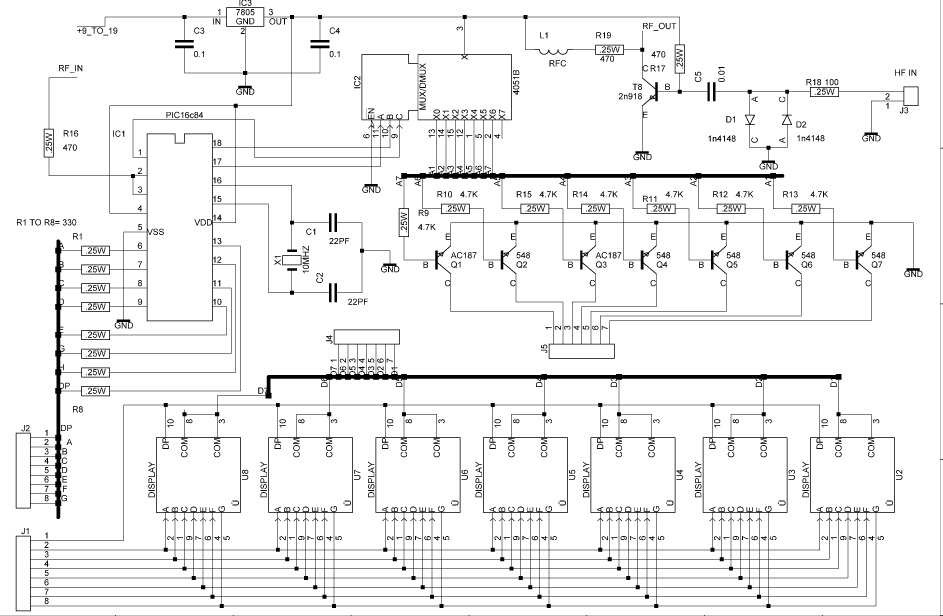
Frequency counter using PIC16f84
This is a simple frequency counter based on the microcontroller PIC16F84. Its maximum operating frequency is approximately 30 MHz, with a resolution of 10 Hz and low current consumption of 15 mA. The assembly process is straightforward. The device employs...
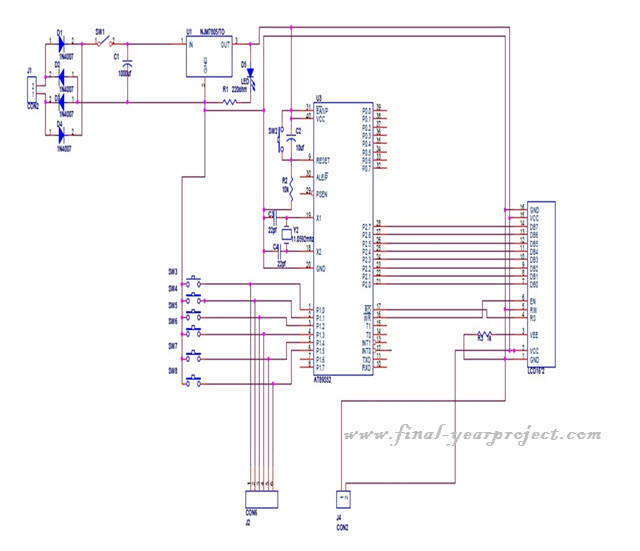
Microcontroller based College Automation System
This project is a microcontroller-based college automation system aimed at addressing the challenges faced in educational institutions. It replaces the conventional notice board with an automated device that allows users to both hear and read the information being announced through...