


PWM Motor Speed Control Circuit with Diagram for DC Motor
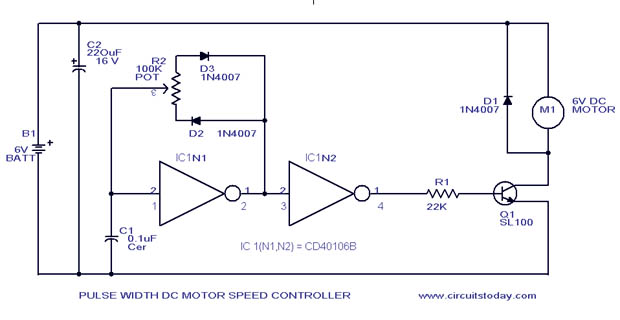
Description: A simple PWM motor speed control circuit with a diagram and schematic for low power DC motors. This easy-to-make PWM DC motor controller is created using the IC CD40106B.
The PWM (Pulse Width Modulation) motor speed control circuit utilizes the CD40106B integrated circuit, which is a Schmitt trigger inverter. This design is particularly suitable for controlling the speed of low-power DC motors by varying the duty cycle of the PWM signal delivered to the motor.
The circuit typically consists of the CD40106B, resistors, capacitors, and the DC motor. The Schmitt trigger inverter provides a stable output that can drive the MOSFET or transistor used to control the motor. The frequency of the PWM signal is determined by the values of the resistors and capacitors connected to the input of the inverter.
When the circuit is powered, the capacitor charges and discharges through the resistors, generating a square wave output. By adjusting the resistance or capacitance, the duty cycle of the PWM signal can be altered, which effectively changes the average voltage supplied to the motor. This results in variable speed control, allowing for precise adjustments to the motor's operation.
The schematic diagram typically shows the connections between the CD40106B, the power supply, the motor, and the control components. It is essential to ensure that the components are rated appropriately for the voltage and current requirements of the motor to prevent damage. Additionally, the circuit can be enhanced with features such as an on/off switch or feedback mechanisms for more advanced control.
This PWM motor controller is an efficient and straightforward solution for applications requiring speed regulation of low-power DC motors, making it suitable for hobby projects and small-scale automation systems.A simple PWM motor speed control circuit with diagram and schematic for low power dc motors. This easy to make pwm dc motor controller is made using IC CD40106B..
The PWM (Pulse Width Modulation) motor speed control circuit utilizes the CD40106B integrated circuit, which is a Schmitt trigger inverter. This design is particularly suitable for controlling the speed of low-power DC motors by varying the duty cycle of the PWM signal delivered to the motor.
The circuit typically consists of the CD40106B, resistors, capacitors, and the DC motor. The Schmitt trigger inverter provides a stable output that can drive the MOSFET or transistor used to control the motor. The frequency of the PWM signal is determined by the values of the resistors and capacitors connected to the input of the inverter.
When the circuit is powered, the capacitor charges and discharges through the resistors, generating a square wave output. By adjusting the resistance or capacitance, the duty cycle of the PWM signal can be altered, which effectively changes the average voltage supplied to the motor. This results in variable speed control, allowing for precise adjustments to the motor's operation.
The schematic diagram typically shows the connections between the CD40106B, the power supply, the motor, and the control components. It is essential to ensure that the components are rated appropriately for the voltage and current requirements of the motor to prevent damage. Additionally, the circuit can be enhanced with features such as an on/off switch or feedback mechanisms for more advanced control.
This PWM motor controller is an efficient and straightforward solution for applications requiring speed regulation of low-power DC motors, making it suitable for hobby projects and small-scale automation systems.A simple PWM motor speed control circuit with diagram and schematic for low power dc motors. This easy to make pwm dc motor controller is made using IC CD40106B..
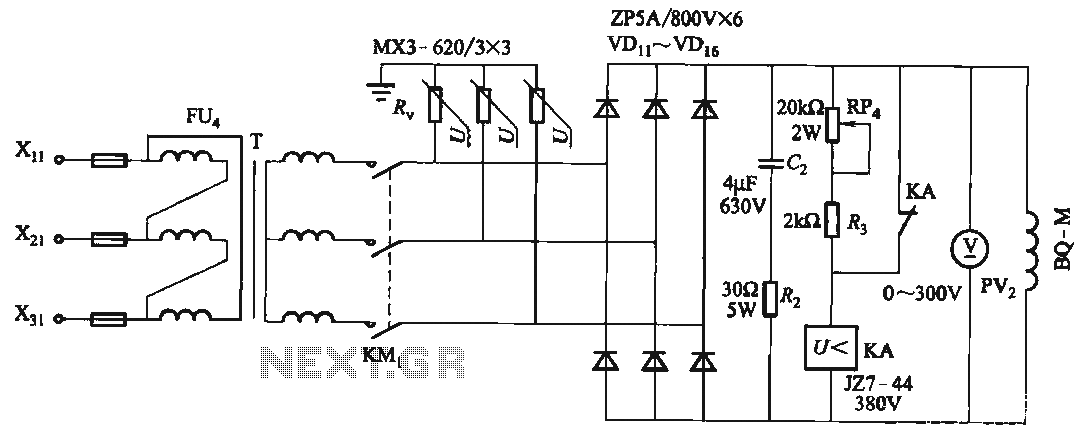
DC motor excitation current circuit
FIG T is the excitation transformer, R is a varistor, and there are rectifier diodes to protect against breakdowns from VDii to VD16; Rz and C2 provide resistive-capacitive protection. The circuit is designed to absorb voltage from the magnetic field...
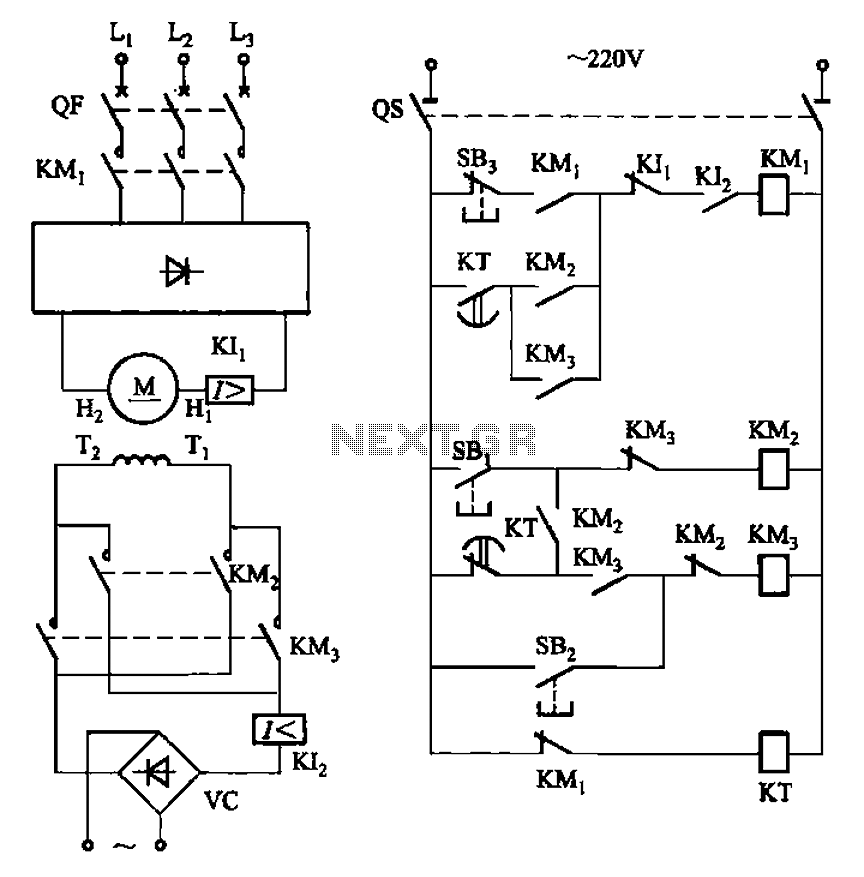
Separately excited DC motor reversing circuit
The circuit depicted in Figure 3-193 illustrates a separately excited DC motor. The brake circuit is not activated; therefore, positive reversals occur alternately using a delay action relay, ensuring that the motor reverses direction after coming to a stop.
The schematic...
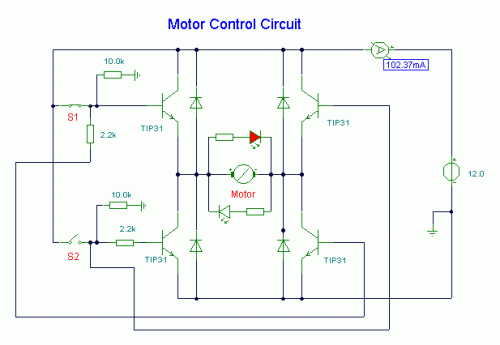
DC Motor Control Circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes can be either red or green and are used solely for indicating direction. The TIP31 transistors may need to be adjusted based on the motor specifications. It is important...
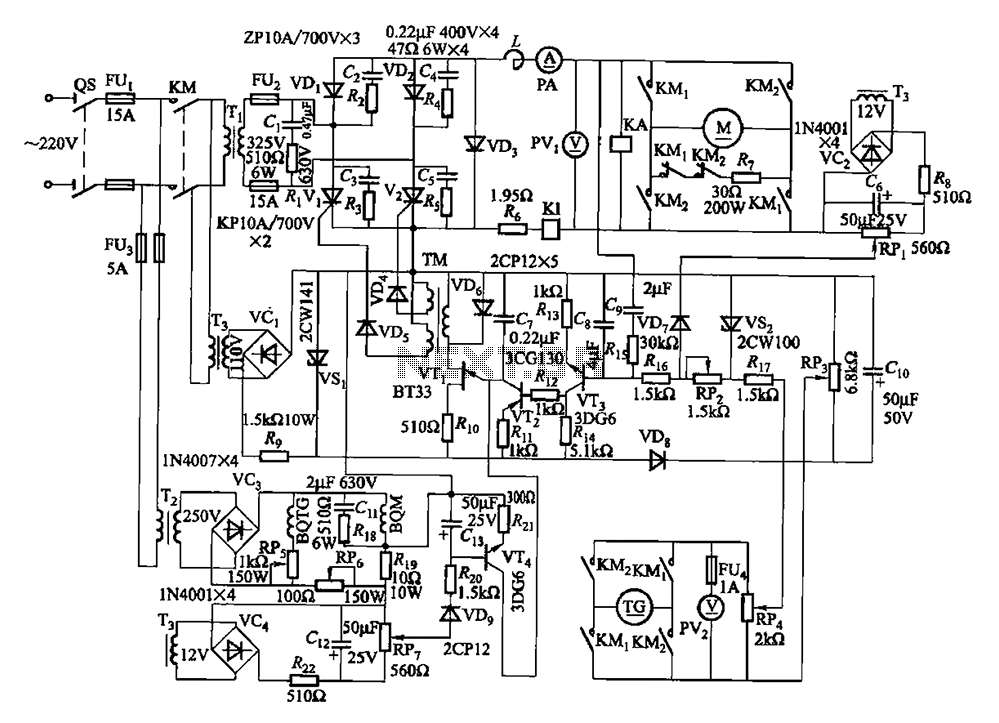
Quadruple semi-continuous casting machine speed control circuit
The circuit encompasses a main circuit, a trigger circuit, speed negative feedback, negative feedback differential voltage, a current cut-off circuit, loss of field protection, and other components. Given that the motor power is small (1.1 kW), a single-phase circuit is...
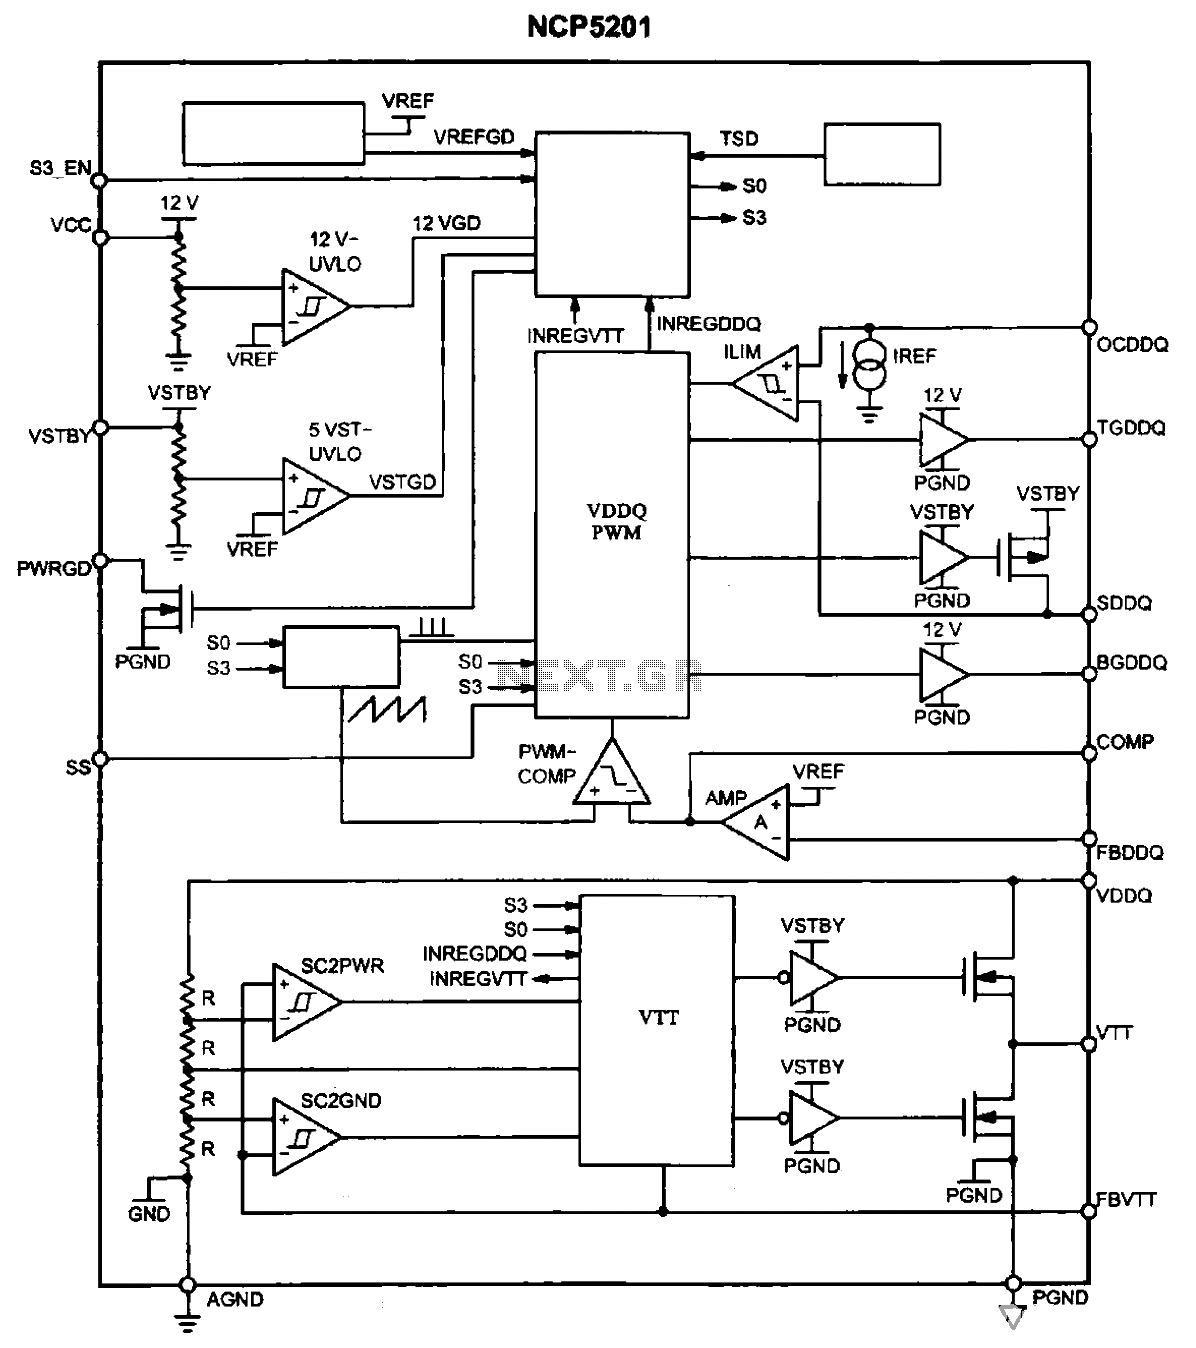
Internal functional block diagram of NCP5201
The NCP5201 chip contains two sets of PWM signal generating circuits, each with a dedicated set of output pins. These circuits produce two opposite phase PWM signals, which are applied to the gates of three field effect transistors. This arrangement...
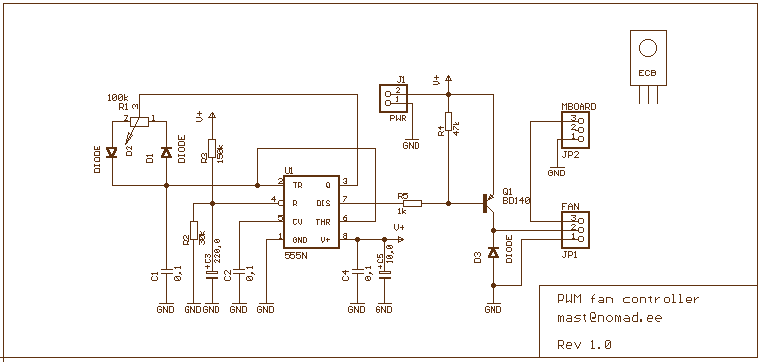
Simple PWM controller
This 555 timer based PWM controller features almost 0..100% pulse width regulation using R1, while keeping the oscillator frequency relatively stable. The frequency is dependent on values of R1 and C1, values shown will give a frequency range from about...
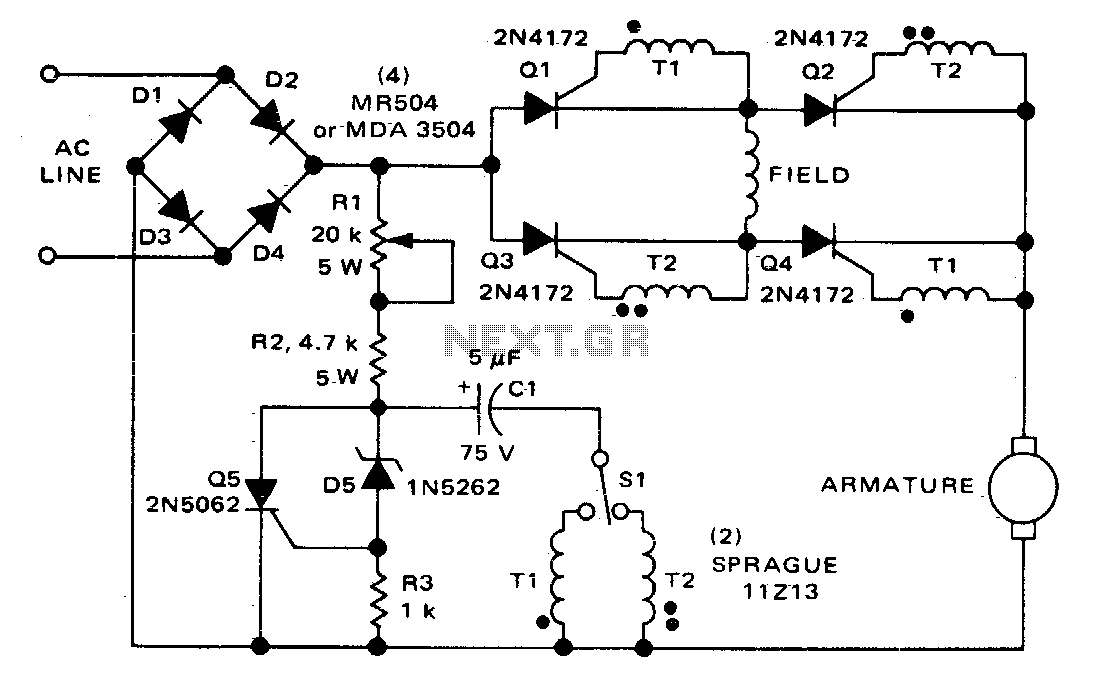
Direction and speed control for series-wound motors
The circuit can control the speed and direction of rotation of a series-wound DC motor. Silicon controlled rectifiers Q1-Q4 are arranged in a bridge configuration and are triggered in diagonal pairs. The selection of which pair to activate is managed...
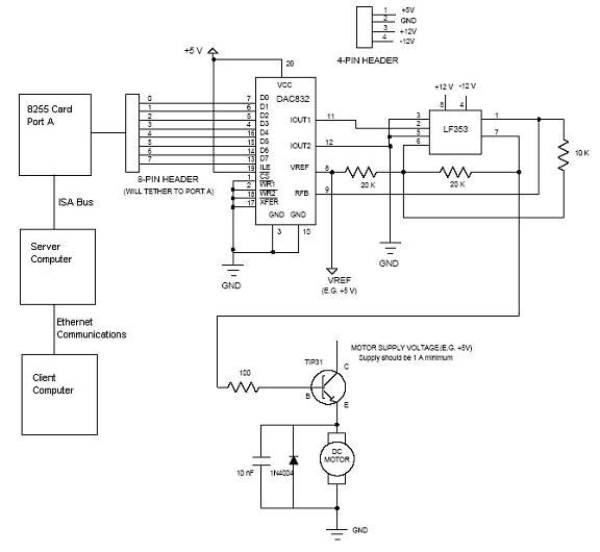
Open Loop Speed Control of a DC Motor via 8255 Controller
Open loop speed control of a DC motor is implemented using the 8255 Digital I/O Controller chip in conjunction with a TCP/IP server-client application programmed in Visual Basic. The DAC0832 chip serves as the Digital to Analog Converter. This project...
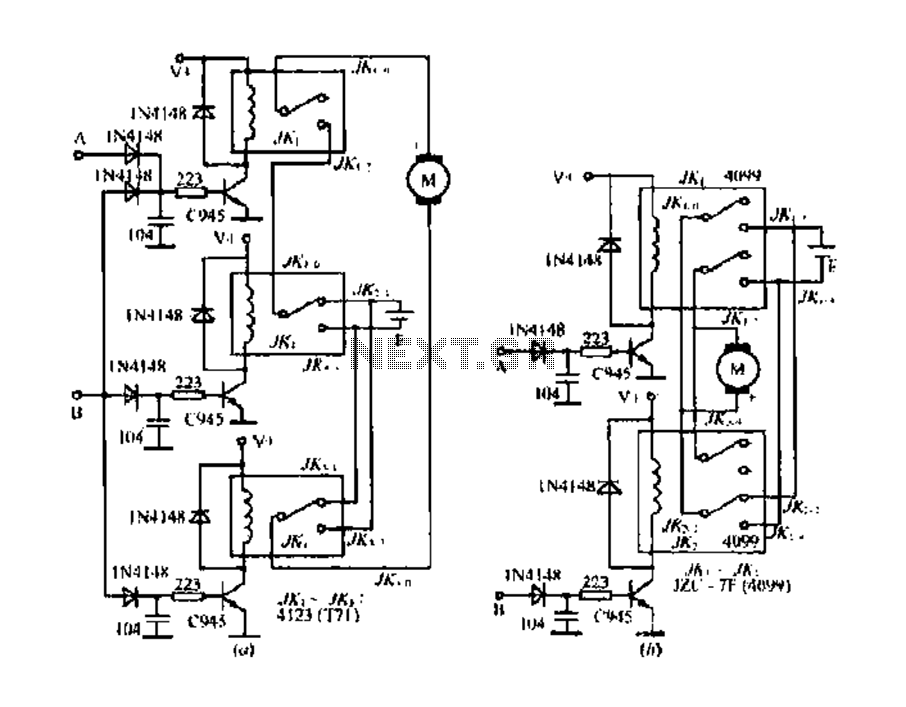
Two models of DC motor reversing control circuit
The DC motor E inversion control circuit utilizes a loop configuration with various relay contacts. It employs a single set of normally open/normally closed relay contacts. When both inputs A and B are low, relay KI is activated. In this...