


Polarity Reverser
#polarity reverser
#motor
#bridge rectifier
#voltage drop
#current
#heat dissipation
#supply voltage
#electronics
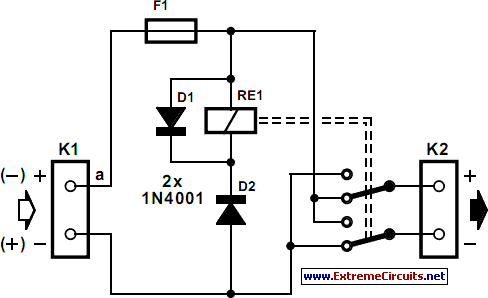
Description: In certain systems, it is essential for the supply voltage of a motor to maintain the correct polarity. While a bridge rectifier can achieve this, it may not be suitable for high current applications due to significant voltage drops across the diodes, leading to excessive heat dissipation, or because the peak current may surpass the diode's current rating. Fortunately, an effective and cost-efficient mechanical rectifier can be constructed using a relay. In the circuit diagram, the supply voltage is connected to relay K1, while the motor requiring the correct polarity is connected to relay K2. If fuse F1 is intact, a positive voltage at terminal 'a' of K1 will be applied to the positive terminal of K2. Diode D2 prevents K1 from being energized. When the polarity at K1 is reversed, the relay is activated through D2. The relay contacts then switch the connections to the terminals of K2, ensuring that the supply voltage polarity to the load remains consistent. Diode D1 serves as a freewheeling diode for the relay coil. The choice of relay depends on the required operating voltage and the current through its contacts. Other components in the circuit are not critical. It is important to note that this circuit is unsuitable for small battery applications, as the relay coil consumes a relatively large current.
In this circuit design, the relay-based polarity correction mechanism provides a robust solution for applications requiring precise voltage polarity control. The implementation of relay K1 acts as a switch that directs the supply voltage to the motor while ensuring that the correct polarity is maintained regardless of changes in the input voltage. The use of fuse F1 adds a layer of protection by preventing damage to the circuit in case of an overload or short circuit condition.
Diodes D1 and D2 play crucial roles in the operation of the circuit. D1, as a freewheeling diode, protects the relay coil from voltage spikes that occur when the relay is de-energized, thus preventing potential damage to the relay and other components. D2, on the other hand, ensures that the relay is not inadvertently energized when the voltage is in the correct polarity, thereby maintaining the integrity of the circuit.
The relay's specifications, including its operating voltage and current rating, must be carefully selected based on the application requirements. This ensures that the relay can handle the load without overheating or failing. The circuit's design allows for flexibility in component selection, as long as the relay meets the necessary electrical characteristics.
Overall, this relay-based approach offers a simple yet effective means of maintaining the correct polarity in motor supply applications, particularly in scenarios where traditional diode rectification may not be viable due to high current demands. The circuit's design considerations make it suitable for a variety of industrial and automotive applications where reliable operation is paramount.There are systems in which it is imperative that the supply voltage of, say, a motor, always has the correct polarity. It is, of course, possible to use a bridge rectifier for this, but if large currents are involved, this is not always possible.
This may be because large voltage drops across diodes result in appreciable heat dissipation, or that the peak current exceeds the current rating of a diode. Fortunately, a good, inexpensive mechanical rectifier may be constructed with the aid of a relay. In the diagram, the supply voltage is applied to K1, while the motor that needs a supply with correct polarity is linked to K2. Provided fuse F1 is intact, a positive potential at terminal a of K1 will be applied to the positive terminal of K2.
Diode D2 prevents the relay being energized. When the polarity at K1 is reversed, the relay will be energized via D2. The relay contacts then interchange the connections to the terminals of K2 to ensure that the previous polarity of the supply to the load is retained. Diode D1 is a freewheeling diode for the relay coil. The type of relay to be used depends on the requisite operating voltage and the current through its contacts.
Other parts of the circuit are not critical. It stands to reason that the circuit is not suitable for use with a small battery, since the relay coil draws a fairly large current.
In this circuit design, the relay-based polarity correction mechanism provides a robust solution for applications requiring precise voltage polarity control. The implementation of relay K1 acts as a switch that directs the supply voltage to the motor while ensuring that the correct polarity is maintained regardless of changes in the input voltage. The use of fuse F1 adds a layer of protection by preventing damage to the circuit in case of an overload or short circuit condition.
Diodes D1 and D2 play crucial roles in the operation of the circuit. D1, as a freewheeling diode, protects the relay coil from voltage spikes that occur when the relay is de-energized, thus preventing potential damage to the relay and other components. D2, on the other hand, ensures that the relay is not inadvertently energized when the voltage is in the correct polarity, thereby maintaining the integrity of the circuit.
The relay's specifications, including its operating voltage and current rating, must be carefully selected based on the application requirements. This ensures that the relay can handle the load without overheating or failing. The circuit's design allows for flexibility in component selection, as long as the relay meets the necessary electrical characteristics.
Overall, this relay-based approach offers a simple yet effective means of maintaining the correct polarity in motor supply applications, particularly in scenarios where traditional diode rectification may not be viable due to high current demands. The circuit's design considerations make it suitable for a variety of industrial and automotive applications where reliable operation is paramount.There are systems in which it is imperative that the supply voltage of, say, a motor, always has the correct polarity. It is, of course, possible to use a bridge rectifier for this, but if large currents are involved, this is not always possible.
This may be because large voltage drops across diodes result in appreciable heat dissipation, or that the peak current exceeds the current rating of a diode. Fortunately, a good, inexpensive mechanical rectifier may be constructed with the aid of a relay. In the diagram, the supply voltage is applied to K1, while the motor that needs a supply with correct polarity is linked to K2. Provided fuse F1 is intact, a positive potential at terminal a of K1 will be applied to the positive terminal of K2.
Diode D2 prevents the relay being energized. When the polarity at K1 is reversed, the relay will be energized via D2. The relay contacts then interchange the connections to the terminals of K2 to ensure that the previous polarity of the supply to the load is retained. Diode D1 is a freewheeling diode for the relay coil. The type of relay to be used depends on the requisite operating voltage and the current through its contacts.
Other parts of the circuit are not critical. It stands to reason that the circuit is not suitable for use with a small battery, since the relay coil draws a fairly large current.
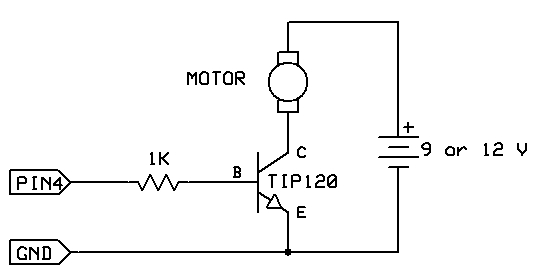
motor switch led circuit
The strategy involves assembling the circuit in stages, testing each component as it is integrated. Once all connections are established and can be controlled or read correctly by the computer, the main program can be developed with assurance that all...
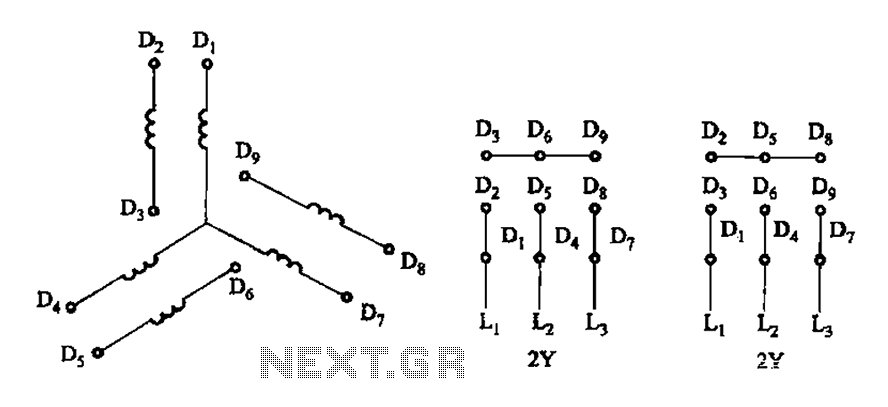
Two-speed motor stator winding 2Y-2Y connection
As illustrated in Figure 3-105, this diagram depicts the lead wiring configuration for a two-speed motor stator with a 2Y/2Y connection.
The two-speed motor stator wiring diagram is essential for understanding the configuration and operation of the motor. In this setup,...
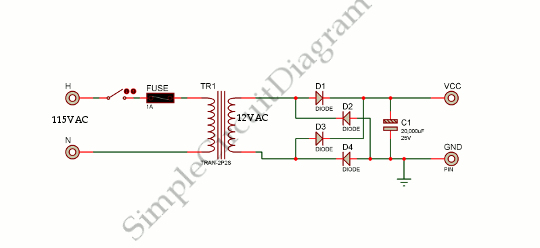
Low Voltage Power Supply
This is a power supply circuit that produces a voltage range of 12 to 24 V. It is straightforward, requiring only a bridge rectifier, a filter capacitor, and a transformer, without the need for a regulator. A bridge rectifier utilizes...
Gray Tube Replication 85
The information regarding operating the motor without the tubes is new to the individual. There is a desire to learn more about this subject.
The operation of a motor without the use of tubes can be a significant topic in the...
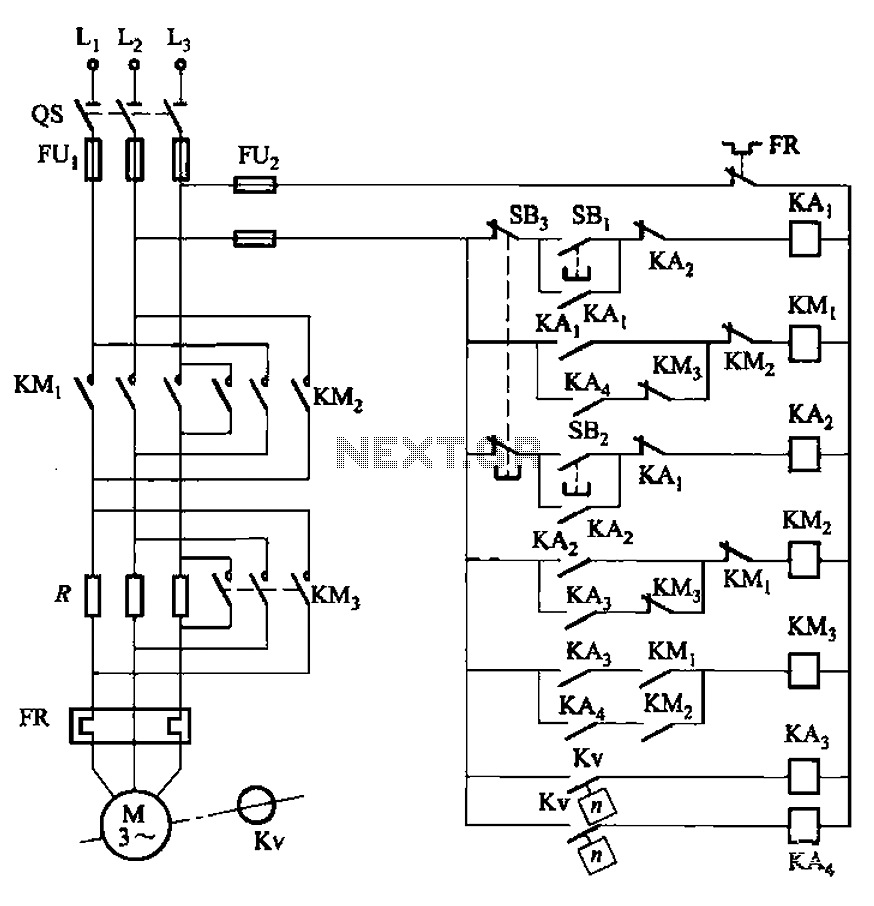
Three reversing operation of the reverse brake circuit
The circuit illustrated in Figure 3-130 differs from the circuit in Figure 3-129 in that when the stop button SB3 is pressed, the electric motor initiates braking. Furthermore, during both the startup and braking phases, the motor power lines are...
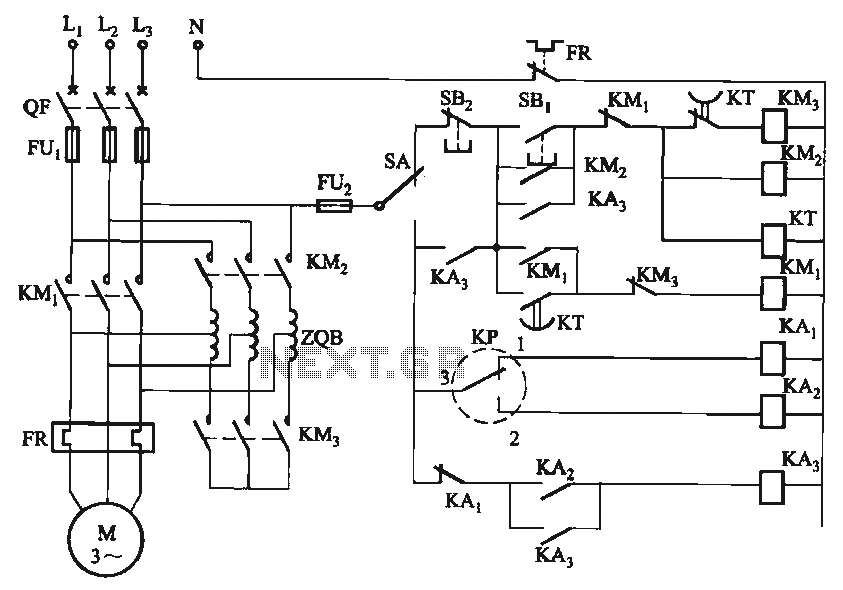
Electrical contacts Level IV controlled circuit
The circuit utilizes a motor auto-voltage transformer for starting.
The motor auto-voltage transformer start circuit is designed to provide a controlled method for initiating the operation of an electric motor. This type of circuit is particularly beneficial in applications where a...
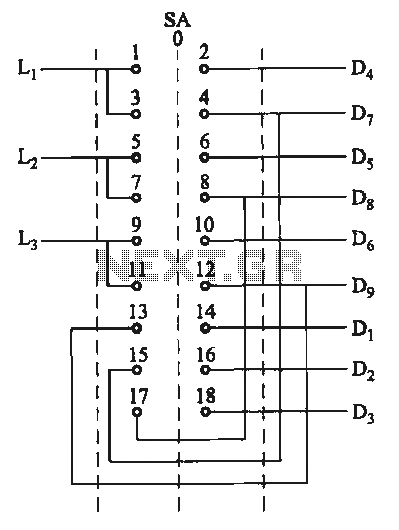
Switching two-speed motor control circuit
The motor switch control circuit depicted in the figure provides two speed settings for counter-steering, allowing for operation at two speeds in opposite directions.
The motor switch control circuit is designed to facilitate the operation of a motor at two distinct...
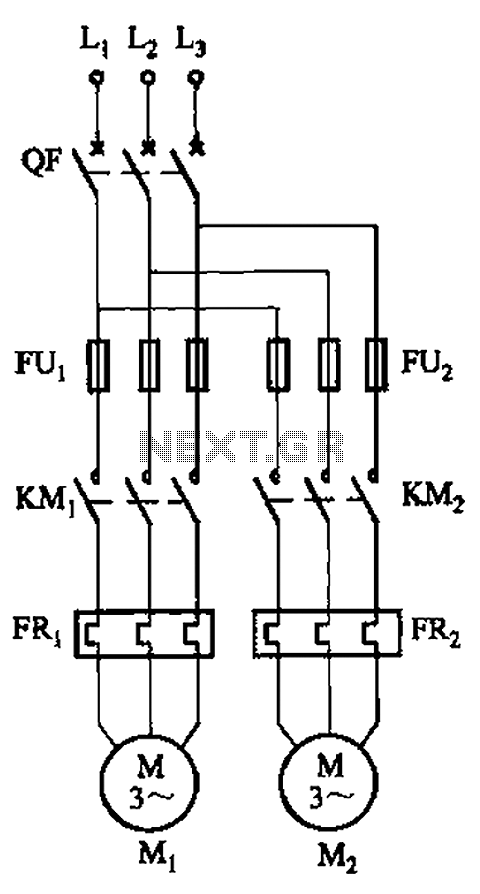
The use of a motor control switch automatic circuit a mutual investment
The circuit illustrated in Figure 3-64 operates with switch SA1 in the work position and switch SA2 in the standby position, allowing motor Mi to run while motor Mz remains on standby. In the event of downtime for motor Mi,...
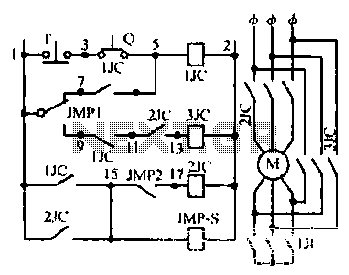
Motor Y starting circuit shape
Motor windings are set to connect in a Y configuration while the load is active. The system includes an electric suction mechanism, and the motor is designed to operate under specific conditions. It is rated for 600 revolutions per minute...