


Motorized Camera rotator
#EPROM
#H-bridge
#motor driver
#limit sensor
#clockwise rotation
#counter clockwise rotation
#logic table
#2716 EPROM
#camera rotator
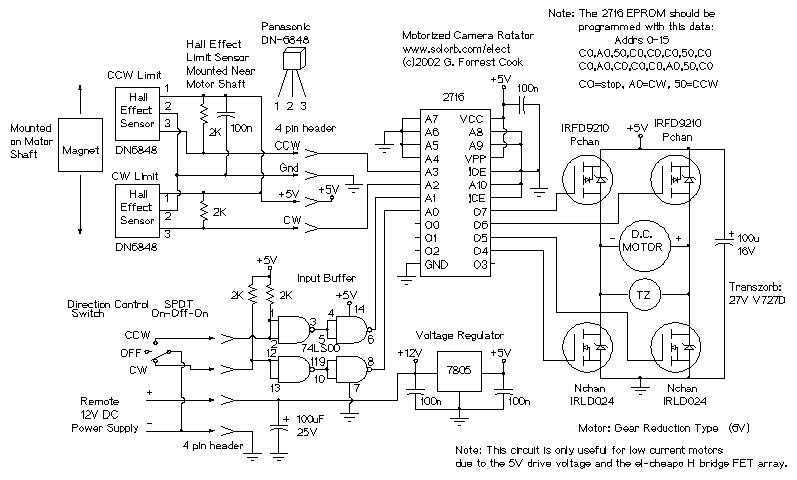
Description: The camera rotator circuit uses a 2716 EPROM to store a table of logic values that control the motor driver (H-bridge) circuit. The EPROM data is shown in the schematic. By using the EPROM, a large number of discrete gates are eliminated. The logic table is designed to allow the motor to turn clockwise until the clockwise limit sensor is activated. The same operation happens with counter clockwise rotation and the counter clockwise limit sensor. More: Inputs to the EPROM come from the limit sensors and the two control switch directions. Outputs go to the four H-bridge transistor gates. The control switch signals are buffered through the 7400 quad NAND gate, this allows for a long control wire.
The camera rotator circuit is designed to provide precise control over the rotational movement of a camera using a motor driver configuration. At the heart of the circuit is a 2716 EPROM, which serves as a programmable read-only memory device. This EPROM contains a logic table that dictates the operational states of the motor driver, specifically an H-bridge configuration that allows for bidirectional motor control.
The circuit operates by receiving inputs from limit sensors that detect the position of the motor. These sensors are crucial for preventing mechanical overrun and ensuring that the motor stops when it reaches its designated limits. The logic table stored in the EPROM is programmed to enable the motor to rotate in a clockwise direction until the clockwise limit sensor is triggered. A similar arrangement is in place for counterclockwise rotation, where the motor will continue to operate until the counterclockwise limit sensor is activated.
Control signals for the motor's direction are provided through two control switches, which allow the user to dictate the desired rotation. These control signals are then buffered using a 7400 quad NAND gate, a component that enhances signal integrity and allows for longer cable runs without degradation of the control signals. This buffering is particularly important in applications where the control switches may be located at a distance from the motor driver circuit.
The outputs from the EPROM are directed to the gates of four transistors in the H-bridge configuration, which are responsible for driving the motor. This arrangement allows for efficient control of the motor's direction and speed, while the use of the EPROM significantly reduces the number of discrete logic gates that would otherwise be required in a more traditional design.
Overall, the camera rotator circuit exemplifies an efficient approach to motor control, leveraging programmable logic to simplify the design and enhance functionality.The camera rotator circuit uses a 2716 EPROM to store a table of logic values that control the motor driver (H-bridge) circuit. The EPROM data is shown in the schematic. By using the EPROM, a large number of discrete gates are eliminated. The logic table is designed to allow the motor to turn clockwise until the clockwise limit sensor is activated.
The same operation happens with counter clockwise rotation and the counter clockwise limit sensor. Inputs to the EPROM come from the limit sensors and the two control switch directions. Outputs go to the four H-bridge transistor gates. The control switch signals are buffered through the 7400 quad NAND gate, this allows for a long control wire. All of t
The camera rotator circuit is designed to provide precise control over the rotational movement of a camera using a motor driver configuration. At the heart of the circuit is a 2716 EPROM, which serves as a programmable read-only memory device. This EPROM contains a logic table that dictates the operational states of the motor driver, specifically an H-bridge configuration that allows for bidirectional motor control.
The circuit operates by receiving inputs from limit sensors that detect the position of the motor. These sensors are crucial for preventing mechanical overrun and ensuring that the motor stops when it reaches its designated limits. The logic table stored in the EPROM is programmed to enable the motor to rotate in a clockwise direction until the clockwise limit sensor is triggered. A similar arrangement is in place for counterclockwise rotation, where the motor will continue to operate until the counterclockwise limit sensor is activated.
Control signals for the motor's direction are provided through two control switches, which allow the user to dictate the desired rotation. These control signals are then buffered using a 7400 quad NAND gate, a component that enhances signal integrity and allows for longer cable runs without degradation of the control signals. This buffering is particularly important in applications where the control switches may be located at a distance from the motor driver circuit.
The outputs from the EPROM are directed to the gates of four transistors in the H-bridge configuration, which are responsible for driving the motor. This arrangement allows for efficient control of the motor's direction and speed, while the use of the EPROM significantly reduces the number of discrete logic gates that would otherwise be required in a more traditional design.
Overall, the camera rotator circuit exemplifies an efficient approach to motor control, leveraging programmable logic to simplify the design and enhance functionality.The camera rotator circuit uses a 2716 EPROM to store a table of logic values that control the motor driver (H-bridge) circuit. The EPROM data is shown in the schematic. By using the EPROM, a large number of discrete gates are eliminated. The logic table is designed to allow the motor to turn clockwise until the clockwise limit sensor is activated.
The same operation happens with counter clockwise rotation and the counter clockwise limit sensor. Inputs to the EPROM come from the limit sensors and the two control switch directions. Outputs go to the four H-bridge transistor gates. The control switch signals are buffered through the 7400 quad NAND gate, this allows for a long control wire. All of t
Simple H-bridges Tutorial
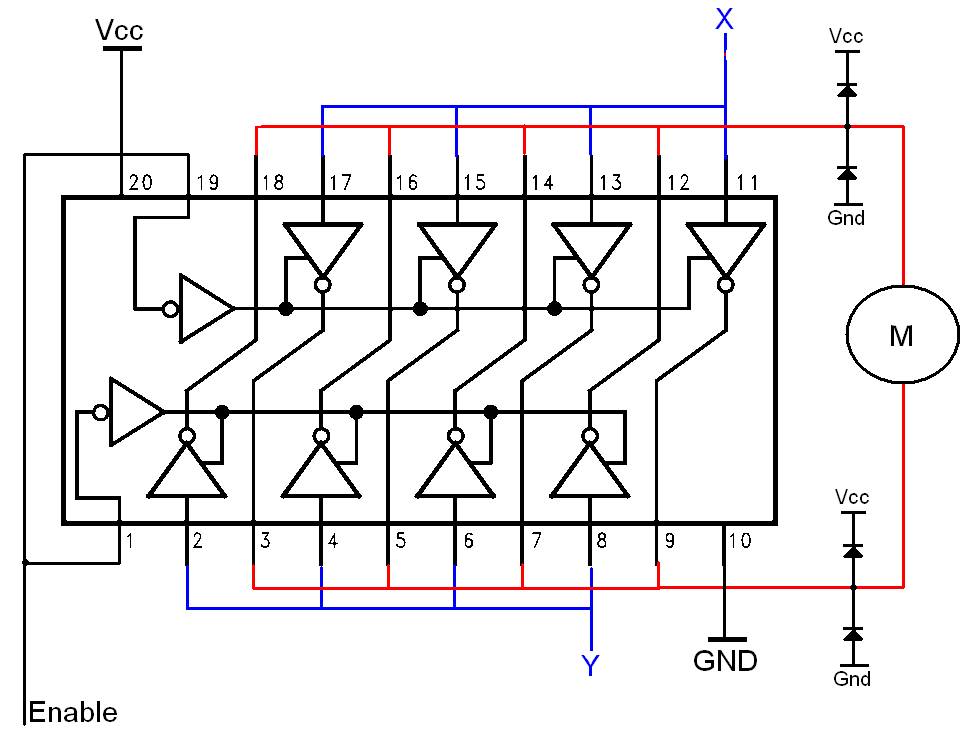
The H-bridge is a well-known and widely used circuit configuration for driving brushed DC motors. It enables straightforward control of motor direction, allowing for both forward and reverse operation.
The H-bridge circuit consists of four switches, typically implemented using transistors or...
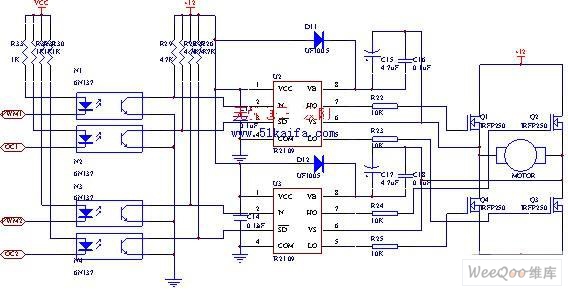
Using IRFP250 power tube H-bridge motor drive circuit
The drive circuit for the electromotor comprises a FET bridge circuit, a FET base drive circuit, a current sensor for the motor drive circuit, and a relay. The FET bridge circuit primarily consists of four high-power MOSFETs, which must possess...
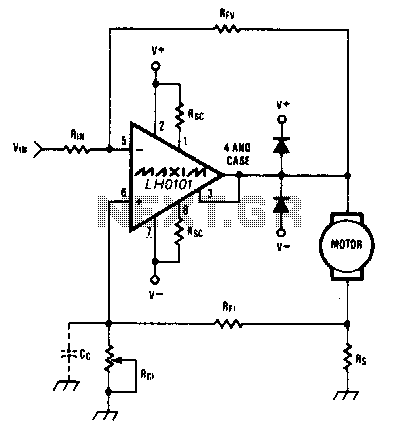
Constant-speed-motor-driver
When the torque load on the motor increases, its current also rises. This increase in current is detected across Rs, and positive feedback is applied to the noninverting terminal of the LH0101, which in turn raises the motor voltage to...
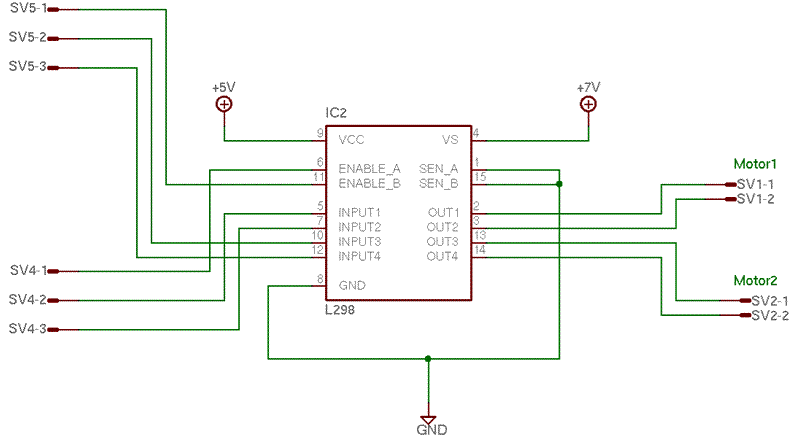
motor h bridge
The basic stamp cannot directly power motors due to its maximum current output of only 20mA, while motors typically require around an amp or more, with even higher current spikes. To address this limitation, a circuit will be implemented where...
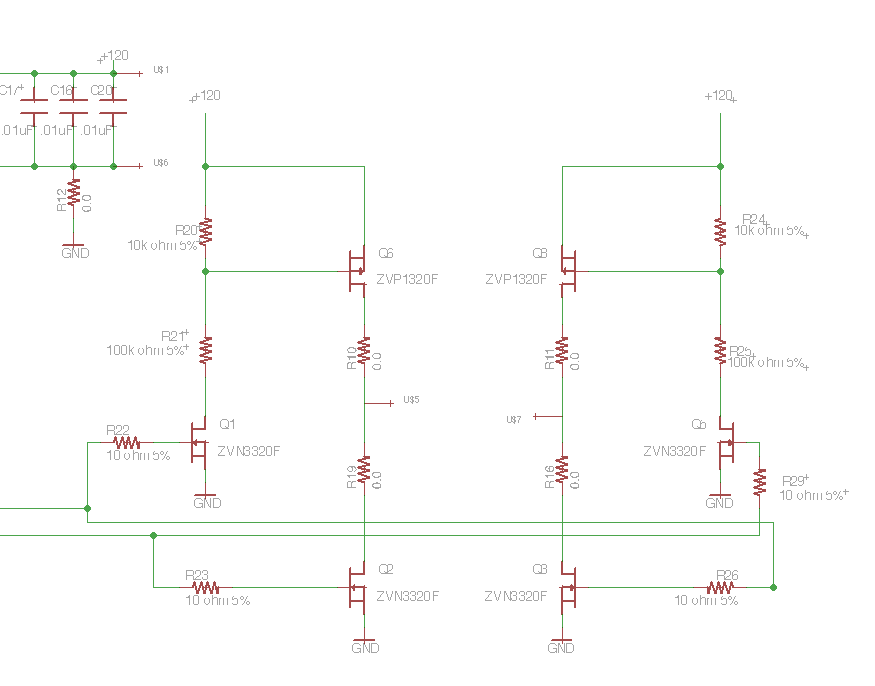
Driving a Capacitive Load with an H-bridge
Following the publication of a previous post, some unusual issues were encountered, which required several days to clarify. The main focus was on building a simple Class D amplifier designed to provide an EL panel with a +/- 120V square...
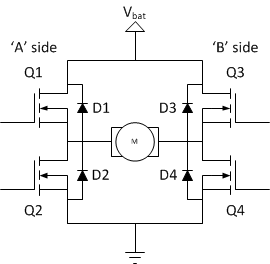
h-bridge basics
Learn how to build H-bridges from various online and offline resources. These circuits are not overly complex. Some resources are reliable, while others may not be as helpful. Upon starting to work with H-bridges, it became evident that many personal...
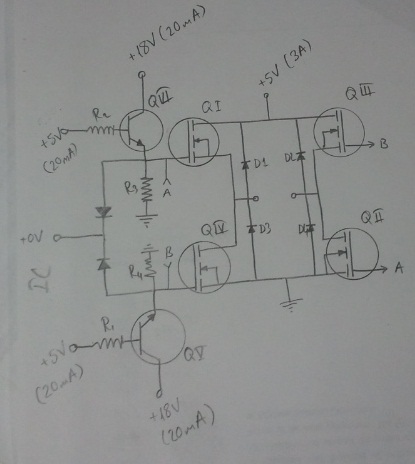
H-bridge driving problemMOSFET frequently damage
An H-bridge is being utilized with IRF740 MOSFETs to convert 315V DC to 230V AC. However, the upper MOSFETs are frequently damaged within a few seconds, and the cause of this issue has not been identified.
The described circuit employs an...
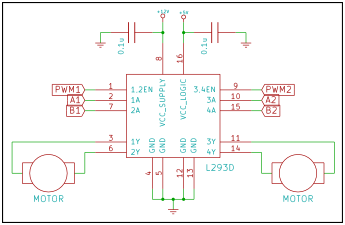
H-Bridge Tutorial
The H-bridge is a circuit utilized in the electronic control of high-current devices, particularly in applications where the device's polarity needs to be reversed, such as in DC motors. The name derives from the circuit's resemblance to the letter "H."...
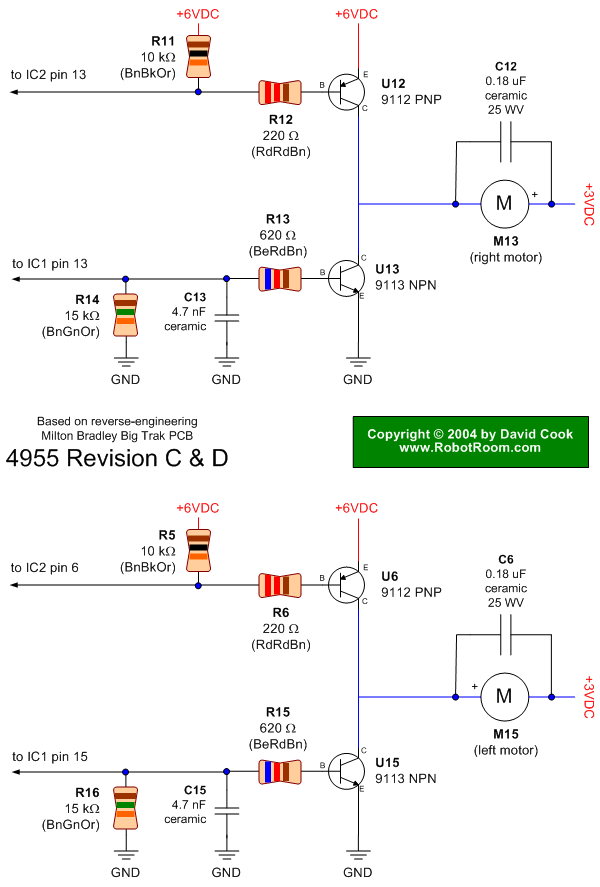
Big Trak Motor Driver Schematic
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...