


Motor speed controller using LM324
#LM324
#motor speed controller
#closed loop control
#tachogenerator
#permanent magnet motor
#battery motor
#speed adjustment
#volts per rpm
Description: Most battery motor speed controllers are under manual control and the operator automatically adjusts speed to match demand. Under these conditions closed loop motor speed control is an unnecessary expense. However, when it is required, a tachogenerator can easily be added. True tachogenerators are usually expensive - which puts off most potential users. The expense is because they are very accurately manufactured and calibrated. They are also low volume items. However for most uses a small permanent magnet motor is perfectly adequate. It won't come with an accurate 'volts per rpm' calibration and it may (just possibly) drift over several years. For most purposes this simply does not matter! With any tacho feedback system, the loop gain (controller, motor, tacho, tacho amplifier) must not be more than unity or instability results.
To put that more simply: the feedback system must alter the output voltage to the motor so that the motor voltage is raised to exactly match the drop in the motor armature caused by the current flowing, so the mechanical speed remains constant.
If the loop over compensates, then the motor will go too fast if loaded and will 'hunt' - the speed will be unstable and will bounce about. If the compensation is too little - performance will be less than optimum.
However - there are a lot of variables, including battery voltage and motor temperature. An ideal system would measure everything and compensate for it (and be very expensive!). In practice, adjustment is quite easy: you will simply include a pot in series with the motor used as the tacho generator and will adjust this until the motor starts to hunt (show speed variation), then back it off a bit until it is slightly below optimum. The board is built in two versions (Pro-120 and VTX or NCC) but the only difference is the connector - 9 way for Pro (black numbers) and 6 way for VTX.
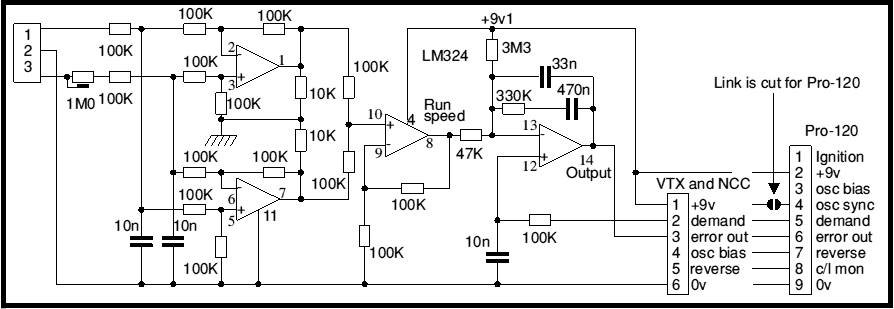
The circuit uses a quad op-amp type LM324. The first two stages are straightforward difference amplifiers that compare the two wires from the tacho generator. One works for positive voltages and the other for negative.
Now the circuit is used from a single supply. Therefore the op-amp outputs cannot swing negative. Therefore one amplifier gives a positive output for one tacho generator direction and the other for the reverse direction. The third section of the op-amp sums the outputs, the result is a rectified version of the input.
There is a snag in using an op-amp thus. On the inputs which should swing the output negative, the op-amp is in fact cut-off and the output is not conducting. The inputs are outside their working range, so they cannot clamp the control signal. There is then a straight feed-forward path via the 'feedback' resistor to the inoperative output.
That mechanism explains the 10K load resistors from the outputs of the first two stages of the op-amp to earth. These, in conjunction with the three 100K resistors in the feed-forward path, form an attenuator so that the error from feed-forward is reduced to around 3%. It may interest browsers to know that the circuit was first used with an LM3900 (which is a Norton op-amp) where the inputs can never rise above one transistor Vbe above 0V. With this, the feed-forward effect is not noticeable and the clamping resistors are not required. The LM3900 circuit which you will note, does not show an output integrator.
The fourth stage compares the rectified tacho generator voltage with the demand speed, integrates the difference, and gives an output to drive the PWM modulator.
The feedback system is critical in maintaining stable motor speed under varying load conditions. The loop gain must be carefully managed to avoid instability, which can result in oscillations or hunting behavior. The operational amplifier configuration allows for differentiation between the positive and negative voltage outputs from the tacho generator, enabling effective feedback control.
In practical applications, a potentiometer is often used to fine-tune the system, allowing for adjustments based on real-time operational conditions. The integration stage in the circuit serves to filter out any DC offset from the error signal, ensuring that the PWM modulator receives a clean control signal for precise motor speed regulation.
The overall design emphasizes simplicity and cost-effectiveness, utilizing readily available components while still achieving the desired closed-loop control performance. The use of the LM324 op-amp in this application highlights the adaptability of common ICs in creating robust motor control solutions.Most battery motor speed controllers are under manual control and the operator automatically adjusts speed to match demand. Under these conditions closed loop motor speed control is an unnecessary expense. However, when it is required, a tachogenerator can easily be added. True tachogenerators are usually expensive - which puts off most potential users. The expense is because they are very accurately manufactured and calibrated. They are also low volume items. However for most uses a small permanent magnet motor is perfectly adequate. It won't come with an accurate 'volts per rpm' calibration and it may (just possibly) drift over several years.
For most purposes this simply does not matter! With any tacho feedback system, the loop gain (controller, motor, tacho, tacho amplifier) must not be more than unity or instability results. To put that more simply: the feedback system must alter the output voltage to the motor so that the motor voltage is raised to exactly match the drop in the motor armature caused by the current flowing, so the mechanical speed remains constant.
If the loop over compensates, then the motor will go too fast if loaded and will 'hunt' - the speed will be unstable and will bounce about. If the compensation is too little - perfornance will be less than optimum. However - there are a lot of variables, including battery voltage and motor temperature. An ideal system would measure everything and compensate for it (and be very expensive!). In practise, adjustment is quite easy: you will simply include a pot in series with the motor used as the tacho generator and will adjust this until the motor starts to hunt (show speed variation), then back it of a bit until it is slightly below optimum.
The board is built in two versions (Pro-120 and VTX or NCC) but the only difference is the connector - 9 way for Pro (black numbers) and 6 way for VTX. The circuit uses a quad op-amp type LM324. The first two stages are are straight forward difference amplifiers that compare the two wires from the tacho generator.
One works for positive voltages and the other for negative. Now the circuit is used from a single supply. Therefore the op-amp outputs cannot swing negative. Therefore one amplifier gives a positive output for one tacho generator direction and the other for the reverse direction. The third section of the op-amp sums the outputs, the result is a rectified version of the input. There is a snag in using an op-amp thus. On the inputs which should swing the output negative, the op-amp is in fact cut-off and the output is not conducting.
The inputs are outside their working range, so they cannot clamp the control signal. There is then a straight feed-forward path via the 'feedback' resistor to the inoperative output. That mechanism explains the 10K load resistors from the outputs of the first two stages of the op-amp to earth. These, in conjunction with the 3 100K resistors in the feed-forward path, form an attenuator so that the error from feed-forward is reduced to around 3%.
It may interest browsers to know that the circuit was first used with an LM3900 (which is a Norton op-amp) where the inputs can never rise above one transistor Vbe above 0v. With this, the feed-forward effect is not noticeable and the clamping resistors are not required. The LM3900 circuit which you will note, does not show an output integrator. The fourth stage compares the rectified tacho generator voltage with the demand speed, integrates the difference and gives an output to drive the PWM modulator.
I don't intend to go into the mathematics but, if you don't get things correct a tacho feedback circuit can go dreadfully wrong. Motors are mechanical things and take time to react. If the control signal reacts faster than the motor then it will over-react and an oscillation loop will result.
As well as being our TFB, part of this (the 3 LH sections of the quad op-amp) is actually the circuit that we use in the 4QD series controllers to provide armature voltage feedback. It is a precision rectifier circuit with error amplifier and it can either detect the armature voltage or the voltage from a tacho generator to provide closed loop control.
The output stage is an integrator to remove the d.c. component of the error signal.
To put that more simply: the feedback system must alter the output voltage to the motor so that the motor voltage is raised to exactly match the drop in the motor armature caused by the current flowing, so the mechanical speed remains constant.
If the loop over compensates, then the motor will go too fast if loaded and will 'hunt' - the speed will be unstable and will bounce about. If the compensation is too little - performance will be less than optimum.
However - there are a lot of variables, including battery voltage and motor temperature. An ideal system would measure everything and compensate for it (and be very expensive!). In practice, adjustment is quite easy: you will simply include a pot in series with the motor used as the tacho generator and will adjust this until the motor starts to hunt (show speed variation), then back it off a bit until it is slightly below optimum. The board is built in two versions (Pro-120 and VTX or NCC) but the only difference is the connector - 9 way for Pro (black numbers) and 6 way for VTX.
The circuit uses a quad op-amp type LM324. The first two stages are straightforward difference amplifiers that compare the two wires from the tacho generator. One works for positive voltages and the other for negative.
Now the circuit is used from a single supply. Therefore the op-amp outputs cannot swing negative. Therefore one amplifier gives a positive output for one tacho generator direction and the other for the reverse direction. The third section of the op-amp sums the outputs, the result is a rectified version of the input.
There is a snag in using an op-amp thus. On the inputs which should swing the output negative, the op-amp is in fact cut-off and the output is not conducting. The inputs are outside their working range, so they cannot clamp the control signal. There is then a straight feed-forward path via the 'feedback' resistor to the inoperative output.
That mechanism explains the 10K load resistors from the outputs of the first two stages of the op-amp to earth. These, in conjunction with the three 100K resistors in the feed-forward path, form an attenuator so that the error from feed-forward is reduced to around 3%. It may interest browsers to know that the circuit was first used with an LM3900 (which is a Norton op-amp) where the inputs can never rise above one transistor Vbe above 0V. With this, the feed-forward effect is not noticeable and the clamping resistors are not required. The LM3900 circuit which you will note, does not show an output integrator.
The fourth stage compares the rectified tacho generator voltage with the demand speed, integrates the difference, and gives an output to drive the PWM modulator.
The feedback system is critical in maintaining stable motor speed under varying load conditions. The loop gain must be carefully managed to avoid instability, which can result in oscillations or hunting behavior. The operational amplifier configuration allows for differentiation between the positive and negative voltage outputs from the tacho generator, enabling effective feedback control.
In practical applications, a potentiometer is often used to fine-tune the system, allowing for adjustments based on real-time operational conditions. The integration stage in the circuit serves to filter out any DC offset from the error signal, ensuring that the PWM modulator receives a clean control signal for precise motor speed regulation.
The overall design emphasizes simplicity and cost-effectiveness, utilizing readily available components while still achieving the desired closed-loop control performance. The use of the LM324 op-amp in this application highlights the adaptability of common ICs in creating robust motor control solutions.Most battery motor speed controllers are under manual control and the operator automatically adjusts speed to match demand. Under these conditions closed loop motor speed control is an unnecessary expense. However, when it is required, a tachogenerator can easily be added. True tachogenerators are usually expensive - which puts off most potential users. The expense is because they are very accurately manufactured and calibrated. They are also low volume items. However for most uses a small permanent magnet motor is perfectly adequate. It won't come with an accurate 'volts per rpm' calibration and it may (just possibly) drift over several years.
For most purposes this simply does not matter! With any tacho feedback system, the loop gain (controller, motor, tacho, tacho amplifier) must not be more than unity or instability results. To put that more simply: the feedback system must alter the output voltage to the motor so that the motor voltage is raised to exactly match the drop in the motor armature caused by the current flowing, so the mechanical speed remains constant.
If the loop over compensates, then the motor will go too fast if loaded and will 'hunt' - the speed will be unstable and will bounce about. If the compensation is too little - perfornance will be less than optimum. However - there are a lot of variables, including battery voltage and motor temperature. An ideal system would measure everything and compensate for it (and be very expensive!). In practise, adjustment is quite easy: you will simply include a pot in series with the motor used as the tacho generator and will adjust this until the motor starts to hunt (show speed variation), then back it of a bit until it is slightly below optimum.
The board is built in two versions (Pro-120 and VTX or NCC) but the only difference is the connector - 9 way for Pro (black numbers) and 6 way for VTX. The circuit uses a quad op-amp type LM324. The first two stages are are straight forward difference amplifiers that compare the two wires from the tacho generator.
One works for positive voltages and the other for negative. Now the circuit is used from a single supply. Therefore the op-amp outputs cannot swing negative. Therefore one amplifier gives a positive output for one tacho generator direction and the other for the reverse direction. The third section of the op-amp sums the outputs, the result is a rectified version of the input. There is a snag in using an op-amp thus. On the inputs which should swing the output negative, the op-amp is in fact cut-off and the output is not conducting.
The inputs are outside their working range, so they cannot clamp the control signal. There is then a straight feed-forward path via the 'feedback' resistor to the inoperative output. That mechanism explains the 10K load resistors from the outputs of the first two stages of the op-amp to earth. These, in conjunction with the 3 100K resistors in the feed-forward path, form an attenuator so that the error from feed-forward is reduced to around 3%.
It may interest browsers to know that the circuit was first used with an LM3900 (which is a Norton op-amp) where the inputs can never rise above one transistor Vbe above 0v. With this, the feed-forward effect is not noticeable and the clamping resistors are not required. The LM3900 circuit which you will note, does not show an output integrator. The fourth stage compares the rectified tacho generator voltage with the demand speed, integrates the difference and gives an output to drive the PWM modulator.
I don't intend to go into the mathematics but, if you don't get things correct a tacho feedback circuit can go dreadfully wrong. Motors are mechanical things and take time to react. If the control signal reacts faster than the motor then it will over-react and an oscillation loop will result.
As well as being our TFB, part of this (the 3 LH sections of the quad op-amp) is actually the circuit that we use in the 4QD series controllers to provide armature voltage feedback. It is a precision rectifier circuit with error amplifier and it can either detect the armature voltage or the voltage from a tacho generator to provide closed loop control.
The output stage is an integrator to remove the d.c. component of the error signal.
Phase tracking three-phase generator
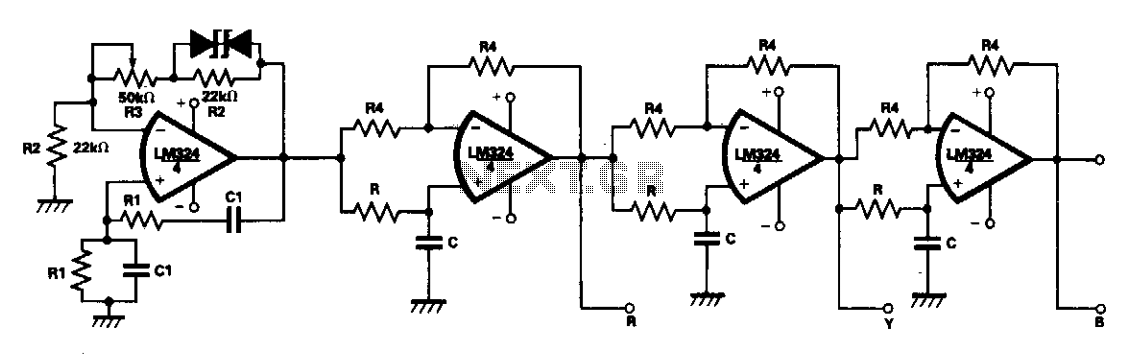
A single LM324 chip can effectively reduce the size of a 3-phase waveform generator through the use of active R-C networks, making it advantageous for compact and stable 3-phase inverters. One quarter of the LM324 functions as a Wien bridge...
LM324 Connection Diagram
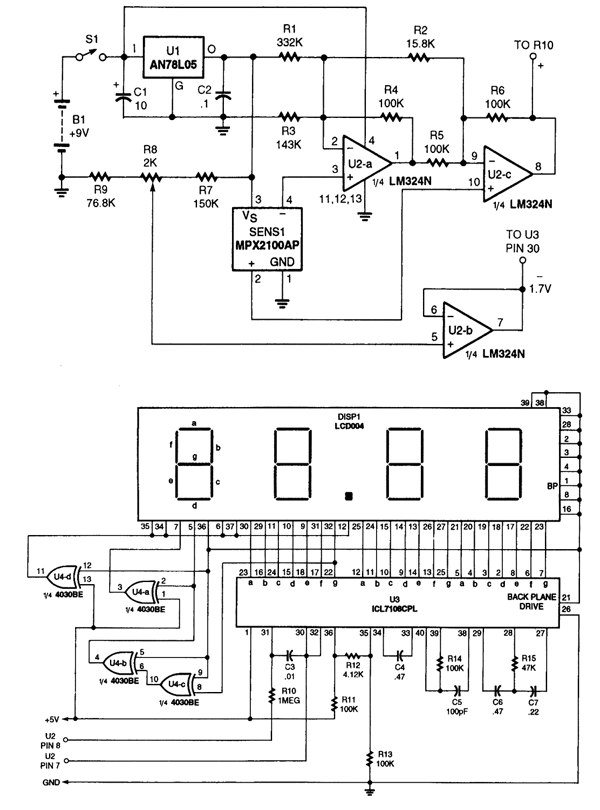
The LM324N is part of the LM324 family, which includes four independent, high-gain, internally frequency-compensated operational amplifiers. These amplifiers are designed to operate from a single power supply over a wide range of voltages. Operation from split power supplies is...
logic circuit diagram
The two drawings utilize the LM324 operational amplifier to create a low-voltage comparator. Resistor R1 is part of a voltage divider circuit, while operational amplifier A1 is configured to a reference voltage level U1. Resistor R2 forms another voltage divider...
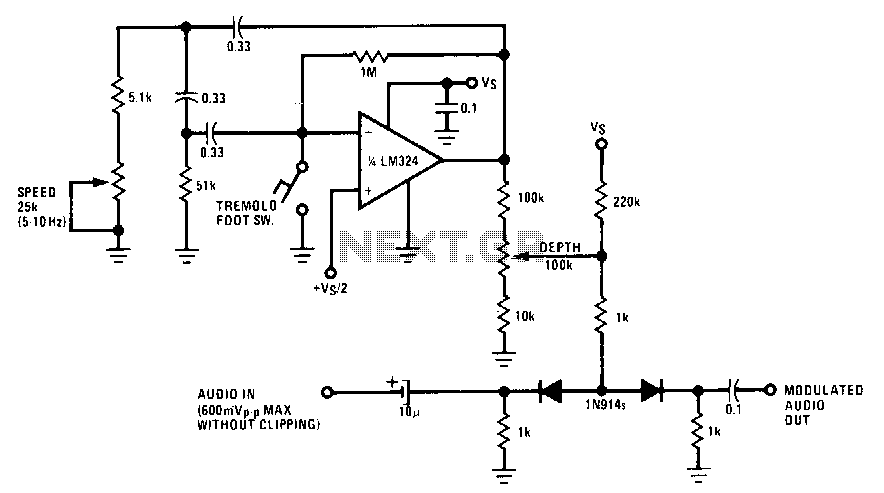
Tremolo
A phase shift oscillator utilizing the LM324 operates at an adjustable frequency range of 5-10 Hz, which is determined by a speed potentiometer. A segment of the oscillator output is extracted from the depth potentiometer and is employed to modulate...
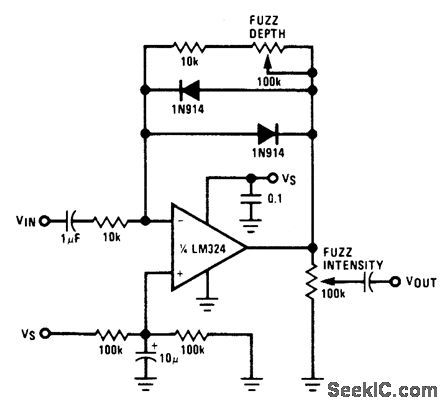
FUZZ_CIRCUIT
Two diodes in the feedback path of an LM324 operational amplifier create a musical instrument effect known as fuzz by limiting the output voltage swing to ±0.7 V. The resultant square wave primarily contains odd harmonics, resembling the sounds of...
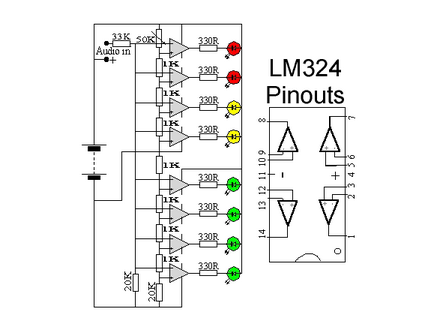
Audio VU Meter
This circuit utilizes two quad op-amps to create an eight LED audio level meter. The op-amp employed in this circuit is the LM324, which is a widely available integrated circuit. The 1K resistors in the circuit are crucial for activating...
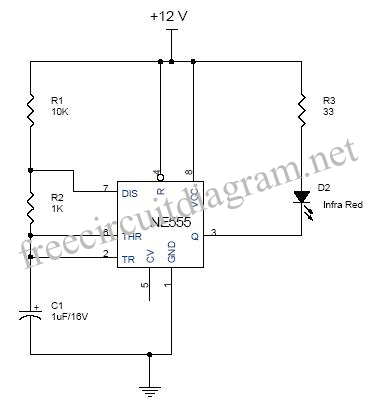
Simple Parking Sensor Using LM324
The circuit diagram represents a simple parking sensor system that measures the distance between the rear bumper of a vehicle and obstacles located behind it. The schematic consists of two main components: the transmitter and the receiver. The distance measurement...
Window Generator
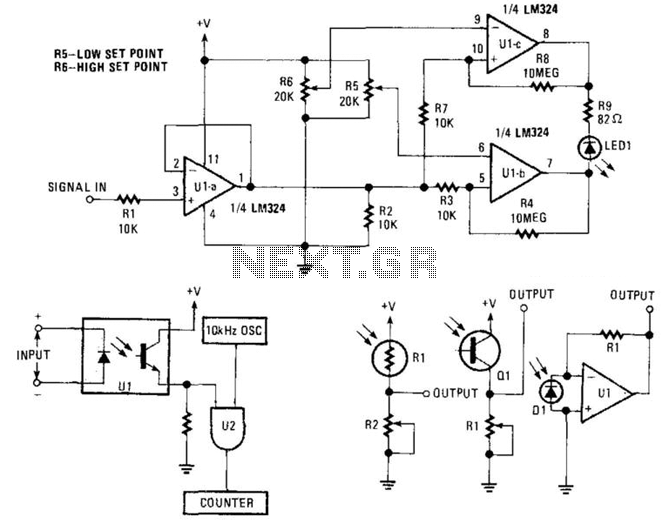
This window generator utilizes a single LM324 operational amplifier and includes two adjustable set points. When the two comparators formed by U1B go high, LED1 illuminates. When U1C goes high, the LED turns off. Hysteresis is implemented using 10 MΩ...
Permanent Magnet Motor Control with SCR
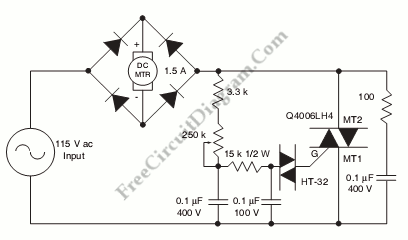
This is a schematic diagram of a Permanent Magnet Motor Control circuit. This circuit is used to control the operation of a permanent magnet motor.
The Permanent Magnet Motor Control circuit is designed to efficiently manage the performance of permanent magnet...