


dc servo motor controller
#servo motor
#A3952S
#motor driver
#Allegro MicroSystems
#DC motor
#controller
#bipolar
#stepper motor
#driver circuit
#integrated circuit
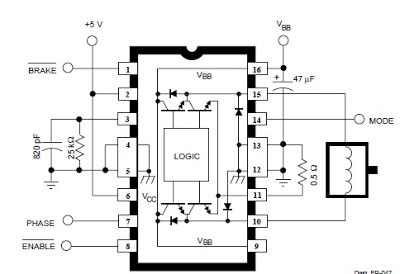
Description: The A3952S integrated circuit, designed by Allegro MicroSystems, can be utilized to create straightforward and effective motor driver circuits. A previous article discussed a basic bipolar stepper motor driver circuit that employs two A3952S circuits. The A3952S is capable of continuous output currents of up to 2 A and can operate at voltages ranging up to 50 V. This document presents a simple DC servo motor application suitable for various electronic projects. The DC servo motor driver schematic utilizes only one integrated circuit along with a few additional electronic components. For bidirectional DC servo motors, the PHASE terminal facilitates mechanical direction control. Similar to dynamic braking of the motor, abrupt changes in the direction of a rotating motor generate a current due to back EMF, with the magnitude of this current being dependent on the mode of operation.
The A3952S integrated circuit is a versatile solution for motor control applications, particularly in the context of DC servo motors. This IC integrates several functions that simplify the design of motor driver circuits. The primary features of the A3952S include its ability to handle continuous output currents up to 2 A and operate within a voltage range of 8 V to 50 V, making it suitable for a wide array of applications.
In the schematic for the DC servo motor driver, the A3952S is connected to the motor, power supply, and various passive components. The circuit typically includes resistors and capacitors for filtering and stability, ensuring that the motor operates smoothly without unwanted oscillations. The PHASE terminal is crucial for controlling the direction of the motor. By toggling this terminal, the user can reverse the motor's direction, which is essential for applications requiring bidirectional motion.
In addition to direction control, the A3952S provides features such as current sensing and thermal shutdown, which enhance the reliability of the motor driver circuit. The back EMF generated during abrupt direction changes necessitates careful consideration of the circuit design to prevent damage to the components. The design must accommodate the transient currents that occur, especially when switching directions, to ensure the longevity of the integrated circuit and the motor.
Overall, the A3952S offers a compact and efficient solution for controlling DC servo motors, making it an excellent choice for hobbyists and professionals alike in various electronic projects.As we presented in another article the A3952S integrated circuit ( designed by Allegro MicroSystems ) can be used to design very simple and useful motor driver circuits. In the precedent article was presented a simple bipolar stepper motor driver circuit that use two A3952S circuits.
As we presented in that article, the A3952S is capable of cont inuous output currents up to 2 A and operating voltages range up to 50 V. This circuit presents a simple DC servo motor application that can be used in various electronic projects. As you can see in the circuit schematic this Dc servo motor driver schematic circuit use just one integrated circuit and other few external electronic components.
With bidirectional dc servo motors, the PHASE terminal can be used for mechanical direction control. Similar to when braking the motor dynamically, abrupt changes in the direction of a rotating motor produce a current generated by the back EMF. The current generated will depend on the mode of operation.
The A3952S integrated circuit is a versatile solution for motor control applications, particularly in the context of DC servo motors. This IC integrates several functions that simplify the design of motor driver circuits. The primary features of the A3952S include its ability to handle continuous output currents up to 2 A and operate within a voltage range of 8 V to 50 V, making it suitable for a wide array of applications.
In the schematic for the DC servo motor driver, the A3952S is connected to the motor, power supply, and various passive components. The circuit typically includes resistors and capacitors for filtering and stability, ensuring that the motor operates smoothly without unwanted oscillations. The PHASE terminal is crucial for controlling the direction of the motor. By toggling this terminal, the user can reverse the motor's direction, which is essential for applications requiring bidirectional motion.
In addition to direction control, the A3952S provides features such as current sensing and thermal shutdown, which enhance the reliability of the motor driver circuit. The back EMF generated during abrupt direction changes necessitates careful consideration of the circuit design to prevent damage to the components. The design must accommodate the transient currents that occur, especially when switching directions, to ensure the longevity of the integrated circuit and the motor.
Overall, the A3952S offers a compact and efficient solution for controlling DC servo motors, making it an excellent choice for hobbyists and professionals alike in various electronic projects.As we presented in another article the A3952S integrated circuit ( designed by Allegro MicroSystems ) can be used to design very simple and useful motor driver circuits. In the precedent article was presented a simple bipolar stepper motor driver circuit that use two A3952S circuits.
As we presented in that article, the A3952S is capable of cont inuous output currents up to 2 A and operating voltages range up to 50 V. This circuit presents a simple DC servo motor application that can be used in various electronic projects. As you can see in the circuit schematic this Dc servo motor driver schematic circuit use just one integrated circuit and other few external electronic components.
With bidirectional dc servo motors, the PHASE terminal can be used for mechanical direction control. Similar to when braking the motor dynamically, abrupt changes in the direction of a rotating motor produce a current generated by the back EMF. The current generated will depend on the mode of operation.
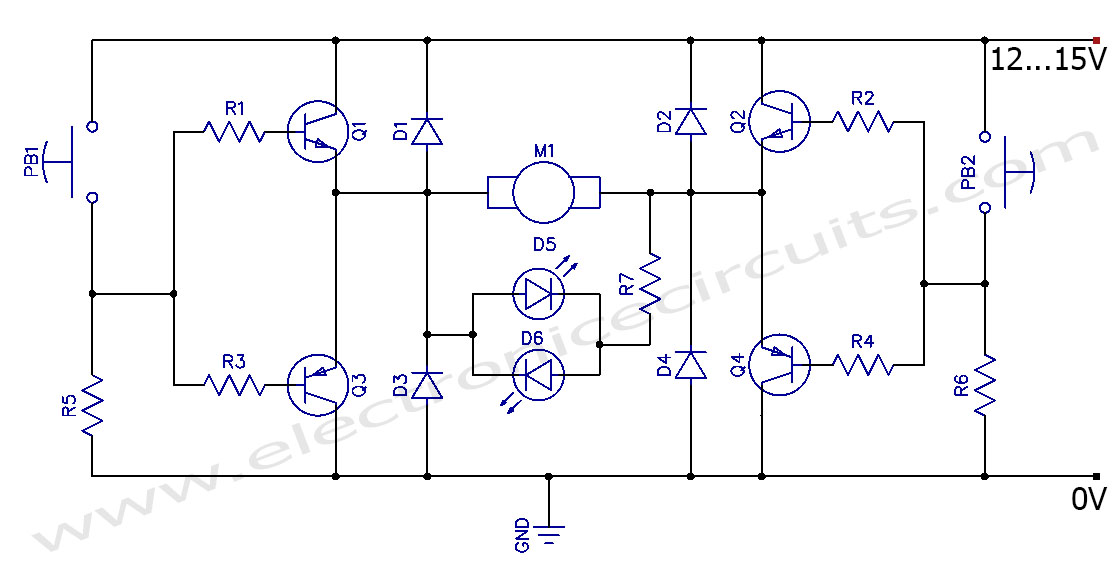
DC Motor Clockwise Anticlockwise Control H-bridge Circuit
This circuit can control the direction of a DC motor, allowing it to operate in both clockwise and counterclockwise directions (forward and backward).
The described circuit employs an H-bridge configuration, which is essential for reversing the polarity of the voltage applied...
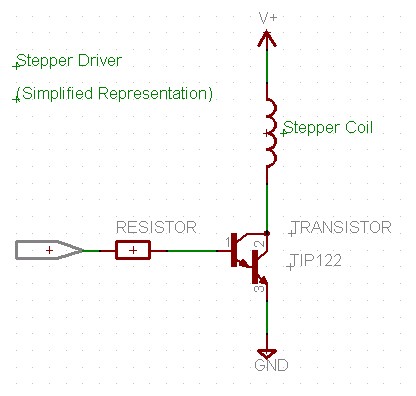
Stepper Motor Control
This program initializes all sixteen I/O lines of the U4x1 to function as outputs. The lower four port pins of port A (A0 - A3) correspond to "channel 1" for stepper motor activity, while the upper four port pins of...
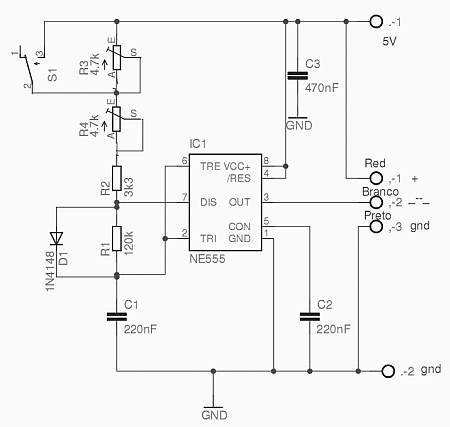
circuit to test servo motor (pole rotor) of parabolic antenna
This circuit is designed to test the servo motor of a parabolic antenna. It functions effectively, although a system with a low-noise block feed (LNBF) is generally more suitable. Many users continue to utilize systems that employ an LNB and...
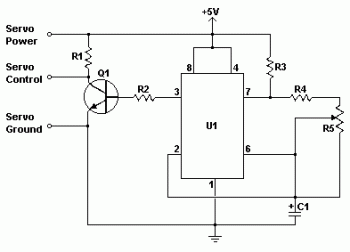
simple servo motor controller circuit
The servo motor has numerous applications in various fields, including robotics, puppetry, photography, and more. These compact motors can accurately position their output shaft to any specified angle and maintain that position. Most servos have a motion range of approximately...
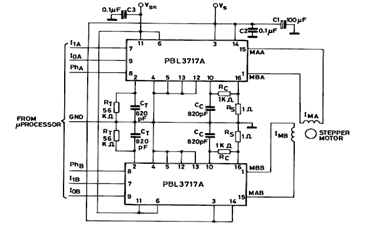
Two Phase Bipolar Stepper Motor Driver Circuit using PBL3717A
The diagram below illustrates a Two Phase Bipolar Stepper Motor Driver utilizing the PBL3717A. It depicts two PBL3717A integrated circuits (ICs) that control and drive two bipolar stepper motors.
The Two Phase Bipolar Stepper Motor Driver circuit is designed to efficiently...
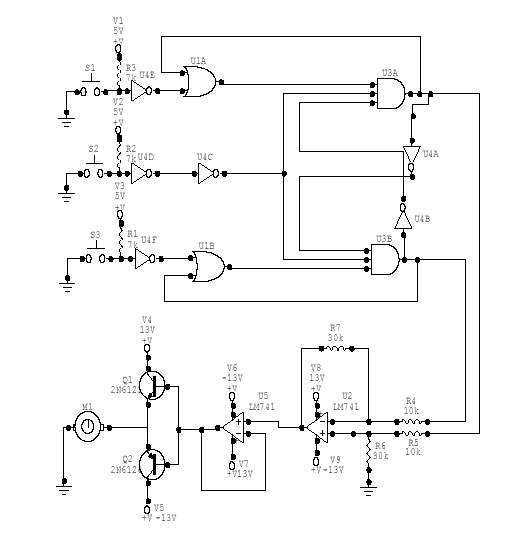
DC Motor Controller
This DC Motor Controller circuit will control a 12V dc motor. The system will have three pushbuttons: a START button, a REVERSE button and a STOP button. Initially, the motor must not be running. When the START button is pressed,...
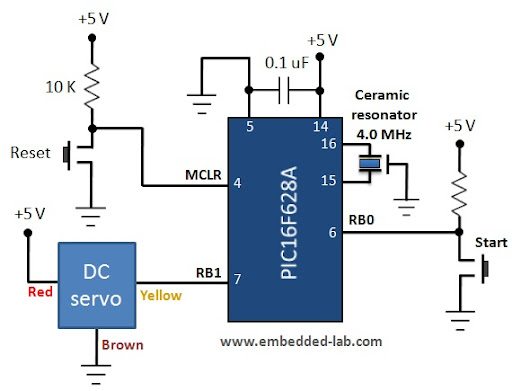
Servo motor control
A servo motor is a specialized geared DC motor that includes an electronic circuit for controlling the direction and position of the motor shaft. Due to its capability for precise angular positioning, servo motors are widely utilized in robotics, as...
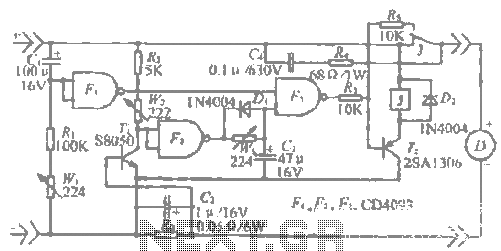
A high-power DC motor overcurrent protection circuit
The "R-h sampling circuit limit order" aims to reduce the sampling resistor. A DC voltage level can be positioned between the components. The circuit includes a line amplifier that allows for magnification adjustments and is designed to protect against current...
Stepper Motor Control Circuit
This circuit is not visually appealing nor easy to implement, requiring considerable effort. The stepper motor consists of two coils, necessitating the use of two LMD18245 chips to manage the current flow through these coils. It is noteworthy that motor...