


Constant current motor drive circuit
#constant current
#DC motor
#motor drive
#stall protection
#lock-up prevention
#current regulation
#driver circuit
#motor control
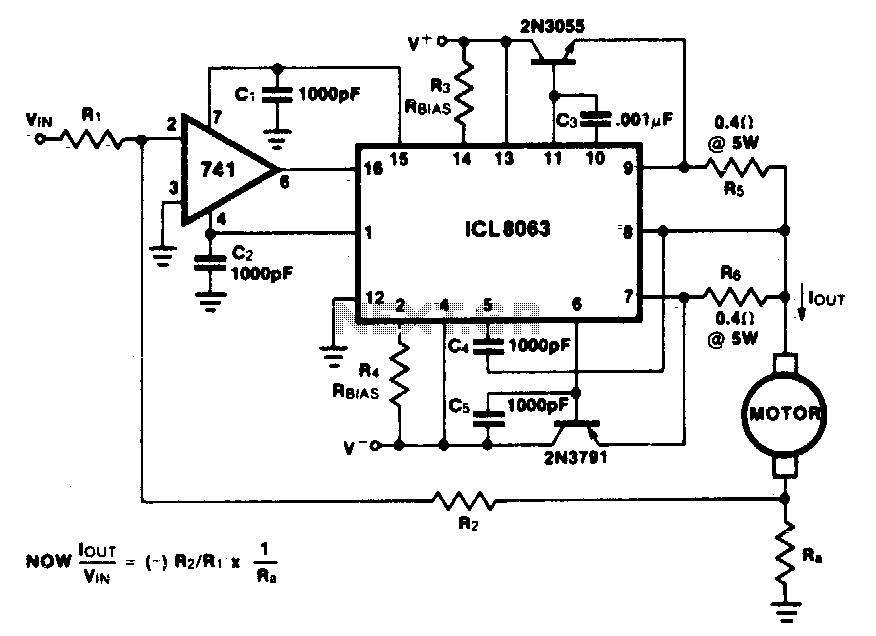
Description: This minimum device circuit can be used to drive DC motors where there is some likelihood of stalling or lock-up. If the motor locks, the current drive remains constant, and the system does not destroy itself.
This circuit is designed to provide a reliable method for driving DC motors while minimizing the risk of damage due to stalling or lock-up conditions. The core functionality relies on a feedback mechanism that monitors the motor's current draw. When the motor stalls, the circuit automatically adjusts the current to a predetermined safe level, preventing overheating and potential damage to the motor and associated components.
The essential components of this circuit typically include a DC motor, a current sensing resistor, an operational amplifier (op-amp) configured as a comparator, and a power transistor or MOSFET for driving the motor. The current sensing resistor is placed in series with the motor to measure the current flowing through it. The voltage across this resistor is fed into the op-amp, which compares it against a reference voltage that corresponds to the maximum allowable current.
In normal operation, when the motor runs without stalling, the current remains below the threshold set by the reference voltage. However, if the motor begins to stall, the current will increase, causing the voltage across the sensing resistor to exceed the reference level. The op-amp will then output a signal that turns off or reduces the drive to the power transistor, effectively limiting the current supplied to the motor.
This approach ensures that the motor can be operated safely under various load conditions without the risk of thermal damage. Additionally, the circuit can be designed to include features such as hysteresis to prevent rapid cycling of the motor drive during minor fluctuations in load, further enhancing reliability.
Overall, this minimum device circuit provides a robust solution for driving DC motors in applications where stalling is a concern, ensuring longevity and operational safety.This minimum de vice circuit can be used to drive dc motors where there is some likelihood of stalling or lock up if the motor locks, the current drive remains constant and the system does not destroy itself.
This circuit is designed to provide a reliable method for driving DC motors while minimizing the risk of damage due to stalling or lock-up conditions. The core functionality relies on a feedback mechanism that monitors the motor's current draw. When the motor stalls, the circuit automatically adjusts the current to a predetermined safe level, preventing overheating and potential damage to the motor and associated components.
The essential components of this circuit typically include a DC motor, a current sensing resistor, an operational amplifier (op-amp) configured as a comparator, and a power transistor or MOSFET for driving the motor. The current sensing resistor is placed in series with the motor to measure the current flowing through it. The voltage across this resistor is fed into the op-amp, which compares it against a reference voltage that corresponds to the maximum allowable current.
In normal operation, when the motor runs without stalling, the current remains below the threshold set by the reference voltage. However, if the motor begins to stall, the current will increase, causing the voltage across the sensing resistor to exceed the reference level. The op-amp will then output a signal that turns off or reduces the drive to the power transistor, effectively limiting the current supplied to the motor.
This approach ensures that the motor can be operated safely under various load conditions without the risk of thermal damage. Additionally, the circuit can be designed to include features such as hysteresis to prevent rapid cycling of the motor drive during minor fluctuations in load, further enhancing reliability.
Overall, this minimum device circuit provides a robust solution for driving DC motors in applications where stalling is a concern, ensuring longevity and operational safety.This minimum de vice circuit can be used to drive dc motors where there is some likelihood of stalling or lock up if the motor locks, the current drive remains constant and the system does not destroy itself.
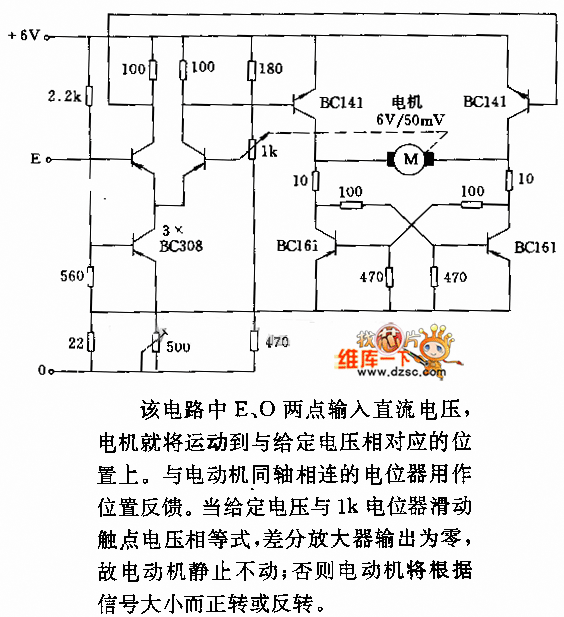
DC motor servo control circuit diagram
In the circuit, when E and O are input DC voltages, the motor moves to a position corresponding to the voltage. A potentiometer, coaxially connected to the motor, is used for position feedback. When the given voltage equals the wiper...
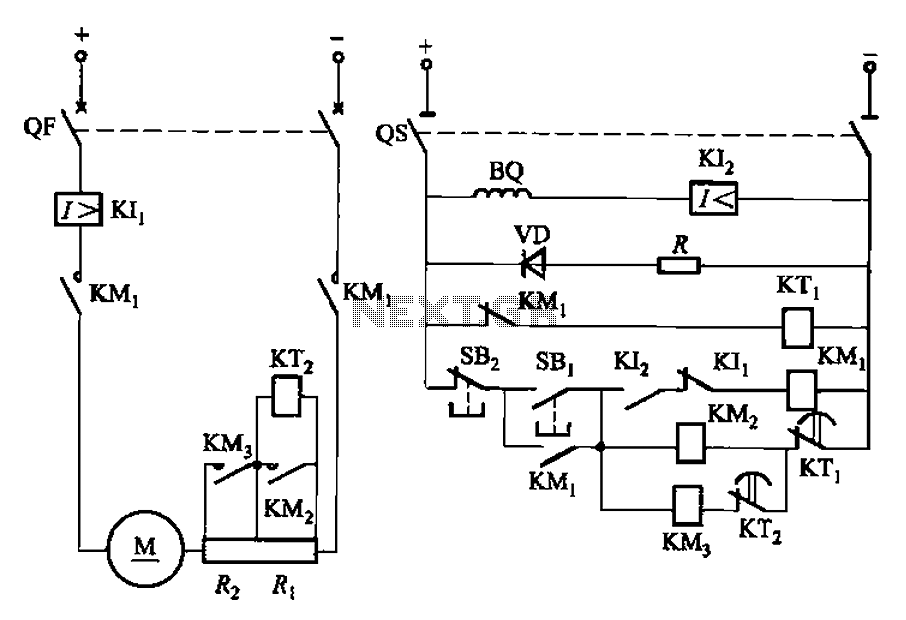
DC motor armature resistance in series to start debugging circuit 2
The circuit illustrated in Figure 3-191 features a DC motor armature circuit that includes two series startup resistors, Ri and Rz. The operation of the motor is controlled using buttons for starting and stopping. During the startup phase, two relays,...
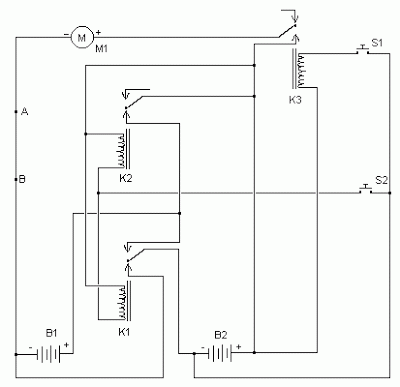
two speed contactor dc motor controller
The simplest form of motor controllers, apart from a basic on/off switch, is the contactor controller. This contactor controller is recommended for use in electric scooter projects. It is based on three 12V relays, two 12V batteries, two switches, and...

One of reversing circuit reverse braking resistor in series with a DC motor armature start
The circuit depicted in Figure 3-201 includes two starting resistors, with one controlled by a time relay. A master switch (SA) is utilized to manage the motor's reversing operation. The circuit incorporates a reverse braking mechanism, which is automatically controlled...
DC motor servo control circuit diagram
In the circuit, when E and O are input DC voltages, the motor moves to a position corresponding to the voltage. A potentiometer, coaxially connected to the motor, is used for position feedback. When the given voltage equals the wiper...
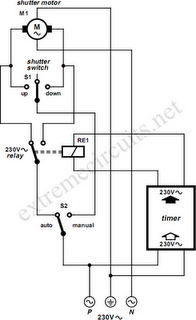
To Automate Rolling Shutter Motor
To automate the opening and closing of a rolling shutter using a time-controlled switch, additional wiring will be necessary.
To implement an automated system for a rolling shutter, a time-controlled switch can be utilized to manage the operation of the shutter....
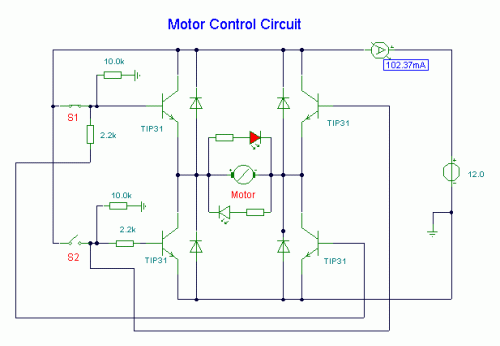
DC Motor Control Circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes, which can be either red or green, serve solely to indicate the direction of operation. The TIP31 transistors may need to be adjusted based on the specifications of the...
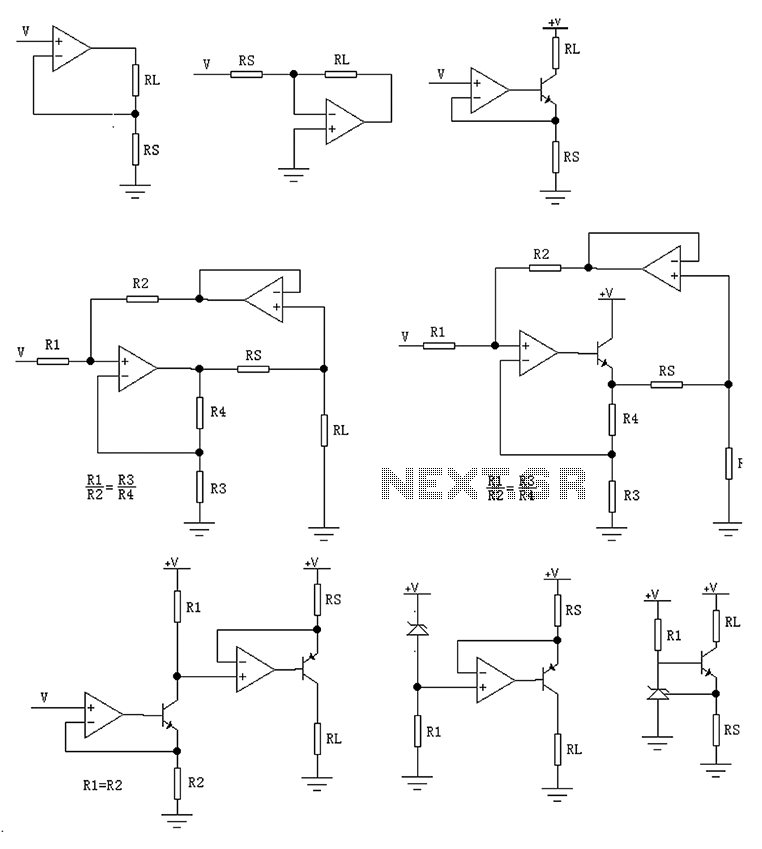
Comparison of various circuit diagram VI conversion and a constant current source
The circuit is designed to provide several constant current outputs to the load resistor RL. The first RL is floating and is rarely utilized. The second RL serves as a virtual ground and is not commonly used either. The third...
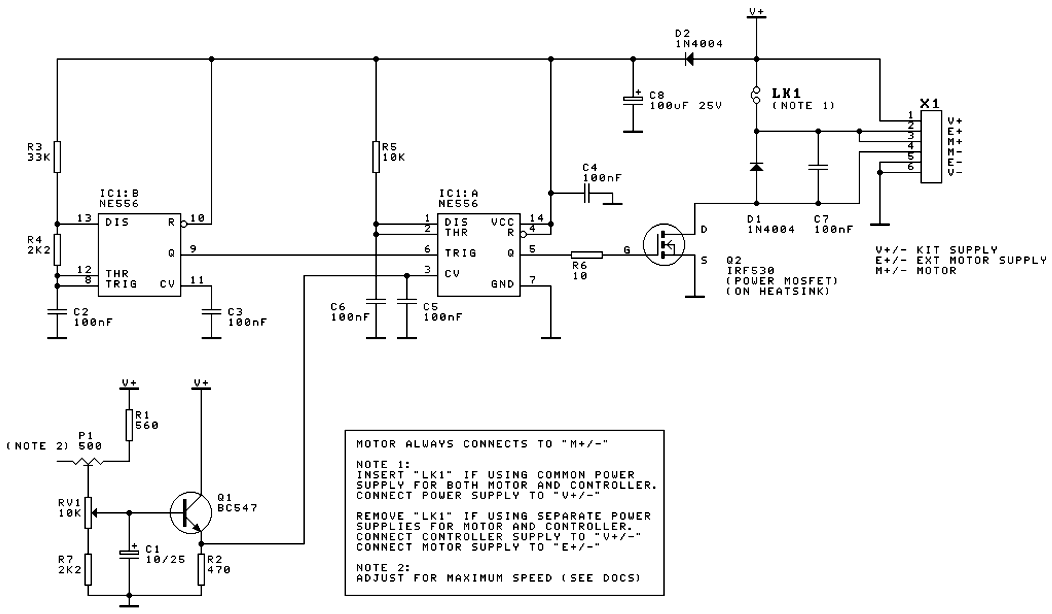
DC Motor Speed Controller
A DC motor speed controller circuit utilizes two timers configured as a Pulse Width Modulator (PWM). The integrated circuit employed for this purpose is the NE556, which is a dual timer/oscillator using NMOS technology.
The DC motor speed controller circuit operates...